
In the field of mechanical engineering, the study of gear dynamics has garnered significant attention due to its critical role in ensuring the efficiency, reliability, and longevity of transmission systems. Among various gear types, the helical gear stands out for its smooth operation, high load capacity, and reduced noise compared to spur gears. The integration of composite materials into helical gear design has opened new avenues for lightweight, high-performance applications, particularly in aerospace, automotive, and marine industries. While extensive research has been conducted on the dynamic characteristics of composite spur gears, the investigation into composite helical gears remains relatively scarce, especially concerning the influence of parameters such as pressure angle. This paper aims to address this gap by developing a comprehensive dynamic model for orthotropic composite helical gears based on the First-Order Shear Deformation Theory (FSDT) and the Rayleigh-Ritz method. I will validate the model against existing literature data and explore the effects of material properties and pressure angle on the natural frequencies and dynamic behavior of helical gears. The findings are expected to provide a foundational understanding for the practical application of composite helical gears in advanced engineering systems.
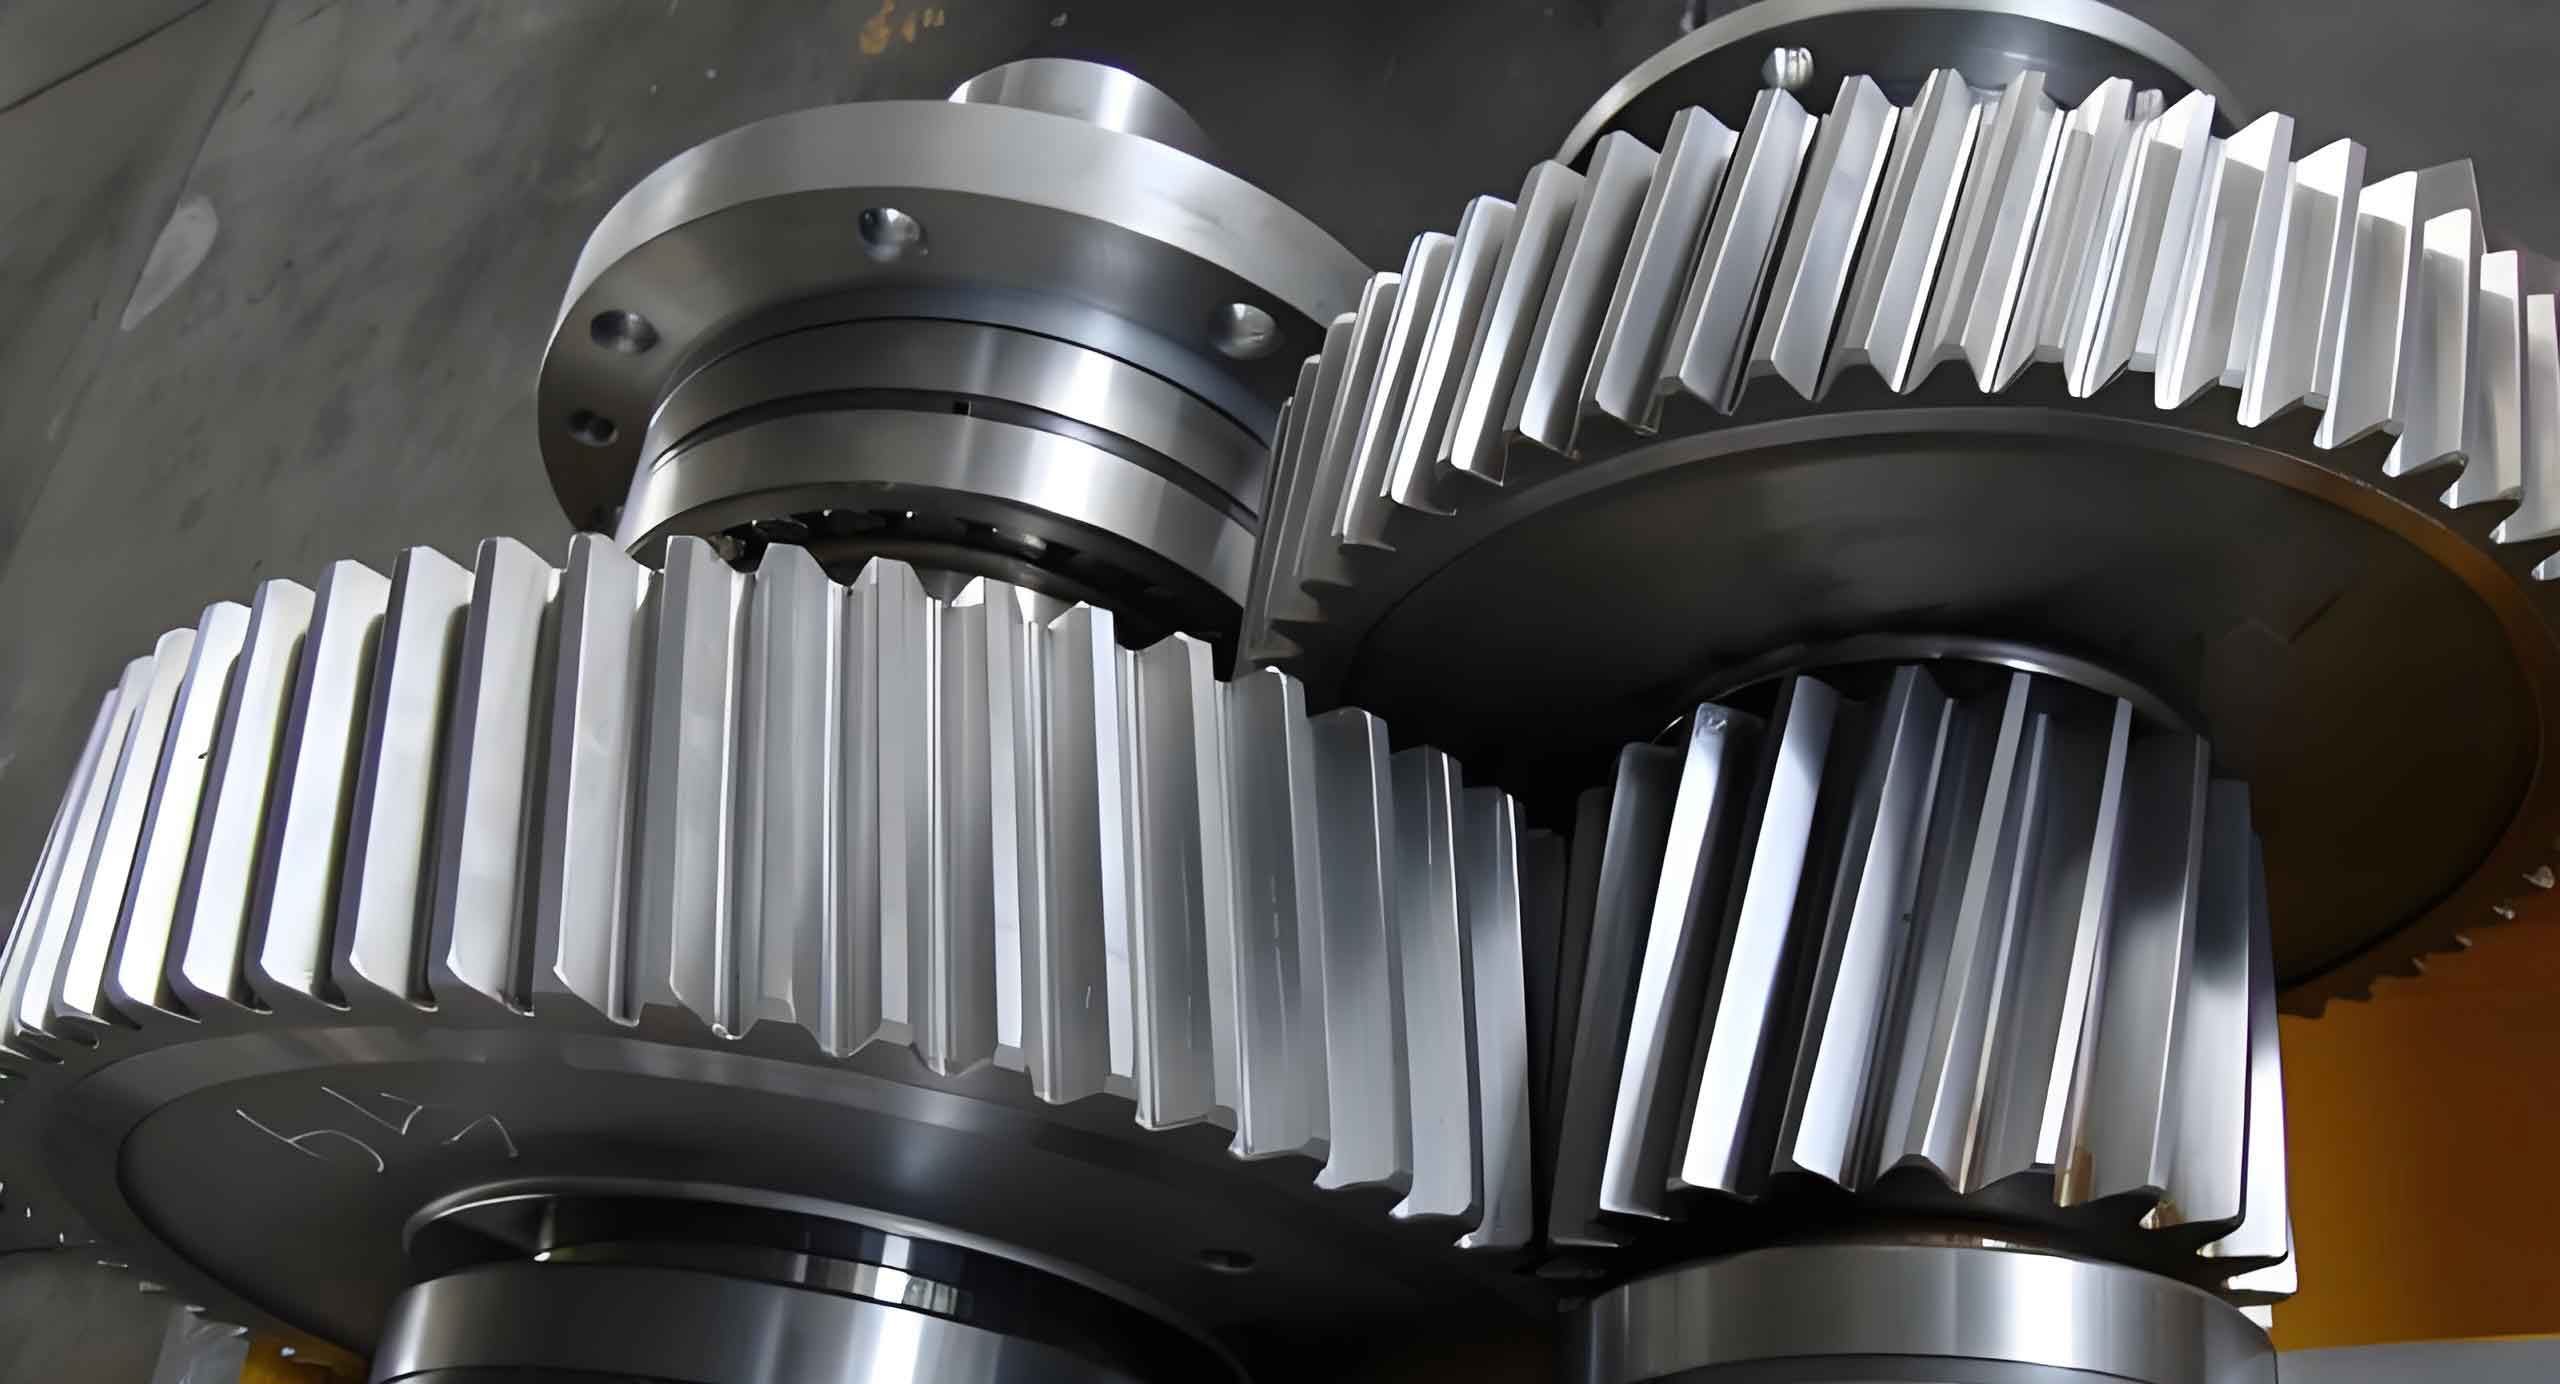
The theoretical model for the composite helical gear is constructed as a multi-layered structure composed of carbon fiber reinforced polymer (CFRP) laminates. The helical gear is idealized as a plate-like structure to simplify the analysis while capturing essential dynamic features. A coordinate system o-xyz is established at the mid-plane of the helical gear, with dimensions defined as length \(l\), width \(d\), and thickness \(h\). Each carbon fiber layer is assigned a local material coordinate system denoted by directions “1”, “2”, and “3”, where direction “1” aligns with the fiber orientation, and direction “3” is normal to the layer plane. The angle \(\theta\) represents the orientation of the fibers relative to the x-axis. The total number of fiber layers is \(n_f\), with the subscript “f” indicating carbon fiber properties, including density \(\rho_f\). Prior to modeling, it is assumed that the layers are perfectly bonded, with no slip or relative deformation between them, ensuring a continuous displacement field.
Based on the First-Order Shear Deformation Theory, the displacement field for the composite helical gear structure can be expressed as:
$$
\begin{align*}
u(x, y, z, t) &= u_0(x, y, t) + z \phi_x(x, y, t) = u_0(x, y, t) – z \frac{\partial \theta}{\partial x}, \\
v(x, y, z, t) &= v_0(x, y, t) + z \phi_y(x, y, t) = v_0(x, y, t) – z \frac{\partial \theta}{\partial y}, \\
w(x, y, z, t) &= w_0(x, y, t),
\end{align*}
$$
where \(u_0\), \(v_0\), and \(w_0\) are the mid-plane displacements, \(\phi_x\) and \(\phi_y\) are the rotations of the transverse normals in the xoz and yoz planes, respectively, and \(t\) is time. The mid-plane displacement vector \(\delta_f\) is defined as:
$$
\delta_f = \left[ u_0(t), v_0(t), w_0(t), \phi_x(t), \phi_y(t) \right]^T.
$$
The stiffness matrix \(K_f\) for the carbon fiber layers is derived from the constitutive relations and strain-displacement equations. For a helical gear made of orthotropic materials, the stiffness matrix elements involve integrated terms over the thickness. The expression for \(K_f\) is:
$$
K_f = \iiint_{-\frac{h_f}{2}}^{\frac{h_f}{2}} \mathbf{B}_{\tau f}^T
\begin{bmatrix}
\bar{Q}_{f11} & \bar{Q}_{f12} & 0 \\
\bar{Q}_{f21} & \bar{Q}_{f22} & 0 \\
0 & 0 & \bar{Q}_{f66}
\end{bmatrix}
\mathbf{B}_{\gamma f} \, dz \, dx \, dy,
$$
where \(\mathbf{B}_{\tau f}\) and \(\mathbf{B}_{\gamma f}\) are displacement matrices related to in-plane and shear deformations, respectively. The reduced stiffness coefficients \(\bar{Q}_{fmn}\) (with \(m, n = 1, 2, 4, 5, 6\)) for the carbon fiber layer are given by:
$$
\begin{align*}
\bar{Q}_{f11} &= \frac{E_{f1}}{1 – \nu_{f12} \nu_{f21}}, \\
\bar{Q}_{f12} &= \bar{Q}_{f21} = \frac{\nu_{f12} E_{f2}}{1 – \nu_{f12} \nu_{f21}}, \\
\bar{Q}_{f22} &= \frac{E_{f2}}{1 – \nu_{f12} \nu_{f21}}, \\
\bar{Q}_{f66} &= G_{f12}.
\end{align*}
$$
Here, \(E_{f1}\) and \(E_{f2}\) are the Young’s moduli in the fiber and transverse directions, \(G_{f12}\) is the shear modulus, and \(\nu_{f12}\) and \(\nu_{f21}\) are Poisson’s ratios. The total kinetic energy \(T^*\) and total strain energy \(U^*\) of the composite helical gear structure are formulated as:
$$
T^* = \dot{\delta}_f^T M_f \dot{\delta}_f, \quad U^* = \delta_f^T K_f \delta_f,
$$
where \(\dot{\delta}_f\) is the time derivative of the displacement vector, and \(M_f\) is the mass matrix derived from the density and geometry of the helical gear.
To solve for the dynamic characteristics, particularly the natural frequencies and mode shapes, the Rayleigh-Ritz method is employed. The transverse displacement \(w(x, y, t)\) is approximated by a series expansion:
$$
w(x, y, t) = \sum_{m=1}^{M} \sum_{n=1}^{N} A_{mn} P_m(\alpha) P_n(\beta) \sin(\omega t),
$$
where \(m\) and \(n\) are the half-wave numbers in the x and y directions, \(M\) and \(N\) are truncation coefficients, \(A_{mn}\) are the mode shape coefficients, and \(P_m(\alpha)\) and \(P_n(\beta)\) are the admissible functions that satisfy the geometric boundary conditions. These functions are defined recursively as:
$$
\begin{align*}
P_1(\alpha) &= \phi(\alpha), \quad P_1(\beta) = \varphi(\beta), \\
P_2(\zeta) &= (\zeta – B_2) P_1(\zeta), \\
P_n(\zeta) &= (\zeta – B_n) P_{n-1}(\zeta) – C_n P_{n-2}(\zeta), \\
B_n &= \frac{\int_0^1 [P_{n-1}(\zeta)]^2 \zeta \, d\zeta}{\int_0^1 [P_{n-1}(\zeta)]^2 \, d\zeta}, \\
C_n &= \frac{\int_0^1 P_{n-1}(\zeta) P_{n-2}(\zeta) \zeta \, d\zeta}{\int_0^1 [P_{n-2}(\zeta)]^2 \, d\zeta}, \\
\phi(\alpha) &= \alpha^p (1 – \alpha)^q, \quad \varphi(\beta) = \beta^r (1 – \beta)^s,
\end{align*}
$$
with \(\zeta = \alpha, \beta\); \(\alpha = x/l\), \(\beta = y/d\); and \(p, q, r, s\) being boundary parameters set to 0, 1, or 2 for free, simply supported, and clamped edges, respectively. By setting \(\sin(\omega t) = 1\) for free vibration analysis, the Lagrangian \(L\) is constructed as:
$$
L = T^* – U^*.
$$
Minimizing \(L\) with respect to \(A_{mn}\) yields the eigenvalue problem:
$$
\left( K – \omega_i^2 M \right) \mathbf{q} = 0,
$$
where \(K\) and \(M\) are the global stiffness and mass matrices, \(\omega_i\) is the \(i\)-th natural frequency, and \(\mathbf{q}\) is the eigenvector representing the mode shape. Solving this equation provides the natural frequencies and corresponding mode shapes for the composite helical gear.
To validate the proposed model, I compare the natural frequencies computed for spur gears made of structural steel and aluminum alloy with results from published literature. The geometric parameters for the spur gears are: number of teeth = 18, module = 10 mm, pressure angle = 20°, and face width = 54 mm. The material properties are as follows:
| Material | Density (kg/m³) | Young’s Modulus (GPa) | Poisson’s Ratio |
|---|---|---|---|
| Structural Steel | 7850 | 200 | 0.3 |
| Aluminum Alloy | 2770 | 71 | 0.33 |
Using truncation coefficients \(M = N = 8\), the first three natural frequencies are calculated and compared with literature values, as summarized in the table below:
| Mode | Material | Model Frequency (Hz) | Literature Frequency (Hz) | Error (%) |
|---|---|---|---|---|
| 1 | Structural Steel | 2043.6 | 2019.4 | 1.2 |
| 2 | Structural Steel | 3273.1 | 3219.1 | 1.7 |
| 3 | Structural Steel | 3602.5 | 3566.6 | 1.0 |
| 1 | Aluminum Alloy | 2049.9 | 2003.8 | 2.3 |
| 2 | Aluminum Alloy | 3315.1 | 3217.1 | 3.0 |
| 3 | Aluminum Alloy | 3672.4 | 3573.8 | 2.8 |
The close agreement, with maximum errors below 3.0%, confirms the accuracy and reliability of the present model for dynamic analysis of gears. This validation supports the extension of the model to composite helical gears, which are the primary focus of this study.
For the parametric study, I analyze a composite helical gear with the following specifications: number of teeth = 23, module = 7 mm, pressure angle = 20°, helix angle = 11°, face width = 100 mm. The carbon fiber composite material has properties: density \(\rho_f = 1370 \, \text{kg/m}^3\), Young’s moduli \(E_{f1} = 115 \, \text{GPa}\) and \(E_{f2} = 9.5 \, \text{GPa}\), shear modulus \(G_{f12} = 7.1 \, \text{GPa}\), and Poisson’s ratio \(\nu_f = 0.32\). The first four natural frequencies are computed and normalized for comparison across different materials: structural steel, aluminum alloy, and carbon fiber composite. The normalization is done with respect to the fundamental frequency of the structural steel helical gear. The results are presented in the table below:
| Material | Normalized Frequency (Mode 1) | Normalized Frequency (Mode 2) | Normalized Frequency (Mode 3) | Normalized Frequency (Mode 4) |
|---|---|---|---|---|
| Structural Steel | 1.000 | 1.602 | 1.763 | 2.145 |
| Aluminum Alloy | 0.998 | 1.615 | 1.788 | 2.178 |
| Carbon Fiber Composite | 0.720 | 1.153 | 1.269 | 1.544 |
The data clearly shows that the carbon fiber composite helical gear exhibits significantly lower natural frequencies compared to metallic gears, with a maximum reduction of approximately 28% for the first mode. This reduction indicates enhanced vibration resistance, making composite helical gears advantageous in applications where damping and lightweight are critical. The inherent anisotropy of composites, combined with the helical geometry, contributes to this dynamic behavior by altering stiffness and mass distribution.
Next, I investigate the influence of pressure angle on the dynamic characteristics of the composite helical gear. Pressure angles of 16°, 18°, and 20° are considered, while keeping other parameters constant. The first four natural frequencies are normalized relative to the values at 20° pressure angle. The results are summarized in the following table:
| Pressure Angle | Normalized Frequency (Mode 1) | Normalized Frequency (Mode 2) | Normalized Frequency (Mode 3) | Normalized Frequency (Mode 4) |
|---|---|---|---|---|
| 16° | 0.963 | 0.958 | 0.952 | 0.945 |
| 18° | 0.982 | 0.979 | 0.976 | 0.972 |
| 20° | 1.000 | 1.000 | 1.000 | 1.000 |
As the pressure angle increases from 16° to 20°, the natural frequencies show a slight increase, with a maximum rise of about 5% for the fourth mode. This trend suggests that higher pressure angles marginally improve the stiffness of the helical gear, thereby raising its natural frequencies. However, the effect is relatively small, indicating that pressure angle variations within this range do not drastically alter the dynamic response. In practical design, a trade-off exists: a lower pressure angle may enhance vibration resistance (due to lower frequencies) but at the cost of reduced load-carrying capacity and increased bending stresses. Conversely, a higher pressure angle improves meshing stiffness and power transmission efficiency but may lead to slightly higher vibration levels. Therefore, selecting an optimal pressure angle for a composite helical gear requires balancing dynamic performance with structural integrity.
To further elucidate the dynamic behavior, I explore the mode shapes associated with the composite helical gear. The first four mode shapes typically involve bending, torsion, and combined deformations. For instance, Mode 1 often corresponds to the first bending mode in the transverse direction, Mode 2 to the first torsional mode, and Modes 3 and 4 to higher-order bending and coupled modes. The helical geometry introduces coupling between axial and torsional vibrations, which is more pronounced in composite materials due to their directional properties. This coupling can be analyzed through the off-diagonal terms in the stiffness matrix, which are influenced by fiber orientation and layup sequence. For a helical gear with fibers aligned along the tooth direction, the coupling effects may be minimized, leading to more predictable dynamic responses. However, if the fibers are oriented at an angle, the gear may exhibit complex mode shapes that affect noise and vibration characteristics.
The dynamic model also allows for the analysis of damping in composite helical gears. While this study focuses on undamped free vibration, composite materials inherently possess higher damping ratios compared to metals due to viscoelastic effects at the fiber-matrix interface. Incorporating damping into the model would involve adding a damping matrix \(C\) to the equation of motion:
$$
M \ddot{\delta}_f + C \dot{\delta}_f + K \delta_f = 0.
$$
This extension could provide insights into the transient response and resonance avoidance in operational conditions. For example, the damping properties of carbon fiber composites can help suppress vibrations near critical speeds, enhancing the stability of helical gear systems in high-speed applications.
In addition to material and pressure angle, other parameters such as helix angle, face width, and number of teeth significantly impact the dynamics of helical gears. A sensitivity analysis can be performed by varying these parameters within typical ranges. For instance, increasing the helix angle generally improves smoothness and load distribution but may reduce axial stiffness, affecting natural frequencies. The face width influences the mass and stiffness distributions; a wider face increases inertia and may lower frequencies, while also altering mode shapes. The number of teeth affects the gear’s geometry and meshing stiffness, with more teeth leading to finer contact and potentially higher natural frequencies due to increased stiffness. These interactions highlight the complexity of designing composite helical gears for optimal dynamic performance.
From a practical perspective, the application of composite helical gears in industries like wind turbines, robotics, and precision machinery demands careful consideration of environmental factors. Temperature variations, moisture absorption, and fatigue can alter material properties over time, affecting the dynamic characteristics. For example, the Young’s modulus of carbon fiber composites may decrease at elevated temperatures, leading to lower natural frequencies. Similarly, moisture ingress can plasticize the matrix, reducing stiffness and increasing damping. Long-term dynamic analysis should account for these factors to ensure reliability throughout the gear’s service life.
To summarize, the dynamic analysis of composite helical gears reveals several key insights. First, the developed model based on FSDT and Rayleigh-Ritz method accurately predicts natural frequencies, as validated against literature data. Second, carbon fiber composite helical gears exhibit lower natural frequencies compared to metallic gears, indicating superior vibration resistance—a critical advantage for noise-sensitive applications. Third, pressure angle variations have a modest effect on dynamics, with higher angles slightly increasing stiffness and frequencies. These findings underscore the importance of material selection and geometric design in optimizing the performance of helical gears.
Future work could extend this research by incorporating nonlinear effects, such as large deformations, contact dynamics between meshing teeth, and time-varying meshing stiffness. Additionally, experimental validation using prototype composite helical gears would strengthen the model’s credibility. The integration of smart materials, like piezoelectric fibers, could enable active vibration control, opening new frontiers in adaptive gear systems. As industries continue to seek lightweight and efficient solutions, the role of composite helical gears is poised to expand, driven by advanced dynamic modeling and material innovations.
In conclusion, this study provides a comprehensive framework for analyzing the dynamic behavior of orthotropic composite helical gears. The model captures essential features through a combination of shear deformation theory and energy methods, offering a tool for designers to evaluate and enhance gear performance. By understanding the influences of material properties and pressure angle, engineers can tailor composite helical gears for specific applications, balancing dynamic response with structural requirements. The ongoing evolution of composite technology promises further advancements, making helical gears even more integral to modern mechanical systems.