
In modern mechanical transmission systems, helical gearboxes play a critical role due to their ability to provide smooth and efficient power transfer with high load capacity and reduced noise compared to spur gears. However, the dynamic performance of helical gearboxes is influenced by a complex interplay of factors such as manufacturing tolerances, assembly errors, varying operational conditions like speed and load, and inherent nonlinearities. These factors lead to dynamic responses that can affect the gearbox’s reliability, efficiency, and noise-vibration-harshness (NVH) characteristics. Therefore, comprehensive testing and analysis of multiple physical parameters are essential for state evaluation, structural optimization, and fault diagnosis. This work presents a detailed investigation into the dynamic behavior of helical gearboxes through a multi-parameter testing approach, focusing on parameters like rotational speed, transmission error, axis orbit, vibration acceleration, sound pressure, and load torque. By developing a custom test platform and employing advanced data analysis techniques, we aim to uncover the correlations between these parameters and assess the assembly accuracy and operational state of helical gearboxes under varying conditions.
The dynamic responses of helical gearboxes arise from various excitation sources, including gear meshing stiffness variations, misalignments, unbalance, and torque fluctuations. Traditional single-parameter analyses often fall short in capturing the holistic behavior, necessitating a multi-parameter approach. In this study, we leverage synchronous measurement of diverse physical quantities to gain insights into the system’s dynamics. The integration of data from encoders, proximity sensors, accelerometers, microphones, and torque sensors allows for a nuanced understanding of how helical gears interact with other components like shafts and bearings. Our methodology emphasizes angle-domain analysis, which transforms time-domain signals into angle-sampled data to handle non-stationary conditions during speed variations. This approach enables precise calculation of dynamic transmission error (DTE), which is a key indicator of gear mesh quality and NVH performance. Through systematic testing under different speeds and loads, we evaluate the assembly state of the gearbox components and explore the interrelationships between vibration, noise, and transmission error. The findings contribute to improved design and maintenance strategies for helical gearboxes, highlighting the importance of multi-parameter monitoring in enhancing their dynamic performance.
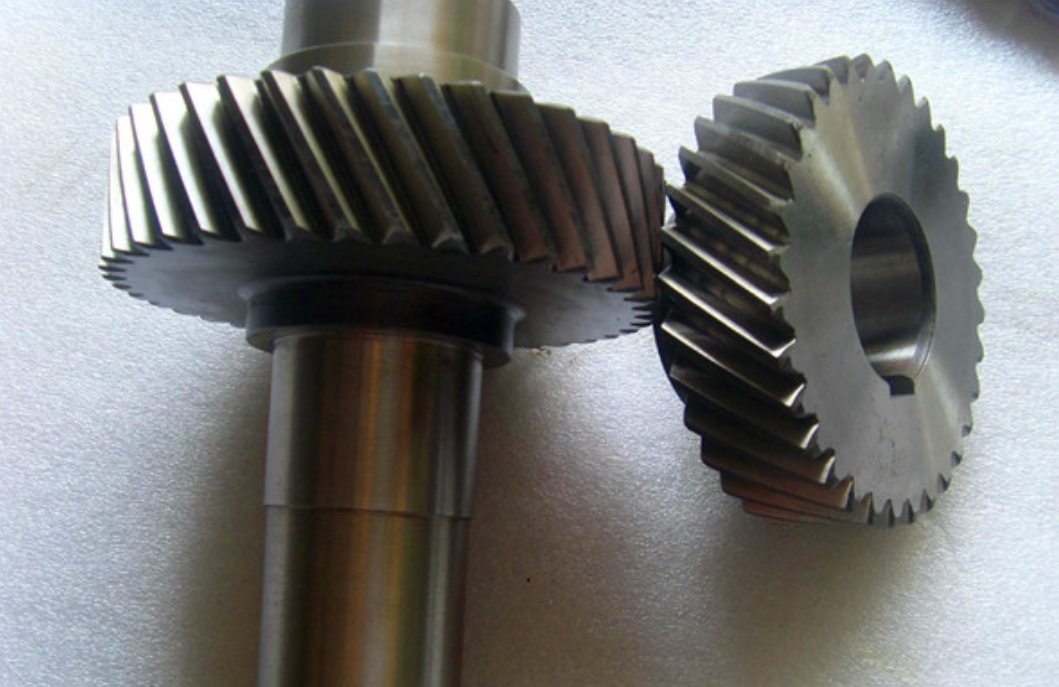
The test platform for evaluating helical gearboxes was meticulously designed to simulate real-world operating conditions while allowing precise control and measurement. At its core, an industrial-grade helical gearbox was used, with specifications detailed in Table 1. This gearbox features helical gears with a spiral angle of 13°, a transmission ratio of 1.62, and a center distance of 100 mm. The gears are precision-grade 7, ensuring typical manufacturing tolerances found in commercial applications. The input shaft is integrated with the pinion (a gear-shaft combination), and both shafts are supported by thrust roller bearings to handle axial loads inherent in helical gears. The driving unit consists of a Yaskawa servo motor operated in speed control mode, providing stable and adjustable rotational input. A magnetic powder brake serves as the loading device, enabling torque application from no-load to full-load conditions. This setup mimics the variable loads experienced by helical gearboxes in industrial machinery, such as conveyors or automotive transmissions.
| Parameter | Pinion (Small Gear) | Gear (Large Gear) |
|---|---|---|
| Number of Teeth | 29 | 47 |
| Base Circle Radius (mm) | 34.8515 | 56.4835 |
| Face Width (mm) | 40 | 35 |
| Module (mm) | 2.5 | 2.5 |
| Helix Angle | 13° | |
| Transmission Ratio | 1.62 | |
| Maximum Speed (r/min) | 1500 | |
Data acquisition was performed using a National Instruments PXIe-1078 chassis equipped with appropriate modules. The PXIe-4463 board generated analog voltage signals to control the motor speed, while the PXIe-4492 board sampled sensor data at a rate of 200 kHz to capture high-frequency dynamics. Sensors were strategically mounted on the gearbox: eddy current displacement sensors at both shaft ends to measure radial runout, incremental encoders with 2048 lines per revolution for angular position, a torque sensor on the output shaft, a piezoelectric accelerometer on the bearing housing near the output shaft, and a GRAS sound pressure microphone placed 0.5 meters from the gearbox casing. The specifications of these sensors are summarized in Table 2. Synchronization of motor control and data collection was achieved through SignalPad software, ensuring that all parameters were recorded simultaneously under each test condition. This comprehensive sensor array allows for correlated analysis of mechanical vibrations, acoustic emissions, and kinematic errors in helical gears.
| Sensor Type | Range/Sensitivity | Purpose |
|---|---|---|
| Eddy Current Displacement | 1 mm | Measure shaft radial runout |
| Incremental Encoder | 2048 pulses/rev | Measure angular position and speed |
| Torque Sensor | 100 N·m | Measure load torque |
| Piezoelectric Accelerometer | 101.7 mV/g | Measure vibration acceleration |
| Sound Pressure Microphone | 42.53 mV/Pa | Measure acoustic noise |
The analysis of dynamic data from helical gearboxes requires specialized methods to handle non-stationary signals and extract meaningful features. A cornerstone of our approach is the calculation of instantaneous rotational speed from encoder signals. Using the elapsed time method, the angular speed $$ \omega $$ is computed based on the time intervals between consecutive encoder pulses. If $$ f $$ is the clock frequency, $$ m $$ is the number of clock cycles between pulses, and $$ M $$ is the encoder line count, the speed in radians per second is given by:
$$ \omega = \frac{2\pi f}{M m} $$
This method provides high-resolution speed data, essential for analyzing speed fluctuations that influence gear dynamics. For instance, at a nominal speed of 60 r/min, we observed peak-to-peak speed variations of approximately 4 r/min, indicative of torque ripples or system instabilities.
To address non-stationarity during speed changes, time-domain signals are resampled into the angle domain. Assuming the shaft undergoes uniformly accelerated motion over short intervals, the angular position $$ \theta(t) $$ can be modeled as a quadratic function of time:
$$ \theta(t) = b_0 + b_1 t + b_2 t^2 $$
where $$ b_0, b_1, $$ and $$ b_2 $$ are coefficients determined from three consecutive encoder pulse times. Solving for these coefficients allows us to express time as a function of angle:
$$ t = \frac{1}{2b_2} \left[ \sqrt{4b_2(\theta – b_0) + b_1^2} – b_1 \right] $$
Using cubic spline interpolation, time-domain signals such as vibration acceleration are resampled at constant angular increments $$ \Delta \theta $$, transforming them into angle-domain signals $$ x[m] $$ with $$ m $$ denoting the sample index in angle. This resampling facilitates order analysis, where spectral components are expressed as multiples of the rotational frequency, known as orders. The order $$ o $$ is related to the frequency $$ f $$ and reference speed $$ n $$ in r/min by:
$$ o = \frac{60f}{n} $$
The order spectrum $$ X(o) $$ is obtained via discrete Fourier transform of the angle-domain signal:
$$ X(o) = \frac{1}{N} \sum_{m=0}^{N-1} x[m] e^{-2\pi j o m \Delta \theta} $$
where $$ N $$ is the number of samples and the order resolution is $$ \Delta o = 1/(N \Delta \theta) $$. This method effectively separates harmonic components related to shaft rotation and gear meshing in helical gears, even under varying speeds.
Transmission error (TE) is a critical parameter for assessing the kinematic accuracy and NVH behavior of helical gears. Under quasi-static or low-speed conditions with load, TE represents the inherent excitation due to gear imperfections. In dynamic regimes, it becomes the dynamic transmission error (DTE), reflecting the system’s vibratory response. The linear DTE on the line of action is calculated from the angular positions of the driving and driven gears. Let $$ \theta_1 $$ and $$ \theta_2 $$ be the angular positions of the input and output shafts, respectively, and $$ r_{b1} $$ and $$ r_{b2} $$ their base circle radii. The DTE $$ e_{DTE} $$ is given by:
$$ e_{DTE} = r_{b2} \theta_2 – r_{b1} \theta_1 $$
In practice, we synchronize the angular data from both shafts by interpolating the output shaft’s angle-time series onto the input shaft’s time base, then apply the above formula. This yields a signal that combines long-wave components (related to shaft rotations) and short-wave components (related to individual tooth meshes). The peak-to-peak value of the short-wave component serves as an indicator of gear mesh quality.
To quantify relationships between different parameters, we employ correlation analysis. The Pearson correlation coefficient $$ r $$ between two datasets $$ x $$ and $$ y $$, each with $$ N $$ samples, is defined as:
$$ r(x, y) = \frac{\sum_{i=1}^{N} (x_i – \bar{x})(y_i – \bar{y})}{\sqrt{\sum_{i=1}^{N} (x_i – \bar{x})^2 \sum_{i=1}^{N} (y_i – \bar{y})^2}} $$
where $$ \bar{x} $$ and $$ \bar{y} $$ are the sample means. This coefficient, ranging from -1 to 1, measures the linear dependence between variables, helping to identify how vibration, noise, and transmission error interrelate in helical gearboxes.
The experimental results provide rich insights into the dynamic performance of helical gearboxes. Starting with rotational speed, the instantaneous speed profiles derived from encoder data reveal fluctuations that correlate with torque variations. For example, under no-load conditions at a nominal 60 r/min, speed oscillations of about 4 r/min peak-to-peak were observed, attributable to motor control dynamics and load-independent resistances. This speed variability underscores the need for angle-domain analysis to stabilize signal periodicity.
Shaft center trajectories, derived from eddy current sensor measurements, offer visual and quantitative evidence of alignment and balance issues. At an input speed of 40 r/min, the horizontal components of the axis orbits for both shafts were analyzed under varying loads. The input shaft exhibited relatively smaller vibrations compared to the output shaft, likely due to the larger axial forces on the helical gear requiring more robust balancing. As load torque increased, the peak-to-peak amplitude of the orbits grew, indicating heightened deflection and bearing forces. Spectral analysis of the orbit components showed dominant frequencies at the shaft rotational orders and their harmonics. For the input shaft, multiple harmonics suggested misalignment with the motor shaft, while the output shaft’s spectrum was dominated by the fundamental rotational frequency, pointing to dynamic unbalance. These findings highlight the sensitivity of helical gearboxes to assembly precision.
Torque measurements displayed fluctuations of approximately 4 N·m peak-to-peak, consistent with the speed variations. This torque ripple contributes to non-periodic vibrations and noise. The vibration and noise data were analyzed using speed-frequency spectrograms, covering a speed range from 100 to 500 r/min in 40 r/min increments. The spectrograms revealed distinct bands at the gear mesh frequency $$ f_m $$ and its sidebands, as well as at shaft rotational frequencies $$ f_r $$. The presence of sidebands around $$ f_m $$ indicates modulation effects, possibly due to eccentricities or misalignments in the helical gears. The overall sound pressure level correlated strongly with vibration amplitude, confirming that gearbox noise primarily originates from structural vibrations.
Transmission error analysis yielded detailed profiles under different conditions. Under quasi-static no-load at 30 r/min, the TE signal comprised a long-wave sinusoidal component (period equal to shaft rotation) and a short-wave component with tooth-period oscillations. The short-wave peak-to-peak value varied with applied torque, showing a minimum at a specific torque (around 20 N·m in our tests). This behavior is characteristic of helical gears: at low loads, teeth may not be fully engaged due to gaps or errors; as load increases, elastic deformations improve contact until excessive load causes deflections that increase TE. This nonlinear relationship emphasizes the importance of optimal loading for minimizing transmission error in helical gears.
Dynamic transmission error under varying speeds was examined through order spectra. The dominant orders corresponded to the shaft rotations (order 1 for input, order 0.62 for output) and the gear mesh (order 29, equal to the pinion tooth count). The mesh order amplitude was relatively low compared to rotational orders, suggesting good gear health without significant faults. However, additional harmonics in the DTE spectrum indicated eccentricities or time-varying misalignments, consistent with the vibration findings.
Correlation analysis between parameters uncovered significant relationships. Vibration acceleration (root mean square, RMS) and sound pressure level showed a correlation coefficient of 0.996 across different speeds, demonstrating that noise in helical gearboxes is predominantly vibration-driven. The DTE peak-to-peak value correlated positively with speed, and at a given speed, it showed a correlation coefficient of 0.6 with the peak-to-peak value of the output shaft’s radial runout. This implies that as vibration intensifies with speed, it exacerbates shaft跳动, creating a feedback loop. Under quasi-static conditions, the TE short-wave peak-to-peak value and vibration RMS had a correlation of 0.62 across different torques, reinforcing that transmission error is a key excitation source for vibrations in helical gears.
To summarize the interparameter relationships, Table 3 presents correlation coefficients between key dynamic parameters under varying operational conditions. This table underscores the interconnected nature of the system responses.
| Parameter Pair | Correlation Coefficient | Condition |
|---|---|---|
| Vibration RMS vs. Sound Pressure RMS | 0.996 | Variable speed, no load |
| DTE Peak-to-Peak vs. Output Shaft Runout Peak-to-Peak | 0.60 | Variable speed, no load |
| TE Short-wave Peak-to-Peak vs. Vibration RMS | 0.62 | 30 r/min, variable torque |
| Speed vs. DTE Peak-to-Peak | Positive trend | Variable speed, no load |
The assembly state of the helical gearbox was evaluated synthetically from the multi-parameter data. The evidence points to minor but measurable imperfections: input shaft misalignment with the motor shaft (indicated by harmonic-rich vibration spectra), output shaft dynamic unbalance (from dominant fundamental frequency in orbits), and gear eccentricities (from sidebands in mesh frequency). These issues are common in industrial gearboxes and can be mitigated through precision alignment and balancing during assembly. The helical gears themselves exhibited good mesh quality, as seen in the low mesh-order amplitudes, but the axial forces inherent in helical gears likely contributed to the observed thrust bearing impacts.
In conclusion, this study demonstrates the value of multi-parameter testing for comprehensively assessing the dynamic performance of helical gearboxes. By integrating measurements of speed, transmission error, axis orbit, vibration, noise, and torque, we have revealed intrinsic correlations that govern system behavior. The angle-domain analysis proved effective in handling non-stationary signals, enabling precise calculation of dynamic transmission error and order spectra. Key findings include the strong correlation between vibration and noise, the influence of speed and load on transmission error, and the identification of assembly issues like misalignment and unbalance. These insights can guide the optimization of helical gearbox design, assembly processes, and condition monitoring strategies. Future work could explore the effects of lubrication, temperature, and different helical gear geometries on dynamic responses. Ultimately, the multi-parameter approach provides a robust framework for enhancing the reliability and efficiency of helical gearboxes in diverse mechanical applications.