
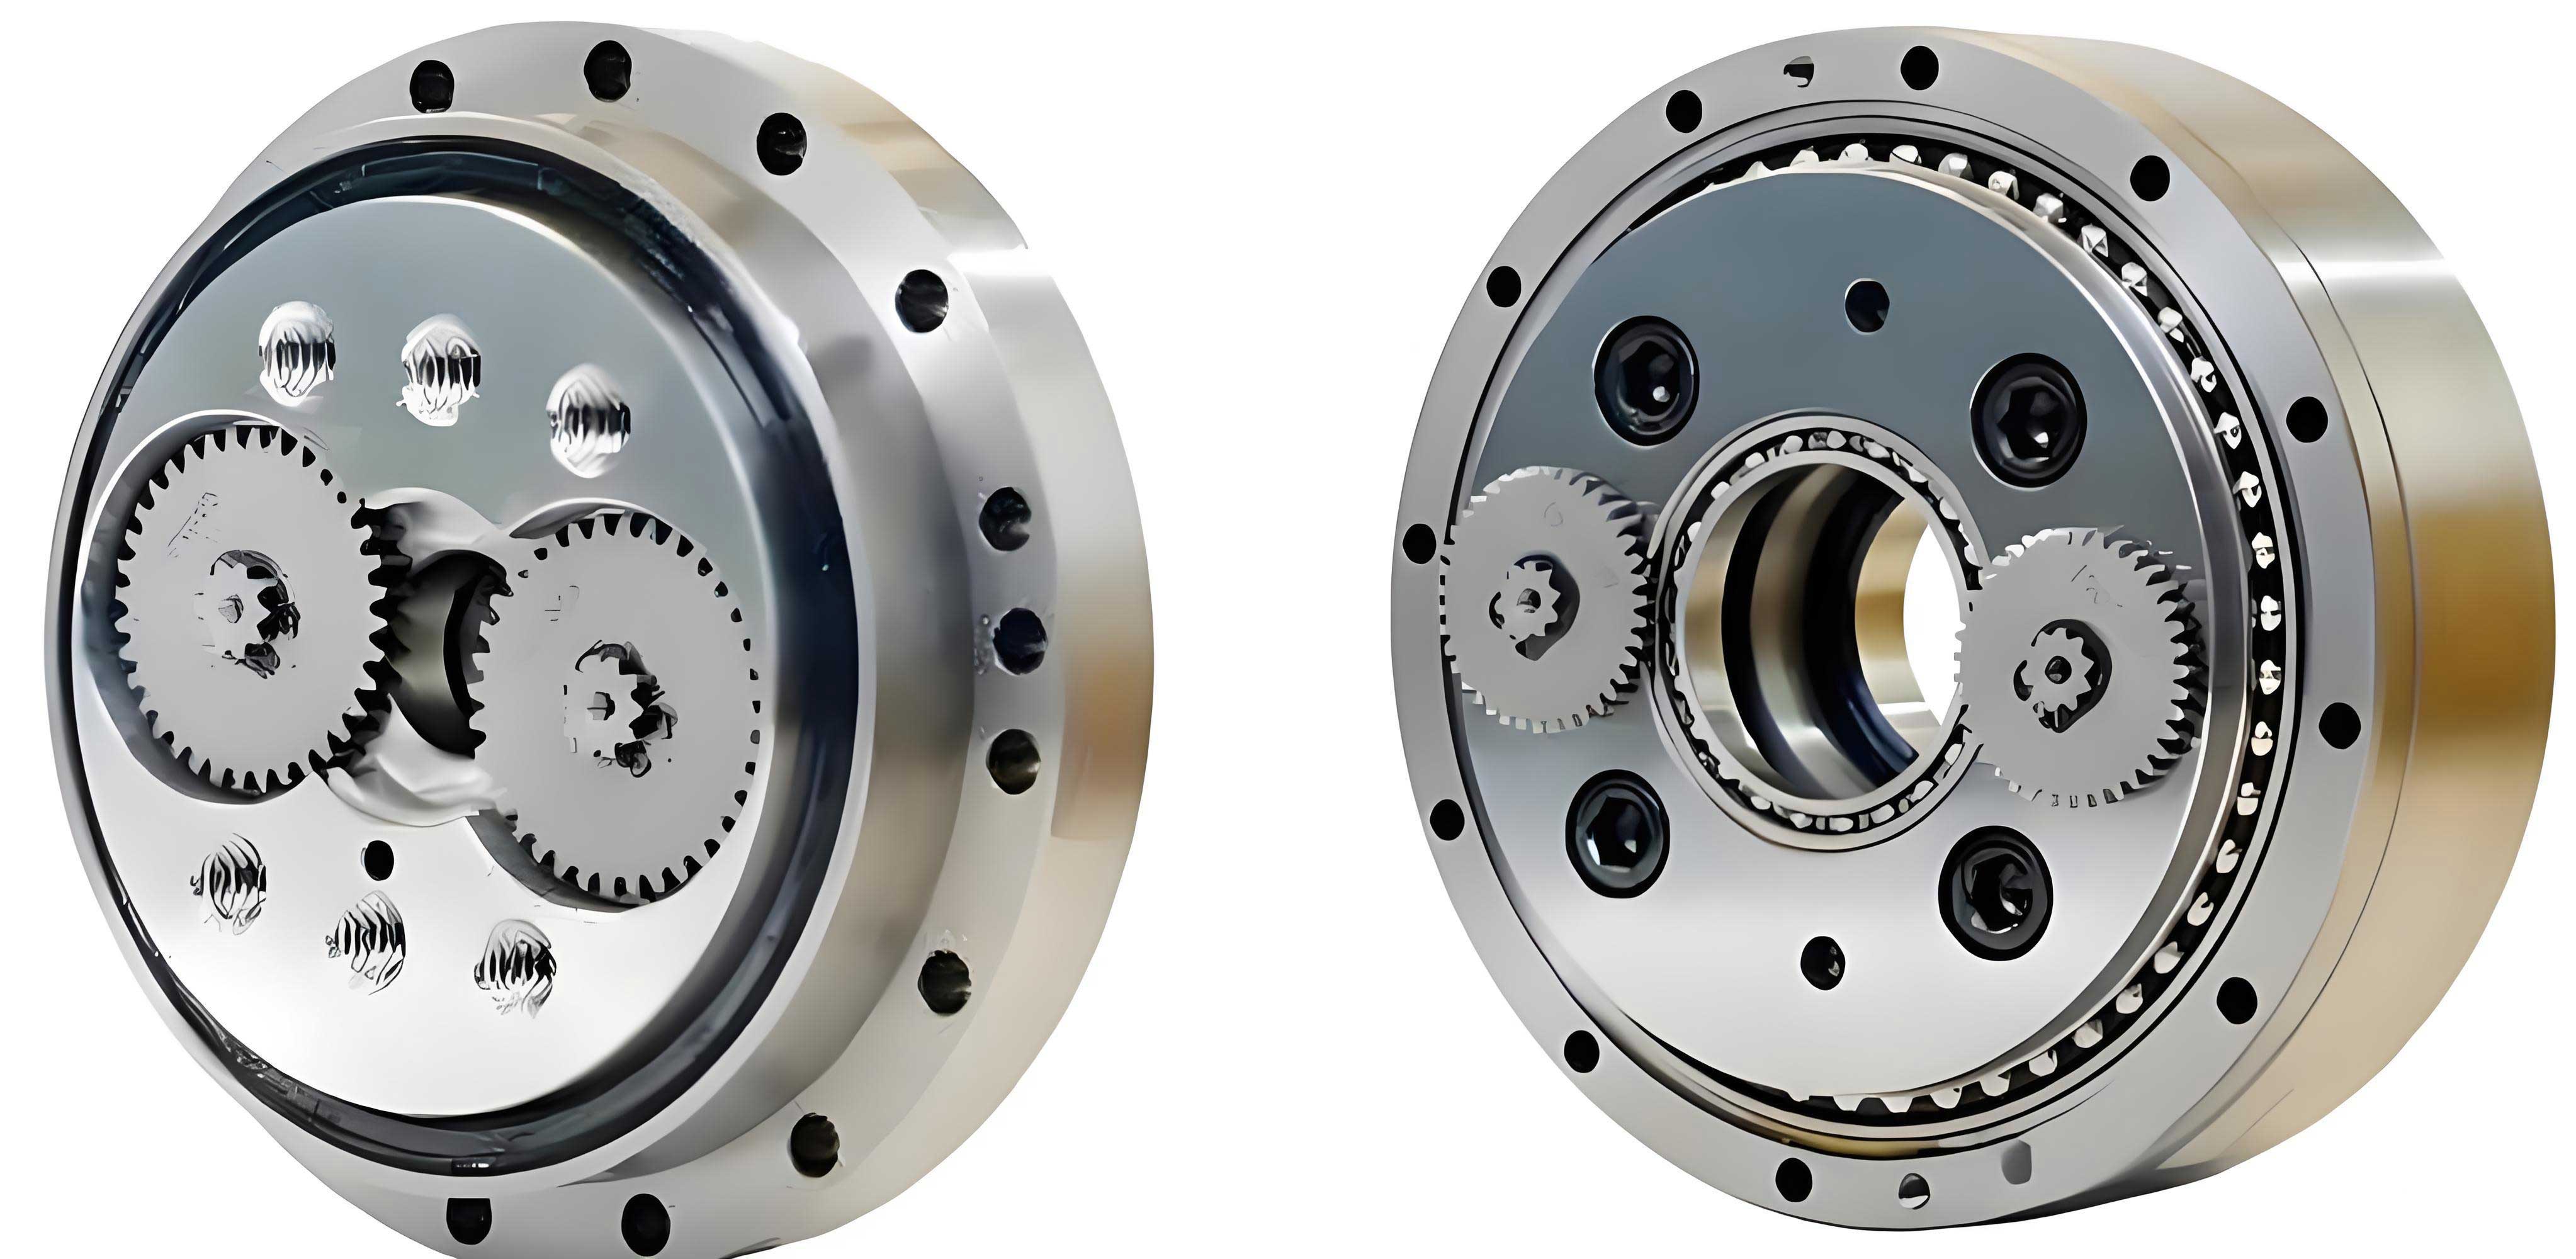
As a core transmission component in industrial robotics, the health and reliability of the RV reducer are paramount. This complex system, comprising a planetary gear stage and a cycloidal-pin gear stage, is susceptible to localized gear faults due to harsh operational loads and frequent acceleration/deceleration cycles. Effective fault diagnosis is crucial, yet challenging, because traditional vibration signals are heavily modulated by time-varying transfer paths within the RV reducer, and the planet and cycloidal gears share identical rotational frequencies, making their fault signatures identical in the frequency domain. This study investigates the use of Instantaneous Angular Speed (IAS) signals, derived from a servo motor’s built-in encoder, to overcome these limitations and distinguish between planet and cycloidal gear localized faults.
Architecture and Characteristic Orders of the RV Reducer
The RV reducer achieves high reduction ratios through a two-stage mechanism. The first stage is a standard planetary gear train where an input sun gear drives multiple planet gears. The planet gears rotate on their axes while also revolving, transmitting torque to crankshafts. These crankshafts drive the second stage—the cycloidal-pin mechanism. Here, the eccentric rotation of the cycloidal gears causes their teeth to engage in a rolling motion with stationary pin teeth, ultimately driving the output flange. The total reduction ratio, n, is given by:
$$ n = \frac{N_s}{N_c} = 1 + \frac{Z_w \cdot Z_p}{Z_s \cdot (Z_w – Z_c)} $$
where \( N_s \) and \( N_c \) are the rotational speeds of the sun gear and output flange, respectively; \( Z_s \), \( Z_p \), \( Z_c \), and \( Z_w \) are the tooth numbers of the sun gear, planet gear, cycloidal gear, and the number of pin teeth. Defining the sun gear rotational order as 1×, the characteristic orders of the system are as summarized in Table 1.
| Component | Order (×) | Formula |
|---|---|---|
| Output Flange (\(O_c\)) | 1/n | \( O_c = 1/n \) |
| Planet/Cycloidal Gear (\(O_p = O_{cy}\)) | \( \frac{Z_s \cdot Z_w}{Z_p \cdot (Z_s + Z_w)} \) | \( O_p = \frac{Z_s}{Z_s + Z_p} \) (for standard stage, with carrier fixed) *Note: In RV reducer kinematics, this simplifies to the given formula. |
| Planetary Stage Meshing (\(O_{mp}\)) | \( Z_s \cdot (1 – O_c) \) | \( O_{mp} = Z_s \) |
| Cycloidal-Pin Stage Meshing (\(O_{mc}\)) | \( Z_w \cdot (O_p – O_c) \) | \( O_{mc} = Z_w \cdot O_p \) |
Time-Varying Mesh Stiffness Under Fault Conditions
The dynamic response of any gear system is fundamentally driven by the time-varying mesh stiffness (TVMS), which acts as a primary internal excitation. For the planetary stage (involute gears), the TVMS for a single tooth pair \(k_t\) is calculated using the potential energy method, considering Hertzian contact (\(k_h\)), bending (\(k_b\)), shear (\(k_s\)), and axial compressive (\(k_a\)) stiffness components:
$$ \frac{1}{k_t} = \frac{1}{k_{h}} + \frac{1}{k_{b1}} + \frac{1}{k_{s1}} + \frac{1}{k_{a1}} + \frac{1}{k_{b2}} + \frac{1}{k_{s2}} + \frac{1}{k_{a2}} $$
The total mesh stiffness \(K_p(t)\) is the sum of the stiffness of all tooth pairs in contact, governed by the contact ratio. A localized fault, such as spalling on a planet gear tooth, reduces the effective contact length, leading to a sharp drop in \(k_t\) when that faulty tooth enters the mesh zone. This results in a periodic stiffness reduction in \(K_p(t)\) with a period corresponding to the planet gear rotation (\(1/O_p\)).
For the cycloidal-pin stage, the mesh stiffness \(K_c(t)\) is derived from Hertzian contact theory. The normal force at the contact point varies with the pressure angle \(\alpha_c\). The contact half-width \(L\) and consequently the radial deformation \(t_c\) are:
$$ L = \sqrt{ \frac{8 F_n (1-\mu^2)}{\pi b E} \left( \frac{1}{\rho_i} – \frac{1}{r} \right)^{-1} } $$
$$ t_c = \frac{L^2}{2\rho_i} = \frac{4 F_n (1-\mu^2)}{\pi b E \rho_i} \left( \frac{1}{\rho_i} – \frac{1}{r} \right)^{-1} $$
The local mesh stiffness at a contact point is \(k_c = F_t / t_c\), where \(F_t\) is the tangential force. The total stage stiffness is the sum of the stiffness from approximately one-third to one-half of the teeth simultaneously in contact. A localized fault (e.g., abnormal wear) on a cycloidal tooth reduces its load-bearing capacity, causing a significant drop in \(k_c\) over the entire engagement period of that faulty tooth. Since the engagement arc for a single cycloidal tooth is long (high contact ratio), this results in a prolonged stiffness reduction in \(K_c(t)\), also periodic with the cycloidal gear’s rotation (\(1/O_{cy} = 1/O_p\)).
IAS Response Analysis via a Torsional Dynamic Model
A pure torsional lumped-parameter model of the RV reducer was established to simulate the IAS response. The equations of motion are derived from torque balance for the sun gear (s), planet gears (p_i), cycloidal gears (c_j), and output flange (o):
$$ \begin{aligned}
J_s \ddot{\theta}_s + \sum_{i=1}^{N_p} F_{sp_i} r_s + c_s \dot{\theta}_s + k_s \theta_s &= T_{in} \\
J_p \ddot{\theta}_{p_i} – F_{sp_i} r_p + c_{p_i} \dot{\theta}_{p_i} + k_{p_i} \theta_{p_i} &= 0 \\
J_c \ddot{\theta}_{c_j} + F_{cb_j} + c_{c_j} \dot{\theta}_{c_j} + k_{c_j} \theta_{c_j} &= 0 \\
J_o \ddot{\theta}_o – \sum_{j=1}^{2} F_{cb_j} r_o + c_o \dot{\theta}_o + k_o \theta_o &= -T_{out}
\end{aligned} $$
where \(F_{sp_i}\) and \(F_{cb_j}\) are the mesh forces for the planetary and cycloidal-pin stages, respectively, defined as:
$$ F_{sp_i} = c_{sp_i} (r_s \dot{\theta}_s – r_p \dot{\theta}_{p_i}) + k_{sp_i}(t) (r_s \theta_s – r_p \theta_{p_i}) $$
$$ F_{cb_j} = c_{cb_j} \dot{\theta}_{c_j} + k_{cb_j}(t) \theta_{c_j} $$
The time-varying stiffness terms \(k_{sp_i}(t)\) and \(k_{cb_j}(t)\) are the key internal excitations, modeled as described in the previous section for normal, planet gear fault, and cycloidal gear fault conditions. The simulated IAS signal (\(\omega_s = \dot{\theta}_s\)) is obtained by solving this system of equations.
Simulation Results and Signal Characteristics: The simulated IAS signals, after removing the mean rotational speed, reveal distinct signatures for different fault types in the RV reducer.
- Waveform: Both planet and cycloidal gear faults cause periodic impulsive jitters in the IAS waveform with an identical period corresponding to the fault order \(O_p\). However, the nature of the jitter differs significantly. A planet gear fault produces a sharp, narrow dip due to the low contact ratio of involute gears. In contrast, a cycloidal gear fault causes a broader, more prolonged speed fluctuation, reflecting the high contact ratio and extended engagement of the faulty tooth.
- Order Spectrum: The order spectra of the IAS signals provide further discrimination. In the planet gear fault case, the planetary stage meshing order (\(O_{mp}\)) is prominently surrounded by multiple sideband families spaced at the fault order \(O_p\). For the cycloidal gear fault, it is the cycloidal-pin stage meshing order (\(O_{mc}\)) that exhibits the most pronounced sidebands at \(\pm n \cdot O_p\).
| Condition | IAS Waveform Feature | Dominant Order Spectrum Feature |
|---|---|---|
| Normal | Small, regular fluctuations from meshing. | Peaks at \(O_{mp}\) and \(O_{mc}\) only. |
| Planet Gear Fault | Sharp, narrow periodic jitters at period \(1/O_p\). | Strong sidebands at \(O_{mp} \pm n \cdot O_p\). |
| Cycloidal Gear Fault | Broad, prolonged periodic jitters at period \(1/O_p\). | Strong sidebands at \(O_{mc} \pm n \cdot O_p\). |
Experimental Validation
Experiments were conducted on an RV reducer test rig (RV-80E-81, reduction ratio n=81) driven by a servo motor and loaded by a magnetic powder brake. The servo motor’s built-in 2500 PPR incremental encoder signal was captured to compute the IAS. Artificially seeded localized faults included a spall on a planet gear tooth and abnormal wear on a cycloidal gear tooth.
Constant Speed Condition (200 rpm): The measured IAS signals and their order spectra confirmed the simulation findings. The fault-induced jitters appeared with the predicted period. The planet gear fault caused sharper impulses, while the cycloidal fault caused wider disturbances. The order spectra clearly showed that for the planet fault, sidebands were strongest around \(O_{mp}\) (15.8×), whereas for the cycloidal fault, they were dominant around \(O_{mc}\) (19.3×).
Variable Speed Condition (20 to 220 rpm ramp): Since IAS is computed from constant angular sampling (encoder pulses), it is inherently in the angular domain, avoiding the need for resampling. After removing the speed trend via least-squares fitting, the same waveform and order spectrum characteristics as in the constant speed case were observed, demonstrating the robustness of the method for variable speed operation of the RV reducer.
Conclusion
This study demonstrates that IAS signals, readily available from a servo motor’s built-in encoder, are highly effective for detecting and distinguishing between planet and cycloidal gear localized faults in an RV reducer. The key differentiators are rooted in the distinct TVMS behaviors of the two gear stages under fault conditions, leading to unique IAS dynamic responses. The high-contact-ratio cycloidal gear fault produces a broad speed disturbance, while the low-contact-ratio planet gear fault results in a sharp impulse, both recurring at the same fundamental period. Furthermore, spectral analysis reveals that the fault-modulated sidebands predominantly appear around the meshing order of the faulty stage. These identified characteristics provide a practical and sensorless methodology for the condition monitoring and fault diagnosis of critical RV reducers in industrial robotic systems.