
The demand for high-performance power transmission systems, particularly in sectors like aerospace, automotive, and heavy machinery, continuously pushes the boundaries of gear design. Among various gear types, the spiral bevel gear stands out for its ability to transmit power smoothly and efficiently between intersecting shafts, typically at a right angle. Its curved teeth allow for gradual engagement, leading to higher load capacity and quieter operation compared to straight bevel gears. However, as modern machinery evolves towards higher speeds and lower noise emission, traditional design methods for spiral bevel gears often reach their limits. There is a pressing need for advanced design philosophies that can simultaneously enhance gear meshing smoothness, increase load-bearing capacity, and improve operational reliability.
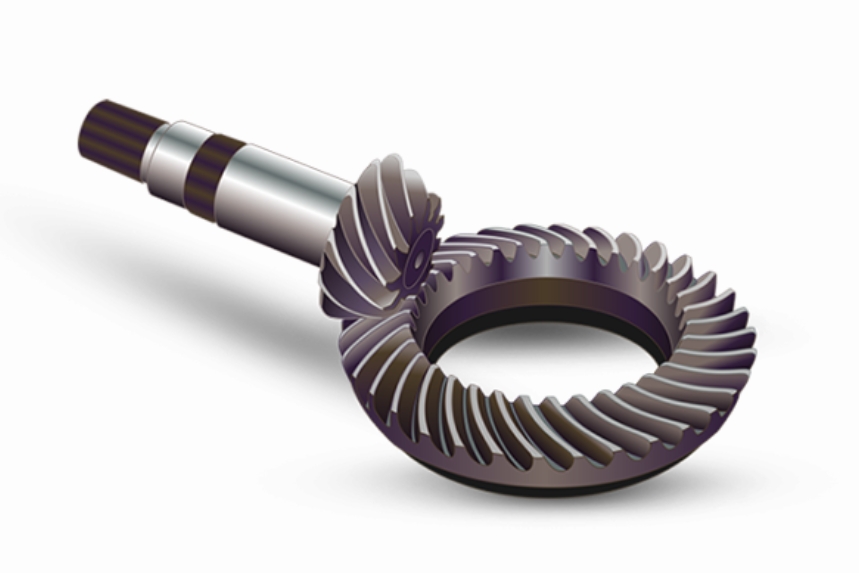
The primary source of vibration and noise in geared systems is often linked to fluctuations in the transmission error—the deviation between the actual and theoretical positions of the output gear. These fluctuations are exacerbated when the load is concentrated on a single tooth pair for a significant portion of the meshing cycle. A key metric for assessing meshing smoothness is the contact ratio. A higher contact ratio indicates that more than one tooth pair is sharing the load for a longer duration, which effectively averages out manufacturing imperfections, reduces load per tooth, and minimizes transmission error variation. Consequently, designing a spiral bevel gear pair with a high contact ratio is a fundamental strategy for achieving low-noise, high-performance transmission.
This article explores an integrated methodology for designing high-contact-ratio spiral bevel gears by synergizing two powerful concepts: the geometric principles of non-zero negative displacement (negative transmission) and the precision machining parameter design enabled by the local synthesis method. Traditional “zero-displacement” spiral bevel gear designs, such as the conventional Gleason system, have established practices but may not optimize for maximum smoothness. The non-zero displacement theory introduces the flexibility to deliberately alter the tooth profile geometry by separating the pitch cone and the dividing cone. Specifically, a negative displacement design, where the pitch cone radius is smaller than the dividing cone radius, inherently increases the transverse contact ratio by reducing the operating pressure angle. While this boosts smoothness, a potential trade-off is a slight reduction in individual tooth bending strength due to a thinner tooth profile.
To counter this and further amplify performance gains, we integrate the local synthesis method for machining parameter design. Unlike traditional methods that focus on tooth geometry alone, local synthesis allows direct control over second-order contact parameters on the tooth surface. By strategically designing the contact path to have a high degree of inclination across the tooth face, we can significantly increase the effective overlap of successive tooth engagements, thereby boosting the overall contact ratio beyond what geometry alone provides. This controlled contact path also optimizes load distribution. This integrated approach—using negative displacement for geometric enhancement and local synthesis for contact condition optimization—forms a comprehensive strategy for developing superior spiral bevel gear drives.
Fundamentals of Non-Zero Negative Displacement Design for Spiral Bevel Gears
The core principle of non-zero displacement design for spiral bevel gears lies in the intentional dissociation of the pitch cone and the dividing (standard) cone. In a conventional zero-displacement design, these cones are coincident. The pitch cone is defined by the kinematics of the mesh (determined by the shaft angle and tooth numbers), while the dividing cone is the reference for defining standard module and pressure angle. In non-zero design, these cones are separated, meaning the pitch cone angle and the dividing cone angle are different for the same gear. This is achieved by applying radial displacement coefficients (\(x_1\) and \(x_2\)) to the pinion and gear, respectively.
For a negative transmission design, the sum of the radial displacement coefficients is negative (\(x_1 + x_2 < 0\)). This results in the pitch cone being nested inside the dividing cone. Graphically, on the gear blank drawing, the pitch line and the root/face apex lines do not converge at the same point. In the equivalent spur gear representation on the back cone, the pitch circle radius (\(r’\)) becomes smaller than the standard dividing circle radius (\(r\)).
The key geometric changes induced by negative displacement are:
1. Reduced Operating Pressure Angle (\(\alpha’\)): This is the most critical effect for increasing contact ratio. The meshing pressure angle is smaller than the standard tool pressure angle (\(\alpha\)).
2. Increased Transverse Contact Ratio: The transverse (or profile) contact ratio \(\epsilon_{\alpha}\) is primarily a function of the pressure angle and addendum. A lower \(\alpha’\) directly increases \(\epsilon_{\alpha}\).
3. Altered Tooth Profile: The tooth thickness at the pitch line changes. With negative displacement, the tooth typically becomes thinner at the tip and thicker at the root compared to a standard tooth, increasing flexibility.
The geometric relationship for the operating pressure angle in a negative transmission is derived from the geometry of the equivalent gear pair on the back cone:
$$
\inv(\alpha’) = \inv(\alpha) + 2 \frac{x_1 + x_2}{z_{v1} + z_{v2}} \tan(\alpha)
$$
where \(\inv\) is the involute function, \(z_{v1}\) and \(z_{v2}\) are the virtual tooth numbers of the pinion and gear, and \(\alpha\) is the standard pressure angle. Since \(x_1 + x_2 < 0\), \(\alpha’ < \alpha\).
The total contact ratio (\(\epsilon_{\gamma}\)) for a spiral bevel gear is the sum of the transverse contact ratio (\(\epsilon_{\alpha}\)) and the face contact ratio (\(\epsilon_{\beta}\)).
$$
\epsilon_{\gamma} = \epsilon_{\alpha} + \epsilon_{\beta}
$$
The face contact ratio depends on the face width, spiral angle, and module, and is largely unaffected by displacement. Therefore, the gain from negative displacement comes primarily from boosting \(\epsilon_{\alpha}\).
Design Example – Geometric Parameters: To illustrate, let’s consider a spiral bevel gear pair for a precision right-angle reducer. The basic design requirements are common, but we will apply two different design philosophies. The following table compares the fundamental geometric parameters obtained from a Non-Zero Negative Displacement design against a Conventional Gleason (Zero-Displacement) design.
| Parameter | Non-Zero Negative Design | Conventional Gleason Design |
|---|---|---|
| Module (mm) | 3 | 3 |
| Number of Teeth (Pinion/Gear) | 25 / 25 | 25 / 25 |
| Standard Pressure Angle (°) | 20 | 20 |
| Shaft Angle (°) | 90 | 90 |
| Face Width (mm) | 18 | 18 |
| Mean Spiral Angle (°) | 35 | 35 |
| Operating Pressure Angle (°) | 21.77 | 23.96 |
| Total Geometric Contact Ratio | 2.171 | 2.097 |
| Radial Displacement Coefficient | -0.27 / -0.27 | 0 / 0 |
| Tangential Displacement Coefficient | 0.015 / 0.015 | 0 / 0 |
| Pitch Cone Angle (°) | 45 / 45 | 45 / 45 |
The table clearly shows the effect of negative displacement. The operating pressure angle is reduced from 23.96° to 21.77°. This directly contributes to an increase in the calculated total geometric contact ratio from 2.097 to 2.171. While this is a beneficial increase, the true potential for meshing smoothness is unlocked not just by geometry, but by how the teeth are manufactured to contact each other. This is where the local synthesis method becomes indispensable for designing high-performance spiral bevel gears.
Enhancing Contact Ratio via Local Synthesis and Machining Parameter Design
The geometric design provides the blueprint, but the actual performance of a spiral bevel gear pair is dictated by the precise shape of its tooth surfaces, which are generated during the cutting process. The Local Synthesis method is a sophisticated mathematical approach for determining the optimal machine-tool settings (cutter geometry, machine angles, positions, and cradle roll ratios) to produce tooth surfaces with predetermined contact characteristics.
Local synthesis moves beyond basic gear geometry to control the second-order properties of the mating surfaces—specifically, the principal curvatures and directions at the designated contact point. This allows an engineer to pre-design two critical performance indicators:
1. The Transmission Error Function: The pattern of positional deviation over the mesh cycle. A low-amplitude, parabolic function is often targeted for low vibration.
2. The Contact Path: The locus of contact points on the tooth surface under no-load conditions. The orientation and length of this path are crucial.
For the goal of maximizing the effective contact ratio, the design of the contact path is paramount. A conventional design might aim for a contact path that is short and centrally located across the face width. In contrast, to achieve a high-contact-ratio spiral bevel gear, we use local synthesis to design a highly inclined and elongated contact path. A large inclination angle (relative to the root line) ensures that as one tooth pair is near the end of its contact, the next pair has already started engaging at the opposite end of its face. This leads to a substantial overlap in the load-sharing period between successive tooth pairs.
The effective meshing contact ratio, observed through Tooth Contact Analysis (TCA) simulation, can be significantly higher than the purely geometric calculation. TCA simulates the kinematic meshing of the theoretically perfect tooth surfaces. In the TCA output for a high-inclination design, the transmission error curve shows a nearly continuous, low-amplitude waveform. The angular width of this curve (the mesh period for one tooth) divided by the angular pitch between teeth gives a theoretical meshing contact ratio that truly reflects the multi-pair contact enabled by the machining parameters.
Design Example – Machining Parameters: Applying local synthesis, we derive machine settings for the non-zero negative displacement gear pair to produce a highly inclined contact path on the tooth surface (e.g., targeting a 21° angle between the contact path and the root line). For comparison, conventional settings for the zero-displacement pair typically yield a more vertical contact path (e.g., 78°). Key contrasting machining parameters are summarized below.
| Machining Parameter | High-Ratio Design (Pinion Concave) | Conventional Design (Pinion Concave) |
|---|---|---|
| Cutter Radius (mm) | 88.23 | 84.98 |
| Machine Root Angle (°) | 41.62 | 41.64 |
| Radial Setting (mm) | 40.32 | 39.93 |
| Cradle Angle (deg) | 63.48 | 63.90 |
| Machine Center to Back (mm) | -0.418 | 1.512 |
| Ratio of Roll | 1.41544 | 1.36981 |
| Designed Contact Path Inclination | ~21° (High Inclination) | ~78° (Near Vertical) |
The TCA results for the two designs vividly demonstrate the impact. For the high-inclination design based on the non-zero negative displacement spiral bevel gear, the transmission error curve spans approximately 29° of pinion rotation for one tooth, while the angular pitch is 14.4°. The ratio gives a theoretical meshing contact ratio of about 2.01. For the conventional spiral bevel gear design, the corresponding value is only about 1.28. This confirms that the synergy of negative displacement geometry and optimized local synthesis machining parameters dramatically increases the functional overlap of tooth engagements, a critical factor for smooth operation.
Loaded Performance Analysis: Stress and Transmission Behavior
Superior geometric and kinematic design must ultimately translate into improved performance under load. To evaluate this, we employ Loaded Tooth Contact Analysis (LTCA) and Finite Element Analysis (FEA). LTCA simulates gear meshing considering tooth deflections under a specified load torque, providing insights into the loaded transmission error, contact pattern shift and size, and most importantly, load sharing among multiple tooth pairs. FEA is used to compute detailed stress distributions.
We analyze both the high-contact-ratio negative transmission spiral bevel gear design and the conventional design under an identical load condition of 48 N·m.
1. Loaded Transmission Error and Load Sharing:
The amplitude of the loaded transmission error (LTE) is a direct indicator of dynamic excitation. A lower amplitude signifies smoother operation and lower noise potential. The load sharing factor indicates the proportion of the total load carried by an individual tooth pair at any instant. A value less than 1.0 indicates multi-pair contact.
- High-Ratio Design: The LTE shows a very low amplitude. Crucially, the load sharing factor is always less than 1.0 throughout the mesh cycle, with a maximum of around 0.72. This confirms continuous double- or triple-pair contact, validating the high-contact-ratio design goal for the spiral bevel gear.
- Conventional Design: The LTE amplitude is higher. The load sharing factor reaches 1.0 for significant portions of the cycle, indicating periods where only a single tooth pair bears the entire load.
2. Bending and Contact Stress Analysis:
Using FEA, we compute the maximum tooth root bending stress for both the pinion and gear, as well as the maximum contact (Hertzian) stress on the flanks.
The bending stress history over a mesh cycle for both designs shows distinct patterns. The high-contact-ratio spiral bevel gear design exhibits lower and more evenly distributed stress peaks due to the load being shared. The following table summarizes the critical stress results, showcasing the performance advantage of the integrated design methodology for the spiral bevel gear pair.
| Stress Metric | High-Ratio Negative Design | Conventional Gleason Design | Improvement |
|---|---|---|---|
| Max Pinion Bending Stress (MPa) | 110.25 | 185.32 | Reduction of 40.5% |
| Max Gear Bending Stress (MPa) | 104.52 | 144.15 | Reduction of 27.5% |
| Max Contact Stress (MPa) | 1174.79 | 1213.85 | Reduction of 3.2% |
The results are compelling. The high-contact-ratio design delivers a dramatic reduction in tooth root bending stress—over 40% for the pinion. This effectively mitigates the potential weakening concern associated with the negative displacement’s thinner tooth tip, turning it into a significant strength advantage. The contact stress is also slightly lower, contributing to better pitting resistance. These stress reductions, combined with the superior load distribution, directly translate to higher fatigue life and greater operational reliability for the spiral bevel gear drive.
Conclusion
This analysis demonstrates a powerful integrated methodology for designing advanced spiral bevel gear drives. By combining the geometric freedom of non-zero negative displacement with the precise contact control of the local synthesis method, it is possible to engineer spiral bevel gears with significantly enhanced performance characteristics.
The negative displacement geometry provides a foundational increase in the transverse contact ratio by reducing the operating pressure angle. The local synthesis method builds upon this by enabling the design of a highly inclined contact path, which maximizes the functional overlap of tooth engagements. This synergy results in a spiral bevel gear pair with a substantially higher effective contact ratio compared to conventional designs.
The performance benefits under load are unequivocal. The designed high-contact-ratio spiral bevel gear exhibits:
1. A loaded transmission error with lower amplitude, indicating smoother operation and lower vibration/noise excitation.
2. Continuous multi-pair contact, as evidenced by load sharing factors consistently below 1.0.
3. A dramatic reduction in tooth root bending stress (over 40% for the pinion in the example), leading to greatly improved bending fatigue strength.
4. A slight reduction in contact stress, contributing to improved surface durability.
This approach moves beyond traditional design charts and empirical rules, leveraging modern computational analysis (TCA, LTCA, FEA) to predict and optimize performance virtually. It provides a systematic and analytical framework for developing low-noise, high-strength, and highly reliable spiral bevel gear transmissions suitable for the most demanding applications. The methodology confirms that pursuing a high contact ratio through intelligent geometric and manufacturing design is a highly effective path toward superior spiral bevel gear performance.