
The evolution of the automotive industry is inextricably linked to the pursuit of efficiency and sustainability. Among the various technological pathways, hybrid electric vehicles (HEVs) have established themselves as a crucial bridge technology, successfully merging the high-energy density of internal combustion engines with the efficiency and flexibility of electric powertrains. The core challenge in a hybrid system lies not merely in the presence of multiple power sources—typically an engine, an electric motor, and an energy storage battery—but in their intelligent and seamless integration. This integration is physically and functionally orchestrated by a critical component: the power coupling device, or coupler. The coupler’s role is to combine, distribute, and manage the mechanical power flows from the engine and the motor, enabling diverse operating modes such as electric drive, engine drive, hybrid drive, regenerative braking, and battery charging. The choice of coupling mechanism profoundly impacts the vehicle’s performance, cost, complexity, and control strategy. While planetary gear sets and hydraulic couplings are common, this discourse focuses on the design and control of a mechanically elegant, robust, and cost-effective alternative: the bevel gears-based coupler for parallel hybrid architectures.
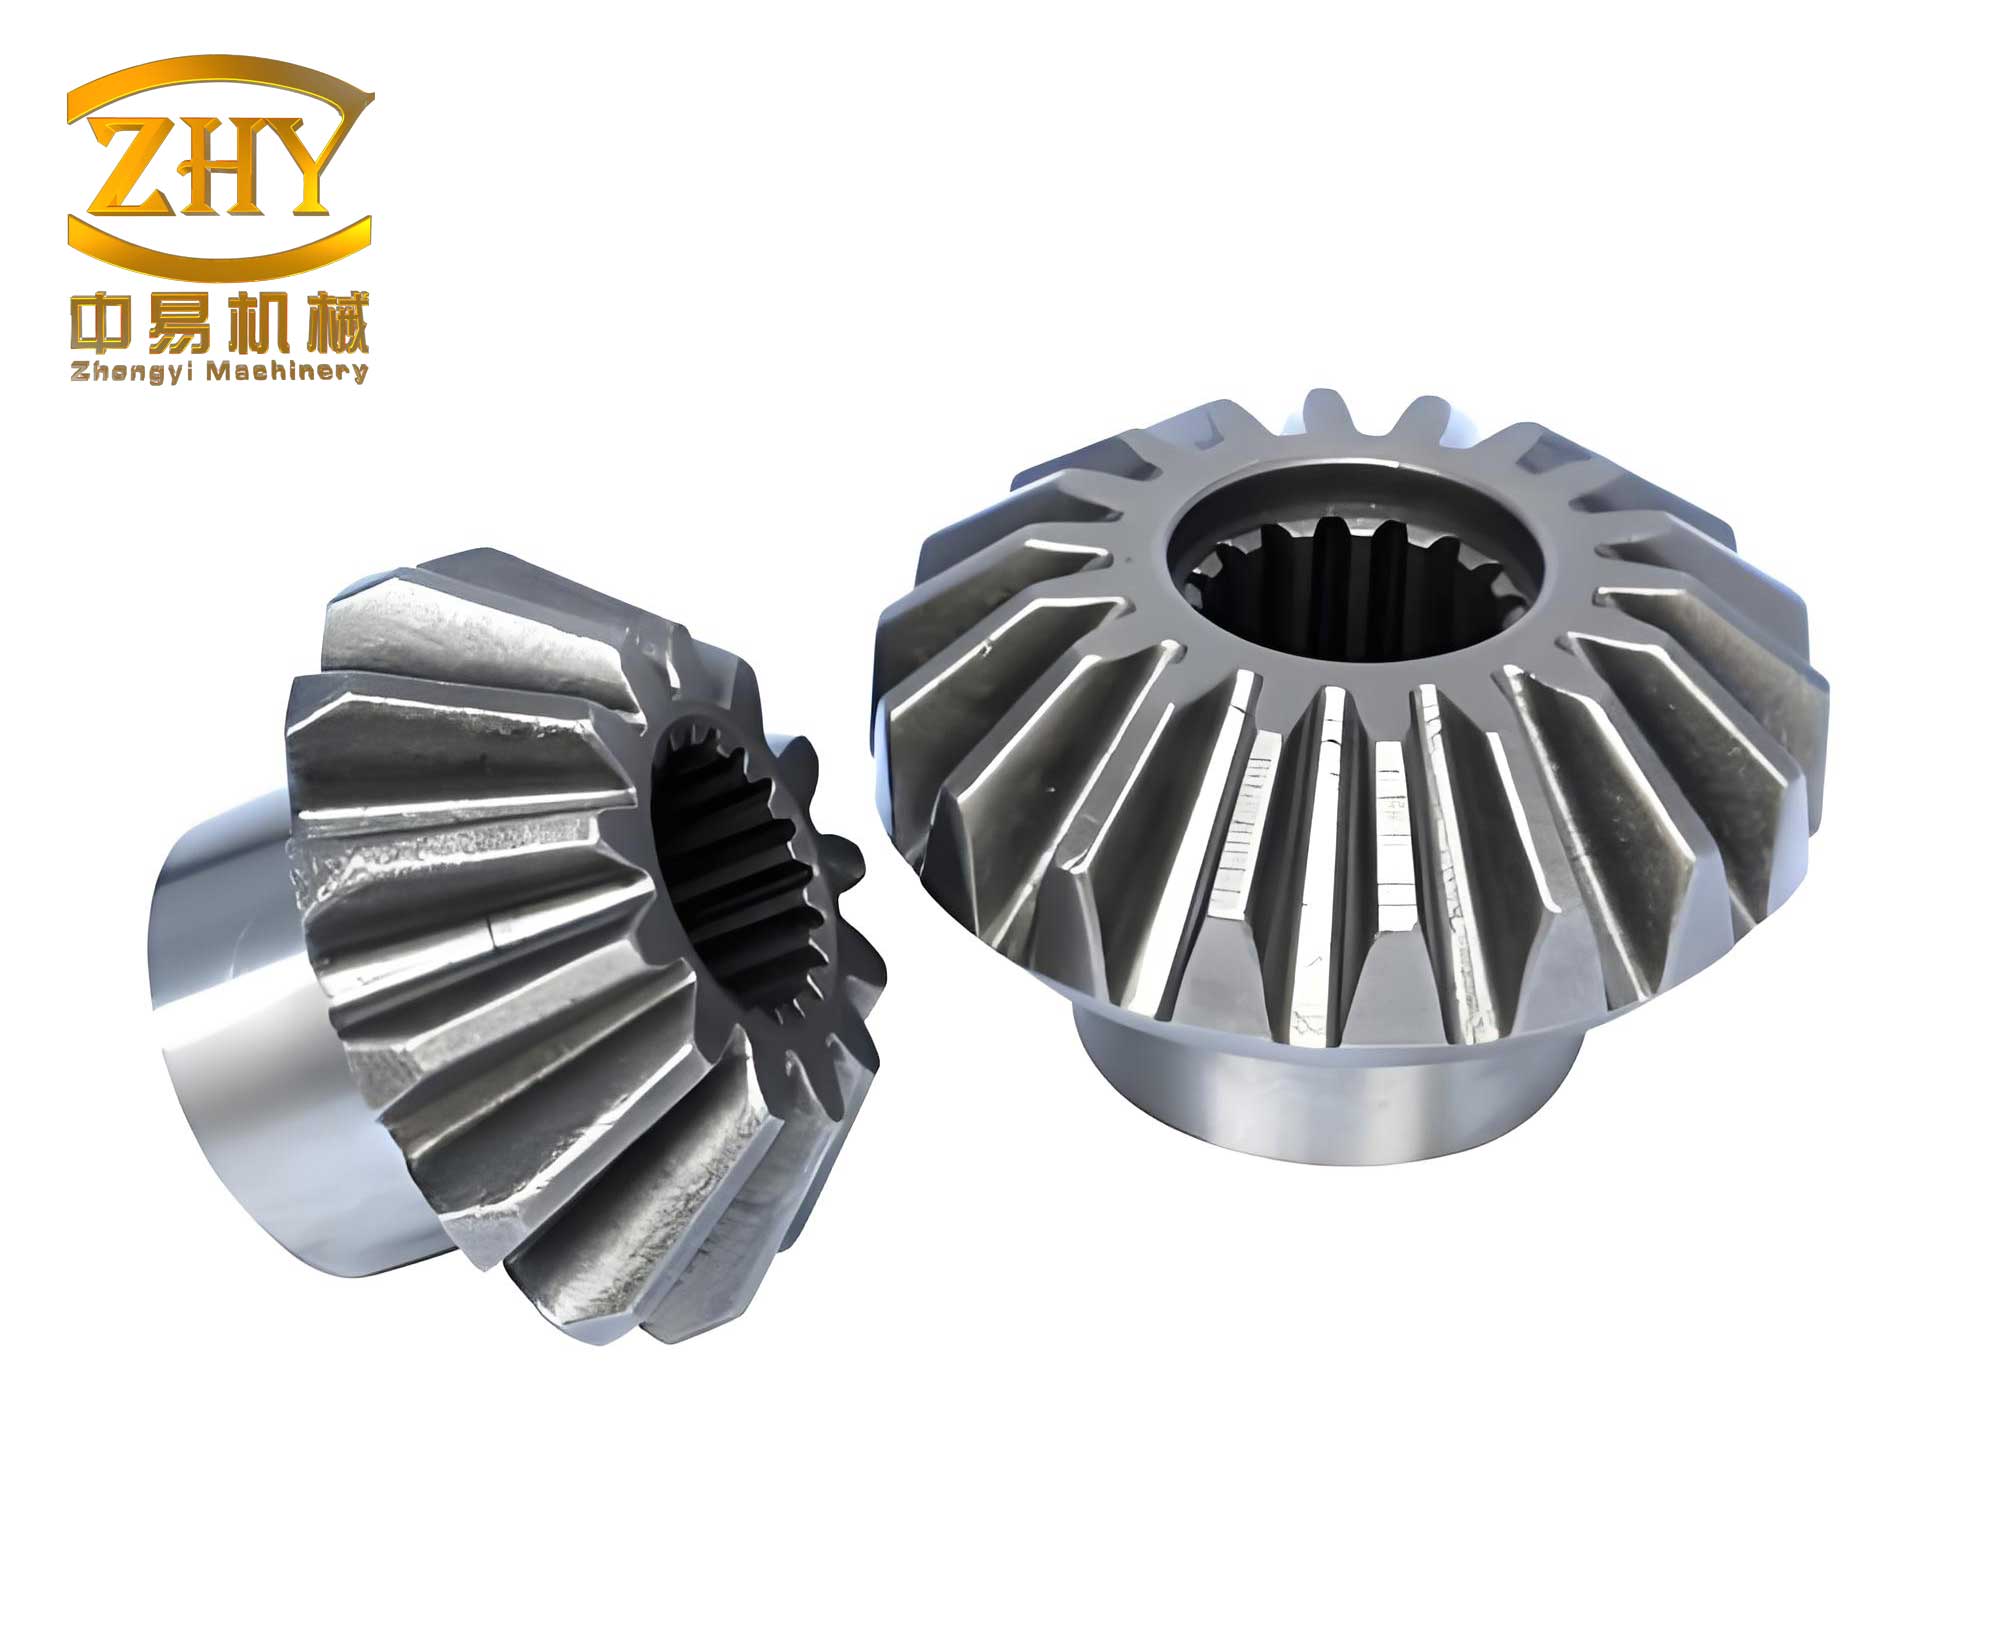
The fundamental appeal of using bevel gears as a coupling mechanism stems from their inherent mechanical simplicity and reliability. Compared to the intricate kinematics of a planetary gear set or the fluid-dependent operation of a hydraulic coupler, a system built around bevel gears offers a more straightforward power summation. The primary advantages include simplified manufacturing processes leading to lower production costs, reduced maintenance requirements due to the absence of sensitive hydraulic fluids or complex multi-path gear meshes, and superior environmental resilience. Mechanical systems based on bevel gears are less susceptible to performance degradation from temperature fluctuations, which can affect hydraulic fluid viscosity and pressure characteristics. This inherent robustness makes the bevel gears coupler a compelling candidate for automotive applications where durability and cost are paramount.
System Architecture and Operational Principles
The parallel HEV configuration under consideration employs a topology where the engine and the electric motor can both deliver torque directly to the vehicle’s driveline. The core of this topology is the bevel gear coupler. The system’s major components, as illustrated in the structural diagram, include the internal combustion engine (ICE), the electric motor/generator (EM), a traction battery, a multi-speed transmission, a final drive, and the central coupling device. The engine is connected to the coupler via a controllable clutch, which allows for the complete disconnection of the engine, enabling pure electric driving modes. The electric motor is directly coupled to one input of the coupler. The output of the coupler is directed towards the transmission and subsequently to the driven wheels.
The mechanical heart of this system is a set of three bevel gears arranged to allow two inputs and one output. In a typical implementation:
- Bevel Gear 1 is coaxially connected to the output shaft of the engine clutch.
- Bevel Gear 2 is coaxially connected to the rotor shaft of the electric motor.
- Bevel Gear 3 is coaxially connected to the input shaft of the transmission.
Gears 1 and 2 mesh with Gear 3, forming a simple yet effective torque-combining junction. This arrangement of bevel gears facilitates the key power flow paths necessary for hybrid operation. The clutch between the engine and Gear 1 is the critical enabler for mode transitions. Its engagement or disengagement, coordinated with the motor’s operation, allows the system to switch between various states, which are governed by a high-level Energy Management Strategy (EMS).
The predominant strategy adopted for this parallel architecture is the “Motor Assist” or “Electric Assist” strategy. In this paradigm, the internal combustion engine serves as the primary source of propulsion, ideally operating within its region of optimal fuel efficiency (often visualized as a Brake Specific Fuel Consumption map). The electric motor acts as a dynamic auxiliary source. Its primary functions are:
1. Torque “Fill-in”: Providing additional torque during high-power demand events (e.g., hard acceleration, hill climbing) to prevent the engine from operating inefficiently at high load points outside its optimum zone.
2. Torque “Shaving”: Absorbing excess engine torque during low-power demand or when the engine operates at a point more powerful than needed, using this energy to generate electricity and charge the battery.
3. Regenerative Braking: Acting as a generator during vehicle deceleration to convert kinetic energy into electrical energy, storing it in the battery.
4. Battery State of Charge (SOC) Sustenance: The motor’s actions are also modulated to maintain the battery’s SOC within a predetermined window (e.g., 40%-70%), ensuring energy availability and battery health.
Thus, the motor “assists” the engine by smoothing its load profile, leading to significant overall fuel savings and emission reductions. The coupler, through its bevel gears, is the physical entity where this “load leveling” mathematically manifests as the summation or subtraction of torques.
| Coupler Type | Key Components | Advantages | Disadvantages |
|---|---|---|---|
| Planetary Gear (e.g., Toyota THS) | Sun gear, planet carrier, ring gear | Continuous variable power-split, high efficiency in optimal range, compact. | Complex control strategy, high manufacturing precision required, power circulation losses possible. |
| Hydraulic Coupling | Pump, turbine, impeller, control valves, hydraulic fluid | Smooth torque transmission, vibration damping, can handle large speed differences. | Lower transmission efficiency, sensitive to fluid temperature/viscosity, requires pumps/reservoirs, potential for leaks. |
| Bevel Gear Coupler (This Work) | Input/Output Bevel Gears, Clutch | Mechanically simple & robust, low cost, high reliability, environmentally resilient, straightforward control logic. | Requires a clutch for mode switching, fixed gear ratio, no inherent torque multiplication/smoothing. |
Mathematical Modeling and Control System Design
The effectiveness of the motor assist strategy hinges entirely on the precise real-time control of the coupler’s input torques. This requires a well-defined mathematical model of the coupler’s dynamics, which serves as the foundation for the control algorithm implemented in the Vehicle Control Unit (VCU). The control system’s objective is to determine, at every moment, the required torque from the motor ($T_{R\_m}$) such that the engine operates desirably and the final output torque ($T_{O\_A}$) matches the driver’s demand ($T_{O\_R}$), which is derived from the accelerator pedal position and vehicle state.
The control logic flow can be described as follows, with the core equations governing the bevel gears coupler:
- Driver Demand Propagation: The total torque required at the wheels ($T_{wheel\_req}$) is calculated based on driving resistance (aerodynamic, rolling, gradient). This demand is translated back through the final drive ratio ($i_{fd}$) and the selected transmission gear ratio ($i_{gear}$) to find the required torque at the coupler’s output shaft (the transmission input):
$$ T_{O\_R} = \frac{T_{wheel\_req}}{i_{gear} \cdot i_{fd}} $$
Simultaneously, the required rotational speed at the coupler output is:
$$ n_{O\_R} = n_{wheel} \cdot i_{gear} \cdot i_{fd} $$ - Coupler Input Demand (Accounting for Losses): Power must be conserved, accounting for mechanical losses within the coupler itself (primarily gear mesh losses in the bevel gears). These losses are often modeled as a constant torque loss or a loss proportional to speed and load. For simplicity in control design, a constant loss torque ($T_{loss\_cp}$) can be assumed when power is flowing. Therefore, the total torque that must be provided to the coupler’s input side (from both engine and motor combined) is:
$$ T_{I\_R} = T_{O\_R} + T_{loss\_cp} $$
The input speed is equal to the output speed due to the rigid connection through the bevel gears:
$$ n_{I\_R} = n_{O\_R} $$ - Engine Torque Allocation: The high-level Energy Management Strategy (EMS) determines the target operating point for the engine ($T_{R\_eng}, n_{R\_eng}$) based on the driver’s power demand, battery SOC, and efficiency maps. The engine controller and clutch actuator work to deliver this as the actual engine torque at the coupler input ($T_{A\_f}$). The actual engine speed at the coupler ($n_{A\_f}$) is essentially the same as the target if the clutch is engaged.
- Motor Torque Command Calculation: This is the pivotal control action. The torque that the engine cannot or should not provide to meet $T_{I\_R}$ is assigned to the motor. The required motor torque, reflected to its own shaft (considering the gear ratio $K_{mf}$ between the motor shaft and the engine/motor input shafts at the bevel gears), is:
$$ T_{R\_m} = (T_{I\_R} – T_{A\_f}) \times K_{mf} $$
A positive $T_{R\_m}$ indicates motoring (assisting), while a negative value indicates generating (charging). The required motor speed is dictated by the kinematics of the bevel gears. Since the motor’s bevel gear and the engine’s bevel gear must rotate at the same speed as the output bevel gear (Gear 3) when connected, the motor speed command is:
$$ n_{R\_m} = n_{O\_R} \times K_{mf} $$
In practice, a minimum function is used to ensure the command does not exceed physical limits of either source: $n_{R\_m} = min(n_{A\_f}, n_{O\_R}) \times K_{mf}$. - Actual Coupler Output: The final torque delivered to the transmission is the sum of the actual motor torque (converted via the gear ratio) and the actual engine torque, minus the coupler losses:
$$ T_{O\_A} = (T_{A\_m} \times \frac{1}{K_{mf}}) + T_{A\_f} – T_{loss\_cp} $$
Where $T_{A\_m}$ is the actual torque produced by the motor. This $T_{O\_A}$ should ideally equal $T_{O\_R}$, validating the control action.
This mathematical framework translates directly into a control system block diagram. The VCU continuously executes this algorithm: it samples the driver demand and vehicle state, calculates $T_{O\_R}$, determines the optimal $T_{A\_f}$ from the EMS, computes the required $T_{R\_m}$ using the equation above, and sends commands to the Engine Control Unit (ECU), Motor Controller (MCU), and Clutch Actuator. The simplicity of the torque summation equation, a direct result of the fixed-ratio bevel gears geometry, leads to a correspondingly straightforward and computationally efficient control algorithm compared to the more complex optimization required for power-split planetary systems.
Simulation Model Development and Analysis
To validate the proposed control strategy for the bevel gears coupler, a simulation model is developed in the MATLAB/Simulink environment. The model implements the mathematical relationships described in the previous section. The simulation is driven by a standard urban driving cycle (e.g., the data from the referenced study: duration 1369s, distance 11.99 km, average speed 31.51 km/h), which provides the time-varying vehicle speed profile from which the wheel torque demand $T_{wheel\_req}$ is derived using a backward-facing vehicle dynamics model.
The key parameters for the simulation, based on a representative parallel HEV, are summarized in the table below:
| Parameter | Symbol | Value / Specification |
|---|---|---|
| Vehicle Mass | $m$ | 1500 kg |
| Engine Peak Power/Torque | $P_{eng}$ / $T_{eng}$ | 70 kW / 130 Nm |
| Motor Peak Power/Torque | $P_{mot}$ / $T_{mot}$ | 30 kW / 180 Nm |
| Battery Capacity | $Q_{bat}$ | 5 Ah (Li-ion) |
| Final Drive Ratio | $i_{fd}$ | 4.1 |
| Gear Ratios (5-speed) | $i_{gear}$ | [3.5, 2.0, 1.4, 1.0, 0.8] |
| Bevel Gears Ratio (Motor to Output) | $K_{mf}$ | 1.0 (for simplicity, but can be other values) |
| Coupler Constant Loss Torque | $T_{loss\_cp}$ | 5 Nm |
The simulation results provide clear, time-domain traces of the torque flows, vividly illustrating the “motor assist” strategy in action facilitated by the bevel gears coupler. Analysis of the plots reveals several key operational regimes:
1. Electric Launch and Low-Speed Assist: At vehicle launch (t=0s), the driver’s torque demand is high to overcome inertia. The EMS may decide to keep the engine off or at idle to avoid inefficient low-load operation. The entire demanded torque at the coupler output ($T_{O\_R}$) is supplied by the electric motor via the bevel gears. The motor provides its peak torque of 180 Nm, which, after accounting for driveline ratios, results in strong initial acceleration. This demonstrates the coupler’s ability to support pure electric drive when the clutch is disengaged.
2. Hybrid Acceleration and Torque Fill-in: During periods of moderate to high acceleration (e.g., between t=20s and t=40s in a typical cycle), the engine is engaged and operates at a efficient medium-load point. However, the driver’s demand $T_{I\_R}$ exceeds this chosen engine torque $T_{A\_f}$. The difference is precisely calculated by the controller. The motor instantly provides positive torque (motoring) to fill this gap: $T_{R\_m} = (T_{I\_R} – T_{A\_f}) > 0$. This positive torque from the motor is combined with the engine torque at the bevel gears, ensuring the vehicle meets the performance demand while the engine remains in its efficient zone.
3. Steady-State Cruising and Battery Charging: During steady-speed cruising, the engine often produces more power than is strictly needed to maintain speed. The EMS can command the engine to operate at a point with good efficiency that provides excess torque. This excess is used to charge the battery. In this regime, $T_{I\_R}$ (the torque needed just to maintain speed) is less than $T_{A\_f}$. The control calculation yields a negative $T_{R\_m}$: $T_{R\_m} = (T_{I\_R} – T_{A\_f}) < 0$. The motor acts as a generator, absorbing mechanical power from the engine through the bevel gears. This mechanical power is converted to electricity, and the reaction torque from the generator loads the engine appropriately. This is clearly seen in simulation plots where motor torque dips negative while engine torque remains positive.
4. Regenerative Braking: During deceleration events, the driver’s demand $T_{O\_R}$ becomes negative (a braking request). The engine clutch is typically disengaged. The controller sets $T_{A\_f} = 0$. The required $T_{I\_R}$ is also negative (including the loss term). The motor command becomes: $T_{R\_m} = (T_{I\_R} – 0) < 0$. The motor operates strongly as a generator, using the vehicle’s kinetic energy, transmitted backward through the driveline and the bevel gears, to produce electricity and provide braking torque. This energy is stored in the battery, improving overall efficiency.
5. Validation of Torque Summation: The most critical verification is the comparison between the coupler’s required output torque $T_{O\_R}$ (from the driver) and its actual output torque $T_{O\_A}$ (from the sum of engine and motor inputs, minus loss). The simulation results show that these two traces are virtually identical throughout the driving cycle. This confirms that the control law governing the bevel gears coupler—$T_{O\_A} = T_{A\_m}/K_{mf} + T_{A\_f} – T_{loss\_cp}$—is correctly implemented and that the system successfully meets the driver’s demand under all conditions. The slight time delays or very minor discrepancies are attributable to actuator dynamics and controller sample times modeled in the simulation.
The following formula summarizes the power balance at the bevel gears coupler during generating mode, highlighting the energy flow:
$$ P_{engine} = P_{driveline} + P_{loss\_cp} + P_{motor/gen} $$
$$ (T_{A\_f} \cdot \omega) = (T_{O\_A} \cdot \omega) + (T_{loss\_cp} \cdot \omega) + (T_{A\_m} \cdot \omega_m) $$
Where $\omega$ is the angular speed at the coupler’s output/engine input shafts, and $\omega_m = \omega \cdot K_{mf}$ is the motor angular speed. When $P_{motor/gen}$ is negative, power flows from the engine, through the bevel gears, to the motor acting as a generator.
Conclusions and Future Perspectives
The analysis and simulation presented substantiate the viability and effectiveness of a bevel gears-based coupler for parallel hybrid electric vehicles. The primary conclusions are:
- Mechanical and Control Simplicity: The bevel gears coupler offers a fundamentally simpler mechanical architecture compared to planetary gear systems or hydraulic couplings. This mechanical simplicity propagates into the control domain. The core control algorithm is essentially a direct torque summation/subtraction, making it computationally lightweight, fast, and deterministic. This contrasts with the complex optimization and continuous variable control required for power-split devices.
- Effective Strategy Implementation: The proposed motor-assist control strategy, when executed through the mathematical model of the bevel gears coupler, successfully manages the power flows between the engine, motor, and driveline. It enables all essential HEV modes: electric launch, engine-alone driving, hybrid boost, regenerative braking, and on-the-fly battery charging. The simulation based on an urban driving cycle confirms that the driver’s torque demand is consistently met ($T_{O\_A} \approx T_{O\_R}$) while the engine operates in more efficient regions due to the motor’s “fill-in” and “shaving” actions.
- Robustness and Cost-Effectiveness: The reliance on proven bevel gears technology and a dry or wet clutch leads to a system with high inherent reliability and durability. It is less sensitive to environmental factors like temperature, which is a known challenge for hydraulic systems. The anticipated lower manufacturing and maintenance costs make this architecture particularly attractive for cost-sensitive market segments or applications where extreme robustness is valued.
The design parameters extracted from such dynamic simulations—such as the required torque capacity of the bevel gears, the clutch engagement speed profiles, and the motor torque response times—provide invaluable data for the physical design and component selection in a real-world implementation.
Future work on this architecture could explore several avenues. The integration of a more sophisticated, predictive Energy Management Strategy (e.g., using route data or traffic information) would further optimize the torque allocation commands sent to the coupler’s control layer. The physical design of the bevel gears set, including tooth geometry optimization for noise, vibration, and harshness (NVH) reduction and efficiency maximization under highly variable load conditions, is a critical area of mechanical research. Furthermore, the potential of using a dual-clutch system or a dog clutch in conjunction with the bevel gears to enable even faster and smoother mode transitions without torque interruption could be investigated. Ultimately, the bevel gears coupler stands as a compelling testament to the principle that elegant, simple mechanical solutions, when paired with intelligent control, can effectively address the complex challenges of modern hybrid vehicle propulsion.