
In the field of mechanical transmission, screw gears represent a critical and widely utilized form of gearing, particularly in applications requiring high torque and compact design. Traditional screw gears, often referred to as worm drives, exhibit distinct characteristics such as high load-carrying capacity. However, they are plagued by significant drawbacks, including excessive sliding friction and inherent backlash. Excessive sliding friction leads to numerous issues like severe wear, low transmission efficiency, overheating, and potential seizure or scoring. Backlash, on the other hand, introduces positional error or hysteresis, rendering traditional screw gears unsuitable for high-precision applications such as indexing devices in precision machine tools or robotic systems. Therefore, the development of novel screw gear configurations that mitigate or eliminate these drawbacks holds substantial theoretical and practical importance.
To address the issue of excessive sliding friction in conventional screw gears, numerous researchers have explored various solutions and proposed new gear forms. Primary approaches include: improving lubrication with advanced coatings or oils to reduce frictional losses; fundamentally replacing sliding contact with rolling contact through innovative designs; and modifying tooth profiles based on gear meshing principles to minimize sliding. Among these, the development of new screw gear types that incorporate rolling elements to substitute sliding friction has proven particularly effective. Notable examples include cylindrical roller enveloping screw gears, conical roller enveloping screw gears, and ball screw gears, along with their derivatives. These designs often feature rollers or balls as the gear teeth, transforming the contact interface from sliding to rolling, thereby enhancing efficiency and reducing wear. However, many such designs involve complex structures that are challenging to manufacture and assemble. Furthermore, the issue of backlash remains a critical concern for precision applications. Various anti-backlash mechanisms have been proposed, including split gear adjustment, dual-lead screws, and dual-worm or dual-gear arrangements. These methods often increase complexity or reduce spatial efficiency.
In this work, we propose and analyze a novel configuration termed the Parallel Inclined Double Roller Enveloping Screw Gears. This design is derived from modifications to single-roller enveloping hourglass worm drives and incorporates concepts from backlash-free double-roller designs. The primary innovation lies in the use of two parallel, inclined rollers as the gear teeth on the driven member (referred to as the gear or wheel), which engage with a single, integrated screw (referred to as the worm or screw). This arrangement aims to achieve multiple-tooth contact for high load capacity, reduce sliding friction via rolling contact, improve lubrication conditions, and offer potential for backlash adjustment or elimination. The inclined placement of the rollers enhances key meshing performance parameters. In this analysis, we will establish the fundamental mathematical model, derive the meshing equations and performance characteristics, and evaluate the meshing performance of this novel screw gear system. The term “screw gears” is used here to emphasize the generalized gear pair involving a screw-like driver and a geared wheel, encompassing various worm and helical gear interactions.
The basic operating principle of the Parallel Inclined Double Roller Enveloping Screw Gears is illustrated conceptually. The transmission pair consists primarily of a single, integrated screw (worm) and a gear (wheel). The central plane of the gear coincides with that of the screw. Motion or power is input through the screw and output from the gear. The gear teeth are comprised of two parallel rollers that can rotate about their own axes. These rollers are mounted on the gear body with their axes inclined at a specific angle, denoted by $\gamma$, relative to the radial direction of the gear. This inclination angle is crucial for improving meshing performance. During operation, contact occurs on one side of the roller with the corresponding flank of the screw thread at any given instant. The use of rollers converts the interfacial contact from sliding to rolling friction, thereby reducing friction losses and increasing transmission efficiency. The parallel arrangement allows for a more compact design compared to staggered configurations, and the inclination can be optimized to enhance parameters like the lubrication angle and self-rotation angle.
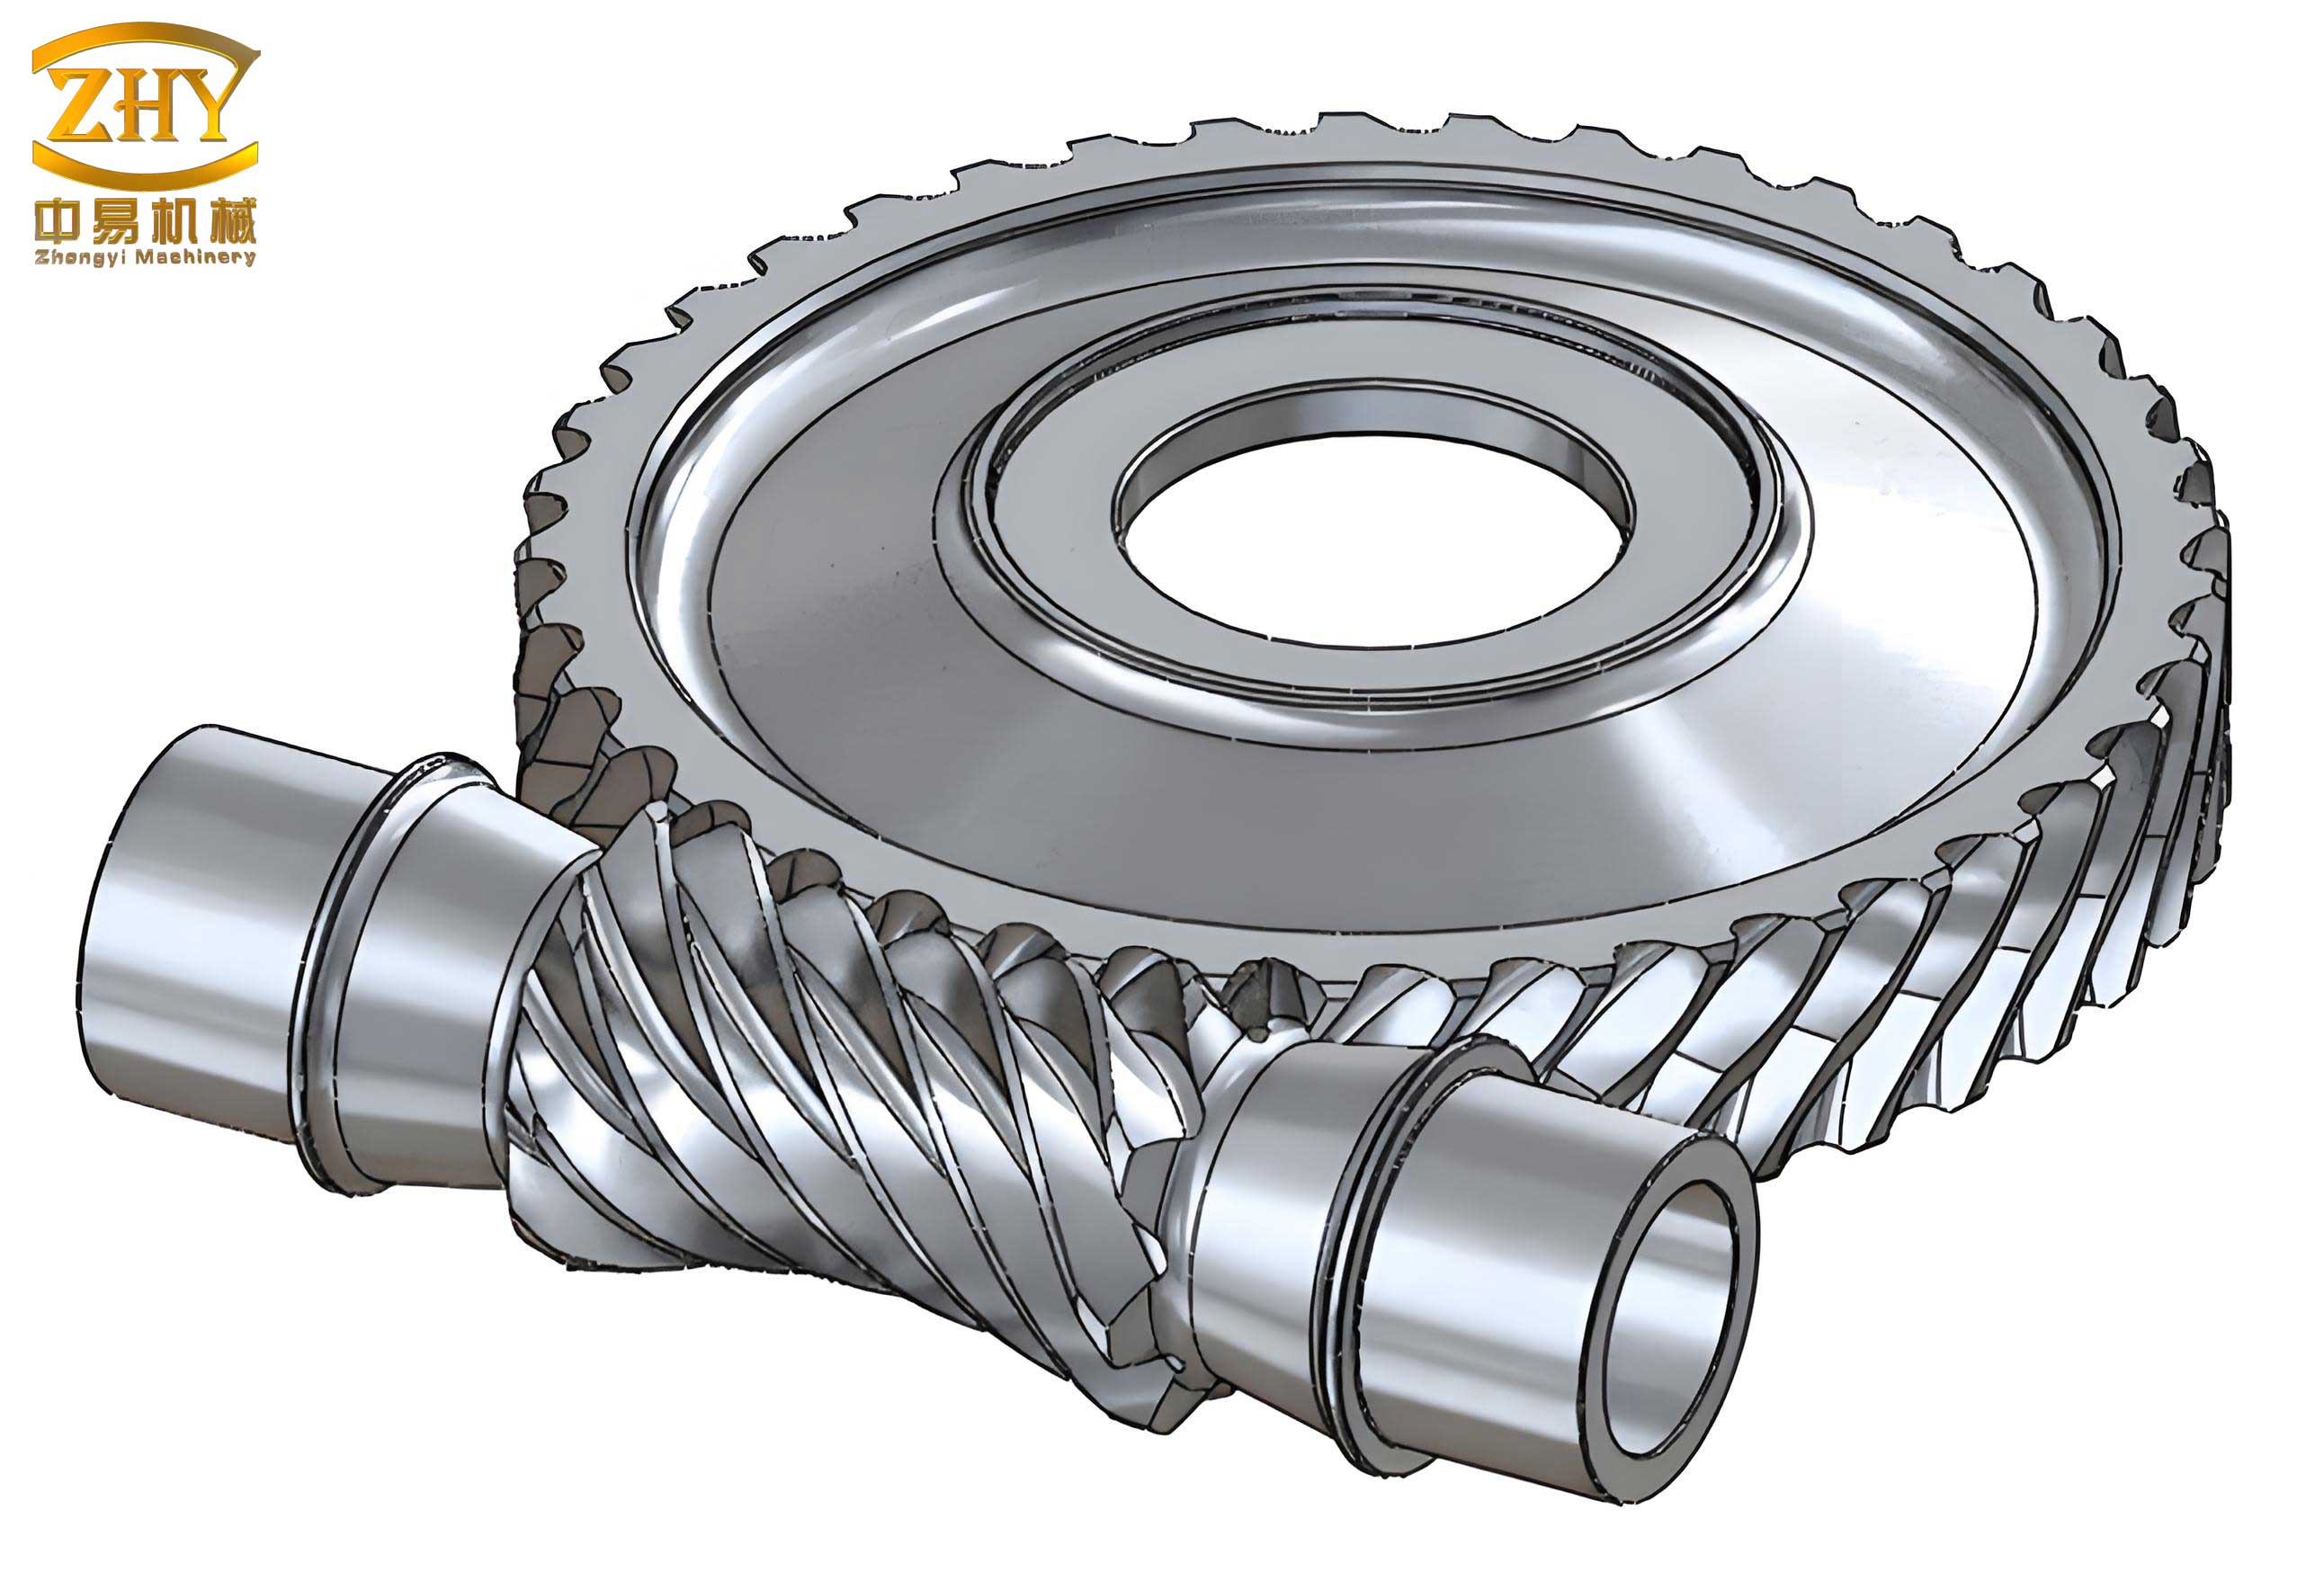
The gear tooth structure, utilizing two parallel rollers, can be implemented with a needle roller bearing assembly. This replaces simple sliding contact within the roller assembly itself with rolling contact, further improving the self-rotation performance of the rollers and reducing the use of non-ferrous metals typically required for worm wheels. This design contributes to the durability and efficiency of the screw gears.
To analyze the meshing theory of these screw gears, we establish a comprehensive mathematical model based on differential geometry, spatial gear meshing theory, and the generating principle of roller enveloping screw gears. We define several coordinate systems to describe the kinematics and geometry.
Let $S_1′ (O_1′; \mathbf{i}_1′, \mathbf{j}_1′, \mathbf{k}_1′)$ be the fixed coordinate system attached to the screw (worm), and $S_2′ (O_2′; \mathbf{i}_2′, \mathbf{j}_2′, \mathbf{k}_2′)$ be the fixed coordinate system attached to the gear (wheel). The moving coordinate systems attached to the screw and gear are $S_1 (O_1; \mathbf{i}_1, \mathbf{j}_1, \mathbf{k}_1)$ and $S_2 (O_2; \mathbf{i}_2, \mathbf{j}_2, \mathbf{k}_2)$, respectively. At the centers of the roller ends (top centers) for the right and left rollers, we attach coordinate systems $S_{0r} (O_{0r}; \mathbf{i}_{0r}, \mathbf{j}_{0r}, \mathbf{k}_{0r})$ and $S_{0l} (O_{0l}; \mathbf{i}_{0l}, \mathbf{j}_{0l}, \mathbf{k}_{0l})$, fixed to the gear. The positions of $O_{0r}$ and $O_{0l}$ in $S_2$ are given by $(a_{2r}, b_{2r}, 0)$ and $(a_{2l}, b_{2l}, 0)$, respectively. The central distance between the screw and gear axes is $A$. The rotation angles of the screw and gear are $\phi_1$ and $\phi_2$, related by the transmission ratio $i_{12} = \phi_1 / \phi_2 = \omega_1 / \omega_2 = z_2 / z_1$, where $z_1$ and $z_2$ are the number of threads on the screw and teeth on the gear, respectively. The inclination angle of the roller axis relative to the line connecting the gear center and the roller center (or a radial line) is $\gamma$. A positive $\gamma$ indicates inclination towards one side. At the initial position, the fixed and moving coordinate systems coincide, i.e., $\phi_1 = \phi_2 = 0$. Moving frames (or Darboux frames) are established at the contact points on the right and left rollers: $S_{pr} (O_{pr}; \mathbf{e}_{1r}, \mathbf{e}_{2r}, \mathbf{n}_r)$ and $S_{pl} (O_{pl}; \mathbf{e}_{1l}, \mathbf{e}_{2l}, \mathbf{n}_l)$, where $\mathbf{n}$ is the unit normal to the roller surface at the contact point.
The parametric equations for the cylindrical roller surfaces in their respective local frames $S_{0r}$ and $S_{0l}$ are:
For the right roller:
$$\mathbf{r}_{0r} = x_{0r} \mathbf{i}_{0r} + y_{0r} \mathbf{j}_{0r} + z_{0r} \mathbf{k}_{0r}, \quad \text{with} \quad x_{0r} = R \cos \theta_r, \quad y_{0r} = R \sin \theta_r, \quad z_{0r} = u_r.$$
For the left roller:
$$\mathbf{r}_{0l} = x_{0l} \mathbf{i}_{0l} + y_{0l} \mathbf{j}_{0l} + z_{0l} \mathbf{k}_{0l}, \quad \text{with} \quad x_{0l} = R \cos \theta_l, \quad y_{0l} = R \sin \theta_l, \quad z_{0l} = u_l.$$
Here, $R$ is the radius of the rollers, $u_r, u_l$ are axial parameters, and $\theta_r, \theta_l$ are angular parameters defining a point on the cylinder.
The coordinate transformations between these systems are essential for analysis. The transformation from the screw moving frame $S_1$ to its fixed frame $S_1’$ involves a rotation about its axis by $\phi_1$:
$$
\mathbf{B}_{1′} = \mathbf{M}_{1’1} \mathbf{B}_1, \quad \text{where} \quad \mathbf{M}_{1’1} =
\begin{bmatrix}
\cos \phi_1 & -\sin \phi_1 & 0 & 0 \\
\sin \phi_1 & \cos \phi_1 & 0 & 0 \\
0 & 0 & 1 & 0 \\
0 & 0 & 0 & 1
\end{bmatrix}.
$$
Similarly, for the gear:
$$
\mathbf{B}_{2′} = \mathbf{M}_{2’2} \mathbf{B}_2, \quad \text{with} \quad \mathbf{M}_{2’2} =
\begin{bmatrix}
\cos \phi_2 & -\sin \phi_2 & 0 & 0 \\
\sin \phi_2 & \cos \phi_2 & 0 & 0 \\
0 & 0 & 1 & 0 \\
0 & 0 & 0 & 1
\end{bmatrix}.
$$
The transformation from the screw moving frame $S_1$ to the gear moving frame $S_2$ is derived through intermediate steps and is given by:
$$
\mathbf{B}_2 = \mathbf{M}_{21} \mathbf{B}_1, \quad \text{with} \quad \mathbf{M}_{21} =
\begin{bmatrix}
a_{11} & a_{12} & a_{13} & a_{14} \\
a_{21} & a_{22} & a_{23} & a_{24} \\
a_{31} & a_{32} & 0 & 0 \\
0 & 0 & 0 & 1
\end{bmatrix},
$$
where
$$
\begin{aligned}
a_{11} &= -\cos \phi_1 \cos \phi_2, \quad a_{21} = \cos \phi_1 \sin \phi_2, \quad a_{31} = -\sin \phi_1, \\
a_{12} &= \sin \phi_1 \cos \phi_2, \quad a_{22} = -\sin \phi_1 \sin \phi_2, \quad a_{32} = -\cos \phi_1, \\
a_{13} &= -\sin \phi_2, \quad a_{23} = -\cos \phi_2, \quad a_{14} = A \cos \phi_2, \quad a_{24} = -A \sin \phi_2.
\end{aligned}
$$
The transformations from the gear frame $S_2$ to the moving frames on the rollers $S_{pr}$ and $S_{pl}$ involve rotations accounting for the inclination angle $\gamma$ and the roller angular position $\theta$. For the right roller contact frame:
$$
\mathbf{S}_{pr} = \mathbf{A}_{pr2} \mathbf{S}_2, \quad \text{with} \quad \mathbf{A}_{pr2} =
\begin{bmatrix}
a_{pr211} & a_{pr212} & a_{pr213} \\
a_{pr221} & a_{pr222} & a_{pr223} \\
a_{pr231} & a_{pr232} & a_{pr233}
\end{bmatrix},
$$
where
$$
\begin{aligned}
a_{pr211} &= -\sin \gamma \cos \theta_r, \quad a_{pr221} = -\sin \gamma, \quad a_{pr231} = -\sin \gamma \sin \theta_r, \\
a_{pr212} &= \cos \gamma \cos \theta_r, \quad a_{pr222} = -\sin \gamma, \quad a_{pr232} = \cos \gamma \sin \theta_r, \\
a_{pr213} &= -\sin \theta_r, \quad a_{pr223} = 0, \quad a_{pr233} = \cos \theta_r.
\end{aligned}
$$
For the left roller contact frame, a similar matrix $\mathbf{A}_{pl2}$ exists with $\theta_l$ replacing $\theta_r$.
To derive the meshing conditions, we need the relative velocity and relative angular velocity at the contact points. Let $\boldsymbol{\omega}_1$ and $\boldsymbol{\omega}_2$ be the angular velocity vectors of the screw and gear, respectively. Assuming the screw rotates with unit angular speed $\omega_1 = 1$ (for generality), we have:
$$
\boldsymbol{\omega}_1 = -\sin \phi_2 \, \mathbf{i}_2 – \cos \phi_2 \, \mathbf{j}_2, \quad \boldsymbol{\omega}_2 = i_{21} \, \mathbf{k}_2,
$$
where $i_{21} = \omega_2 / \omega_1 = 1 / i_{12}$ is the speed ratio from gear to screw. The relative angular velocity is:
$$
\boldsymbol{\omega}_{12} = \boldsymbol{\omega}_1 – \boldsymbol{\omega}_2 = -\sin \phi_2 \, \mathbf{i}_2 – \cos \phi_2 \, \mathbf{j}_2 – i_{21} \, \mathbf{k}_2.
$$
The position vectors of the contact points in the gear frame $S_2$ are obtained by transforming the roller surface equations and accounting for the inclination. For the right roller contact point:
$$
\mathbf{r}_{2r} = x_{2r} \mathbf{i}_2 + y_{2r} \mathbf{j}_2 + z_{2r} \mathbf{k}_2,
$$
with
$$
\begin{aligned}
x_{2r} &= a_{2r} – y_{0r} \sin \gamma – z_{0r} \cos \gamma, \\
y_{2r} &= b_{2r} + y_{0r} \cos \gamma – z_{0r} \sin \gamma, \\
z_{2r} &= x_{0r} = R \cos \theta_r.
\end{aligned}
$$
Similarly, for the left roller contact point:
$$
\mathbf{r}_{2l} = x_{2l} \mathbf{i}_2 + y_{2l} \mathbf{j}_2 + z_{2l} \mathbf{k}_2,
$$
with
$$
\begin{aligned}
x_{2l} &= a_{2l} – y_{0l} \sin \gamma – z_{0l} \cos \gamma, \\
y_{2l} &= b_{2l} + y_{0l} \cos \gamma – z_{0l} \sin \gamma, \\
z_{2l} &= x_{0l} = R \cos \theta_l.
\end{aligned}
$$
The vector from the gear center to the screw center in $S_2$ is $\boldsymbol{\xi} = A \cos \phi_2 \, \mathbf{i}_2 – A \sin \phi_2 \, \mathbf{j}_2$. The relative velocity at the contact point, considering the gear frame, is given by $\mathbf{v}_{12} = \dot{\boldsymbol{\xi}} + \boldsymbol{\omega}_{12} \times \mathbf{r}_1 – \boldsymbol{\omega}_2 \times \boldsymbol{\xi}$. Since $A$ is constant, $\dot{\boldsymbol{\xi}} = \mathbf{0}$. After vector operations and transformations, the relative velocity components in the moving frames $S_{pr}$ and $S_{pl}$ can be derived. For the right contact:
$$
\mathbf{v}_{12r} = v_{12r1} \mathbf{e}_{1r} + v_{12r2} \mathbf{e}_{2r} + v_{12rn} \mathbf{n}_r,
$$
with
$$
\begin{aligned}
v_{12r1} &= -B_{3r} \sin \theta_r + B_{2r} \cos \gamma \cos \theta_r – B_{1r} \sin \gamma \cos \theta_r, \\
v_{12r2} &= -B_{1r} \cos \gamma – B_{2r} \sin \gamma, \\
v_{12rn} &= B_{2r} \cos \gamma \sin \theta_r + B_{3r} \cos \theta_r – B_{1r} \sin \gamma \sin \theta_r,
\end{aligned}
$$
where
$$
\begin{aligned}
B_{1r} &= y_{2r} i_{21} – z_{2r} \cos \phi_2, \\
B_{2r} &= -x_{2r} i_{21} + z_{2r} \sin \phi_2, \\
B_{3r} &= x_{2r} \cos \phi_2 – y_{2r} \sin \phi_2 – A.
\end{aligned}
$$
For the left contact, analogous expressions hold with subscript $l$ replacing $r$.
The relative angular velocity components in the moving frames are also needed. For the right side:
$$
\boldsymbol{\omega}_{12} = \omega_{121r} \mathbf{e}_{1r} + \omega_{122r} \mathbf{e}_{2r} + \omega_{12}^{nr} \mathbf{n}_r,
$$
with
$$
\begin{aligned}
\omega_{121r} &= i_{21} \sin \theta_r – \cos \gamma \cos \phi_2 \cos \theta_r + \sin \gamma \cos \theta_r \sin \phi_2, \\
\omega_{122r} &= \sin \gamma \cos \phi_2 + \cos \gamma \sin \phi_2, \\
\omega_{12}^{nr} &= \sin \gamma \sin \theta_r \sin \phi_2 – i_{21} \cos \theta_r – \cos \gamma \cos \phi_2 \sin \theta_r.
\end{aligned}
$$
Similar expressions apply for the left side.
The fundamental condition for contact (meshing) between two surfaces is that the relative velocity has no component along the common normal at the contact point, i.e., $\mathbf{v}_{12} \cdot \mathbf{n} = 0$. This leads to the meshing functions and equations. For the right roller contact:
$$
\Phi_r = v_{12rn} = M_{1r} \cos \phi_2 + M_{2r} \sin \phi_2 + M_{3r} = 0,
$$
where
$$
\begin{aligned}
M_{1r} &= a_{2r} \cos \theta_r – u_r \cos \gamma \cos \theta_r, \\
M_{2r} &= u_r \sin \gamma \cos \theta_r – b_{2r} \cos \theta_r, \\
M_{3r} &= i_{21} u_r \sin \theta_r – A \cos \theta_r – b_{2r} i_{21} \sin \gamma \sin \theta_r – a_{2r} i_{21} \cos \gamma \sin \theta_r.
\end{aligned}
$$
For the left roller contact:
$$
\Phi_l = v_{12ln} = M_{1l} \cos \phi_2 + M_{2l} \sin \phi_2 + M_{3l} = 0,
$$
with similar coefficients $M_{1l}, M_{2l}, M_{3l}$ involving $a_{2l}, b_{2l}, u_l, \theta_l$.
These meshing equations define the relationship between the surface parameters $(u, \theta)$ and the gear rotation angle $\phi_2$ for which contact occurs. They are essential for determining the contact lines and the generated screw thread surface.
The contact lines on the roller surfaces are the sets of points that satisfy the meshing equation for a fixed value of $\phi_2$. For a given $\phi_2$, the contact line on the right roller is given by the cylinder equation and the meshing condition:
$$
\mathbf{r}_{0r} = R \cos \theta_r \mathbf{i}_{0r} + R \sin \theta_r \mathbf{j}_{0r} + u_r \mathbf{k}_{0r}, \quad \text{with} \quad u_r = f(\theta_r, \phi_2) = \frac{P_{3r}}{P_{4r}},
$$
where
$$
\begin{aligned}
P_{3r} &= b_{2r} \sin \phi_2 \cos \theta_r + b_{2r} i_{21} \sin \gamma \sin \theta_r + a_{2r} i_{21} \cos \gamma \sin \theta_r + A \cos \theta_r – a_{2r} \cos \phi_2 \cos \theta_r, \\
P_{4r} &= \sin \gamma \sin \phi_2 \cos \theta_r + i_{21} \sin \theta_r – \cos \gamma \cos \phi_2 \cos \theta_r.
\end{aligned}
$$
A similar equation holds for the left roller. Typically, for the right flank contact, $\theta_r \in [-\pi, 0]$, and for the left flank contact, $\theta_l \in [0, \pi]$. The contact lines on the roller surfaces, when developed onto a plane, appear as slightly curved lines. They are denser near the central region (throat) of the screw and shorter near the entry and exit zones, indicating a favorable load distribution.
The surface of the screw thread is generated as the envelope of the family of roller surfaces as the gear rotates. The screw thread surface equations are obtained by transforming the contact point coordinates from the gear system to the screw system. For the right flank:
$$
\mathbf{r}_{1r} = x_{1r} \mathbf{i}_1 + y_{1r} \mathbf{j}_1 + z_{1r} \mathbf{k}_1,
$$
with
$$
\begin{aligned}
x_{1r} &= y_{2r} \cos \phi_1 \sin \phi_2 – x_{2r} \cos \phi_1 \cos \phi_2 – z_{2r} \sin \phi_1 + A \cos \phi_1, \\
y_{1r} &= x_{2r} \sin \phi_1 \cos \phi_2 – y_{2r} \sin \phi_1 \sin \phi_2 – z_{2r} \cos \phi_1 – A \sin \phi_1, \\
z_{1r} &= -x_{2r} \sin \phi_2 – y_{2r} \cos \phi_2,
\end{aligned}
$$
where $x_{2r}, y_{2r}, z_{2r}$ are functions of $u_r$ and $\theta_r$, and $u_r$ is determined by the meshing condition $u_r = f(\theta_r, \phi_2)$, with $\phi_2$ varying over the engagement range, typically $\phi_2 \in [-\pi/5, \pi/5]$ for a single pair of rollers. A similar set of equations defines the left flank of the screw thread. These equations describe the complete geometry of the novel screw gears.
To evaluate the performance of these screw gears, we analyze key meshing characteristics: induced normal curvature, lubrication angle, self-rotation angle, and relative entrainment velocity. These parameters are derived using the moving frame method and differential geometry.
The induced normal curvature along the contact line direction is a measure of the local conformity between the screw and roller surfaces. For the right contact, it is given by:
$$
k_{12}^{\sigma r} = -k_{21}^{\sigma r} = -\frac{ \left( \dfrac{v_{12r1}}{R} – \omega_{122r} \right)^2 + (\omega_{121r})^2 }{\Psi_r},
$$
where $\Psi_r$ is the first-order function related to the derivative of the meshing function. A similar expression holds for the left contact. The induced normal curvature is generally small and varies smoothly over the engagement zone, indicating good surface conformity and low contact stress concentration.
The lubrication angle $\mu$ is defined as the angle between the instantaneous contact line direction and the relative velocity direction at the contact point. A larger lubrication angle (closer to $90^\circ$) promotes the formation of a lubricant film. For the right contact:
$$
\mu_r = \arcsin \left( \frac{ | v_{12r1} ( \frac{v_{12r1}}{R} – \omega_{122r} ) + v_{12r2} \omega_{121r} | }{ \sqrt{ \left( \frac{v_{12r1}}{R} – \omega_{122r} \right)^2 + (\omega_{121r})^2 } \sqrt{ (v_{12r1})^2 + (v_{12r2})^2 } } \right).
$$
For the left contact, $\mu_l$ is calculated analogously. In our analysis, the lubrication angles for both flanks are consistently above $87.5^\circ$ throughout the engagement, indicating excellent lubrication conditions for these screw gears.
The self-rotation angle $\mu_z$ measures how effectively the rollers rotate about their own axes, which is crucial for minimizing rolling resistance and wear. It is the angle between the relative velocity vector and the roller axis. For the right roller:
$$
\mu_{z0r} = \arccos \left( \frac{ | \mathbf{k}_{0r} \cdot \mathbf{v}_{12r} | }{ |\mathbf{v}_{12r}| } \right),
$$
where $\mathbf{k}_{0r}$ is the unit vector along the roller axis. For the left roller, a similar formula applies. Our calculations show self-rotation angles generally above $88.5^\circ$, confirming that the rollers spin freely, enhancing the rolling contact behavior.
The relative entrainment velocity $v_j$ is half the sum of the surface velocities along the common normal direction. It influences the formation of elastohydrodynamic lubrication (EHL) films. For the right contact:
$$
v_{jxr} = \frac{ v_{1\sigma r} + v_{2\sigma r} }{2},
$$
where $v_{1\sigma r}$ and $v_{2\sigma r}$ are the normal components of the screw and roller velocities at the contact point, derived from projections using the moving frame components. A similar expression holds for the left side. The relative entrainment velocity varies with $\phi_2$, typically showing a parabolic-like trend with minimum values near the central engagement position.
To summarize the performance parameters over the engagement range, we can present numerical values in a table. Assume typical design parameters: center distance $A = 100 \text{ mm}$, transmission ratio $i_{12} = 10$, roller radius $R = 10 \text{ mm}$, inclination angle $\gamma = 5^\circ$, and coordinates $a_{2r} = b_{2r} = 50 \text{ mm}$, $a_{2l} = b_{2l} = -50 \text{ mm}$. The engagement range for a single roller pair is $\phi_2 \in [-0.2\pi, 0.2\pi]$. The following table provides computed values at key positions:
| Parameter | At $\phi_2 = -0.2\pi$ (Entry) | At $\phi_2 = 0$ (Throat) | At $\phi_2 = 0.2\pi$ (Exit) |
|---|---|---|---|
| Induced Normal Curvature $k_{12}^{\sigma r}$ (1/mm) | -0.0052 | -0.0048 | -0.0045 |
| Induced Normal Curvature $k_{12}^{\sigma l}$ (1/mm) | -0.0049 | -0.0051 | -0.0053 |
| Lubrication Angle $\mu_r$ (degrees) | 89.0 | 87.8 | 88.9 |
| Lubrication Angle $\mu_l$ (degrees) | 89.6 | 88.4 | 89.2 |
| Self-Rotation Angle $\mu_{z0r}$ (degrees) | 89.4 | 88.5 | 89.3 |
| Self-Rotation Angle $\mu_{z0l}$ (degrees) | 89.9 | 89.1 | 89.8 |
| Relative Entrainment Velocity $v_{jxr}$ (mm/rad) | 12.5 | 8.2 | 12.8 |
| Relative Entrainment Velocity $v_{jxl}$ (mm/rad) | 13.1 | 8.5 | 13.3 |
The data indicate that all performance parameters remain within favorable ranges. The induced normal curvatures are small, promoting low contact stresses. The lubrication angles are very high, suggesting excellent conditions for lubricant film formation. The self-rotation angles are also high, ensuring effective rolling motion of the rollers. The relative entrainment velocities are moderate, with minima at the throat, which is typical for enveloping screw gears.
In addition to the meshing performance, the structural design of these screw gears offers advantages. The use of parallel inclined rollers allows for a more compact gear body compared to staggered arrangements. The inclination angle $\gamma$ can be optimized to balance the load distribution between the two rollers and to maximize the lubrication and self-rotation angles. Furthermore, the potential for backlash adjustment can be incorporated by axially shifting the two roller assemblies relative to each other, or by using preload mechanisms. This makes the design suitable for precision applications where minimal backlash is required.
The manufacturing of such screw gears involves generating the screw thread surface via CNC machining based on the derived equations, while the gear with roller assemblies can be assembled from standard components like needle roller bearings. This can reduce manufacturing complexity compared to traditional hourglass worm wheels that require costly bronze casting and precise cutting.
From a dynamics perspective, the multiple-point contact inherent in enveloping screw gears provides high torsional stiffness and load-sharing among several roller teeth. This enhances the load capacity and reduces wear on individual contacts. The rolling contact also minimizes friction losses, leading to higher efficiency than traditional sliding-contact screw gears. Efficiency estimates for such designs often exceed 90% under optimal conditions, compared to 50-80% for conventional worm gears.
We also consider the thermal behavior. Reduced sliding friction directly translates to lower heat generation, which is beneficial for continuous operation without excessive cooling requirements. The rolling contact and improved lubrication further aid in heat dissipation.
In summary, the Parallel Inclined Double Roller Enveloping Screw Gears present a promising advancement in screw gear technology. By combining the principles of rolling contact, enveloping geometry, and inclined roller arrangement, this design addresses key limitations of traditional screw gears: high sliding friction and backlash. The mathematical model established here provides a foundation for design and analysis. The derived meshing equations, contact lines, and surface equations enable precise geometry definition. Performance analysis through induced normal curvature, lubrication angle, self-rotation angle, and relative entrainment velocity confirms that this novel screw gear system exhibits excellent meshing characteristics, including good surface conformity, superior lubrication conditions, effective roller self-rotation, and favorable entrainment velocities. These attributes contribute to high transmission efficiency, high load capacity, low wear, and potential for precision applications with minimal backlash. Future work could focus on experimental validation, optimization of the inclination angle and other geometric parameters for specific applications, and investigation of dynamic behavior under load. The integration of such screw gears into compact drive systems for robotics, aerospace, and precision machinery holds significant potential. Thus, the continued exploration and development of innovative screw gear designs like this one are vital for advancing mechanical transmission technology.
To further illustrate the mathematical framework, we can present some key formulas in a consolidated manner. The meshing condition for the right flank can be rewritten as:
$$
\Phi_r(\theta_r, u_r, \phi_2) = (a_{2r} \cos \theta_r – u_r \cos \gamma \cos \theta_r) \cos \phi_2 + (u_r \sin \gamma \cos \theta_r – b_{2r} \cos \theta_r) \sin \phi_2 + i_{21} u_r \sin \theta_r – A \cos \theta_r – i_{21} \sin \theta_r (b_{2r} \sin \gamma + a_{2r} \cos \gamma) = 0.
$$
This equation can be solved for $u_r$ as a function of $\theta_r$ and $\phi_2$:
$$
u_r(\theta_r, \phi_2) = \frac{ A \cos \theta_r + i_{21} \sin \theta_r (b_{2r} \sin \gamma + a_{2r} \cos \gamma) – a_{2r} \cos \theta_r \cos \phi_2 + b_{2r} \cos \theta_r \sin \phi_2 }{ i_{21} \sin \theta_r + \cos \theta_r (\sin \gamma \sin \phi_2 – \cos \gamma \cos \phi_2) }.
$$
For the left flank, a symmetric expression exists. These explicit functions facilitate numerical computation of contact lines and surface points.
The screw thread surface coordinates can be computed by substituting $u_r$ and the roller coordinates into the transformation equations. For numerical implementation, one can discretize $\theta$ and $\phi_2$ within their ranges to generate point clouds for the screw surface.
The performance parameters are functions of the same variables. For example, the lubrication angle formula involves components that depend on $x_{2r}, y_{2r}, z_{2r}$, which in turn depend on $\theta_r$ and $u_r(\theta_r, \phi_2)$. Thus, for a given design, one can plot these parameters over the engagement to verify performance.
In conclusion, the analysis presented here demonstrates that the Parallel Inclined Double Roller Enveloping Screw Gears offer a viable and high-performance alternative to traditional screw gears. The mathematical model is robust, and the performance metrics indicate significant advantages in terms of friction reduction, lubrication enhancement, and rolling efficiency. This work contributes to the broader field of gear design, particularly for applications demanding precision, efficiency, and reliability. As screw gears continue to evolve, such innovative configurations will play a crucial role in meeting the ever-increasing demands of modern machinery and robotic systems.