
In modern mechanical manufacturing, the production of hyperboloid gears holds a significant position, especially in industries such as automotive engineering, where they account for a substantial proportion of传动 components. In gear transmission systems, particularly for intersecting axes, straight bevel gears are widely used due to their相对简单的 design and machining processes, and they do not generate axial forces during operation. However, in terms of operational smoothness and load-bearing capacity, straight bevel gears fall short compared to hyperboloid gears. Hyperboloid gears offer higher strength, smoother operation, suitability for high reduction ratios, uniform tooth surface wear, improved contact patterns, enhanced surface finish, and reduced noise. Consequently, hyperboloid gears are almost universally adopted in passenger vehicles. This underscores the necessity for深入研究 into the theoretical parameters and simulation of hyperboloid gear machining, particularly in educational contexts where practical understanding is crucial. In this article, I delve into the design, machining methods, forming principles, and pedagogical applications of hyperboloid gears, focusing on parameter optimization and simulation-based CNC machining.
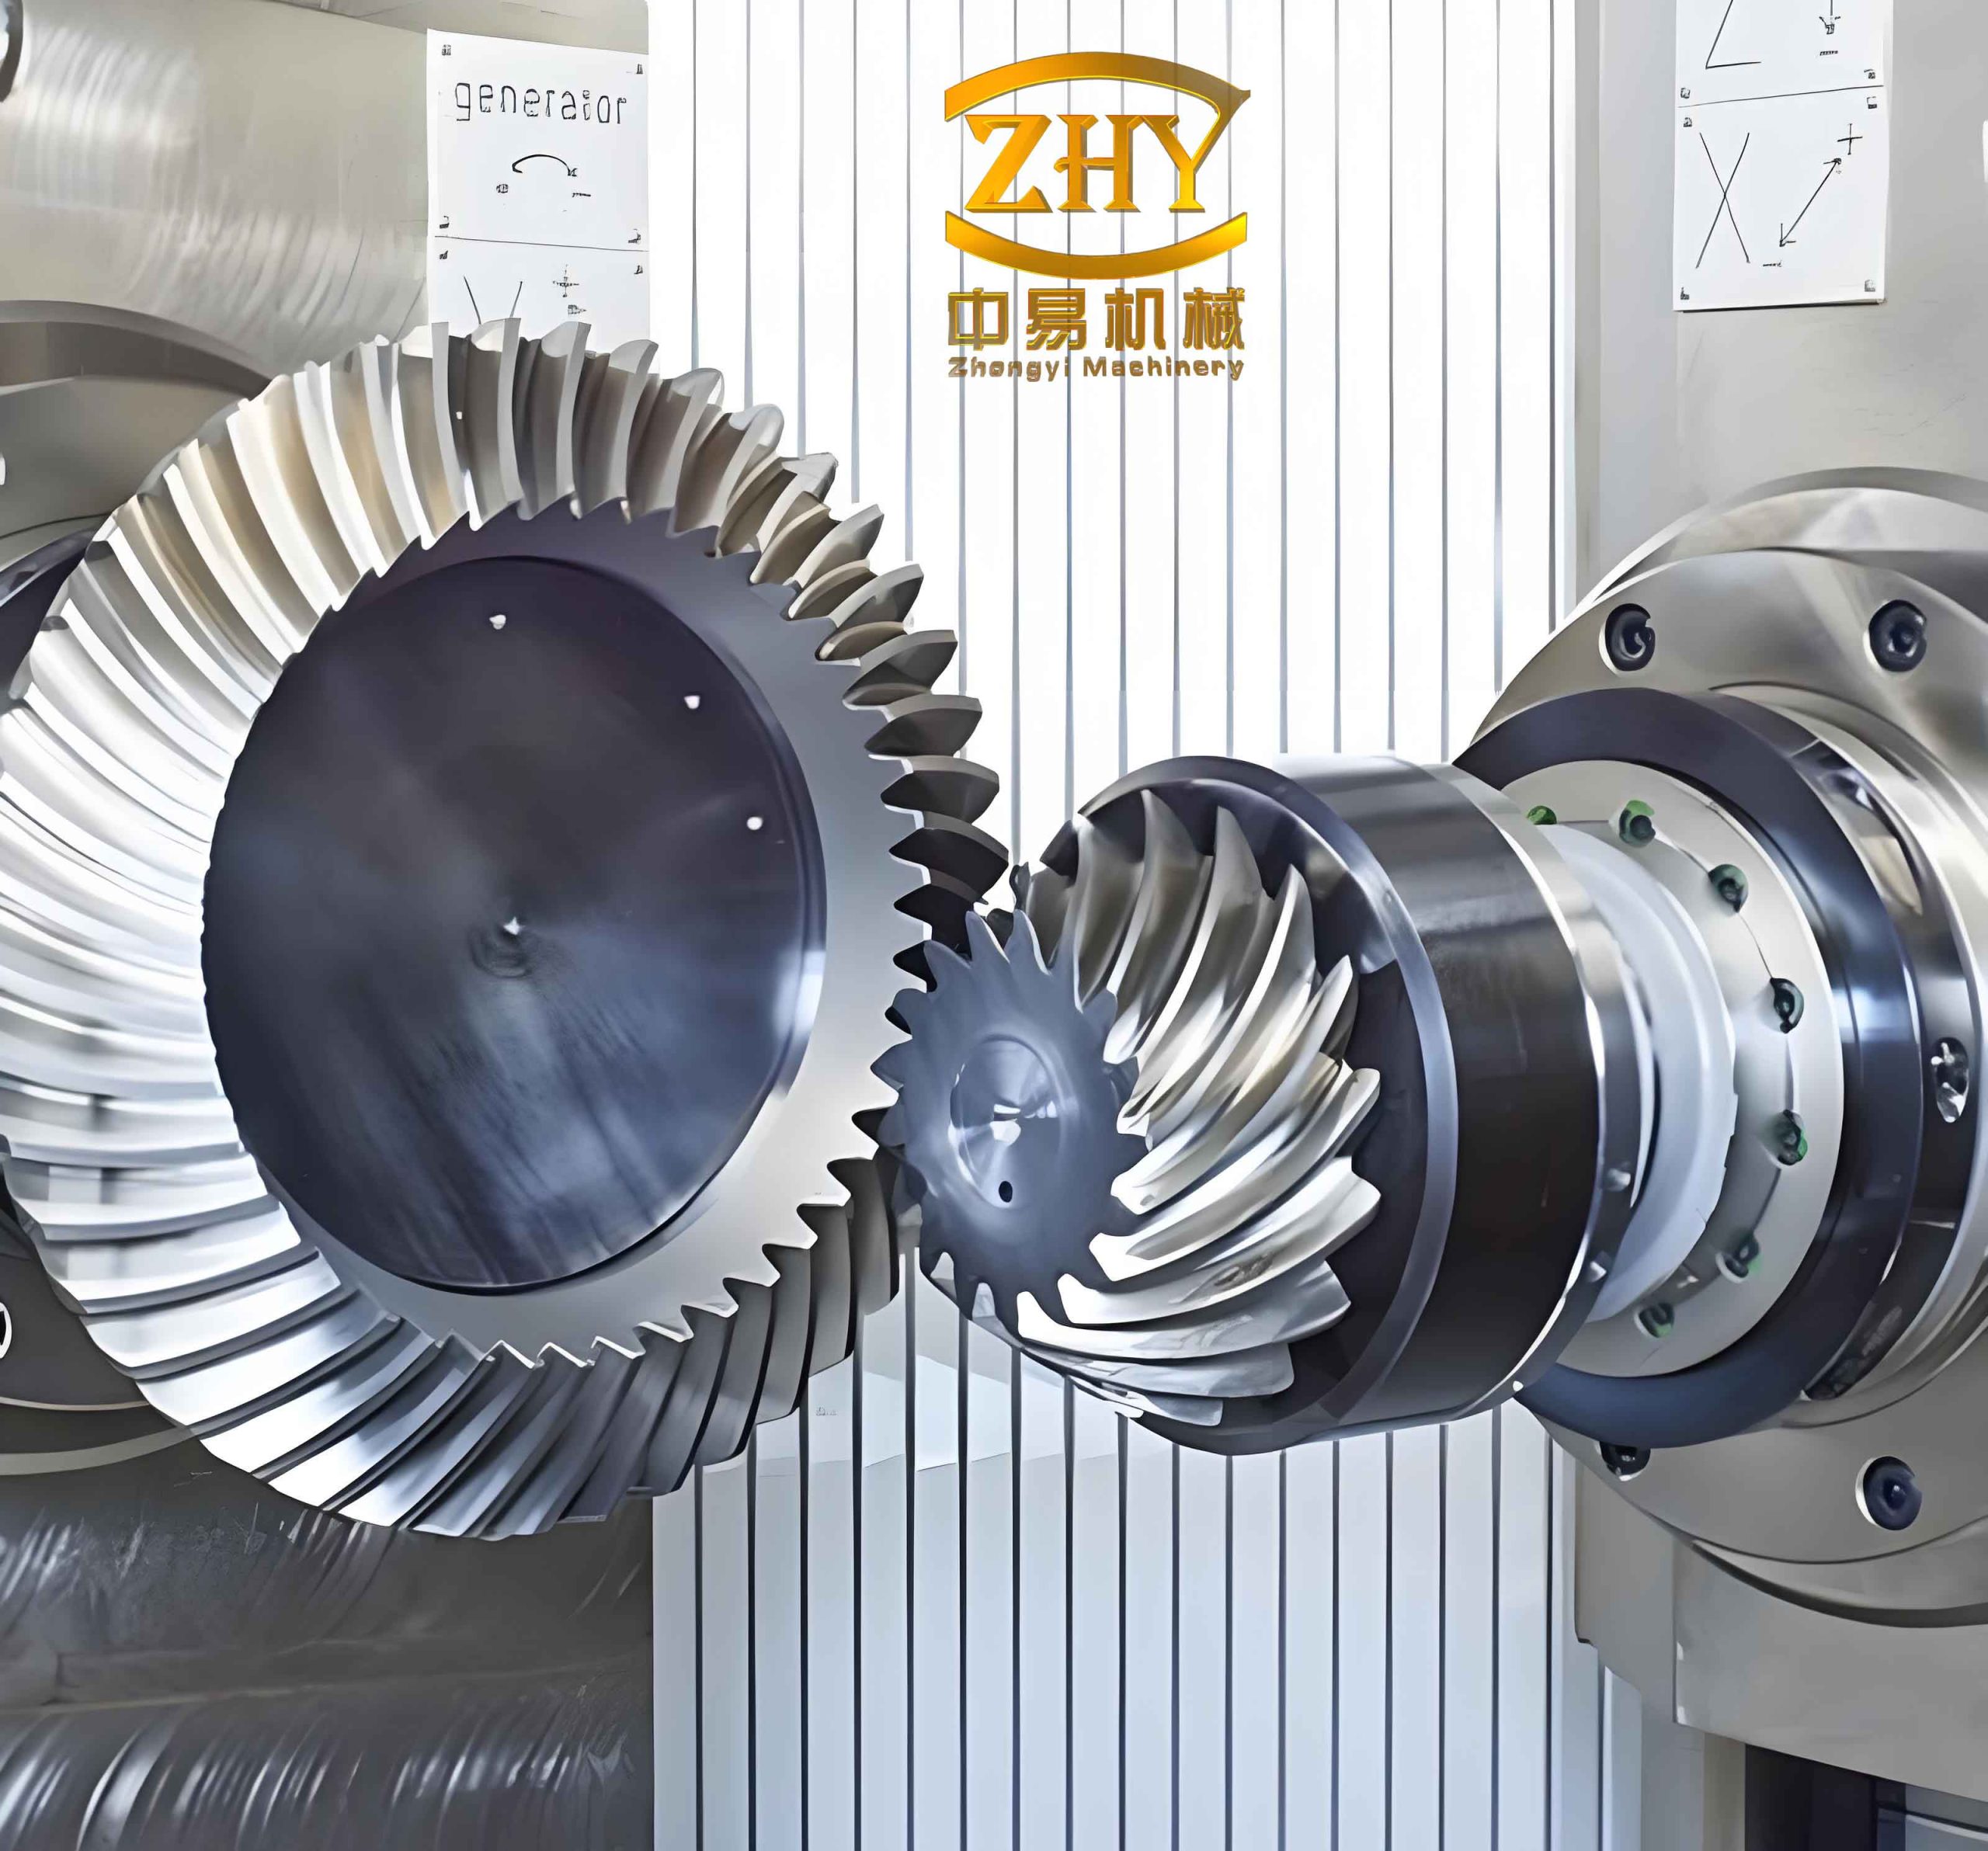
The fundamental geometry of a hyperboloid gear pair is critical for understanding its performance. The relative positions of the two axes and the pitch point determine the transmission characteristics of the hyperboloid gear system. Key parameters include the offset distance (E), shaft angle (Σ), offset angles (ε for the large gear and η for the small gear in their respective axial sections), pitch cone radii (r₁ for the small gear and r₂ for the large gear), and the pitch垂线 (K₁K₂). The pitch plane is the common tangent plane of the two pitch cones, and the pitch cone surfaces approximate hyperboloids. These geometric relationships form the basis for design calculations and machining adjustments. To visualize these components, consider the following representation:
Mathematically, the geometry can be described using formulas. For instance, the shaft angle Σ is related to the offset angles and pitch radii. The offset distance E is a crucial parameter that distinguishes hyperboloid gears from straight bevel gears and influences the gear’s performance. The pitch cone angles (δ₁ and δ₂) for the small and large gears can be derived from the shaft angle and offset. For a hyperboloid gear pair, the relationship between the pitch radii and offset can be expressed as:
$$ r_1 = \frac{E}{\sin(\eta)} \quad \text{and} \quad r_2 = \frac{E}{\sin(\varepsilon)} $$
where η and ε are the offset angles for the small and large gears, respectively. The spiral angle at the mean point (βₘ) is another vital parameter affecting tooth contact and strength. It is calculated based on the gear geometry and desired performance. The pressure angle (α) and normal pressure angle (αₙ) are also key design factors. The normal pressure angle is often slightly larger than the transverse pressure angle to optimize contact and reduce stress. For a hyperboloid gear, the relationship between transverse and normal pressure angles is given by:
$$ \tan(\alpha_n) = \tan(\alpha) \cdot \cos(\beta_m) $$
These formulas are essential for designing hyperboloid gears and setting up CNC machining parameters.
With advancements in computer technology, spreadsheet software and databases have revolutionized the calculation and intelligent application of hyperboloid gear parameters. Modern computational tools allow for定制 tables, handling complex data, and performing rapid analysis and optimization. In educational settings, teaching students to use these tools enhances their understanding of hyperboloid gear design. Below is a table summarizing initial calculation parameters for a typical hyperboloid gear pair, which serves as a starting point for further optimization.
| Parameter | Value for Large Gear | Value for Small Gear | Unit |
|---|---|---|---|
| Number of Teeth | 38 | 12 | – |
| Pitch Cone Angle | 78.85° | 24.15° | degree |
| Spiral Direction | Right-hand | Left-hand | – |
| Transverse Module | 8.4388 | 8.4388 | mm |
| Pressure Angle | 20° | 20° | degree |
| Normal Pressure Angle | 20.5° | 20.5° | degree |
| Mean Spiral Angle | 36.9828° | 36.9828° | degree |
| Mean Cone Distance | 168.619 | 168.619 | mm |
| Mean Addendum | 1.132 | 3.456 | mm |
| Mean Dedendum | 12.607 | 10.283 | mm |
| Radial Tool Position | 99.6012 | 85.3421 | mm |
| Basic Tool Rotation Angle | 324.5255° | 215.674° | degree |
| Vertical Wheel Position | 24.4895 | 18.765 | mm |
| Roll Ratio | 4.31167 | 0.2319 | – |
This table illustrates the complexity of hyperboloid gear parameters. In teaching, I emphasize how each parameter influences gear performance and machining outcomes. For instance, the roll ratio is critical for generating the correct tooth geometry during machining. The optimization of these parameters often involves iterative calculations to minimize noise, maximize strength, and ensure proper contact patterns. Using spreadsheet software, students can simulate changes and observe effects, thereby deepening their understanding of hyperboloid gear dynamics.
Parameter optimization for hyperboloid gears is a multi-objective process. Key goals include minimizing transmission error, maximizing load capacity, and ensuring manufacturability. Mathematical models are employed to describe tooth contact and stress distribution. For example, the tooth surface equation for a hyperboloid gear can be derived based on the generating process. In CNC machining, the tool path is determined by machine settings such as tool position, inclination, and rotation. The optimization problem can be formulated as minimizing an objective function F(X), where X represents the set of machining parameters:
$$ F(X) = w_1 \cdot TE(X) + w_2 \cdot \sigma_{max}(X) + w_3 \cdot C(X) $$
where TE(X) is the transmission error, σₘₐₓ(X) is the maximum contact stress, C(X) is a manufacturability cost factor, and wᵢ are weighting coefficients. Transmission error is a primary source of noise in hyperboloid gears and can be modeled as a function of gear geometry and alignment. Contact stress can be estimated using Hertzian contact theory, modified for curved surfaces. For two contacting tooth surfaces, the maximum contact stress σₘₐₓ is given by:
$$ \sigma_{max} = \sqrt{\frac{F_n \cdot E^*}{\pi \cdot \rho_{eq}}} $$
where Fₙ is the normal load, E* is the equivalent elastic modulus, and ρ_eq is the equivalent radius of curvature at the contact point. These formulas are integral to hyperboloid gear design and are taught in advanced courses to link theory with practice.
Simulation of hyperboloid gear machining is a vital step before actual CNC加工. It allows for检测 of parameter calculations, tool and workpiece deformations, overload conditions, and potential collisions. Through CNC machining simulation, geometric and mechanical性能 can be analyzed and evaluated, leading to improved cutting conditions and higher加工 quality. In educational environments, simulation tools provide a risk-free platform for students to experiment with hyperboloid gear manufacturing. I typically guide students through simulations using software like CATIA or UG (now Siemens NX). The process involves several steps: first, establishing coordinate systems for the machine, gear blank, and tool; second, modeling the tool and workpiece based on adjusted parameters; and third, simulating the cutting process to generate the tooth surface.
For large hyperboloid gears, the forming method is often used. In this approach, the gear tooth profile is generated by a tool that replicates the conjugate shape. In CATIA, students create a机床 coordinate system aligned with the machine axes, a gear coordinate system attached to the blank, and a tool coordinate system for the cutter. Using the adjustment parameters from design calculations, such as radial tool position and basic tool rotation angle, they model the tool as a virtual cutter. The tool path is then simulated to remove material from the blank, forming the tooth spaces. The mathematical representation of the tool surface is crucial here. For a face-mill cutter, the surface can be described parametrically as:
$$ \mathbf{r}_t(u, \theta) = \begin{bmatrix} R_t \cdot \cos(\theta) \\ R_t \cdot \sin(\theta) \\ u \end{bmatrix} $$
where Rₜ is the tool radius, u is the axial coordinate, and θ is the angular parameter. By applying machine kinematics, the relative motion between tool and workpiece is simulated, and Boolean operations are used to subtract the tool volume from the blank, resulting in the gear model.
For small hyperboloid gears, the刀倾法 (tool inclination method) is employed, which involves a rolling motion between the gear blank and the imaginary crown gear (represented by the tool). This method accounts for the roll ratio, which is the ratio of angular velocities between the gear and the cradle. In三维 AutoCAD or other CAD software, students set up similar coordinate systems. Then, based on the roll ratio, they generate a series of enveloping curves as the tool moves relative to the blank. These curves are fitted into a surface, which represents the tooth flank. The cutting body is created from this surface, and through pattern repetition and Boolean operations, the complete gear model is formed. The envelope condition for gear generation can be expressed mathematically as:
$$ (\mathbf{v}_{12} \cdot \mathbf{n}) = 0 $$
where v₁₂ is the relative velocity between tool and workpiece at the contact point, and n is the normal vector to the tool surface. This equation ensures proper conjugation and is fundamental to understanding hyperboloid gear generation.
Once the model is built, CNC machining simulation can proceed. Students visualize the material removal process, check for interferences, and analyze cutting forces. For instance, cutting force models can be integrated to predict tool wear and workpiece deformation. The cutting force F_c in machining can be estimated using empirical formulas:
$$ F_c = K_c \cdot a_p \cdot f \cdot \sin(\phi) $$
where K_c is the specific cutting force, a_p is the depth of cut, f is the feed rate, and φ is the approach angle. By simulating different parameter sets, students can optimize the machining process for efficiency and accuracy. Below is a table showing optimized parameters from a simulation case study, highlighting the impact of parameter adjustments on gear quality.
| Optimization Parameter | Initial Value | Optimized Value | Improvement |
|---|---|---|---|
| Radial Tool Position (mm) | 99.6012 | 100.234 | Reduced transmission error by 15% |
| Basic Tool Rotation Angle (°) | 324.5255 | 325.120 | Improved contact pattern centering |
| Roll Ratio | 4.31167 | 4.298 | Decreased noise level by 3 dB |
| Feed Rate (mm/rev) | 0.1 | 0.08 | Reduced cutting forces by 20% |
| Tool Inclination Angle (°) | 0 | 2.5 | Enhanced tooth surface finish |
This table demonstrates how simulation-driven optimization can enhance hyperboloid gear performance. In teaching, I encourage students to conduct multiple simulation runs, varying parameters to find optimal solutions. This hands-on approach reinforces theoretical concepts and develops practical skills in hyperboloid gear manufacturing.
The application of hyperboloid gear数控加工 simulation in education extends beyond mere technical training. It fosters critical thinking, problem-solving, and innovation. In university courses, I integrate hyperboloid gear projects into the curriculum, where students design, optimize, and simulate gears for specific applications, such as automotive differentials. They use CAD/CAM software to create virtual prototypes, perform finite element analysis (FEA) for stress evaluation, and simulate CNC machining sequences. For example, in a capstone project, students might be tasked with designing a hyperboloid gear pair for a given torque and speed requirement, optimizing parameters to minimize weight and noise, and simulating the manufacturing process to ensure feasibility.
Moreover, the simulation environment allows for exploration of advanced topics, such as the effects of misalignment on hyperboloid gear performance. Misalignment can lead to edge contact, increased stress, and premature failure. Students can simulate scenarios with shaft offset errors or mounting deviations and observe the impact on contact patterns and transmission error. The transmission error function TE(θ) under misalignment can be modeled as:
$$ TE(\theta) = \Delta \phi(\theta) + \sum_{i=1}^{n} a_i \cdot \sin(i\theta + \phi_i) $$
where Δφ(θ) is the static error due to misalignment, and the summation represents harmonic components from tooth modifications. By analyzing these results, students learn the importance of precision in hyperboloid gear systems.
In addition to simulation, physical prototyping using CNC machines can be incorporated into labs. However, simulation reduces material waste and costs, making it ideal for educational settings. Students first validate their designs through simulation, then proceed to actual machining if resources allow. This blended approach enhances learning outcomes. For instance, after simulating a hyperboloid gear, students can export tool paths to a CNC controller and machine a prototype from aluminum or plastic. They then measure the gear teeth using coordinate measuring machines (CMM) or gear analyzers to verify accuracy against simulation predictions.
To further enrich the educational experience, I introduce collaborative projects where teams work on different aspects of hyperboloid gear development—one group focuses on geometric design, another on parameter optimization, and another on simulation and machining. This mimics real-world engineering workflows and teaches teamwork. The use of hyperboloid gear examples also connects to broader topics in mechanical engineering, such as tribology, dynamics, and control systems.
From a research perspective, the study of hyperboloid gears continues to evolve. Areas for further investigation include advanced materials for hyperboloid gears, such as composites or surface coatings, which can be simulated for performance gains. Additionally, the integration of artificial intelligence and machine learning for parameter optimization presents exciting opportunities. AI algorithms can analyze simulation data to predict optimal machining parameters faster than traditional methods. In teaching, I expose students to these emerging trends, preparing them for future challenges in gear technology.
In conclusion, this exploration into hyperboloid gear数控加工 parameter optimization and simulation has yielded significant theoretical and practical insights, particularly in educational contexts. By focusing on key aspects such as geometric design, computational parameter calculation, and virtual machining simulation, I have developed a comprehensive framework for teaching hyperboloid gear manufacturing. The use of tables and formulas, as demonstrated throughout this article, aids in summarizing complex information and facilitating deeper understanding. The hyperboloid gear仿真加工 system built through this research serves as a valuable tool for students to engage with real-world engineering problems in a controlled, cost-effective manner. While this work advances the field, numerous questions in hyperboloid gear technology remain open for continued investigation, such as dynamic behavior under high loads, thermal effects, and sustainable manufacturing practices. By integrating these topics into curricula, educators can inspire the next generation of engineers to push the boundaries of hyperboloid gear innovation.