
In the field of power transmission systems, particularly in automotive drive axles, hyperboloidal gears play a critical role due to their ability to transmit motion between non-parallel and non-intersecting shafts with high efficiency and compact design. The dynamic behavior of gear systems is heavily influenced by the time-varying mesh parameters, which include the mesh point position, direction of mesh force, transmission error, and mesh stiffness. Accurate determination of these parameters is essential for predicting vibration, noise, and fatigue life in hyperboloidal gear systems. Traditional methods often rely on simplified assumptions that may not capture the complex geometry and loading conditions of hyperboloidal gears. This article presents a comprehensive study on the time-varying mesh characteristics of hyperboloidal gears using the Finite Element Method (FEM), specifically focusing on Loaded Tooth Contact Analysis (LTCA) to compute equivalent mesh parameters under varying torque loads.
The geometry of hyperboloidal gears is inherently complex, featuring offset axes and curved tooth surfaces that lead to time-dependent contact patterns. Unlike parallel-axis gears, hyperboloidal gears exhibit significant variations in mesh stiffness and force direction during rotation, making their dynamic analysis more challenging. Previous research has often approximated mesh stiffness using linear superposition or simplified contact models, but these approaches may not accurately reflect the nonlinear behavior under load. Here, I employ a detailed FEM approach to simulate the quasi-static meshing process of hyperboloidal gears, enabling precise calculation of time-varying equivalent mesh parameters. This method accounts for the actual contact conditions, including multiple tooth pairs in contact and the effects of torque variations.
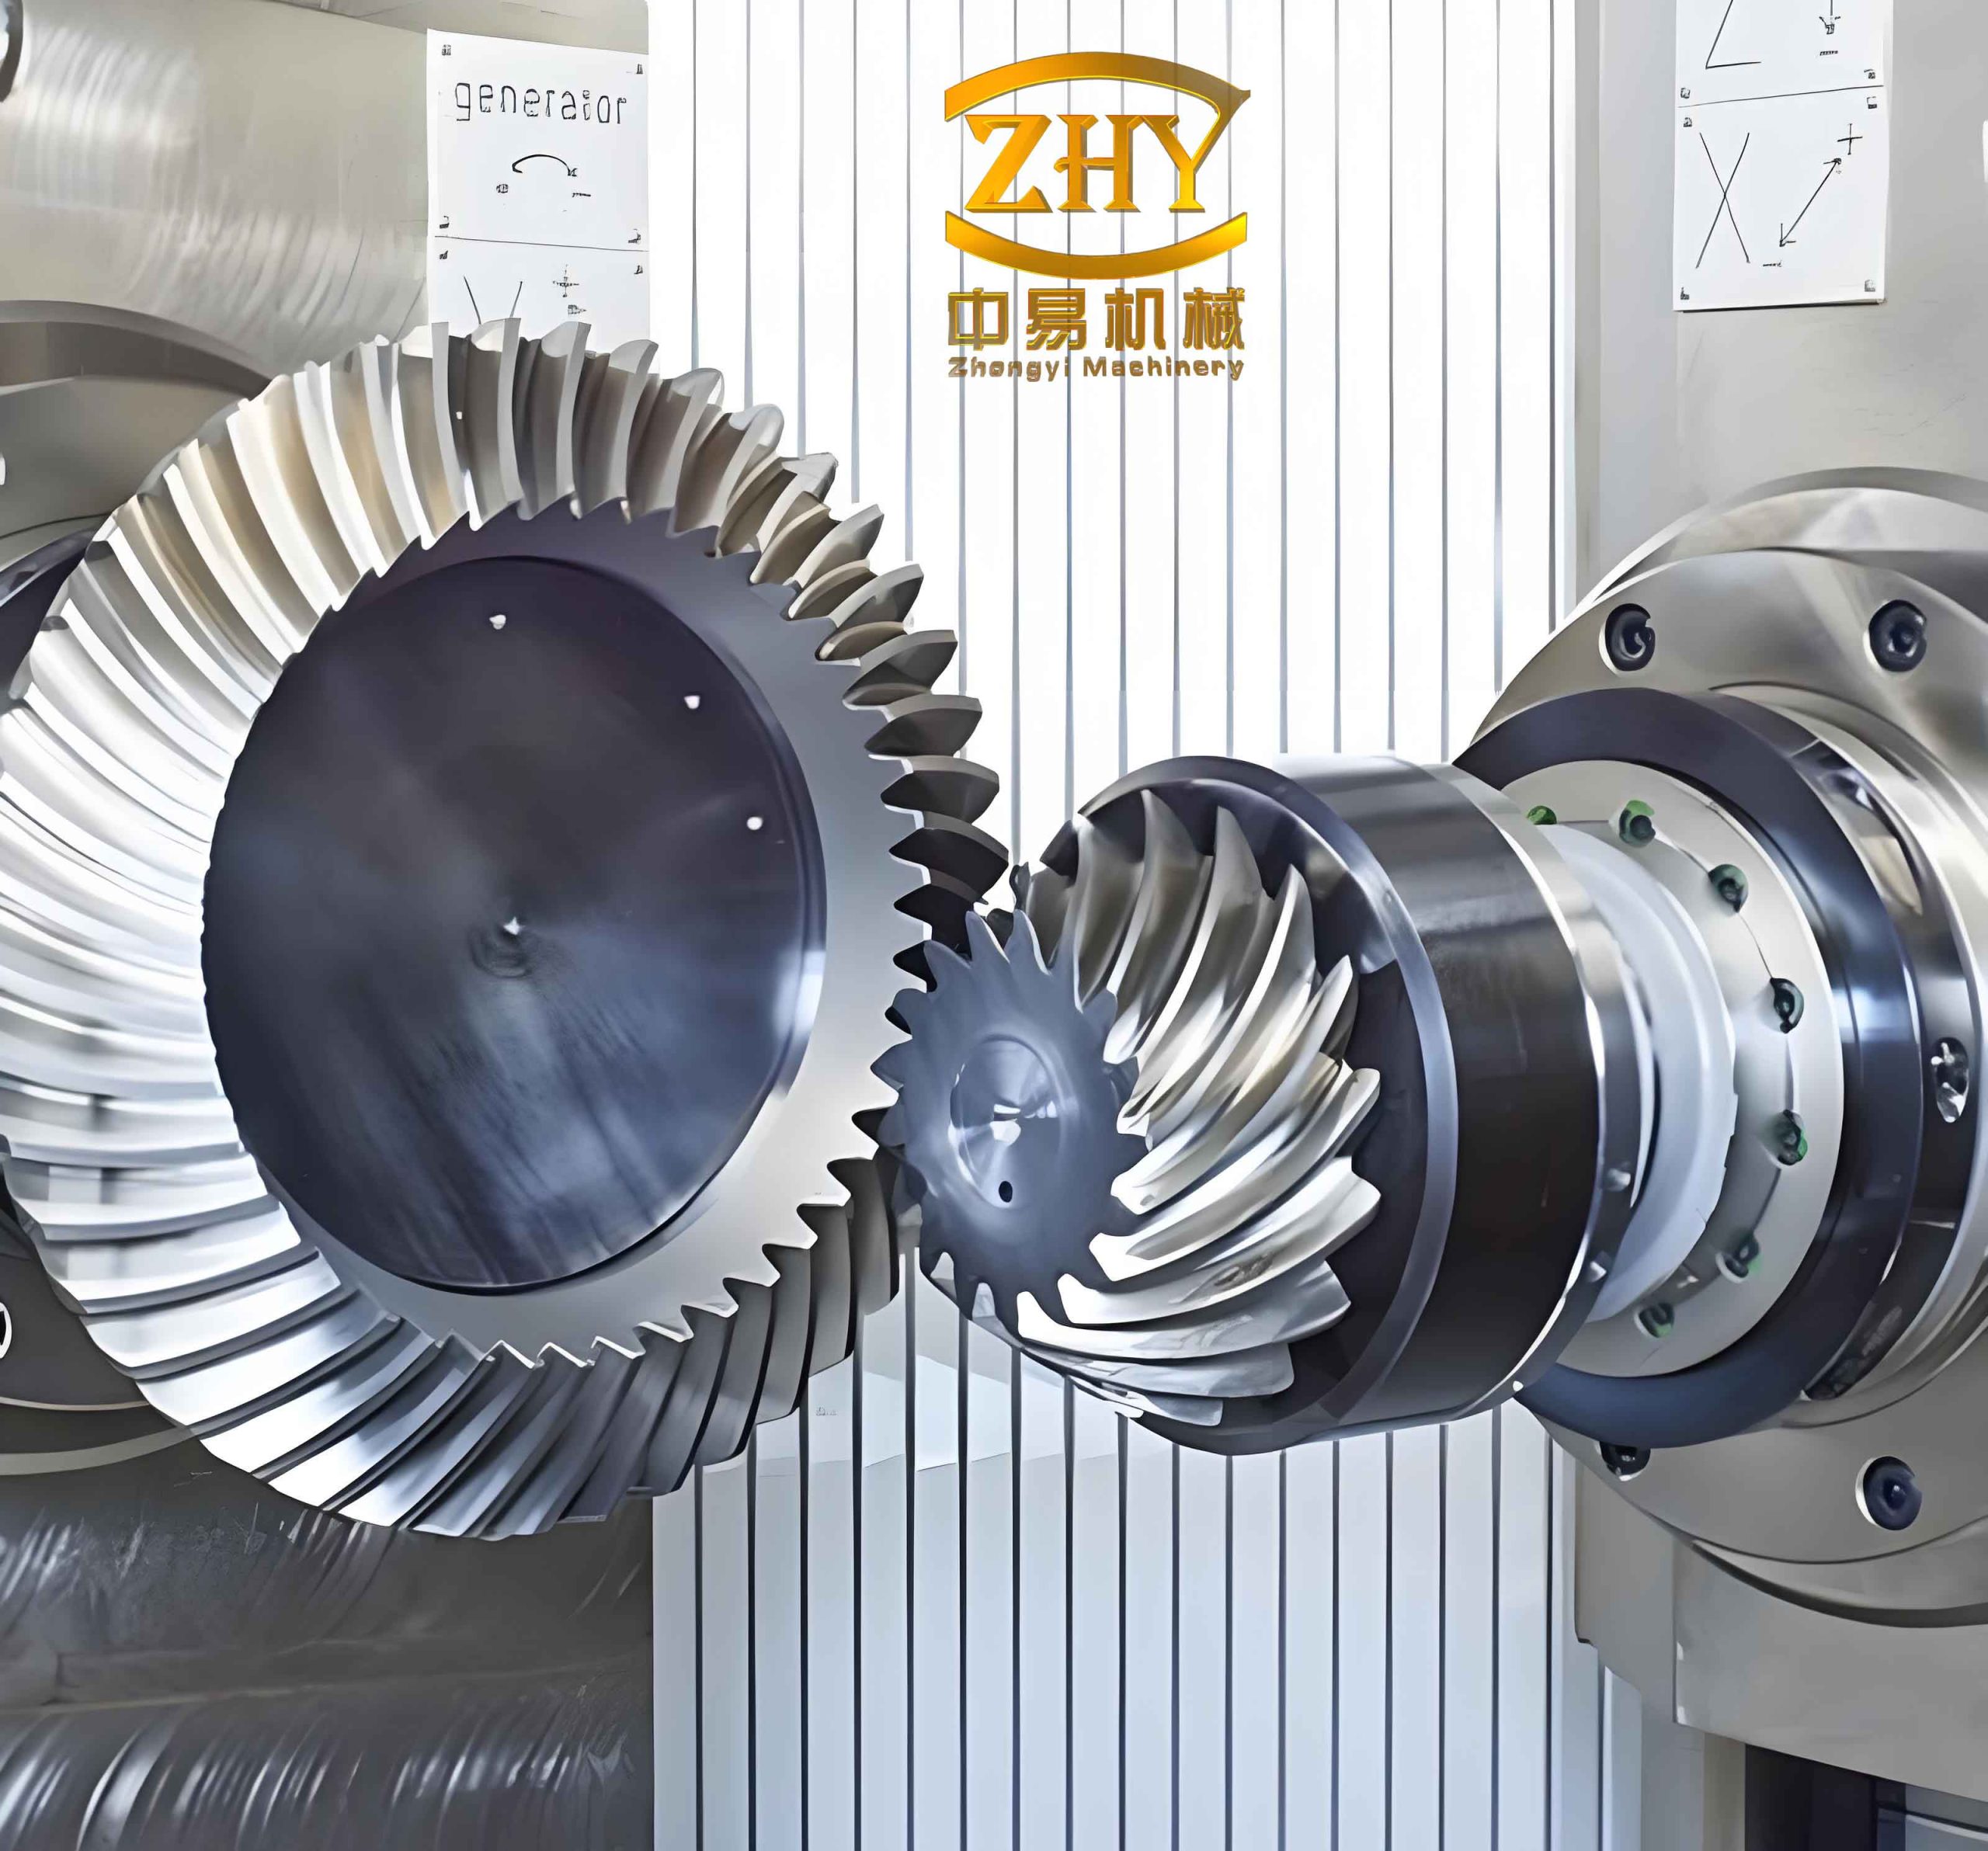
The finite element model is constructed based on the mathematical definition of hyperboloidal gear tooth surfaces, derived from gear generation principles. Key parameters include the number of teeth, module, pressure angle, offset distance, and spiral angles, as summarized in Table 1. The model uses 8-node hexahedral elements with realistic material properties to ensure accuracy. A 5-tooth segment is analyzed to balance computational efficiency and precision, with contact pairs defined between the concave side of the pinion and convex side of the gear for the driving condition. Boundary conditions and loads are applied incrementally: initial constraints to establish contact, followed by applied torques and rotational displacements to simulate meshing under load. The analysis uses implicit static steps in ABAQUS to capture the quasi-static behavior, outputting data for each pinion rotation increment.
| Parameter | Pinion (Driver) | Gear (Driven) |
|---|---|---|
| Number of Teeth | 7 | 39 |
| Module (mm) | 10.9 | |
| Face Width (mm) | 64.79 | 61 |
| Pressure Angle (°) | 22.5 | |
| Offset Distance (mm) | 26 | |
| Spiral Angle (°) | 43.85 | 35.84 |
| Hand of Spiral | Left | Right |
Validation of the FEM model is performed by comparing results with classical Tooth Contact Analysis (TCA) for unloaded transmission error and with experimental loaded contact patterns. The transmission error curves from FEM and TCA show good agreement, confirming the model’s geometric accuracy. For loaded conditions, contact patterns from FEM match experimental observations under a torque of 3000 N·m, as shown in Table 2, verifying the LTCA approach. This validation ensures that the subsequent analysis of time-varying mesh parameters is reliable.
| Contact Pattern Parameter | FEM Calculation | Experimental Test |
|---|---|---|
| Distance to Toe (mm) | 15.5 | 13.8 |
| Distance to Heel (mm) | 13.2 | 11.1 |
| Distance to Root (mm) | 3.1 | 3.1 |
| Total Length (mm) | 48.3 | 52.1 |
| Total Width (mm) | 12.2 | 12.4 |
The time-varying equivalent mesh parameters are derived from the FEM output for each meshing position. In hyperboloidal gears, up to three tooth pairs may be in contact simultaneously. The equivalent mesh force vector $\mathbf{F}_m = (F_x, F_y, F_z)$ is computed by summing the force components of individual contact pairs:
$$F_x = \sum_{i=1}^{3} f_{ix}, \quad F_y = \sum_{i=1}^{3} f_{iy}, \quad F_z = \sum_{i=1}^{3} f_{iz}$$
where $f_{ix}, f_{iy}, f_{iz}$ are the force components of the $i$-th contact pair in the global coordinate system. The magnitude of the equivalent mesh force is:
$$F_{\text{total}} = \sqrt{F_x^2 + F_y^2 + F_z^2}$$
The direction of the equivalent mesh force is given by the unit vector $\mathbf{L}_m = (n_x, n_y, n_z)$, where:
$$n_x = \frac{F_x}{F_{\text{total}}}, \quad n_y = \frac{F_y}{F_{\text{total}}}, \quad n_z = \frac{F_z}{F_{\text{total}}}$$
The position of the equivalent mesh point $\mathbf{R}_m = (x_m, y_m, z_m)$ is determined from force and moment equilibrium. For the $x$-coordinate:
$$x_m = \frac{\sum_{i=1}^{3} f_{ix} r_{ix}}{\sum_{i=1}^{3} f_{ix}}$$
where $r_{ix}$ is the $x$-coordinate of the $i$-th contact point. The $y_m$ and $z_m$ coordinates are derived from moment balance equations. The transmission error in the direction of the equivalent mesh force is calculated from angular displacement errors. The unloaded angular transmission error $\epsilon_{0A}$ and loaded angular error $\epsilon_{LA}$ are converted to linear displacements:
$$\epsilon_0 = \epsilon_{0A} (z_m n_x – x_m n_z), \quad \epsilon_L = \epsilon_{LA} (z_m n_x – x_m n_z)$$
Traditional methods compute the equivalent secant mesh stiffness $k_m^n$ as:
$$k_m^n = \frac{F_{\text{total}}}{\epsilon_L – \epsilon_0}$$
However, this represents a secant stiffness, which underestimates the actual stiffness due to nonlinear contact behavior. The true tangent stiffness $k_m^t$ is defined as the derivative of force with respect to deformation:
$$k_m^t = \frac{dF}{d\delta}$$
where $dF$ is a small change in equivalent mesh force and $d\delta$ is the corresponding deformation in the force direction. Using FEM results at different torque levels $T$, $T-\Delta T$, and $T+\Delta T$, the tangent stiffness is approximated via central difference:
$$k_m^t(\theta) = \frac{1}{2} \left( \frac{F_{\text{total}}^{T+\Delta T} – F_{\text{total}}^{T-\Delta T}}{\epsilon_L^{T+\Delta T} – \epsilon_L^{T-\Delta T}} + \frac{F_{\text{total}}^{T} – F_{\text{total}}^{T-\Delta T}}{\epsilon_L^{T} – \epsilon_L^{T-\Delta T}} \right)$$
where $\theta$ is the pinion rotation angle, and superscripts denote torque levels. This approach provides a more accurate representation of the dynamic stiffness in hyperboloidal gears.
For a case study with a gear torque of 3000 N·m, the time-varying equivalent mesh point position traces a closed curve near the mid-face width of the gear, as illustrated in Figure 1. The coordinates vary cyclically with pinion rotation, with the $x$-coordinate showing larger variations due to the longitudinal movement of the contact zone along the gear tooth. The direction of the equivalent mesh force remains relatively constant but exhibits periodic fluctuations in its components $n_x$, $n_y$, and $n_z$. The linear displacement transmission error $\epsilon_L$ displays a periodic pattern, serving as a primary excitation source for vibrations in hyperboloidal gear systems.
The secant and tangent mesh stiffnesses are compared over one mesh cycle. The tangent stiffness $k_m^t$ is consistently higher than the secant stiffness $k_m^n$, as expected from nonlinear contact theory. For instance, at 3000 N·m, the average tangent stiffness is approximately 20-30% larger than the secant stiffness, highlighting the importance of using tangent stiffness for dynamic analysis. The stiffness curves also show variations corresponding to the number of tooth pairs in contact, with smoother transitions at higher loads due to increased contact ratio.
The influence of torque magnitude on time-varying mesh parameters is investigated for torque levels ranging from 1000 N·m to 9000 N·m. As torque increases, the contact ratio of the hyperboloidal gears rises, leading to more stable meshing conditions. Table 3 summarizes the average contact ratio for different torques, computed from FEM results. The increase in contact ratio reduces the fluctuation amplitude of equivalent mesh point position and force direction, as shown in Figures 2 and 3. The $x$, $y$, and $z$ coordinates of the equivalent mesh point exhibit smaller variations at higher torques, indicating a more centralized contact zone. Similarly, the components of the mesh force direction vector become less variable, contributing to reduced dynamic excitations.
| Torque (N·m) | Average Contact Ratio |
|---|---|
| 1000 | 1.5 |
| 2000 | 1.7 |
| 3000 | 1.9 |
| 4500 | 2.2 |
| 6000 | 2.4 |
| 9000 | 2.6 |
The linear displacement transmission error $\epsilon_L$ increases with torque due to greater elastic deformation under load, as depicted in Figure 4. However, the rate of increase diminishes at higher torques because of the nonlinear stiffness behavior. The equivalent mesh stiffness, both secant and tangent, also rises with torque, but the tangent stiffness shows a more pronounced nonlinear trend. Figure 5 plots the average secant and tangent stiffnesses against torque, revealing that the tangent stiffness is significantly higher and asymptotically approaches a limit as torque increases. This nonlinearity is crucial for accurately modeling the dynamics of hyperboloidal gear systems, especially under varying operational loads.
Furthermore, the variation in tangent stiffness over a mesh cycle is more pronounced at lower torques (e.g., 1000-3000 N·m) where the contact ratio is below 2, leading to alternating single and double tooth contact. At higher torques (e.g., 4500-9000 N·m), the contact ratio exceeds 2, resulting in more consistent double or triple tooth contact and reduced stiffness fluctuation. This stability at high loads can mitigate vibration and noise in hyperboloidal gear applications, such as in heavy-duty vehicle axles.
The methodology presented here offers several advantages over conventional approaches. By using FEM-based LTCA, the time-varying mesh parameters of hyperboloidal gears are computed with high fidelity, capturing effects like load distribution, contact ellipse evolution, and nonlinear deformation. The calculation of tangent stiffness via central difference provides a realistic stiffness value for dynamic simulations, avoiding the inaccuracies associated with secant stiffness. Moreover, the study of torque effects demonstrates how hyperboloidal gears adapt to load changes, with increased contact ratio enhancing meshing smoothness but larger deformations raising transmission error.
In practical applications, these findings can inform the design and optimization of hyperboloidal gear systems for improved performance. For instance, designers can tailor tooth geometry and manufacturing corrections to control transmission error and stiffness variations under expected loads. The FEM procedures outlined here can be integrated into virtual prototyping tools, reducing reliance on physical testing. Additionally, the time-varying parameters can be used as inputs for multi-body dynamics models to predict system-level behavior, such as torsional vibrations or noise radiation in drive axles.
Future work could extend this analysis to include dynamic effects like inertia and damping, or to study non-standard conditions such as misalignments or thermal effects. The FEM approach can also be applied to other gear types, like spiral bevel or worm gears, to compare mesh characteristics. Advanced techniques like reduced-order modeling could further enhance computational efficiency while maintaining accuracy for real-time simulations.
In conclusion, this article provides a detailed exploration of the time-varying mesh characteristics of hyperboloidal gears using finite element analysis. The computation of equivalent mesh parameters—including position, force direction, transmission error, and stiffness—under varying torque loads reveals the complex, nonlinear behavior of these gears. The tangent stiffness, derived via central difference, is shown to be more accurate than traditional secant stiffness for dynamic analysis. The increase in contact ratio with torque stabilizes meshing but amplifies transmission error, highlighting trade-offs in gear design. The validated FEM methodology serves as a robust tool for understanding and optimizing hyperboloidal gear systems, contributing to advancements in power transmission technology. By leveraging these insights, engineers can develop quieter, more efficient, and more durable gear drives for automotive and industrial applications.