
In this article, I explore the modeling techniques for hyperboloidal gears by simulating their actual machining processes. Hyperboloidal gears, also known as hypoid gears, are essential components in various mechanical systems, particularly in automotive differentials, where they enable efficient power transmission between non-intersecting and non-parallel shafts. Their complex geometry, characterized by offset axes and curved tooth surfaces, poses significant challenges in design and manufacturing. Therefore, accurate modeling is crucial for performance analysis, stress evaluation, and optimization. I focus on two primary machining methods: forming and generating, and detail how to create three-dimensional models using UGNX software. By replicating the relative motions between cutting tools and gear blanks, I aim to simplify the modeling process for designers and enhance precision, ultimately reducing development cycles and costs.
The importance of hyperboloidal gears lies in their ability to handle high torque and provide smooth operation, but their manufacturing requires specialized techniques. Traditionally, gear modeling relies on theoretical calculations and simplifications, which may not capture real-world machining effects. Here, I adopt a practical approach by emulating actual cutting processes, ensuring that the models reflect genuine tooth profiles. This method is particularly valuable for custom gear designs and small-batch production, where traditional methods might be inefficient. Throughout this discussion, I will emphasize the term “hyperboloidal gears” to underscore their unique geometry and applications. The modeling workflow begins with the driven gear (often the larger gear) due to its simpler geometry, then proceeds to the driving gear (the smaller gear), ensuring proper meshing and performance.
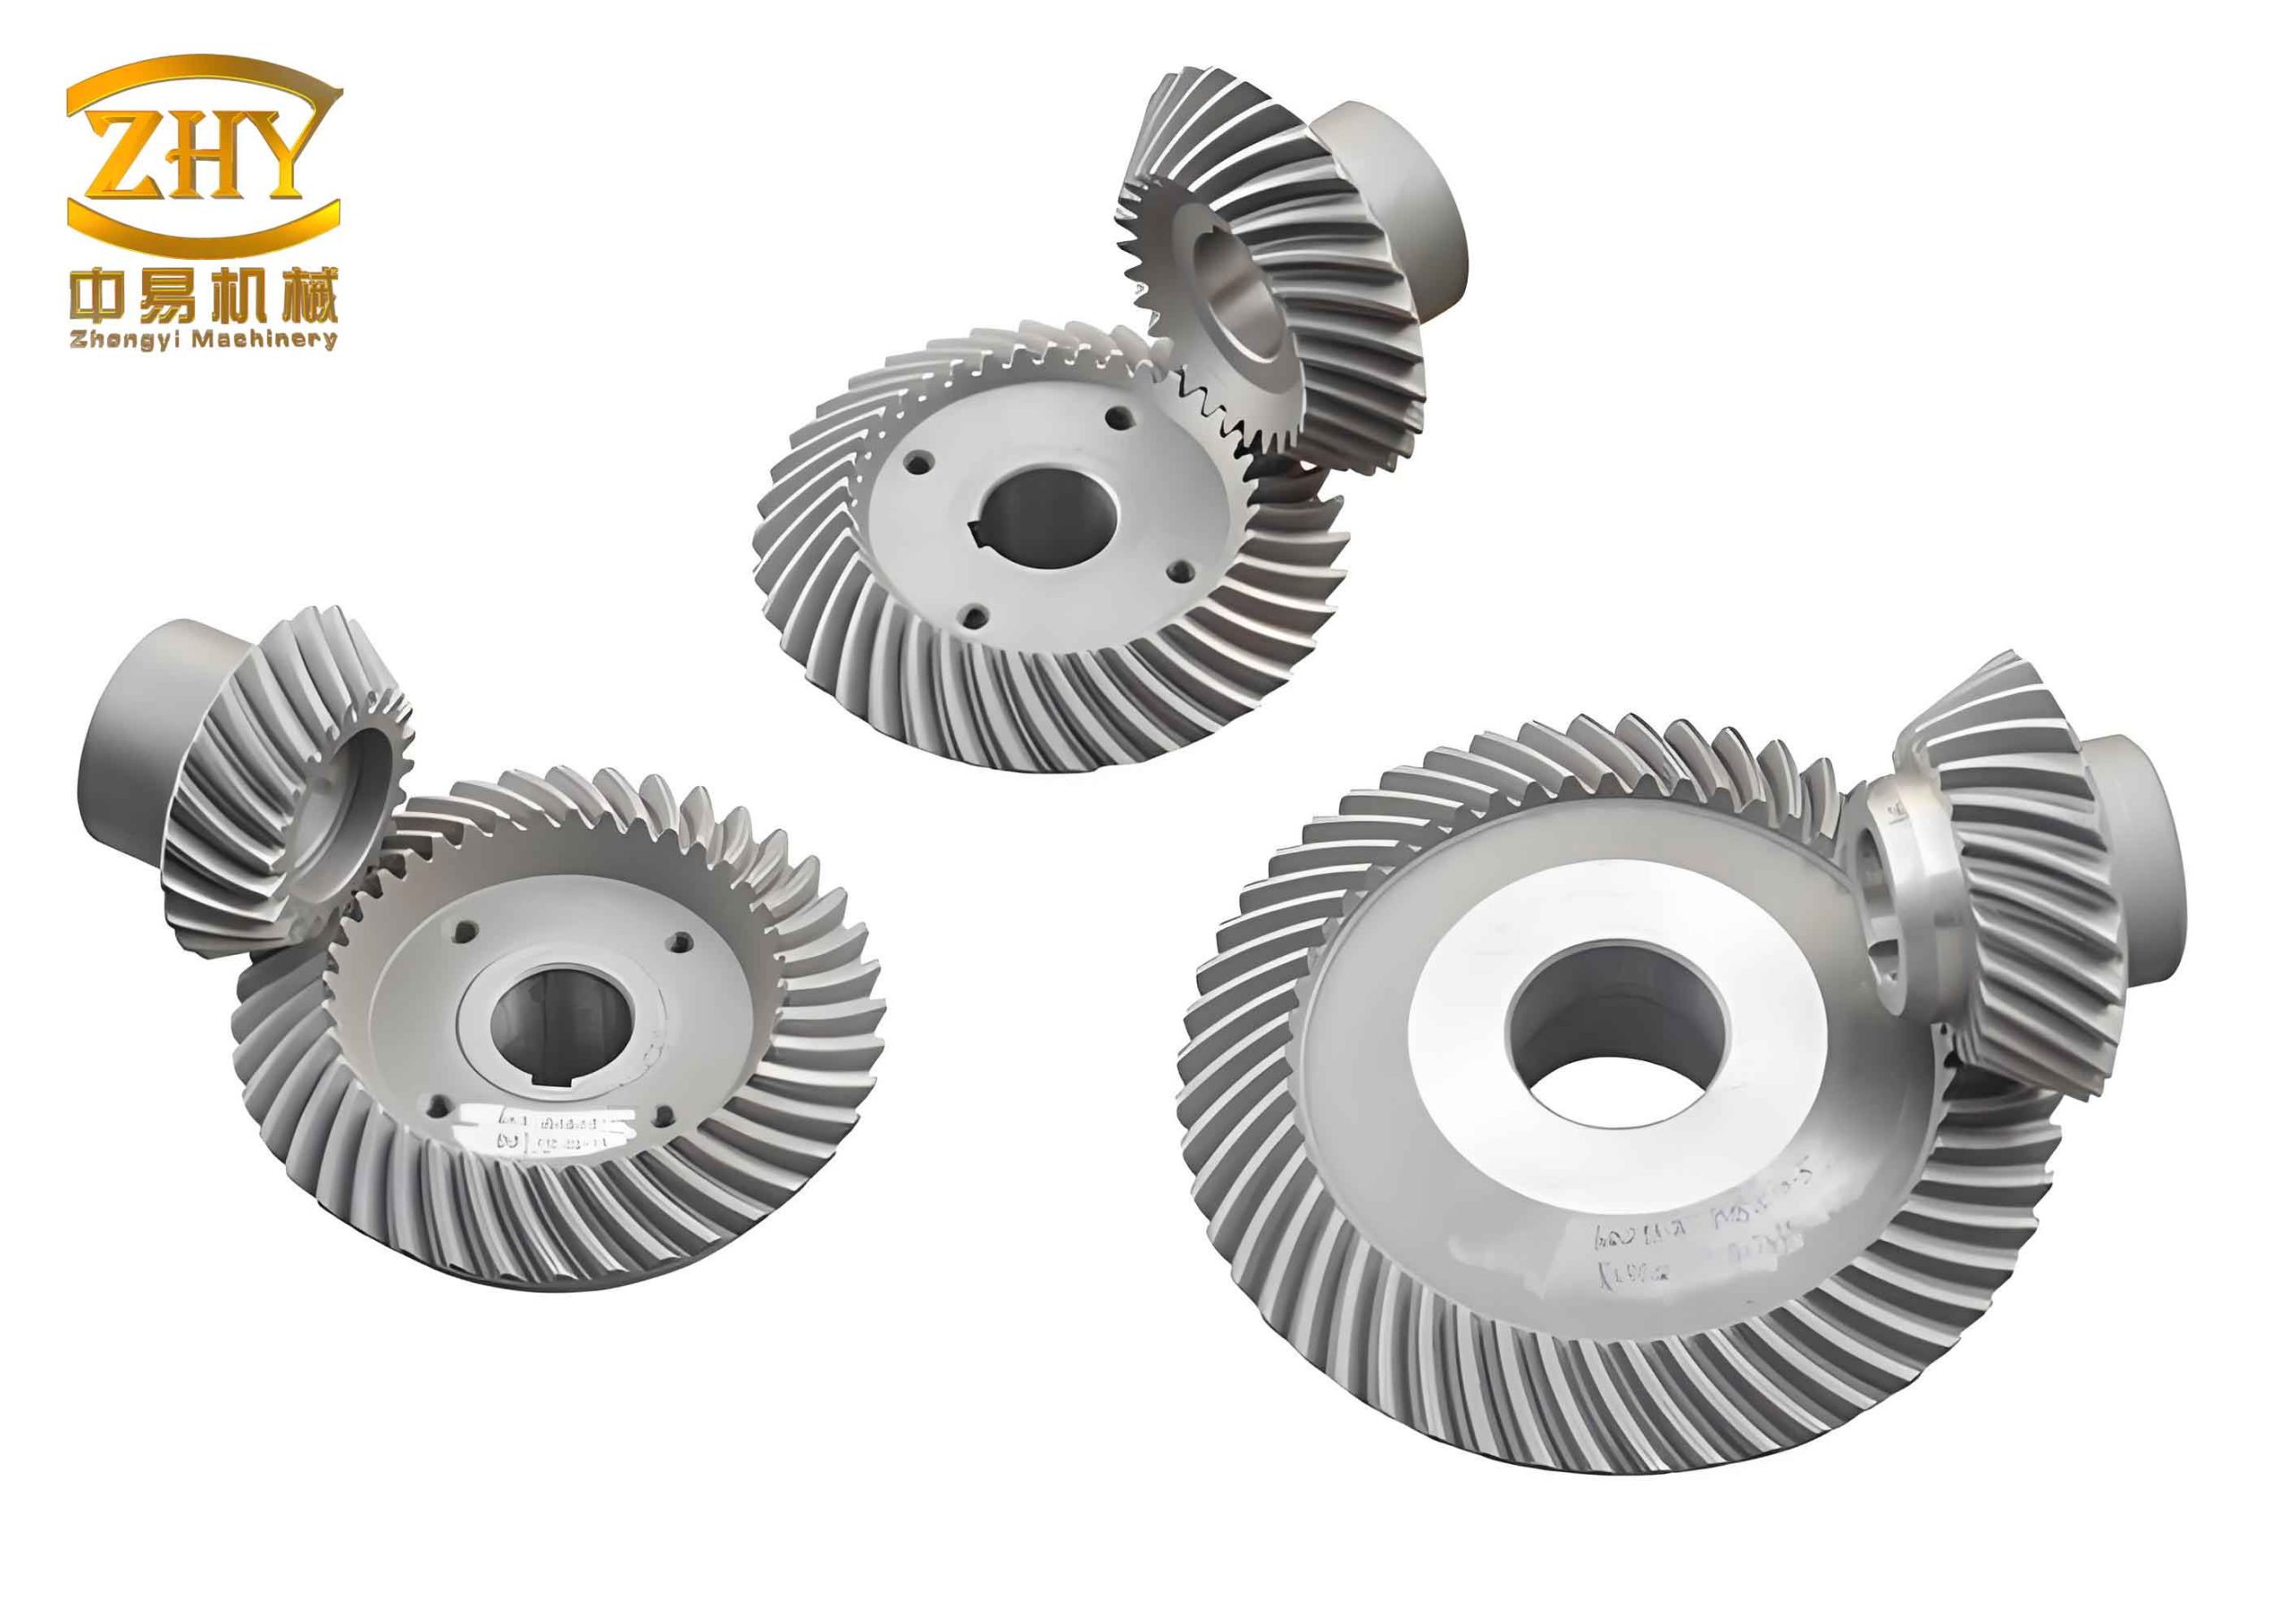
Hyperboloidal gears are defined by several key parameters, including shaft offset, gear ratio, pitch angles, and tooth curvature. The machining of these gears involves complex kinematics, where the cutter head and gear blank move relative to each other to generate the tooth surface. In UGNX, I leverage its parametric modeling and Boolean operations to simulate these motions. The primary steps include creating gear blank and cutter head models, adjusting installation angles, and performing cutting simulations. Below, I outline the fundamental equations and tables that guide this process. For instance, the basic geometry of hyperboloidal gears can be described using pitch cone angles and offset distances. The relationship between the driving and driven gears is critical for proper meshing, and it is governed by the gear ratio, denoted as \( i \).
The gear ratio \( i \) is defined as the ratio of the number of teeth on the driven gear to the number on the driving gear: $$ i = \frac{N_2}{N_1} $$ where \( N_1 \) is the number of teeth on the driving gear and \( N_2 \) on the driven gear. For hyperboloidal gears, this ratio influences the choice of machining method. When \( i > 3 \), the driven gear’s tooth profile approximates a straight line, making forming methods feasible. Conversely, for lower ratios, generating methods are preferred to achieve accurate involute profiles. The tooth surface geometry can be represented using parametric equations. For example, the position vector of a point on the tooth surface in a coordinate system attached to the gear blank is given by: $$ \mathbf{r}(u, v) = \begin{bmatrix} x(u, v) \\ y(u, v) \\ z(u, v) \end{bmatrix} $$ where \( u \) and \( v \) are parameters related to tooth length and height, respectively. These parameters are derived from cutter head geometry and motion trajectories.
To better understand the parameters involved in hyperboloidal gears modeling, I summarize key design variables in Table 1. These parameters are typically obtained from gear design specifications and adjustment calculation cards used in machining.
| Parameter | Symbol | Description | Typical Range |
|---|---|---|---|
| Shaft Offset | \( E \) | Distance between gear axes | 10–100 mm |
| Gear Ratio | \( i \) | Ratio of driven to driving teeth | 1.5–10 |
| Pitch Cone Angle (Driven) | \( \delta_2 \) | Angle of driven gear pitch cone | 20°–80° |
| Pitch Cone Angle (Driving) | \( \delta_1 \) | Angle of driving gear pitch cone | 10°–70° |
| Number of Teeth (Driving) | \( N_1 \) | Teeth on driving gear | 5–20 |
| Number of Teeth (Driven) | \( N_2 \) | Teeth on driven gear | 15–40 |
| Module | \( m \) | Standard size parameter | 2–10 mm |
| Face Width | \( b \) | Width of gear tooth | 20–100 mm |
| Cutter Head Radius | \( R_c \) | Radius of cutting tool | 50–200 mm |
| Pressure Angle | \( \alpha \) | Angle between tooth profile and tangent | 15°–25° |
Machining methods for hyperboloidal gears are broadly classified into forming and generating techniques. Forming methods involve cutting the tooth shape directly into the gear blank using a tool that mirrors the final tooth profile. This approach is efficient for mass production, especially for driven gears with high gear ratios. In contrast, generating methods simulate the meshing of two gears, where the cutter head and gear blank rotate in a coordinated manner to produce an involute profile. This method offers better surface finish and contact patterns, making it suitable for custom hyperboloidal gears and small batches. The choice between these methods depends on factors like production volume, gear ratio, and required precision. In UGNX modeling, I replicate both processes to create accurate digital twins of hyperboloidal gears.
For forming methods, the tool geometry is critical. The cutter head for hyperboloidal gears typically consists of multiple blades arranged in a circular pattern. The tool path is linear relative to the gear blank, and the tooth shape is generated in a single pass. The mathematical model for forming can be simplified as a Boolean subtraction operation in UGNX. If \( \mathbf{T} \) represents the tool volume and \( \mathbf{G} \) the gear blank volume, the resulting gear tooth volume \( \mathbf{V} \) is given by: $$ \mathbf{V} = \mathbf{G} – \mathbf{T} $$ This operation is performed for each tooth, considering the rotational symmetry of hyperboloidal gears. The tool position is determined by installation angles, which align the cutter head with the gear blank’s root cone. The key angles include the workpiece installation angle \( \gamma_w \), which orients the gear blank relative to the machine base, and the cutter head tilt angle \( \gamma_c \), which ensures proper tooth depth.
Generating methods are more complex due to the simultaneous rotations of the cutter head and gear blank. The process mimics a gear pair in mesh, where the cutter head acts as a imaginary generating gear. The relative motion is defined by a roll ratio, which dictates the speed relationship between the cutter head and gear blank. In mathematical terms, if \( \theta_c \) is the rotation angle of the cutter head and \( \theta_g \) that of the gear blank, the roll ratio \( R_r \) is: $$ R_r = \frac{\theta_g}{\theta_c} $$ This ratio is derived from the gear ratio and machine settings. Additionally, eccentric angles and swivel angles are adjusted to position the cutter head correctly. The tooth surface is generated as an envelope of the cutter blade positions over time. In UGNX, this is achieved by simulating the kinematic chain and using swept operations. The parametric equations for the generating process involve time-dependent transformations. For a point on the cutter blade, its position in the gear blank coordinate system is: $$ \mathbf{r}_g(t) = \mathbf{M}(t) \cdot \mathbf{r}_c $$ where \( \mathbf{r}_c \) is the position in cutter coordinates, and \( \mathbf{M}(t) \) is a time-varying transformation matrix that incorporates rotations and translations.
To illustrate the differences between forming and generating methods for hyperboloidal gears, I provide a comparative analysis in Table 2. This table highlights key aspects such as accuracy, efficiency, and applicability.
| Aspect | Forming Method | Generating Method |
|---|---|---|
| Principle | Direct cutting with shaped tool | Envelope cutting via relative motion |
| Accuracy | Moderate; depends on tool wear | High; produces true involute profiles |
| Surface Finish | Good, but may require post-processing | Excellent, with smooth tooth surfaces |
| Production Speed | Fast, suitable for high volume | Slower, ideal for small batches |
| Tool Complexity | Simple, dedicated tooling | Complex, with adjustable settings |
| Applicability | Driven gears with \( i > 3 \) | All hyperboloidal gears, especially driving gears |
| Modeling in UGNX | Boolean subtraction with static tool | Kinematic simulation with moving tool |
| Cost | Lower for mass production | Higher due to setup and time |
Now, I delve into the detailed modeling process for hyperboloidal gears in UGNX. The first step is creating the gear blank and cutter head models. Both are rotational solids, so I use UGNX’s revolving features. I set the coordinate system origin at the center of the gear blank’s back face for consistency. The gear blank dimensions, such as pitch diameter, face width, and root angle, are input based on design parameters. For the cutter head, parameters like blade radius, pressure angle, and blade number are obtained from machine adjustment cards. The models are constructed by sketching profiles and revolving them 360 degrees around their axes. This results in solid bodies that represent the initial state before cutting. Proper positioning is crucial; for hyperboloidal gears, the cutter head axis must be perpendicular to the root cone of the gear blank to ensure correct tooth depth.
For driven gear modeling using the forming method, I simulate a broaching process where the tool moves linearly relative to the gear blank. In UGNX, I position the cutter head model to intersect with the gear blank at the tooth space location. Then, I use Boolean subtraction to remove the tool volume from the blank, creating one tooth gap. Due to symmetry, I pattern this operation around the gear axis to generate all teeth. The key is to ensure the tool orientation matches the root cone angle. The installation angle \( \gamma_w \) is adjusted by rotating the gear blank relative to the global coordinate system. This angle is calculated as: $$ \gamma_w = \delta_f + \Delta \gamma $$ where \( \delta_f \) is the root cone angle and \( \Delta \gamma \) is a correction factor from machine settings. After Boolean operations, I obtain a driven gear model with formed teeth. This approach is efficient for hyperboloidal gears with high gear ratios, as the tooth profile is nearly straight, minimizing errors.
For driven gear modeling using the generating method, the process involves coordinated motion. I set up a kinematic simulation in UGNX by defining rotational joints for both the cutter head and gear blank. The motion is controlled by a gear constraint that enforces the roll ratio \( R_r \). Additionally, I adjust eccentric and swivel angles to replicate machine settings. The eccentric angle \( \epsilon \) positions the cutter head offset relative to the gear blank, and the swivel angle \( \kappa \) orients the cutter head axis. These angles are derived from machine adjustment cards and are critical for accurate tooth generation. In UGNX, I use expressions to link these angles to motion parameters. The generating process is simulated over a full cycle, and the swept volume of the cutter blades is subtracted from the gear blank using Boolean operations. The tooth surface emerges as an envelope, represented by a set of points. To smooth the surface, I apply curve fitting and surface patching tools in UGNX, ensuring continuity and precision for subsequent analysis of hyperboloidal gears.
The driving gear modeling is more challenging because it typically requires generating methods due to its curved tooth profile. In UGNX, I follow a similar approach as for the driven gear but with different adjustment parameters. The driving gear often needs tooth modifications to ensure proper meshing with the driven gear. This is based on the local conjugation principle, where a point on the tooth surface is selected, and the surrounding area is slightly relieved to create a localized contact pattern. Mathematically, this modification can be described as a surface deviation. If \( \mathbf{S}_0(u, v) \) is the theoretical tooth surface, the modified surface \( \mathbf{S}(u, v) \) is: $$ \mathbf{S}(u, v) = \mathbf{S}_0(u, v) + \delta(u, v) \cdot \mathbf{n}(u, v) $$ where \( \delta(u, v) \) is a relief function that decreases with distance from the selected point, and \( \mathbf{n}(u, v) \) is the unit normal vector. In UGNX, I achieve this by offsetting surfaces or using deformation tools. The modeling process involves generating the basic tooth profile via generating methods, then applying modifications based on contact analysis with the driven gear.
To ensure the hyperboloidal gears model is accurate, I perform an assembly check in UGNX. I assemble the driving and driven gears according to their design positions, considering shaft offset and mounting distances. Then, I simulate rotational motion to check for interference and contact patterns. UGNX’s interference detection tool helps identify collisions, and motion analysis verifies smooth meshing. This step is crucial for validating the modeling process and ensuring that the hyperboloidal gears will function correctly in real applications. Additionally, I export the models for finite element analysis (FEA) to evaluate stress distributions and durability. The entire workflow, from blank creation to assembly check, is summarized in Table 3, which outlines the key steps and UGNX commands used.
| Step | Description | UGNX Features Used | Key Parameters |
|---|---|---|---|
| 1. Gear Blank Creation | Revolve sketch based on design parameters | Revolve, Sketch | Pitch diameter, face width, cone angles |
| 2. Cutter Head Creation | Revolve tool profile from machine data | Revolve, Pattern | Cutter radius, blade angle, number of blades |
| 3. Positioning | Adjust installation, eccentric, and swivel angles | Move Object, Expressions | \( \gamma_w \), \( \epsilon \), \( \kappa \) |
| 4. Tooth Generation (Forming) | Boolean subtraction for each tooth space | Subtract, Circular Pattern | Tooth number, root cone alignment |
| 5. Tooth Generation (Generating) | Kinematic simulation with swept cut | Swept, Boolean, Motion Simulation | Roll ratio \( R_r \), time parameters |
| 6. Surface Smoothing | Fit surfaces to generated points | Through Curves, Patch | Tolerance settings, continuity constraints |
| 7. Tooth Modification (Driving Gear) | Offset surface for localized contact | Offset Surface, Deform | Relief function \( \delta(u, v) \) |
| 8. Assembly and Check | Assemble gears and simulate motion | Assembly Constraints, Interference Check | Shaft offset \( E \), mounting distance |
Mathematical modeling plays a central role in accurately representing hyperboloidal gears. The tooth surface geometry can be derived from the principles of gear theory. For a generating process, the equation of meshing relates the cutter surface and gear blank motions. If \( \mathbf{r}_c(u, v) \) is a point on the cutter surface in cutter coordinates, and the cutter undergoes a rotation \( \phi_c(t) \) while the gear blank rotates \( \phi_g(t) \), the condition for contact is that the relative velocity is perpendicular to the common normal. This leads to the meshing equation: $$ \mathbf{n}_c \cdot (\mathbf{v}_c – \mathbf{v}_g) = 0 $$ where \( \mathbf{n}_c \) is the normal vector on the cutter surface, and \( \mathbf{v}_c \) and \( \mathbf{v}_g \) are velocities of the cutter and gear blank points, respectively. Solving this equation along with coordinate transformations yields the tooth surface points. In UGNX, these equations are embedded in the kinematic simulations, but understanding them helps in setting correct parameters.
For hyperboloidal gears, the offset shaft introduces additional complexity. The transformation matrix between coordinate systems includes translation for the offset. If the driving gear coordinate system is offset by distance \( E \) along the x-axis relative to the driven gear system, the transformation involves both rotation and translation. This affects the contact pattern and requires careful adjustment in modeling. The local conjugation principle for tooth modification can be quantified using relief depth formulas. For example, a parabolic relief function might be used: $$ \delta(u, v) = a \cdot ( (u – u_0)^2 + (v – v_0)^2 ) $$ where \( (u_0, v_0) \) is the selected point, and \( a \) is a coefficient determined by contact analysis. This ensures that hyperboloidal gears have a controlled contact area, reducing stress concentration and noise.
In practical applications, hyperboloidal gears are used in differentials, industrial machinery, and aerospace systems. Their modeling accuracy directly impacts performance, efficiency, and lifespan. By using UGNX to simulate real machining processes, designers can optimize tooth profiles before physical production, saving time and resources. The models generated through this approach can be used for CNC programming, 3D printing prototypes, or virtual testing. Moreover, the ability to switch between forming and generating methods in UGNX allows flexibility for different production scenarios. Throughout this article, I have emphasized the importance of hyperboloidal gears and detailed modeling techniques. The integration of mathematical formulas, tables, and software tools provides a comprehensive framework for engineers working with these complex components.
To further illustrate the parameter relationships, I present Table 4, which shows example values for a typical hyperboloidal gear set and the corresponding modeling adjustments. This table can serve as a reference for practitioners.
| Parameter Type | Driven Gear Example | Driving Gear Example | Modeling Adjustment |
|---|---|---|---|
| Number of Teeth | 30 | 10 | Gear ratio \( i = 3 \) |
| Shaft Offset | 25 mm | 25 mm | Coordinate translation in assembly |
| Pitch Cone Angle | 60° | 30° | Workpiece installation angle setting |
| Module | 4 mm | 4 mm | Tooth size scaling in sketches |
| Cutter Head Radius | 120 mm | 100 mm | Tool model dimension |
| Pressure Angle | 20° | 20° | Blade angle in cutter head |
| Roll Ratio | 1.2 (for generating) | 0.4 (for generating) | Motion simulation ratio |
| Eccentric Angle | 15° | 10° | Cutter head offset adjustment |
| Swivel Angle | 5° | 8° | Cutter head orientation |
| Relief Coefficient | N/A (for forming) | 0.001 mm⁻¹ | Tooth modification parameter |
In conclusion, modeling hyperboloidal gears based on real machining processes using UGNX software offers significant advantages in accuracy and efficiency. By simulating both forming and generating methods, designers can create detailed digital models that reflect actual tooth profiles. The mathematical foundations, including gear geometry equations and meshing conditions, guide the parameter settings. Tables summarizing parameters, methods, and workflows provide practical insights. This approach not only streamlines the design phase but also enables thorough analysis and optimization, contributing to the advancement of hyperboloidal gears technology. As manufacturing evolves towards digital twins and Industry 4.0, such integrated modeling techniques will become increasingly vital for producing high-performance hyperboloidal gears for diverse applications.