
Straight bevel gears are indispensable mechanical components widely employed to transmit power and motion between intersecting axes. Their manufacturing accuracy and installation quality directly determine the performance, reliability, and service life of the entire transmission system. In modern mechanical industries ranging from automotive manufacturing to aerospace engineering, the demand for higher precision and quieter operation of gear drives has been increasing steadily. However, the measurement of straight bevel gears presents considerable challenges due to the spherical involute tooth profile, which cannot be developed onto a plane. The current state of measurement technology for straight bevel gears still relies heavily on expensive imported instruments, while domestic research remains relatively limited. Therefore, developing a complete measurement and error evaluation system for straight bevel gears based on domestic hardware platforms has significant academic value and practical engineering significance.
This dissertation is dedicated to an in-depth investigation of the measurement technology and error evaluation methodology for straight bevel gears. The entire research work is conducted on the hardware platform of a CNC gear measuring center. The primary research contents include: establishing a precise mathematical model of the tooth surface of straight bevel gears; designing a rational measurement scheme including probe path planning and zero position setting; studying the error evaluation algorithms for profile deviation, helix deviation, pitch deviation, and radial run-out based on the least squares principle; developing corresponding software modules; and finally verifying the feasibility and accuracy of the proposed methodology through practical measurement experiments.
1. Introduction to Straight Bevel Gear Measurement
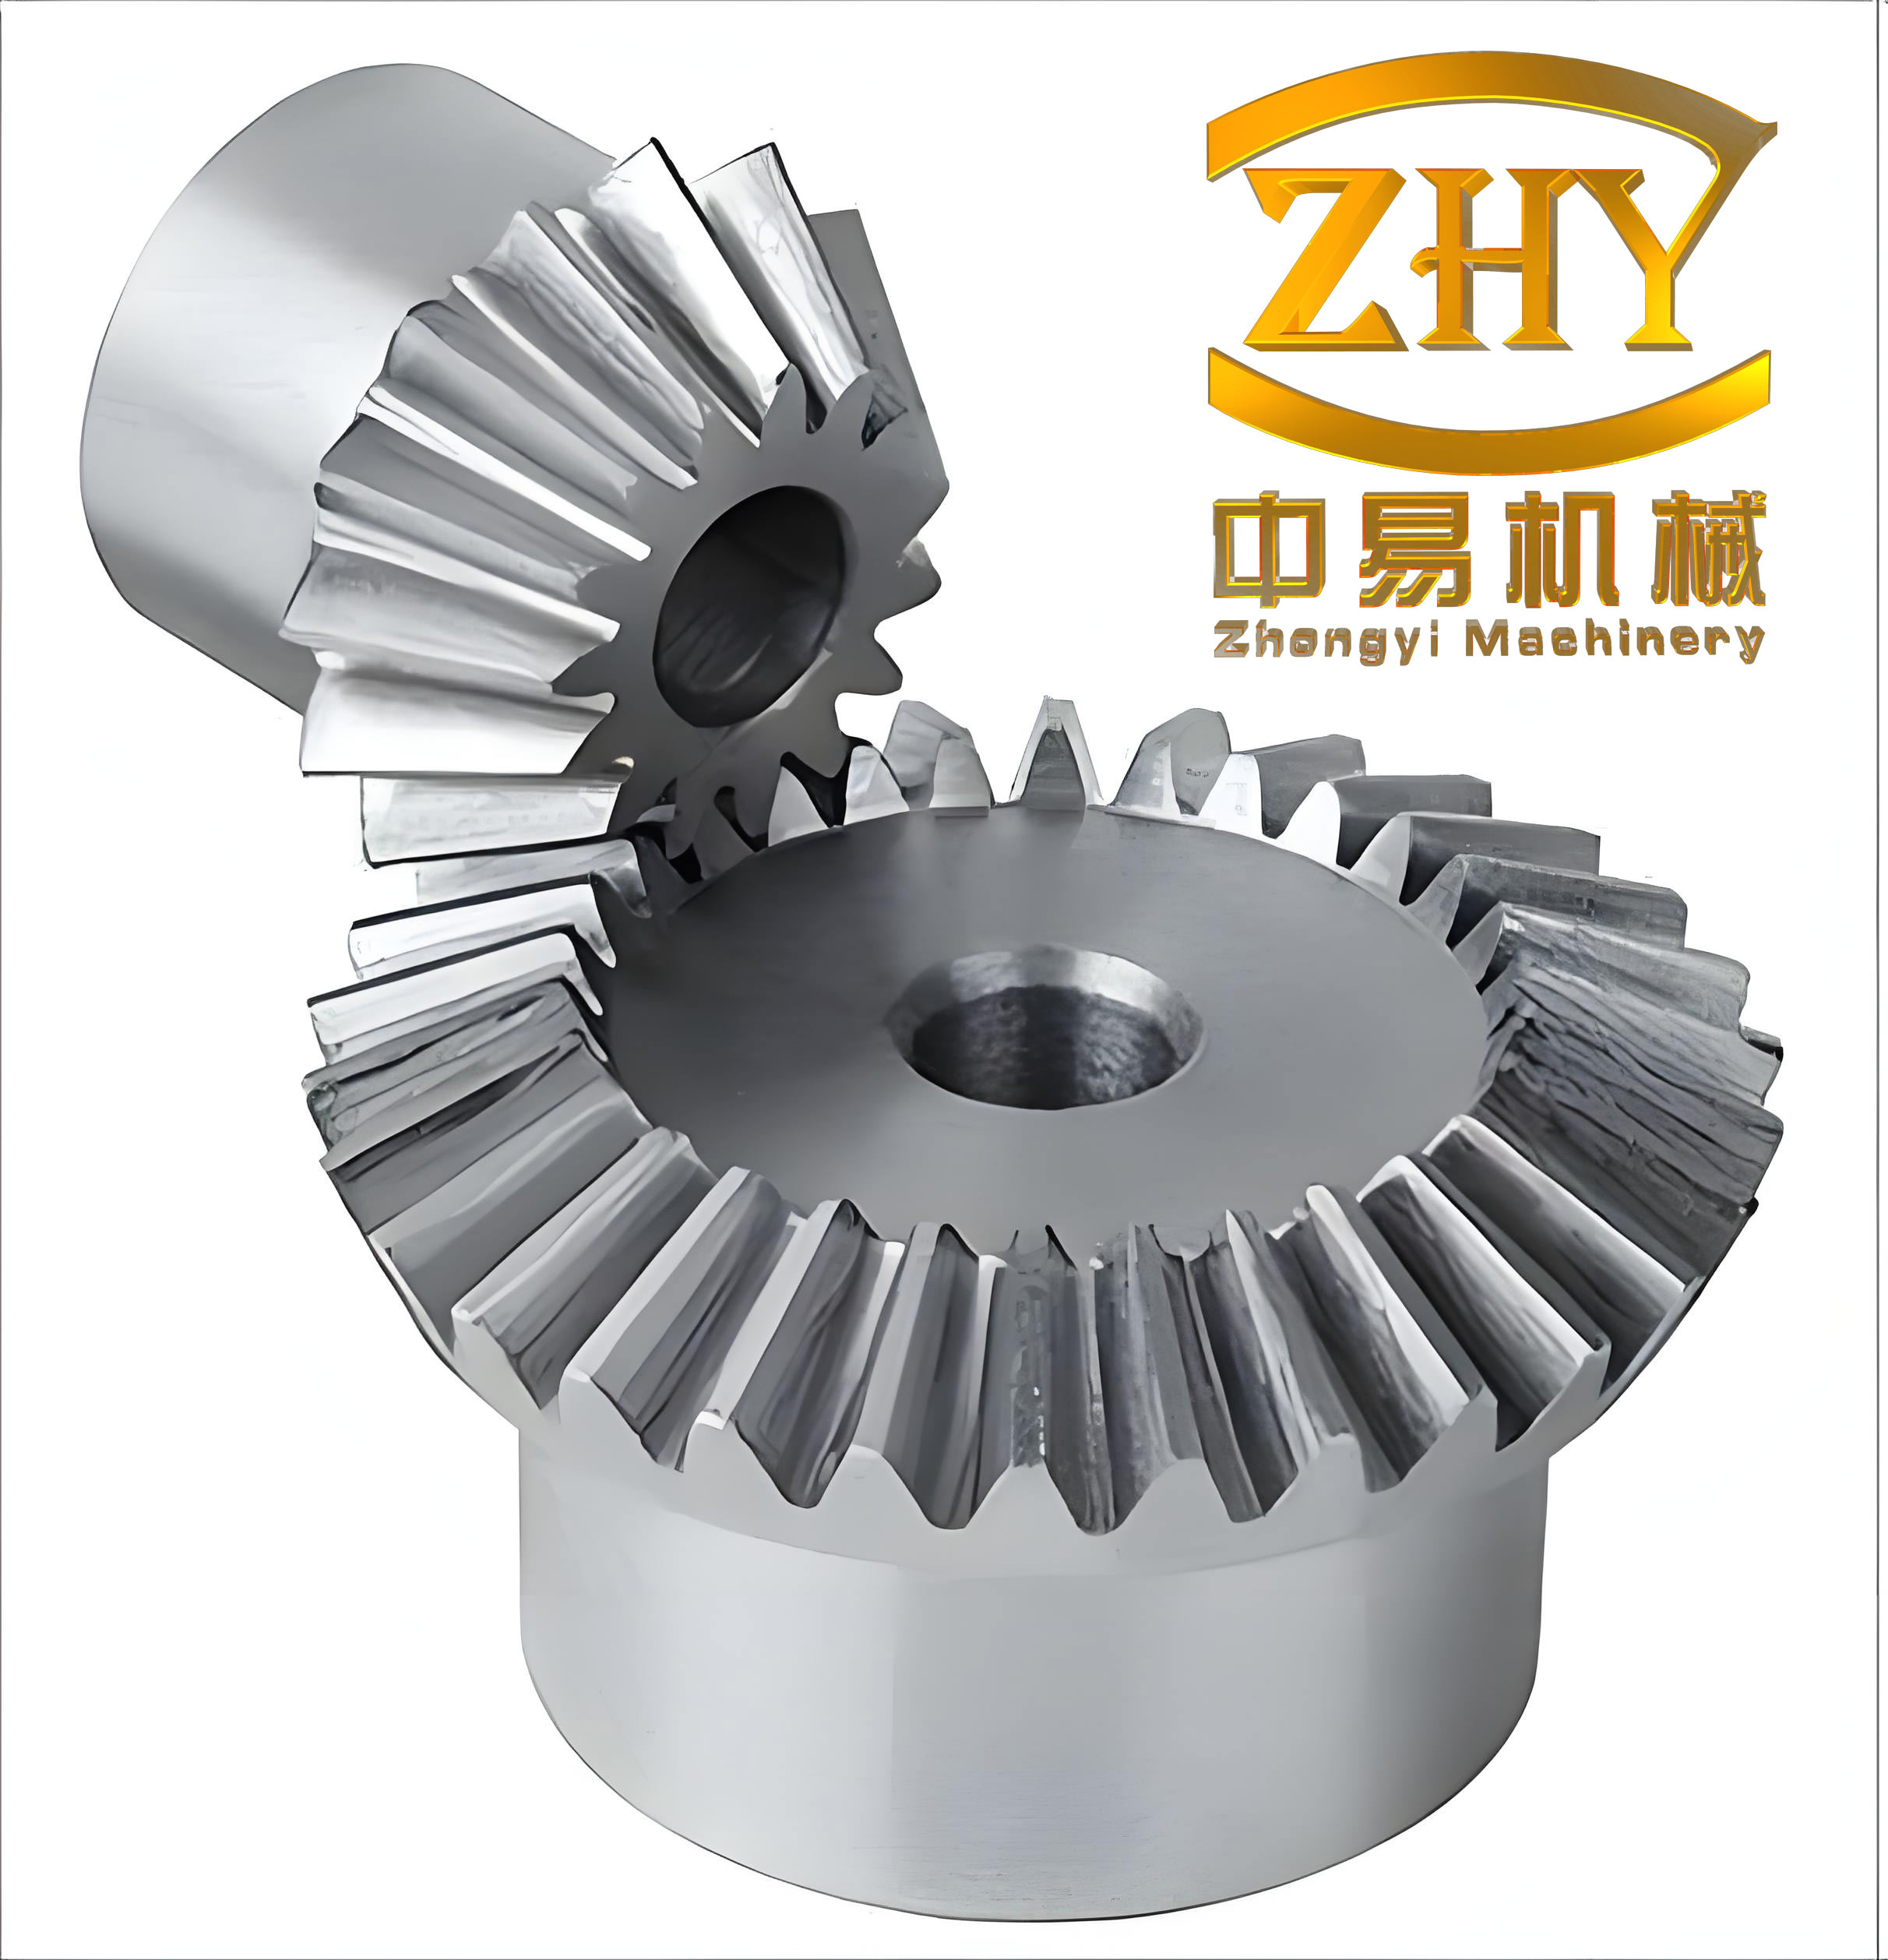
Gear transmission is one of the most fundamental forms of mechanical transmission, and gears are vital components in almost all mechanical systems. Bevel gears, specifically straight bevel gears, are designed for transmitting motion and power between two intersecting shafts, usually at a right angle. Compared with cylindrical gears, the tooth surface of straight bevel gears is more complex because it is formed on a conical surface. The theoretical tooth profile of straight bevel gears is a spherical involute, which significantly complicates the measurement process, as spherical surfaces cannot be flattened onto a planar surface without distortion.
The measurement techniques for gears have evolved remarkably over the past century. Traditional mechanical generating measurement methods rely on high-precision mechanical mechanisms to realize the relative generating motion between the probe and the workpiece. The measurement accuracy is then largely dependent on the accuracy of these mechanical generating mechanisms. However, the appearance of CNC (Computer Numerical Control) gear measuring centers has fundamentally transformed this situation. The CNC gear measuring center employs the so-called electronic generating method, in which the computer controls the servo axes to generate the desired relative motion trajectory between the probe and the gear. During the measurement, the computer simultaneously collects the probe readings and the coordinate values from the grating sensors. The actual coordinates of the measured points on the gear surface are then obtained and compared with the theoretical model to derive the error values.
In the past few decades, several foreign companies such as Klingelnberg, M&M Precision Systems, and Mahr have dominated the market for high-end CNC gear measuring centers. These instruments provide excellent measurement capabilities for a broad spectrum of gear types, including straight bevel gears, spiral bevel gears, and hypoid gears. Their measurement uncertainty can reach the level of 1 to 2 micrometers, meeting the strictest national or international standards. However, these advanced instruments are often astronomically priced, and strict export controls are imposed on the most accurate models. This situation poses significant challenges for the domestic gear manufacturing industry in China. Developing measurement instruments with independent intellectual property rights has therefore become a strategic priority.
Domestic research and development efforts have achieved encouraging progress in recent years. Several Chinese companies, including Harbin Measuring & Cutting Tool Group Co., Ltd. and Harbin Jingda Company, have successively launched their own CNC gear measuring centers with competitive performance and price advantages. Nevertheless, those instruments still have room for improvement in terms of measurement stability, software functionality, and failure diagnosis capabilities, especially when it comes to the measurement of conical gears. The present research seeks to contribute to this field by exploring the measurement and error evaluation technologies specifically tailored to straight bevel gears on a domestic CNC gear measuring center platform.
2. Mathematical Modeling of the Tooth Surface of Straight Bevel Gears
The precision measurement and error evaluation of straight bevel gears are heavily dependent on an accurate mathematical description of the desired tooth surface. Since straight bevel gears have a spherical involute tooth profile, it is essential to derive the exact equations governing the tooth surface geometry. This chapter first reviews the fundamental geometrical parameters of straight bevel gears and then proceeds to derive the mathematical expressions for both the left and right tooth surfaces, as well as their normal vectors.
2.1 Geometrical Parameters and Tooth Profile Generation
A standard straight bevel gear pair with an orthogonal shaft angle is shown in Table 1, which lists the main geometric parameters that are involved in the subsequent mathematical derivation and measurement procedure.
| Parameter | Symbol | Definition |
|---|---|---|
| Module | m | Ratio of pitch diameter to number of teeth |
| Number of teeth | z | Number of teeth on the gear |
| Face width | b | Width of the tooth measured along the pitch cone element |
| Shaft angle | S | Angle between the two intersecting axes (usually 90°) |
| Pitch angle | δ₀ | Angle between the pitch cone element and the gear axis |
| Root angle | δ_f | Angle between the root cone element and the gear axis |
| Face angle (tip angle) | δ_a | Angle between the face cone element and the gear axis |
| Pitch cone distance | R | Distance from the cone apex to the outer end of the tooth |
| Pressure angle | α | Standard pressure angle at the pitch circle (20° or 20°30′) |
| Addendum | h_a | Height of the tooth above the pitch cone |
| Dedendum | h_f | Depth of the tooth below the pitch cone |
| Mounting distance | M | Distance from the mounting surface to the cone apex |
The tooth surface of straight bevel gears is formed by the pure rolling of a plane (the generating plane) over the base cone. When a plane is rolled without slipping over the base cone, a straight line on the plane that passes through the cone apex traces out a spherical involute surface. This spherical involute surface constitutes the theoretical tooth flank of the straight bevel gear.
2.2 Derivation of the Tooth Surface Equations
For a detailed mathematical derivation, a spatial coordinate system is established with the origin at the cone apex. The Z-axis is aligned with the gear axis, pointing from the large end toward the small end. As illustrated in the axial cross-section, the relationship between the coordinates of an arbitrary point on the tooth surface can be expressed. Let an arbitrary point on the involute conical surface be denoted by its polar coordinates (r, δ, z), where r represents the distance from the cone apex to the point (the cone distance of that point), δ represents the cone angle of the conical surface at that point, and z represents the axial coordinate.
Considering the geometric relationship in the axial section of the gear, the radial distance from the axis at the base cone can be expressed. The base circle radius at the large end is given by:
$$ r_k = r \cdot \sin\delta $$
In the standard involute development, the pressure angle at a point K on the involute is determined by the ratio of the base radius to the radius of the point. For the bevel gear, this ratio is expressed through the tangent values of the corresponding cone angles. Thus, the pressure angle can be derived as:
$$ \alpha_k = \arccos\left( \frac{\tan\delta_f}{\tan\delta} \right) $$
The polar angle θ_k of the involute at point K is then expressed by the standard involute function:
$$ \theta_k = \tan\alpha_k – \alpha_k $$
Substituting the expression of α_k into the above equation yields the polar angle as a function of the cone angles δ_f and δ. The Z-coordinate of the point is related to r through the geometric construction of the conical surface. Specifically, the axial coordinate is determined by projecting the cone distance along the respective cone angles:
$$ z = \frac{R \cdot \cos\theta_f}{\cos\delta_f} – r \cdot \cos\delta $$
where θ_f denotes the root angle of the gear, which is defined as the difference between the pitch angle and the root angle. Combining all the above expressions, the left tooth surface of the straight bevel gear in cylindrical coordinates is governed by the following system of equations:
\[
\begin{cases}
r_k = r \cdot \sin\delta \\[2pt]
\theta_k = \tan\alpha_k – \alpha_k \\[2pt]
\alpha_k = \arccos\left( \dfrac{\tan\delta_f}{\tan\delta} \right) \\[2pt]
z = \dfrac{R \cdot \cos\theta_f}{\cos\delta_f} – r \cdot \cos\delta
\end{cases}
\]
These equations are further transformed into the Cartesian coordinate system. Taking the direction from the base circle center to the starting point of the involute on the left flank as the positive X-axis, and the gear axis as the Z-axis, the Cartesian coordinates of the left tooth surface are expressed as:
\[
\begin{cases}
x = r \cdot \sin\delta \cdot \cos\theta_k \\[2pt]
y = r \cdot \sin\delta \cdot \sin\theta_k \\[2pt]
z = \dfrac{R \cdot \cos\theta_f}{\cos\delta_f} – r \cdot \cos\delta
\end{cases}
\]
where r and δ serve as the two independent surface parameters. For the right tooth surface, a similar derivation is carried out by establishing a coordinate system with the Z-axis pointing in the opposite direction. Through a coordinate transformation involving a rotation around the Z-axis by an angle φ, the Cartesian equations of the right (counterclockwise involute) surface are obtained:
\[
\begin{cases}
x = r \cdot \sin\delta \cdot (\cos\theta_k \cdot \cos\phi + \sin\theta_k \cdot \sin\phi) \\[2pt]
y = r \cdot \sin\delta \cdot (\cos\theta_k \cdot \sin\phi – \sin\theta_k \cdot \cos\phi) \\[2pt]
z = \dfrac{R \cdot \cos\theta_f}{\cos\delta_f} – r \cdot \cos\delta
\end{cases}
\]
2.3 Derivation of the Surface Normal Vectors
For the subsequent probe radius compensation, it is necessary to calculate the unit normal vector at any point on the tooth surface. The unit normal vector of a parametric surface described by the position vector H(r, δ) is obtained from the cross product of the two tangent vectors:
$$ \mathbf{n} = \frac{\mathbf{H}_r \times \mathbf{H}_\delta}{|\mathbf{H}_r \times \mathbf{H}_\delta|} $$
where H_r and H_δ are the partial derivatives of the position vector with respect to the parameters r and δ, respectively. After performing the partial differentiation and simplification, the unit normal vector of the left tooth surface is obtained. Similarly, the unit normal vector for the right tooth surface is derived by applying the same procedure to the right-hand surface equations. These normal vectors are crucial for correctly compensating the probe ball radius during the coordinate measurement process.
2.4 Visualization and Verification of the Mathematical Model
In order to verify the correctness of the established mathematical model, a visualization simulation was carried out using the Matlab software tool. Taking a typical straight bevel gear with the parameters listed below as an example, the three-dimensional tooth surface geometry was rendered from various perspectives, as shown in the figure. The gear parameters used for the simulation are: module = 9.222 mm, number of teeth = 10, face width = 24 mm, face angle = 39°20′, pitch angle = 32°, root angle = 27°23′, pressure angle = 20°30′, pitch cone distance = 87 mm, addendum = 9.46 mm, dedendum = 7.08 mm, mounting distance = 80.04 mm, and outside diameter = 100 mm. The rendered views presented a smooth and continuous tooth surface that conformed to the expected geometry, thereby confirming that the mathematical derivation is both theoretically sound and practically applicable.
3. Measurement Technology and Scheme Design
The measurement of straight bevel gears on a CNC gear measuring center is inherently a coordinate measurement process. The fundamental principle is to acquire a sequence of coordinate points on the actual tooth surface and compare those points with the nominal surface geometry represented by the mathematical model established in the previous chapter. The differences between the measured data and the theoretical model constitute the so-called tooth surface deviations.
3.1 Structure and Working Principle of the CNC Gear Measuring Center
The CNC gear measuring center utilized in this research is the model 3906 manufactured by Harbin Measuring & Cutting Tool Group Co., Ltd. The instrument primarily consists of three subsystems: the mechanical system, the measurement and control system, and the computer system. The mechanical system provides four motion axes: three mutually orthogonal linear axes (X, Y, Z) and one rotational axis (W). The workpiece is mounted on the rotary table, which is driven by the W-axis servo motor. The three linear axes position the probe relative to the workpiece. High-resolution grating scales are installed on each linear axis, and a circular grating is coaxially mounted on the spindle to measure the angular position. The measurement and control system receives commands from the computer, controls the servo drives, and acquires the probe signals and grating readings synchronously in real time. The computer system executes the measurement algorithm, processes the acquired data, and generates the measurement results.
The electronic generating method is realized through the CNC controller. During the measurement of a tooth profile, the computer calculates the theoretical trajectory of the probe relative to the gear based on the gear equations. The servo system drives the probe along this trajectory while the data acquisition system records the instantaneous probe deflections and the absolute coordinate readings from the gratings. Since the actual trajectory may deviate from the theoretical one due to various errors, these deviations are recorded and corrected in the subsequent data processing stage. This mechanism distinguishes the CNC gear measuring center from conventional mechanical instruments, where the accuracy of the measurement is strictly limited by the mechanical accuracy of the generating mechanism.
3.2 Measurement Path Planning
One of the most critical steps in the measurement of straight bevel gears is the planning of the probe measurement path. Since the tooth profile of straight bevel gears is the spherical involute, which cannot be unwrapped onto a flat plane, the profile deviation is measured on the equivalent cylindrical gear (the virtual gear that corresponds to the back cone of the bevel gear). The probe trajectory during a tooth profile measurement lies in a plane perpendicular to the pitch cone element.
For the helix deviation, the measurement is performed on the pitch circle. The probe moves along the pitch cone element from the large end to the small end of the gear, and the deviation is evaluated as a function of the face width. For the pitch deviation measurement, a single point is acquired on each tooth flank at the middle of the face width and at the middle of the tooth height. To obtain the cumulative pitch deviation, the probe is indexed around the entire gear. For the radial run-out measurement, a ball probe is placed in the tooth space, making contact simultaneously with both flanks of adjacent teeth. The radial movement of the probe relative to the gear axis is recorded as the gear rotates.
3.3 Zero Position Setting and Coordinate System Establishment
Before any measurement can be performed, it is essential to establish a precise relationship between the instrument coordinate system and the gear geometry. On the 3906 gear measuring center, the workpiece is mounted between the headstock and tailstock centers with a driving clamp. The process of zero setting begins with locating a reference sphere mounted on the machine table. The probe is brought into contact with the reference sphere, and a series of points on the sphere surface are acquired. From these points, the coordinates of the sphere center are fitted. This sphere center position serves as a reference point for the instrument coordinate system.
In contrast to the conventional method which involves locating the gear cone apex through the installation reference plane, this research adopts a simplified approach. Since the measuring probe is installed with its defection direction in the horizontal plane, only the standard sphere center needs to be determined. The known machine constant — the distance between the standard sphere center and the spindle axis — is then used to establish the X and Y coordinates of the spindle axis. The Z coordinate of the sphere center is taken as the Z-axis zero reference. This simplified procedure considerably reduces the preparation time while maintaining sufficient accuracy for the subsequent measurements.
3.4 Probe Radius Compensation
During the measurement, the contact between the probe ball and the tooth surface occurs at a point that is not necessarily collinear with the probe center in the measurement direction. Since the tooth surface is a curved three-dimensional surface, the actual contact point differs from the probe center position by an offset equal to the probe ball radius along the surface normal direction. In this research, the contact point trajectory method based on the equidistant surface principle is adopted for probe radius compensation. It is assumed that the actual contact point B_i lies on the surface normal vector n at the theoretical contact point. Given the measured probe center coordinates (x′_i, y′_i, z′_i), the actual contact point coordinates (x_i, y_i, z_i) on the tooth surface are obtained through the following compensation equations:
\[
\begin{cases}
x_i = x’_i – \Delta\rho_{xi} \\[2pt]
y_i = y’_i – \Delta\rho_{yi} \\[2pt]
z_i = z’_i – \Delta\rho_{zi}
\end{cases}
\]
where the compensation components are calculated as:
$$ \Delta\rho_{xi} = R \cdot n_{xi}, \qquad \Delta\rho_{yi} = R \cdot n_{yi}, \qquad \Delta\rho_{zi} = R \cdot n_{zi} $$
with R being the probe ball radius and n = (nx, ny, nz) being the unit normal vector at the contact point, which is obtained from the mathematical model of the tooth surface described in chapter 2.
4. Error Evaluation Methods for Straight Bevel Gears
This chapter focuses on the evaluation methodologies for the most important individual errors of straight bevel gears, namely the tooth profile deviation, helix deviation, pitch deviation, and radial run-out. According to the national standard GB/T10095.1-2001, these deviations are defined with respect to the design (theoretical) tooth flank and the actual measurable tooth flank.
4.1 Tooth Profile Deviation
Tooth profile deviation is evaluated on the equivalent cylindrical gear of the straight bevel gear in a plane perpendicular to the pitch cone element. The measured profile is compared with the theoretical involute profile, and the deviations are plotted against the roll length. The following three parameters are defined:
Total profile deviation (Fα) — the distance between two design profile lines that enclose the actual profile trace within the evaluation range. In software implementation, it is computed as the difference between the maximum and minimum values of the profile deviation points within the evaluation range.
Profile shape deviation (ffα) — the distance between two curves that are exactly identical to the average profile trace and that enclose the actual profile trace within the evaluation range. It represents the random component of the profile deviation after removing the systematic trend.
Profile slope deviation (fHα) — the distance between two design profile traces that intersect the average profile trace at the endpoints of the evaluation range. It reflects the systematic inclination of the measured profile relative to the design profile.
The average profile trace is determined using the least squares principle. It is obtained by subtracting a straight line from the design profile trace, where the position and inclination of this straight line are chosen such that the sum of squares of the residuals between the actual profile trace and the average profile trace is minimized.
4.2 Helix Deviation
Helix deviation is evaluated on the pitch circle along the direction of the pitch cone element. The probe traverses from the large end to the small end of the gear, and the deviations of the actual helix line relative to the design helix line are recorded. Similar to the profile deviation, three corresponding parameters are defined:
Total helix deviation (Fβ) — the distance between two design helix lines enclosing the actual helix trace within the evaluation range.
Helix shape deviation (ffβ) — the distance between two curves identical to the average helix trace that enclose the actual helix trace.
Helix slope deviation (fHβ) — the distance between two design helix traces intersecting the average helix trace at the endpoints of the evaluation range.
The computation follows the same least squares regression methodology as for the profile deviation. The average helix trace is derived by fitting a straight line that minimizes the squared residuals of the actual helix deviation points.
4.3 Pitch Deviation
Pitch deviation of straight bevel gears is defined on the pitch circle at the middle of the face width. The following parameters are evaluated:
Single pitch deviation (fpt) — the algebraic difference between the actual pitch and the theoretical pitch at the measurement radius. During the measurement, the angular positions of all the teeth on the same flank are recorded. The theoretical pitch angle is determined by the formula:
$$ \tau_p = \frac{2\pi}{z} $$
The actual angular increment between successive teeth is computed from the measured angular positions. The single pitch deviation for the i-th tooth is then calculated as:
$$ f_{pt,i} = r_m \cdot \Delta\theta_i – p_s $$
where Δθ_i is the actual angular increment between tooth (i-1) and tooth i, r_m is the measurement radius, and p_s is the nominal pitch arc length at that radius.
Cumulative pitch deviation over k teeth (Fpk) — the algebraic sum of k consecutive single pitch deviations, representing the accumulated error over a group of k tooth intervals.
Total cumulative pitch deviation (Fp) — the algebraic sum of all single pitch deviations around the entire gear. It represents the maximum range of the cumulative pitch deviation curve.
4.4 Radial Run-out Error
Radial run-out (Fr) of straight bevel gears is defined as the maximum variation of the measuring probe position relative to the gear axis when a probe is placed in the tooth space and makes double-flank contact with both tooth flanks at the pitch circle level. The measurement is performed in a direction perpendicular to the pitch cone element. Radial run-out is often caused by the eccentricity between the gear blank axis and the indexing axis during manufacturing. In practice, the radial run-out measurement can be carried out simultaneously with the pitch measurement. By analyzing the measured radial positions of the probe in each tooth space, the radial run-out error curve is constructed, and the maximum range of this curve is reported as the radial run-out value.
4.5 Least Squares Based Evaluation Model
For both profile and helix deviation evaluations, the least squares method plays a central role in extracting the average deviation trace. Given a set of n measured deviation points y_i corresponding to the positions x_i, the regression line is expressed as:
$$ \hat{y}(x) = a + b \cdot x $$
The coefficients a and b are determined by minimizing the sum of squared residuals:
$$ \sum_{i=1}^{n} \left[ y_i – (a + b \cdot x_i) \right]^2 = \min $$
Solving this optimization problem yields the explicit formulas for the slope b and intercept a. Once the average trace is determined, the total deviation, shape deviation, and slope deviation are computed according to the definitions given above.
5. Software Development and Measurement Experiments
5.1 Software System Design
The error evaluation software package for straight bevel gears was developed in the Visual Basic 2005 programming environment. This development platform offers a rich set of object-oriented features, comprehensive graphical user interface design tools, and a robust runtime framework. The software architecture follows a modular design philosophy, which greatly facilitates maintenance, testing, and future extensions. The overall system is organized into several functional modules: geometrical parameter input, measurement task configuration, data acquisition and communication, error evaluation, and result visualization and report generation.
The program flow starts with the specification of the gear parameters. A dedicated input interface allows the operator to enter all the required geometrical data of the straight bevel gear. After the initial data entry, the operator selects the measurement task (e.g., profile measurement, helix measurement, pitch measurement, or radial run-out measurement). The measurement control module then guides the CNC system through the specified measurement path, collecting the raw data points. Finally, the error evaluation module processes the raw coordinate data and generates the deviation curves and error values.
The main functions of the error evaluation software package are summarized in Table 2.
| Module | Function Description |
|---|---|
| Parameter input | Input of gear module, number of teeth, face width, pitch angle, pressure angle, etc. |
| Profile evaluation | Calculation of Fα, ffα, fHα with least squares average trace |
| Helix evaluation | Calculation of Fβ, ffβ, fHβ with least squares average trace |
| Pitch evaluation | Calculation of fpt, Fpk, Fp for both left and right flanks |
| Radial run-out evaluation | Calculation of Fr from the tooth space measurements |
| Result visualization | Graphical display of deviation curves and report generation |
5.2 Measurement Experiments
To validate the mathematical model, the measurement scheme, and the error evaluation software, a series of measurement experiments was carried out on the 3906 CNC gear measuring center. The tested straight bevel gear has the following parameters: module m = 9.222 mm, number of teeth z = 10, face width b = 24 mm, face angle δ_a = 39°20′, pitch angle δ₀ = 32°, root angle δ_f = 27°23′, pressure angle α = 20°30′, pitch cone distance R = 87 mm, addendum h_a = 9.46 mm, dedendum h_f = 7.08 mm, mounting distance M = 80.04 mm, and outside diameter d_a = 100 mm.
Profile measurement. The profile deviation was measured in the plane perpendicular to the pitch cone element. The probe moved along the theoretical involute path and recorded the deviations at discrete roll length positions. The evaluation range was selected according to the standard definition. The measured profile deviation data were processed by the software module, and the resulting deviation curve was generated. The computed profile error values are listed in Table 3.
| Total profile deviation Fα (μm) | Profile shape deviation ffα (μm) | Profile slope deviation fHα (μm) |
|---|---|---|
| 77.6 | 37.0 | 61.4 |
Helix measurement. The helix deviation was measured along the pitch cone element on the pitch circle. The probe traversed from the large end toward the small end of the gear while the deviation signals were recorded. The measured helix deviation data were processed, and the deviation curve was plotted. The evaluated helix error values are presented in Table 4.
| Total helix deviation Fβ (μm) | Helix shape deviation ffβ (μm) | Helix slope deviation fHβ (μm) |
|---|---|---|
| 26.2 | 19.1 | 11.6 |
Pitch measurement. Pitch measurement was conducted at the middle of the face width on the pitch circle of the gear. A single measurement point was acquired on each tooth flank for all ten teeth, and the first tooth was measured twice to verify repeatability. The measured angular positions were used to compute the single pitch deviation, the cumulative pitch deviation over three consecutive teeth, and the total cumulative pitch deviation for both the left and right flanks. The corresponding deviation curves are depicted in the figures, and the computed pitch error values are summarized in Table 5.
| Flank | Total cumulative pitch deviation Fp (μm) | 3-tooth cumulative deviation Fp3 (μm) | Single pitch deviation fpt (μm) | Tooth with max deviation |
|---|---|---|---|---|
| Left flank | 70.0 | 70.2 | 30.4 | Tooth 0 / 6 |
| Right flank | 45.6 | 52.0 | 32.5 | Tooth 5 / 7 |
Radial run-out measurement. The radial run-out was measured simultaneously with the pitch measurement by placing the probe in each tooth space of the gear. The radial position of the probe was recorded for every tooth space during one complete revolution of the gear. The radial run-out deviation curve was generated by plotting the measured radial positions as a function of the tooth space number, and the maximum range was evaluated as the radial run-out value. The radial run-out error was evaluated as 3.5 μm for this gear.
5.3 Discussion of Experimental Results
The measurement results obtained from the experiments were compared with those from the reference measurements performed on the production prototype instrument of the manufacturer. The comparison indicated that the deviations between the two sets of measurement results remain within the permitted tolerance range, demonstrating that the error evaluation software module developed in this research is feasible and reliable. The profile deviation values are relatively large, which suggests that the tooth profile generation of the tested gear may have some systematic deviation from the theoretical spherical involute profile. This could originate from the chosen manufacturing method or from the approximations introduced by using the equivalent cylindrical gear profile to represent the spherical involute. The helix deviation values are smaller than the profile deviation values, indicating a relatively better geometric accuracy in the longitudinal direction of the tooth. The radial run-out value is notably small for this gear, which indicates that the gear blank eccentricity and the indexing errors of the manufacturing equipment are well controlled.
It should also be mentioned that the measurement of straight bevel gears presents additional challenges compared to cylindrical gears because the mounting of the gear and the alignment of the instrument coordinate system have a significant influence on the final results. The simplified zero-position setting procedure adopted in this research contributes to a more efficient workflow. In the future, further improvements could focus on the online auto-calibration of the probe system, the optimization of the measurement path for higher measurement efficiency, and the extension of the current methodology to the measurement of spiral bevel gears and hypoid gears.
Conclusions
This dissertation has systematically investigated the measurement technology and error evaluation methodology for straight bevel gears on a CNC gear measuring center. The main contributions and conclusions of this research are summarized as follows:
First, a comprehensive mathematical model of the tooth surface of straight bevel gears has been established. Based on the analysis of the tooth surface generation principle, the equations of the tooth surface and the surface normal were derived for both the left and right flanks. The mathematical model was visualized and verified using the Matlab simulation environment, confirming its correctness and applicability to subsequent measurement and evaluation procedures.
Second, a complete measurement scheme for straight bevel gears has been designed. On the basis of an in-depth analysis of the composition and operating principle of the CNC gear measuring center, the probe path planning and zero position setting procedures were developed. The probe radius compensation method based on the contact point trajectory principle was studied and implemented, which correctly transforms the probe center coordinates into the actual contact point coordinates on the tooth surface.
Third, the error evaluation techniques for key individual errors of straight bevel gears were thoroughly studied. The evaluation algorithms for the profile deviation, helix deviation, pitch deviation, and radial run-out were established based on the least squares principle. The definitions of the total deviation, shape deviation, and slope deviation were interpreted and implemented in the software. An error evaluation software package was successfully developed in the Visual Basic 2005 environment, providing the functions of automatic data processing, deviation curve plotting, and error value calculation.
Fourth, measurement experiments were conducted on a real straight bevel gear using the 3906 CNC gear measuring center. The experimental results confirm that the mathematical model and the error evaluation methodology established in this dissertation are correct, the measurement scheme is reasonable, and the accuracy of the error evaluation software module satisfies the technical requirements of the project.
The research work presented in this dissertation provides a solid foundation for the further development of gear measuring centers with independent intellectual property rights. It contributes to improving the quality of domestic gear products and enhancing their international competitiveness. Moreover, the results of this work can be extended to the measurement of other types of conical gears, such as spiral bevel gears and hypoid gears, which are widely used in the automotive and aerospace industries.