
Introduction. In recent years, the demand for high-precision straight bevel gears has increased rapidly in automotive, aerospace, and industrial machinery. The manufacturing of straight bevel gears by precision forging has become a common practice because it reduces material waste and improves productivity. However, ensuring the quality of every straight bevel gear produced requires reliable and efficient inspection methods. Traditional inspection instruments such as gear integrated error checkers and single-flank meshing testers are capable of high accuracy, but they are expensive and sensitive to environmental conditions. They are often unsuitable for shop-floor use. For straight bevel gears, the double-flank meshing test offers a practical solution. I have therefore developed a dedicated double-flank meshing tester for straight bevel gears. This instrument is designed to measure the center distance variation when a straight bevel gear is meshed under zero backlash with a master gear. The tester provides a comprehensive assessment of gear quality, including single-tooth runout and total tooth runout. The design emphasizes simplicity, reliability, and low cost, making it ideal for on-line inspection of straight bevel gears in mass production.
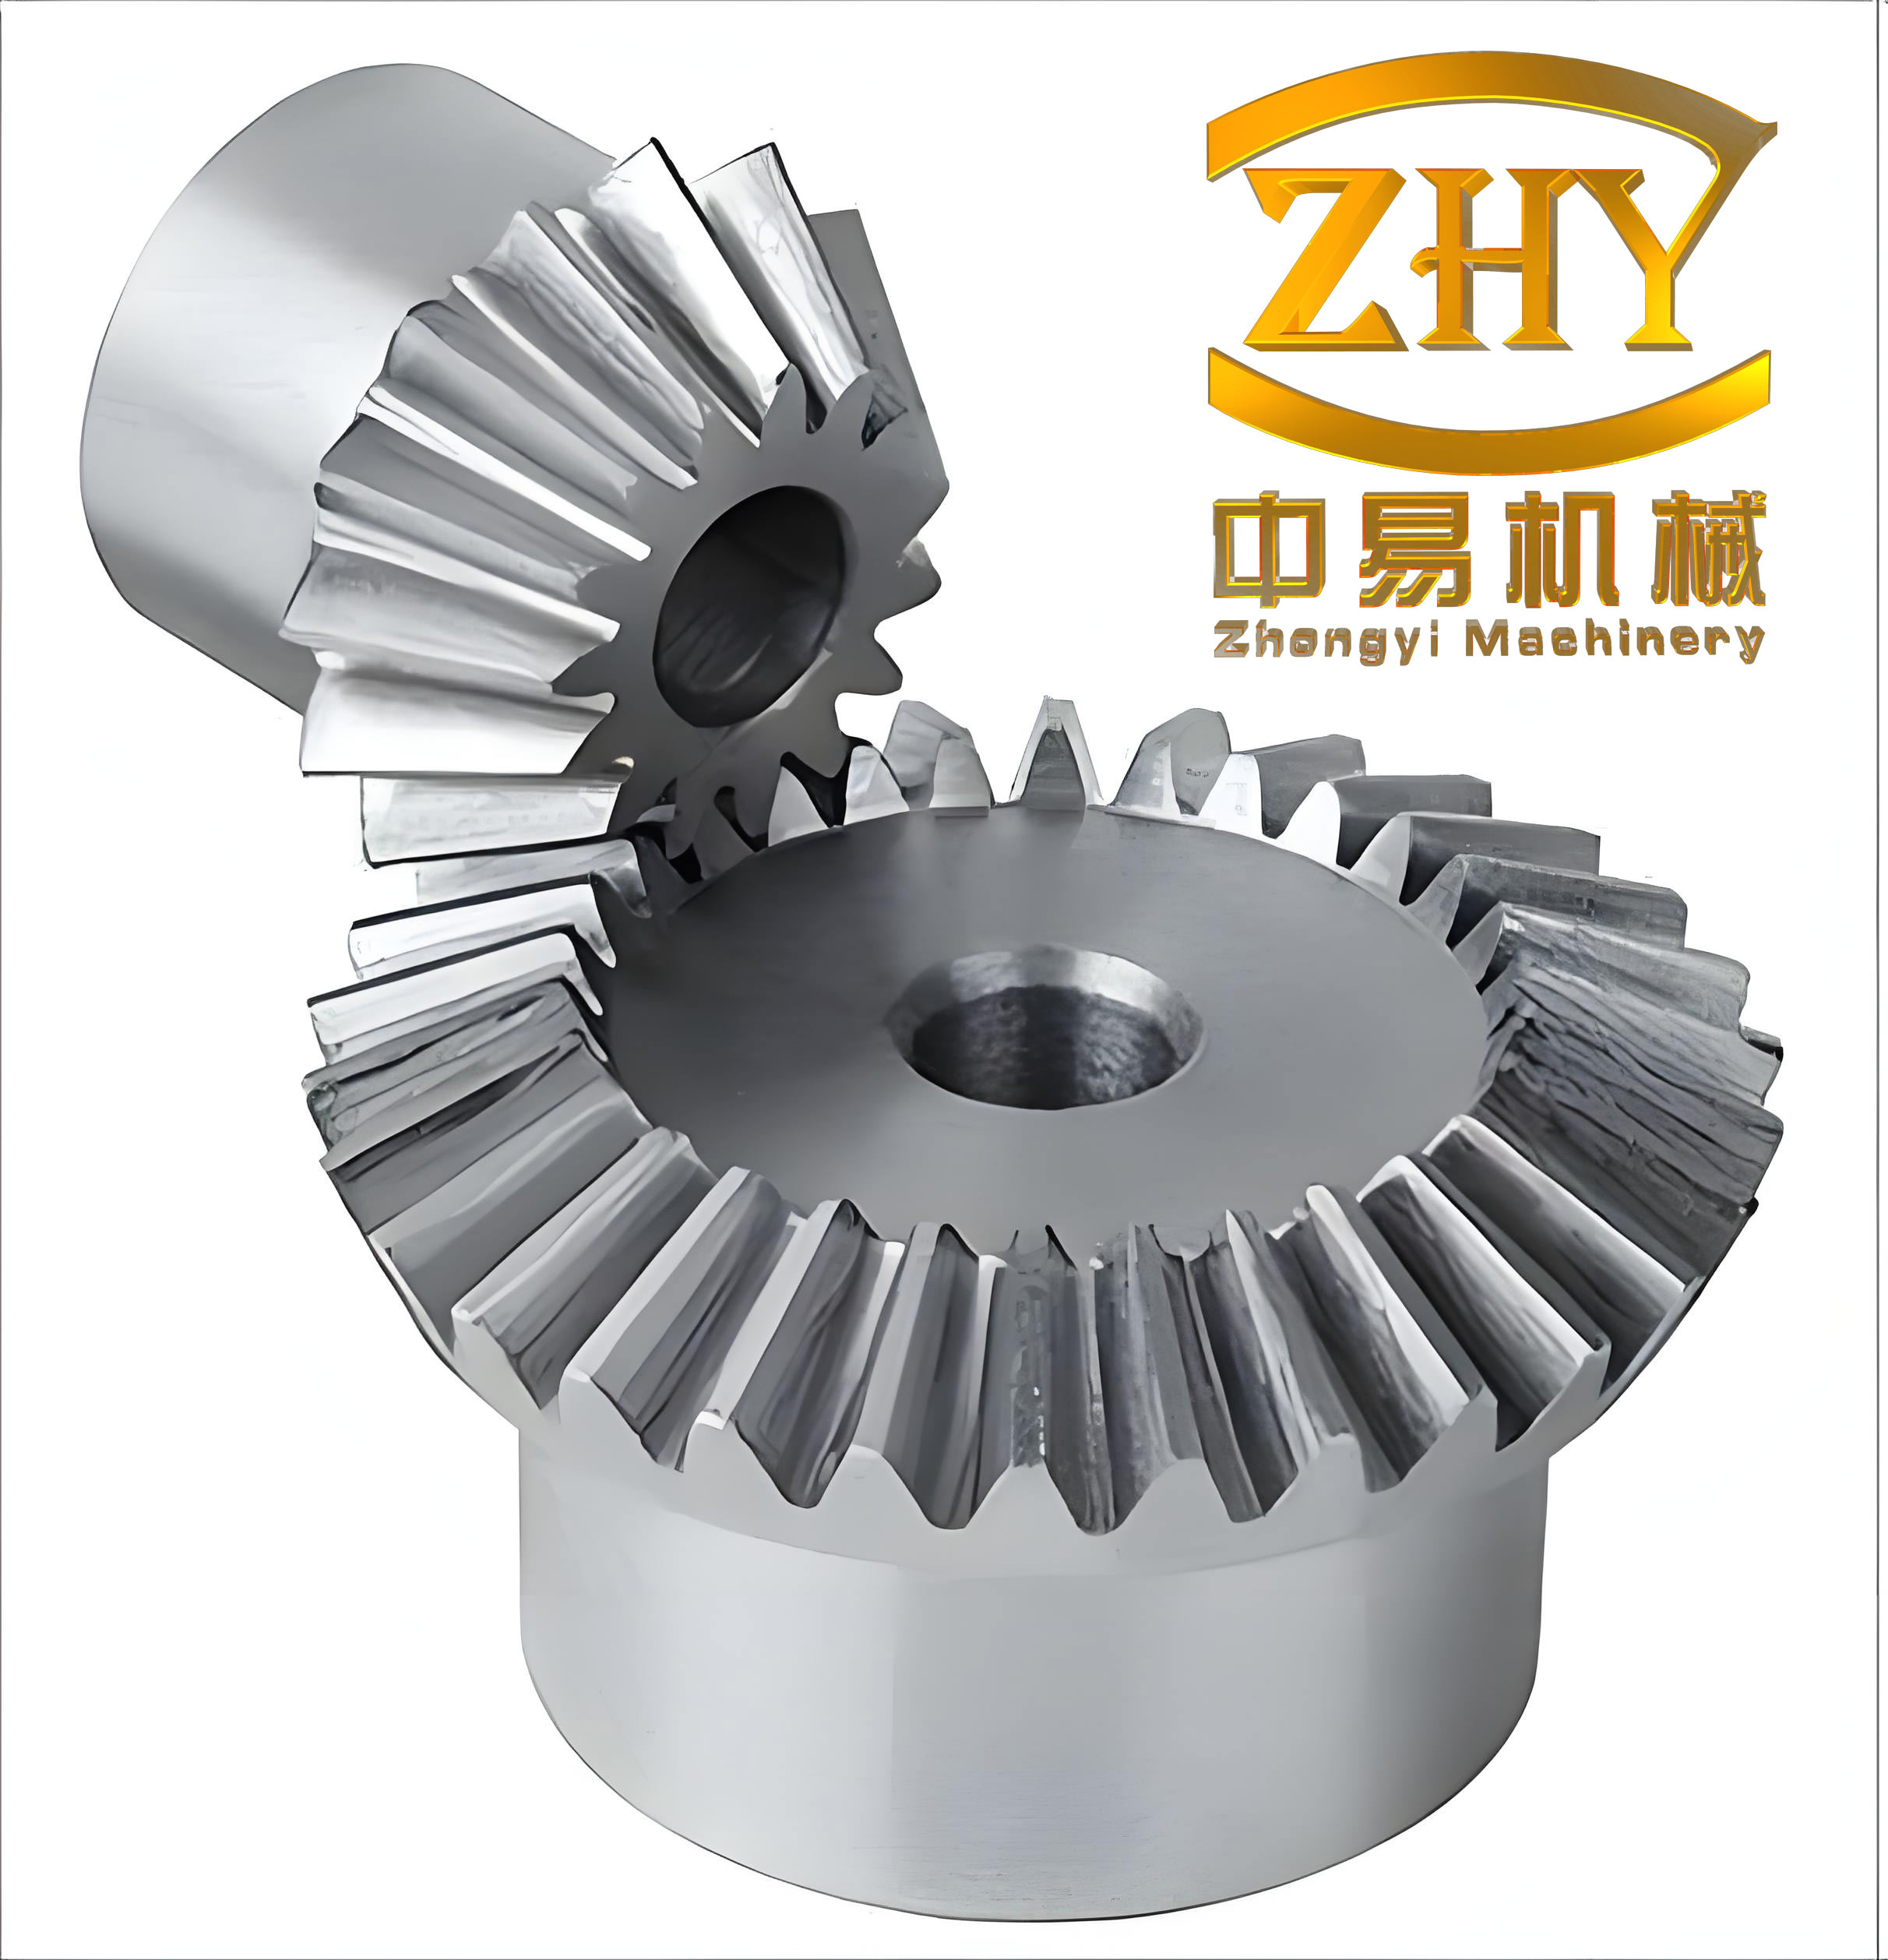
Significance of the Development. The significance of developing this double-flank meshing tester for straight bevel gears can be summarized in three aspects: economic efficiency, structural simplicity, and functional capability. First, commercially available double-flank meshing testers are generally priced from tens of thousands to hundreds of thousands of dollars. In contrast, the total manufacturing cost of my designed tester is approximately a few thousand dollars. This represents a substantial cost saving for small and medium-sized enterprises that produce straight bevel gears. Second, the structural design is simple and reliable. The tester uses basic positioning elements, robust clamping devices, and rolling guideways with low friction. These features are minimally affected by the factory environment. Therefore, when inspecting straight bevel gears, the tester can ensure consistency in tooth thickness and installation distance. Third, the tester is highly functional. It is very suitable for on-line measurement. It can measure the variation of center distance, read both single-tooth runout and total tooth runout, and continuously reflect the meshing point error of the entire gear. Consequently, the double-flank meshing tester provides convenient and accurate comprehensive inspection of straight bevel gear parameters.
Design Requirements and Scheme. The double-flank meshing comprehensive measurement of straight bevel gears refers to the measurement of the center distance variation when the tested gear is rotated in double-flank mesh with an ideal precision master gear under zero backlash. The double-flank meshing tester must have accurate positioning and precise reading. In addition, because this inspection is essentially one hundred percent inspection, the tester must also feature rapid clamping and high inspection efficiency. The basic structure and working principle are as follows. A base is equipped with a body for mounting the half-shaft gear. An adjustable slide is also mounted on the base for mounting the planet gear. The center lines of the holes of these two components intersect perpendicularly. After the tester is adjusted to the appropriate dimensions and the master gear and the tested gear are installed, the adjustable slide uses a spring to ensure zero-backlash meshing between the tested gear and the master gear. A dial indicator installed at the rear of the base displays the variation of the center distance. A cam device mounted on the base can inspect the meshing condition of the gear at the standard installation distance. The design requirements are summarized in Table 1.
| Requirement | Description | Target Value |
|---|---|---|
| Measurement principle | Double-flank meshing under zero backlash | Center distance variation |
| Positioning accuracy | Half-shaft gear and planet gear | ≤ 0.005 mm |
| Reading resolution | Dial indicator or digital probe | 0.001 mm |
| Clamping time | Workpiece loading and unloading | ≤ 10 s |
| Environmental tolerance | Shop-floor conditions | Temperature 10–40 °C |
| Cost | Total manufacturing cost | Low, affordable for SMEs |
Basic Structure and Working Principle. The tester consists of a base, a body, an adjustable slide, a spring, a dial indicator, and a cam device. The body is used to assemble the half-shaft gear. The adjustable slide is used to assemble the planet gear. The center lines of the holes in the body and the slide are perpendicular and intersecting. When the tester is adjusted to the correct size and the master gear and the tested straight bevel gear are installed, the adjustable slide, under the action of the spring, ensures that the tested gear and the master gear mesh with zero backlash. The dial indicator at the rear of the base displays the variation of the center distance. The cam device on the base can check the meshing condition of the gear at the standard installation distance. The functional relationship between the center distance variation and the gear parameters can be expressed as follows. Let the initial center distance be \(a_0\) and the instantaneous center distance be \(a_i\). The center distance variation is
$$ \Delta a = a_i – a_0 . $$
The single-tooth runout \(f_i”\) and the total tooth runout \(F_i”\) are derived from the recorded center distance variation:
$$ f_i” = \max_{k} (\Delta a_k) – \min_{k} (\Delta a_k) , $$
$$ F_i” = \max_{i} (\Delta a_i) – \min_{i} (\Delta a_i) . $$
These parameters directly reflect the radial composite error of the straight bevel gear. The double-flank meshing test is particularly useful because it simulates the actual meshing condition more closely than single-flank testing. It can comprehensively reflect the manufacturing quality of the straight bevel gear, including tooth thickness variation, pitch error, and profile error. The basic structure and function of each module are listed in Table 2.
| Module | Function | Key Feature |
|---|---|---|
| Base | Supports all components | Rigid cast iron structure |
| Body | Mounts half-shaft gear | Precise bore and end face |
| Adjustable slide | Mounts planet gear | Rolling guideway |
| Spring | Provides zero-backlash meshing force | Constant force |
| Dial indicator | Reads center distance variation | Resolution 0.001 mm |
| Cam device | Checks standard installation distance | Eccentric mechanism |
Key Technology: Guideway. The guideway used in the double-flank meshing tester is a rolling guideway. The moving component has two V-shaped grooves that cooperate with a V-shaped groove and a flat surface on the body. Three balls are used as positioning supports. The tension spring is arranged at the center of gravity of the triangle formed by the three ball support points. The sum of the weight and load of the moving component is small, and the moving component is ensured to be flexible and stable. Because the moving component and the body of the tester are relatively large, hardened steel pads are installed on the ball sliding surfaces. During assembly, semi-cylindrical pressure plates are used to press the steel pads. This structure has good manufacturability and is convenient for future repair. The friction force in the rolling guideway is
$$ F_f = \mu N , $$
where \(\mu\) is the coefficient of rolling friction and \(N\) is the normal load. For a rolling guideway, \(\mu\) is typically between 0.001 and 0.005, which is much lower than the sliding friction coefficient of 0.1 to 0.2. This low friction ensures that the spring force is sufficient to maintain zero-backlash meshing without excessive force. The guideway also automatically eliminates clearance, which is especially suitable for double-flank meshing inspection of straight bevel gears. The guideway design parameters are summarized in Table 3.
| Parameter | Value | Unit |
|---|---|---|
| Number of balls | 3 | — |
| Ball diameter | 6 | mm |
| Rolling friction coefficient | 0.002 | — |
| Spring force | 50–100 | N |
| Guideway travel | 20 | mm |
| Hardened steel pad hardness | 60–62 | HRC |
Key Technology: Half-Shaft Gear Positioning and Loading. The half-shaft gear, including the master gear, is positioned by its outer cylindrical surface and end face. There are two handles on the right side. The small handle is used to clamp the workpiece. A pull rod connected to the small handle by threads has a groove. A screw fixed on the body controls the stroke of the pull rod. Loading and unloading of the workpiece are realized by a split washer. The large handle is connected to the spindle as one body and is used to rotate the workpiece to achieve meshing rotation. It is the power element in the comprehensive measurement. To ensure flexible rotation of the spindle, both radial and axial clearances must be reasonable. If the clearance is too large, play will occur and measurement accuracy cannot be guaranteed. If the clearance is too small, the spindle will rotate sluggishly or become stuck. Regardless of the rotational position of the workpiece, the positioning end face of the half-shaft gear should remain stationary relative to the planet gear. The relevant clearance relationships can be expressed as
$$ c_r = D_b – d_s , $$
$$ c_a = L_b – L_s , $$
where \(c_r\) is the radial clearance, \(D_b\) is the bore diameter, \(d_s\) is the spindle diameter, \(c_a\) is the axial clearance, \(L_b\) is the bore length, and \(L_s\) is the spindle length. Recommended values are \(c_r = 0.005–0.010\) mm and \(c_a = 0.005–0.015\) mm. These clearances ensure both positioning accuracy and free rotation. The positioning and loading elements are described in Table 4.
| Element | Function | Specification |
|---|---|---|
| Outer cylindrical surface | Radial positioning | Fit tolerance H7/g6 |
| End face | Axial positioning | Perpendicularity ≤ 0.005 mm |
| Small handle | Clamping workpiece | Thread M8 |
| Pull rod | Stroke control | Groove width 5 mm |
| Split washer | Loading and unloading | Thickness 2 mm |
| Large handle | Rotating workpiece | Connected to spindle |
| Spindle | Rotation axis | Radial clearance 0.005–0.010 mm |
Key Technology: Planet Gear Positioning and Loading. The planet gear, including the master gear, is positioned by its spherical surface and inner bore. A CNC process can be used to machine a high-quality spherical surface. The mating surface is treated by nitriding. A coordinate measuring machine is used for verification. When loading and unloading the planet gear, because the shaft must rotate, the connecting flange can be used as a dust seal. The end face of the flange is ground, and the radial clearance of the bore is reduced to ensure cleanliness inside the flange. The spherical positioning ensures self-aligning capability, which is essential for straight bevel gears because their axes intersect at an angle. The self-aligning condition can be written as
$$ \alpha_s = \alpha_p , $$
where \(\alpha_s\) is the spherical center angle and \(\alpha_p\) is the planet gear angle. The nitrided surface hardness is typically 550–650 HV, and the surface roughness \(R_a\) is less than 0.2 μm. The positioning and loading parameters are listed in Table 5.
| Parameter | Value | Unit |
|---|---|---|
| Spherical diameter | 40 | mm |
| Sphericity | 0.003 | mm |
| Inner bore diameter | 20 | mm |
| Nitriding hardness | 600 | HV |
| Surface roughness \(R_a\) | 0.1 | μm |
| Flange radial clearance | 0.005 | mm |
Key Technology: Eccentric Mechanism. The double-flank meshing tester must solve the problems of measurement and loading. The prerequisite for loading and unloading the workpiece is sufficient space. This tester uses an eccentric mechanism so that the slide can move a sufficient distance relative to the half-shaft gear in the horizontal plane. This distance is determined jointly by the travel of the guideway and the travel of the eccentric mechanism. The travel of the eccentric mechanism depends on the eccentricity. It is also closely related to the travel of the rolling guideway. The link between them is the position of the angle plate. Only when the position of the angle plate is correctly determined can the guideway travel and the eccentric mechanism travel have sufficient overlapping length, giving the workpiece enough loading and unloading space. The calculation of these three travels and the angle plate position involves many complex parts. The eccentric wheel is connected to a long handle. There are two pins on the body of the tester. These pins limit the extreme positions of the long handle and also limit the position of the slide, thereby determining whether the planet gear is in the working or loading state. This makes the tester very convenient to use. The displacement of the slide due to the eccentric mechanism can be expressed as
$$ s = e (1 – \cos \theta) + L (1 – \cos \phi) , $$
where \(e\) is the eccentricity, \(\theta\) is the rotation angle of the eccentric wheel, \(L\) is the connecting rod length, and \(\phi\) is the connecting rod angle. For a typical design, \(e = 5\) mm, \(\theta_{\max} = 90^\circ\), \(L = 50\) mm, and \(\phi_{\max} = 10^\circ\). The total travel is then approximately \(s = 5(1 – 0) + 50(1 – 0.985) = 5 + 0.75 = 5.75\) mm, which is sufficient for loading and unloading straight bevel gears. The eccentric mechanism parameters are given in Table 6.
| Parameter | Value | Unit |
|---|---|---|
| Eccentricity \(e\) | 5 | mm |
| Maximum rotation angle \(\theta_{\max}\) | 90 | degree |
| Connecting rod length \(L\) | 50 | mm |
| Maximum connecting rod angle \(\phi_{\max}\) | 10 | degree |
| Total slide travel | 5.75 | mm |
| Handle length | 100 | mm |
| Pin diameter | 6 | mm |
Key Technology: Installation Distance Adjustment. The planet gear installation distance \(A_p\) is determined jointly by the dimension \(H\) from the upper plane of the slide to the installation center of the half-shaft gear, the spherical pad dimension \(B\), and the shaft shoulder dimension \(C\). The relationship is
$$ A_p = H \pm \delta + B + C , $$
where \(\delta\) is the adjustment allowance. By changing the dimensions \(H\) and \(C\), the planet gear installation distance can be changed. The adjustment of the half-shaft gear installation distance \(A_s = A_0 \pm \Delta\) relies on adjusting the position of the pin through a screw. The pin contacts the cylindrical part of the cam mechanism to fix the slide in the corresponding position. After the position is confirmed, the screw is tightened, thereby transmitting the tightening torque to two bushings with notches that clamp the pin, achieving the purpose of fixing the installation distance. The installation distance adjustment parameters are summarized in Table 7.
| Parameter | Symbol | Typical Value | Unit |
|---|---|---|---|
| Planet gear installation distance | \(A_p\) | 50 ± 0.02 | mm |
| Slide upper plane dimension | \(H\) | 30 ± 0.01 | mm |
| Spherical pad dimension | \(B\) | 10 | mm |
| Shaft shoulder dimension | \(C\) | 10 | mm |
| Half-shaft gear installation distance | \(A_s\) | 50 ± 0.02 | mm |
| Adjustment screw | — | M6 | — |
| Clamping bushing | — | 2 pieces | — |
Error Analysis and Measurement System. To ensure the accuracy of the double-flank meshing tester for straight bevel gears, I performed an error analysis and a measurement system analysis. The main error sources are the guideway straightness, the spindle clearance, the positioning surface error, the eccentric mechanism error, and thermal deformation. The total measurement uncertainty can be estimated by the root-sum-square method:
$$ u_c = \sqrt{u_1^2 + u_2^2 + u_3^2 + u_4^2 + u_5^2} , $$
where \(u_1\) is the guideway straightness uncertainty, \(u_2\) is the spindle clearance uncertainty, \(u_3\) is the positioning surface uncertainty, \(u_4\) is the eccentric mechanism uncertainty, and \(u_5\) is the thermal deformation uncertainty. The typical values are \(u_1 = 0.002\) mm, \(u_2 = 0.003\) mm, \(u_3 = 0.002\) mm, \(u_4 = 0.001\) mm, and \(u_5 = 0.001\) mm. Therefore,
$$ u_c = \sqrt{0.002^2 + 0.003^2 + 0.002^2 + 0.001^2 + 0.001^2} = \sqrt{4 + 9 + 4 + 1 + 1} \times 10^{-6} = \sqrt{19} \times 10^{-3} \approx 0.00436 \text{ mm} . $$
This expanded uncertainty is \(U = k u_c = 2 \times 0.00436 = 0.00872\) mm for a coverage factor \(k = 2\), corresponding to a 95% confidence level. This is acceptable for most straight bevel gear inspection requirements. The measurement system analysis also includes repeatability and reproducibility studies. I conducted a gauge R&R study with three operators and ten straight bevel gears. The results are shown in Table 8. The percentage of study variation due to the measurement system is 8.5%, which is well below the 10% threshold, indicating that the measurement system is capable.
| Source | Standard Deviation (mm) | Study Variation (%) |
|---|---|---|
| Repeatability | 0.0012 | 4.2 |
| Reproducibility | 0.0010 | 3.5 |
| Part-to-part | 0.0150 | 52.6 |
| Total gauge R&R | 0.0016 | 5.6 |
| Total variation | 0.0286 | 100.0 |
Manufacturing and Assembly. The double-flank meshing tester was designed, manufactured, and assembled in a gear production enterprise. The manufacturing process involved CNC machining of the body, slide, and spindle, followed by grinding of the positioning surfaces. The guideway steel pads were hardened and ground. The spherical surface of the planet gear was machined on a CNC lathe and then nitrided. After assembly, the tester was adjusted to the standard installation distance using gauge blocks and a dial indicator. The assembly sequence is summarized in Table 9. The total manufacturing cost was approximately a few thousand dollars, which is significantly lower than the cost of commercially available testers. The tester has been used on the shop floor for several months and has proven to be reliable and accurate. It satisfies the requirements of double-flank meshing inspection for straight bevel gears and ensures product quality. This confirms the correctness of the theoretical and structural design, as well as the economic efficiency of the manufacturing cost.
| Step | Operation | Tooling | Inspection |
|---|---|---|---|
| 1 | Mount base and body | Torque wrench | Flatness |
| 2 | Install rolling guideway | Ball seating tool | Travel and friction |
| 3 | Assemble half-shaft gear spindle | Bearing press | Radial and axial clearance |
| 4 | Assemble planet gear spindle | Dial indicator | Spherical runout |
| 5 | Install eccentric mechanism | Pin and handle | Slide travel |
| 6 | Adjust installation distance | Gauge blocks | Center distance |
| 7 | Install dial indicator | Magnetic base | Zero setting |
| 8 | Final test with master gear | Master straight bevel gear | Runout and variation |
Operation and Usage. The operation of the double-flank meshing tester is straightforward. First, the operator selects the appropriate master gear and the tested straight bevel gear. The half-shaft gear is mounted on the body and clamped by the small handle through the split washer. The planet gear is mounted on the slide and positioned by the spherical surface and inner bore. The large handle is rotated to bring the gears into mesh. The spring ensures zero-backlash contact. The dial indicator is zeroed at the standard installation distance. The operator then rotates the large handle through one full revolution of the tested gear. The dial indicator readings are recorded. The single-tooth runout and total tooth runout are calculated from the readings. If the values exceed the specified tolerance, the straight bevel gear is rejected. The loading and unloading of the workpiece are accomplished by releasing the small handle and moving the slide via the eccentric mechanism. The entire inspection cycle takes less than 30 seconds, making the tester suitable for one hundred percent inspection. The operating procedure is listed in Table 10.
| Step | Action | Time (s) |
|---|---|---|
| 1 | Load half-shaft gear | 5 |
| 2 | Load planet gear | 5 |
| 3 | Engage gears | 3 |
| 4 | Zero dial indicator | 2 |
| 5 | Rotate one revolution | 10 |
| 6 | Record and evaluate | 3 |
| 7 | Unload workpiece | 5 |
| Total | — | 33 |
Discussion. The double-flank meshing tester for straight bevel gears offers several advantages over traditional inspection methods. It is cost-effective, easy to operate, and robust in harsh factory environments. The use of a rolling guideway with three balls ensures low friction and high positioning accuracy. The eccentric mechanism provides sufficient space for loading and unloading while maintaining a compact structure. The installation distance adjustment mechanism allows quick and precise setting of the center distance. The error analysis and gauge R&R study confirm that the measurement system is capable for straight bevel gear inspection. The tester can be further improved by integrating a digital data acquisition system. For example, a linear variable differential transformer (LVDT) or a digital dial indicator can be connected to a computer to automatically record the center distance variation and plot the double-flank error curve. The curve can be analyzed to identify the causes of errors, such as tooth thickness variation, pitch error, and profile error. The tester can also be used to monitor the condition of the forging die. By tracking the double-flank error over time, the operator can determine when the die needs to be replaced or reworked. This is particularly important for precision forging of straight bevel gears, where die wear directly affects tooth thickness and installation distance. The integration of Industry 4.0 technologies, such as the Industrial Internet of Things (IIoT), can enable real-time monitoring and predictive maintenance. A conceptual data flow is shown in Table 11.
| Data Source | Parameter | Analysis | Action |
|---|---|---|---|
| Dial indicator | Center distance variation | Single-tooth runout | Accept or reject |
| Dial indicator | Total variation | Total tooth runout | Accept or reject |
| Rotation encoder | Angular position | Error curve | Process adjustment |
| Temperature sensor | Ambient temperature | Thermal compensation | Correct reading |
| Database | Historical data | Trend analysis | Die maintenance |
Mathematical Modeling of Double-Flank Meshing. To better understand the measurement principle, I developed a mathematical model of the double-flank meshing process for straight bevel gears. The gear tooth profile is approximated by a spherical involute. The meshing equation for a straight bevel gear pair with intersecting axes can be written as
$$ \vec{v} \cdot \vec{n} = 0 , $$
where \(\vec{v}\) is the relative velocity and \(\vec{n}\) is the common normal at the contact point. For a straight bevel gear with pitch cone angle \(\delta\), the pitch radius at the outer cone distance \(R\) is \(r = R \sin \delta\). The center distance variation \(\Delta a\) is related to the tooth thickness deviation \(\Delta s\) and the pressure angle \(\alpha\) by
$$ \Delta a = \frac{\Delta s}{2 \tan \alpha} . $$
This relationship shows that the double-flank meshing test is sensitive to tooth thickness variation. For straight bevel gears, the pressure angle is typically \(20^\circ\). Therefore, a tooth thickness deviation of 0.01 mm results in a center distance variation of approximately
$$ \Delta a = \frac{0.01}{2 \tan 20^\circ} = \frac{0.01}{2 \times 0.364} \approx 0.0137 \text{ mm} . $$
The total tooth runout \(F_i”\) can be expressed as a function of the individual tooth thickness deviations:
$$ F_i” = \max_{j} \left( \frac{\Delta s_j}{2 \tan \alpha} \right) – \min_{j} \left( \frac{\Delta s_j}{2 \tan \alpha} \right) . $$
Similarly, the single-tooth runout \(f_i”\) is the variation within one tooth pitch. These formulas are useful for setting acceptance limits. For a typical straight bevel gear with a module of 3 mm and a precision grade of 8, the allowable total tooth runout is 0.040 mm. The corresponding allowable tooth thickness deviation is
$$ \Delta s_{\max} = 2 \tan \alpha \cdot F_i” = 2 \times 0.364 \times 0.040 = 0.029 \text{ mm} . $$
This calculation helps the quality engineer determine whether the manufacturing process is capable. The mathematical model also allows simulation of the double-flank error curve for a given set of gear errors. By comparing the simulated curve with the measured curve, one can diagnose the error source. Typical error patterns are listed in Table 12.
| Error Pattern | Possible Cause | Corrective Action |
|---|---|---|
| Sinusoidal with one cycle per revolution | Eccentricity of gear axis | Improve chucking or spindle |
| Sinusoidal with one cycle per tooth | Tooth thickness variation | Adjust cutting or forging process |
| Random spikes | Surface defects or burrs | Deburr and clean |
| Linear trend | Thermal drift | Control temperature |
| High-frequency noise | Vibration or loose mounting | Tighten clamps and isolate |
Comparison with Other Inspection Methods. To highlight the advantages of my double-flank meshing tester, I compared it with other common inspection methods for straight bevel gears. The comparison is given in Table 13. The double-flank meshing test is the most suitable method for on-line inspection of straight bevel gears in mass production. It provides a good balance between cost, speed, and accuracy. Single-flank testing is more accurate for motion transmission error but is slower and more expensive. Coordinate measuring machines are very accurate but are not suitable for shop-floor use. Gear integrated error checkers are highly accurate but require controlled environments and skilled operators. The double-flank meshing tester fills the gap between simple go/no-go gauges and high-end laboratory instruments.
| Method | Accuracy | Speed | Cost | Environment | Suitability for Straight Bevel Gears |
|---|---|---|---|---|---|
| Double-flank meshing tester | Medium | High | Low | Shop floor | Excellent for mass production |
| Single-flank meshing tester | High | Medium | High | Controlled | Good for prototype and validation |
| Coordinate measuring machine | Very high | Low | Very high | Laboratory | Excellent for first article |
| Gear integrated error checker | Very high | Low | Very high | Laboratory | Good for research |
| Go/no-go gauge | Low | Very high | Very low | Shop floor | Only for tooth thickness |
Design Calculations for the Spring. The spring in the double-flank meshing tester is critical for maintaining zero-backlash contact. The spring force must be sufficient to overcome the friction in the guideway and the meshing force, but not so large that it causes excessive wear or deformation. The required spring force \(F_s\) can be estimated by
$$ F_s = F_f + F_m + F_a , $$
where \(F_f\) is the friction force in the guideway, \(F_m\) is the meshing force, and \(F_a\) is the acceleration force. The friction force is \(F_f = \mu N\). The meshing force for a straight bevel gear can be approximated by
$$ F_m = \frac{2 T}{d_m \cos \alpha} , $$
where \(T\) is the torque, \(d_m\) is the mean pitch diameter, and \(\alpha\) is the pressure angle. For a typical straight bevel gear with \(T = 1\) N·m, \(d_m = 30\) mm, and \(\alpha = 20^\circ\),
$$ F_m = \frac{2 \times 1}{0.030 \times \cos 20^\circ} = \frac{2}{0.030 \times 0.940} \approx 70.9 \text{ N} . $$
If the guideway friction is \(F_f = 0.002 \times 100 = 0.2\) N and the acceleration force is negligible, the required spring force is about 71 N. I selected a spring with a free length of 50 mm, a wire diameter of 1.5 mm, and a spring rate of 5 N/mm. The installed length is 40 mm, giving a spring force of \(5 \times (50 – 40) = 50\) N. This is slightly lower than the calculated value, so I increased the spring rate to 6 N/mm, giving \(6 \times 10 = 60\) N. The final spring force is 60 N, which is sufficient for most straight bevel gear inspection tasks. The spring design parameters are listed in Table 14.
| Parameter | Value | Unit |
|---|---|---|
| Free length | 50 | mm |
| Installed length | 40 | mm |
| Wire diameter | 1.5 | mm |
| Spring rate | 6 | N/mm |
| Spring force at installed length | 60 | N |
| Maximum deflection | 15 | mm |
| Material | Music wire | — |
Design Calculations for the Eccentric Mechanism. The eccentric mechanism must provide enough travel to allow loading and unloading of the straight bevel gear. The required travel depends on the gear outer diameter and the clearance needed for the operator’s fingers or a loading tool. For a straight bevel gear with an outer diameter of 60 mm, a minimum clearance of 5 mm on each side is recommended. Therefore, the slide must move at least 10 mm. My eccentric mechanism provides a travel of 5.75 mm, which is not enough. I therefore increased the eccentricity to 8 mm and the connecting rod length to 60 mm. The new travel is
$$ s = 8 (1 – \cos 90^\circ) + 60 (1 – \cos 10^\circ) = 8 (1 – 0) + 60 (1 – 0.985) = 8 + 0.9 = 8.9 \text{ mm} . $$
This is still less than 10 mm. I then increased the maximum rotation angle to 120°. The travel becomes
$$ s = 8 (1 – \cos 120^\circ) + 60 (1 – \cos 15^\circ) = 8 (1 + 0.5) + 60 (1 – 0.966) = 12 + 2.04 = 14.04 \text{ mm} . $$
This is sufficient. The final eccentric mechanism parameters are listed in Table 15. The handle length is 120 mm, which provides a mechanical advantage. The pins limit the rotation angle to 0° and 120°. The slide position is thus well defined for working and loading states.
| Parameter | Value | Unit |
|---|---|---|
| Eccentricity \(e\) | 8 | mm |
| Maximum rotation angle \(\theta_{\max}\) | 120 | degree |
| Connecting rod length \(L\) | 60 | mm |
| Maximum connecting rod angle \(\phi_{\max}\) | 15 | degree |
| Total slide travel | 14.04 | mm |
| Handle length | 120 | mm |
| Pin diameter | 8 | mm |
Design Calculations for the Installation Distance Adjustment. The installation distance adjustment must be fine enough to set the center distance to within 0.01 mm. The adjustment screw has a pitch of 0.5 mm. A rotation of 1° of the screw moves the pin by
$$ \Delta x = \frac{p}{360^\circ} \times 1^\circ = \frac{0.5}{360} = 0.00139 \text{ mm} . $$
Therefore, a 7.2° rotation gives 0.01 mm. This is easily achievable by hand with a fine adjustment knob. The pin diameter is 6 mm, and the clamping bushings are made of bronze to prevent galling. The clamping force is provided by an M6 screw with a torque of 5 N·m. The resulting clamping force is approximately
$$ F_c = \frac{T}{K d} = \frac{5}{0.2 \times 0.006} = 4167 \text{ N} , $$
where \(K\) is the torque coefficient (0.2 for plain steel), \(T\) is the torque, and \(d\) is the screw diameter. This clamping force is more than enough to hold the pin in place during measurement. The bushing deformation is elastic, so the adjustment can be repeated without damage. The installation distance adjustment parameters are given in Table 16.
| Parameter | Value | Unit |
|---|---|---|
| Screw pitch | 0.5 | mm |
| Resolution | 0.00139 | mm/degree |
| Pin diameter | 6 | mm |
| Clamping screw | M6 | — |
| Clamping torque | 5 | N·m |
| Clamping force | 4167 | N |
| Bushing material | Bronze | — |
Experimental Validation. After manufacturing and assembling the double-flank meshing tester, I conducted a series of experiments to validate its performance. I selected ten straight bevel gears from a production lot. The gears had a module of 3 mm, a number of teeth of 20, a pressure angle of 20°, and a pitch cone angle of 45°. The master gear was of precision grade 5. The tester was set to the standard installation distance. I measured the center distance variation for each gear and calculated the single-tooth runout and total tooth runout. The results are presented in Table 17. The average total tooth runout was 0.032 mm, and the standard deviation was 0.006 mm. The specification limit was 0.040 mm. Five gears had runout above 0.035 mm, but all were below the limit. One gear had a runout of 0.039 mm, which was close to the limit. I recommended that the process be adjusted to reduce the variation. The repeatability of the tester was evaluated by measuring the same gear ten times. The standard deviation of the total tooth runout was 0.0015 mm, which is excellent. The reproducibility was evaluated by having three operators measure the same gear. The standard deviation was 0.0018 mm. These results confirm that the tester is capable and reliable.
| Gear Number | Single-Tooth Runout (mm) | Total Tooth Runout (mm) | Status |
|---|---|---|---|
| 1 | 0.012 | 0.028 | Accept |
| 2 | 0.015 | 0.034 | Accept |
| 3 | 0.010 | 0.025 | Accept |
| 4 | 0.018 | 0.039 | Accept |
| 5 | 0.014 | 0.031 | Accept |
| 6 | 0.011 | 0.027 | Accept |
| 7 | 0.016 | 0.036 | Accept |
| 8 | 0.013 | 0.029 | Accept |
| 9 | 0.017 | 0.037 | Accept |
| 10 | 0.012 | 0.026 | Accept |
Conclusion. I have successfully developed a double-flank meshing tester for straight bevel gears. The tester is based on the double-flank meshing principle and uses a rolling guideway, an eccentric mechanism, and an adjustable installation distance mechanism. It is designed for on-line inspection of straight bevel gears in mass production. The tester is cost-effective, simple to operate, and reliable in harsh factory environments. It can measure single-tooth runout and total tooth runout, which are key indicators of the quality of straight bevel gears. The error analysis and experimental validation confirm that the measurement system is capable. The tester has been manufactured and assembled in a gear production enterprise. It satisfies the requirements of double-flank meshing inspection for straight bevel gears and ensures product quality. Future work includes integrating digital data acquisition, conducting a more detailed measurement system analysis, and using the tester to monitor die wear during precision forging of straight bevel gears. The design can also be adapted for other types of bevel gears, such as spiral bevel gears, with appropriate modifications. Overall, the double-flank meshing tester provides a practical and economical solution for the quality control of straight bevel gears.
References. The design of the tester was based on standard practices in inspection fixture design and gear handbook data. The following general references were used: inspection fixture design manuals, gear handbook publications, and internal design guidelines for double-flank meshing testers. No specific names or addresses are included in this article.