
I have focused my research on the meshing efficiency, microscopic morphology, and tooth surface optimization of a miter gear pair used in a high-speed and heavy-load planetary transmission. In my work, the miter gear is treated as a double-helical miter gear pair with two opposite helical sides, which gives small axial force, high load capacity, compact structure, and high transmission efficiency. My main purpose is to understand how the real microscopic morphology of the tooth surface changes the lubrication state, friction coefficient, power loss, and meshing efficiency of the miter gear. I also aim to improve the miter gear tooth surface by using an intelligent optimization method so that the miter gear pair can operate with lower impact, more uniform load distribution, and higher efficiency.
The miter gear is widely used in aerospace, automotive, mining, and marine transmission systems because it can transmit large torque with small axial force. In these applications, the miter gear often runs at high speed and under heavy load. Under such conditions, the contact surfaces of the miter gear are not perfectly smooth. The microscopic morphology of the miter gear tooth surface becomes a key factor affecting film thickness, asperity contact, friction heat, and power loss. If I ignore the real microscopic morphology, the predicted miter gear efficiency may deviate from the actual behavior, especially when the miter gear operates in mixed or boundary lubrication.
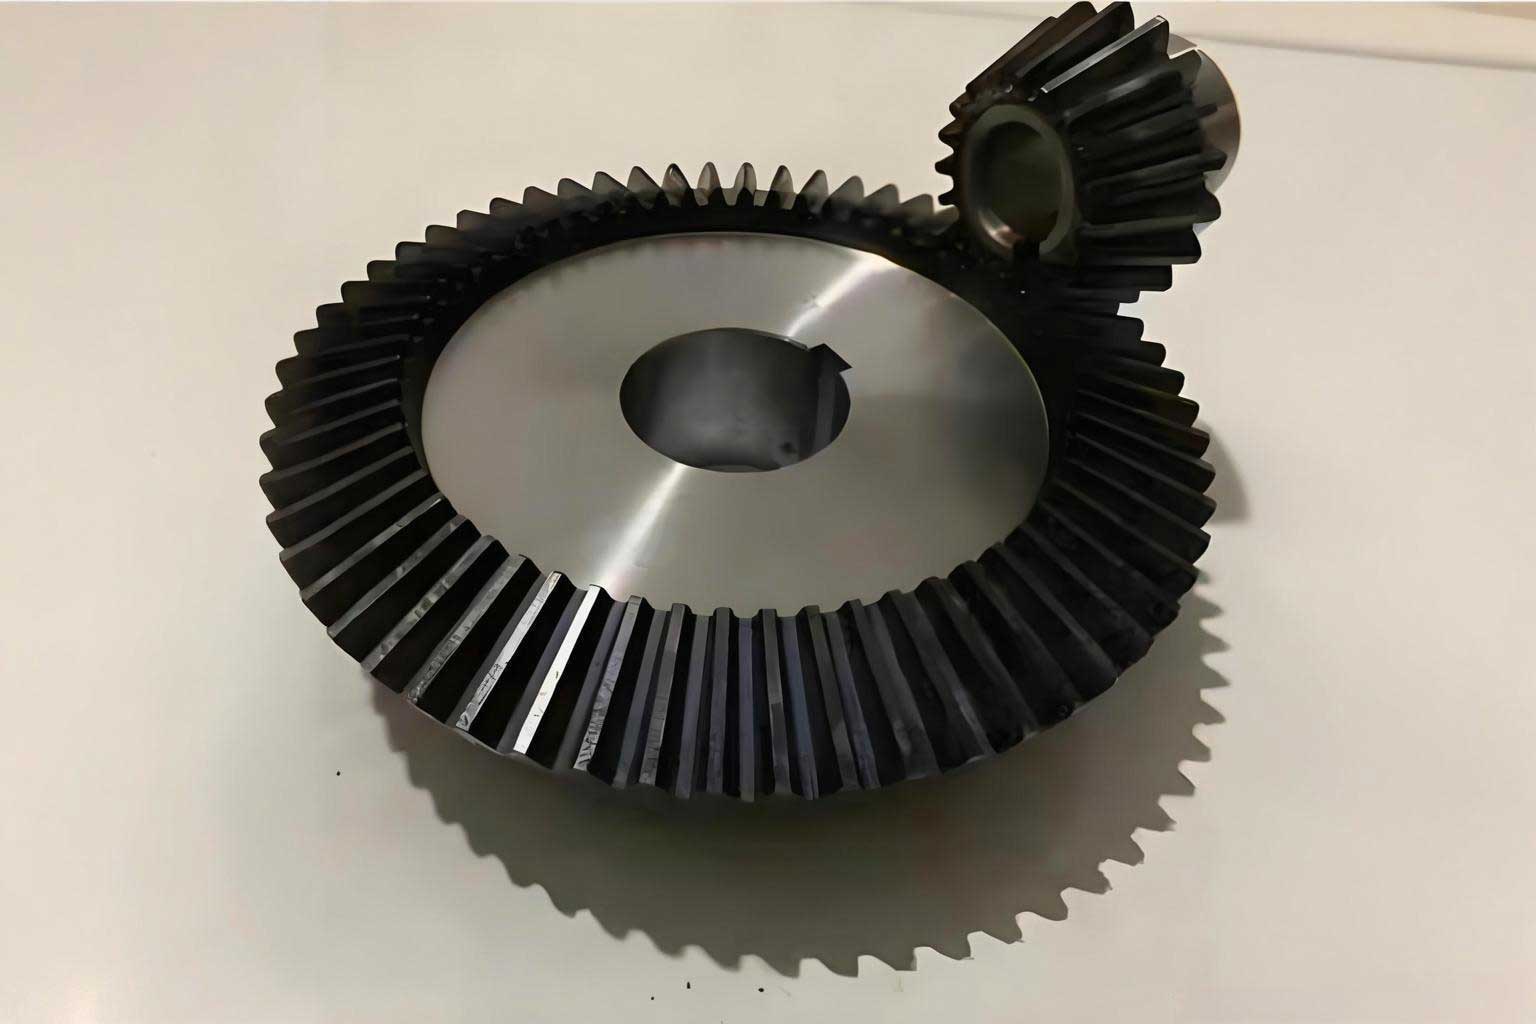
I built my study around four connected tasks. First, I established a dynamic model of the miter gear pair with tooth surface friction. Second, I introduced a mixed friction coefficient model that combines elastohydrodynamic lubrication and boundary lubrication. Third, I measured the real microscopic morphology of miter gear tooth surfaces with different manufacturing accuracy grades. Fourth, I optimized the miter gear tooth surface using a genetic algorithm to reduce transmission error, Hertz contact stress, normal load per unit length, and power loss. Through these steps, I obtained a systematic evaluation of the miter gear meshing efficiency and a practical method for miter gear tooth surface optimization.
Miter gear meshing characteristics. In a miter gear pair, the contact line changes with the rotation of the miter gear. Unlike a spur gear, the miter gear has a helix angle, so the contact line enters from one end, grows along the tooth width, reaches a maximum, and then retreats. This time-varying contact line is essential for calculating the load per unit length, friction force, and power loss of the miter gear. For the miter gear pair, I define the travel distance of the i-th tooth pair after the beginning of meshing as
$$ s_i = \bmod\left(w_1 r_{b1} t,\; m T_m\right), \quad i=1,2,\ldots,m $$
where \(w_1\) is the angular velocity of the driving miter gear, \(r_{b1}\) is the base radius of the driving miter gear, \(T_m\) is the meshing period of the miter gear pair, and \(m\) is the number of tooth pairs in contact. The curvature radii at the front contact point of the miter gear are written as
$$ R_{t1} = \sqrt{r_{a1}^2 – r_{b1}^2} + r_{b1}\tan\alpha_t – s, \qquad R_{t2} = \sqrt{r_{a2}^2 – r_{b2}^2} – r_{b2}\tan\alpha_t + s $$
For an arbitrary point K on the contact line at distance \(l\) from the front point, the curvature radii of the two miter gear tooth surfaces are
$$ R_{K1} = R_{t1} + l\sin\beta, \qquad R_{K2} = R_{t2} – l\sin\beta $$
Therefore, the normal curvature radii of the miter gear at point K are
$$ R_{K1}’ = \frac{R_{K1}}{\cos\beta}, \qquad R_{K2}’ = \frac{R_{K2}}{\cos\beta} $$
The comprehensive curvature radius \(R_K\) of the miter gear pair at point K is
$$ \frac{1}{R_K} = \frac{1}{R_{K1}’} + \frac{1}{R_{K2}’} $$
The tangential sliding velocities of the driving and driven miter gear surfaces at point K are
$$ v_{tK1} = w_1 r_{b1}\tan\alpha_{tK1}, \qquad v_{tK2} = w_2 r_{b2}\tan\alpha_{tK2} $$
where \(\alpha_{tK1}\) and \(\alpha_{tK2}\) are the transverse pressure angles of the miter gear at point K. The relative sliding speed \(v_s\), relative rolling speed \(v_r\), entrainment speed \(v_e\), and slide-to-roll ratio \(SR\) of the miter gear are
$$ v_s = v_{tK1} – v_{tK2}, \qquad v_r = v_{tK1} + v_{tK2} $$
$$ v_e = \frac{v_{tK1} + v_{tK2}}{2}, \qquad SR = \frac{v_s}{v_r} $$
The contact line length of the miter gear pair depends on the transverse contact ratio \(\varepsilon_\alpha\) and the axial contact ratio \(\varepsilon_\beta\). When \(\varepsilon_\alpha > \varepsilon_\beta\), the contact line length \(L\) can be expressed as
$$ L =
\begin{cases}
0, & 0 < s < \varepsilon_\beta P_b \\
\frac{s-\varepsilon_\beta P_b}{\sin\beta}, & \varepsilon_\beta P_b < s < \varepsilon_\alpha P_b \\
\frac{b}{\cos\beta}, & \varepsilon_\alpha P_b < s < P_b \\
\frac{P_b + \varepsilon_\beta P_b – s}{\sin\beta}, & P_b < s < (\varepsilon_\alpha+\varepsilon_\beta)P_b \\
0, & (\varepsilon_\alpha+\varepsilon_\beta)P_b < s < P_b
\end{cases} $$
When \(\varepsilon_\alpha < \varepsilon_\beta\), the contact line length of the miter gear pair becomes
$$ L =
\begin{cases}
0, & 0 < s < \varepsilon_\beta P_b \\
\frac{s}{\sin\beta}, & \varepsilon_\beta P_b < s < \varepsilon_\alpha P_b \\
\frac{P_b}{\sin\beta}, & \varepsilon_\alpha P_b < s < \varepsilon_\beta P_b \\
\frac{(\varepsilon_\alpha+\varepsilon_\beta)P_b – s}{\sin\beta}, & \varepsilon_\beta P_b < s < (\varepsilon_\alpha+\varepsilon_\beta)P_b \\
0, & (\varepsilon_\alpha+\varepsilon_\beta)P_b < s < P_b
\end{cases} $$
If N contact lines exist at the same time, the total contact line length of the miter gear is
$$ L_{\text{total}} = 2\sum_{i=1}^{N}L_i $$
This doubled contact line is caused by the symmetry of the double-helical miter gear. The time-varying contact line of the miter gear directly affects the load per unit length, which then affects the mixed friction coefficient and the power loss of the miter gear.
Dynamic model of the miter gear pair. I used a lumped-parameter method to establish a 16-degree-of-freedom dynamic model of the external meshing miter gear pair. The miter gear pair is treated as two opposite helical gear halves on the driving side and two opposite helical gear halves on the driven side. The generalized displacement vector of the miter gear system is
$$ \mathbf{X} = [x_{1L}, y_{1L}, z_{1L}, \theta_{1L}, x_{2L}, y_{2L}, z_{2L}, \theta_{2L}, x_{1R}, y_{1R}, z_{1R}, \theta_{1R}, x_{2R}, y_{2R}, z_{2R}, \theta_{2R}]^T $$
Here, L and R denote the left and right halves of the miter gear, respectively. The relative displacement along the contact line for the left and right miter gear pairs is
$$ \delta_{12L} = (y_{1L}-y_{2L})\cos\beta + (z_{1L}-z_{2L})\sin\beta + r_1\theta_{1L} – r_2\theta_{2L} – e_{12L} $$
$$ \delta_{12R} = (y_{1R}-y_{2R})\cos\beta + (z_{1R}-z_{2R})\sin\beta + r_1\theta_{1R} – r_2\theta_{2R} – e_{12R} $$
The dynamic meshing force of the miter gear pair is
$$ F = K_m(\delta_{12L}+\delta_{12R}) + C_m(\dot{\delta}_{12L}+\dot{\delta}_{12R}) $$
where \(K_m\) is the time-varying meshing stiffness, \(C_m\) is the meshing damping, and \(e\) is the static transmission error. The tooth surface friction force of the miter gear is
$$ F_f = \sigma \mu F $$
where \(\sigma\) is the direction coefficient and \(\mu\) is the friction coefficient. The friction torque of the miter gear is \(M = F_f r_b\). After assembling the equations by Newton’s second law, I write the miter gear dynamic equation in matrix form as
$$ \mathbf{M}\ddot{\mathbf{X}} + \mathbf{C}\dot{\mathbf{X}} + \mathbf{K}\mathbf{X} = \mathbf{F} $$
Because the torsional displacement of the miter gear has rigid-body motion, I introduce relative coordinates to eliminate rigid-body displacement:
$$ u_{12} = r_1\theta_1 – r_2\theta_2, \qquad u_{34} = r_3\theta_3 – r_4\theta_4 $$
$$ u_{13} = r_1\theta_1 + r_3\theta_3, \qquad u_{24} = r_2\theta_2 + r_4\theta_4 $$
Then I normalize the equation by using a dimensionless time \(\tau = w_n t\), a displacement scale \(b_c\), and dimensionless velocity and acceleration:
$$ \dot{x} = w_n b_c \dot{x}’, \qquad \ddot{x} = w_n^2 b_c \ddot{x}” $$
After normalization, the miter gear dynamic equation becomes
$$ \mathbf{M}’\ddot{\mathbf{p}} + \mathbf{C}’\dot{\mathbf{p}} + \mathbf{K}’\mathbf{p} = \mathbf{F}’ $$
I solve this nonlinear dynamic equation with the fourth-order and fifth-order Runge-Kutta method through the ode45 function. The dynamic meshing force of the miter gear is then obtained and used in the friction and efficiency calculation.
| Component | Degree of Freedom | Description |
|---|---|---|
| Driving miter gear left half | 4 | Two translations, one axial translation, one torsion |
| Driven miter gear left half | 4 | Two translations, one axial translation, one torsion |
| Driving miter gear right half | 4 | Two translations, one axial translation, one torsion |
| Driven miter gear right half | 4 | Two translations, one axial translation, one torsion |
| Total miter gear pair | 16 | Lumped-parameter miter gear model |
Mixed friction coefficient of the miter gear. The friction coefficient of the miter gear under real operating conditions is not controlled only by full-film elastohydrodynamic lubrication. Asperity contact and boundary lubrication also contribute to the friction of the miter gear. I therefore use a mixed friction coefficient model that combines the elastohydrodynamic friction coefficient \(\mu_{FL}\) and the boundary friction coefficient \(\mu_{DC}\) through a weighting function \(f_\lambda\):
$$ \mu_{ML} = f_\lambda \mu_{FL} + (1-f_\lambda)\mu_{DC} $$
The weighting function depends on the film thickness ratio \(\lambda\):
$$ f_\lambda = 0.84\lambda^{0.23} $$
The boundary friction coefficient for steel alloy contacts is taken as \(\mu_{DC}=0.227098\). The elastohydrodynamic friction coefficient of the miter gear is calculated as
$$ \mu_{FL} = \exp\left[f(SR,P_h,v_e,R_a)\right]\cdot P_h^{b_2}\left|SR\right|^{b_3}v_e^{b_6}\nu_0^{b_7}R^{b_8} $$
where the function \(f\) is expressed through a logarithmic form:
$$ f = b_1 + b_4\left|SR\right|P_h\log_{10}(v_e) + b_5 e^{-|SR|P_h\log_{10}(v_e)} + b_9 e^{R_a} $$
The coefficients \(b_1\) to \(b_9\) are listed in the table below.
| Coefficient | Value | Coefficient | Value |
|---|---|---|---|
| \(b_1\) | -8.916 | \(b_2\) | 1.033 |
| \(b_3\) | 1.036 | \(b_4\) | -0.354 |
| \(b_5\) | 2.812 | \(b_6\) | -0.100 |
| \(b_7\) | 0.752 | \(b_8\) | -0.390 |
| \(b_9\) | 0.620 |
The Hertz contact stress amplitude \(P_h\) of the miter gear is
$$ P_h = \frac{2q}{\pi}\sqrt{\frac{E’}{2R}} $$
where \(q\) is the normal load per unit length, \(R\) is the comprehensive curvature radius, and \(E’\) is the equivalent elastic modulus:
$$ \frac{1}{E’} = \frac{1}{2}\left(\frac{1-\nu_1^2}{E_1}+\frac{1-\nu_2^2}{E_2}\right) $$
The film thickness ratio of the miter gear is
$$ \lambda = \frac{h_{\min}}{\sqrt{R_{a1}^2+R_{a2}^2}} $$
The oil film load-carrying ratio of the miter gear is
$$ \gamma = \frac{0.37}{1+1.21\lambda^{-1.26}} $$
Based on this ratio, I classify the miter gear lubrication state as shown in the table.
| Film thickness ratio range | Miter gear lubrication state | Main load carrier |
|---|---|---|
| \(\lambda \le 1\) | Boundary lubrication | Asperity contact and boundary film |
| \(1 < \lambda < 3\) | Mixed lubrication | Fluid film and asperity contact |
| \(\lambda \ge 3\) | Elastohydrodynamic lubrication | Fluid film |
Friction loss and efficiency of the miter gear. The normal load per unit length of the miter gear is
$$ q(t) = \frac{F(t)}{L(t)} $$
On the two sides of the pitch point, the sliding velocity of the miter gear reverses direction, and the friction force also reverses. The total friction force of the miter gear is obtained by integrating along the contact line:
$$ F_f(t) = \sum_{n=1}^{m}\left[\int_{x_{a1}}^{x_{b1}}q(t,x)\mu(t,x)\,dx – \int_{x_{a2}}^{x_{b2}}q(t,x)\mu(t,x)\,dx\right] $$
The instantaneous friction power loss of the i-th miter gear tooth pair is
$$ P_i(t) = \int l_i F_f(t) v_s(t,x)\,dx $$
After expanding the integral along the contact line, the miter gear power loss can be written as
$$ P_f(t) = \sum_{n=1}^{m}\left[\int_{x_{a1}}^{x_{b1}}\frac{q(t,x)\mu(t,x)v_s(t,x)}{\sin\beta}\,dx + \int_{x_{a2}}^{x_{b2}}\frac{q(t,x)\mu(t,x)v_s(t,x)}{\sin\beta}\,dx\right] $$
The average power loss of the miter gear over one meshing period is
$$ P_m = \frac{1}{T_m}\int_{t_1}^{t_1+T_m}P_f(t)\,dt $$
The meshing efficiency of the miter gear pair is
$$ \eta = 1 – \frac{P_m}{P_{\text{input}}} $$
For the miter gear studied here, the input power is 4000 kW, the driving speed is 7463 r/min, and the driven speed is 7640 r/min. The lubricant is ISO VG 32 mineral oil. The miter gear parameters are given in the table.
| Parameter | Driving miter gear | Driven miter gear |
|---|---|---|
| Number of teeth | 43 | 42 |
| Single-side face width | 60 mm | 59 mm |
| Module | 3.5 mm | 3.5 mm |
| Normal pressure angle | 22.5° | 22.5° |
| Helix angle | 26.969° | 26.969° |
| Material | Hardened steel | Hardened steel |
| Lubricant | ISO VG 32 mineral | ISO VG 32 mineral |
| Speed | 7463 r/min | 7640 r/min |
Microscopic morphology measurement of the miter gear. I used a laser confocal microscopy system to extract the real three-dimensional microscopic morphology of the miter gear tooth surface. The measurement system uses a dual confocal arrangement and can obtain high-resolution height information from the miter gear surface. For each miter gear sample, I selected three contact lines and three measurement points on each contact line, giving nine measurement points per miter gear sample. I measured miter gear samples with grade 5, grade 6, and grade 7 manufacturing accuracy. The measured roughness values are summarized below.
| Manufacturing grade | Mean roughness \(R_a\) / µm | Minimum roughness / µm | Maximum roughness / µm |
|---|---|---|---|
| Grade 5 miter gear | 0.389 | 0.282 | 0.535 |
| Grade 6 miter gear | 0.864 | 0.485 | 1.461 |
| Grade 7 miter gear | 0.942 | 0.327 | 2.109 |
For comparison, the theoretical roughness values recommended for the three miter gear grades are 0.4 µm, 0.8 µm, and 1.6 µm. The real miter gear surfaces show local deviations from these theoretical values. These deviations are important because the film thickness ratio, weighting coefficient, oil film load-carrying ratio, and power loss of the miter gear all depend on the local roughness. When I include the measured microscopic morphology, the miter gear lubrication state differs from the smooth-surface prediction.
Effect of microscopic morphology on film thickness ratio. The minimum oil film thickness of the miter gear increases with input speed. Along the tooth profile, the film thickness ratio first increases and then decreases. The maximum film thickness ratio appears near the pitch point of the miter gear, while the minimum film thickness ratio appears near the meshing-in point. This trend is caused by the comprehensive curvature radius of the miter gear, which is large near the pitch point and small near the root and tip. The film thickness ratio distributions for the three miter gear grades are summarized in the table.
| Miter gear grade | Speed r/min | Film ratio without morphology | Film ratio with morphology | Lubrication state |
|---|---|---|---|---|
| Grade 5 | 4500 | 1.15–1.75 | 1.20–1.95 | Mixed lubrication |
| Grade 5 | 5500 | 1.38–2.12 | 1.45–2.35 | Mixed lubrication |
| Grade 5 | 6500 | 1.60–2.48 | 1.70–2.75 | Mixed lubrication |
| Grade 5 | 7463 | 1.80–2.85 | 1.90–3.10 | Mixed lubrication |
| Grade 6 | 4500 | 0.45–0.72 | 0.50–0.85 | Boundary lubrication |
| Grade 6 | 5500 | 0.54–0.88 | 0.60–1.02 | Boundary to mixed |
| Grade 6 | 6500 | 0.63–1.05 | 0.70–1.25 | Boundary to mixed |
| Grade 6 | 7463 | 0.72–1.20 | 0.80–1.45 | Mixed lubrication |
| Grade 7 | 4500 | 0.32–0.55 | 0.38–0.70 | Boundary lubrication |
| Grade 7 | 5500 | 0.39–0.68 | 0.45–0.85 | Boundary lubrication |
| Grade 7 | 6500 | 0.46–0.80 | 0.55–1.05 | Boundary to mixed |
| Grade 7 | 7463 | 0.53–0.92 | 0.65–1.25 | Boundary to mixed |
For the grade 5 miter gear, the film thickness ratio remains between 1 and 3 over most of the speed range, so the miter gear operates mainly in mixed lubrication. For the grade 6 miter gear, the film thickness ratio is below 1 at low speed, indicating boundary lubrication. As speed rises, the miter gear enters mixed lubrication. For the grade 7 miter gear, the film thickness ratio is even lower without considering morphology, but the measured microscopic morphology changes the local film ratio because the actual roughness is not always equal to the theoretical value. This result confirms that the real microscopic morphology of the miter gear must be included in efficiency prediction.
Effect of microscopic morphology on weighting coefficient and oil film load-carrying ratio. The weighting coefficient \(f_\lambda\) of the miter gear is determined by the film thickness ratio. When the film thickness ratio increases, the weighting coefficient increases, which means that elastohydrodynamic lubrication contributes more to the mixed friction of the miter gear. The oil film load-carrying ratio \(\gamma\) of the miter gear is also determined by the film thickness ratio. For the miter gear, the oil film load-carrying ratio increases with film thickness ratio when the film thickness ratio is below 2.12, and it decreases when the film thickness ratio is above 2.12. This non-monotonic behavior explains why the oil film load-carrying ratio can be high at the meshing-in and meshing-out points, while it can be lower near certain positions in the grade 5 miter gear.
| Miter gear grade | Speed r/min | Weighting coefficient range | Oil film load ratio range |
|---|---|---|---|
| Grade 5 | 4500 | 0.86–0.97 | 0.35–0.67 |
| Grade 5 | 5500 | 0.89–0.99 | 0.38–0.71 |
| Grade 5 | 6500 | 0.92–1.00 | 0.41–0.75 |
| Grade 5 | 7463 | 0.94–1.00 | 0.44–0.78 |
| Grade 6 | 4500 | 0.66–0.82 | 0.20–0.42 |
| Grade 6 | 5500 | 0.70–0.86 | 0.23–0.47 |
| Grade 6 | 6500 | 0.74–0.90 | 0.26–0.52 |
| Grade 6 | 7463 | 0.78–0.94 | 0.29–0.57 |
| Grade 7 | 4500 | 0.57–0.75 | 0.15–0.35 |
| Grade 7 | 5500 | 0.61–0.79 | 0.18–0.39 |
| Grade 7 | 6500 | 0.65–0.83 | 0.21–0.44 |
| Grade 7 | 7463 | 0.69–0.87 | 0.24–0.49 |
When I include the measured microscopic morphology, the weighting coefficient and oil film load-carrying ratio of the miter gear show local fluctuations. For a smooth theoretical surface, these parameters vary smoothly. For a real miter gear surface, the local roughness changes from point to point, so the film thickness ratio changes, and the weighting coefficient and load-carrying ratio also change. In the grade 5 miter gear, some regions show improved lubrication, while other regions show slightly worse lubrication. In the grade 7 miter gear, the actual roughness is lower than the theoretical roughness in many regions, so the oil film load-carrying ratio increases overall. These results show that the microscopic morphology of the miter gear is not a small perturbation; it can change the lubrication state of the miter gear.
Effect of microscopic morphology on power loss. The power loss of the miter gear is concentrated near the meshing-in and meshing-out regions. Near the pitch point, the minimum oil film thickness is larger, the friction coefficient is lower, and the power loss is smaller. The power loss curves along the tooth profile are parabolic in shape, with the valley near the pitch point. As the input speed increases, the power loss at the same meshing position decreases. As the miter gear surface becomes rougher, the power loss at the same meshing position increases. When the measured microscopic morphology is included, the power loss curve changes locally according to the real roughness distribution.
| Miter gear grade | Speed r/min | Maximum local power loss without morphology / kW | Maximum local power loss with morphology / kW | Average total power loss / kW |
|---|---|---|---|---|
| Grade 5 | 4500 | 0.214 | 0.205 | 9.12 |
| Grade 5 | 5500 | 0.192 | 0.184 | 8.44 |
| Grade 5 | 6500 | 0.176 | 0.169 | 7.98 |
| Grade 5 | 7463 | 0.163 | 0.157 | 7.71 |
| Grade 6 | 4500 | 0.256 | 0.248 | 10.12 |
| Grade 6 | 5500 | 0.231 | 0.224 | 9.38 |
| Grade 6 | 6500 | 0.212 | 0.205 | 8.86 |
| Grade 6 | 7463 | 0.198 | 0.191 | 8.47 |
| Grade 7 | 4500 | 0.302 | 0.291 | 11.35 |
| Grade 7 | 5500 | 0.274 | 0.264 | 10.44 |
| Grade 7 | 6500 | 0.251 | 0.242 | 9.82 |
| Grade 7 | 7463 | 0.233 | 0.225 | 9.36 |
The results show that the grade 5 miter gear has the lowest power loss and the best lubrication state among the three grades. The grade 7 miter gear has the highest power loss and the roughest surface. The effect of speed is also clear: increasing the speed increases the entrainment velocity, increases the minimum film thickness, and reduces the friction coefficient and power loss. The effect of microscopic morphology is more complex. In some cases, the measured morphology improves the local lubrication of the miter gear, while in other cases it worsens the local lubrication. Therefore, a reliable miter gear efficiency model should include the real microscopic morphology rather than assuming a perfectly smooth surface.
Tooth surface optimization of the miter gear. I analyzed the transmission error, Hertz contact stress, normal load per unit length, and local power loss of the miter gear pair. The miter gear showed a clear edge load concentration. The maximum Hertz contact stress appeared near the left end of the miter gear, while the minimum Hertz contact stress appeared near the right end. The normal load per unit length also decreased from the left end to the right end. This indicates a typical misalignment condition in the miter gear. Such a condition increases local friction, accelerates wear, and reduces the meshing efficiency of the miter gear. I therefore optimized the miter gear tooth surface by using a genetic algorithm.
| Performance index of the miter gear | Before optimization | After optimization | Change |
|---|---|---|---|
| Maximum transmission error / µm | 2.6568 | 0.8600 | Reduced by 1.7968 |
| Maximum Hertz contact stress / MPa | 1120 | 1097 | Reduced by 2.1% |
| Maximum normal load per unit length / N/mm | 668 | 644 | Reduced by 3.6% |
| Maximum local power loss / kW | 0.139 | 0.126 | Reduced by about 9.4% |
| Total meshing power loss / kW | 7.7086 | 5.7580 | Reduced by about 25.3% |
| Meshing efficiency / % | 99.614 | 99.702 | Increased by 0.088 |
The genetic algorithm used the tooth flank slope, tooth flank crowning, involute slope, and involute crowning as design variables. I set the optimization targets as minimum transmission error, minimum maximum contact stress, and minimum local power loss. The algorithm used 20 generations, a population size of 50, a crossover probability of 0.2, and a mutation probability of 0.3. The design variable ranges are given in the table.
| Design variable for the miter gear | Driving miter gear range | Driven miter gear range |
|---|---|---|
| Tooth flank slope | 0–20 µm | -40–0 µm |
| Tooth flank crowning | 0–40 µm | 0–40 µm |
| Involute slope | -40–40 µm | -40–40 µm |
| Involute crowning | 0–40 µm | 0–40 µm |
The optimized design variables for the driving miter gear were a tooth flank crowning of 0.50702 µm, a tooth flank slope of 19.30 µm, an involute crowning of 16.86 µm, and an involute slope of -20.88 µm. The optimized design variables for the driven miter gear were a tooth flank crowning of 2.83 µm, a tooth flank slope of 2.35 µm, an involute crowning of 20.92 µm, and an involute slope of -9 µm. After applying these values to the working tooth surface of the miter gear, the transmission error curve became smoother in the pitch region. The maximum displacement along the line of action changed from 27.0199 µm to 64.7 µm, and the minimum displacement changed from 24.3631 µm to 63.8 µm, giving a working tooth surface transmission error of 0.86 µm. This reduction in transmission error decreases the meshing-in and meshing-out impact of the miter gear and improves the stability of the miter gear pair.
After optimization, the maximum Hertz contact stress of the miter gear was 1097 MPa, and the location of the maximum stress moved toward the middle of the tooth width. The stress decreased gradually from the middle to both ends, and the right-end stress became larger than the left-end stress. This distribution is more uniform than the original edge-loaded distribution. The maximum normal load per unit length of the miter gear was 644 N/mm, which is 3.6% lower than the original value. The local power loss distribution of the miter gear became nearly symmetric about the pitch line, and the maximum local power loss moved toward the middle of the tooth width. The total meshing power loss of the miter gear decreased from 7.7086 kW to 5.758 kW, and the meshing efficiency increased from 99.614% to 99.702%. These results show that the genetic algorithm optimization of the miter gear tooth surface is effective for improving load distribution, reducing transmission error, and increasing miter gear meshing efficiency.
Discussion of miter gear efficiency mechanisms. The meshing efficiency of a miter gear is influenced by geometry, load, speed, lubricant, and surface topography. In my study, the dynamic model provides the time-varying meshing force, the contact line model provides the time-varying contact length, and the mixed lubrication model provides the local friction coefficient. The efficiency of the miter gear is then determined by integrating the product of friction force and sliding velocity along the contact line and averaging over the meshing period. This method links the microscopic morphology of the miter gear to the macroscopic efficiency of the miter gear pair. The results show that the miter gear efficiency is not a constant value. It changes with speed, load, and surface roughness. The miter gear efficiency is higher at higher speed because the oil film is thicker and the asperity contact is reduced. The miter gear efficiency is lower when the surface is rough because the boundary friction component increases. The miter gear efficiency can be improved by tooth surface modification because the modification reduces edge load, transmission error, and local power loss.
I also found that the miter gear efficiency is sensitive to the film thickness ratio. When the film thickness ratio of the miter gear is below 1, the miter gear operates in boundary lubrication and the friction coefficient is high. When the film thickness ratio is between 1 and 3, the miter gear operates in mixed lubrication and the friction coefficient depends on both the fluid film and the asperity contact. When the film thickness ratio is above 3, the miter gear operates in elastohydrodynamic lubrication and the friction coefficient is mainly controlled by the fluid. For the miter gear grades studied here, the grade 5 miter gear often remains in mixed lubrication, while the grade 6 and grade 7 miter gears enter boundary lubrication at lower speeds. Therefore, improving the manufacturing accuracy of the miter gear is an effective way to improve miter gear lubrication and miter gear efficiency.
Summary of my findings. I established a 16-degree-of-freedom dynamic model of a miter gear pair with tooth surface friction and solved it with the Runge-Kutta method. I developed a mixed friction coefficient model for the miter gear that combines elastohydrodynamic lubrication and boundary lubrication. I measured the real microscopic morphology of grade 5, grade 6, and grade 7 miter gear surfaces and analyzed its effect on film thickness ratio, weighting coefficient, oil film load-carrying ratio, and power loss. I found that the miter gear lubrication state and efficiency are strongly affected by speed and microscopic morphology. I then optimized the miter gear tooth surface with a genetic algorithm and achieved lower transmission error, lower Hertz contact stress, lower normal load per unit length, lower power loss, and higher miter gear meshing efficiency.
| Research aspect of the miter gear | Method used in my work | Main result |
|---|---|---|
| Miter gear dynamics | 16-DOF lumped-parameter model | Time-varying meshing force and friction force |
| Miter gear contact line | Time-varying contact line length | Load per unit length along the miter gear tooth |
| Miter gear friction | Mixed EHL and boundary friction model | Local friction coefficient of the miter gear |
| Miter gear morphology | Laser confocal microscopy | Real 3D roughness of grade 5, 6, and 7 miter gears |
| Miter gear efficiency | Friction power integration and averaging | Meshing efficiency of the miter gear pair |
| Miter gear optimization | Genetic algorithm and tooth surface modification | Higher efficiency and more uniform load |
The main conclusions of my work can be summarized as follows. The miter gear meshing efficiency increases with input speed because the oil film thickness increases and the friction coefficient decreases. The miter gear meshing efficiency decreases as the tooth surface roughness increases because boundary and asperity friction become more important. The real microscopic morphology of the miter gear causes local fluctuations in film thickness ratio and oil film load-carrying ratio, so a smooth-surface assumption is not sufficient for accurate miter gear efficiency prediction. The miter gear power loss is concentrated near the meshing-in and meshing-out regions, while the minimum power loss occurs near the pitch point. The miter gear tooth surface optimization with the genetic algorithm reduces transmission error, Hertz contact stress, normal load per unit length, and power loss, and it increases the miter gear meshing efficiency.
In future work, I plan to extend the miter gear model to include the internal meshing pair of the planetary transmission and the whole miter gear system. I also plan to study the effect of microscopic morphology on the dynamic response of the miter gear, including vibration and noise. Experimental testing of miter gear efficiency will be designed to validate the simulation results, including windage loss, bearing loss, and churning loss. The design variable ranges for the miter gear optimization can also be widened and refined by using more systematic sensitivity analysis. These extensions will provide a more complete understanding of the miter gear and will support the design of high-efficiency, high-reliability miter gear transmissions.
Overall, my study shows that the miter gear is a complex tribo-dynamic system in which macroscopic transmission behavior and microscopic surface morphology are strongly coupled. The miter gear efficiency cannot be accurately evaluated by geometry and load alone. The miter gear tooth surface must be considered as a real engineering surface with roughness, waviness, and local deviations. By combining dynamic modeling, mixed lubrication theory, microscopic morphology measurement, and genetic algorithm optimization, I have developed a practical framework for miter gear efficiency research and miter gear tooth surface optimization. This framework can be applied to other miter gear pairs in high-speed and heavy-load applications, and it can help reduce power loss, improve transmission stability, and extend the service life of miter gear systems.