
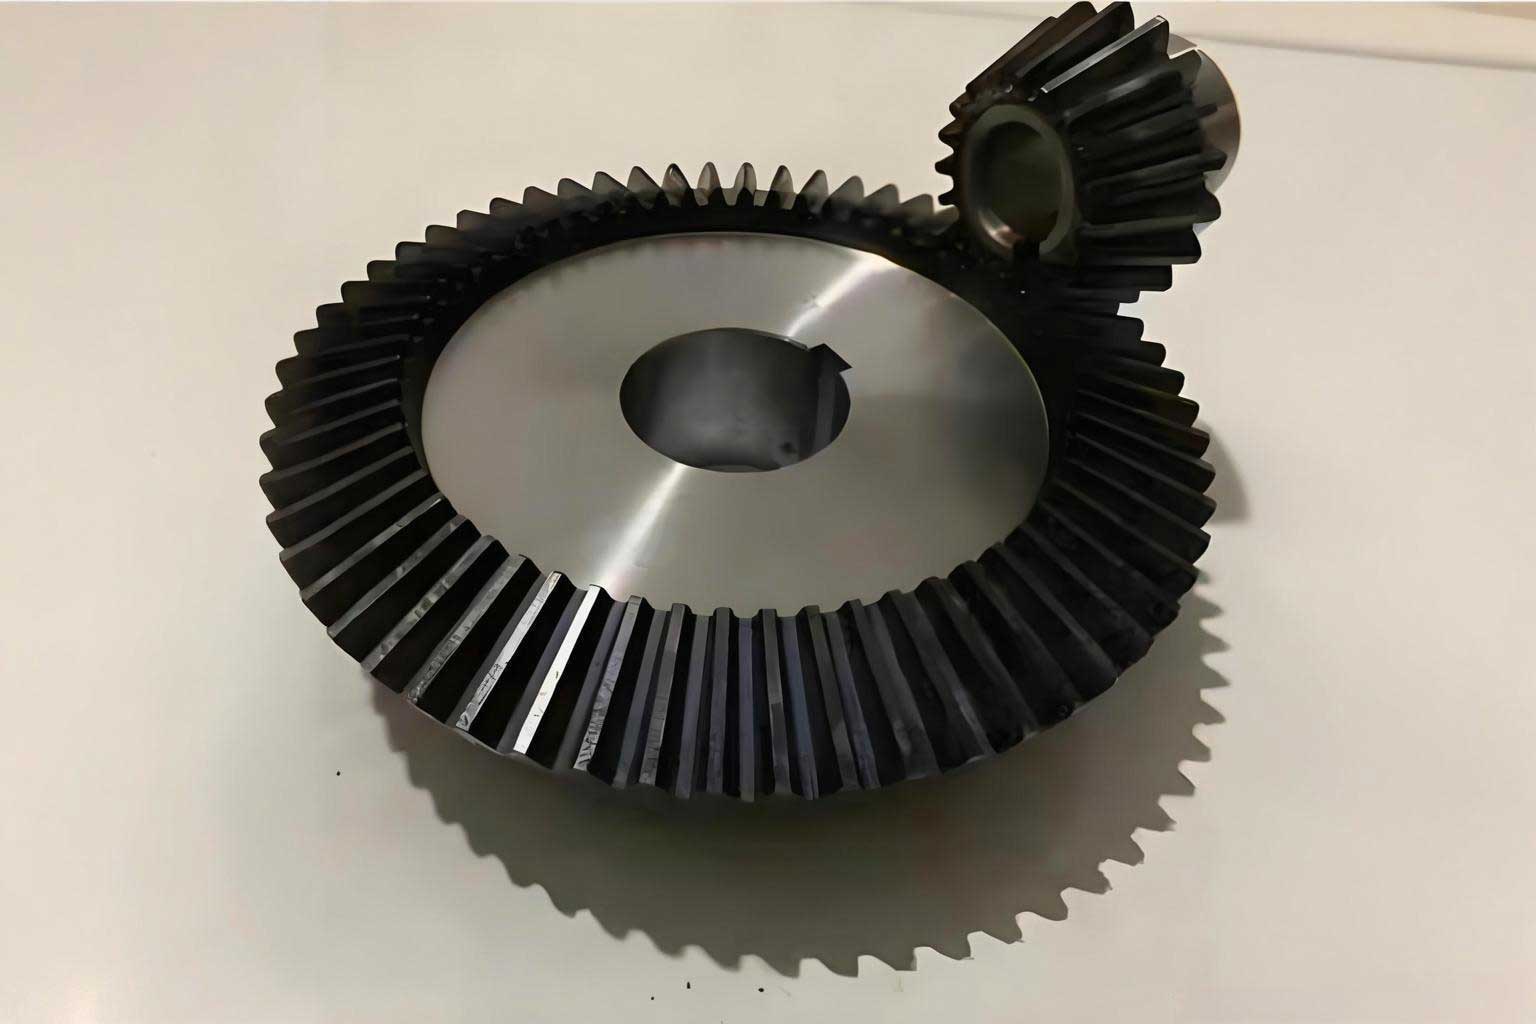
In this study I investigate the dynamic behavior of a miter gear transmission and the vibration response of its surrounding gearbox. I treat the miter gear as a double-helical gear arrangement in which two opposite-handed helical gear halves operate in parallel, so that the axial forces generated by the two halves can largely cancel each other. This makes the miter gear a preferred configuration for high-speed, heavy-load, and high-power transmission systems. My objective is to build a reliable simulation chain that begins with the miter gear mesh model, proceeds through time-varying mesh stiffness and dynamic meshing performance, and finally predicts the vibration response of the gearbox. I use finite element contact analysis, explicit dynamic contact simulation, multi-body dynamics, and modal superposition. Throughout the work I repeatedly examine how the miter gear mesh stiffness, miter gear impact behavior, miter gear tooth contact stress, and miter gear root bending stress are influenced by hub flexibility, load, elastic modulus, damping, rotational speed, and external torque.
1. Motivation and Scope
Gear transmission is one of the most important power transmission forms in mechanical equipment because it offers a compact structure, a constant transmission ratio, and a long service life. When a gear pair rotates normally, elastic deformation of the gear teeth and the continuous change in the number of meshing tooth pairs cause the mesh stiffness to vary with time. This time-varying mesh stiffness acts as a parametric excitation and produces a dynamic mesh force. The dynamic mesh force is transmitted through the shafts, bearings, and bearing supports to the gearbox, where it can cause strong vibration and noise. In the miter gear system, the two helical halves share the load, and the mesh stiffness of the miter gear can be treated as the parallel combination of the two half-helical mesh stiffnesses. Therefore, accurate prediction of the miter gear mesh stiffness is a necessary first step for dynamic analysis.
I also focus on the dynamic meshing performance of the miter gear, especially during start-up acceleration. During this stage, the miter gear experiences meshing impact, and the contact force can be much larger than the corresponding static value. The contact stress on the miter gear tooth surface and the bending stress at the miter gear tooth root are closely related to fatigue failure and load-carrying capacity. If these stresses are underestimated, the design may suffer from premature pitting, wear, or root cracking. If they are overestimated, the gearbox may become unnecessarily heavy. My aim is to quantify these effects for a specific miter gear system and to provide guidance for dynamic design and vibration control.
2. Dynamic Model of the Miter Gear Transmission
I begin with the general dynamic equation of a gear transmission system:
$$M\ddot{\delta}+C\dot{\delta}+K\delta=F(t)$$
Here, \(M\), \(C\), and \(K\) are the mass, damping, and stiffness matrices, respectively, \(\delta\) is the generalized displacement vector, and \(F(t)\) is the external force vector. For the miter gear system, I consider the left half of the miter gear and the right half of the miter gear as two symmetric helical gear pairs. When manufacturing and assembly accuracy are sufficiently high, the axial vibration can be neglected because the axial forces cancel. I therefore simplify the miter gear transmission to a six-degree-of-freedom model for one half of the miter gear. The generalized displacement vector is:
$$\delta=\begin{bmatrix}x_1 & y_1 & \theta_1 & x_2 & y_2 & \theta_2\end{bmatrix}^{T}$$
In this vector, \(x_1\) and \(y_1\) are the translational displacements of the driving miter gear center, \(x_2\) and \(y_2\) are the translational displacements of the driven miter gear center, and \(\theta_1\) and \(\theta_2\) are the rotational displacements of the driving and driven miter gears about their axes. The displacements at the mesh point on the driving and driven sides can be written as:
$$y_A=y_1+R_{t1}\theta_1$$
$$y_B=y_2-R_{t2}\theta_2$$
where \(R_{t1}\) and \(R_{t2}\) are the transverse base circle radii of the driving and driven miter gear halves. The normal mesh stiffness \(k_m\), normal damping \(c_m\), and normal transmission error \(e\) can be projected onto the line of action. For a helical miter gear half with helix angle \(\beta\), I use:
$$k_{my}=k_m\cos\beta,\qquad c_{my}=c_m\cos\beta,\qquad e_y=e\cos\beta$$
The dynamic mesh force along the \(y\) direction is then:
$$F_y=k_{my}(y_A-y_B-e_y)+c_{my}(\dot{y}_A-\dot{y}_B-\dot{e}_y)$$
By substituting the displacement relations into the mesh force, the six-degree-of-freedom equations of the miter gear transmission can be expressed in matrix form as:
$$M\ddot{\delta}+C\dot{\delta}+K\delta=P$$
I summarize the main parameters used in my miter gear model in Table 1 and Table 2.
| Parameter | Driving miter gear half | Driven miter gear half |
|---|---|---|
| Number of teeth | 31 | 102 |
| Normal module | 4.5 mm | 4.5 mm |
| Pressure angle | 20 degrees | 20 degrees |
| Helix angle | 28.2024 degrees | 28.2024 degrees |
| Face width | 90 mm | 90 mm |
| Component | Density (kg/m³) | Elastic modulus (Pa) | Poisson ratio |
|---|---|---|---|
| Driving and driven miter gear | \(7.8\times10^3\) | \(2.09\times10^{11}\) | 0.29 |
| Gearbox housing | \(7.3\times10^3\) | \(1.3\times10^{11}\) | 0.25 |
The transverse contact ratio and overlap contact ratio of one helical half of the miter gear are important because they determine how many teeth share the load. I calculate the transverse contact ratio as:
$$\varepsilon_\alpha=\frac{1}{2\pi}\left[z_1(\tan\alpha_{at1}-\tan\alpha_t)+z_2(\tan\alpha_{at2}-\tan\alpha_t)\right]$$
and the overlap contact ratio as:
$$\varepsilon_\beta=\frac{b\tan\beta}{\pi m_t}$$
For my miter gear half, the total contact ratio is:
$$\varepsilon_\gamma=\varepsilon_\alpha+\varepsilon_\beta$$
The calculated value is approximately \(4.46\) under light load. Under the rated load, the contact ratio can increase because of elastic deformation, and I observed an effective value near \(4.75\). This high contact ratio is beneficial for the miter gear because it reduces the fluctuation of the miter gear mesh stiffness and improves load sharing.
3. Contact Finite Element Formulation
I use finite element contact analysis to solve the miter gear mesh problem. In a contact problem, the two bodies must satisfy a non-penetration condition. If \(\delta_A\) and \(\delta_B\) are the spatial coordinates of a point on the master surface and a point on the slave surface, and \(n_A\) is the outward normal at the master point, then the condition can be written as:
$$(\delta_A-\delta_B)\cdot n_A\ge 0$$
For the miter gear contact simulation, I use the penalty method because it is suitable for explicit dynamic contact and does not increase the number of unknowns. The contact force is activated when penetration occurs and is proportional to the penetration depth. I also use a hard contact condition in the normal direction and a frictionless or Coulomb friction condition in the tangential direction, depending on the stage of the analysis.
For implicit static contact analysis of the miter gear mesh stiffness, I use ABAQUS/Standard with the Newton-Raphson method. At each increment, the solver checks whether each contact pair is open or closed. If a pair is closed, the solver applies the contact constraint and determines whether the contact state is sticking or sliding. The equilibrium equations are then solved iteratively. For explicit dynamic analysis, I use ABAQUS/Explicit with the central difference method. The acceleration at the beginning of an increment is:
$$\ddot{u}^{N}=M^{-1}(P^{N}-I^{N})$$
The velocity and displacement updates are:
$$\dot{u}^{N+1/2}=\dot{u}^{N-1/2}+\frac{\Delta t}{2}\ddot{u}^{N}$$
$$u^{N+1}=u^{N}+\Delta t\dot{u}^{N+1/2}$$
The stability limit of the explicit solution is controlled by the smallest element size \(L_{\min}\) and the dilatational wave speed \(c_d\):
$$\Delta t\le\frac{L_{\min}}{c_d}$$
For an isotropic elastic material, the wave speed is:
$$c_d=\sqrt{\frac{\lambda+2\mu}{\rho}}$$
where
$$\lambda=\frac{E\nu}{(1+\nu)(1-2\nu)},\qquad \mu=\frac{E}{2(1+\nu)}$$
Because the miter gear contact region requires a fine mesh, the stable time increment becomes small. I therefore refine only the miter gear teeth that participate in contact and use coarser elements in noncritical regions. I also use reduced integration elements with hourglass control to avoid zero-energy modes. The hourglass control is important for the miter gear dynamic contact model because the contact force can otherwise produce nonphysical deformation modes.
4. Mesh Stiffness of the Miter Gear
The mesh stiffness of the miter gear is one of the most important internal excitations. I define the transmission error of the miter gear as the deviation between the actual rotational position of the driven gear and its ideal position. For a gear pair with tooth numbers \(z_1\) and \(z_2\), the transmission error is:
$$TE=\theta_2-\frac{z_1}{z_2}\theta_1$$
For the helical half of the miter gear, I express the loaded transmission error along the line of action as:
$$LTE=R_{bn2}\theta_2-R_{bn1}\theta_1$$
where \(R_{bn1}\) and \(R_{bn2}\) are the normal base circle radii. I decompose the loaded transmission error into the no-load transmission error and the elastic deformation of the miter gear teeth:
$$LTE=NLTE+\Delta\delta$$
The elastic deformation along the line of action is therefore:
$$\Delta\delta=LTE-NLTE=R_{bn2}\theta_2-R_{bn1}\theta_1-NLTE$$
The normal mesh stiffness of one helical half of the miter gear is:
$$k_n=\frac{F_n}{\Delta\delta}=\frac{F_n}{LTE-NLTE}$$
Since the miter gear consists of two opposite-handed helical halves acting in parallel, the total miter gear mesh stiffness is:
$$k_{\text{miter}}=2k_n$$
I validate the contact finite element model using a spur gear pair and Hertz contact theory. For two parallel cylinders in contact, the maximum contact pressure is:
$$p_{\max}=\sqrt{\frac{P}{\pi L}\frac{1/R_1+1/R_2}{(1-\mu_1^2)/E_1+(1-\mu_2^2)/E_2}}$$
I compare the Hertz result with the finite element contact result for several torques. The relative error remains within about six percent, which confirms that my mesh density and contact settings are acceptable. The validation results are summarized in Table 3.
| Torque (Nm) | Hertz contact stress (MPa) | Finite element result (MPa) | Relative error (%) |
|---|---|---|---|
| 460 | 750.7 | 707.9 | -5.7 |
| 560 | 838.6 | 795.0 | -5.2 |
| 660 | 918.9 | 874.4 | -4.8 |
| 760 | 993.4 | 932.8 | -6.1 |
| 860 | 1063.1 | 1004.6 | -5.5 |
For the miter gear mesh stiffness calculation, I build a ten-tooth contact model for each helical half. The model includes the hub because the hub deformation contributes significantly to the loaded transmission error. I apply a rigid coupling between the gear inner bore and a reference point on the axis. I then apply a small angular displacement to establish contact, followed by a small torque, the rated torque, and finally a rotational displacement on the driving gear. I record the normal contact force and the rotational displacements of the reference points. The no-load transmission error and loaded transmission error of the miter gear are shown in Table 4.
| Quantity | Average value (µm) | Maximum value (µm) |
|---|---|---|
| No-load transmission error | 1.35 | 1.38 |
| Loaded transmission error | 10.95 | 10.98 |
| Elastic deformation used for stiffness | 9.60 | 9.63 |
The normal contact force of the miter gear fluctuates as the number of contacting tooth pairs changes between four and five. The resulting miter gear mesh stiffness curve is periodic. For one helical half, the maximum stiffness is approximately \(1.453\times10^9\) N/m, and the minimum stiffness is approximately \(1.446\times10^9\) N/m. For the complete miter gear, the stiffness is approximately twice these values. The fluctuation is small because the contact ratio is high. This is a favorable characteristic of the miter gear, because it means that the miter gear mesh stiffness excitation is relatively mild. The miter gear mesh stiffness results are summarized in Table 5.
| Item | Minimum | Maximum | Period |
|---|---|---|---|
| One helical half mesh stiffness | \(1.446\times10^9\) N/m | \(1.453\times10^9\) N/m | 0.12 s |
| Complete miter gear mesh stiffness | \(2.892\times10^9\) N/m | \(2.906\times10^9\) N/m | 0.12 s |
I also study the influence of the hub, load, and elastic modulus on the miter gear mesh stiffness. When I remove the hub, the loaded transmission error decreases and the mesh stiffness increases significantly. The no-hub model predicts a maximum stiffness of about \(1.627\times10^9\) N/m for one helical half, which is about twelve percent higher than the hub-inclusive model. Therefore, I conclude that the hub must not be neglected when calculating the miter gear mesh stiffness. The load effect is also important. As the torque increases, the loaded transmission error increases almost linearly, while the miter gear mesh stiffness increases but with a decreasing rate. The elastic modulus effect is different: as the elastic modulus increases, the loaded transmission error decreases, and the miter gear mesh stiffness increases nearly linearly. These trends are summarized in Table 6.
| Factor | Change | Effect on loaded transmission error | Effect on miter gear mesh stiffness |
|---|---|---|---|
| Hub | Removed | Decreases by about 5% | Increases by about 12% |
| Load | Increases from 1 kNm to 3 kNm | Increases linearly | Increases with decreasing rate |
| Elastic modulus | Increases from \(0.5\times10^5\) MPa to \(2.0\times10^5\) MPa | Decreases with decreasing rate | Increases nearly linearly |
5. Dynamic Meshing Performance of the Miter Gear
After obtaining the miter gear mesh stiffness, I establish a full-tooth explicit dynamic contact model for the miter gear. The model includes eight teeth on each gear for the dynamic contact analysis. I use reduced integration elements with enhanced hourglass control. The mesh in the contact region is refined, and the mesh in the noncontact region is coarser. I apply a rotational speed of 1000 rpm to the driving miter gear and a load torque of 6000 Nm to the driven miter gear. The speed and torque are ramped up gradually to avoid an unrealistic initial impact. I use Rayleigh damping:
$$C=\alpha M+\beta K$$
The modal damping ratio for mode \(i\) is:
$$\xi_i=\frac{\alpha}{2\omega_i}+\frac{\beta\omega_i}{2}$$
I choose \(\alpha=800\) rad/s and \(\beta=5\times10^{-8}\) for the baseline miter gear dynamic simulation. The dynamic results show that the driving and driven miter gear speeds rise from zero and approach stable values. The driving speed reaches approximately \(104.67\) rad/s, and the driven speed reaches approximately \(31.8\) rad/s. These values satisfy the transmission ratio. In the first part of the start-up stage, the angular accelerations of both the driving and driven miter gears oscillate strongly. The impact region lasts for about one millisecond. After that, the oscillations decay quickly because of damping. The dynamic contact force of the miter gear also shows a clear impact peak in this early stage. The first five contacting tooth pairs experience the impact, while later tooth pairs enter mesh after the impact has decayed.
I extract the contact stress and root bending stress at two representative times: an early time when five tooth pairs are in contact, and a later time when four tooth pairs are in contact. When five tooth pairs are in contact, the load sharing is more uniform, and the maximum contact stress away from the tooth tip is generally between 250 MPa and 300 MPa. Local stress concentration near the tooth tip can raise the contact stress to about 600 MPa. When four tooth pairs are in contact, the load per tooth is higher, and the local contact stress near the tooth tip can reach about 700 MPa. The contact stress on the driving miter gear is generally higher than that on the driven miter gear because the driving miter gear has a smaller radius of curvature. The miter gear tooth root bending stress is lower than the contact stress. For the driving miter gear, the root bending stress remains below about 212 MPa, including the impact peak. For the driven miter gear, the root bending stress remains below about 185 MPa. The dynamic stress results are summarized in Table 7.
| Quantity | Driving miter gear | Driven miter gear |
|---|---|---|
| Maximum contact stress, five-tooth contact | About 600 MPa near tip | About 600 MPa near tip |
| Maximum contact stress, four-tooth contact | About 700 MPa near tip | About 700 MPa near tip |
| Maximum root bending stress including impact | About 212 MPa | About 185 MPa |
| Typical contact stress away from tip | 250 to 300 MPa | 250 to 300 MPa |
The system damping has a strong influence on the miter gear impact behavior. I compare three damping levels by changing the mass-proportional coefficient \(\alpha\): 400 rad/s, 600 rad/s, and 800 rad/s. In the initial acceleration stage, the miter gear speed and acceleration curves are almost identical for all damping values. However, in the oscillatory decay stage, a larger damping value produces smaller oscillation amplitudes and faster decay. The same trend is observed in the miter gear root bending stress. A larger damping value reduces the oscillation amplitude and accelerates the decay of the stress fluctuation. The damping effect is summarized in Table 8.
| Damping coefficient \(\alpha\) (rad/s) | Impact-stage behavior | Oscillation amplitude | Decay speed |
|---|---|---|---|
| 400 | Almost identical | Largest | Slowest |
| 600 | Almost identical | Intermediate | Intermediate |
| 800 | Almost identical | Smallest | Fastest |
Rotational speed also affects the miter gear dynamic meshing performance. I compare driving speeds of 600 rpm, 800 rpm, and 1000 rpm. As the speed increases, the stable speed of the driven miter gear changes according to the transmission ratio. The angular acceleration peak during the impact stage becomes larger as the speed increases, which means that the miter gear meshing impact becomes more severe. In the decay stage, the oscillation amplitude of the miter gear angular acceleration also increases with speed, while the decay rate remains nearly unchanged. The root bending stress of the miter gear shows a similar trend. A higher speed causes a larger dynamic root stress and a larger oscillation amplitude. In addition, the time required for one tooth pair to complete its mesh cycle becomes shorter as speed increases. The speed effect is summarized in Table 9.
| Driving speed (rpm) | Impact angular acceleration | Root stress oscillation | Mesh cycle duration |
|---|---|---|---|
| 600 | Smallest | Smallest | Longest |
| 800 | Intermediate | Intermediate | Intermediate |
| 1000 | Largest | Largest | Shortest |
Load also changes the miter gear dynamic response, but its effect is different from speed. When I increase the load torque from 6 kNm to 10 kNm while keeping the speed and damping unchanged, the driven miter gear speed and angular acceleration remain almost unchanged. This is because the speed history is controlled mainly by the input motion and damping, not by the load in this simulation. However, the miter gear root bending stress increases with load. The increase in root stress is not linearly proportional to the load increase; the stress increase is smaller than the load increase. The load effect is summarized in Table 10.
| Load torque (kNm) | Driven speed | Driven angular acceleration | Root bending stress |
|---|---|---|---|
| 6 | Unchanged | Unchanged | Baseline |
| 8 | Unchanged | Unchanged | Increased |
| 10 | Unchanged | Unchanged | Further increased |
6. Modal Analysis of the Miter Gear Shafts and Gearbox
I next analyze the modal characteristics of the miter gear transmission shafts and the gearbox housing. The natural frequencies and mode shapes provide the basis for the subsequent vibration response analysis. For a general undamped system, the free vibration equation is:
$$M\ddot{\delta}+K\delta=0$$
Assuming a harmonic solution \(\delta=X\cos(\omega t+\phi)\), I obtain the eigenvalue problem:
$$(K-\omega^2M)X=0$$
The non-trivial solution requires:
$$\det(K-\omega^2M)=0$$
I use the Lanczos method to extract the first ten modes of the driving and driven miter gear shafts with their bearing locations constrained. The results are summarized in Table 11 and Table 12. The first mode of each shaft is a rigid-body rotation about its own axis because the axial rotation is not constrained. The driving shaft has higher local frequencies than the driven shaft because the driven shaft is larger and has a more flexible hub region. The miter gear system therefore has a relatively low-frequency shaft mode that could interact with the gearbox modes.
| Mode | Frequency (Hz) | Mode description |
|---|---|---|
| 1 | 0 | Rigid rotation about the shaft axis |
| 2 | 1462.5 | Local expansion |
| 3 | 1511.3 | Local bending |
| 4 | 1511.3 | Local bending |
| 5 | 2163.6 | Local stretching |
| 6 | 2219.9 | Transverse bending |
| 7 | 2220.0 | Transverse bending |
| 8 | 2522.0 | Local complex deformation |
| 9 | 2522.5 | Local complex deformation |
| 10 | 2799.7 | Local rotation |
| Mode | Frequency (Hz) | Mode description |
|---|---|---|
| 1 | 0 | Rigid rotation about the shaft axis |
| 2 | 238.55 | Local rotation |
| 3 | 238.60 | Local rotation |
| 4 | 506.86 | Local stretching |
| 5 | 567.29 | Transverse bending |
| 6 | 567.95 | Transverse bending |
| 7 | 741.93 | Local expansion |
| 8 | 899.20 | Local bending |
| 9 | 899.20 | Local bending |
| 10 | 916.22 | Complex deformation |
For the gearbox housing, I model the upper housing, lower housing, and bearing covers. I use tie constraints to represent the bolted connections between the upper and lower housings. I fix the bolt holes at the bottom of the lower housing. The first ten natural frequencies of the gearbox are summarized in Table 13. The fundamental frequency is about 188.2 Hz, and the tenth frequency is about 433.9 Hz. The lower housing deforms less than the upper housing because the bottom bolt holes are fixed. The upper housing and the ribbed panels are more flexible. The gearbox modes are important because the miter gear mesh frequency is around 516 Hz. Although the first ten gearbox modes are below this frequency, the higher gearbox modes may still be excited by harmonics of the miter gear mesh frequency.
| Mode | Frequency (Hz) | Mode description |
|---|---|---|
| 1 | 188.2 | Vertical vibration of the vent opening |
| 2 | 259.13 | Swinging in the Z direction |
| 3 | 264.12 | Expansion and contraction |
| 4 | 313.68 | Top plate twisting |
| 5 | 359.68 | Upper housing Z-direction motion |
| 6 | 385.47 | Housing contraction |
| 7 | 389.43 | Squeezing deformation |
| 8 | 406.01 | Upper housing side wall twisting |
| 9 | 420.37 | Side wall and top twisting |
| 10 | 433.87 | Twisting and Z-direction swing |
7. Bearing Reaction Forces from Multi-Body Dynamics
To obtain the excitation forces acting on the gearbox, I build a multi-body dynamics model of the miter gear transmission system. I use rigid gear bodies, rigid shafts, and bearing elements. The miter gear contact is defined with the average mesh stiffness obtained from the finite element analysis. I include friction with a static coefficient of 0.3 and a dynamic coefficient of 0.1. I apply a driving speed of 1000 rpm and a driven load torque of 6000 Nm. I run the simulation for 0.2 s with 2000 steps. The initial impact transient is discarded, and I extract 200 data points from 0.04 s to 0.06 s for the vibration response analysis. The bearing reaction force histories show clear periodicity. Because the driving miter gear has a smaller radius, the bearing reactions on the driving shaft are generally larger than those on the driven shaft. The frequency spectrum of the bearing reaction force has peaks at the miter gear mesh frequency and its harmonics. The calculated mesh frequency is 516 Hz, which matches the peak in the spectrum. This confirms that the multi-body dynamics model captures the miter gear excitation correctly. The bearing reaction results are summarized in Table 14.
| Bearing location | Mean reaction force (kN) | Dominant frequency | Observation |
|---|---|---|---|
| Driving shaft bearing 1 | About 20 to 25 | 516 Hz and harmonics | Symmetric with bearing 2 |
| Driving shaft bearing 2 | About 20 to 25 | 516 Hz and harmonics | Symmetric with bearing 1 |
| Driven shaft bearing 1 | About 10 to 15 | 516 Hz and harmonics | Lower than driving side |
| Driven shaft bearing 2 | About 10 to 15 | 516 Hz and harmonics | Lower than driving side |
8. Vibration Response of the Gearbox
I use modal superposition to calculate the vibration response of the gearbox. The physical coordinate response is represented as a linear combination of the modal vectors:
$$\delta=Xq$$
Substituting this transformation into the dynamic equation and premultiplying by \(X^T\) gives a set of independent modal equations:
$$\ddot{q}_i+2\xi_i\omega_i\dot{q}_i+\omega_i^2q_i=Q_i(t)$$
where
$$Q_i(t)=X_i^T F(t)$$
I extract the first twenty modes of the gearbox and apply the bearing reaction forces to the corresponding bearing seats. I fix the bottom bolt holes. I obtain the stress distribution and the vibration response at two reference points: point A near the driving shaft bearing seat and point B near the driven shaft bearing seat. The maximum von Mises stress in the gearbox is about 48.7 MPa. The critical locations are the connections between the ribbed panels and the housing walls and the bottom bolt holes. These regions should be checked carefully in design, and fillets or local thickening may be needed to reduce stress concentration.
The vibration response at point A is larger than that at point B because the driving shaft bearing reaction is larger. For both points, the vibration displacement, velocity, and acceleration in the horizontal direction are larger than those in the vertical direction. This is because the ribbed panels increase the vertical stiffness of the gearbox more than the horizontal stiffness. The frequency spectrum of the vibration displacement shows that the dominant peak occurs at the miter gear mesh frequency. This means that the gearbox vibration is mainly driven by the miter gear mesh excitation. The vibration response results are summarized in Table 15.
| Response quantity | Point A, horizontal | Point A, vertical | Point B, horizontal | Point B, vertical |
|---|---|---|---|---|
| Displacement amplitude (µm) | Largest | Smaller | Smaller | Smallest |
| Velocity amplitude (µm/s) | Largest | Smaller | Smaller | Smallest |
| Acceleration amplitude (m/s²) | Largest | Smaller | Smaller | Smallest |
| Dominant frequency | Miter gear mesh frequency | Miter gear mesh frequency | Miter gear mesh frequency | Miter gear mesh frequency |
I also find that the gearbox stress is not uniformly distributed. The upper housing deforms more than the lower housing. The bearing seats are locally stiffened, but the surrounding panels can still vibrate. The ribbed panels carry a large portion of the bearing reaction force, and the bottom bolt holes carry the reaction from the foundation. Therefore, I recommend that the rib-to-wall junctions and the bottom bolt-hole regions be treated as critical design zones for the miter gear gearbox. If the miter gear excitation is expected to increase, these regions should be reinforced or redesigned to shift the local modes away from the miter gear mesh frequency and its harmonics.
9. Discussion of the Miter Gear Simulation Chain
The simulation chain I developed has four main parts. First, I calculate the miter gear mesh stiffness using implicit finite element contact analysis. Second, I calculate the miter gear dynamic meshing performance using explicit dynamic contact analysis. Third, I calculate the bearing reaction forces using multi-body dynamics. Fourth, I calculate the gearbox vibration response using modal superposition. The miter gear appears in every part of the chain: the miter gear mesh stiffness controls the contact force, the miter gear contact force controls the bearing reaction, and the bearing reaction controls the gearbox vibration. Therefore, improving the accuracy of the miter gear mesh stiffness and the miter gear dynamic contact model is essential for reliable gearbox vibration prediction.
One important observation is that the miter gear mesh stiffness is only weakly time-varying when the contact ratio is high. The miter gear stiffness fluctuation is small compared with that of a low-contact-ratio spur gear. This is beneficial because it reduces the parametric excitation from the miter gear. However, the miter gear still produces a periodic mesh force because the contact point moves along the tooth surface and the number of contacting tooth pairs changes. The miter gear dynamic factor during start-up is much larger than the steady-state dynamic factor. Therefore, the start-up and shutdown stages should be considered separately in miter gear design.
Another important observation is that the hub flexibility affects the miter gear mesh stiffness more than I initially expected. If I model the miter gear as a rigid hub, the miter gear mesh stiffness is overestimated by about twelve percent. This error propagates into the dynamic mesh force and then into the bearing reaction and gearbox vibration. Therefore, I recommend including the hub and shaft coupling flexibility in future miter gear models whenever the mesh stiffness is used for dynamic analysis.
The load effect on the miter gear mesh stiffness is nonlinear. As the load increases, the miter gear mesh stiffness increases, but the increase becomes smaller. This is because the contact area and the number of contacting tooth pairs change with load. The elastic modulus effect is closer to linear. These trends are useful for design because they show that changing the material stiffness may be a more direct way to adjust the miter gear mesh stiffness than changing the load.
The damping effect on the miter gear dynamic response is also clear. A larger damping coefficient reduces the oscillation amplitude and accelerates the decay of the start-up transient. However, damping does not significantly change the initial impact peak. This means that damping is effective for controlling the post-impact vibration but not for eliminating the initial miter gear meshing impact. To reduce the initial impact, I would need to modify the miter gear tooth profile, the start-up acceleration profile, or the initial contact condition.
Speed has a strong effect on the miter gear impact. A higher speed produces a larger angular acceleration peak and a larger root stress oscillation. Therefore, if the miter gear must operate at high speed, I should pay special attention to the dynamic root stress and the contact stress near the tooth tip. Load also increases the miter gear root stress, but its effect on the impact stage is smaller than the effect of speed.
For the gearbox, the vibration response is dominated by the miter gear mesh frequency. This is consistent with the frequency content of the bearing reaction forces. The gearbox modes below 500 Hz are not directly coincident with the miter gear mesh frequency of 516 Hz, but harmonics of the mesh frequency can still excite higher gearbox modes. Therefore, I recommend checking the gearbox modal frequencies against the miter gear mesh frequency and its first several harmonics during design.
10. Conclusions
I have presented a complete dynamic simulation and vibration response analysis for a miter gear transmission and its gearbox. The main conclusions are as follows.
First, I built a six-degree-of-freedom dynamic model of the miter gear transmission using the lumped-parameter method. The model includes transmission error, mesh stiffness, mesh damping, support stiffness, support damping, and friction. The model provides the mass, damping, and stiffness matrices needed for dynamic analysis. The miter gear is represented as two parallel helical halves, and the total miter gear mesh stiffness is twice the stiffness of one half.
Second, I calculated the miter gear mesh stiffness using implicit finite element contact analysis. I validated the contact model with Hertz contact theory. I found that the hub has a significant effect on the miter gear mesh stiffness. Ignoring the hub increases the predicted stiffness by about twelve percent. I also found that the loaded transmission error increases linearly with load, while the miter gear mesh stiffness increases with load at a decreasing rate. The miter gear mesh stiffness increases nearly linearly with elastic modulus.
Third, I established a full-tooth explicit dynamic contact model of the miter gear. I obtained the start-up impact characteristics, the contact force history, the contact stress distribution, and the root bending stress history. The miter gear impact is concentrated in the first millisecond of start-up. During this stage, the angular acceleration and root stress oscillate strongly. A larger damping coefficient reduces the oscillation amplitude and accelerates the decay. A higher rotational speed increases the impact and the dynamic root stress. A larger load increases the root stress but does not significantly change the speed or angular acceleration history.
Fourth, I performed constrained modal analysis of the miter gear shafts and the gearbox housing. The driving shaft and driven shaft have different local frequencies because of their different sizes and hub structures. The gearbox has a fundamental frequency of about 188.2 Hz and its first ten modes are below about 434 Hz. The miter gear mesh frequency is about 516 Hz, so the gearbox designer should consider the mesh frequency and its harmonics when evaluating resonance risk.
Fifth, I extracted the bearing reaction forces from a multi-body dynamics model of the miter gear transmission. The bearing reaction spectra show peaks at the miter gear mesh frequency and its harmonics. I applied these bearing reactions to the gearbox bearing seats and used modal superposition to calculate the gearbox vibration response. The gearbox vibration is largest near the driving shaft bearing seat, and the horizontal vibration is larger than the vertical vibration because the ribbed panels increase the vertical stiffness. The maximum von Mises stress in the gearbox is about 48.7 MPa, and the critical regions are the rib-to-wall junctions and the bottom bolt holes.
Overall, my study shows that the miter gear mesh stiffness, miter gear dynamic meshing performance, and gearbox vibration response are strongly coupled. Accurate prediction of the miter gear mesh stiffness is the foundation of the entire simulation chain. The miter gear dynamic contact analysis provides the impact and stress data needed for fatigue assessment. The multi-body dynamics and modal superposition analysis provide the gearbox vibration response needed for vibration control. I believe that the methods and results presented here can support the dynamic design of miter gear systems and help reduce gearbox vibration and noise.
11. Summary Tables
| Analysis stage | Method | Main output | Key miter gear quantity |
|---|---|---|---|
| Mesh stiffness | Implicit finite element contact | Loaded transmission error, mesh stiffness | Miter gear mesh stiffness |
| Dynamic meshing | Explicit dynamic contact | Impact, contact stress, root stress | Miter gear dynamic factor |
| Bearing reaction | Multi-body dynamics | Bearing force history and spectrum | Miter gear mesh frequency |
| Gearbox vibration | Modal superposition | Displacement, velocity, acceleration, stress | Miter gear excitation response |
| Influence factor | Miter gear mesh stiffness | Miter gear impact | Miter gear root stress | Gearbox vibration |
|---|---|---|---|---|
| Hub flexibility | Significant; cannot be ignored | Moderate | Moderate | Indirect |
| Load | Increases with decreasing rate | Small | Increases | Increases |
| Elastic modulus | Nearly linear increase | Moderate | Moderate | Indirect |
| Damping | Not dominant | Reduces oscillation amplitude | Reduces oscillation amplitude | Reduces vibration |
| Rotational speed | Weak | Increases strongly | Increases | Shifts excitation frequency |
These summary tables reflect the main trends I observed. They can be used as a quick reference when designing a miter gear transmission or when interpreting vibration measurements from a miter gear gearbox. The miter gear mesh excitation remains the central quantity in the entire chain, and any change in the miter gear mesh stiffness or miter gear dynamic contact behavior will affect the bearing reactions and the gearbox vibration response.