
I study the anti-scuffing load capacity of herringbone gear transmission systems, and I extend the same calculation philosophy to miter gears. In my view, miter gears and herringbone gears both require a coupled treatment of rough-surface mixed lubrication, flash temperature, contact evolution, friction, wear, and load sharing. For miter gears, the contact path is usually discretized into small elements; for herringbone gears, I decompose the teeth into left and right helical slices and then assemble the slice results. The same numerical strategy is useful for miter gears when the local contact pressure and sliding speed vary along the tooth surface. I therefore build a unified framework that can be applied to miter gears, herringbone gears, helical gears, and spur gears with appropriate geometric inputs.
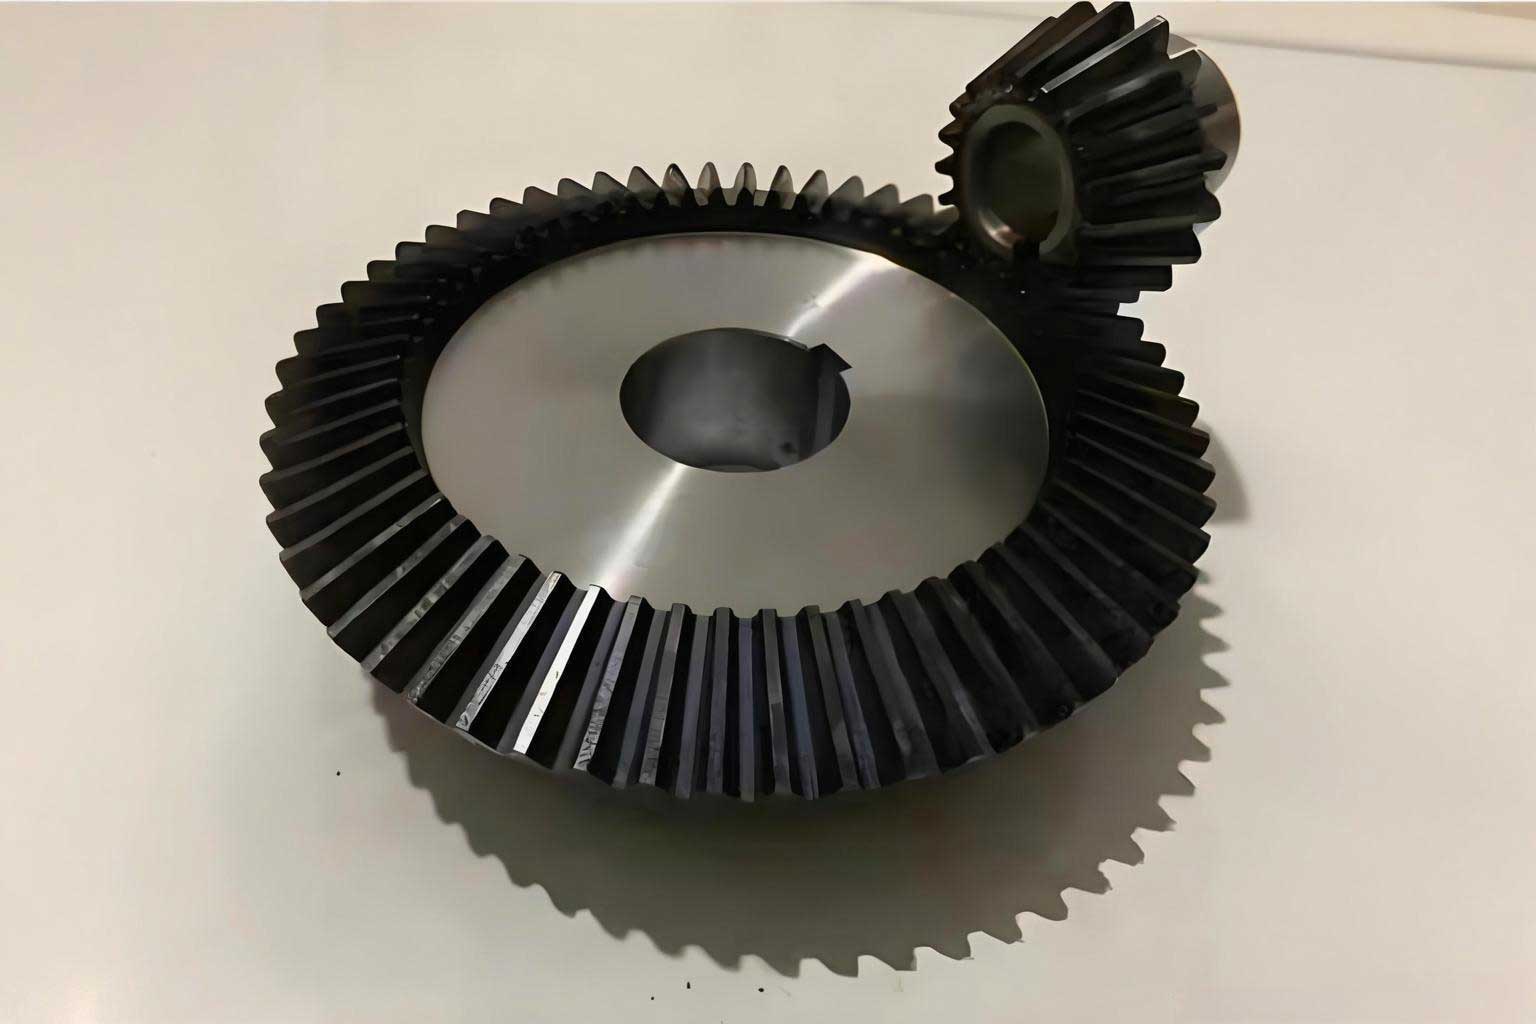
I begin with the mixed thermal elastohydrodynamic lubrication problem. For miter gears, the contact is often approximated as a line contact or a point contact depending on the tooth form. For the herringbone gears in my study, I treat each meshing side as a line contact and include roughness, asperity load sharing, and lubricant viscosity-pressure-temperature effects. I define the nominal geometry and working conditions in Table 1. These values are used throughout my anti-scuffing calculations, and I also use them to demonstrate how miter gears can be analyzed with the same dimensionless groups.
| Parameter | Unit | Pinion | Gear |
|---|---|---|---|
| Number of teeth | – | 17 | 26 |
| Normal module | mm | 4.5 | 4.5 |
| Normal pressure angle | deg | 20 | 20 |
| Face width | mm | 45 | 45 |
| Helix angle | deg | 15 | 15 |
| Input speed | rpm | 150 | – |
| Input torque | N m | 200 | – |
| Equivalent modulus | GPa | 206 | 206 |
| Poisson ratio | – | 0.3 | 0.3 |
| Hardness | HRC | 50 | 50 |
| Surface roughness | μm | 0.5 | 0.5 |
I use two lubricants in my comparisons: a conventional SAE 30 oil and a poly-alpha-olefin oil. The material and lubricant data are summarized in Table 2. For miter gears, the same lubricant properties are used because the thermal and rheological behavior of the oil is not limited to one gear type. I found that the choice of lubricant has a strong influence on miter gears as well as on herringbone gears, especially when the contact temperature approaches the scuffing threshold.
| Property | Unit | SAE 30 | PAO | Gear steel |
|---|---|---|---|---|
| Density | kg/m3 | 888 | 826 | 7800 |
| Viscosity at reference temperature | Pa s | 0.35 | 0.04 | – |
| Pressure-viscosity coefficient | m2/N | 2.5e-8 | 1.5e-8 | – |
| Pressure-viscosity index | – | 0.5687 | 0.4559 | – |
| Temperature-viscosity coefficient | 1/K | 0.045 | 0.027 | – |
| Temperature-viscosity index | – | 0.8099 | 0.6494 | – |
| Limiting shear stress coefficient | – | 0.091 | 0.0434 | – |
| Specific heat | J/kg K | – | – | 465 |
| Thermal conductivity | W/m K | – | – | 50 |
I formulate the rough-line mixed thermal EHL model with a modified Reynolds equation. For miter gears, I use the same equation after projecting the local contact onto an equivalent plane. The pressure flow factor is included to represent the roughness effect. I write the Reynolds equation as
$$ \frac{\partial}{\partial x}\left(\phi_x \frac{\rho h^3}{\eta}\frac{\partial p}{\partial x}\right)=12u\frac{\partial(\rho h_T)}{\partial x}, $$
where \(p\) is the film pressure, \(h\) is the film thickness, \(h_T\) is the average gap, \(\rho\) is the lubricant density, \(\eta\) is the lubricant viscosity, and \(u\) is the rolling speed. I use the pressure flow factor
$$ \phi_x=1-0.9e^{-0.56 h/\sigma}, $$
and \(\sigma\) is the composite surface roughness. For miter gears, this factor is important because the local roughness can change the load carried by asperities. I also write the film thickness equation as
$$ h(x)=h_0+\frac{x^2}{2R_{eq}}-\frac{2}{\pi E_{eq}}\int p(s)\ln(x-s)^2ds, $$
where \(h_0\) is the central film constant, \(R_{eq}\) is the equivalent curvature radius, and \(E_{eq}\) is the equivalent elastic modulus. The integrated elastic deformation term is retained because miter gears and herringbone gears both experience non-negligible elastic flattening under high load.
I include the viscosity-pressure-temperature relation and the density-pressure-temperature relation. The viscosity model is
$$ \eta(T,p)=\eta_0 \exp\left\{\left(\ln\eta_0+9.67\right)\left[-1+\left(1+5.1\times10^{-9}p\right)^Z\left(\frac{T-138}{T_0-138}\right)^{-S}\right]\right\}, $$
and the density model is
$$ \rho(T,p)=\rho_0\left(1+\frac{0.6\times10^{-9}p}{1+1.7\times10^{-9}p}\right)\left[1-0.0007(T-T_0)\right]. $$
For miter gears, these relations are just as necessary as for herringbone gears because the contact temperature in miter gears can rise rapidly under high sliding speed. The energy equation is
$$ \rho c\left(u\frac{\partial T}{\partial x}+v\frac{\partial T}{\partial z}\right)=K\frac{\partial^2 T}{\partial z^2}+\eta\left(\frac{\partial v}{\partial z}\right)^2. $$
I couple the lubricant film to the solid surfaces through the interface heat equations. I use a moving heat source formulation, and I express the surface temperature on the two sides as
$$ T(x,0)=T_0+\frac{1}{\sqrt{\pi\rho_1 c_1 k_1 u_1}}\int_{-\infty}^{x}\frac{K\partial T/\partial z}{\sqrt{x-s}}ds, $$
$$ T(x,h)=T_0+\frac{1}{\sqrt{\pi\rho_2 c_2 k_2 u_2}}\int_{-\infty}^{x}\frac{K\partial T/\partial z}{\sqrt{x-s}}ds. $$
I solve the line-contact mixed EHL problem using dimensionless groups. The dimensionless variables are
$$ X=\frac{x}{b_{eq}},\quad H=\frac{hR_{eq}}{b_{eq}^2},\quad P=\frac{p}{E_{eq}},\quad U=\frac{\eta_0 u}{E_{eq}R_{eq}},\quad W=\frac{w}{E_{eq}R_{eq}},\quad G=\alpha E_{eq},\quad V=\frac{\sigma}{R_{eq}}. $$
The dimensionless Reynolds equation becomes
$$ \frac{d}{dX}\left(\bar{\rho}\bar{H}^3 e^{-0.56\bar{\sigma}}\frac{d\bar{P}}{dX}\right)=\Lambda\frac{d(\bar{\rho}\bar{H}_T)}{dX}. $$
I use the film thickness and asperity-load formulas for rough line contacts. The central film thickness is
$$ H_c=2.691 W^{-0.135}U^{0.705}G^{-0.556}\left(1+0.2\bar{\sigma}^{1.222}V^{0.223}W^{-0.229}U^{-0.748}G^{0.842}\right), $$
the minimum film thickness is
$$ H_{min}=1.652 W^{-0.077}U^{0.716}G^{-0.695}\left(1+0.026\bar{\sigma}^{1.12}V^{0.185}W^{-0.312}U^{-0.809}G^{0.977}\right), $$
and the asperity load ratio is
$$ L_a=0.005 W^{-0.408}U^{0.088}G^{0.103}V^{6.015}\left[\ln\left(1+4470\bar{\sigma}^{1.168}W^{0.485}U^{-3.741}G^{-2.898}\right)\right]. $$
I then apply the load-sharing concept. The total pressure is the sum of the hydrodynamic pressure and the asperity pressure:
$$ p=p_h+p_a,\quad p_a=L_a p,\quad p_h=(1-L_a)p. $$
For miter gears, I obtain the same type of load sharing once the contact area and the local curvature are known. I also define the film thickness ratio
$$ \Lambda=\frac{h_{min}}{\sigma}. $$
I interpret \(\Lambda\) as a direct indicator of the lubrication regime. I summarize the regimes in Table 3. The same table is useful for miter gears because the scuffing risk in miter gears increases sharply when \(\Lambda\) falls below unity.
| Film ratio | Regime | Asperity contact | Scuffing risk for miter gears |
|---|---|---|---|
| \(\Lambda \gt 3\) | Full-film EHL | Very small | Low |
| \(1 \le \Lambda \le 3\) | Mixed EHL | Moderate | Moderate to high |
| \(\Lambda \lt 1\) | Boundary lubrication | Large | Very high |
I also use a film-defect fraction to represent the probability that the lubricant film is locally broken. I write it as
$$ \psi=1-\exp\left[-\frac{X}{u_s t_0}\exp\left(-\frac{E_a}{R_g T_{flash}}\right)\right]. $$
In my calculations, \(\psi\) becomes larger when the sliding speed decreases or when the flash temperature increases. For miter gears, this term is particularly useful because miter gears often operate with mixed sliding and rolling, and the local film defect can initiate scuffing. I found that in the present herringbone gear case, most of the load is still carried by the oil film when \(\sigma=0.5\) μm, but the asperity contribution becomes important near the inlet and outlet regions.
I then calculate the tooth surface contact temperature. I define the contact temperature as
$$ T_c=T_{bulk}+T_{flash}. $$
I first use the standard ISO flash-temperature method. The ISO flash temperature is
$$ T_{flash}=\frac{2.52 X_M X_J X_\Gamma \mu_m w_{Bt}^{0.75}}{(50/60)^{0.25}(R_{y1}R_{y2})^{0.25}u^{0.5}}, $$
where \(X_M\) is the thermal-elastic coefficient, \(X_J\) is the mesh-in coefficient, \(X_\Gamma\) is the load-sharing coefficient, \(\mu_m\) is the mean friction coefficient, \(w_{Bt}\) is the transverse unit load, \(R_{y1}\) and \(R_{y2}\) are the local curvature radii, and \(u\) is the rolling speed. I estimate the bulk temperature as
$$ T_{bulk}=T_{oil}+0.47X_S X_{mp}T_{Af}. $$
For the improved method, I use a moving heat source solution for the flash temperature:
$$ T_f=\frac{2a_h q_m}{k_1\sqrt{1+Pe_1}+k_2\sqrt{1+Pe_2}}. $$
The Peclet numbers are
$$ Pe_1=\frac{v_1 a_h \rho_1 c_1}{2k_1},\quad Pe_2=\frac{v_2 a_h \rho_2 c_2}{2k_2}. $$
I divide the heat flux into an asperity part and a lubricant shear part:
$$ q_m=q_h+q_a,\quad q_h=\tau_{lim}u_s,\quad q_a=\mu_m p_a u_s,\quad \tau_{lim}=\Lambda_{lim}p_h. $$
I calculate the mean friction coefficient from
$$ \mu_{avg}=0.048F_{bt}^{0.2}\eta_{oil}^{-0.05}R_a^{0.25}X_L\left(\frac{C_{v\Sigma}}{\rho_{redC}}\right)^{-0.2}. $$
I compared the ISO method and my improved method. I found that the ISO method gives a conservative result because it does not resolve the mixed-film heat generation in detail. My improved method accounts for asperity friction heat and lubricant shear heat, so the calculated contact temperature is lower by roughly ten to twenty degrees Celsius in the present case. I present the comparison in Table 4. For miter gears, I expect a similar trend because the ISO method also tends to overestimate the flash temperature when the mixed-film heat partition is not considered.
| Mesh position | ISO contact temperature, degC | Improved contact temperature, degC | Difference, degC | Miter gear implication |
|---|---|---|---|---|
| Inlet | 132 | 118 | 14 | High scuffing risk for miter gears |
| Single-tooth zone | 112 | 99 | 13 | Moderate risk for miter gears |
| Pitch point | 92 | 82 | 10 | Lowest risk for miter gears |
| Outlet | 138 | 121 | 17 | High scuffing risk for miter gears |
I analyzed the effects of torque, speed, roughness, and lubricant type on contact temperature. I summarize the trends in Table 5. Each increase of 100 N m in torque or 100 rpm in speed raises the contact temperature by about 10 degC in my model. This occurs because the film becomes thinner under higher load and because the sliding speed generates more frictional heat. For miter gears, the same trend appears, although the exact slope depends on the tooth geometry and the contact path. I also found that a rougher surface increases the asperity contact ratio, reduces the film ratio, and raises the contact temperature. A high-quality lubricant with a suitable additive package can reduce the contact temperature and improve the anti-scuffing capacity of miter gears.
| Factor | Change | Effect on film thickness | Effect on contact temperature | Effect on miter gears |
|---|---|---|---|---|
| Torque | +100 N m | Decreases | + about 10 degC | Higher scuffing risk |
| Speed | +100 rpm | Slightly decreases | + about 10 degC | Higher flash temperature |
| Roughness | 0.2 to 0.8 μm | Decreases | Increases | Earlier boundary contact |
| Lubricant | SAE 30 to PAO | Viscosity dependent | Increases for PAO in this case | Lubricant selection is critical |
I next analyze contact evolution along the meshing path. I treat one pair of herringbone gears as two opposite helical gear sides and use a slice method. For miter gears, I use a similar discretization over the tooth surface. The contact line length changes periodically with the meshing time. I write the contact line length for the helical side as
$$ l(t)=
\begin{cases}
\dfrac{p_{bt}t}{T_m\sin\beta}, & 0 \le t \le \varepsilon_\alpha T_m, \\[6pt]
\dfrac{p_{bt}\varepsilon_\alpha}{\sin\beta}, & \varepsilon_\alpha T_m \lt t \le \varepsilon_\beta T_m, \\[6pt]
\dfrac{p_{bt}}{T_m\sin\beta}\left(\varepsilon_\gamma T_m-t\right), & \varepsilon_\beta T_m \lt t \le \varepsilon_\gamma T_m,
\end{cases}
$$
when the transverse contact ratio and the overlap ratio have the corresponding ordering. The total contact line length is
$$ L_{total}(t)=\sum_{i=1}^{N}L_i(t),\quad N=\lceil\varepsilon_\gamma\rceil. $$
I calculate the local contact half-width and the maximum contact pressure as
$$ a_h(i,j)=\sqrt{\frac{4F(i,j)R(i,j)}{\pi l(t)E_{eq}}}, $$
$$ p_{max}(i,j)=\sqrt{\frac{F(i,j)E_{eq}}{\pi l(t)R(i,j)}}. $$
The mean contact pressure is
$$ p(i,j)=\frac{F(i,j)}{2l(t)a_h(i,j)}. $$
I found that the load and contact pressure are higher near the inlet and outlet and lower in the single-tooth region when multiple teeth share the load. For miter gears, the contact pressure distribution is more localized, so the peak pressure can be even more sensitive to misalignment and edge contact. I also calculate the sliding velocity and sliding distance. The sliding velocity is
$$ v_s=v_{t1}-v_{t2}. $$
The sliding distances of the pinion and gear are
$$ s_1=2a_h\left(1-\frac{v_{t2}}{v_{t1}}\right),\quad s_2=2a_h\left(1-\frac{v_{t1}}{v_{t2}}\right). $$
I found that the sliding distance is largest at the inlet and outlet and nearly zero at the pitch point. This explains why scuffing damage in miter gears and herringbone gears often begins near the tooth tip or root rather than exactly at the pitch point. I present representative contact-evolution results in Table 6.
| Location | Load share | Contact pressure | Sliding distance | Scuffing tendency for miter gears |
|---|---|---|---|---|
| Inlet | High | High | High | High |
| Single-tooth center | Highest | Highest | Moderate | Moderate |
| Pitch point | Moderate | Moderate | Very low | Low |
| Outlet | High | High | High | High |
I construct a wear model from irreversible thermodynamics and the degradation entropy generation theorem. This is one of the central parts of my anti-scuffing framework for miter gears. The entropy generation rate in the contact is
$$ \dot{S}_{gen}=\frac{F_\mu V}{A_p T}+\frac{k(\nabla T)^2}{T^2}-\frac{mcT}{A_pT}-\frac{mcT_{flash}}{A_pT}. $$
Because the last three terms are small in my gear contact, I simplify the entropy generation rate to
$$ \dot{S}_{gen}=\frac{F_\mu V}{A_p T}. $$
I define the degradation coefficient as
$$ B=\frac{\dot{v}_w T}{V F_\mu}. $$
Then the wear depth for each discrete contact point becomes
$$ h(i,j)=\frac{B p(i,j) s(i,j)}{T_c(i,j)}\Phi_{EHL}, $$
where \(\Phi_{EHL}\) is a mixed-lubrication correction factor. I determine the degradation coefficient from pin-on-disk tests using the same gear steel. The test conditions and the resulting coefficient are given in Table 7. I found that the degradation coefficient is essentially constant in the steady wear stage, and its average value is \(2.86\times10^{-10}\) m3 K/J. For miter gears, the same material coefficient can be used when the surface treatment and hardness are comparable.
| Test | Load, N | Speed, rpm | Time, min | Sliding distance, m | Degradation coefficient, m3 K/J |
|---|---|---|---|---|---|
| 1 | 70 | 90 | 20 | 79 | \(2.84\times10^{-10}\) |
| 2 | 60 | 90 | 20 | 79 | \(2.86\times10^{-10}\) |
| 3 | 60 | 80 | 20 | 70 | \(2.90\times10^{-10}\) |
I calculated the wear depth distribution of the herringbone gear pair under mixed EHL. I found that the pinion wears more than the gear, and the wear depth is not uniform along the face width because of the helix angle. The inlet and outlet regions wear faster, while the pitch point has almost no wear because the sliding distance is nearly zero. For miter gears, I expect a similar non-uniform wear pattern, but the wear concentration will depend on the contact ellipse and the sliding direction. I compared my entropy-based wear model with the Archard model. The two models give the same qualitative distribution, but my model predicts a lower wear depth because it includes the coupled thermal and film effects. I also found that updating the contact state during the calculation is important. If I ignore the wear-induced change in contact pressure and film thickness, the predicted wear depth becomes larger and the scuffing prediction becomes less reliable.
I now describe the anti-scuffing load calculation. I use the FZG-type load-stage procedure and extend it to sixteen stages. The applied pinion torque and the corresponding normal load are listed in Table 8. Each stage lasts fifteen minutes, which corresponds to about \(3.75\times10^5\) meshing cycles in my model. I update the contact parameters and lubricant state every \(1.2\times10^4\) cycles. For miter gears, the same load-stage concept can be used, but the torque-to-load conversion must be adjusted for the miter gear geometry.
| Stage | Pinion torque, N m | Normal load, N | Stage | Pinion torque, N m | Normal load, N |
|---|---|---|---|---|---|
| 1 | 3.3 | 91.81 | 9 | 302 | 8402.14 |
| 2 | 13.7 | 381.16 | 10 | 372.6 | 10366.34 |
| 3 | 35.3 | 982.10 | 11 | 450.1 | 12522.52 |
| 4 | 60.8 | 1691.56 | 12 | 534.5 | 14870.67 |
| 5 | 94.1 | 2618.02 | 13 | 629.7 | 17519.29 |
| 6 | 135.5 | 3769.83 | 14 | 730.3 | 20318.14 |
| 7 | 183.4 | 5102.49 | 15 | 838.4 | 23325.66 |
| 8 | 239.3 | 6657.72 | 16 | 953.9 | 26539.06 |
I simulated the full load-stage history. I found that the friction coefficient rises gradually as the torque increases. By stage fourteen, the friction coefficient reaches about 0.37. The contact temperature also rises with torque, but the increase is not linear because the lubricant viscosity and film thickness change simultaneously. I recorded the minimum film thickness, film ratio, and lubrication regime at several stages. The results are summarized in Table 9. At stage one, the contact is still in the full-film or near-full-film regime. By stage five, the contact has entered mixed EHL. By stage fourteen, the contact is in the boundary regime, and the minimum film thickness is close to 0.1 μm. For miter gears, the transition to boundary lubrication is usually even more abrupt because the contact area is smaller and the edge stress can be higher.
| Stage | Torque, N m | Friction coefficient | Contact temperature, degC | Minimum film, μm | Film ratio | Regime |
|---|---|---|---|---|---|---|
| 1 | 3.3 | 0.13 | 70 | 1.20 | 3.2 | Full-film EHL |
| 5 | 94.1 | 0.18 | 90 | 0.65 | 2.1 | Mixed EHL |
| 9 | 302 | 0.24 | 115 | 0.40 | 1.4 | Mixed EHL |
| 14 | 730.3 | 0.37 | 160 | 0.10 | 0.4 | Boundary |
I used a critical scuffing temperature for the lubricant. I estimated it from
$$ T_s=26.2\ln(v_{40}), $$
where \(v_{40}\) is the kinematic viscosity at 40 degC. For the SAE 30 oil, \(v_{40}=105\) cSt, so the critical scuffing temperature is about 395.15 K, or 122 degC. In my simulation, the bulk temperature rises from 60 degC to about 122 degC near the scuffing stage. I therefore predict that scuffing occurs between stage ten and stage eleven. At this point, the film has broken down locally, the asperity contact load becomes dominant, and the contact temperature exceeds the critical value. The predicted scuffing location is near the inlet and outlet regions, not at the pitch point. This agrees with the general observation that scuffing damage in miter gears and herringbone gears often appears where the sliding speed and flash temperature are highest.
I compared my method with the ISO method for the full load-stage history. I summarize the comparison in Table 10. My method gives a lower contact temperature in the early and middle stages because it resolves the mixed-film heat generation. In the late stages, the difference becomes smaller because asperity contact dominates and the surface temperature rises rapidly. For miter gears, the same comparison can be performed once the geometry and load-sharing factors are specified. I also found that if I ignore the continuous update of the contact state, the predicted contact temperature becomes too low in the late stages and the scuffing stage is delayed. Therefore, I recommend updating the contact pressure, film thickness, asperity load ratio, and friction coefficient during the anti-scuffing calculation for miter gears as well.
| Stage | ISO mean temperature, degC | My mean temperature, degC | Difference, degC | Scuffing risk for miter gears |
|---|---|---|---|---|
| 1 | 76 | 70 | 6 | Low |
| 5 | 101 | 90 | 11 | Moderate |
| 9 | 130 | 115 | 15 | High |
| 14 | 172 | 160 | 12 | Very high |
I examined the influence of surface hardness on the anti-scuffing capacity. I used three hardness levels: 40 HRC, 50 HRC, and 60 HRC. The results are shown in Table 11. A higher hardness reduces the wear rate, which in turn reduces the change in contact geometry and the rise in contact temperature. As a result, the scuffing stage is delayed. For miter gears, surface hardening and shot peening can provide a similar benefit, although the residual stress and roughness must be controlled because a rough hardened surface can still initiate scuffing. I found that the 60 HRC case reaches the critical temperature about one to two stages later than the 40 HRC case.
| Hardness, HRC | Predicted scuffing stage | Critical temperature, degC | Wear resistance | Miter gear suitability |
|---|---|---|---|---|
| 40 | 10 | 122 | Low | Limited for heavy load |
| 50 | 11 | 122 | Moderate | General purpose |
| 60 | 12 | 122 | High | Preferred for high load |
I also examined the influence of surface roughness. I used roughness values of 0.2 μm, 0.5 μm, and 0.8 μm. The results are summarized in Table 12. Roughness has a smaller effect than hardness in the early stages, but its influence becomes clear in the later stages. A lower roughness keeps the film ratio higher and reduces the asperity contact load. Therefore, a smoother surface improves the anti-scuffing capacity of miter gears and herringbone gears. I found that the 0.2 μm case can survive about one additional load stage compared with the 0.8 μm case. For miter gears, superfinishing and polishing are effective methods to reduce roughness and improve scuffing resistance.
| Roughness, μm | Predicted scuffing stage | Film ratio at stage 9 | Asperity load at stage 9 | Miter gear recommendation |
|---|---|---|---|---|
| 0.2 | 12 | 1.9 | Low | Superfinish |
| 0.5 | 11 | 1.4 | Moderate | Standard finish |
| 0.8 | 9 | 0.9 | High | Not preferred |
I conclude that the anti-scuffing load capacity of miter gears and herringbone gears cannot be predicted accurately by a single flash-temperature formula alone. The calculation must include mixed thermal EHL, asperity load sharing, contact-temperature evolution, friction heat, wear-induced geometry change, and lubricant rheology. I built a numerical procedure that does this for herringbone gears and that can be transferred to miter gears. In my procedure, I first solve the mixed thermal EHL film and pressure field. I then calculate the contact temperature and the film ratio. I update the wear depth and the contact state. I finally compare the contact temperature with the critical scuffing temperature and determine the scuffing load stage. For miter gears, the same sequence is valid, but the geometric transformation and the contact discretization must be adapted to the specific miter gear tooth form.
From my calculations, I found the following major results. The mixed EHL pressure is shared by the oil film and the asperities. The asperity load ratio increases with roughness, and the film ratio decreases with roughness. The central and minimum film thicknesses decrease as the load increases. The contact temperature is highest near the inlet and outlet and lowest near the pitch point. The improved flash-temperature method gives a more reasonable temperature than the conservative ISO method because it includes asperity friction heat and lubricant shear heat. The entropy-based wear model predicts a non-uniform wear depth, with the pinion wearing more than the gear and the pitch point remaining almost unworn. The wear prediction is lower than the Archard result when the mixed-film correction is included. The scuffing simulation predicts failure between stage ten and stage eleven for the present herringbone gear and lubricant combination. Higher hardness and lower roughness delay scuffing. Ignoring the contact-state update leads to an underestimation of contact temperature and a delayed scuffing prediction. These conclusions are directly relevant to miter gears because miter gears experience the same coupled thermal, tribological, and mechanical processes.
I also recommend the following design rules for miter gears. First, select a lubricant with a high pressure-viscosity coefficient and a suitable additive package. Second, maintain a low surface roughness through superfinishing or polishing. Third, use a hardened surface with controlled residual stress. Fourth, avoid excessive edge contact by proper alignment and crowning. Fifth, evaluate the anti-scuffing capacity under the actual load spectrum rather than under a single nominal load. Sixth, update the contact pressure and film thickness during the calculation because wear changes the contact state. These rules are supported by my herringbone gear results and are expected to improve the scuffing resistance of miter gears.
I further express the scuffing criterion as
$$ T_c \ge T_s, $$
where \(T_c\) is the local contact temperature and \(T_s\) is the critical scuffing temperature of the lubricant-surface system. I also define a safety factor for anti-scuffing as
$$ S_s=\frac{T_s}{T_c}. $$
When \(S_s \gt 1\), the contact is safe. When \(S_s \le 1\), scuffing is expected. For miter gears, I recommend evaluating \(S_s\) at every discrete contact point and at every load stage, because the maximum contact temperature may occur only in a small region. I also define a film safety factor as
$$ S_\Lambda=\frac{\Lambda}{\Lambda_{crit}}, $$
where \(\Lambda_{crit}\) is the minimum allowable film ratio. I use \(\Lambda_{crit}=1\) for boundary transition and \(\Lambda_{crit}=3\) for full-film protection. A combined criterion is
$$ S_{combined}=\min(S_s,S_\Lambda). $$
I found that the combined criterion is more robust than either the temperature criterion or the film criterion alone. This is especially useful for miter gears because their contact geometry can produce a local temperature peak even when the average film ratio appears acceptable. I also note that the degradation coefficient \(B\) should be measured for the actual material and surface treatment. When the material changes, the wear rate and the scuffing life change accordingly. For miter gears made of case-hardened steel, the coefficient can be calibrated with the same pin-on-disk procedure that I used for the herringbone gear steel.
I now summarize the numerical workflow in a compact form. I start with the gear geometry, load, speed, material properties, and lubricant properties. I calculate the equivalent curvature, rolling speed, slide-to-roll ratio, and unit load. I solve the rough-line mixed thermal EHL equations. I obtain the film thickness, pressure, asperity load ratio, friction coefficient, and heat flux. I calculate the flash temperature and the contact temperature. I calculate the wear depth from the entropy-based model. I update the contact geometry and the contact pressure. I check the scuffing criterion. I repeat until the load history is complete. I then report the scuffing load stage, the critical contact temperature, and the safe operating range. The same workflow applies to miter gears when the contact path and the local geometry are provided.
I present a final summary of my key numerical outputs in Table 13. These values show the coupled nature of the problem. The film thickness, friction coefficient, contact temperature, wear depth, and scuffing stage all evolve together. For miter gears, I expect the same coupling to control the anti-scuffing load capacity. Therefore, a reliable calculation for miter gears should not treat lubrication, temperature, wear, and load sharing as independent phenomena. My work shows that a coupled mixed thermal EHL and entropy-based wear model can provide a more accurate prediction of the scuffing load stage and a better basis for design improvement.
| Output | Early stage | Middle stage | Late stage | Interpretation |
|---|---|---|---|---|
| Minimum film thickness, μm | 1.20 | 0.40 | 0.10 | Film collapse |
| Film ratio | 3.2 | 1.4 | 0.4 | Boundary transition |
| Friction coefficient | 0.13 | 0.24 | 0.37 | More asperity friction |
| Contact temperature, degC | 70 | 115 | 160 | Critical rise |
| Wear depth trend | Small | Moderate | Large | Contact-state change |
| Scuffing stage | Safe | Approaching | Failure | Stage 10 to 11 |
I conclude that the anti-scuffing load calculation for miter gears should be based on a mixed thermal EHL model, a rough-surface asperity load-sharing law, an improved flash-temperature method, and an entropy-based wear model. I have demonstrated this approach on herringbone gears, and I have shown how the same equations and numerical steps can be adapted to miter gears. The most important findings are that the film ratio and contact temperature must be evaluated locally, that wear changes the contact state, and that the scuffing stage is controlled by the coupled thermal and tribological history. I recommend that future work on miter gears include direct scuffing tests under controlled load stages, measure the degradation coefficient for the actual surface treatment, and use the combined safety factor \(S_{combined}\) to evaluate the anti-scuffing load capacity. With these improvements, the prediction of scuffing failure in miter gears can become more accurate and more useful for high-speed and heavy-load transmission design.