
This article presents an integrated analysis of the tribo-dynamic and elastohydrodynamic lubrication (EHL) performance of a TI (Involute Helicoid) hourglass worm drive. The interaction between dynamic tooth loads, friction, and the lubricating film is critical for the performance and longevity of high-load, precision gearing systems like the screw gear. A simplified dynamic model is established by synthesizing the load-sharing theory and fundamental dynamic principles, incorporating time-varying mesh stiffness, transmission error, and the influence of asperity friction. This tribo-dynamic character is then integrated into a line-contact EHL model. The solution yields the variation trends of meshing force and friction over an engagement cycle. Furthermore, the distributions of oil film pressure and thickness under various operational and design parameters are investigated numerically. Key parameters influencing the lubrication performance, such as dynamic load, mesh stiffness, and surface roughness friction coefficient, are discussed in detail to provide insights for the design and analysis of robust screw gear systems.
1. Introduction
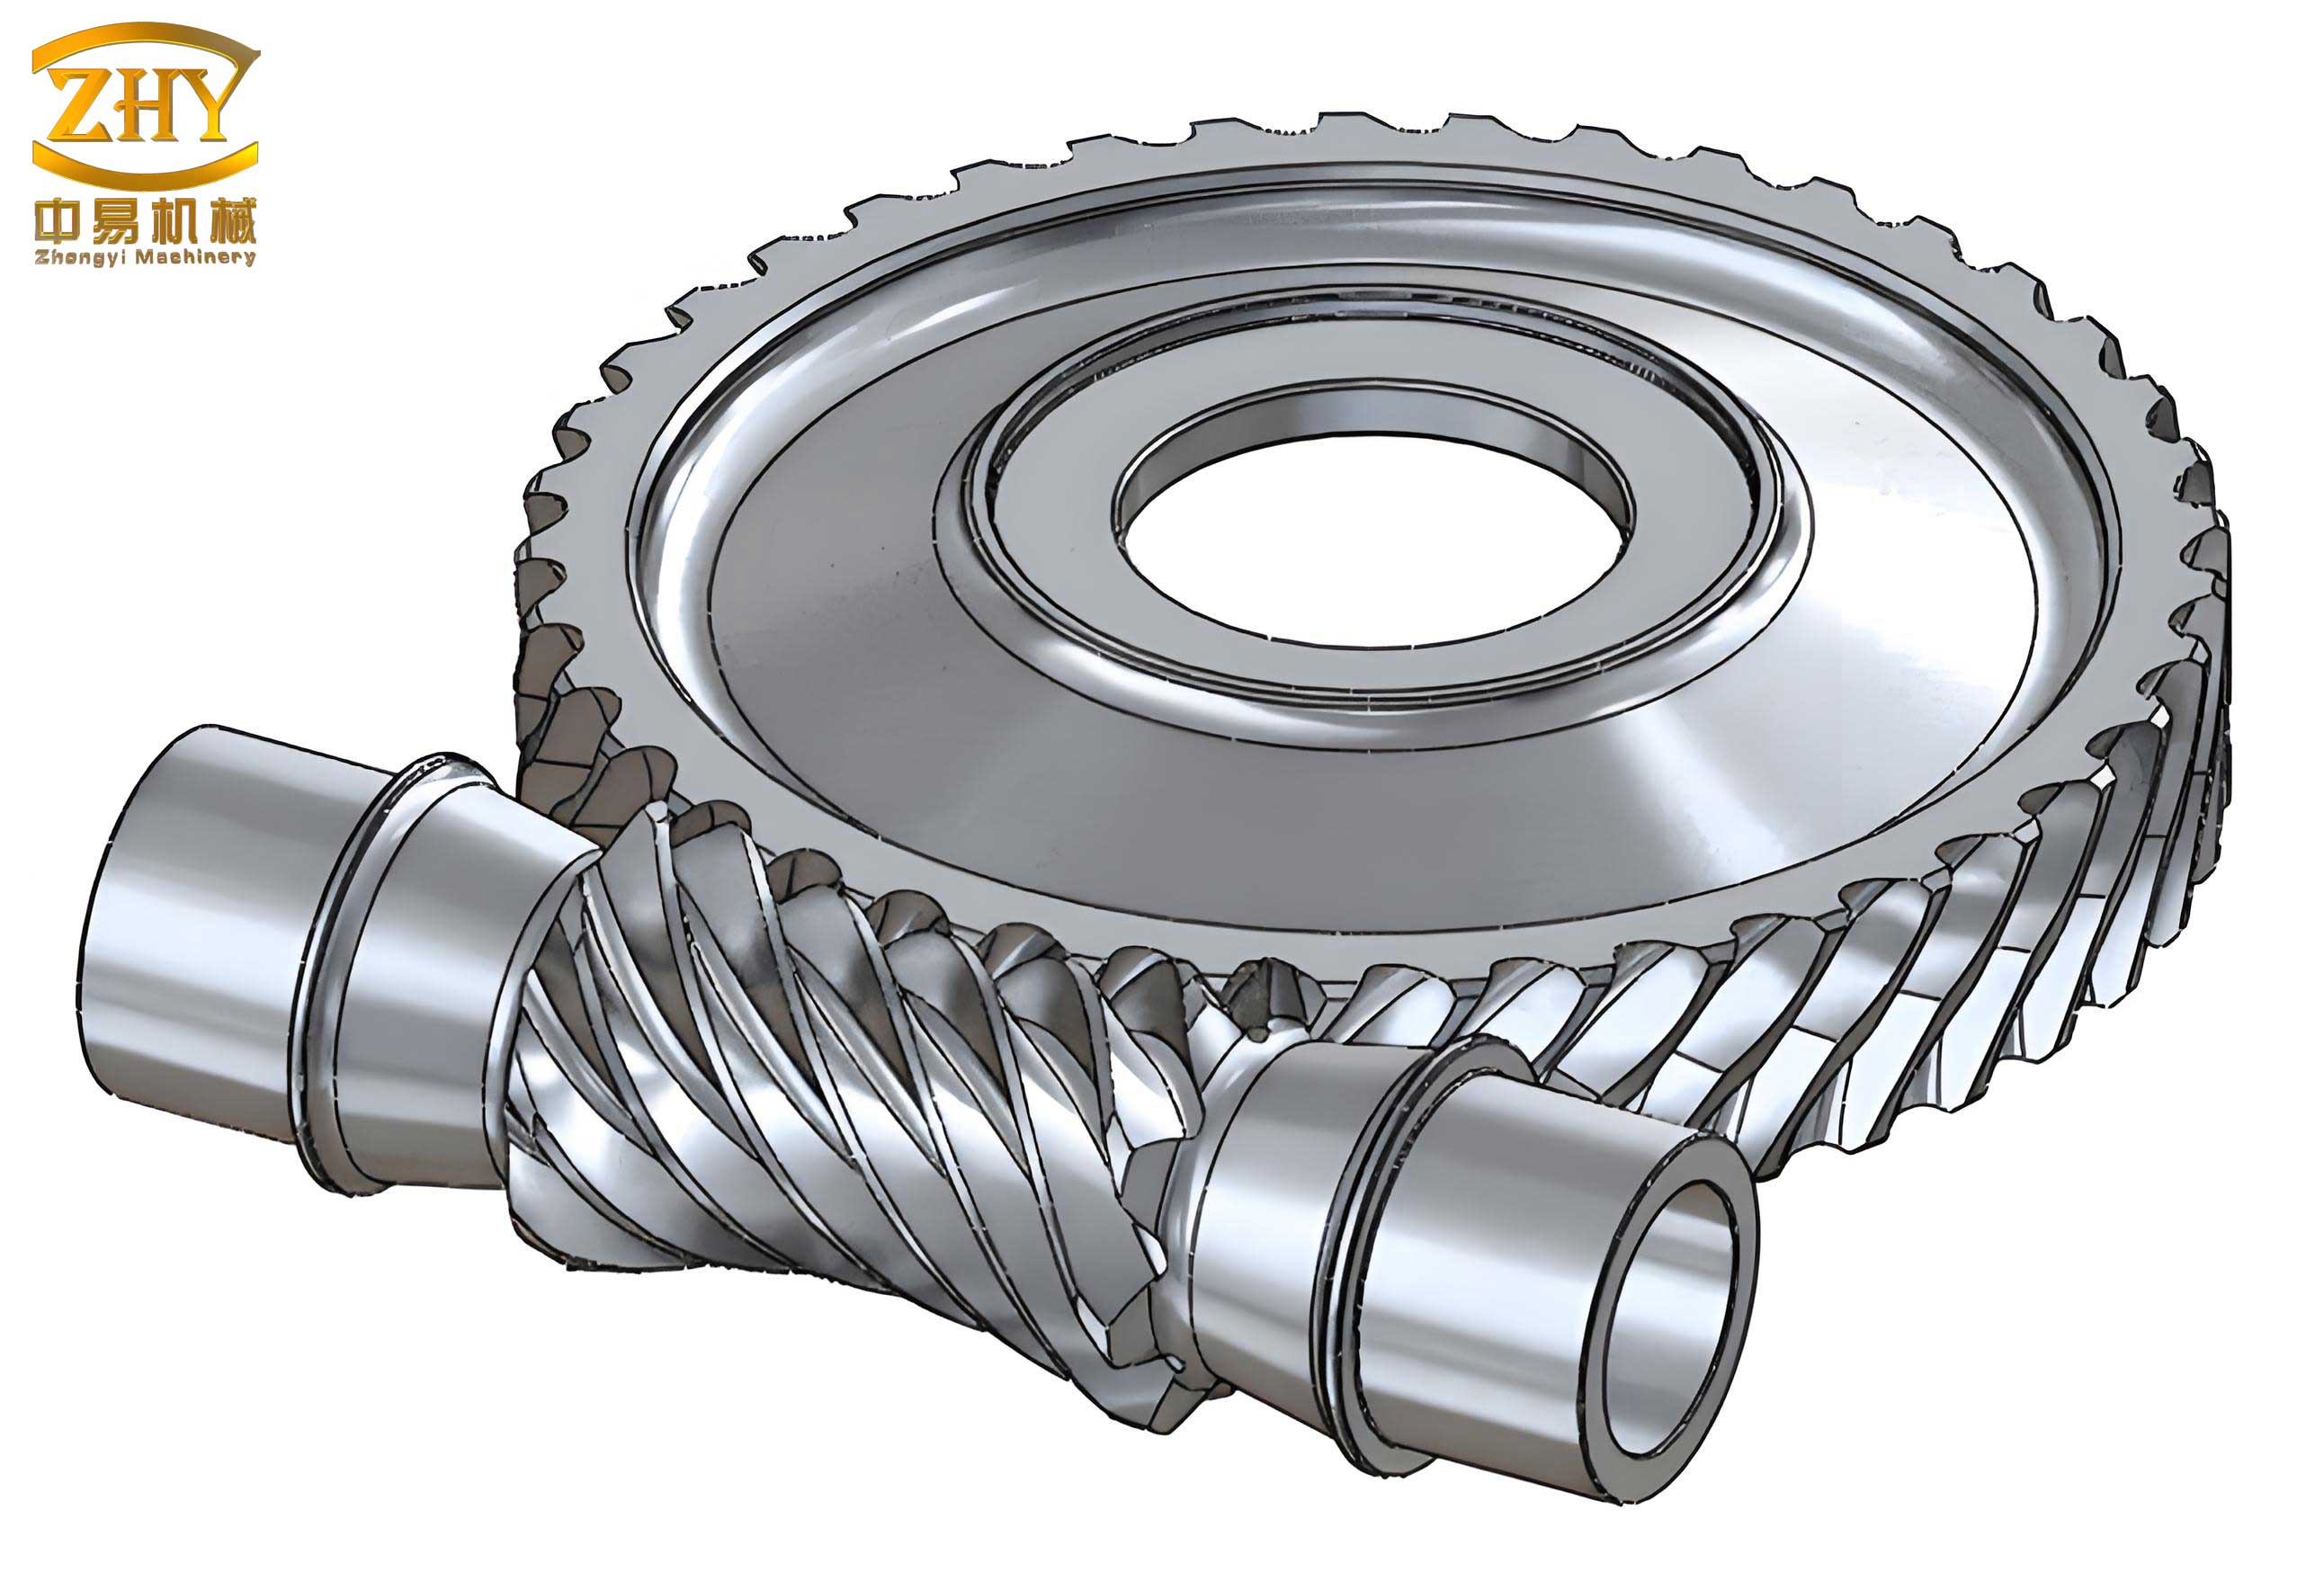
The TI hourglass worm drive, a specific and high-performance type of screw gear, is renowned for its high load-carrying capacity and transmission efficiency, making it suitable for heavy-duty and high-speed applications. The dynamic behavior and lubrication characteristics are pivotal factors determining the reliable and efficient operation of this worm gear pair. In mechanical transmission components, perfectly smooth contact surfaces do not exist. When the surface roughness is significantly smaller than the lubricant film thickness, surfaces can be assumed smooth for analysis. However, for ground TI hourglass worm pairs, the surface roughness is often of the same order of magnitude as the EHL film thickness, making its influence non-negligible.
Recent research has focused extensively on the lubricating film state during gear mesh. Studies have established dynamic models for spur gears coupled with thermal EHL theory, analyzed vibration models considering oil film squeeze effects, and investigated the impact of single and continuous wavy surface roughness on micro-thermal EHL. Furthermore, analyses combining tooth surface friction with lubricant film effects on dynamic load and comparative studies of film distribution under dry and lubricated conditions have been conducted, primarily for gear systems. Research specifically addressing the EHL analysis of involute worm gear pairs considering tribological dynamics is relatively scarce. Therefore, this study takes the TI hourglass worm drive, a sophisticated screw gear variant, as the object. By incorporating frictional characteristics, it aims to analyze the dynamic behavior and the variation laws of oil film pressure and thickness under different parameters.
2. Theoretical Foundation and Modeling
The analysis of a complex screw gear system like the TI worm drive requires coupled modeling of its mechanical dynamics and the fluid film lubrication separating the contacting teeth.
2.1 Tribo-Dynamic Model of the TI Worm Drive
The worm drive system is simplified using a lumped mass method. The worm and worm wheel shafts are assumed rigid. The system is modeled with six degrees of freedom for each member: three translational (x, y, z) and three rotational, though rotations about the X and Y axes are neglected. The model focuses on the torsional vibration about the worm axis (Z_w) and the wheel axis (Z_p), and the translational vibrations. External drive and load torques are denoted as $T_w$ and $T_p$, with moments of inertia $J_w$ and $J_p$, and angular displacements $\theta_w$ and $\theta_p$, respectively. Bearing stiffness and damping are represented by $k_{w}^{x,y,z}$, $k_{p}^{x,y,z}$ and $c_{w}^{x,y,z}$, $c_{p}^{x,y,z}$. The gear mesh is characterized by a time-varying mesh stiffness $k(t)$, damping $c(t)$, dynamic transmission error $\delta(t)$, and static transmission error $e(t)$.
The relative displacement along the line of action is derived from the angular motion:
$$ x(t) = s_w – s_p = r_{bw}\theta_w(t) – r_{bp}\theta_p(t) $$
where $r_{bw}$ and $r_{bp}$ are the base circle radii of the worm and wheel, respectively. Equivalent masses $m_w = J_w / r_{bw}^2$ and $m_p = J_p / r_{bp}^2$ are defined.
The static transmission error, a key excitation source in screw gear dynamics, is expanded as a Fourier series:
$$ e(t) = e_m + \sum_{j=1}^{\infty} e_j \left[\cos(j\omega_e t) + \sin(j\omega_e t)\right] $$
with $e_m$ as the mean amplitude, $e_j$ as harmonic amplitudes, and $\omega_e = 2\pi Z_1 n_w / 60$ as the mesh frequency ($Z_1$: number of worm threads, $n_w$: worm speed).
The dynamic transmission error, accounting for bearing deflections $x_w(t)$ and $x_p(t)$, is:
$$ \delta(t) = r_{bw}\theta_w(t) – r_{bp}\theta_p(t) + x_w(t) – x_p(t) $$
The difference between dynamic and static transmission error is:
$$ \Delta(t) = x(t) + x_w(t) – x_p(t) – e(t) $$
Considering the backlash $b_n$, the displacement function $\zeta(t)$ for the gear mesh is defined with a piecewise linear function. The dynamic meshing force for the $i$-th tooth pair is:
$$ F_{d}^{i}(t) = k_i(t) \zeta(t) + c_i(t) \dot{\Delta}(t) $$
The corresponding friction force on the tooth flank is:
$$ F_{f}^{i}(t) = \Lambda_i(t) \mu_i(t) F_{d}^{i}(t) $$
where $\mu_i(t)$ is the friction coefficient at the contact point, and $\Lambda_i(t) = \text{sgn}(v_1 – v_2)$ is a direction coefficient based on the sliding velocities $v_1$ and $v_2$ of the worm and wheel.
2.2 Time-Varying Mesh Stiffness Including Oil Film Compliance
In the coupled system, the lubricant film between the screw gear teeth acts as a spring with stiffness $k_H$, connected in series with the mechanical tooth contact stiffness $k_M$. The oil film stiffness is defined as the derivative of the dynamic load with respect to the central film thickness $H_c$:
$$ k_{H}^i(t) = \frac{\partial F_d^i(t)}{\partial H_c^i(t)} $$
Thus, the effective time-varying mesh stiffness $k_i(t)$ for a tooth pair, considering EHL compliance, becomes:
$$ \frac{1}{k_i(t)} = \frac{1}{k_{M}^i(t)} + \frac{1}{k_{H}^i(t)} \quad \Rightarrow \quad k_i(t) = \frac{k_{M}^i(t) k_{H}^i(t)}{k_{M}^i(t) + k_{H}^i(t)} $$
This formulation directly links the dynamic load from the mechanical model to the lubrication analysis.
2.3 Governing Dynamic Equations
Applying Newton’s second law to the tribo-dynamic model yields the system of differential equations governing the screw gear pair’s motion:
$$
\begin{aligned}
J_w \ddot{\theta}_w(t) + r_{bw} \sum_{i=1}^{n_z} F_{d}^{i}(t) + \sum_{i=1}^{n_z} \Lambda_i \lambda_{wi} \mu_i F_{f}^{i}(t) &= T_w \\
J_p \ddot{\theta}_p(t) – r_{bp} \sum_{i=1}^{n_z} F_{d}^{i}(t) + \sum_{i=1}^{n_z} \Lambda_i \lambda_{pi} \mu_i F_{f}^{i}(t) &= -T_p \\
m_w \ddot{x}_w(t) + c_w^x \dot{x}_w(t) + k_w^x x_w(t) + \sum_{i=1}^{n_z} F_{d}^{i}(t) &= 0 \\
m_p \ddot{x}_p(t) + c_p^x \dot{x}_p(t) + k_p^x x_p(t) – \sum_{i=1}^{n_z} F_{d}^{i}(t) &= 0 \\
… \quad \text{(Equations for y and z directions follow similarly)}
\end{aligned}
$$
where $n_z$ is the number of tooth pairs in simultaneous contact, and $\lambda$ coefficients account for the direction cosines of friction forces.
3. Elastohydrodynamic Lubrication Model
The contact in a TI worm drive can be modeled as an equivalent line contact. Given the small contact width relative to the surface radii of curvature, the meshing can be approximated by the contact of two equivalent cylinders. According to Hertzian theory, this can be further simplified to a contact between a rigid plane and an equivalent elastic cylinder with effective radius $R$ and effective modulus $E’$, as shown below.
$$
\frac{1}{E’} = \frac{1}{2} \left( \frac{1-\mu_1^2}{E_1} + \frac{1-\mu_2^2}{E_2} \right), \quad R = \frac{\rho_w \rho_p}{\rho_w + \rho_p}
$$
Since the kinematic and geometric parameters vary with time, the EHL analysis is performed at discrete points along the instantaneous contact line, treating each as a transient line contact problem.
3.1 Governing Reynolds Equation and Film Thickness
The generalized Reynolds equation for the line contact, considering non-Newtonian effects, is:
$$ \frac{\partial}{\partial x} \left( \frac{\rho h^3}{\eta^*} \frac{\partial p}{\partial x} \right) = 12 u_{e} \frac{\partial (\rho h)}{\partial x} + 12 \frac{\partial (\rho h)}{\partial t} $$
where $h$ is the film thickness, $p$ is pressure, $\rho$ is density, $u_{e}$ is the entrainment velocity, and $\eta^*$ is an effective viscosity accounting for limiting shear stress behavior.
The film thickness equation comprises the geometric gap, elastic deformation $\delta(x,t)$, and surface roughness $S(x,t)$:
$$ h(x,t) = h_0(t) + \frac{x^2}{2R} + \delta(x,t) + S(x,t) $$
The elastic deformation is given by the integral of pressure:
$$ \delta(x,t) = -\frac{2}{\pi E’} \int_{x_{in}}^{x_{out}} p(s,t) \ln|x-s| \, ds $$
Surface roughness is modeled as a superposition of transverse cosine functions for both surfaces of the screw gear.
3.2 Load Sharing and Friction in Mixed EHL
Under mixed lubrication conditions, the total dynamic load $F_d$ is shared between the fluid film and the contacting asperities:
$$ F_d = F_h + F_a $$
Similarly, the total friction force $F_f$ is the sum of viscous shear in the fluid and asperity friction:
$$ F_f = F_{fh} + F_{fa} \quad \text{with} \quad F_{fa} = \mu_a F_a $$
where $\mu_a$ is the boundary friction coefficient. The viscous friction component is obtained by integrating the shear stress $\tau$ across the contact. The effective friction coefficient experienced by the screw gear tooth is then:
$$ \mu = \frac{F_f}{F_d} = \frac{F_{fh} + \mu_a F_a}{F_d} $$
3.3 Material and Lubricant Properties
The pressure-viscosity relationship is described by the commonly used Roelands equation:
$$ \eta(p) = \eta_0 \exp\left\{ (\ln \eta_0 + 9.67) \left[ (1 + 5.1 \times 10^{-9} p)^z – 1 \right] \right\} $$
The density-pressure relationship is:
$$ \rho(p) = \rho_0 \left( 1 + \frac{0.6 \times 10^{-9} p}{1 + 1.7 \times 10^{-9} p} \right) $$
The central film thickness in the rough surface EHL contact is estimated using the Moes dimensionless parameter relations, which correlate film thickness to load, speed, material, and lubricant properties.
4. Numerical Solution Methodology
The coupled tribo-dynamic and EHL problem is solved iteratively, as the oil film stiffness $k_H$ required in the dynamic model depends on the EHL solution, which itself requires the dynamic load and kinematics as input.
- Step 1: Dynamic Analysis. Solve the system of dynamic equations (assuming an initial guess for $k_H$ and $\mu$) to obtain the time-history of dynamic tooth load $F_d^i(t)$, entrainment velocity $u_e(t)$, effective radius $R(t)$, and sliding velocity for each discrete contact point.
- Step 2: EHL Analysis. For each time step/contact point, use the dynamic results as inputs to solve the transient EHL equations (Reynolds, film thickness, elasticity, force balance) numerically. This yields the central film thickness $H_c(t)$ and the average friction coefficient $\mu(t)$.
- Step 3: Property Update. Calculate the new oil film stiffness $k_H(t) = \partial F_d / \partial H_c$ and update the friction coefficient.
- Step 4: Iteration. Feed the updated $k_H(t)$ and $\mu(t)$ back into the dynamic model. Repeat Steps 1-3 until the oil film stiffness values converge within a specified tolerance.
This iterative loop effectively captures the mutual interaction between the rigid body dynamics of the screw gear and the separating lubricant film.
5. Results and Discussion
Using the developed model, simulations are performed for a TI worm drive with parameters listed in Table 1. The lubricant properties are also specified.
| Parameter | Symbol | Value |
|---|---|---|
| Number of worm threads / Wheel teeth | $Z_1 / Z_2$ | 1 / 40 |
| Normal module | $m_n$ | 5 mm |
| Pressure angle | $\alpha$ | 20° |
| Helix angle (Worm) | $\beta$ | 5°, 10°, 15° |
| Center distance | $a$ | 125 mm |
| Poisson’s ratio (Worm / Wheel) | $\mu_1 / \mu_2$ | 0.26 / 0.29 |
| Elastic modulus (Worm / Wheel) | $E_1 / E_2$ | 205 / 209 GPa |
| Worm speed (base) | $n_w$ | 3000 rpm |
| Backlash | $b_n$ | 6 $\mu$m |
| Bearing stiffness | $k_{w,p}$ | $1 \times 10^{11}$ N/m |
| Damping ratio | $\zeta$ | 0.1 |
| Asperity friction coefficient | $\mu_a$ | 0.1 |
| Lubricant density | $\rho_0$ | 864 kg/m³ |
| Lubricant dynamic viscosity (@40°C) | $\eta_0$ | 0.068 Pa·s |
| Pressure-viscosity coefficient | $\alpha$ | 2.2e-8 Pa⁻¹ |
5.1 Dynamic Behavior: Meshing Force and Friction
Figure 1 shows the variation of the dynamic meshing force over one mesh cycle for different helix angles $\beta$ and at two speed levels (high and low).
Observation 1: The meshing force is higher at the engagement start (inlet), reduces during the middle of the mesh, and increases again near the disengagement (outlet) due to the changing number of contact lines and load sharing. At low speed, the inertia effects are lower, and the force at engagement is more pronounced compared to high speed. A larger helix angle $\beta$ increases the overall meshing force at both inlet and outlet, promoting more stable load transmission in the screw gear.
Figure 2 illustrates the corresponding tooth friction force during the mesh cycle.
Observation 2: The friction force exhibits a more complex pattern: it initially increases, then decreases, and finally increases in the opposite direction as the sliding velocity reverses sign near the pitch line. Low-speed operation results in higher friction forces at engagement. Crucially, increasing the helix angle $\beta$ not only stabilizes the force but also reduces the peak magnitude of the friction force. This reduction in maximum friction is directly beneficial for improving the transmission efficiency and service life of the screw gear system.
5.2 EHL Performance: Pressure and Thickness Profiles
The EHL film profiles are analyzed under a steady-state condition representative of a high-load point in the mesh. The dimensionless domain is $X = x/b \in [-3.5, 2.0]$, where $b$ is the Hertzian half-width. The boundary conditions are $P(X_{in})=0$ and $P(X_{out})=\frac{dP}{dX}(X_{out})=0$.
Effect of Dynamic Meshing Force $F_d$: Figure 3 shows pressure $P$ and film thickness $H$ profiles for different loads.
$$ \text{As } F_d \text{ increases:} \quad \text{Max}(P) \uparrow, \quad \text{Film Thickness } H \uparrow, \quad \text{Pressure fluctuations } \downarrow $$
Higher load increases the Hertzian pressure but also enhances the piezoviscous effect, leading to a thicker central film. The pressure spike becomes more pronounced but the inlet perturbations are dampened.
Effect of Mesh Stiffness $k_M$: Figure 4 shows the influence of varying the mechanical tooth stiffness.
$$ \text{As } k_M \text{ increases:} \quad \text{Max}(P) \uparrow \uparrow, \quad \text{Film Thickness } H \uparrow \uparrow, \quad \text{Fluctuations } \downarrow $$
Mesh stiffness has the most significant impact. A stiffer screw gear tooth contact reduces compliance, leading to a smaller Hertzian contact area and thus higher peak pressure. The consequent stronger viscous wedge effect generates a noticeably thicker lubricant film.
Effect of Asperity Friction Coefficient $\mu_a$: Figure 5 shows profiles for different $\mu_a$.
$$ \text{As } \mu_a \text{ increases:} \quad \text{Max}(P) \uparrow, \quad \text{Film Thickness } H \downarrow $$
A higher boundary friction coefficient increases the shear stresses in the contact zone. This additional thermal and shear effect slightly elevates the pressure peak and can lead to a marginal reduction in the central film thickness due to altered flow conditions.
6. Conclusions
An integrated tribo-dynamic and elastohydrodynamic lubrication model has been developed and solved for a TI hourglass worm drive, a high-performance screw gear system. The model successfully couples the time-varying mechanical excitations (stiffness, error) with the mixed lubrication physics at the tooth interface. Key findings are summarized as follows:
- Dynamic Performance: The meshing force varies cyclically, being highest at engagement and re-engagement. Low-speed operation leads to higher engagement forces. Increasing the helix angle $\beta$ raises the meshing force throughout the cycle, enhancing stability. The friction force follows a complex pattern due to sliding reversal. A larger $\beta$ reduces the peak friction force, which is critical for improving the longevity and efficiency of the screw gear drive.
- Lubrication Performance: The EHL film is significantly influenced by operating conditions. Both increased dynamic load $F_d$ and mesh stiffness $k_M$ lead to a thicker central oil film, with stiffness having the dominant effect. A higher asperity friction coefficient $\mu_a$ slightly increases the pressure peak and reduces film thickness.
- Design Implication: Selecting a material with high tooth stiffness is beneficial not only for structural integrity but also for promoting the formation of a thicker elastohydrodynamic film in the screw gear contact, thereby improving wear protection. Optimizing the helix angle can effectively manage both dynamic loads and friction losses.
This analysis provides a framework for understanding the complex interactions in precision screw gear systems, enabling more informed design choices for high-load, high-efficiency worm gear applications.