
In the realm of mechanical power transmission, spur and pinion gears stand as fundamental components, prized for their simplicity, efficiency, and ease of manufacturing. As a mechanical engineer deeply involved in dynamic analysis, I have consistently observed that the operational performance of these gears is not static. During service, spur and pinion gears are subjected to a complex interplay of external loads from driven machinery and internal excitations arising from mesh stiffness variation and manufacturing errors. This dynamic environment can induce resonant conditions, leading to excessive vibration and noise, accelerated wear, and premature failures such as bending and torsional fatigue. Therefore, a profound understanding of their intrinsic dynamic characteristics, primarily their natural frequencies and mode shapes, is paramount during the initial design phase. The core objective is to strategically position these natural frequencies away from dominant excitation frequencies to ensure reliable and quiet operation. In this extensive analysis, I will detail the process of establishing a high-fidelity three-dimensional model of a spur and pinion gear, performing a finite element-based modal analysis, and extracting critical insights to inform robust dynamic design and optimization.
The theoretical foundation for this investigation lies in structural dynamics and modal analysis theory. Any elastic structure, including a spur and pinion gear, can be discretized into a multi-degree-of-freedom system. Its dynamic response under time-varying forces is governed by the well-known equation of motion:
$$ [M]\{\ddot{x}\} + [C]\{\dot{x}\} + [K]\{x\} = \{F(t)\} $$
where $[M]$, $[C]$, and $[K]$ represent the global mass, damping, and stiffness matrices of the system, respectively. The vectors $\{\ddot{x}\}$, $\{\dot{x}\}$, and $\{x\}$ correspond to the nodal acceleration, velocity, and displacement. $\{F(t)\}$ is the vector of external excitation forces. To find the inherent dynamic properties—the natural frequencies and mode shapes—we consider the undamped free-vibration condition. By setting the damping matrix $[C]$ and the force vector $\{F(t)\}$ to zero, the equation simplifies to:
$$ [M]\{\ddot{x}\} + [K]\{x\} = \{0\} $$
Assuming a harmonic solution of the form $\{x\} = \{\phi\}_i \sin(\omega_i t)$, we arrive at the fundamental eigenvalue problem:
$$ \left( [K] – \omega_i^2 [M] \right) \{\phi\}_i = \{0\} $$
Solving this eigenvalue problem yields $n$ eigenvalues $\omega_i^2$ and corresponding eigenvectors $\{\phi\}_i$, where $n$ is the number of degrees of freedom. The natural frequency $f_i$ for the $i$-th mode is calculated as $f_i = \omega_i / (2\pi)$. The eigenvector $\{\phi\}_i$ describes the deformed shape of the structure when vibrating at that particular natural frequency, known as the mode shape. In practical engineering, the lower-order modes (typically the first 6 to 10) are most critical, as they are most easily excited by common operational forces and contain the majority of the system’s vibrational energy. Consequently, my analysis focuses on the first six modal parameters of a representative spur and pinion gear.
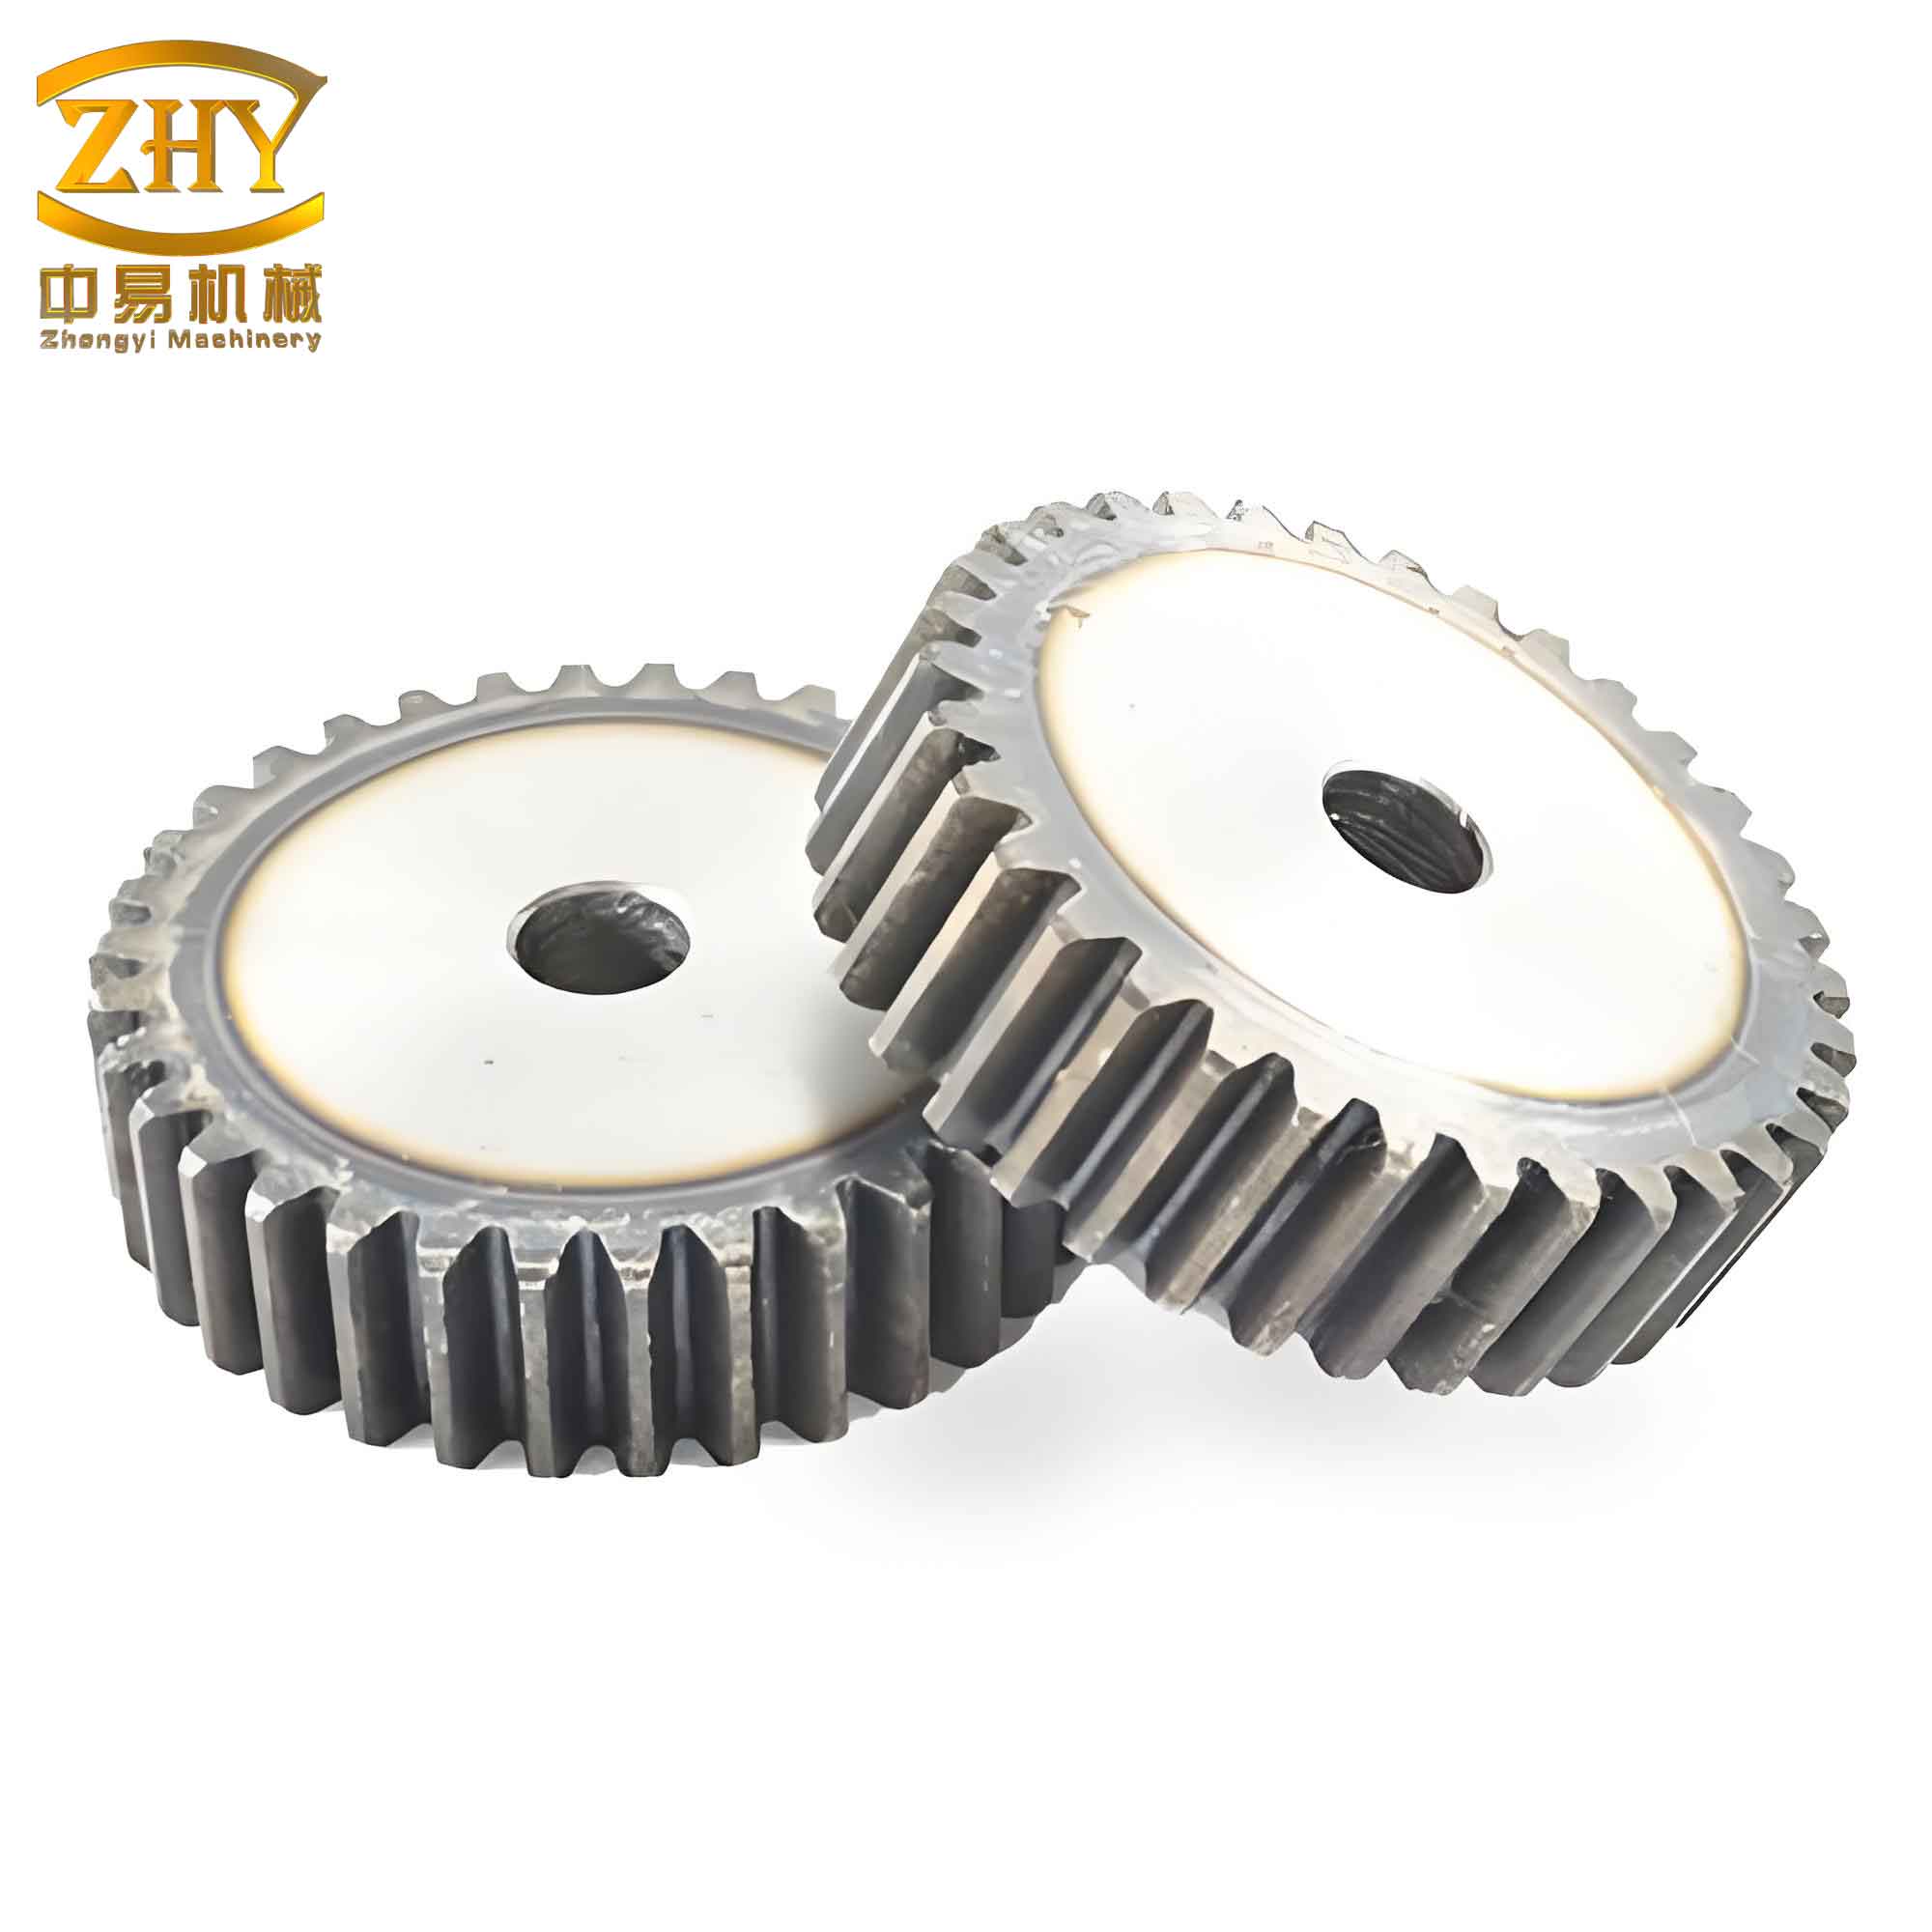
Accurate geometric modeling is the indispensable first step in any credible finite element analysis. For this study, I selected a standard involute spur gear with parameters common in industrial power transmission systems. The three-dimensional solid model was meticulously constructed using advanced CAD software, ensuring precise tooth geometry based on the fundamental law of gearing. The key parameters for this spur and pinion gear model are as follows:
- Number of Teeth (Z): 40
- Module (m): 2 mm
- Pressure Angle (α): 20°
- Face Width (b): 20 mm
- Bore Diameter (Φ): 20 mm
- Material: Medium Carbon Steel
- Young’s Modulus (E): 2.06e5 MPa
- Poisson’s Ratio (μ): 0.27
- Density (ρ): 7850 kg/m³
The material properties are crucial for determining both the mass and stiffness matrices, $[M]$ and $[K]$, in the finite element formulation. The precise involute profile ensures that the stiffness distribution along the gear rim, which significantly influences torsional modes, is correctly represented in the model.
With the solid model complete, the next phase involves preparing it for finite element analysis. I utilized an integrated simulation environment to perform this modal extraction. The process begins with defining the boundary conditions, which for a free-modal analysis (to find the gear’s intrinsic properties) typically involve leaving the gear unconstrained. However, to simulate a more realistic mounted condition, I applied a fixed constraint to the entire surface of the bore and keyway, representing a rigid connection to a shaft. This boundary condition is critical as it dramatically affects the resulting frequencies, particularly the lower-order modes involving body translation and rotation, which would otherwise be zero for a free body.
The gear body is then discretized into a finite number of small elements. For this analysis, I employed a combination of tetrahedral and hexahedral solid elements, which are well-suited for capturing the complex three-dimensional stress and deformation fields. The software’s automatic meshing algorithm was guided by a curvature-based refinement rule to ensure a finer mesh along the root fillets and tooth profiles—areas of high-stress concentration. The final mesh statistics were robust, consisting of over 5000 solid elements and approximately 2000 nodes, ensuring solution accuracy while maintaining computational efficiency. The governing matrices $[K]$ and $[M]$ are assembled based on this discretized geometry and the material properties.
The core modal analysis was executed by instructing the solver to extract the first six eigenvalues and eigenvectors from the system defined by $[K]$ and $[M]$, following the equation $([K] – \omega_i^2 [M])\{\phi\}_i = 0$. The results, namely the natural frequencies and their associated mode shapes, provide a vivid picture of how the spur and pinion gear will vibrate if excited at these specific frequencies. The calculated natural frequencies for the first six modes are summarized in the table below.
| Mode Number | Natural Frequency (Hz) | Primary Mode Shape Description |
|---|---|---|
| 1 | 10764 | First Circumferential (Nodal Diameter) Mode: The gear rim deforms into a two-lobed (elliptical) shape. |
| 2 | 12123 | Second Circumferential Mode: The rim deforms into a three-lobed shape, often appearing as a “triangular” distortion. |
| 3 | 12344 | First Axial (Umbrella) Mode: The gear web and rim oscillate axially, resembling an umbrella opening and closing. |
| 4 | 13842 | Third Circumferential Mode: The rim deforms into a four-lobed shape (“square” distortion). |
| 5 | 16083 | First Torsional Mode: The gear experiences twisting about its central axis, with opposite sides of the rim moving out of phase axially. |
| 6 | 16234 | Coupled Torsional-Axial Mode: A more complex deformation combining twisting and axial bending of the web. |
Analyzing these results reveals critical patterns for the dynamic design of spur and pinion gears. The first two modes are dominated by circumferential bending of the gear rim. These “diametral” modes are particularly sensitive to forces arising from tooth meshing, especially if there is any mass unbalance or asymmetry. For a spur and pinion gear pair, the meshing frequency $f_m$ is given by $f_m = N * \text{RPM} / 60$, where $N$ is the number of teeth on the subject gear. It is absolutely vital to ensure that $f_m$ and its higher harmonics (e.g., $2f_m$, $3f_m$) do not coincide with any of the natural frequencies listed in the table, particularly the lower-order ones like Mode 1 and Mode 2. A coincidence would lead to resonance, dramatically amplifying vibrations and stresses.
Modes 3 and 6 show significant axial displacement. These modes can be excited by axial thrust components, which, although minimal in ideal spur and pinion gears, can be present due to misalignment or other system imperfections. The torsional mode (Mode 5) is of utmost importance for the transmission of torque. Excitation for this mode comes directly from the fluctuating torque input and the time-varying mesh stiffness of the engaging spur and pinion teeth. The frequency of torsional excitation can be related to the tooth meshing frequency. If the system’s torsional natural frequency is close to this excitation frequency, it can lead to severe torsional vibrations, potentially causing shaft failure or accelerated tooth wear.
The finite element method allows for powerful “what-if” scenarios that are invaluable for optimizing the spur and pinion gear design. By parametrically varying the model’s geometry, one can systematically study the influence of key design parameters on the natural frequencies. For instance, increasing the face width $b$ generally increases the stiffness against torsional and axial modes, thereby raising their natural frequencies. However, it also increases the mass, which has the opposite effect. The net result depends on which factor dominates. Similarly, increasing the web thickness or adding ribs (webbing) between the hub and rim dramatically increases the stiffness for rim bending and torsional modes, shifting their frequencies higher. Modifying the bore diameter or hub design alters the boundary condition stiffness, affecting all modes, especially the lower ones. A larger, stiffer hub raises all frequencies. The material properties are direct scaling factors. The natural frequencies are proportional to $\sqrt{E/\rho}$. Therefore, switching from steel to a material like titanium (higher $E/\rho$ ratio) would increase all natural frequencies.
To put this into a practical design framework, I can formulate a simplified objective for optimizing a spur and pinion gear against resonance. One common approach is to maximize the frequency separation between the excitation and natural frequencies. If $f_{ex}$ is a primary excitation frequency (e.g., mesh frequency or its harmonic), and $f_{n,i}$ are the gear’s natural frequencies, a designer might seek to maximize a minimum separation factor $\eta$:
$$ \eta = \min_i \left( \frac{|f_{n,i} – f_{ex}|}{f_{ex}} \right) $$
Subject to geometric constraints such as:
$$ b_{min} \le b \le b_{max} $$
$$ m_{min} \le m \le m_{max} $$
$$ d_{hub,min} \le d_{hub} \le d_{hub,max} $$
This is a constrained optimization problem where the design variables (face width $b$, module $m$, web thickness, etc.) are adjusted, the finite element model is updated automatically, a new modal analysis is performed, and $\eta$ is recalculated until an optimum is found.
In conclusion, the modal analysis of spur and pinion gears is not merely an academic exercise but a critical pillar of modern mechanical design. Through the methodology I have presented—starting from precise geometric modeling, through careful finite element discretization and boundary condition application, to the solution of the eigenvalue problem—we can accurately predict the fundamental dynamic signatures of these components. The results unequivocally show that the lower-order modes of a spur and pinion gear, encompassing circumferential bending, axial motion, and torsion, are the most susceptible to excitation from common operational forces. The strategic interpretation of these mode shapes and natural frequencies enables engineers to proactively design gears that avoid resonant conditions. This is achieved by intelligent geometric tailoring, such as optimizing web profiles and face widths, and by carefully planning operational speeds (RPM) to keep excitation frequencies away from critical natural frequencies. By integrating this simulation-driven approach early in the design cycle, we can significantly enhance the reliability, longevity, and acoustic performance of transmission systems relying on spur and pinion gears, moving from a paradigm of failure mitigation to one of performance assurance.