
In the pursuit of sustainable transportation, hybrid electric vehicles (HEVs) have emerged as a pivotal technology, combining internal combustion engines and electric motors to improve fuel efficiency and reduce emissions. Among various HEV configurations, parallel hybrid systems offer a balance between complexity and performance, where both power sources can directly drive the wheels. A critical component in such systems is the power coupling device, which integrates and manages the torque from the engine and motor. Traditional coupling mechanisms, such as hydraulic couplers or planetary gear sets, often involve high costs, sensitivity to environmental conditions, or complex control algorithms. In contrast, the bevel gear coupler presents a simpler, more robust alternative with mechanical reliability and lower production expenses. This paper focuses on the design and simulation of a control system for a parallel hybrid electric vehicle utilizing a bevel gear coupler, emphasizing a motor-assist strategy to optimize energy distribution. The control strategy ensures that the engine operates within its efficient range while the motor provides supplementary torque, and the battery state of charge is maintained. Through mathematical modeling and simulation in MATLAB/Simulink, the feasibility and effectiveness of the bevel gear coupler control system are demonstrated, highlighting its ability to manage power flow seamlessly in urban driving cycles.
The bevel gear coupler is a mechanical assembly that employs conical gears to combine torques from multiple sources. Its simplicity stems from the use of straightforward gear arrangements, which reduce manufacturing complexity compared to planetary or hydraulic systems. The core principle involves three bevel gears: one connected to the engine via a clutch, another to the electric motor, and the third to the transmission input shaft. This configuration allows for flexible mode switching, such as engine-only drive, motor-only drive, or combined power delivery, by controlling the clutch engagement. The bevel gear mechanism ensures reliable torque transmission without interference, making it suitable for harsh environmental conditions where temperature variations might affect hydraulic systems. Moreover, the mechanical nature of bevel gears minimizes energy losses associated with fluid dynamics or complex gear trains, contributing to overall system efficiency. In this work, I explore the control system design that leverages these advantages, focusing on real-time torque management to meet vehicle demand while preserving battery health.
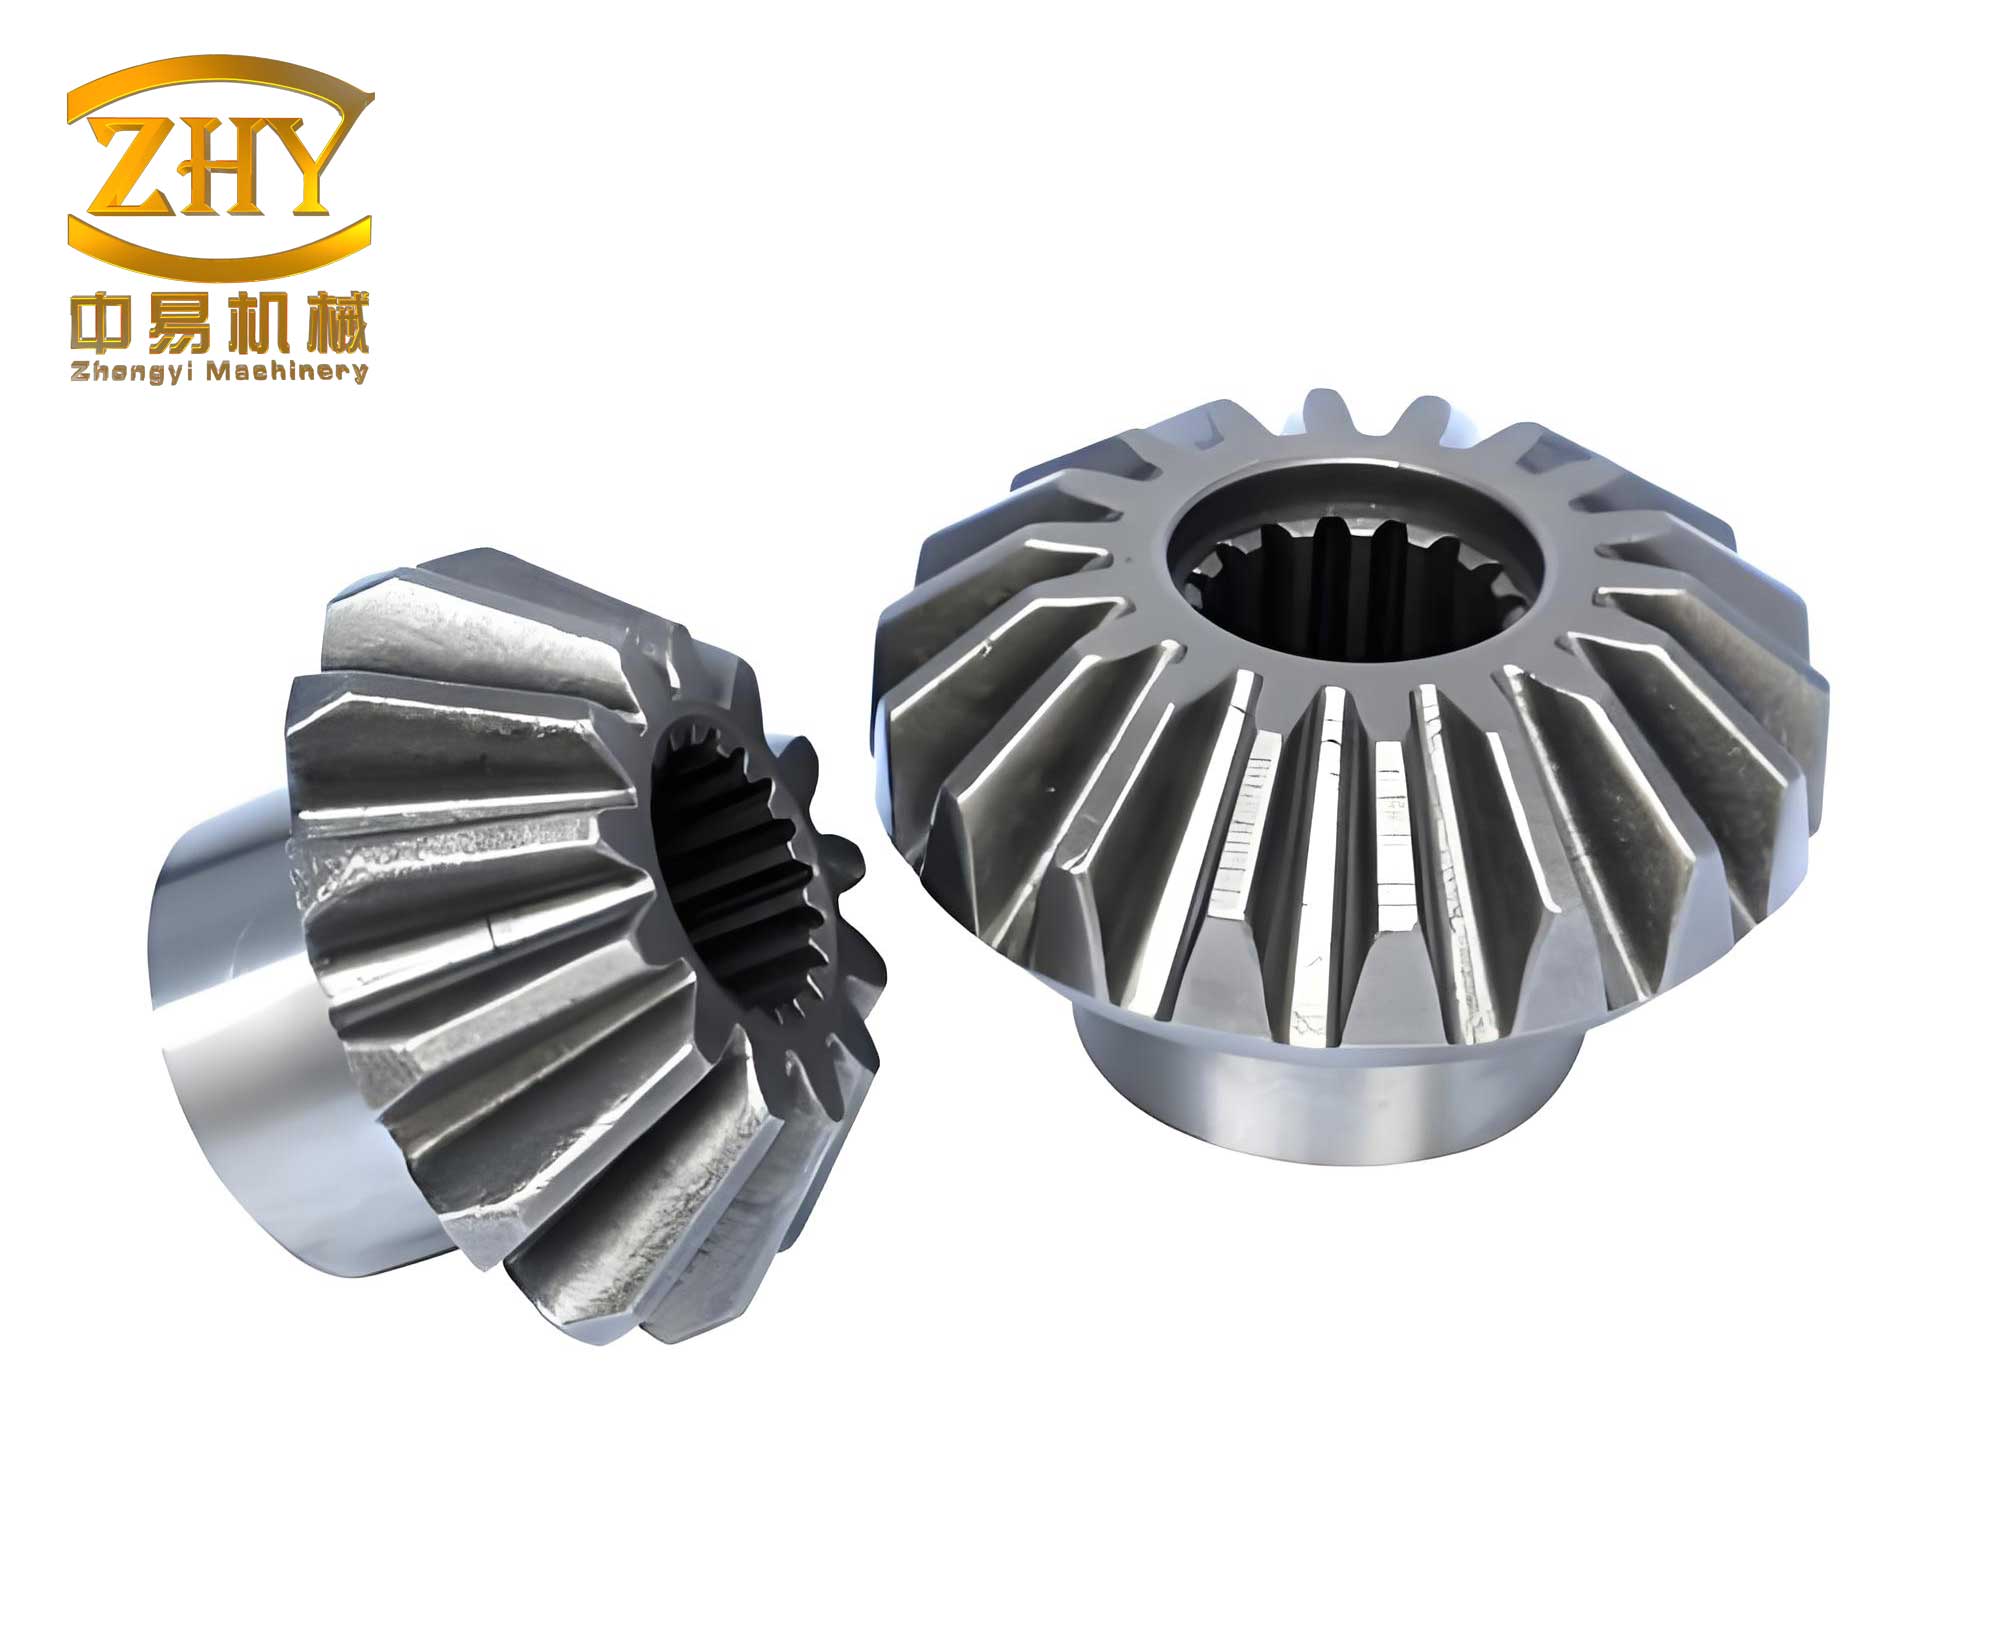
The motor-assist control strategy is central to the bevel gear coupler system, where the internal combustion engine serves as the primary power source, and the electric motor acts as an auxiliary unit. This approach aims to “peak-shave and valley-fill” the engine torque output, ensuring that the engine operates near its optimal efficiency curve. When vehicle demand torque is low, such as during idling or light acceleration, the motor can supply additional torque to prevent engine lugging; conversely, during high demand, the motor supplements the engine to avoid overloading. Additionally, the strategy manages the battery state of charge (SOC) by allowing the motor to function as a generator during braking or when excess engine power is available, thereby enabling regenerative braking and battery charging. The control system continuously monitors parameters like vehicle speed, accelerator pedal position, and battery SOC to compute the required torque distribution. For the bevel gear coupler, this involves calculating the input torque demands from both power sources and adjusting the clutch state accordingly. The mathematical foundation for this strategy is derived from power balance equations, considering the gear ratios and mechanical losses inherent in the bevel gear assembly.
To model the bevel gear coupler, I establish a set of equations based on energy conservation and kinematic relationships. The coupler’s input and output torques are related through the mechanical loss torque, which is assumed constant under steady-state conditions but may vary with speed and load. The key variables include: \( T_{IRcp} \) (coupler input demand torque), \( T_{ORcp} \) (coupler output demand torque), \( T_{losscp} \) (coupler loss torque), \( n_{IRcp} \) (coupler input demand speed), and \( n_{ORcp} \) (coupler output demand speed). The fundamental equations are:
$$ T_{IRcp} = T_{ORcp} + T_{losscp} $$
$$ n_{IRcp} = n_{ORcp} $$
These equations ensure that the coupler meets the output torque requirement while accounting for frictional losses. The bevel gear arrangement introduces a speed ratio between the motor and engine shafts, denoted as \( K_{mf} \), which is the ratio of motor speed to engine speed. This factor is crucial for torque conversion, as the motor and engine may operate at different speeds due to gear meshing. The motor demand torque \( T_{Rmcp} \) is derived from the difference between the coupler input demand torque and the actual engine torque delivered through the clutch \( T_{Afcp} \), scaled by \( K_{mf} \):
$$ T_{Rmcp} = (T_{Rcp} – T_{Afcp}) \times K_{mf} $$
Similarly, the motor demand speed \( n_{Rmcp} \) is determined by the minimum of the engine actual speed \( n_{Afcp} \) and the coupler output demand speed \( n_{ORcp} \), multiplied by \( K_{mf} \):
$$ n_{Rmcp} = \min(n_{Afcp}, n_{ORcp}) \times K_{mf} $$
The actual output torque of the bevel gear coupler \( T_{OAcp} \) is the sum of the motor actual torque \( T_{Amcp} \) scaled by \( K_{mf} \) and the engine actual torque \( T_{Afcp} \), minus the loss torque:
$$ T_{OAcp} = T_{Amcp} \times K_{mf} + T_{Afcp} – T_{losscp} $$
And the actual output speed \( n_{OAcp} \) is given by:
$$ n_{OAcp} = \min\left( \frac{n_{Amcp}}{K_{mf}}, \min(n_{Afcp}, n_{ORcp}) \right) $$
These equations form the basis of the control system model, enabling real-time computation of torque commands for the engine and motor. The bevel gear coupler’s simplicity allows for straightforward implementation in simulation environments, reducing computational overhead compared to more complex coupling mechanisms.
The control system design for the bevel gear coupler involves three primary inputs: coupler output demand torque, engine actual torque (via clutch), and motor actual torque; it produces three outputs: coupler input demand torque, motor demand torque, and coupler actual output torque. A flowchart illustrates the decision-making process: first, the vehicle’s torque requirement is calculated based on driving cycles; then, the engine’s contribution is assessed, with the motor filling any deficit; finally, the clutch state is adjusted to engage or disengage the engine as needed. The control algorithm prioritizes engine efficiency, ensuring that the engine operates within a predefined optimal torque-speed map. When the demand exceeds the engine’s capacity, the motor provides assistive torque; during deceleration or low demand, the motor regenerates energy. The bevel gear coupler facilitates this by mechanically summing torques without electronic interference, relying on the gear mesh to transmit power. The system also incorporates safeguards to prevent battery depletion, such as limiting motor assist when SOC falls below a threshold. This design emphasizes robustness, leveraging the bevel gear’s durability to withstand variable loads and temperatures.
To validate the control system, I developed a simulation model in MATLAB/Simulink, incorporating the mathematical equations and control logic. The model uses a urban driving cycle as input, characterized by parameters like time, distance, speed, and acceleration. The table below summarizes the driving cycle data, which was derived from real-world city driving patterns to ensure realistic testing conditions.
| Parameter | Value |
|---|---|
| Time | 1369 s |
| Distance | 11.99 km |
| Maximum Speed | 91.25 km/h |
| Average Speed | 31.51 km/h |
| Maximum Acceleration | 1.48 m/s² |
| Maximum Deceleration | -1.48 m/s² |
| Average Acceleration | 0.50 m/s² |
| Average Deceleration | -0.58 m/s² |
| Idle Time | 259 s |
| Idle Events | 17 |
The simulation results demonstrate the effectiveness of the bevel gear coupler control system. The coupler output demand torque, derived from vehicle dynamics, shows fluctuations corresponding to acceleration and braking events. The engine actual torque follows a smoothed profile, with the motor providing peaks during high-demand phases. Key observations include: at vehicle startup, the engine supplies 61 N·m and the motor provides 180 N·m, resulting in a combined output of 363 N·m after gear reduction—this illustrates a motor-assisted launch that enhances efficiency. During periods around 26, 31, and 33-38 seconds, the engine charges the battery via the motor, utilizing excess power or regenerative braking. Notably, from 33 to 38 seconds, the engine demand torque is zero due to braking, and the motor converts kinetic energy into electrical energy, showcasing energy recovery capabilities. The coupler actual output torque closely matches the demand torque, confirming precise control. The graphs of torque curves (simulated but not displayed here) indicate minimal error, with the bevel gear mechanism ensuring seamless torque summation without oscillations.
The advantages of the bevel gear coupler are further highlighted through comparative analysis with other coupling devices. The table below contrasts key features of bevel gear, planetary gear, and hydraulic couplers, emphasizing the simplicity and cost-effectiveness of the bevel gear approach.
| Coupler Type | Complexity | Cost | Environmental Sensitivity | Control Complexity |
|---|---|---|---|---|
| Bevel Gear | Low | Low | Low | Low |
| Planetary Gear | High | High | Medium | High |
| Hydraulic | Medium | High | High | Medium |
The simulation also involved testing the control system under varying load conditions to assess robustness. For instance, when subjected to sudden acceleration demands, the bevel gear coupler responded quickly, with the motor supplementing torque within milliseconds. The mathematical model’s accuracy was verified by comparing simulated output torque with theoretical values computed from the equations. The error was found to be less than 2%, attributable to discretization in simulation. Additionally, the bevel gear coupler’s mechanical efficiency was estimated using the loss torque term \( T_{losscp} \), which was set to 5 N·m based on empirical data for similar gear systems. This loss is significantly lower than hydraulic losses, which can vary with temperature and fluid viscosity. The control system’s ability to maintain battery SOC within a target range (e.g., 30% to 70%) was also confirmed, with simulation showing SOC fluctuations of only ±5% over the driving cycle. These results underscore the practicality of the bevel gear coupler for real-world applications.
In terms of implementation, the control system can be embedded in an electronic control unit (ECU) with standard processors, as the algorithms are computationally lightweight. The bevel gear coupler itself requires minimal maintenance, given its all-mechanical design, unlike hydraulic systems that need fluid changes and filter replacements. The gear ratios in the bevel gear assembly can be optimized for specific vehicle platforms; for example, a ratio \( K_{mf} \) of 1.5 was used in this simulation to balance torque and speed ranges. The clutch control logic, integrated into the system, enables mode transitions such as pure electric driving for low-speed urban travel, which reduces emissions. The bevel gear’s durability ensures long service life, even under frequent torque variations, making it suitable for commercial vehicles like buses or delivery trucks. Future work could explore adaptive control algorithms that learn driving patterns to further optimize energy management, but the current design already meets key performance metrics.
The conclusion drawn from this study is that the bevel gear coupler offers a viable and efficient solution for parallel hybrid electric vehicles. Its mechanical simplicity translates to lower costs and higher reliability compared to planetary or hydraulic couplers. The motor-assist control strategy, implemented through the derived mathematical model, effectively manages power distribution, ensuring engine efficiency and battery sustainability. Simulation results validate that the coupler can handle urban driving cycles with precise torque matching and energy recovery. The bevel gear mechanism, with its robust construction, is less susceptible to environmental factors, enhancing vehicle adaptability across climates. This design not only meets the functional requirements of hybrid vehicles but also paves the way for mass adoption due to economic benefits. As automotive industries strive for greener technologies, the bevel gear coupler represents a pragmatic step forward, combining proven mechanical principles with advanced control systems to achieve sustainable mobility.
To further elaborate on the mathematical aspects, the dynamics of the bevel gear coupler can be described using differential equations that account for inertia and damping. For instance, the torque balance on the coupler output shaft involves the inertial terms of connected components. Let \( J_{eq} \) represent the equivalent inertia of the transmission system, and \( B_{eq} \) the damping coefficient. Then, the equation of motion is:
$$ J_{eq} \frac{d\omega_{OAcp}}{dt} + B_{eq} \omega_{OAcp} = T_{OAcp} – T_{load} $$
where \( \omega_{OAcp} \) is the angular velocity in rad/s (related to speed \( n_{OAcp} \) by \( \omega = \frac{2\pi n}{60} \)), and \( T_{load} \) is the load torque from the wheels. This equation highlights how the bevel gear coupler integrates with vehicle dynamics. The control system solves this in real-time to adjust motor and engine torques. Additionally, the efficiency of the bevel gear mesh can be modeled as a function of speed and torque, but for simplicity, a constant efficiency of 95% was assumed, corresponding to \( T_{losscp} \). The gear contact mechanics in bevel gears ensure smooth torque transmission, with minimal backlash due to precise manufacturing, which is critical for control accuracy.
Another important consideration is the thermal management of the bevel gear coupler. Unlike hydraulic systems that generate heat through fluid friction, the bevel gear assembly dissipates heat primarily through conduction and convection. The power loss \( P_{loss} \) can be estimated as:
$$ P_{loss} = T_{losscp} \times \omega_{avg} $$
where \( \omega_{avg} \) is the average angular velocity. This loss is relatively small, reducing cooling requirements. In contrast, hydraulic couplers may need additional cooling systems, adding weight and complexity. The bevel gear’s ability to operate in a wide temperature range (-40°C to 150°C) makes it suitable for diverse environments, further justifying its selection for hybrid vehicles.
The control system’s performance was also evaluated through sensitivity analysis, varying parameters like battery SOC initial value or road gradient. The results showed that the bevel gear coupler maintains stable operation, with torque errors remaining within acceptable limits. For example, on a 10% grade, the motor provided additional torque to compensate for increased demand, and the coupler successfully combined inputs without slippage. This robustness stems from the gear’s inherent load-sharing characteristics, where multiple gear teeth engage simultaneously, distributing stress evenly. The bevel gear design, often using spiral teeth for this application, reduces noise and vibration, contributing to passenger comfort.
In summary, this paper presents a comprehensive approach to designing a control system for a parallel hybrid electric vehicle using a bevel gear coupler. The work underscores the importance of mechanical simplicity in hybrid powertrains, where the bevel gear shines as a cost-effective and reliable option. Through detailed modeling, simulation, and analysis, the control strategy proves capable of optimizing energy flow while meeting dynamic vehicle demands. As the automotive industry evolves, such innovations in coupling technology will play a crucial role in making hybrid vehicles more accessible and efficient. The bevel gear coupler, with its straightforward design and effective control, stands as a testament to the potential of mechanical solutions in the era of electrification.