
The RV reducer, a high-precision reduction gearbox, serves as the core transmission component in the joints of industrial robots. Its performance directly dictates the robot’s positioning accuracy, load capacity, and operational stability. RV transmission, evolved from cycloidal pinwheel drives, integrates a two-stage reduction mechanism: a first-stage involute planetary gear train and a second-stage cycloidal pinwheel planetary train. This architecture grants it exceptional advantages such as high reduction ratio, compact size, high torsional stiffness, substantial overload capacity, and smooth operation. Consequently, RV reducers have increasingly supplanted harmonic drives and standard cycloidal drives in demanding robotic applications. The development and mastery of design and manufacturing technologies for RV reducers are therefore of strategic importance for the advancement of the robotics industry.
This article details a comprehensive methodology for the digital design and dynamic simulation of an RV reducer. The process begins with parametric three-dimensional modeling based on defined geometric parameters, followed by virtual assembly and interference checking. To validate the design’s kinematic and dynamic performance, a virtual prototype is constructed and analyzed using multi-body dynamics software. This integrated approach from digital model to virtual testing enables rapid iteration and optimization, significantly enhancing the design efficiency and reliability of the RV reducer.
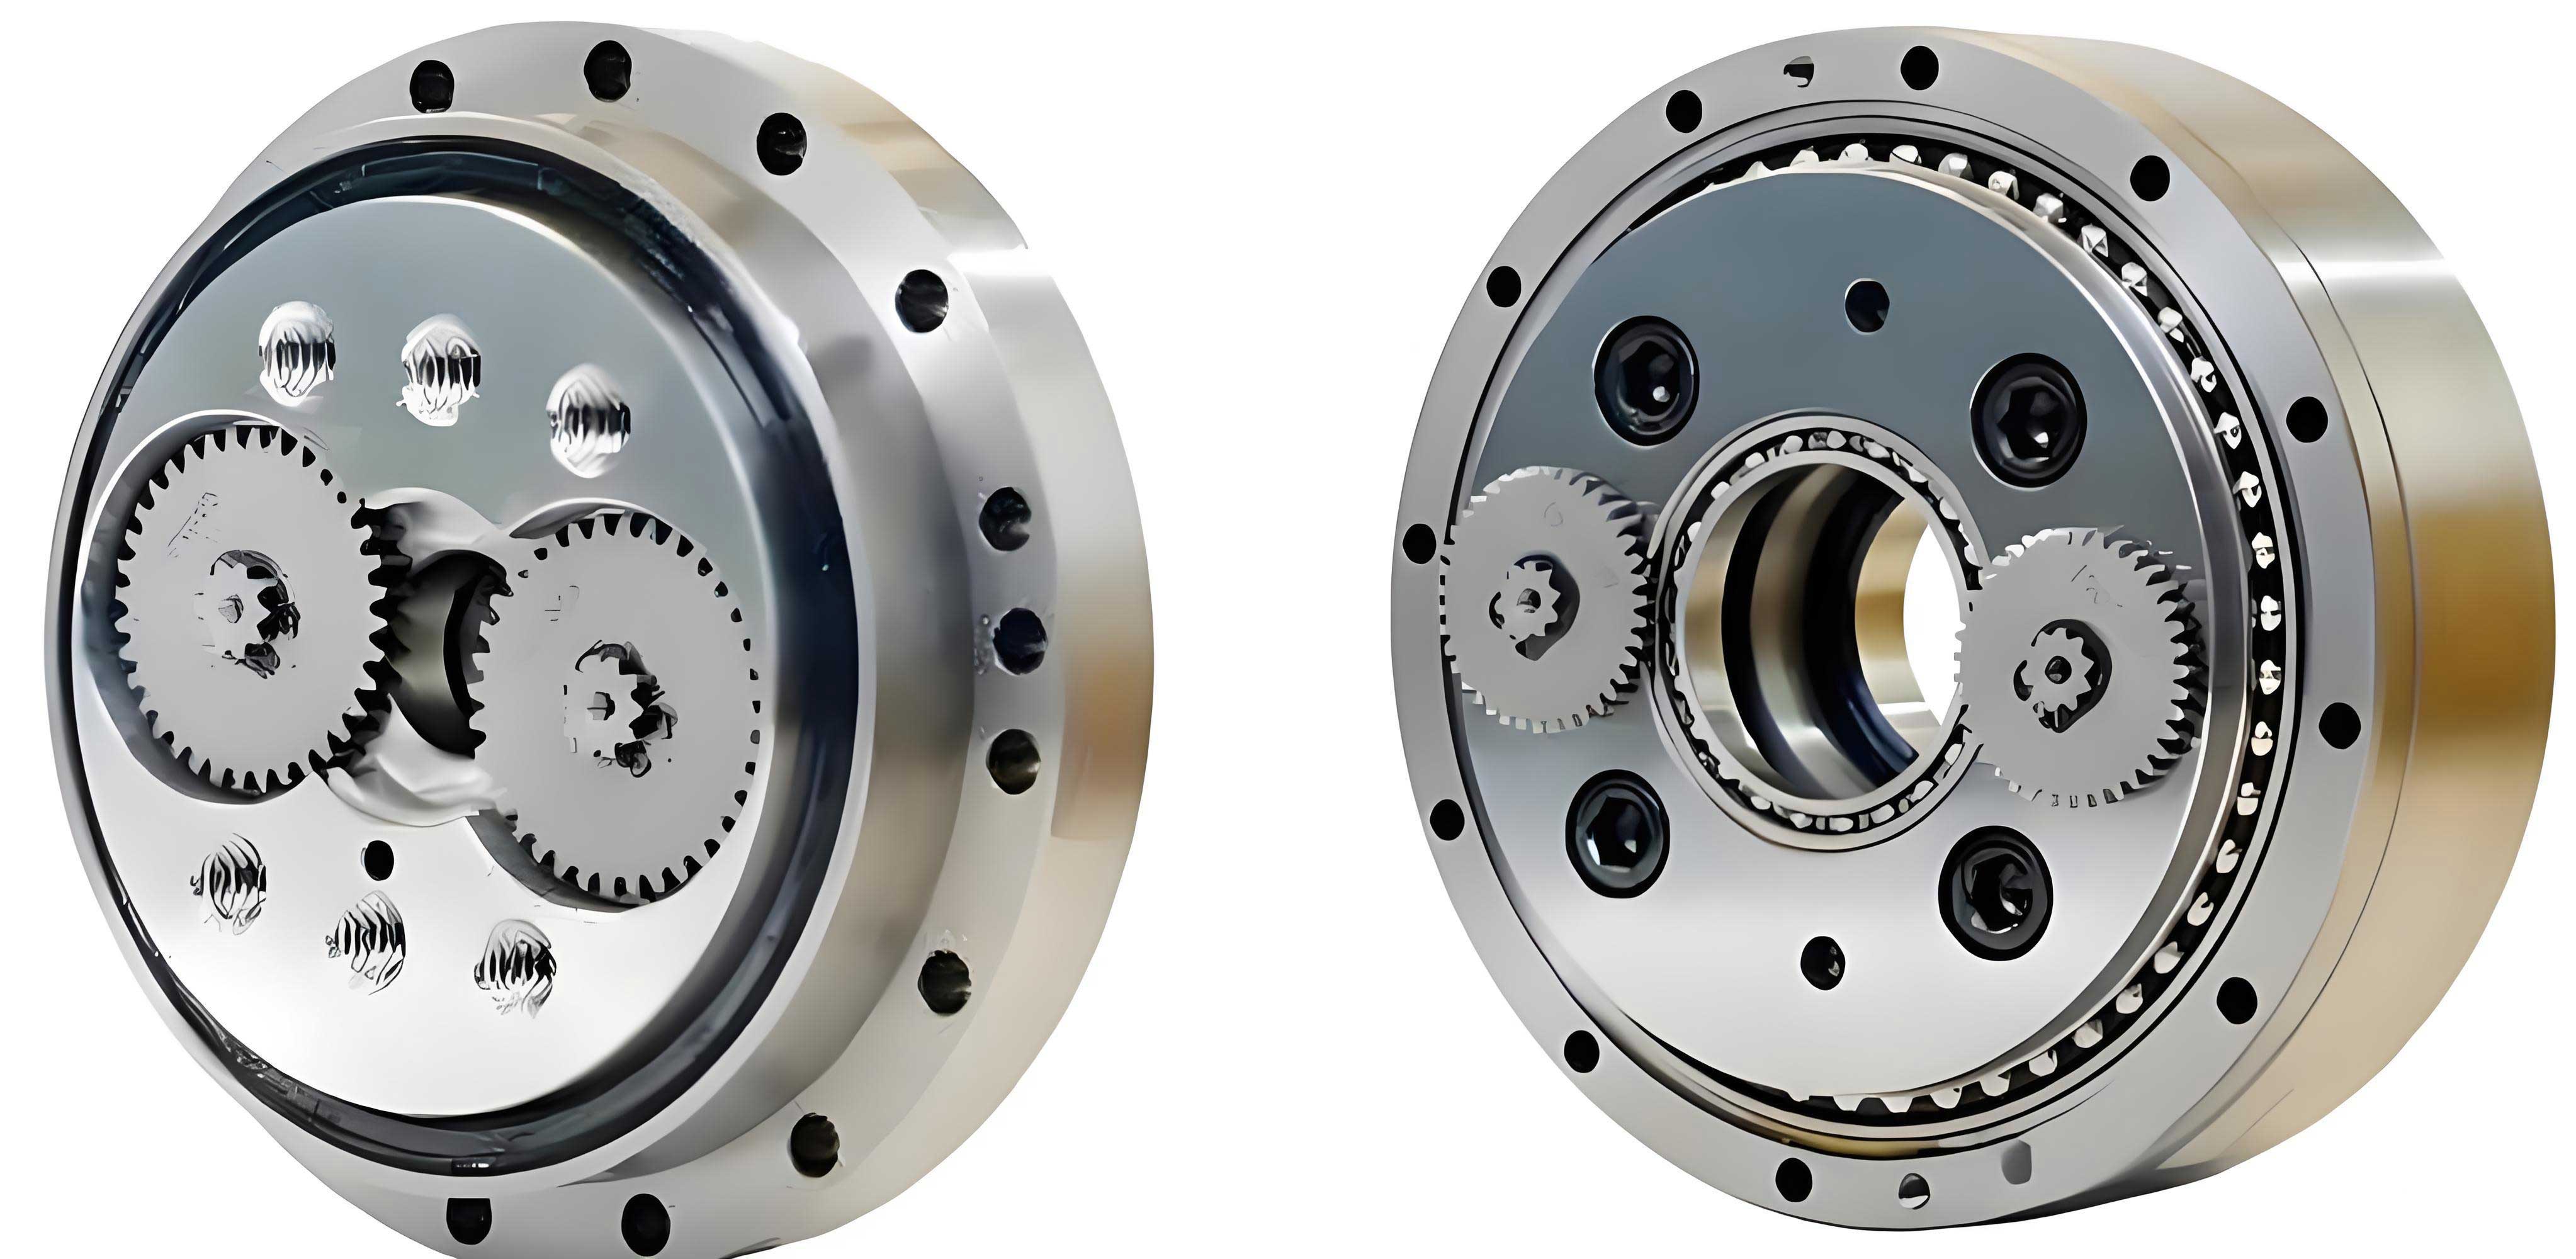
Fundamentals and Digital Design Philosophy
The design of an RV reducer hinges on a set of interlinked geometric parameters. These parameters determine the tooth profiles, overall dimensions, and ultimately the performance characteristics of the reducer. A digital design approach leverages parametric modeling, where these key dimensions are defined as variables. Altering a parameter automatically updates the entire associated geometry, allowing for rapid exploration of design variants and optimization. The core parameters for the RV reducer design include those for both the involute and cycloidal stages.
For the cycloidal stage, critical parameters are the pin center radius \(r_p\), pin radius \(r_{rp}\), eccentricity \(a\), number of cycloidal gear teeth \(z_c\), number of pin teeth \(z_p\), and the modification coefficients: the offset modification \(\Delta r_p\), the equidistant modification \(\Delta r_{rp}\), and the turning angle modification \(\delta\). For the first planetary stage, key parameters are the number of sun gear teeth \(Z_1\), number of planet gear teeth \(Z_2\), module \(m\), and pressure angle. The target reduction ratio, input speed, and output torque are the primary functional constraints.
The parametric modeling of the cycloidal gear, the most critical component, is based on its theoretical tooth profile equation. The standard profile for a cycloidal gear meshing with pins is derived from the trajectory of a point on the generating circle. The parametric equations are:
$$
\begin{aligned}
x_t &= \left( r_p – r_{rp} \Phi(K_1, \varphi) \right) \cos\left((1 – i^H) \varphi\right) – \left( a – K_1 r_{rp} \Phi(K_1, \varphi) \right) \cos\left(i^H \varphi\right) \\
y_t &= \left( r_p – r_{rp} \Phi(K_1, \varphi) \right) \sin\left((1 – i^H) \varphi\right) + \left( a – K_1 r_{rp} \Phi(K_1, \varphi) \right) \sin\left(i^H \varphi\right)
\end{aligned}
$$
where \(i^H = z_p / z_c\) is the transmission ratio between the cycloidal gear and the pin ring, \(\varphi\) is the generating angle (parameter), \(K_1\) is the shortening coefficient given by \(K_1 = (a z_p)/r_p\), and \(\Phi(K_1, \varphi) = (1 + K_1^2 – 2K_1 \cos \varphi)^{-1/2}\).
In practice, to ensure proper lubrication, minimize backlash, and improve load distribution, the standard profile must be modified. The most common method combines offset, equidistant, and sometimes turning angle modifications. The modified profile equations become:
$$
\begin{aligned}
x_t &= \left( r_p’ – r_{rp}’ \Phi(K_1′, \varphi) \right) \cos\left((1 – i^H) \varphi – \delta\right) – \frac{a}{r_{rp}’} \left[ r_{rp}’ – z_p r_{rp}’ \Phi(K_1′, \varphi) \right] \cos\left(i^H \varphi + \delta\right) \\
y_t &= \left( r_p’ – r_{rp}’ \Phi(K_1′, \varphi) \right) \sin\left((1 – i^H) \varphi – \delta\right) + \frac{a}{r_{rp}’} \left[ r_{rp}’ – z_p r_{rp}’ \Phi(K_1′, \varphi) \right] \sin\left(i^H \varphi + \delta\right)
\end{aligned}
$$
where \(r_p’ = r_p + \Delta r_p\), \(r_{rp}’ = r_{rp} + \Delta r_{rp}\), and \(K_1′ = (a z_p)/r_p’\). The final tooth profile is defined by seven independent parameters: \(r_p, r_{rp}, a, z_p, \Delta r_p, \Delta r_{rp}, \delta\).
Parametric 3D Modeling and Virtual Assembly
Using a advanced CAD platform, the parametric modeling process begins by defining the expressions corresponding to the equations above. The software’s expression editor is used to create variables for all key parameters and the complex mathematical relationships of the cycloidal profile. Once defined, the curve law function generates the precise tooth profile curve based on these expressions. This curve is then used as the basis for extruding the 3D model of the cycloidal gear. The major geometric parameters used for modeling a sample RV reducer are summarized in the table below.
| Primary Parameter | Value | Primary Parameter | Value |
|---|---|---|---|
| Number of Cycloid Gear Teeth, \(z_c\) | 31 | Shortening Coefficient, \(K_1\) | 0.8 |
| Number of Pin Teeth, \(z_p\) | 32 | Equidistant Modification, \(\Delta r_{rp}\) (mm) | -0.0533 |
| Sun Gear Teeth, \(Z_1\) | 26 | Offset Modification, \(\Delta r_p\) (mm) | 0.0832 |
| Planet Gear Teeth, \(Z_2\) | 65 | Cycloid Gear Width, \(b_c\) (mm) | 19 |
| Pin Pitch Radius, \(r_p\) (mm) | 161 | Planetary Gear Module, \(m\) (mm) | 2 |
| Pin Radius, \(r_{rp}\) (mm) | 11 | Planetary Gear Width, \(b\) (mm) | 20 |
| Eccentricity, \(a\) (mm) | 4 |
Following the same parametric principles, models for all other components are created: the sun gear, planet gears, crankshafts (eccentric shafts), pin housing, needle pins, and the output flange (output disk). Special attention is paid to the crankshaft, which incorporates two eccentric sections phased at 180 degrees to balance inertial forces.
The virtual assembly process is strategic. Sub-assemblies are created first, such as bearings on crankshafts, needle pins in the pin housing, and planet gears on their bearings. A critical step is assembling the two cycloidal gears onto their respective crankshaft journals with a 180-degree phase difference. This phasing is essential for force balance, reduced vibration, and optimal load sharing among the pins. The final total assembly brings together the input sun gear, the planet gear carrier (integrated with the crankshafts), the cycloidal gear assembly, the pin housing, and the output flange. Upon completion, a comprehensive interference check is performed digitally to identify and resolve any geometric conflicts between parts before any physical prototype is built. This virtual assembly validates the manufacturability and serviceability of the RV reducer design.
Virtual Prototype Development for Dynamics Analysis
The 3D CAD model, while geometrically accurate, lacks the physical properties necessary for performance simulation. To create a virtual prototype for dynamic analysis, the model is transferred to a Multi-Body Dynamics (MBD) software. The process involves defining material properties, applying appropriate joints and constraints, and setting up force interactions and driving conditions.
First, realistic material properties are assigned to each component to define their mass, center of gravity, and moment of inertia. This is crucial as the default imported geometry often has incorrect mass properties. Common materials for RV reducer components are assigned, such as bearing steel (GCr15) for cycloidal gears, crankshafts, and pins, alloy steel (40Cr) for gears, and cast iron (HT200) for the housing.
Next, kinematic joints and constraints are applied to replicate the actual mechanical connections within the RV reducer:
- Fixed Joints: The pin housing (stationary ring) is fixed to the ground. The needle pins are fixed to the pin housing. The output flange is fixed to the planet carrier/crankshaft assembly in this specific configuration.
- Revolute Joints: The input shaft (sun gear) is connected to ground via a revolute joint. Each planet gear is connected to the planet carrier (crankshaft) with a revolute joint. Each cycloidal gear is connected to its crankshaft journal with a revolute joint. The output flange is connected to ground via a revolute joint to measure output motion.
- Contact Forces: This is the most critical step for dynamic analysis. Force-based contacts are defined at all meshing interfaces:
- Between the sun gear and each of the three planet gears (involute gear contact).
- Between each cycloidal gear and all the needle pins in the housing (cycloidal-pin contact).
The contact force is typically modeled using a nonlinear spring-damper model based on impact theory, with parameters like contact stiffness and damping defined according to material properties.
Finally, the driving and loading conditions are applied. A rotational motion is applied to the input sun gear shaft. To simulate a realistic startup and avoid numerical instability, a step function is used to ramp up the speed smoothly. For example: \( \text{Motion} = STEP(time, 0, 0~\text{deg/s}, 0.2, 2430~\text{deg/s}) \). This brings the input to 2430 deg/s (405 RPM) over 0.2 seconds. A constant load torque, opposing the input rotation, is applied to the output flange. Similarly, a step function can be used to gradually apply the full load: \( \text{Torque} = STEP(time, 0, 0~\text{N·mm}, 0.2, 8,213,000~\text{N·mm}) \), applying 8213 N·m.
Kinematic and Dynamic Analysis Results
With the virtual prototype fully defined, a dynamic simulation is performed over a time period of several seconds. The software solves the equations of motion, and the results provide deep insight into the RV reducer’s behavior.
Kinematic Verification: Speeds and Transmission Ratio
The angular velocity of key shafts—input, crankshaft (planet carrier), and output—are measured. The simulation results show that after the initial transient startup phase (0-0.2s), the speeds stabilize to constant values. The input shaft rotates positively at the commanded 2430 deg/s. The crankshafts (planet carrier) rotate in the negative direction, and the output flange rotates positively but at a greatly reduced speed, consistent with the theoretical motion reversal in the planetary stage. The steady-state average values from the simulation are compared with theoretical calculations below.
| Component | Theoretical Speed (deg/s) | Simulated Speed (deg/s) | Relative Error (%) |
|---|---|---|---|
| Input Shaft | 2430.00 | 2430.00 | 0.000 |
| Crankshaft (Planet Carrier) | ~930.00* | 929.76 | 0.025 |
| Output Flange | 30.00 | 29.97 | 0.100 |
| Total Reduction Ratio | 81.00 | 81.08 | 0.098 |
*Theoretical crankshaft speed is calculated from the first-stage planetary train: \( \omega_{\text{carrier}} = \omega_{\text{input}} / (1 + Z_2/Z_1) = 2430 / (1 + 65/26) \approx 930 ~\text{deg/s} \).
The excellent agreement between simulation and theory, with errors less than 0.1%, validates the kinematic correctness of the virtual prototype for the RV reducer. The simulated total ratio of 81.08 matches the design target almost perfectly.
Dynamic Analysis: Gear Meshing Forces
The dynamic simulation provides time-history data for the contact forces at the gear meshes, which are critical for stress analysis and fatigue life prediction.
Involute Gear Mesh (Sun-Planet): The contact force between the sun gear and one planet gear shows periodic variation corresponding to the gear mesh frequency. After the startup transient, the force settles into a steady sinusoidal pattern. The force components in the radial (X) and tangential (Y) directions oscillate with amplitudes of approximately 1.65 kN and 1.68 kN, respectively, resulting in a resultant force amplitude near 3.79 kN. This periodic fluctuation is characteristic of gear meshing dynamics.
Cycloidal-Pin Mesh: The forces at the interface between the cycloidal gear and the needle pins are significantly larger, as this stage handles the higher torque. The simulated forces also show a clear periodic pattern. The radial and tangential force components reach amplitudes in the range of 50-52 kN. These force values align well with theoretical estimates based on the output torque and the geometry of the RV reducer. The multi-tooth contact nature of the cycloidal drive is evidenced by the distribution of force among several pins simultaneously, though the individual pin forces vary sinusoidally as the gear rotates.
Analyzing these force profiles allows engineers to identify peak loads, assess load sharing among planets and pins, and evaluate the need for design refinements such as micro-geometry optimizations (profile modifications) to smooth out force transitions and reduce stress concentrations within the RV reducer.
Conclusion and Advantages of the Integrated Digital Approach
The digital design and virtual prototyping of an industrial robot RV reducer, as demonstrated, provides a powerful and efficient framework for modern precision gearbox development. The parametric modeling approach, centered on the mathematically precise definition of the cycloidal tooth profile, ensures design flexibility and accuracy. The subsequent virtual assembly validates the geometric integrity and assemblability of the complex RV reducer mechanism.
The construction and analysis of a dynamic virtual prototype represent a significant leap from static design. By simulating the real operating conditions—complete with correct inertial properties, joint constraints, contact forces, and loads—the virtual RV reducer can be thoroughly tested before any metal is cut. The kinematic results (speeds, ratio) confirm the fundamental correctness of the assembly and gear train logic. More importantly, the dynamic results (meshing forces) provide invaluable quantitative data that is difficult to obtain analytically, especially for the complex multi-contact cycloidal stage. This data directly informs decisions related to bearing selection, gear tooth strength, housing design, and predicted system life.
This integrated digital approach offers profound advantages: it dramatically shortens the design cycle by enabling rapid iterations and “what-if” studies; it reduces development cost by minimizing the number of physical prototypes and test rigs required; and it enhances final product quality by identifying and resolving potential performance issues in the virtual domain. For a critical and complex component like the RV reducer, which is fundamental to robotic performance, adopting such a simulation-driven design process is not just beneficial but essential for achieving the high levels of precision, reliability, and competitiveness demanded by the industry today.