
In the realm of large-scale marine propulsion systems, helical gears play a pivotal role due to their high power density, compact structure, and smooth operation. Specifically, double-input single-output (DI-SO) helical gear configurations are integral components in many ship propulsion units, where they efficiently transmit torque from two prime movers to a single output shaft. However, the inherent nonlinearities arising from unsymmetrical load distributions can lead to complex dynamic instabilities, such as gear tooth impacts, vibrations, and noise, which threaten system reliability. In this study, I aim to explore the vibrational characteristics of such a DI-SO helical gear system under varying unsymmetrical load conditions, leveraging advanced nonlinear dynamics tools to elucidate the underlying mechanisms.
The importance of helical gears in mechanical transmissions cannot be overstated; their helical tooth design ensures gradual engagement and disengagement, reducing shock loads and enhancing load-carrying capacity. Yet, this advantage is offset by complexities in modeling due to time-varying parameters like meshing stiffness and damping. For DI-SO systems, the asymmetry in load inputs introduces additional challenges, as the lower-load gear pair may transition from passive to active power transmission, leading to state switching between forward and backward meshing. This work delves into these phenomena by developing a comprehensive dynamic model that accounts for key nonlinear factors, including time-varying meshing stiffness, phase differences in stiffness excitation, nonlinear backlash, meshing damping, and composite transmission errors.
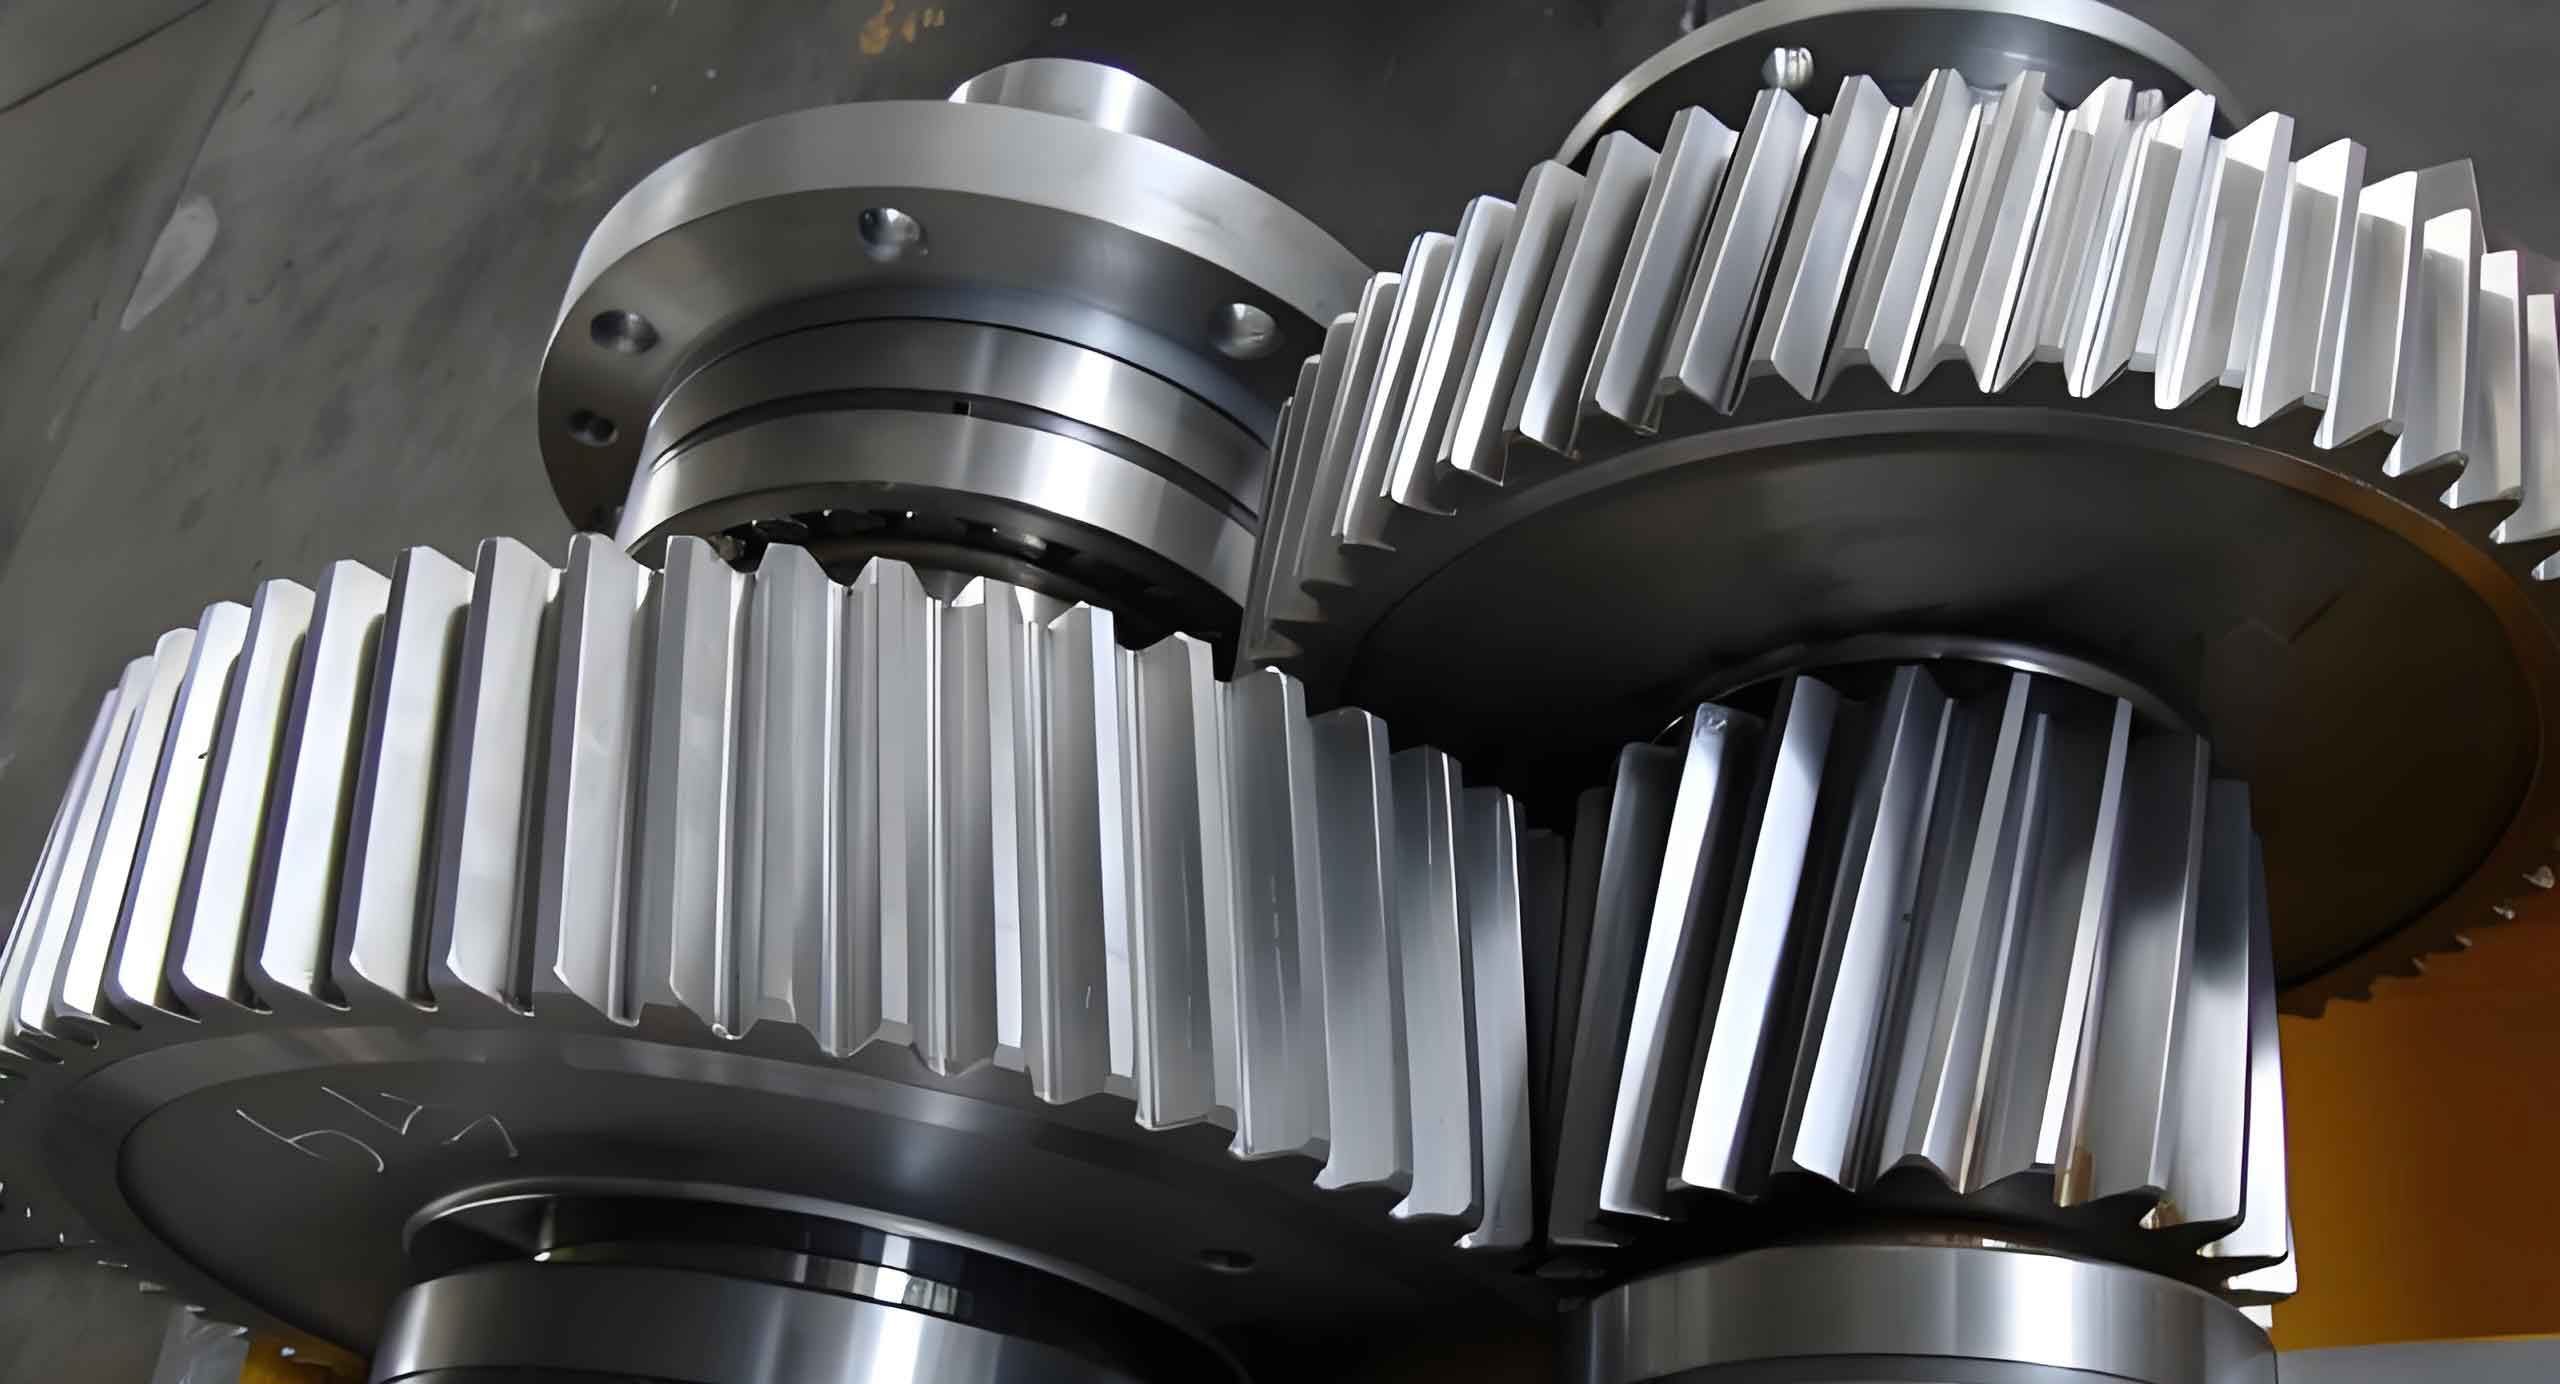
To begin, I establish a pure torsional dynamic model for the DI-SO helical gear system, disregarding shaft and bearing effects for simplicity. The system comprises two input helical gears (denoted as p and q) and one output helical gear (g), coupled to an inertia flywheel. The governing equations are derived using Newton’s second law, considering the dynamic angular displacements and moments. After introducing generalized coordinates and non-dimensionalization, the equations are expressed as:
$$ \begin{cases} \ddot{u} + 2\xi_{11}\dot{u} + 2\xi_{12}\dot{v} + \kappa_{11}(\tau)g(u) + \kappa_{12}(\tau)g(v) = f_1 + \bar{e}”_1(\tau) \\ \ddot{v} + 2\xi_{21}\dot{u} + 2\xi_{22}\dot{v} + \kappa_{21}(\tau)g(u) + \kappa_{22}(\tau)g(v) = f_2 + \bar{e}”_2(\tau) \end{cases} $$
Here, \( u \) and \( v \) represent the non-dimensional vibration displacements for the two gear pairs, \( \xi_{ij} \) are damping coefficients, \( \kappa_{ij}(\tau) \) denote time-varying stiffness terms, \( g(\cdot) \) is the nonlinear backlash function, and \( f_1, f_2 \) are load-related terms. This formulation captures the coupling between the two helical gear pairs, essential for analyzing unsymmetrical effects.
Next, I detail the mathematical descriptions of system parameters, starting with time-varying meshing stiffness. For helical gears, the stiffness varies both temporally and spatially along the contact line. Using the slice method, each helical gear tooth is divided into thin slices treated as spur gears, and their stiffness components—bending, shear, axial compression, foundation, and Hertzian contact—are integrated. The stiffness for a single tooth pair is computed as:
$$ k_{\text{single}} = \left( \frac{1}{k_h} + \sum_{i=1}^{2} \left( \frac{1}{k_{b,i}} + \frac{1}{k_{s,i}} + \frac{1}{k_{a,i}} + \frac{1}{k_{f,i}} \right) \right)^{-1} $$
where the individual stiffnesses are derived from integrals involving gear geometry. The comprehensive meshing stiffness, accounting for multi-tooth contact, is approximated by a third-order harmonic series:
$$ k(t) = k_m + \sum_{j=1}^{3} \left[ k_{j1} \cos(j\omega_e t) + k_{j2} \sin(j\omega_e t) \right] $$
This representation facilitates numerical analysis. A key aspect in DI-SO helical gear systems is the phase difference in meshing stiffness between the two gear pairs, arising from their spatial layout. If the angle between gear centers involves a non-integer number of teeth, a phase shift \( \Delta\phi \) occurs, expressed as:
$$ \Delta\phi = \omega_e \cdot \frac{2\pi\delta}{z_1 \omega_1} $$
where \( \delta \) is the fractional part of the tooth count. This phase difference modulates the stiffness excitation, influencing system dynamics.
Another critical parameter is the nonlinear backlash function. For helical gears with high contact ratios, a piecewise linear model is inadequate. Thus, I employ a polynomial fit to approximate the backlash function \( g(x) \). A seventh-order polynomial provides a balance between accuracy and computational efficiency:
$$ g(x) = 0.0017x^7 – 0.0366x^5 + 0.2833x^3 – 0.1555x $$
This smooth representation mimics the progressive engagement of helical gears, reducing numerical discontinuities.
For numerical analysis, I utilize a variable-step fourth-fifth order Runge-Kutta method to solve the dynamic equations, discarding initial transients. Parameters are based on typical helical gear specifications, as summarized in Table 1.
| Parameter | Value (Driver/Driven) |
|---|---|
| Number of Teeth | 50 / 100 |
| Module (mm) | 4 |
| Pressure Angle (°) | 20 |
| Helix Angle (°) | 10 |
| Face Width (mm) | 50 |
| Poisson’s Ratio | 0.3 |
| Elastic Modulus (Pa) | 2.06 × 10¹¹ |
| Axial Contact Ratio | 0.69 |
| Transverse Contact Ratio | 1.76 |
| Total Contact Ratio | 2.45 |
The damping ratio is set to 0.03, and the non-dimensional excitation frequency \( \bar{\omega} = 0.5 \). The unsymmetrical load is characterized by the load ratio \( \lambda = |f_2 / f_1| \), where \( f_1 \) and \( f_2 \) correspond to the input loads.
I first examine light-load conditions with \( f_1 = 0.1 \). Bifurcation diagrams for \( u \) and \( v \) versus \( \lambda \) reveal rich dynamics. For the high-load gear pair (p-g), the system transitions from quasi-periodic motion (\( \lambda = 0 \text{ to } 0.57 \)) to stable single-period motion (\( \lambda = 0.57 \text{ to } 1 \)). In contrast, the low-load pair (q-g) exhibits chaotic motion at low \( \lambda \), eventually stabilizing to single-period motion as \( \lambda \) increases. Time-domain plots, FFT spectra, phase portraits, and Poincaré sections corroborate these states. For instance, at \( \lambda = 0.1 \), \( u \) oscillates between 0.7 and 1.3, indicating periodic meshing and detachment, while \( v \) shows chaotic oscillations between -1.5 and 1.5, implying alternating forward and backward meshing impacts. At \( \lambda = 0.8 \), both pairs display stable periodic behavior, with dominant frequencies at 0.5 (fundamental) and 1.0 (second harmonic).
Under heavy-load conditions with \( f_1 = 0.5 \), the bifurcation diagrams show narrower instability regions. The p-g pair undergoes quasi-periodic motion (\( \lambda = 0 \text{ to } 0.13 \)) followed by stable three-period motion (\( \lambda = 0.13 \text{ to } 1 \)), while the q-g pair shifts from chaos to three-period motion. Time-frequency analyses confirm these patterns. At \( \lambda = 0.1 \), \( u \) remains in forward meshing (1.4 to 1.6), with spectra showing peaks at 0.5, 1.0, and 1.5, and Poincaré maps indicating near-three-periodicity. For \( v \), chaotic motion persists with broad spectral content. At \( \lambda = 0.8 \), both pairs exhibit three-period motion; \( u \) stays in forward meshing, while \( v \) remains in backward meshing (-1.6 to -1.3), highlighting the influence of load asymmetry on meshing states.
To generalize, I investigate the cross-influence of load value \( f_1 \) and load ratio \( \lambda \) on vibration amplitudes. Table 2 summarizes the trends in maximum \( u \) (Max(u)) and minimum \( v \) (Min(v)) across different \( f_1 \) and \( \lambda \) values.
| Load Condition | Effect on High-Load Pair (p-g) | Effect on Low-Load Pair (q-g) | Stability Implications |
|---|---|---|---|
| Increasing \( \lambda \) | Minor changes in Max(u) | Sharp transition at critical \( \lambda \); Min(v) shifts from chaos to periodicity | Enhances stability, especially for low-load helical gears |
| Increasing \( f_1 \) | Max(u) increases | Critical \( \lambda \) for stability decreases; |Min(v)| grows in chaos | Widens stable periodic regions but amplifies vibration in instability |
| Combined effect | Higher loads yield larger but stable amplitudes | Heavy loads reduce instability range but intensify chaotic oscillations | Optimal design balances load ratio and magnitude |
Mathematically, these behaviors can be linked to system nonlinearities. The equations of motion include stiffness terms that vary with time, such as \( \kappa_{11}(\tau) = \frac{k_1(\tau) \cos\beta_b}{\omega_{n1}^2 m_{e1}} \), where \( k_1(\tau) \) is the time-varying stiffness of the first helical gear pair. The phase difference \( \Delta\phi \) further modulates \( k_2(\tau) \) for the second pair. The backlash function \( g(x) \) introduces nonlinear restoring forces, leading to bifurcations. For example, the transition to chaos often occurs when the system traverses homoclinic or heteroclinic orbits, as seen in Poincaré maps with scattered points.
The numerical results underscore that increasing the load ratio \( \lambda \) suppresses instability by aligning the dynamics of both helical gear pairs, reducing state-switching phenomena. Similarly, higher load values \( f_1 \) shrink the chaos regions, making the system less sensitive to load asymmetry. However, in unstable regimes, larger loads exacerbate vibration amplitudes, posing design trade-offs. These insights are crucial for marine propulsion systems, where helical gears must operate reliably under varying torque demands.
In conclusion, this study comprehensively analyzes the dynamic evolution of a DI-SO helical gear system under unsymmetrical loads. By integrating detailed parameter models—time-varying meshing stiffness, phase differences, and nonlinear backlash—I have captured complex behaviors like quasi-periodicity, chaos, and multi-periodic motions. The findings emphasize that both load ratio and load magnitude are key levers for enhancing stability: higher values contract instability intervals and promote periodic responses. Future work could extend this model to include flexural and axial vibrations, or experimental validation on test rigs. For engineers designing helical gear-based propulsion systems, this research offers a theoretical foundation for optimizing load distributions to mitigate nonlinear instabilities, ensuring smoother and safer operation of marine vessels.
Throughout this analysis, the centrality of helical gears in transmission systems is evident; their geometry and engagement characteristics fundamentally shape the dynamic response. By repeatedly examining helical gears in various contexts—from stiffness calculations to chaos analysis—I highlight their pivotal role in advanced mechanical systems. The methodologies employed here, including harmonic balance approximations and numerical integration, are broadly applicable to other gear types, but the unique features of helical gears necessitate specialized treatment, as demonstrated in this work.