
In this work I investigate the dynamic excitation behavior of automotive differential straight bevel gears. The focus is on the numerical simulation of both internal and external excitation sources because straight bevel gears operate under strongly time-varying contact conditions, manufacturing deviations, engine torque fluctuations, and road-induced disturbances. My objective is to build a consistent modeling route that links finite element contact analysis, mesh impact simulation, time-varying mesh stiffness, transmission error, engine torque excitation, and ground excitation. The final aim is to obtain a set of excitation curves that can be used for subsequent dynamic response analysis of straight bevel gears in vehicle drivelines.
Straight bevel gears are widely used in differential units because they can transmit motion between intersecting shafts with a constant velocity ratio under ideal conditions. However, in real automotive applications, straight bevel gears are never perfectly manufactured, perfectly aligned, or perfectly lubricated. The contact pattern moves along the tooth surface, the number of engaged tooth pairs changes, tooth deflection varies with load, and the relative velocity at engagement produces impact. These effects are internal to the gear pair. At the same time, the engine applies a periodic torque to the driveline, and the road introduces random vibration through the tires and suspension. These effects are external to the gear pair. Together, they define the excitation environment of straight bevel gears.
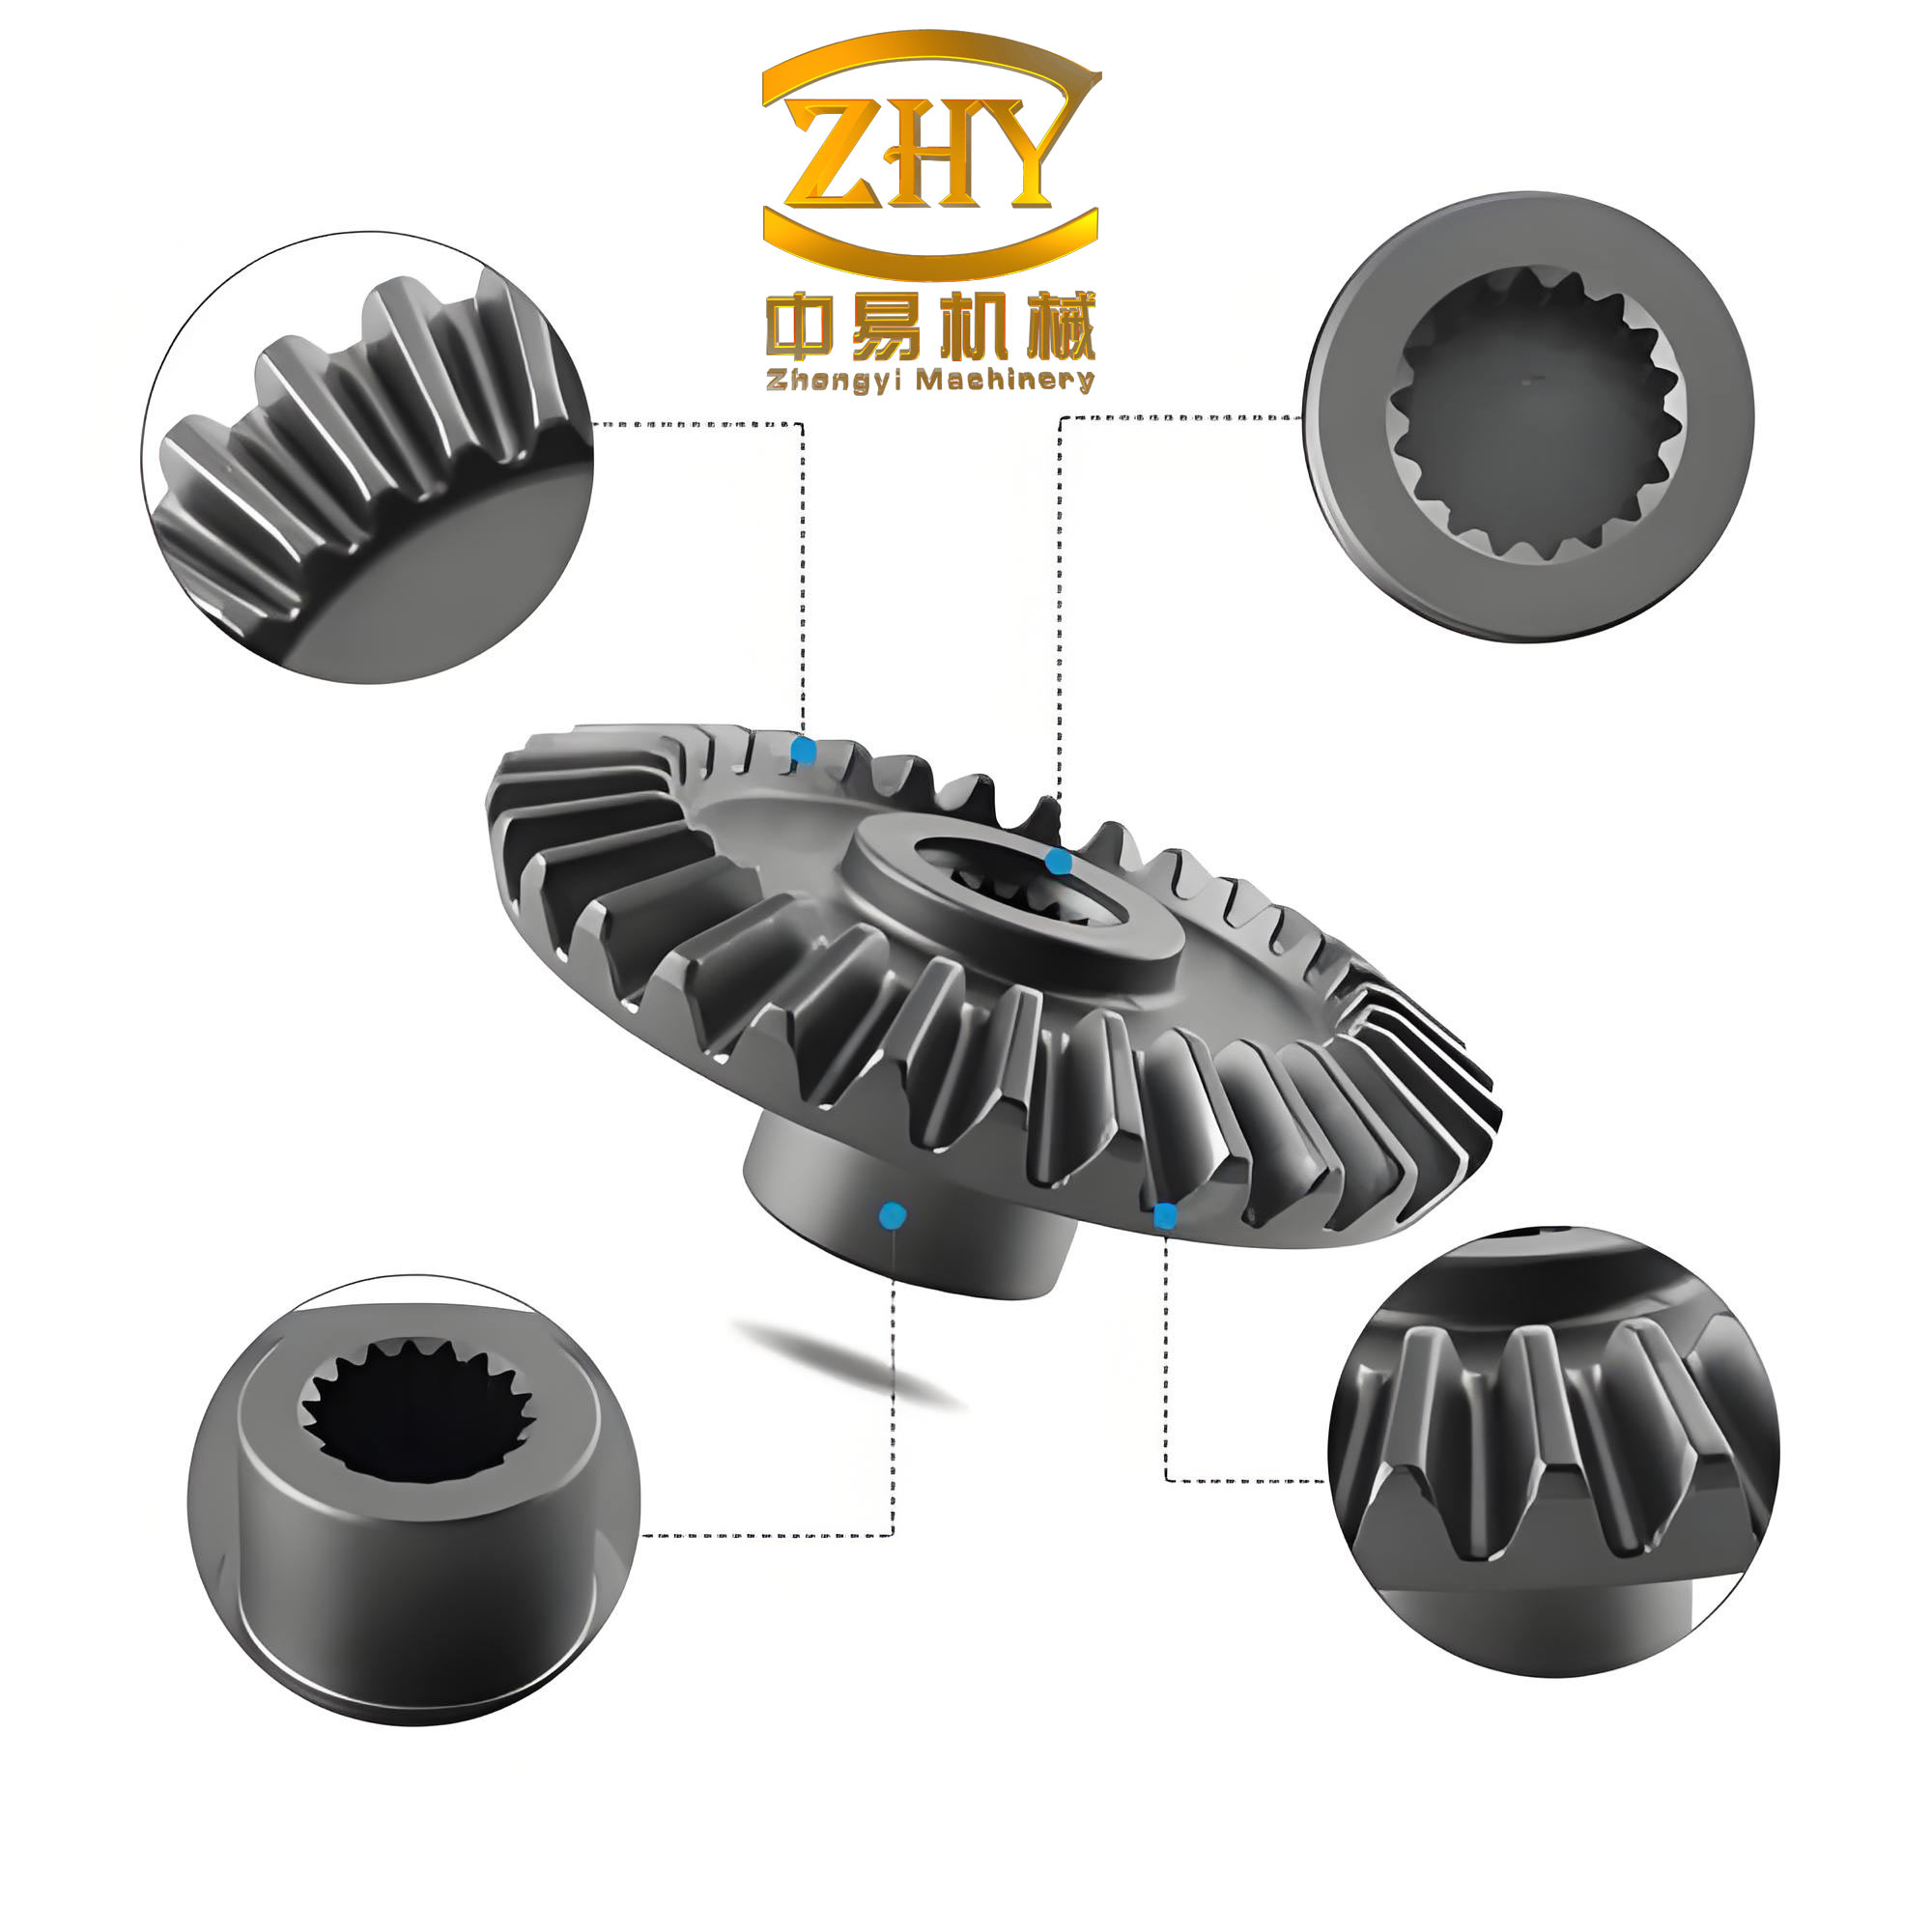
My modeling approach treats the straight bevel gear system as a coupled mechanical system with two main excitation families. The first family contains internal dynamic excitations: mesh impact, time-varying mesh stiffness, and transmission error. The second family contains external dynamic excitations: engine torque fluctuation and ground vibration. I use finite element contact analysis to obtain the contact force history, the engagement position, the relative rotational speed, and the mesh stiffness. I then use a harmonic representation for the error excitation and a multi-cylinder torque representation for the engine excitation. The result is a numerical excitation model that is closer to actual operating conditions than a purely theoretical constant-load model.
Finite Element Model of the Straight Bevel Gear System
I selected a pair of automotive differential straight bevel gears as the study object. The geometric parameters are summarized in Table 1. The material is treated as homogeneous, isotropic, and linearly elastic. The elastic modulus is \(E = 2.01 \times 10^{11}\,\mathrm{Pa}\), the density is \(\rho = 7.8 \times 10^{3}\,\mathrm{kg/m^{3}}\), and the Poisson ratio is \(\mu = 0.30\). I used a three-dimensional solid model and discretized it with SOLID45 elements. The boundary conditions for the static contact analysis are an input rotational speed of \(1000\,\mathrm{r/min}\) and an input torque of \(2443.6\,\mathrm{N \cdot m}\). The driving gear and the driven gear are constrained against all motions except rotation about their own axes.
| Parameter | Driving straight bevel gear | Driven straight bevel gear |
|---|---|---|
| Outer diameter / mm | 81.502 | 144.773 |
| Number of teeth \(z\) | 14 | 28 |
| Face width \(b\) / mm | 19.05 | 19.05 |
| Pressure angle \(\alpha\) / deg | 20 | 20 |
| Elastic modulus \(E\) / Pa | \(2.01 \times 10^{11}\) | \(2.01 \times 10^{11}\) |
| Density \(\rho\) / kg m\(^{-3}\) | \(7.8 \times 10^{3}\) | \(7.8 \times 10^{3}\) |
| Poisson ratio \(\mu\) | 0.30 | 0.30 |
I use the finite element model for three purposes. First, I determine the static contact force distribution along the tooth flank. Second, I identify the instant at which a new tooth pair enters mesh. Third, I calculate the relative rotational speed between the driving and driven straight bevel gears. These quantities are necessary because the mesh impact excitation depends on the impact velocity and the contact force at engagement. The engagement point is defined as the first nonzero contact force in the contact force history of a single tooth pair. In the present simulation, the first nonzero point occurs at \(t_0 = 4.60\,\mathrm{ms}\).
Internal Dynamic Excitation of Straight Bevel Gears
Internal excitation in straight bevel gears arises from the meshing process itself. It is not imposed by an external prime mover or by road unevenness. It is generated by the variation in the number of engaged tooth pairs, tooth compliance, contact stiffness, manufacturing error, and impact at the beginning and end of mesh. I classify the internal excitation into three parts: mesh impact excitation, stiffness excitation, and error excitation. The total internal excitation is then assembled from these parts.
Dynamic Contact Formulation
I describe the contact-impact problem of straight bevel gears using the dynamic equation of the driving and driven gear bodies. Let \(i \in \{p,g\}\) denote the pinion and gear. The equation is
$$
\mathbf{M}_i \ddot{\mathbf{u}}_i(t) + \mathbf{C}_i \dot{\mathbf{u}}_i(t) + \mathbf{K}_i(t)\mathbf{u}_i(t) = \mathbf{P}_i(t) + \mathbf{F}_i(t)
$$
where \(\mathbf{M}_i\) is the mass matrix, \(\mathbf{C}_i\) is the damping matrix, \(\mathbf{K}_i(t)\) is the stiffness matrix, \(\mathbf{P}_i(t)\) is the external load vector, \(\mathbf{F}_i(t)\) is the contact force vector, \(\mathbf{u}_i(t)\) is the displacement vector, \(\dot{\mathbf{u}}_i(t)\) is the velocity vector, and \(\ddot{\mathbf{u}}_i(t)\) is the acceleration vector. The contact condition couples the two bodies through the tooth flank. When the contact force becomes nonzero, a new pair of straight bevel gear teeth enters engagement.
For time integration I use the Newmark-beta method. The contact finite element equation at time \(t+\Delta t\) is written as
$$
\hat{\mathbf{K}}_i \mathbf{u}_i(t+\Delta t) = \hat{\mathbf{P}}_i(t+\Delta t)
$$
The effective stiffness matrix is
$$
\hat{\mathbf{K}}_i = \mathbf{K}_i + \frac{\gamma}{\beta \Delta t}\mathbf{C}_i + \frac{1}{\beta \Delta t^{2}}\mathbf{M}_i
$$
and the effective load vector is
$$
\begin{aligned}
\hat{\mathbf{P}}_i(t+\Delta t) ={}& \mathbf{P}_i(t+\Delta t) \\
&+ \mathbf{M}_i \left[ \frac{1}{\beta \Delta t^{2}}\mathbf{u}_i(t) + \frac{1}{\beta \Delta t}\dot{\mathbf{u}}_i(t) + \left(\frac{1}{2\beta}-1\right)\ddot{\mathbf{u}}_i(t) \right] \\
&+ \mathbf{C}_i \left[ \frac{\gamma}{\beta \Delta t}\mathbf{u}_i(t) + \left(\frac{\gamma}{\beta}-1\right)\dot{\mathbf{u}}_i(t) + \left(\frac{\gamma}{2\beta}-1\right)\Delta t \ddot{\mathbf{u}}_i(t) \right]
\end{aligned}
$$
In my calculations, the contact force history is obtained by solving this system iteratively because the contact state changes as the straight bevel gears rotate. The resulting contact force curve provides the engagement instant, the separation instant, and the peak impact force. I use these values to construct the mesh impact excitation.
Mesh Impact Excitation
Mesh impact in straight bevel gears occurs when a new tooth pair comes into contact before the previous pair has fully unloaded. Because the driving and driven gears have slightly different instantaneous velocities, the engaging teeth collide. The impact force depends on the contact velocity, the transmitted torque, the backlash, and the shaft angle error. I simulate the mesh impact by applying an initial impact velocity to the driving straight bevel gear while the driven gear is subjected to a prescribed torque or fixed constraint.
The impact force curve is not symmetric. It rises quickly to a peak and then decays as the contact compliance and damping dissipate energy. I define the impact duration as the time interval between the first contact and the instant when the contact force falls below a small threshold. The peak force and duration are used as input to the internal excitation model. Table 2 summarizes the influence of the main factors on mesh impact in straight bevel gears.
| Factor | Condition | Observed impact response | Physical interpretation |
|---|---|---|---|
| Driven torque | \(3\,\mathrm{kN \cdot m}\) | Lower peak force, impact duration about \(700\,\mu\mathrm{s}\) | Lower contact load produces smaller tooth deflection and weaker impact |
| Driven torque | \(5\,\mathrm{kN \cdot m}\) | Higher peak force than the \(3\,\mathrm{kN \cdot m}\) case | Higher contact load increases stored elastic energy before impact |
| Driven torque | Driven gear fixed | Maximum peak force, impact duration about \(810\,\mu\mathrm{s}\) | Fixed driven gear removes the relief effect of driven-side rotation |
| Initial impact velocity | \(5\,\mathrm{rad/s}\) | Small impact force | Low relative velocity reduces kinetic energy available for impact |
| Initial impact velocity | \(15\,\mathrm{rad/s}\) | Moderate impact force | Intermediate relative velocity increases contact deformation rate |
| Initial impact velocity | \(20\,\mathrm{rad/s}\) | Large impact force | High relative velocity increases impact kinetic energy |
| Backlash | \(0.2\,\mathrm{mm}\) | Lowest impact force | Small clearance limits acceleration before contact |
| Backlash | \(0.4\,\mathrm{mm}\) | Moderate impact force | Larger clearance allows more relative acceleration |
| Backlash | \(0.6\,\mathrm{mm}\) | Highest impact force | Large clearance produces a larger impact velocity |
| Shaft angle deviation | \(+0.02^\circ\) | Small increase in impact force | Contact area is slightly reduced |
| Shaft angle deviation | \(+0.04^\circ\) | Moderate increase in impact force | Contact concentration becomes stronger |
| Shaft angle deviation | \(+0.06^\circ\) | Large increase in impact force | Local edge contact dominates the impact response |
The results show that the mesh impact excitation of straight bevel gears is sensitive to torque, impact velocity, backlash, and shaft angle deviation. In particular, increasing the driven torque raises the contact force level and therefore the impact amplitude. Increasing the initial relative velocity raises the kinetic energy at engagement and therefore the peak impact force. Increasing backlash allows the driven gear to accelerate before contact, which also raises the impact force. A positive shaft angle deviation reduces the contact area and increases contact stress concentration, so the impact force increases significantly. For the operational range considered here, the shaft angle deviation has a strong relative influence on the impact amplitude even when its absolute value is small.
After computing the individual impact events, I synthesize them into a continuous mesh impact excitation curve. The synthesis accounts for the alternating engagement of tooth pairs and the phase difference between successive meshes. The resulting curve is periodic at the tooth mesh frequency, but its amplitude is modulated by the load and by the contact velocity. This curve is later combined with the stiffness and error excitations to form the total internal excitation of the straight bevel gears.
Stiffness Excitation
Stiffness excitation is caused by the time variation of the mesh stiffness. Even if the transmitted torque is constant, the number of engaged tooth pairs changes as the straight bevel gears rotate. In a real straight bevel gear pair, the mesh stiffness is not constant because the contact line length, the contact position, and the tooth compliance vary. I calculate the mesh stiffness from the contact force and the tooth deformation. For \(n\) engaged tooth pairs, the combined mesh stiffness is
$$
k_m(t) = \sum_{j=1}^{n(t)} \frac{F_j(t)}{\delta_{p,j}(t) + \delta_{g,j}(t)}
$$
where \(F_j(t)\) is the contact force of the \(j\)-th tooth pair, \(\delta_{p,j}(t)\) is the deformation of the driving straight bevel gear tooth, and \(\delta_{g,j}(t)\) is the deformation of the driven straight bevel gear tooth. In the finite element contact model, the contact force is obtained from the static equilibrium equations
$$
\mathbf{K}_{p,s}\mathbf{x}_{p,s} = \mathbf{P}_{p,s} + \mathbf{F}_{p}
$$
$$
\mathbf{K}_{g,s}\mathbf{x}_{g,s} = \mathbf{P}_{g,s} + \mathbf{F}_{g}
$$
where \(\mathbf{K}_{p,s}\) and \(\mathbf{K}_{g,s}\) are the static stiffness matrices, \(\mathbf{x}_{p,s}\) and \(\mathbf{x}_{g,s}\) are the static displacement vectors, \(\mathbf{P}_{p,s}\) and \(\mathbf{P}_{g,s}\) are the static load vectors, and \(\mathbf{F}_{p}\) and \(\mathbf{F}_{g}\) are the dynamic contact force vectors. I solve these equations at each time step and update the contact state until convergence.
The mesh damping of straight bevel gears is related to the mesh stiffness and the equivalent masses. I use the following expression for the mesh damping coefficient:
$$
c_m(t) = 2\zeta \sqrt{k_m(t) \frac{m_p m_g}{m_p + m_g}}
$$
where \(\zeta\) is the mesh damping ratio, usually taken between \(0.03\) and \(0.17\), and \(m_p\) and \(m_g\) are the equivalent masses of the driving and driven straight bevel gears. I select a damping ratio within this range and keep it constant during one simulation case. The resulting mesh stiffness curve is periodic at the tooth mesh frequency. It contains a mean component and a fluctuating component. The fluctuating component is the source of stiffness excitation.
| Quantity | Symbol | Meaning | Use in the model |
|---|---|---|---|
| Contact force | \(F_j(t)\) | Force transmitted by the \(j\)-th tooth pair | Determines load level and impact amplitude |
| Tooth deformation | \(\delta_{p,j}, \delta_{g,j}\) | Elastic deformation of the two mating straight bevel gear teeth | Provides the denominator of the mesh stiffness |
| Mesh stiffness | \(k_m(t)\) | Time-varying combined stiffness | Defines the stiffness excitation |
| Mesh damping | \(c_m(t)\) | Energy dissipation in the mesh | Controls the decay of impact and vibration |
| Damping ratio | \(\zeta\) | Non-dimensional damping parameter | Used to scale the damping coefficient |
I note that the mesh stiffness of straight bevel gears is not only a function of the number of engaged teeth. It also depends on the contact position along the tooth width. When the contact moves toward the tooth tip or toward the tooth root, the effective compliance changes. When the shaft angle deviation is present, the contact area shifts toward one edge, and the stiffness curve becomes more irregular. I therefore include the shaft angle deviation in the stiffness calculation. The stiffness excitation is obtained by subtracting the mean stiffness from the time-varying stiffness:
$$
\Delta k_m(t) = k_m(t) – \bar{k}_m
$$
where \(\bar{k}_m\) is the average mesh stiffness over one mesh cycle. The term \(\Delta k_m(t)\) is used in the internal excitation formula.
Error Excitation
Error excitation in straight bevel gears originates from manufacturing and assembly deviations. The most important contributors are tooth profile error and base pitch error. These errors change the effective contact position and create a displacement excitation even when the transmitted load is constant. I represent the combined transmission error as a harmonic function:
$$
e(t) = e_m + e_r \sin\left(\frac{2\pi \omega t}{T} + \phi\right)
$$
where \(e_m\) is the mean transmission error, \(e_r\) is the error amplitude, \(T\) is the mesh period, \(\omega\) is the mesh frequency, and \(\phi\) is the initial phase angle. The mean part \(e_m\) shifts the average contact position, while the alternating part produces dynamic excitation. I choose the deterministic component of the transmission error according to a five-grade machining accuracy class. The base pitch error and tooth profile error are combined probabilistically. I assume that the error from the tooth root to the tooth tip follows a half-sine distribution. This assumption is consistent with the gradual change of contact position along the tooth height.
| Error parameter | Symbol | Description | Modeling treatment |
|---|---|---|---|
| Mean transmission error | \(e_m\) | Constant offset of the contact position | Included as a static shift |
| Error amplitude | \(e_r\) | Amplitude of the periodic error | Derived from accuracy grade and probabilistic combination |
| Mesh period | \(T\) | Time for one tooth mesh cycle | Calculated from rotational speed and tooth number |
| Mesh frequency | \(\omega\) | Angular frequency of mesh | Used in the harmonic error function |
| Initial phase | \(\phi\) | Phase of the error at the start of simulation | Adjusted to match the engagement instant |
| Tooth profile error | \(f_f\) | Deviation of the actual profile from the ideal profile | Half-sine distribution along the tooth height |
| Base pitch error | \(f_{pb}\) | Deviation of the base pitch | Combined probabilistically with profile error |
The error excitation is important for straight bevel gears because it can shift the engagement instant and change the relative velocity at impact. When the error is large, the contact may begin earlier or later than the ideal engagement time. If contact begins earlier, the impact velocity may increase; if contact begins later, the load may be carried by fewer teeth. Both effects increase the dynamic factor. In my model, the error function is not treated as a simple constant offset. It is inserted into the internal excitation formula together with the stiffness variation and the impact force.
Combined Internal Excitation
The total internal excitation of the straight bevel gears is the sum of the stiffness-related term, the error-related term, and the mesh impact term. I use the following expression:
$$
F_{\text{int}}(t) = \Delta k_m(t)e(t) + S(t)
$$
where \(F_{\text{int}}(t)\) is the internal excitation, \(\Delta k_m(t)\) is the fluctuating part of the mesh stiffness, \(e(t)\) is the combined transmission error, and \(S(t)\) is the mesh impact excitation. This formula is convenient because it separates the parametric stiffness modulation from the direct displacement error and from the impulsive impact. The first term represents the product of stiffness variation and transmission error. The second term represents the short-duration impact force generated when a new tooth pair enters mesh.
I synthesize the internal excitation over several mesh cycles to obtain a representative periodic signal. The signal contains high-frequency components at the mesh frequency and its harmonics. It also contains low-frequency modulation caused by load variation and by the changing number of engaged tooth pairs. In the context of straight bevel gears, this combined internal excitation is the primary source of gear whine and tooth root dynamic stress. The amplitude of the internal excitation increases with transmitted torque, rotational speed, backlash, and shaft angle deviation, as demonstrated by the mesh impact simulations.
External Dynamic Excitation of Straight Bevel Gears
External excitation acts on the straight bevel gear system through the driveline and through the vehicle body. I consider two main sources: engine torque fluctuation and ground vibration. The engine excitation is periodic and deterministic because it is related to the firing order of the cylinders. The ground excitation is stochastic and depends on the road profile, vehicle speed, tire properties, and suspension characteristics. Both sources are transmitted to the final drive where the straight bevel gears operate.
Engine Torque Excitation
The engine is the main source of torsional excitation in the driveline. The torque delivered to the transmission is not constant even under steady throttle because the cylinder pressure, the reciprocating inertia, and the gravitational force on the reciprocating parts vary with crank angle. For a single cylinder, the torque can be written as
$$
M^{(c)}(\theta) = M_p^{(c)}(\theta) + M_j^{(c)}(\theta) + M_g^{(c)}(\theta)
$$
where \(M_p^{(c)}\) is the gas pressure torque, \(M_j^{(c)}\) is the reciprocating inertia torque, and \(M_g^{(c)}\) is the gravity torque. For a multi-cylinder engine, the total torque is the sum of the contributions from all cylinders:
$$
M_e(\theta) = \sum_{c=1}^{N_c} M^{(c)}(\theta)
$$
where \(N_c\) is the number of cylinders. I model an eight-cylinder V-type four-stroke diesel engine. The firing intervals are not perfectly uniform; the engine uses alternating intervals of \(60^\circ\) and \(120^\circ\). This firing pattern introduces a torque spectrum with specific orders that are transmitted through the driveline to the straight bevel gears. The torque fluctuation causes rotational speed fluctuation of the driving straight bevel gear and therefore modulates the mesh impact and the mesh stiffness.
| Engine excitation component | Symbol | Origin | Frequency character |
|---|---|---|---|
| Gas pressure torque | \(M_p^{(c)}\) | Cylinder combustion pressure acting on the piston | Periodic at firing frequency and harmonics |
| Reciprocating inertia torque | \(M_j^{(c)}\) | Acceleration and deceleration of reciprocating masses | Periodic at crank angle frequency and harmonics |
| Gravity torque | \(M_g^{(c)}\) | Weight of reciprocating parts | Periodic at crank angle frequency |
| Total engine torque | \(M_e(\theta)\) | Sum over all cylinders | Contains firing order and harmonics |
I represent the engine torque as a Fourier series for dynamic analysis. The mean torque provides the steady operating load, while the alternating components provide the external excitation. For straight bevel gears, the mean torque determines the contact force and the mesh stiffness level, and the alternating torque determines the amplitude of the torsional vibration. The engine excitation is especially important at low speeds where the torque fluctuation is large relative to the mean torque. At high speeds, the inertia torque becomes more important. In both cases, the external excitation enters the straight bevel gear system through the pinion shaft.
Ground Excitation
Ground excitation reaches the straight bevel gears through the tires, suspension, body, and driveline. It is random in nature because the road profile is not deterministic. I model the ground excitation as a sum of harmonic components with random amplitudes and phases:
$$
z_g(t) = \sum_{r=1}^{N_r} A_r \sin(\omega_r t + \varphi_r)
$$
where \(A_r\) is the amplitude of the \(r\)-th component, \(\omega_r\) is its angular frequency, and \(\varphi_r\) is its phase. In a more detailed model, the amplitudes and phases are derived from a road roughness spectrum. The tire and suspension act as a filter, so not all road frequencies reach the final drive with the same amplitude. The suspension isolates high-frequency road inputs, while the driveline transmits low-frequency and intermediate-frequency inputs. For straight bevel gears, the ground excitation causes time-varying torque at the wheel side and therefore time-varying load on the gear teeth. This load variation changes the contact force, the mesh stiffness, and the impact velocity.
| External source | Physical path | Main frequency range | Effect on straight bevel gears |
|---|---|---|---|
| Engine torque fluctuation | Engine → clutch → transmission → driveshaft → final drive | Firing frequency and harmonics | Modulates input speed and torque; changes impact and stiffness |
| Ground vibration | Road → tire → suspension → body → driveline → final drive | Broadband random | Causes random load variation and torque reversal under severe conditions |
| Combined external excitation | Engine and road together | Mixed periodic and random | Produces time-varying mesh load and speed |
Combined External Excitation
I combine the engine torque and ground excitation into a single external excitation signal. The engine torque is deterministic and periodic, while the ground excitation is random. I add them at the input and output sides of the straight bevel gear system. The input side receives the engine torque fluctuation. The output side receives the ground-induced torque fluctuation through the wheels. The combination produces a time-varying torque difference across the straight bevel gear pair. This torque difference changes the contact force, the number of engaged teeth, and the mesh stiffness. It also changes the relative velocity at engagement, which in turn changes the mesh impact.
The external excitation is therefore not independent of the internal excitation. The engine torque fluctuation changes the mean load and therefore the stiffness excitation amplitude. The ground excitation changes the contact pattern and can cause loss of contact or edge contact in the straight bevel gears. When the load reverses, the driving and driven flanks alternate, and the impact occurs on the opposite side of the tooth. This interaction between internal and external excitation is important for realistic simulation.
Numerical Simulation Procedure
My numerical procedure consists of six main steps. First, I build the three-dimensional solid model of the straight bevel gears. Second, I generate the finite element mesh and assign material properties. Third, I apply the boundary conditions and solve the static contact problem. Fourth, I extract the contact force history and identify the engagement instant. Fifth, I calculate the mesh stiffness, transmission error, and mesh impact excitation. Sixth, I combine the internal and external excitations into a single loading history for dynamic response analysis.
| Step | Task | Output | Use in excitation model |
|---|---|---|---|
| 1 | Create 3D geometry of straight bevel gears | Solid model | Basis for finite element discretization |
| 2 | Mesh the model and assign material data | Finite element model | Provides stiffness and mass matrices |
| 3 | Apply speed, torque, and constraints | Boundary condition set | Defines operating condition |
| 4 | Solve contact problem | Contact force history | Gives engagement instant and impact force |
| 5 | Calculate mesh stiffness and error | \(k_m(t)\), \(e(t)\) | Forms stiffness and error excitation |
| 6 | Assemble internal and external excitation | \(F_{\text{int}}(t)\), \(F_{\text{ext}}(t)\) | Input for dynamic response simulation |
I use the same finite element model for all load cases to ensure consistency. The input speed is fixed at \(1000\,\mathrm{r/min}\) for the baseline case. The input torque is \(2443.6\,\mathrm{N \cdot m}\). I then vary the driven torque, the impact velocity, the backlash, the shaft angle deviation, and the external excitation level. This parametric study allows me to determine which factors have the strongest influence on the excitation of straight bevel gears.
| Case | Variable | Range or value | Purpose |
|---|---|---|---|
| A | Driven torque | \(3\), \(5\,\mathrm{kN \cdot m}\), fixed driven gear | Study load effect on mesh impact |
| B | Initial impact velocity | \(5\), \(15\), \(20\,\mathrm{rad/s}\) | Study relative speed effect |
| C | Backlash | \(0.2\), \(0.4\), \(0.6\,\mathrm{mm}\) | Study clearance effect |
| D | Shaft angle deviation | \(+0.02^\circ\), \(+0.04^\circ\), \(+0.06^\circ\) | Study misalignment effect |
| E | Engine excitation | Eight-cylinder V-type diesel torque | Study periodic external excitation |
| F | Ground excitation | Random road input | Study stochastic external excitation |
Results and Discussion
The simulation results show that the excitation of straight bevel gears is a combination of impact, stiffness variation, transmission error, and external load fluctuation. The relative importance of each component depends on the operating condition. Under low torque, the impact excitation is relatively small but still visible because the backlash allows a certain amount of free motion before contact. Under high torque, the impact excitation increases because the stored elastic energy in the teeth increases. Under high speed, the impact excitation increases because the relative velocity at engagement increases. Under shaft angle deviation, the impact excitation increases because the contact area is reduced and the local contact stiffness changes.
Mesh Impact Response
The mesh impact force curve has a sharp rise and a gradual decay. The peak force is reached shortly after the first contact. The duration of the impact is on the order of several hundred microseconds. When the driven torque is \(3\,\mathrm{kN \cdot m}\), the impact duration is about \(700\,\mu\mathrm{s}\). When the driven gear is fixed, the impact duration increases to about \(810\,\mu\mathrm{s}\). The fixed condition represents the most severe case because the driven side cannot rotate to relieve the contact. In a real vehicle, the driven side is connected to the wheels and the vehicle inertia, so the boundary condition lies between free rotation and fixed support.
The impact velocity is calculated from the difference between the theoretical driven speed and the actual driven speed obtained from the finite element simulation. The theoretical speed is determined by the gear ratio. The actual speed is affected by tooth deflection, backlash, and contact compliance. The difference is converted to the impact velocity at the driving straight bevel gear. The simulation shows that a higher impact velocity produces a higher peak force. This is expected because the kinetic energy available at engagement increases with the square of the velocity. For straight bevel gears in automotive differentials, the impact velocity is influenced by the engine torque fluctuation and by the road load. Therefore, reducing the torque fluctuation and improving the road isolation can reduce the mesh impact.
Backlash and Shaft Angle Effects
Backlash has a direct effect on the impact velocity. When backlash is small, the driven straight bevel gear can move only a short distance before contact, so the impact velocity is limited. When backlash is large, the driven gear can accelerate over a longer distance, so the impact velocity is higher. The simulation shows that increasing backlash from \(0.2\,\mathrm{mm}\) to \(0.6\,\mathrm{mm}\) increases the peak impact force. This result suggests that backlash should be controlled within a proper range to balance lubrication, thermal expansion, and impact reduction.
Shaft angle deviation has an even stronger effect on the contact pattern. A positive shaft angle deviation reduces the contact area and shifts the contact toward the tooth edge. The local contact stiffness increases, and the load is concentrated on a smaller region. As a result, the impact force increases. The simulation shows that a deviation of \(+0.06^\circ\) produces a larger increase in impact force than the same relative change in backlash. This indicates that alignment quality is critical for straight bevel gears. In an automotive differential, the shaft angle deviation can be caused by manufacturing tolerance, bearing clearance, and housing deformation. Therefore, improving the stiffness of the housing and the bearing support can reduce the excitation of straight bevel gears.
Stiffness and Error Excitation
The mesh stiffness curve has a periodic shape. The stiffness is higher when two tooth pairs share the load and lower when only one tooth pair carries the load. The transition between these states produces a fluctuation in the effective stiffness. The amplitude of the fluctuation depends on the contact ratio, the tooth compliance, and the load distribution. The stiffness excitation is proportional to the product of the stiffness fluctuation and the transmission error. Therefore, reducing the transmission error reduces the stiffness excitation even if the stiffness fluctuation remains unchanged.
The error excitation is modeled as a harmonic function. The mean error shifts the contact position, while the alternating error creates a dynamic displacement. The error amplitude is derived from the accuracy grade and from the probabilistic combination of profile error and base pitch error. The simulation shows that the error excitation has a significant effect at low load because the contact force is small and the displacement error is not suppressed by elastic deformation. At high load, the error excitation is partially absorbed by the tooth compliance, but it still contributes to the dynamic response. For straight bevel gears, the error excitation should therefore be controlled by improving manufacturing accuracy and by selecting a proper tooth modification.
| Excitation type | Main cause | Frequency content | Influence factors |
|---|---|---|---|
| Mesh impact | Collision of entering tooth pairs | Broadband, high frequency | Torque, speed, backlash, shaft angle |
| Stiffness | Time-varying number of engaged teeth and contact position | Mesh frequency and harmonics | Contact ratio, tooth compliance, load |
| Error | Profile error, base pitch error, assembly error | Mesh frequency and harmonics | Accuracy grade, modification, load |
| Engine | Cylinder pressure, inertia, gravity | Firing frequency and harmonics | Engine type, speed, load, firing order |
| Ground | Road roughness, tire, suspension | Broadband random | Road class, speed, suspension tuning |
External Excitation Effects
The engine torque fluctuation changes the input speed of the driving straight bevel gear. When the input speed fluctuates, the mesh frequency also fluctuates. This frequency modulation spreads the excitation energy over a wider frequency band. The amplitude modulation caused by the torque fluctuation changes the contact force and therefore the mesh stiffness. The result is a coupled internal-external excitation. In my simulation, the engine excitation is most important at low engine speeds and high loads. Under these conditions, the torque fluctuation is large, and the driveline has less inertia to smooth the fluctuation. The straight bevel gears then experience a strong periodic load variation.
The ground excitation is most important at high vehicle speeds and on rough roads. The random torque at the wheel side propagates through the differential and reaches the straight bevel gears. Because the ground excitation is random, it does not have a single dominant frequency. Instead, it excites many modes of the driveline. When the ground excitation is large, the contact force can drop to zero and then rise again, causing repeated impact. This condition is severe for straight bevel gears because it can produce tooth separation and back-side contact. The simulation shows that smoothing the engine output and improving the road surface can reduce the external excitation. In practical terms, this can be achieved by improving engine mounting, clutch damping, suspension damping, and driveline compliance.
Overall Excitation Synthesis
I assemble the total excitation of the straight bevel gear system by adding the internal and external contributions. The internal contribution dominates the high-frequency content, while the external contribution dominates the low-frequency and random content. The mesh impact provides short-duration pulses. The stiffness and error provide periodic components at the mesh frequency. The engine provides periodic components at the firing frequency and its harmonics. The ground provides broadband random components. When these components are combined, the resulting excitation is a non-stationary signal with both periodic and random features.
The combined excitation can be written conceptually as
$$
F_{\text{total}}(t) = F_{\text{int}}(t) + F_{\text{ext}}(t)
$$
where
$$
F_{\text{int}}(t) = \Delta k_m(t)e(t) + S(t)
$$
and
$$
F_{\text{ext}}(t) = F_{\text{engine}}(t) + F_{\text{ground}}(t)
$$
This separation is useful for design because it shows which excitation source should be targeted for a given problem. If the problem is high-frequency whine, the internal excitation should be reduced by improving tooth contact, reducing transmission error, and optimizing backlash. If the problem is low-frequency shuffle or impact, the external excitation should be reduced by improving engine torque smoothness and road isolation.
| Combined excitation component | Symbol | Main source | Typical effect on straight bevel gears |
|---|---|---|---|
| Internal total | \(F_{\text{int}}(t)\) | Mesh impact, stiffness variation, transmission error | High-frequency vibration, tooth stress, whine |
| External total | \(F_{\text{ext}}(t)\) | Engine torque, ground vibration | Low-frequency torque fluctuation, random load, impact |
| Total excitation | \(F_{\text{total}}(t)\) | Internal plus external | Combined dynamic response |
Sensitivity and Design Implications
The simulation results allow me to rank the sensitivity of straight bevel gear excitation to various parameters. The ranking is not universal because it depends on the operating point, but it provides useful guidance. In general, the transmitted torque has the strongest effect on the mean contact force and on the impact amplitude. The impact velocity has a strong effect on the peak impact force because kinetic energy depends on velocity squared. The shaft angle deviation has a strong effect on the contact pattern and therefore on the local stiffness. Backlash has a moderate effect on the impact velocity and a smaller effect on the stiffness. The transmission error has a strong effect on the periodic internal excitation, especially at low load.
| Parameter | Effect on mesh impact | Effect on stiffness excitation | Effect on error excitation | Overall sensitivity |
|---|---|---|---|---|
| Transmitted torque | Strong increase with torque | Moderate increase with load | Moderate decrease due to compliance | High |
| Rotational speed | Strong increase with speed | Frequency shift | Frequency shift | High |
| Backlash | Moderate increase with clearance | Small | Small | Moderate |
| Shaft angle deviation | Strong increase with deviation | Strong increase due to edge contact | Moderate increase | High |
| Transmission error | Moderate effect on impact timing | Strong product effect | Direct source | High |
| Engine torque fluctuation | Moderate modulation | Moderate modulation | Small direct effect | High for low-frequency response |
| Ground excitation | Strong under rough road | Moderate to strong | Small direct effect | High for random response |
From a design perspective, I can draw several implications for straight bevel gears. First, the contact pattern should be centered and should not be concentrated at the tooth edge. This reduces the sensitivity to shaft angle deviation. Second, backlash should be controlled within a narrow range. Too little backlash may cause binding and thermal problems, while too much backlash increases impact. Third, transmission error should be minimized by using appropriate tooth modification and high manufacturing accuracy. Fourth, the driveline should be tuned to isolate engine and ground excitation. Fifth, the housing and bearing supports should be stiff enough to maintain alignment under load.
Limitations of the Present Model
The present model has several limitations. I did not include bearing deformation in the finite element model. Bearing deformation can change the shaft angle and the contact pattern, especially under high load. I also did not include structural manufacturing and assembly errors beyond the shaft angle deviation and the transmission error. These errors can introduce additional contact misalignment. In addition, I treated the internal and external excitations separately and then combined them linearly. In reality, the interaction between internal and external excitation is nonlinear because the contact state changes with load. For example, a torque reversal caused by ground excitation can change the active tooth flank and produce a different impact. These effects should be considered in future work.
Another limitation is that the ground excitation is represented by a simplified random function. A more detailed model would use measured road profiles and a full vehicle model to calculate the torque at the differential input. Similarly, the engine excitation is represented by a multi-cylinder torque model, but the effects of clutch dynamics, transmission compliance, and driveline backlash are not fully included. These components can filter or amplify the torque fluctuation before it reaches the straight bevel gears. Future work should therefore include a full driveline model with the straight bevel gear excitation model embedded in it.
Conclusions and Future Work
In this work I developed a numerical simulation framework for the internal and external excitation of automotive straight bevel gears. I used finite element contact analysis to obtain the mesh impact, the engagement position, the relative rotational speed, and the time-varying mesh stiffness. I used a harmonic function to represent the transmission error. I combined these internal sources into a single internal excitation curve. I then modeled the external excitation using an eight-cylinder V-type diesel engine torque and a random ground excitation. The resulting excitation model is closer to actual operating conditions than a constant-load model.
The main conclusions are as follows. The mesh impact of straight bevel gears increases with driven torque, impact velocity, backlash, and shaft angle deviation. The impact duration is on the order of several hundred microseconds. A fixed driven gear produces the highest impact force among the boundary conditions considered. The mesh stiffness is time-varying and produces a periodic stiffness excitation at the mesh frequency. The transmission error is an important internal excitation source, especially at low load. The engine torque fluctuation and ground vibration are the main external excitation sources. The total excitation of straight bevel gears is a combination of high-frequency internal effects and low-frequency external effects.
Future work should include bearing deformation, housing flexibility, manufacturing and assembly errors, and nonlinear interaction between internal and external excitation. A full vehicle driveline model should be developed to transmit the engine and ground excitation to the straight bevel gears more accurately. Experimental validation should also be performed using strain gauges, accelerometers, and transmission error measurement. With these improvements, the numerical simulation of straight bevel gear excitation can be used to optimize tooth geometry, backlash, alignment, and driveline tuning. Such an approach will support the design of quieter and more durable automotive differential straight bevel gears.
| Future extension | Reason | Expected benefit |
|---|---|---|
| Bearing deformation | Bearings affect shaft alignment and contact pattern | More accurate shaft angle and contact force prediction |
| Housing flexibility | Housing deformation changes support stiffness | Better prediction of edge contact and misalignment |
| Manufacturing and assembly error | Real parts deviate from ideal geometry | More realistic transmission error and impact |
| Nonlinear internal-external coupling | Contact state changes with load and torque reversal | Improved prediction of impact and tooth separation |
| Full driveline model | Clutch, transmission, and shafts filter excitation | More accurate excitation at the straight bevel gears |
| Experimental validation | Simulation requires physical verification | Increased confidence in the excitation model |
In summary, the excitation of straight bevel gears is a multi-source problem. Internal excitation is controlled by the meshing process, while external excitation is controlled by the engine and the road. My numerical results show that both sources must be considered together to predict the dynamic behavior of automotive differential straight bevel gears. By improving the contact pattern, controlling backlash, reducing transmission error, and isolating external vibration, the excitation level of straight bevel gears can be reduced. These conclusions provide a basis for further research on the dynamic characteristics of straight bevel gears and for the design of more refined automotive driveline systems.