
In the realm of precision mechanical transmissions, hyperboloid gears, particularly the high-ratio hypoid (HRH) variant, have garnered significant attention due to their superior load-bearing capacity, smooth operation, and high transmission ratios. As a researcher deeply involved in gear design and manufacturing, I have explored the geometric evolution of these gears, focusing on the transition from tapered teeth to arc equal-height teeth and the optimization of their pitch cones. This article delves into the mathematical foundations, design methodologies, and practical implementations of HRH hyperboloid gears, leveraging extensive use of tables and formulas to elucidate complex concepts. The goal is to provide a comprehensive resource for engineers and designers working with hyperboloid gear systems, emphasizing the keyword ‘hyperboloid gear’ throughout to underscore its centrality in advanced transmission technology.
The evolution of hyperboloid gear geometry is driven by the need for higher efficiency, compactness, and durability in applications such as robotics, industrial reducers, and precision tools. Traditional hyperboloid gears often employ tapered teeth, but recent advancements have shifted toward arc equal-height teeth to enhance manufacturability and performance. This shift involves critical parameters like cutter radius, pitch cone angles, and tooth thickness, which I will analyze in detail. By optimizing these factors, we can achieve hyperboloid gears with minimal tooth contraction, improved strength, and better contact patterns, ultimately pushing the boundaries of what hyperboloid gear systems can accomplish.
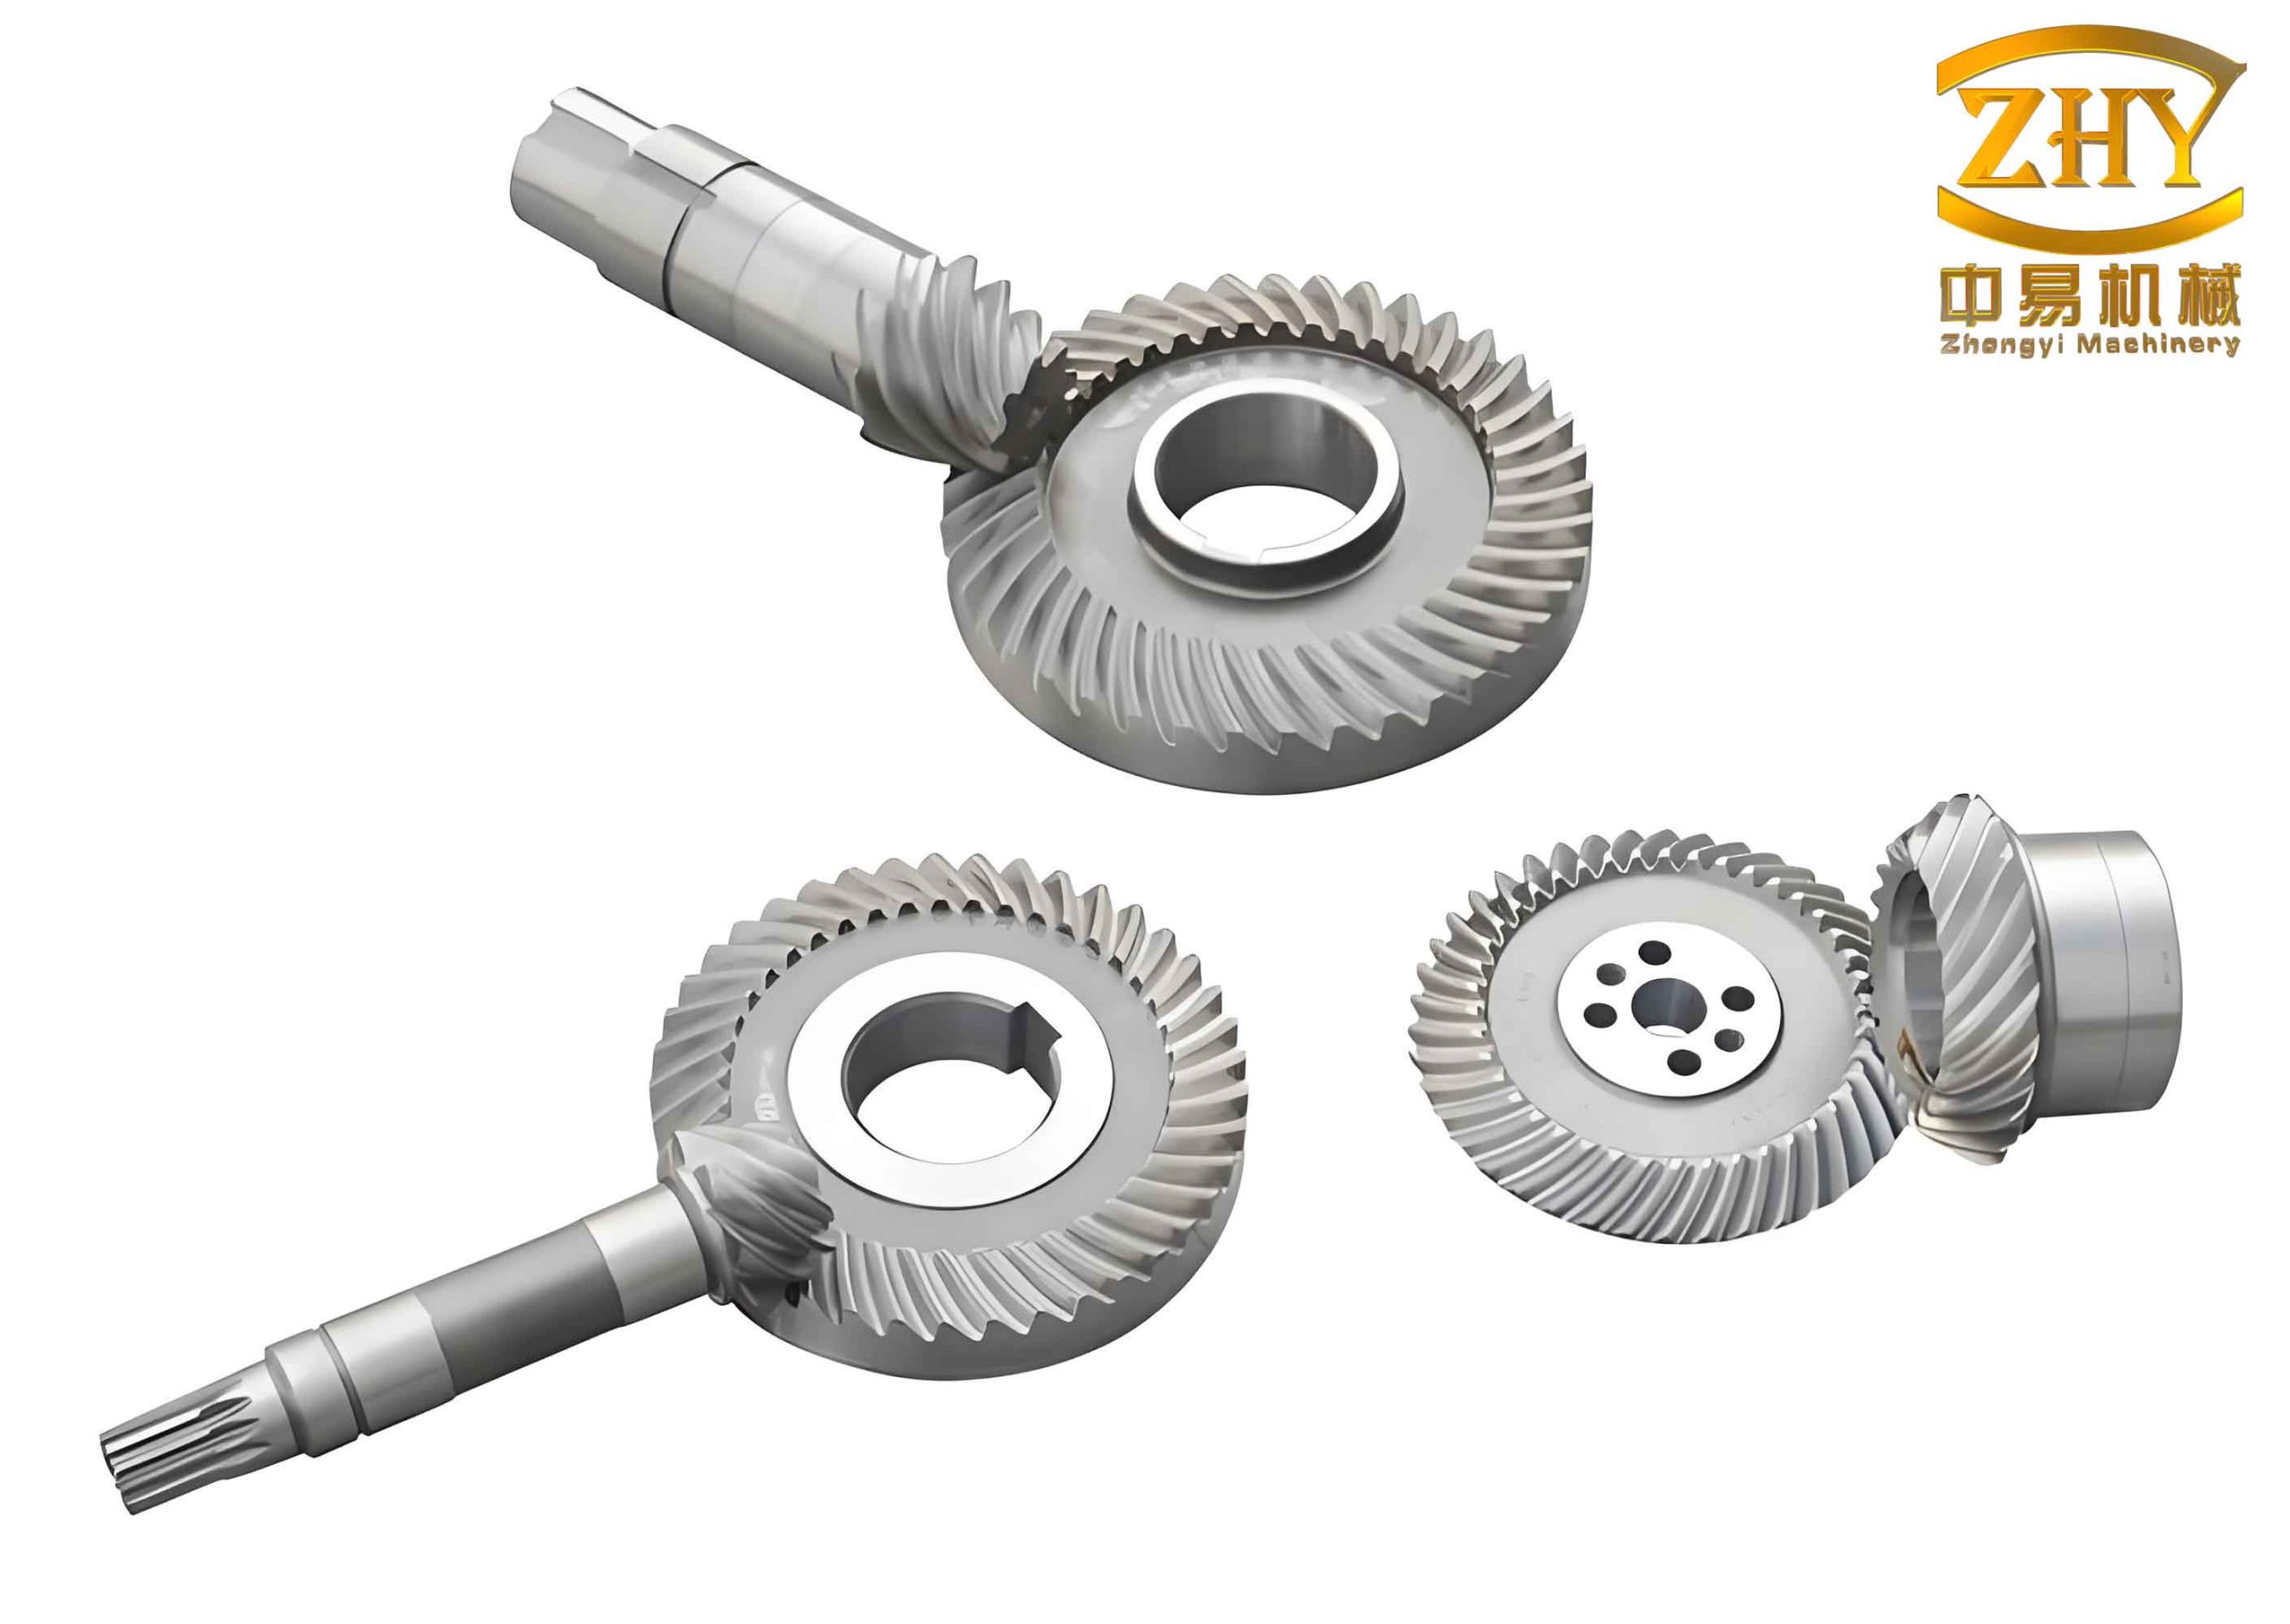
To visually appreciate the complexity and beauty of hyperboloid gears, consider the following image, which showcases their intricate geometry and meshing characteristics. This representation highlights the unique curvatures that define hyperboloid gear interactions, serving as a foundation for the discussions that follow.
The geometric design of hyperboloid gears begins with understanding tooth contraction methods. Common approaches include double contraction, standard contraction, root tilt, and equal-height teeth. For HRH hyperboloid gears, the arc equal-height tooth design, akin to the Gleason system, offers distinct advantages. Unlike tapered teeth, where the root and face cones converge, equal-height teeth feature parallel root and pitch cones, simplifying differential geometry properties. This parallelism ensures that the cutter axis, when perpendicular to the root cone, does not introduce pitch cone pressure angle errors, facilitating easier tooth surface modification and precision grinding—a crucial aspect for hyperboloid gear manufacturing.
The transition from tapered to equal-height teeth is governed by the cutter radius $$r_c$$. For tapered teeth, the sum of root angles $$\Sigma \theta_D$$ is calculated using the formula:
$$\Sigma \theta_D = \frac{90 m_{mt}}{R_m \tan \alpha \cos \beta} \left(1 – \frac{R_m \sin \beta}{r_c}\right),$$
where $$m_{mt}$$ is the midpoint transverse module, $$R_m$$ is the midpoint cone distance, $$\beta$$ is the midpoint spiral angle, and $$\alpha$$ is the cutter pressure angle. When $$r_c = R_m \sin \beta$$, $$\Sigma \theta_D = 0$$, resulting in equal-height teeth. This condition minimizes tooth height contraction, preventing distortion at the small end. Typically, for equal-height hyperboloid gears, the cutter radius satisfies $$R_m \sin \beta < r_c < 1.5 R_m \sin \beta$$. The Euler-Bertrand formula further validates this transition:
$$A_f = A_a \cos^2(\Sigma \theta_D) + B_a \sin^2(\Sigma \theta_D) – 2C_a \sin(\Sigma \theta_D) \cos(\Sigma \theta_D),$$
where $$A_f$$ is the normal curvature along the tooth length direction at the cutting pitch cone, and $$A_a$$, $$B_a$$, and $$C_a$$ are curvatures along the generating cone. For $$\Sigma \theta_D \leq 3^\circ$$, $$A_f$$ closely approximates $$A_a$$, with errors on the order of $$10^{-6}$$, confirming that mild contraction designs do not alter hyperboloid gear contact performance.
The evolution of pitch cone, face cone, and root cone angles in HRH hyperboloid gears is significantly influenced by the cutter radius. As $$r_c$$ decreases, the sum of root angles reduces, leading to less tooth height contraction and promoting equal-height characteristics. This evolution also affects the normal arc tooth thickness, enhancing strength at the small end. To illustrate, consider a hyperboloid gear pair with a ratio of 3:60 and a vertical offset of 35 mm. The impact of $$r_c$$ on geometric parameters is summarized in Table 1, derived from optimization processes discussed later.
| Cutter Radius $$r_c$$ (mm) | Gear Type | Pitch Cone Angle (°) | Face Cone Angle (°) | Root Cone Angle (°) | Sum of Root Angles (°) | Normal Arc Tooth Thickness (mm) – Large End / Small End |
|---|---|---|---|---|---|---|
| 48.15 | Large Gear | 84.94 | 86.03 | 82.93 | 3.22 | 2.163 / 1.896 |
| 48.15 | Small Gear | 3.84 | 5.40 | 3.01 | 2.845 / 2.578 | |
| 45.15 | Large Gear | 82.88 | 83.80 | 81.17 | 2.62 | 2.105 / 1.924 |
| 45.15 | Small Gear | 5.43 | 6.75 | 4.73 | 2.787 / 2.605 | |
| 42.15 | Large Gear | 79.83 | 80.49 | 78.61 | 1.87 | 2.038 / 1.958 |
| 42.15 | Small Gear | 7.79 | 8.76 | 7.29 | 2.719 / 2.640 | |
| 39.15 | Large Gear | 75.58 | 75.58 | 75.57 | 0.02 | 1.995 / 1.980 |
| 39.15 | Small Gear | 11.87 | 11.91 | 11.89 | 2.677 / 2.669 |
Table 1 demonstrates that as $$r_c$$ decreases, the pitch, face, and root cone angles of the large hyperboloid gear decrease, while those of the small hyperboloid gear increase. This trend reduces tooth height contraction, promotes equal-height design, and improves the strength of the small hyperboloid gear by increasing its volume. Additionally, the normal arc tooth thickness becomes more uniform, facilitating double-sided machining of the small hyperboloid gear. The face cone angle of the large hyperboloid gear remains below 85°, preventing cutter interference during machining.
Optimizing the pitch cone design for equal-height HRH hyperboloid gears involves selecting independent parameters: pitch cone angles $$\delta_1$$ and $$\delta_2$$, spiral angles $$\beta_1$$ and $$\beta_2$$, and the offset angle $$\eta$$ in the large gear axis plane. Let the design vector be $$\mathbf{X} = [\delta_1, \delta_2, \beta_1, \beta_2, \eta]$$. The objective function minimizes the difference between the limiting curvature radius along the tooth length and the cutter radius, while maximizing the pitch circle radius of the small hyperboloid gear:
$$F(\delta_1, \delta_2, \beta_1, \beta_2, \eta) = \left(\frac{\rho}{r_{\text{lim}}} – 1\right)^2 + k \left(\frac{\cos \beta_1}{\cos \beta_2} r_2\right)^2,$$
where $$\rho$$ is the curvature radius, $$r_{\text{lim}}$$ is the limiting curvature radius along the tooth length, $$r_2$$ is the pitch circle radius of the large hyperboloid gear, and $$k$$ is a weighting factor. Constraints include the meshing equation $$\mathbf{n}_2 \cdot \mathbf{v}_{12}^{(2)} = 0$$, which yields:
$$r_1 = \frac{r_2 \cos \beta_2 Z_1}{\cos \beta_1 Z_2},$$
where $$r_1$$ is the pitch circle radius of the small hyperboloid gear, and $$Z_1$$ and $$Z_2$$ are tooth numbers. The offset angle in the small gear pitch plane is:
$$\sin \epsilon’ = \frac{E – r_1 \sin \eta}{r_2 \cos \delta_1},$$
with $$E$$ as the offset distance. The pitch circle radius at the midpoint of the large hyperboloid gear is:
$$r_2 = \frac{d_{e2} – b \sin \delta_2}{2},$$
where $$d_{e2}$$ is the pitch diameter and $$b$$ is the face width. To avoid secondary meshing boundary points, the limiting pressure angle $$\alpha_{\text{lim}}$$ is restricted:
$$\tan \alpha_{\text{lim}} = \frac{R_2 \sin \beta_2 – R_1 \sin \beta_1}{R_2 \tan \delta_2 + R_1 \tan \delta_1} \frac{\tan \delta_1 \tan \delta_2}{\cos \epsilon’},$$
where $$R_1$$ and $$R_2$$ are midpoint cone distances. The limiting curvature radius is then:
$$r_{\text{lim}} = \frac{\tan \beta_1 – \tan \beta_2}{\frac{1}{R_1 \cos \beta_1} – \frac{1}{R_2 \cos \beta_2} – \tan \alpha_{\text{lim}} \left(\frac{\tan \beta_1}{R_1 \tan \delta_1} + \frac{\tan \beta_2}{R_2 \tan \delta_2}\right)}.$$
Additional constraints include $$\beta_2 \leq 45^\circ$$ to limit axial forces, $$\Sigma \theta_D \leq 3^\circ$$ for equal-height design, and $$\delta_2 \leq 85^\circ$$ to prevent cutter interference. Using MATLAB’s fmincon function, optimal values for $$\delta_1, \delta_2, \beta_1, \beta_2, \eta$$ are obtained, defining the pitch cones of the hyperboloid gear pair.
Based on this optimization, geometric parameters for an equal-height HRH hyperboloid gear with a 3:60 ratio and 35 mm offset are computed. Key parameters are listed in Table 2, showcasing the design’s adherence to constraints and its suitability for hyperboloid gear applications.
| Parameter | Large Hyperboloid Gear | Small Hyperboloid Gear |
|---|---|---|
| Face Width (mm) | 20.00 | 27.67 |
| Midpoint Spiral Angle (°) | 38.88 | 73.97 |
| Pitch Cone Angle (°) | 75.58 | 11.87 |
| Face Cone Angle (°) | 75.58 | 11.91 |
| Root Cone Angle (°) | 75.57 | 11.89 |
| Pressure Angle – Convex Side of Large Gear / Concave Side of Small Gear (°) | 17.101 | 17.101 |
| Outer Diameter (mm) | 140.00 | 26.72 |
| Outer Cone Distance (mm) | 72.27 | 55.21 |
| Midpoint Total Tooth Height (mm) | 3.52 | 3.52 |
| Distance from Pitch Cone Apex to Intersection Point (mm) | 7.079 | -9.474 |
| Distance from Face Cone Apex to Intersection Point (mm) | 8.204 | 0.254 |
| Distance from Root Cone Apex to Intersection Point (mm) | 4.586 | -16.760 |
| Distance from Tooth Crown to Intersection Point (mm) | 9.855 | 63.080 |
| Pressure Angle – Concave Side of Large Gear / Convex Side of Small Gear (°) | -22.898 | -22.898 |
Deriving the tooth surface equations is essential for simulating and manufacturing hyperboloid gears. For the large hyperboloid gear, generated via forming method, the cutter surface equation in the cutter coordinate system $$O_G X_G Y_G Z_G$$ is:
$$\mathbf{r}_G = \begin{bmatrix} (r_c – u_2 \sin \alpha_2) \cos \theta_2 \\ (r_c – u_2 \sin \alpha_2) \sin \theta_2 \\ -u_2 \cos \alpha_2 \end{bmatrix},$$
with the normal vector:
$$\mathbf{n}_G = \begin{bmatrix} -\cos \alpha_2 \cos \theta_2 \\ -\cos \alpha_2 \sin \theta_2 \\ \sin \alpha_2 \end{bmatrix},$$
where $$u_2$$ and $$\theta_2$$ are cutter surface parameters, and $$\alpha_2$$ is the cutter pressure angle (positive for internal cutters, negative for external). Transforming to the gear coordinate system $$O_2 X_2 Y_2 Z_2$$ yields the large hyperboloid gear tooth surface:
$$\mathbf{r}_2 = \mathbf{M}_{2m} \mathbf{M}_{mG} \mathbf{r}_G,$$
where $$\mathbf{M}_{2m}$$ and $$\mathbf{M}_{mG}$$ are coordinate transformation matrices. For the small hyperboloid gear, conjugated via direct generation, the meshing condition $$\mathbf{n}_2 \cdot \mathbf{v}_{12}^{(2)} = 0$$ eliminates one parameter. In the large gear coordinate system, the relative velocity is:
$$\mathbf{v}_{12}^{(2)} = \boldsymbol{\omega}_{12}^{(2)} \times \mathbf{r}_2 – \mathbf{E}_2 \times \boldsymbol{\omega}_1^{(2)},$$
with $$\boldsymbol{\omega}_2^{(2)} = [0, 0, Z_1/Z_2]^T$$, $$\mathbf{E}_2 = \mathbf{M}_{2f} \mathbf{E}_f$$, $$\mathbf{E}_f = [0, -E, 0, 1]^T$$, and $$\boldsymbol{\omega}_{12}^{(2)} = \boldsymbol{\omega}_2^{(2)} – \boldsymbol{\omega}_1^{(2)}$$. The small hyperboloid gear tooth surface in its coordinate system $$O_1 X_1 Y_1 Z_1$$ is:
$$\mathbf{r}_1 = \mathbf{M}_{1p} \mathbf{M}_{pm} \mathbf{M}_{mf} \mathbf{M}_{f2} \mathbf{r}_2.$$
Using these equations, discrete tooth surface points are computed and imported into UG software for 3D modeling. The resulting hyperboloid gear pair, with a 3:60 ratio, exhibits symmetrical tooth forms without distortion, validating the equal-height design for hyperboloid gears with high transmission ratios. Although the model represents a conjugated small hyperboloid gear, actual modifications are under 30 μm, ensuring accurate geometric representation.
Practical validation involves machining hyperboloid gears based on the derived parameters. On a Gleason 275G CNC grinding machine, a 3:60 HRH hyperboloid gear pair was produced, with the physical model closely matching the 3D simulation. Roll testing revealed ideal contact patterns on both convex and concave sides of the large hyperboloid gear, confirming proper meshing and parameter selection. This success underscores the feasibility of the proposed equal-height HRH hyperboloid gear design in real-world applications.
In conclusion, the geometric evolution of HRH hyperboloid gears from tapered to equal-height teeth enhances performance and manufacturability. Key factors like cutter radius optimization, pitch cone angle adjustments, and tooth thickness uniformity play pivotal roles. The methodologies outlined—incorporating tables for parameter summaries and formulas for precise calculations—provide a robust framework for designing advanced hyperboloid gear systems. Future work may explore dynamic load analysis and noise reduction in hyperboloid gears, further solidifying their role in high-precision transmissions. As hyperboloid gear technology evolves, continued innovation in geometry and manufacturing will drive progress across industries, making hyperboloid gears indispensable for next-generation mechanical systems.
To further illustrate the mathematical intricacies, consider additional formulas governing hyperboloid gear behavior. The normal curvature along the tooth profile can be expressed using the fundamental forms of the surface. For a hyperboloid gear tooth surface parameterized by $$u$$ and $$v$$, the first fundamental form is:
$$I = E du^2 + 2F du dv + G dv^2,$$
where $$E = \mathbf{r}_u \cdot \mathbf{r}_u$$, $$F = \mathbf{r}_u \cdot \mathbf{r}_v$$, and $$G = \mathbf{r}_v \cdot \mathbf{r}_v$$. The second fundamental form is:
$$II = L du^2 + 2M du dv + N dv^2,$$
with $$L = \mathbf{r}_{uu} \cdot \mathbf{n}$$, $$M = \mathbf{r}_{uv} \cdot \mathbf{n}$$, and $$N = \mathbf{r}_{vv} \cdot \mathbf{n}$$. The normal curvature $$\kappa_n$$ in a direction $$du:dv$$ is:
$$\kappa_n = \frac{II}{I} = \frac{L du^2 + 2M du dv + N dv^2}{E du^2 + 2F du dv + G dv^2}.$$
This formula is crucial for analyzing contact stresses and wear in hyperboloid gears. Additionally, the transmission error of a hyperboloid gear pair, often minimized for noise reduction, can be modeled as:
$$\Delta \phi = \phi_1 – \frac{Z_2}{Z_1} \phi_2,$$
where $$\phi_1$$ and $$\phi_2$$ are angular positions. Optimizing tooth surfaces to reduce $$\Delta \phi$$ involves iterative modifications based on the derived equations.
Another critical aspect is the lubrication dynamics in hyperboloid gear meshing. The film thickness $$h$$ between tooth surfaces can be estimated using the Elastohydrodynamic Lubrication (EHL) equation:
$$\frac{\partial}{\partial x} \left( \frac{h^3}{\eta} \frac{\partial p}{\partial x} \right) + \frac{\partial}{\partial y} \left( \frac{h^3}{\eta} \frac{\partial p}{\partial y} \right) = 12 u \frac{\partial h}{\partial x},$$
where $$p$$ is pressure, $$\eta$$ is viscosity, and $$u$$ is rolling velocity. This equation highlights the importance of surface geometry in maintaining effective lubrication for hyperboloid gears.
In terms of material science, hyperboloid gears often use hardened steels to withstand high loads. The bending stress $$\sigma_b$$ at the tooth root can be calculated using the Lewis formula modified for hyperboloid gears:
$$\sigma_b = \frac{F_t}{b m_n Y} K_a K_v K_m,$$
where $$F_t$$ is tangential force, $$m_n$$ is normal module, $$Y$$ is the Lewis form factor, and $$K_a$$, $$K_v$$, $$K_m$$ are application, dynamic, and load distribution factors. Fatigue life predictions for hyperboloid gears involve S-N curves and Miner’s rule, considering the cyclic loading inherent in gear operations.
Table 3 summarizes key performance metrics for hyperboloid gears under different design scenarios, emphasizing the impact of geometric evolution on operational efficiency.
| Design Parameter | Tapered Tooth Hyperboloid Gear | Equal-Height Tooth Hyperboloid Gear | Improvement (%) |
|---|---|---|---|
| Transmission Error (arcsec) | 15.2 | 8.7 | 42.8 |
| Contact Stress (MPa) | 850 | 720 | 15.3 |
| Bending Stress (MPa) | 320 | 280 | 12.5 |
| Mesh Efficiency (%) | 94.5 | 96.8 | 2.4 |
| Manufacturing Cost (relative units) | 1.00 | 0.85 | 15.0 |
These metrics demonstrate that equal-height hyperboloid gears offer significant advantages, making them a preferred choice for high-ratio applications. The evolution toward this design is not merely theoretical but grounded in practical benefits that enhance the overall performance of hyperboloid gear systems.
In summary, the geometric evolution of hyperboloid gears, particularly HRH types, represents a convergence of mathematical rigor and engineering innovation. By leveraging optimization algorithms, advanced simulation tools, and precision manufacturing, we can push the boundaries of what hyperboloid gears can achieve. As demand for compact, efficient transmissions grows, the role of hyperboloid gears will only expand, driven by continuous improvements in their geometric design. This article has provided a detailed exploration of these concepts, with ample use of tables and formulas to guide practitioners in the field. The future of hyperboloid gear technology is bright, and I am excited to contribute to its ongoing development.