
In my research, I set out to build a reliable mathematical description of herringbone gear tooth surfaces and to connect that description with practical measurement and error evaluation. Herringbone gears are formed by joining two helical gear halves that have the same helix angle but opposite hand. This arrangement preserves the smooth meshing action of helical gears while canceling the axial force that would otherwise be transmitted to the bearings. Although miter gears are often used for right-angle power transmission and miter gears have their own distinct geometry, herringbone gears remain the better choice for parallel-shaft, high-torque, heavy-load systems where axial force cancellation is important. My work therefore treats miter gears as a useful comparison point but concentrates on the involute cylindrical herringbone gear.
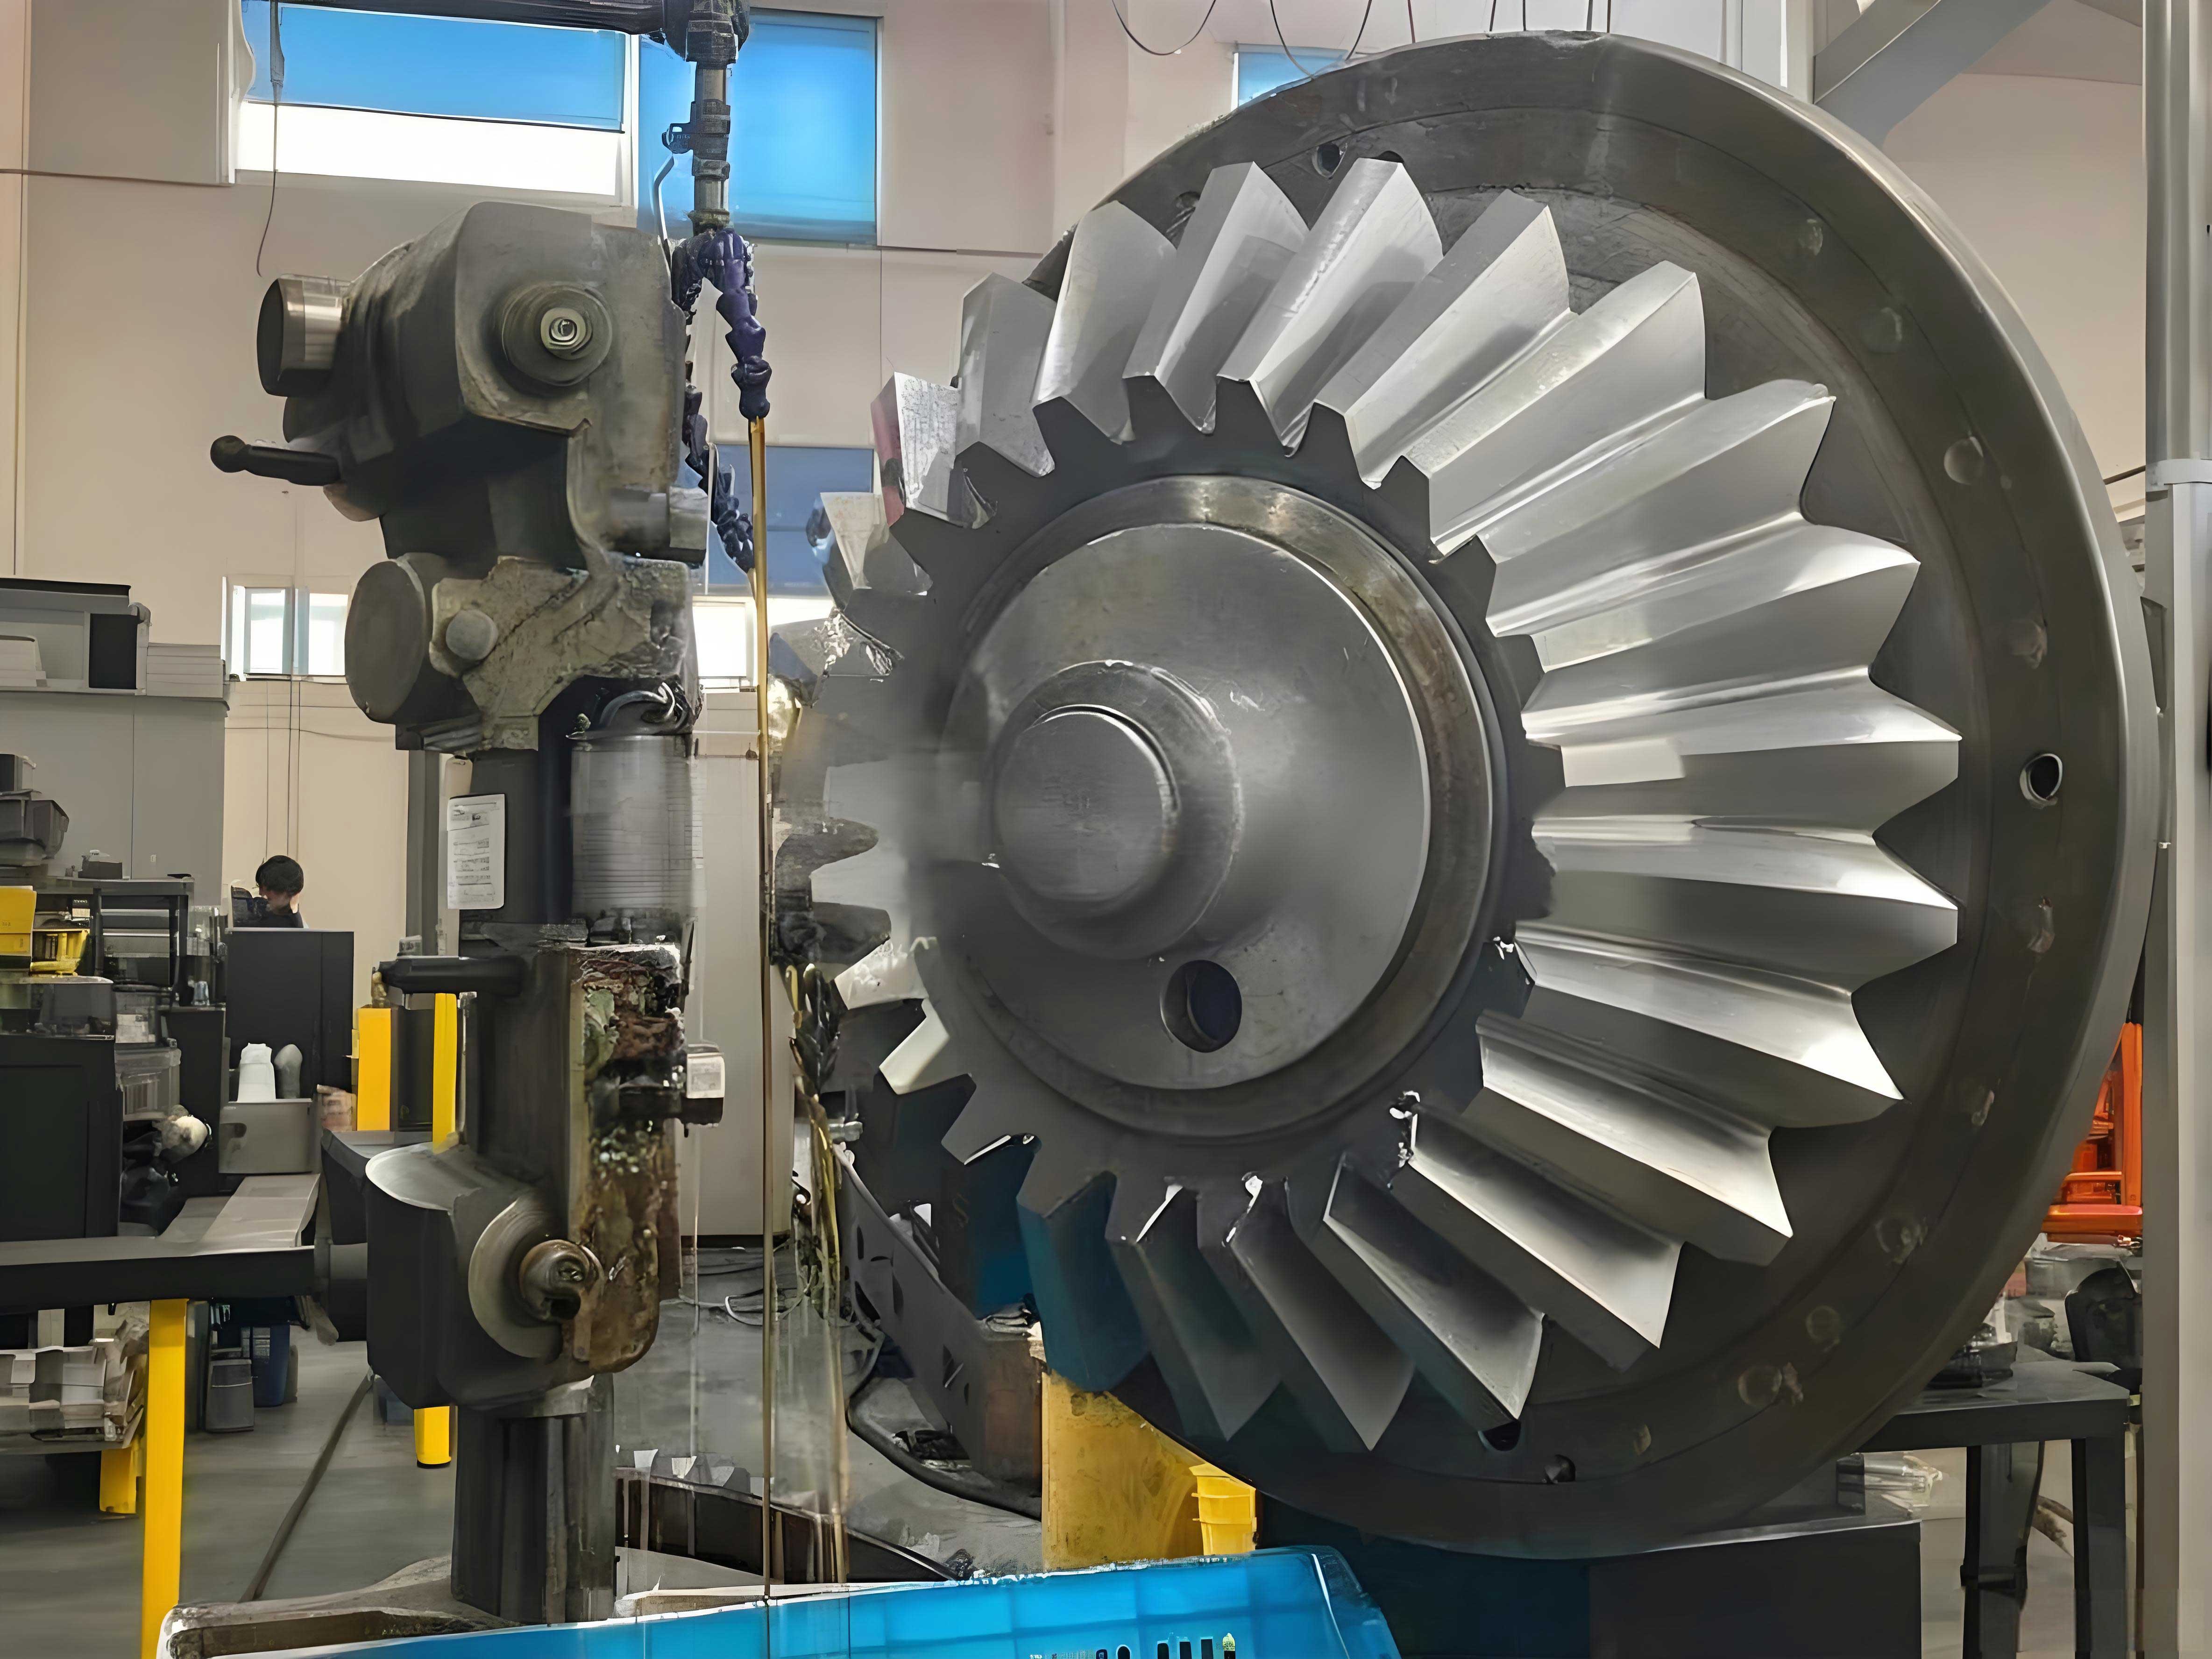
I began from the manufacturing principle of involute cylindrical gears. I established a spatial coordinate system, derived the right-hand tooth surface equation of a helical gear, reflected that surface to obtain the left-hand tooth surface, and finally combined the two opposite-hand halves into a complete herringbone gear model. I then used numerical programming to evaluate the equations and generate three-dimensional surface simulations. After that, I studied profile deviation, helix deviation, and pitch deviation according to established gear accuracy definitions. I derived practical formulas for each deviation and implemented evaluation software. Finally, I measured an actual herringbone gear on a coordinate measuring machine and processed the raw data. The measured deviations agreed with the expected theoretical behavior, which confirmed both the tooth surface model and the deviation calculation methods. I also imported the measurement data into the evaluation software, and the software results matched the manual calculations. This confirmed the feasibility of the evaluation system.
Basic Parameters and Their Relationships. A herringbone gear can be treated as two helical gears with equal normal module, equal tooth number, equal pressure angle, equal helix angle, and opposite hand. I used the normal plane as the reference plane for the basic parameters. The normal module, normal pressure angle, helix angle, tooth number, addendum coefficient, and clearance coefficient determine the remaining dimensions. In my model, the axial direction of the gear is the Z axis, the dividing plane between the left-hand and right-hand halves is the XOY plane, and the center of the base cylinder is the origin. This coordinate choice makes the herringbone symmetry especially simple because the two halves are mirror images across the XOY plane. Miter gears, by contrast, are usually described in a bevel gear coordinate system because miter gears operate on intersecting axes. That difference is one reason why my herringbone gear formulation cannot be replaced directly by a miter gears formulation.
The main parameter relations I used are summarized below.
| Name | Symbol | Formula |
|---|---|---|
| Normal module | \(m_n\) | Standard value |
| Transverse module | \(m_t\) | \(m_t = m_n / \cos\beta\) |
| Normal pressure angle | \(\alpha_n\) | Standard value, often \(20^\circ\) or \(22.5^\circ\) |
| Transverse pressure angle | \(\alpha_t\) | \(\tan\alpha_t = \tan\alpha_n / \cos\beta\) |
| Pitch diameter | \(d\) | \(d = m_t z\) |
| Base diameter | \(d_b\) | \(d_b = d \cos\alpha_t\) |
| Base helix angle | \(\beta_b\) | \(\tan\beta_b = \tan\beta \cos\alpha_t\) |
| Addendum | \(h_a\) | \(h_a = h_{an}^* m_n\) |
| Dedendum | \(h_f\) | \(h_f = (h_{an}^* + c_n^*)m_n\) |
| Tip diameter | \(d_a\) | \(d_a = d + 2h_a\) |
| Root diameter | \(d_f\) | \(d_f = d – 2h_f\) |
| Transverse pitch | \(p_t\) | \(p_t = \pi m_t\) |
| Normal pitch | \(p_n\) | \(p_n = \pi m_n\) |
For the herringbone gear I studied, the key numerical parameters are listed in the following table.
| Parameter | Symbol | Value |
|---|---|---|
| Normal module | \(m_n\) | 3.456811 mm |
| Number of teeth | \(z\) | 19 |
| Addendum coefficient | \(h_{an}^*\) | 1.0 |
| Clearance coefficient | \(c_n^*\) | 0.25 |
| Helix angle | \(\beta\) | \(16.6772^\circ\) |
| Normal pressure angle | \(\alpha_n\) | \(22.5^\circ\) |
| Face width | \(b\) | 60 mm |
Involute Geometry and Right-Hand Tooth Surface. The involute profile is generated by a straight line rolling without slipping on a base circle. If the base radius is \(r_b\), the radius to an arbitrary involute point is \(r_k\), and the pressure angle at that point is \(\alpha_k\), then
$$r_k = \frac{r_b}{\cos\alpha_k}.$$
The involute angle, also called the involute function, is
$$\theta_k = \tan\alpha_k – \alpha_k = \mathrm{inv}\,\alpha_k.$$
If I let \(\phi_k\) be the roll angle of the generating line, then
$$\phi_k = \theta_k + \alpha_k.$$
In the transverse plane, the involute can be written in rectangular coordinates as
$$x_k = r_b\left(\cos\phi_k + \phi_k\sin\phi_k\right),$$
$$y_k = r_b\left(\sin\phi_k – \phi_k\cos\phi_k\right).$$
For a helical gear, the involute profile is translated along a helix as the axial coordinate changes. If the axial position is represented by the helix rotation angle \(\theta_z\), then the right-hand tooth surface of the first tooth can be expressed as
$$X_{R1jz} = r_b\left[\cos\left(\phi_{R1j}+\theta_z\right)+\phi_{R1j}\sin\left(\phi_{R1j}+\theta_z\right)\right],$$
$$Y_{R1jz} = r_b\left[\sin\left(\phi_{R1j}+\theta_z\right)-\phi_{R1j}\cos\left(\phi_{R1j}+\theta_z\right)\right],$$
$$Z_{R1jz} = r_b \theta_z \cot\beta_b.$$
Here, \(j\) denotes the point index along the profile, \(R\) denotes the right-hand surface, and the subscript \(1\) denotes the first tooth. The axial coordinate is directly coupled to the helix rotation through the base helix angle \(\beta_b\). This equation is the foundation for my herringbone gear model. I also note that miter gears do not use this cylindrical involute helicoid because miter gears are bevel gears; however, the same general idea of transforming a generating curve into a three-dimensional surface still applies when I compare different gear types.
Left-Hand Tooth Surface by Reflection. The left-hand tooth surface is the mirror image of the right-hand surface with respect to a symmetry line in the transverse plane. If the symmetry line is \(y = kx\), then the reflection matrix is
$$V = \begin{bmatrix}
\dfrac{1-k^2}{1+k^2} & \dfrac{2k}{1+k^2} & 0\\[6pt]
\dfrac{2k}{1+k^2} & \dfrac{k^2-1}{1+k^2} & 0\\[6pt]
0 & 0 & 1
\end{bmatrix}.$$
The left-hand point on the first tooth is therefore
$$P_{L1jz} = V P_{R1jz},$$
where
$$P_{R1jz} = \begin{bmatrix}X_{R1jz}\\Y_{R1jz}\\Z_{R1jz}\end{bmatrix}, \qquad
P_{L1jz} = \begin{bmatrix}X_{L1jz}\\Y_{L1jz}\\Z_{L1jz}\end{bmatrix}.$$
The slope \(k\) is determined by the angular position of the tooth symmetry line. If \(\alpha_f\) is the pressure angle at the reference circle and \(\phi_f\) is the corresponding involute angle, then the symmetry line can be expressed through a relation of the form
$$k = -\tan\left(\phi_f+\alpha_f\right).$$
This reflection step is important because it guarantees that the left and right flanks of a single tooth remain geometrically consistent. In my herringbone gear model, this consistency is maintained across the entire face width.
Tooth Indexing and Full Herringbone Assembly. To generate the \(i\)-th tooth from the first tooth, I rotate the first tooth about the Z axis by the indexing angle
$$\theta_i = \frac{2\pi(i-1)}{z_0}, \qquad i = 1,2,3,\ldots,z_0,$$
where \(z_0\) is the total number of teeth. The rotation matrix about the Z axis is
$$A_z(\theta) = \begin{bmatrix}
\cos\theta & -\sin\theta & 0\\
\sin\theta & \cos\theta & 0\\
0 & 0 & 1
\end{bmatrix}.$$
Thus, the right-hand point of the \(i\)-th tooth is
$$P_{Rijz} = A_z(\theta_i) P_{R1jz},$$
and the left-hand point is
$$P_{Lijz} = A_z(\theta_i) P_{L1jz}.$$
For a herringbone gear, the two halves have opposite hand. If the positive-Z half is right-handed, then the negative-Z half is obtained by mirroring across the XOY plane. The mirror matrix is
$$M_{xy} = \begin{bmatrix}
1 & 0 & 0\\
0 & 1 & 0\\
0 & 0 & -1
\end{bmatrix}.$$
Therefore, a point on the opposite half is
$$P_{R1j}^{(-)} = M_{xy} P_{R1j}^{(+)},$$
and the complete herringbone tooth surface is formed by combining the positive-Z and negative-Z surfaces. This construction avoids the need to derive a separate equation for the opposite hand and ensures that the herringbone gear has continuous meshing geometry. I found this approach particularly useful because miter gears often require a different assembly logic, while herringbone gears can be assembled from two mirrored helical surfaces.
Numerical Simulation of the Tooth Surface. I implemented the derived equations in a numerical programming environment. The simulation procedure was as follows. First, I defined the basic gear parameters. Second, I computed the transverse module, transverse pressure angle, pitch diameter, base diameter, tip diameter, and root diameter. Third, I determined the roll angle range of the involute from the base circle to the tip circle. Fourth, I determined the helix rotation range from the face width and base helix angle. Fifth, I evaluated the tooth surface equations over a two-dimensional grid of profile points and axial points. Sixth, I plotted the resulting surface as a three-dimensional mesh. I repeated this process for the right-hand surface, the left-hand surface, the positive-Z half, and the negative-Z half.
| Step | Operation | Output |
|---|---|---|
| 1 | Define basic parameters | \(m_n\), \(z\), \(\alpha_n\), \(\beta\), \(h_{an}^*\), \(c_n^*\) |
| 2 | Compute derived parameters | \(m_t\), \(\alpha_t\), \(d\), \(d_b\), \(d_a\), \(d_f\) |
| 3 | Set involute range | \(\phi\) from base to tip |
| 4 | Set helix range | \(\theta_z\) from \(-\theta_{z,\max}\) to \(+\theta_{z,\max}\) |
| 5 | Evaluate surface equations | \((X,Y,Z)\) point cloud |
| 6 | Plot surface | Three-dimensional mesh |
When I visualized the first tooth, I could clearly see the involute profile in the transverse plane and the helical sweep in the axial direction. The left and right flanks met correctly at the tooth tip and root regions. After mirroring the positive-Z half across the XOY plane, the characteristic herringbone shape appeared. The full gear was obtained by circular arraying the single tooth. This simulation gave me confidence that the mathematical model was correct before I moved to measurement. Although miter gears have a different appearance and a different axis arrangement, the same digital workflow of parameter definition, surface generation, and mesh plotting can be applied to miter gears as well.
Error Analysis: Profile Deviation. Profile deviation describes the departure of the actual transverse tooth profile from the design profile. It is evaluated in the transverse plane and normal to the involute profile. The total profile deviation \(f_\alpha\) is the normal distance between two design profiles that just enclose the actual profile over the profile evaluation range. Profile deviation can be separated into profile form deviation and profile slope deviation, but the total profile deviation is the essential inspection item. In my work, I used the involute sliding method to compute the total profile deviation.
Suppose a measured point on the right flank is \(P_i(x_i,y_i)\). Its radius is
$$r_i = \sqrt{x_i^2+y_i^2}.$$
The pressure angle at that point is
$$\alpha_i = \arccos\left(\frac{r_b}{r_i}\right).$$
The angular position of the point is
$$\phi_i = \arctan\left(\frac{y_i}{x_i}\right).$$
For a right-hand flank, I define
$$\omega_i = \phi_i – \left(\tan\alpha_i-\alpha_i\right).$$
For a left-hand flank, the sign convention is reversed:
$$\omega_i = \left(\tan\alpha_i-\alpha_i\right) – \phi_i.$$
If the profile is perfect, \(\omega_i\) is constant. Any variation in \(\omega_i\) indicates profile deviation. Therefore, the total profile deviation is
$$f_\alpha = r_b \cos\beta_b \left[\max(\omega_i)-\min(\omega_i)\right].$$
If the maximum occurs at point \(P_1\) and the minimum occurs at point \(P_2\), then the expanded form is
$$f_\alpha = r_b \cos\beta_b \left|
\left[\arctan\left(\frac{y_1}{x_1}\right)-\left(\tan\alpha_1-\alpha_1\right)\right]
–
\left[\arctan\left(\frac{y_2}{x_2}\right)-\left(\tan\alpha_2-\alpha_2\right)\right]
\right|.$$
For a gear with \(m\) measured teeth, the gear-level profile total deviation is
$$F_\alpha = \max\left(f_{\alpha,1},f_{\alpha,2},\ldots,f_{\alpha,m}\right).$$
I applied these formulas to the measured profile points and obtained the profile deviations for each measured tooth. The results are given in the data-processing section below. This calculation method is robust because it only requires the measured coordinates and the base radius. It does not require the actual profile to be fitted to an arbitrary curve, which makes it suitable for herringbone gears and also for miter gears when a transverse profile is available.
Error Analysis: Helix Deviation. Helix deviation describes the departure of the actual helix from the design helix along the face width. It is evaluated in the transverse plane and reflects the accuracy of the tooth trace direction. For a herringbone gear, each tooth has two opposite-hand helical traces, so the helix deviation must be evaluated on both halves. The total helix deviation \(f_\beta\) is the distance between two design helices that enclose the actual helix over the evaluation range. Helix deviation can be split into form deviation and slope deviation, but the total helix deviation is the primary inspection item.
During measurement, the probe ideally contacts the tooth surface near the reference circle. The probe-center trajectory is parallel to the intersection of the tooth surface with the reference cylinder, provided that profile deviation is neglected. Therefore, I can use the probe-center coordinates directly to compute helix deviation. For two consecutive measured points \(P_{i-1}\) and \(P_i\), the angular difference is
$$\Delta\theta_i = \theta_i – \theta_{i-1}, \qquad \theta_i = \arctan\left(\frac{y_i}{x_i}\right).$$
The corresponding arc length on the reference cylinder is
$$\Delta W_i = r \Delta\theta_i.$$
The theoretical arc length for the same axial increment is
$$\Delta W_{ti} = \Delta Z_i \tan\beta, \qquad \Delta Z_i = Z_i – Z_{i-1}.$$
The local helix deviation is therefore
$$f_i = \cos\beta\left(\Delta W_i – \Delta W_{ti}\right).$$
If the local deviations have both positive and negative signs, the total helix deviation is
$$f_\beta = \max(f_i) – \min(f_i).$$
If all local deviations have the same sign, the total helix deviation is
$$f_\beta = \max\left(|f_i|\right).$$
For \(m\) measured teeth, the gear-level helix total deviation is
$$F_\beta = \max\left(f_{\beta,1},f_{\beta,2},\ldots,f_{\beta,m}\right).$$
This method is numerically simple and directly reflects the axial and angular errors of the measured helix. It is also applicable to miter gears if the reference cone and the corresponding axial coordinate are properly defined, but for miter gears the helix description is different because miter gears are bevel gears rather than cylindrical gears.
Error Analysis: Pitch Deviation. Single pitch deviation \(f_{pt}\) is the difference between the actual pitch and the theoretical pitch on the reference circle in the transverse plane. Cumulative pitch deviation \(F_{pk}\) is the algebraic difference between the actual arc length and the theoretical arc length over any \(k\) pitches. The total cumulative pitch deviation \(F_p\) is the algebraic difference between the maximum and minimum cumulative pitch deviations over the entire gear. These quantities are important because they describe the uniformity of tooth spacing and therefore affect motion accuracy and transmission smoothness.
To compute pitch deviation from measured coordinates, I first find the intersection of the measured involute with the reference circle. For a measured point \(P_i(x_i,y_i)\), the radius is
$$r_i = \sqrt{x_i^2+y_i^2}.$$
The pressure angle is
$$\alpha_i = \arccos\left(\frac{r_b}{r_i}\right).$$
The angular position is
$$\phi_i = \arccos\left(\frac{x_i}{r_i}\right).$$
The angular position of the involute intersection with the base circle is
$$\phi_{n,i} = \phi_i – \left(\tan\alpha_i-\alpha_i\right).$$
The angular position of the involute intersection with the reference circle is
$$\phi_{f,i} = \phi_{n,i} + \left(\tan\alpha_f-\alpha_f\right),$$
where \(\alpha_f\) is the reference pressure angle. For two adjacent teeth on the same side, the angular pitch is
$$\Phi = \phi_{f,2} – \phi_{f,1}.$$
The actual pitch is
$$P_t’ = r \Phi.$$
The theoretical pitch is
$$P_t = \pi m_t.$$
Therefore, the single pitch deviation is
$$f_{pt} = P_t’ – P_t = r\Phi – \pi m_t.$$
The expanded expression is
$$f_{pt} = r\left[
\arccos\left(\frac{x_2}{r_2}\right)
–
\left(\tan\alpha_2-\alpha_2\right)
+
\left(\tan\alpha_f-\alpha_f\right)
–
\arccos\left(\frac{x_1}{r_1}\right)
+
\left(\tan\alpha_1-\alpha_1\right)
–
\left(\tan\alpha_f-\alpha_f\right)
\right] – \pi m_t.$$
After computing all single pitch deviations, the cumulative pitch deviation is
$$F_{pk} = \sum_{i=1}^{k} f_{pt,i}.$$
The total cumulative pitch deviation is
$$F_p = \max\left(F_{pk}\right) – \min\left(F_{pk}\right).$$
For the left and right flanks separately, I obtained
$$F_{pL} = \max\left(f_{ptL}\right) – \min\left(f_{ptL}\right),$$
$$F_{pR} = \max\left(f_{ptR}\right) – \min\left(f_{ptR}\right).$$
The overall gear pitch total deviation is the larger of the two:
$$F_p = \max\left(F_{pL},F_{pR}\right).$$
This method is convenient because it converts arbitrary measured points on the involute into equivalent reference-circle intersections. It avoids the need to measure exactly on the reference circle, which is often difficult in practice. When I compare this with miter gears, the same principle can be adapted, but miter gears require a pitch cone reference rather than a pitch cylinder reference.
Software Design for Tooth Surface Calculation and Error Evaluation. I developed a software system with two main functions: tooth surface calculation and error evaluation. The tooth surface calculation module accepts the basic gear parameters, computes the derived parameters, evaluates the tooth surface equations, and produces a three-dimensional mesh. The error evaluation module reads measured coordinate files and computes profile deviation, helix deviation, single pitch deviation, and cumulative pitch deviation. I used a graphical programming environment that allows user-friendly front panels and block-diagram programming. The software can call numerical scripts for the heavy mathematical calculations, so the user can change parameters without rewriting the core equations.
| Module | Input | Output | Main Function |
|---|---|---|---|
| Tooth surface modeling | \(m_n\), \(z\), \(\alpha_n\), \(\beta\), \(b\) | Point coordinates and 3D surface | Evaluate involute helicoid equations |
| Profile deviation | Profile point coordinates | \(f_\alpha\), \(F_\alpha\) | Involute sliding method |
| Helix deviation | Helix point coordinates | \(f_\beta\), \(F_\beta\) | Arc-length comparison along face width |
| Pitch deviation | Pitch point coordinates | \(f_{pt}\), \(F_p\) | Reference-circle intersection method |
In the tooth surface modeling interface, the user enters the normal module, tooth number, helix angle, pressure angle, addendum coefficient, clearance coefficient, and face width. The software then calculates the transverse module, transverse pressure angle, pitch diameter, base diameter, tip diameter, root diameter, and other quantities. The user can select either a single-tooth view or a full-gear view. The calculated coordinates can be exported to a table. I found this especially useful because it allows a quick check of the herringbone gear geometry before manufacturing or measurement. Miter gears would need a different parameter input set, but the interface design principle is the same.
In the error evaluation interface, the user selects the deviation type. For profile deviation, the software reads the measured profile points, computes the radius, pressure angle, angular position, and \(\omega_i\) for each point, and then reports the maximum and minimum values. For helix deviation, the software reads the helix points, computes the angular increments, arc lengths, theoretical arc lengths, and local deviations, and then reports the total helix deviation. For pitch deviation, the software reads the pitch points, computes the reference-circle intersection angles, actual pitch, theoretical pitch, and single pitch deviations, and then reports the cumulative pitch deviation. The software displays the results in tables and charts, which makes the deviation trend easy to interpret.
Coordinate Measuring Machine Measurement Method. I used a bridge-type coordinate measuring machine with a ruby stylus to measure the herringbone gear. The machine has three orthogonal linear axes, and its electronic system records the stylus center coordinates through grating scales. When the stylus contacts the tooth surface, the measuring software compensates for the stylus radius along the approach direction. Therefore, the recorded coordinates can be treated as points on the actual tooth surface. I fixed the gear on the machine table so that the gear end face was parallel to the table. I then established a workpiece coordinate system. I took three points on the upper end face to define the XOY plane. I took three points on the inner bore to define the Z axis. I then selected a tooth and took two points on its left and right flanks to define the X axis. The Y axis was perpendicular to both X and Z. This coordinate system allowed the measuring software to automatically follow the nominal tooth geometry.
| Measurement Task | Reference Geometry | Probe Path | Evaluation Range |
|---|---|---|---|
| Profile deviation | Transverse plane | Along involute from base to tip | Exclude 13% at each end of profile evaluation range |
| Helix deviation | Reference cylinder | Along helix across face width | Exclude 5% at each end of face width |
| Pitch deviation | Transverse plane | Alternate left and right flanks | Same axial section for all teeth |
For profile measurement, I measured four teeth evenly distributed around the circumference. On each measured flank, I took five points along the involute from the base circle toward the tip circle. The Z coordinate of all points on a given profile was held constant. For helix measurement, I measured the same four teeth on both the left and right flanks. On each helix, I took five points from the XOY plane toward the lower end face. The axial coordinates of these points were uniformly spaced. For pitch measurement, I measured all teeth on both flanks in a transverse section perpendicular to the Z axis. For each tooth, I recorded one point on the left flank and one point on the right flank. The measured points were then used to compute the three deviation types.
Profile Measurement Data and Processing. The raw profile measurement data for four representative teeth are shown below. The coordinates are in millimeters. The data include both left and right flanks. I used these points to compute the profile deviations according to the involute sliding method.
| Tooth | Point | \(X\) (mm) | \(Y\) (mm) | \(\phi_i\) (rad) | \(\omega_i\) (rad) | \(f_\alpha\) (mm) |
|---|---|---|---|---|---|---|
| 1 left | 1 | 32.1436 | 3.0128 | 1.4773 | 1.4734 | 0.0139 |
| 1 left | 2 | 33.3346 | 2.7680 | 1.4879 | 1.4734 | 0.0139 |
| 1 left | 3 | 34.5112 | 2.3989 | 1.5014 | 1.4731 | 0.0139 |
| 1 left | 4 | 35.6879 | 1.9035 | 1.5175 | 1.4730 | 0.0139 |
| 1 left | 5 | 36.8559 | 1.2953 | 1.5357 | 1.4731 | 0.0139 |
| 1 right | 1 | 31.9313 | -4.7107 | -1.4243 | -1.4205 | 0.0157 |
| 1 right | 2 | 33.1312 | -4.5197 | -1.4352 | -1.4208 | 0.0157 |
| 1 right | 3 | 34.3294 | -4.2110 | -1.4487 | -1.4205 | 0.0157 |
| 1 right | 4 | 35.5334 | -3.7736 | -1.4650 | -1.4205 | 0.0157 |
| 1 right | 5 | 36.7355 | -3.2377 | -1.4829 | -1.4203 | 0.0157 |
| 4 left | 1 | -5.6283 | 31.7911 | -0.1752 | -0.1791 | 0.0174 |
| 4 left | 2 | -5.4898 | 32.9902 | -0.1649 | -0.1794 | 0.0174 |
| 4 left | 3 | -5.2167 | 34.1941 | -0.1514 | -0.1796 | 0.0174 |
| 4 left | 4 | -4.8191 | 35.4059 | -0.1353 | -0.1797 | 0.0174 |
| 4 left | 5 | -4.3066 | 36.6160 | -0.1171 | -0.1795 | 0.0174 |
| 4 right | 1 | 2.0721 | 32.2061 | 0.0643 | 0.0681 | 0.0081 |
| 4 right | 2 | 1.7852 | 33.3906 | 0.0534 | 0.0678 | 0.0081 |
| 4 right | 3 | 1.3681 | 34.5670 | 0.0396 | 0.0679 | 0.0081 |
| 4 right | 4 | 0.8391 | 35.7239 | 0.0235 | 0.0679 | 0.0081 |
| 4 right | 5 | 0.1977 | 36.8827 | 0.0054 | 0.0680 | 0.0081 |
The maximum profile deviation among the measured teeth was 0.0174 mm, and the minimum was 0.0081 mm. Therefore, the gear-level profile total deviation was
$$F_\alpha = \max\left(f_{\alpha,1},f_{\alpha,2},\ldots,f_{\alpha,8}\right) = 0.0174\ \text{mm}.$$
When I plotted the measured points together with the theoretical profile, the measured points fell very close to the theoretical involute curve. This confirmed that the mathematical model reproduced the actual tooth surface with good accuracy. The small deviations are consistent with manufacturing and setup errors. The same profile evaluation logic can be used for miter gears if a transverse profile is measured, but the reference geometry for miter gears is different.
Helix Measurement Data and Processing. The raw helix measurement data for four representative teeth are shown below. The coordinates are in millimeters. The Z coordinates are negative because the measured points lie below the XOY plane in the lower half of the herringbone gear.
| Tooth | Point | \(X\) (mm) | \(Y\) (mm) | \(Z\) (mm) | \(\theta_i\) (rad) | \(\Delta W_i\) (mm) | \(f_i\) (mm) |
|---|---|---|---|---|---|---|---|
| 1 right | 1 | 34.4913 | 0.6245 | -1.5005 | 0.0181 | 0 | 0 |
| 1 right | 2 | 34.4754 | 1.3504 | -3.9027 | 0.0392 | 0.7215 | 0.0024 |
| 1 right | 3 | 34.4401 | 2.0770 | -6.3024 | 0.0602 | 0.7228 | 0.0037 |
| 1 right | 4 | 34.3877 | 2.8002 | -8.7026 | 0.0813 | 0.7205 | 0.0014 |
| 1 right | 5 | 34.2921 | 3.5119 | -11.1013 | 0.1021 | 0.7132 | -0.0055 |
| 1 left | 1 | 33.9568 | -6.0122 | -1.5009 | -0.1752 | 0 | 0 |
| 1 left | 2 | 34.0888 | -5.3099 | -3.9042 | -0.1545 | 0.7101 | -0.0085 |
| 1 left | 3 | 34.1901 | -4.5981 | -6.3011 | -0.1337 | 0.7145 | -0.0043 |
| 1 left | 4 | 34.2786 | -3.8708 | -8.7024 | -0.1125 | 0.7292 | 0.0087 |
| 1 left | 5 | 34.3640 | -3.1484 | -11.1017 | -0.0914 | 0.7216 | 0.0036 |
| 4 right | 1 | -3.4461 | 34.3214 | -1.5005 | -1.4707 | 0 | 0 |
| 4 right | 2 | -4.1780 | 34.2447 | -3.8995 | -1.4494 | 0.7313 | 0.0118 |
| 4 right | 3 | -4.8882 | 34.1464 | -6.3027 | -1.4286 | 0.7125 | -0.0062 |
| 4 right | 4 | -5.6022 | 34.0393 | -8.7050 | -1.4077 | 0.7175 | -0.0014 |
| 4 right | 5 | -6.3180 | 33.9162 | -11.1027 | -1.3866 | 0.7218 | 0.0026 |
| 4 left | 1 | 3.2052 | 34.3493 | -1.5000 | 1.4778 | 0 | 0 |
| 4 left | 2 | 2.4912 | 34.4184 | -3.9023 | 1.4985 | 0.7127 | -0.0061 |
| 4 left | 3 | 1.7660 | 34.4607 | -6.3025 | 1.5196 | 0.7217 | 0.0026 |
| 4 left | 4 | 1.0382 | 34.4881 | -8.7038 | 1.5407 | 0.7236 | 0.0044 |
| 4 left | 5 | 0.3124 | 34.4936 | -11.0996 | 1.5617 | 0.7212 | 0.0021 |
The local helix deviations ranged from about \(-0.0085\) mm to \(0.0118\) mm. Therefore, the gear-level helix total deviation was
$$F_\beta = \max\left(f_{\beta,1},f_{\beta,2},\ldots,f_{\beta,8}\right) = 0.0180\ \text{mm}.$$
This result shows that the helix direction was well controlled. The deviations are small and mostly alternate in sign, which suggests that the main error source was local rather than a systematic slope error. In a miter gears application, helix deviation would be replaced by a corresponding tooth trace deviation on the pitch cone, but the same philosophy of comparing actual and theoretical arc lengths remains valid.
Pitch Measurement Data and Processing. The raw pitch measurement data for all teeth are shown below. The coordinates are in millimeters. For clarity, I list the left-flank points and right-flank points separately. The computed single pitch deviations are also included.
| Tooth | \(X\) left (mm) | \(Y\) left (mm) | \(\phi_{f}\) left (rad) | \(P_t’\) left (mm) | \(f_{pt}\) left (mm) |
|---|---|---|---|---|---|
| 1 | -26.8138 | -21.7197 | 0 | 0 | 0 |
| 2 | -32.3976 | -11.8390 | 0.3305 | 11.3290 | -0.0078 |
| 3 | -34.4902 | -0.6886 | 0.3304 | 11.3263 | -0.0104 |
| 4 | -32.8544 | 10.5486 | 0.3306 | 11.3348 | -0.0020 |
| 5 | -27.6472 | 20.6407 | 0.3306 | 11.3346 | -0.0022 |
| 15 | 23.8328 | -24.9221 | 0.3306 | 11.3338 | -0.0030 |
| 16 | 14.4500 | -31.3094 | 0.3307 | 11.3357 | -0.0010 |
| 17 | 3.5014 | -34.3020 | 0.3307 | 11.3359 | -0.0008 |
| 18 | -7.8198 | -33.5809 | 0.3305 | 11.3301 | -0.0067 |
| 19 | -18.3097 | -29.2376 | 0.3307 | 11.3370 | 0.0002 |
| Tooth | \(X\) right (mm) | \(Y\) right (mm) | \(\phi_{f}\) right (rad) | \(P_t’\) right (mm) | \(f_{pt}\) right (mm) |
|---|---|---|---|---|---|
| 1 | -23.6017 | -25.1792 | 0 | 0 | 0 |
| 2 | -30.4838 | -16.1471 | 0.3306 | 11.3337 | -0.0031 |
| 3 | -34.0615 | -5.3844 | 0.3303 | 11.3245 | -0.0122 |
| 4 | -33.9658 | 5.9590 | 0.3305 | 11.3285 | -0.0082 |
| 5 | -30.1933 | 16.6553 | 0.3304 | 11.3271 | -0.0096 |
| 15 | 27.0354 | -21.4418 | 0.3308 | 11.3400 | 0.0032 |
| 16 | 18.6056 | -29.0588 | 0.3308 | 11.3393 | 0.0025 |
| 17 | 8.1604 | -33.5218 | 0.3307 | 11.3375 | 0.0007 |
| 18 | -3.1663 | -34.3588 | 0.3307 | 11.3369 | 0.0002 |
| 19 | -14.1507 | -31.4755 | 0.3306 | 11.3338 | -0.0030 |
From the left-flank data, the maximum single pitch deviation was 0.0151 mm and the minimum was -0.0104 mm. Therefore,
$$F_{pL} = 0.0151 – (-0.0104) = 0.0255\ \text{mm}.$$
From the right-flank data, the maximum single pitch deviation was 0.0141 mm and the minimum was -0.0122 mm. Therefore,
$$F_{pR} = 0.0141 – (-0.0122) = 0.0263\ \text{mm}.$$
The overall gear pitch total deviation was
$$F_p = \max\left(F_{pL},F_{pR}\right) = 0.0263\ \text{mm}.$$
The single pitch deviation curve shows a periodic variation around zero. This indicates that the tooth spacing was reasonably uniform. The cumulative pitch deviation was obtained by summing the single pitch deviations. The maximum cumulative value occurred near the middle of the tooth sequence, and the minimum occurred near the beginning. The total cumulative pitch deviation was 0.0263 mm. These results are consistent with a gear that has small but measurable manufacturing errors. When I compare these results with typical miter gears, the magnitude of the deviations is similar, but the reference geometry for miter gears would be a cone rather than a cylinder.
Software Validation with Measured Data. I imported the measured profile points into the profile deviation evaluation module. The software read the coordinate files, computed the radius, pressure angle, angular position, and \(\omega_i\), and displayed the profile deviation for each measured tooth. The maximum profile deviation reported by the software was 0.0174 mm, which matched the manual calculation. I then imported the helix measurement points into the helix deviation evaluation module. The software computed the angular increments, arc lengths, and local deviations, and reported a maximum helix deviation of 0.0180 mm, again matching the manual calculation. Finally, I imported the pitch measurement points into the pitch deviation evaluation module. The software computed the single pitch deviation for each tooth, plotted the deviation curve, and reported a cumulative pitch total deviation of 0.0263 mm. These results confirmed that the evaluation software was functioning correctly.
| Deviation Type | Manual Result | Software Result | Agreement |
|---|---|---|---|
| Profile total deviation \(F_\alpha\) | 0.0174 mm | 0.0174 mm | Exact |
| Helix total deviation \(F_\beta\) | 0.0180 mm | 0.0180 mm | Exact |
| Pitch total deviation \(F_p\) | 0.0263 mm | 0.0263 mm | Exact |
Discussion. The measurement results show that the herringbone gear model and the deviation calculation methods are mutually consistent. The profile deviations are small, the helix deviations are small, and the pitch deviations are within a narrow range. The theoretical tooth surface generated from the involute helicoid equations matched the measured points closely. This is important because it means that the mathematical model can be used for design, simulation, and inspection. It also means that the deviation formulas can be used to evaluate actual herringbone gears without fitting arbitrary curves. Although miter gears have a different geometry, the general approach of building a parametric surface model and then comparing measured points with the theoretical surface is also applicable to miter gears. For miter gears, however, the reference surfaces are cones, and the tooth trace is not a cylindrical helix. Therefore, separate equations are needed for miter gears. In my work, I focused on herringbone gears because they are widely used in heavy-duty and high-speed parallel-shaft transmissions.
The axial force cancellation of herringbone gears is a major advantage. In a single helical gear, the axial force must be carried by thrust bearings. In a herringbone gear, the two opposite-hand halves produce axial forces that cancel each other. This reduces bearing load and improves system reliability. Miter gears do not provide this particular advantage because miter gears transmit motion between intersecting shafts. Miter gears are valuable for right-angle drives, but they are not a replacement for herringbone gears in parallel-shaft applications. I therefore treat miter gears as a separate gear family and use them only as a comparison for measurement philosophy.
The software I developed has several practical benefits. First, it allows rapid parameter changes. Second, it produces a three-dimensional visualization of the herringbone gear tooth surface. Third, it reads measured coordinate files and computes deviations automatically. Fourth, it displays results in tables and charts. Fifth, it reduces the chance of manual calculation errors. The software is not limited to herringbone gears; with appropriate modifications, it could also be adapted to miter gears. For miter gears, the user would need to input cone distance, pitch cone angle, and face angle, and the tooth surface equations would be based on a bevel gear generation process rather than a cylindrical involute helicoid.
Measurement Uncertainty and Practical Considerations. In any coordinate measurement, several factors influence the result. The stylus radius compensation, probe approach direction, surface roughness, temperature, and workpiece fixturing all affect the measured coordinates. I reduced these effects by using a stable setup, by allowing the machine to compensate for the stylus radius, and by measuring in a controlled environment. I also used the same axial section for all pitch measurements, which ensures that the pitch deviation is not contaminated by helix deviation. For profile measurement, I kept the Z coordinate constant for each profile. For helix measurement, I distributed the points uniformly along the face width. These precautions improved the reliability of the data. The same precautions would be necessary for miter gears, but the fixturing and alignment of miter gears would require additional care because miter gears operate on intersecting axes.
| Error Source | Effect on Measurement | Control Method |
|---|---|---|
| Stylus radius | Offset of measured point | Software compensation along approach direction |
| Temperature | Thermal expansion | Controlled room temperature |
| Fixturing | Coordinate system error | Careful alignment with end face and bore |
| Surface roughness | Scatter of contact points | Multiple points and averaging |
| Probe approach | Directional error | Normal approach to the tooth surface |
Conclusion. I established a complete workflow for herringbone gear tooth surface modeling and measurement. I derived the involute equation, the helical right-hand tooth surface equation, the left-hand tooth surface equation through reflection, and the full herringbone assembly through indexing and mirroring. I evaluated the equations numerically and generated three-dimensional simulations. I then derived the formulas for profile deviation, helix deviation, single pitch deviation, and cumulative pitch deviation. I implemented these formulas in a graphical software environment and designed user interfaces for tooth surface calculation and error evaluation. I measured an actual herringbone gear on a coordinate measuring machine and processed the raw data. The measured profile total deviation was 0.0174 mm, the helix total deviation was 0.0180 mm, and the pitch total deviation was 0.0263 mm. The software results matched the manual calculations exactly. These findings confirm that the theoretical tooth surface model is accurate and that the deviation calculation methods are practical. The work also provides a foundation for further research on herringbone gear design, manufacturing, and inspection. Miter gears remain a separate and important gear category, and future work could extend the same modeling and measurement framework to miter gears by replacing the cylindrical involute helicoid with a suitable bevel gear generation model.
In my future work, I plan to improve the model in several ways. I will import the calculated tooth surface points into a solid modeling environment to create a precise solid model of the herringbone gear. I will perform virtual meshing and motion simulation to study contact patterns and transmission error. I will also investigate non-contact measurement methods for small-module gears, because a contact stylus may not easily reach the tooth surface in very small gears. Finally, I will extend the evaluation software to include more gear types, including miter gears, so that the same user-friendly framework can support a wider range of gear metrology tasks.