
In my research on involute conical worm gears, I have focused on developing a reliable manufacturing process that produces high-quality tooth surfaces with excellent transmission efficiency. The involute conical worm gear pair offers distinct advantages over traditional cylindrical worm gears: it is a developable surface, can be ground with a disc-type grinding wheel, the wheel dressing is simple, and both accuracy and efficiency are high. In this article, I present my systematic approach to machining, grinding, and assembly calculation for these special gear sets.
I begin with the basic processing method on a standard lathe, then derive the mathematical equations of the involute conical worm helical surface, propose a novel turning method using an axial cross-section profile, compute the grinding wheel profile for precision grinding, and finally determine the installation distance and the “high point” of the conical worm gear for proper meshing. Throughout the discussion, I emphasize the importance of worm gears in modern power transmission and the specific challenges posed by the conical geometry.
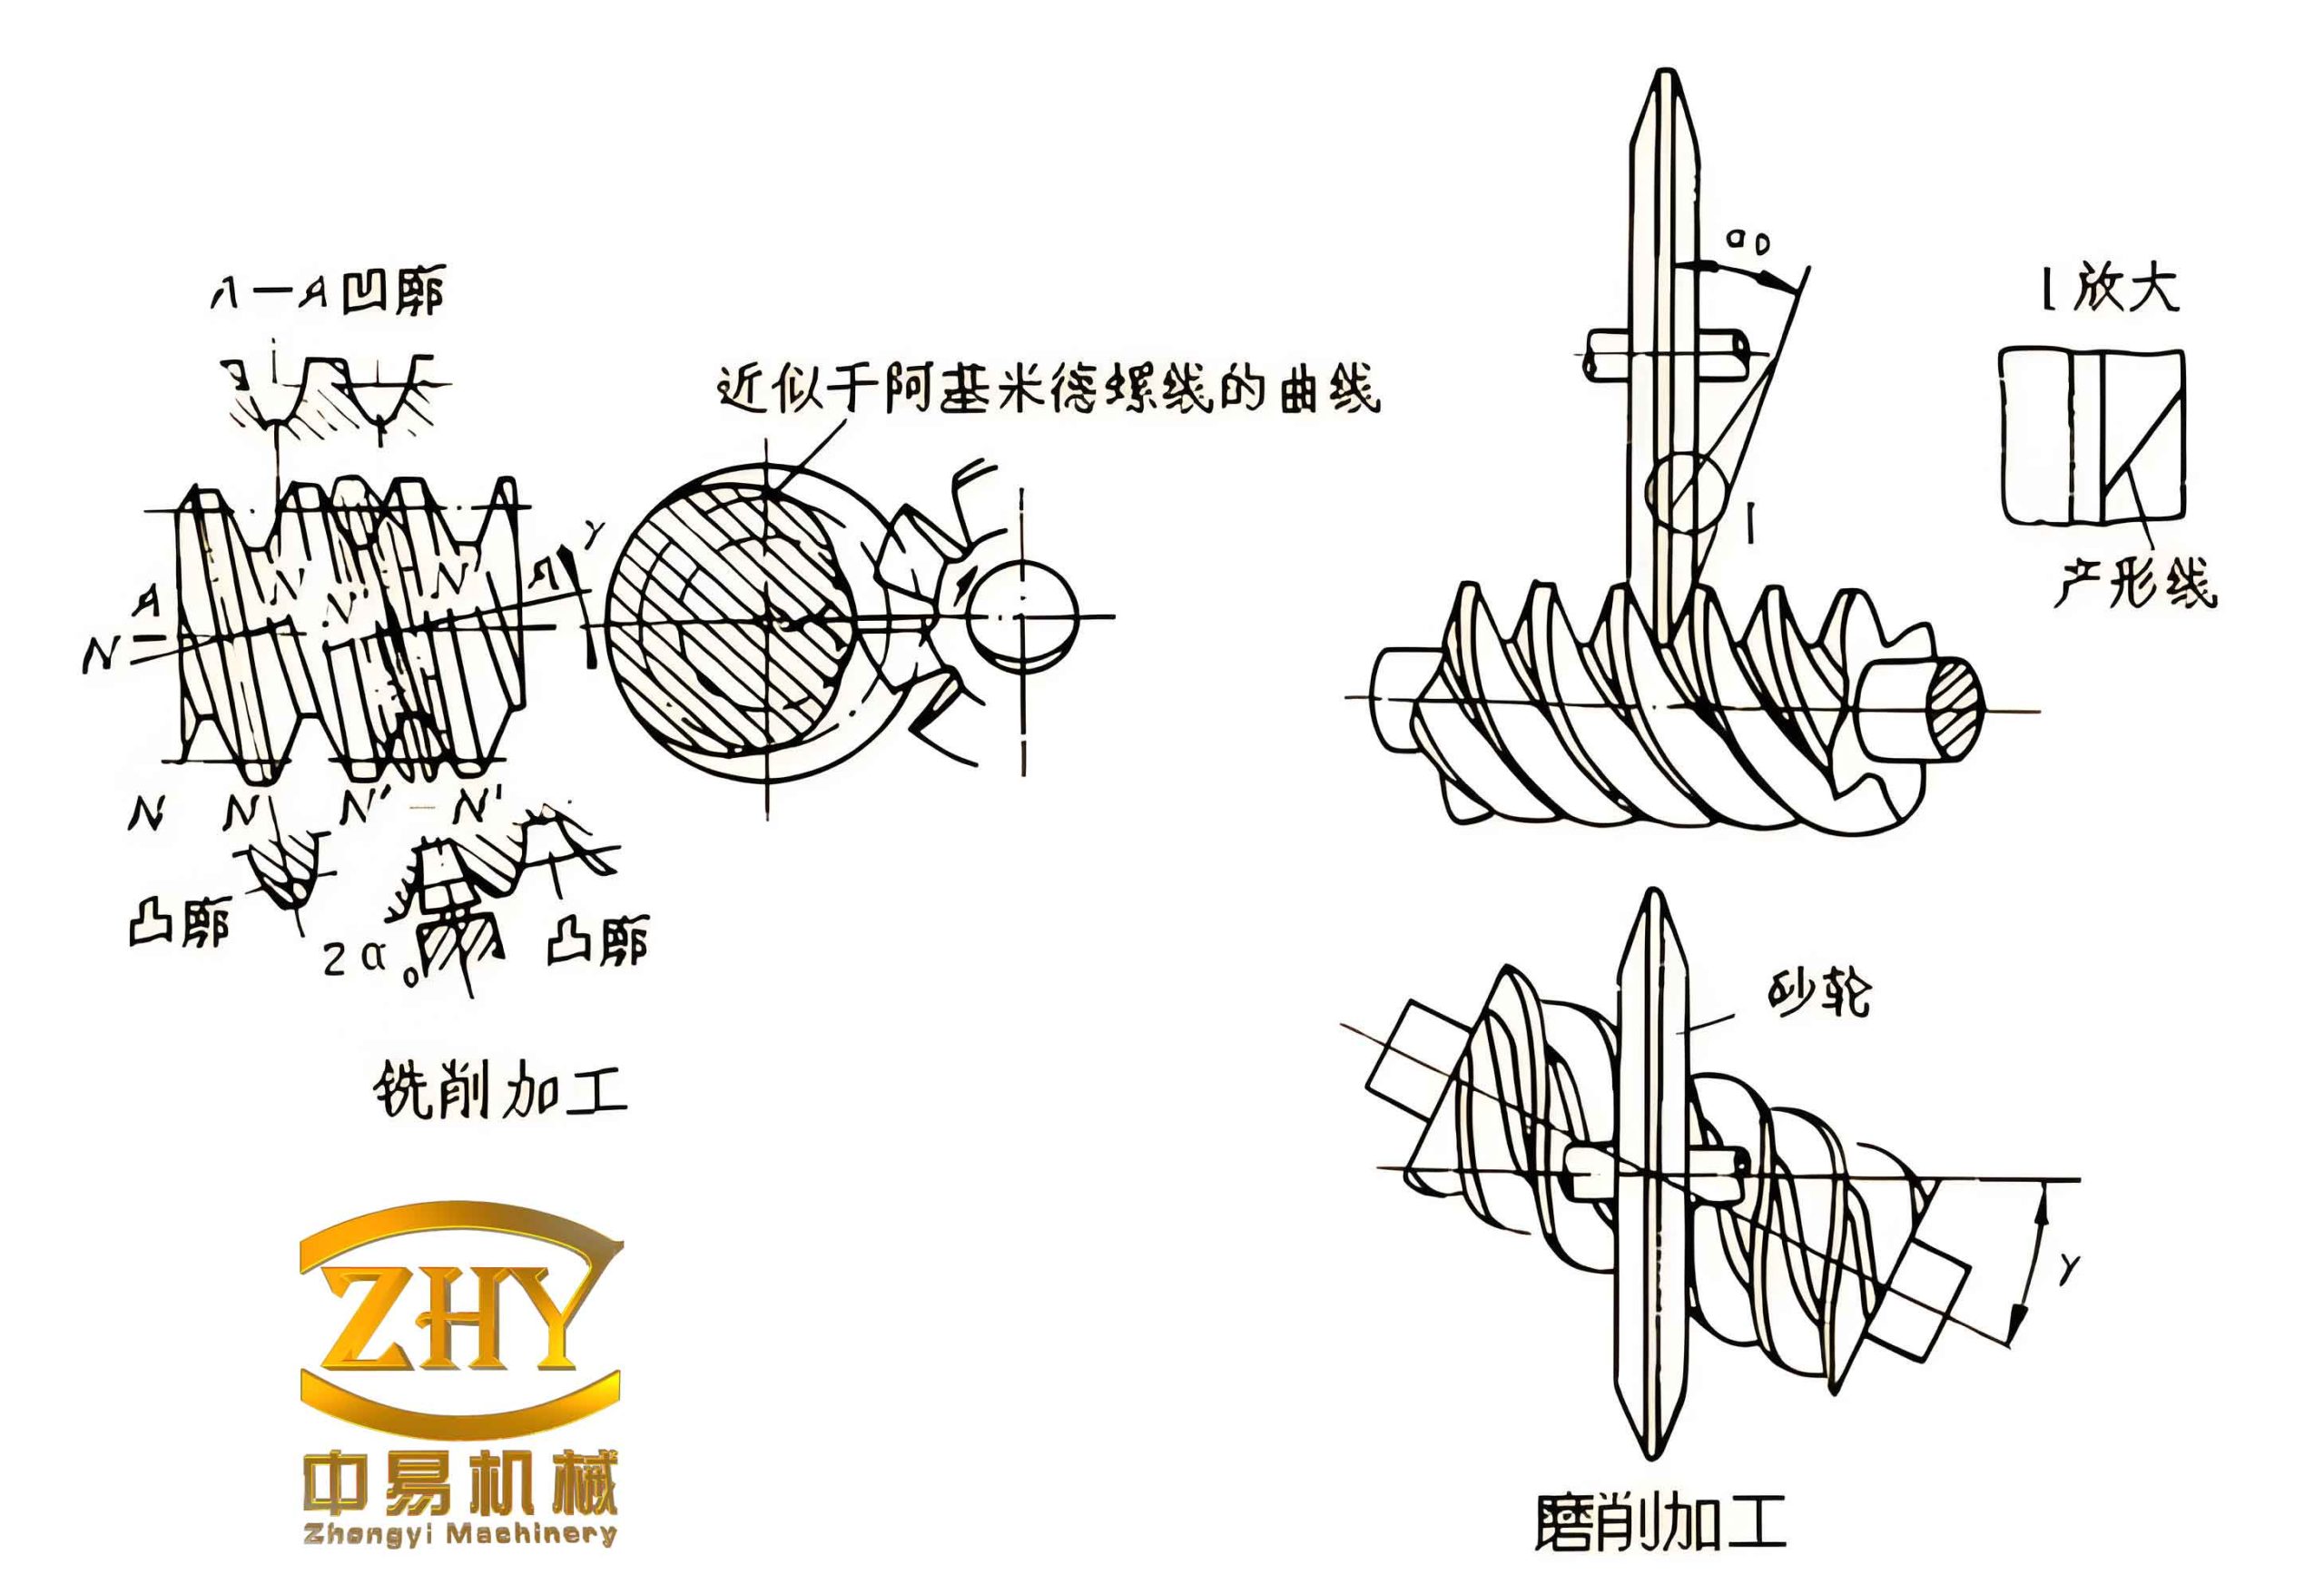
1. Turning the Involute Conical Worm on a Conventional Lathe
To machine the involute conical worm, I use a conventional lathe with a simple modification: a ball‑cage synchronous coupling (similar to a constant velocity joint) is installed between the spindle and the tailstock. This coupling ensures that the workpiece and the tool holder rotate synchronously. The tailstock is offset by a spacer so that the axis of the workpiece can be tilted by a small angle relative to the lathe bed. The cutting tool is a straight‑edged turning tool mounted on a tool post that can be swiveled to the required lead angle. The tool is fed along the inclined axis of the worm blank, producing the conical helix. This method is straightforward and does not require a special machine tool, making it accessible for small‑batch production of worm gears.
| Component | Function |
|---|---|
| Ball‑cage synchronous coupling | Ensures 1:1 rotation between spindle and tailstock |
| Tailstock spacer | Offsets the tailstock to create the conical angle |
| Straight‑edged turning tool | Cuts the involute helical profile |
| Tool post swivel | Adjusts the tool orientation relative to the worm axis |
2. Mathematical Model of the Involute Conical Worm Helical Surface
To understand the tooth geometry, I derived the parametric equations of the involute conical worm surface using three coordinate systems:
- System \(S_w\) – rigidly attached to the worm, with axes \(x_w, y_w, z_w\).
- System \(S_c\) – rigidly attached to the cutting tool, with axes \(x_c, y_c, z_c\).
- System \(S_0\) – a fixed auxiliary system.
During turning, I fix the worm and let the tool rotate around the worm axis while translating along the helical path. The cutting edge is a straight line that makes an angle \(\alpha_0\) with the line perpendicular to the cone generatrix (the base cone of the involute). Let the cone half‑angle be \(\delta\), the tool rotation angle be \(\theta\), the parameter along the tool edge be \(u\), and the helix parameter be \(p\). After applying homogeneous transformation matrices between the coordinate systems, I obtain the following parametric representation of the involute conical worm helical surface:
$$
\begin{aligned}
x_w &= r_b \cos\theta + u \sin\delta \sin\theta, \\
y_w &= r_b \sin\theta – u \sin\delta \cos\theta, \\
z_w &= (u \cos\delta + p\,\theta).
\end{aligned}
$$
Here \(r_b\) is the base radius of the cone. The parameter \(\theta\) represents the rotation angle of the tool, and \(u\) is the distance along the cutting edge from the base cone. This surface is an involute helicoid on a cone.
The cross‑sectional equations can be obtained by fixing \(z_w = \text{const}\) (end‑section) or by fixing \(x_w = \text{const}\) (axial section). For instance, the axial section equation is derived by setting \(x_w = 0\) and solving for the \(y_w-z_w\) profile.
| Symbol | Meaning |
|---|---|
| \(r_b\) | Base radius of the base cone |
| \(\delta\) | Half‑angle of the pitch cone |
| \(\alpha_0\) | Tool edge angle relative to the cone generatrix |
| \(p\) | Helix parameter (\(p = r_b \tan\lambda\)) |
| \(\lambda\) | Lead angle |
3. A Novel Turning Method Using the Axial Cross‑Section Profile
In the conventional turning method for involute conical worms, the straight cutting edge must be tangent to the base cone. However, this arrangement often leads to interference (“tool digging”) because the tool clearance is insufficient. To overcome this, I developed a method in which the cutting tool is placed in the axial plane of the worm, and its cutting edge follows the axial cross‑section profile of the worm tooth space. By using the axial profile as the template, I can turn the worm without the risk of interference, similar to machining an Archimedean worm. The axial cross‑section profile of the involute conical worm is obtained by applying the coordinate transformation and setting \(x_w = 0\) (or any convenient planar section). The resulting profile is a curve that can be approximated by a polynomial or a set of points. I then dress the turning tool to match this axial profile. The advantage is that the tool is always oriented along the worm axis, which simplifies the tool geometry and eliminates digging.
The axial section equation derived from the parametric surface (after setting \(x_w = 0\)) yields:
$$
\begin{cases}
y_a = r_b \sin\theta – u \sin\delta \cos\theta, \\[2pt]
z_a = u \cos\delta + p\,\theta,
\end{cases}
$$
where \(\theta\) and \(u\) are related by the condition \(x_w = 0\). This relation gives \(\theta\) as a function of \(u\) (or vice versa). The tool profile is then designed to match \((y_a, z_a)\) for the entire tooth space.
| Method | Advantage | Disadvantage |
|---|---|---|
| Tangential tool (conventional) | Direct involute generation | Tool digging, complex setup |
| Axial profile tool (new) | No digging, simple tool geometry | Requires precise axial profile calculation |
4. Grinding of the Involute Conical Worm with a Disc‑Type Grinding Wheel
For hardened worm gears, finish grinding is essential. A disc‑type grinding wheel (CBN or corundum) can be used to grind the involute conical worm. However, the contact line between the grinding wheel and the worm surface is not the same as the cutting edge used in turning, so the wheel must be dressed to a specific profile to generate the correct tooth shape. I developed the following procedure:
- Determine the meshing condition between the worm surface and the rotating grinding wheel surface.
- Find the contact line on the worm surface.
- Transform this contact line into the coordinate system of the grinding wheel, thereby obtaining the generatrix of the wheel surface.
- The axial cross‑section of the grinding wheel is then the profile to which the diamond dresser must be guided.
The coordinate systems for grinding are similar to those for turning: a fixed system \(S_f\), a worm system \(S_w\), and a wheel system \(S_g\). The wheel axis is offset from the worm axis by the center distance \(a\) and crossed at an angle equal to the lead angle of the worm. The meshing condition is derived from the relative motion and the condition that the common normal at the contact point must pass through the instantaneous screw axis. After considerable algebra, the contact line on the worm surface is expressed as a function of the tool parameters:
$$
\mathbf{r}_c(\theta, u) = \bigl[ x_w(\theta,u), \; y_w(\theta,u), \; z_w(\theta,u) \bigr]^\mathrm{T},
$$
subject to the meshing equation:
$$
f(\theta, u) = 0.
$$
This line is then mapped into the wheel coordinate system to obtain the wheel surface profile. The axial profile of the grinding wheel is given by the radial distance \(R\) and axial position \(z_g\) along the wheel axis:
$$
\begin{aligned}
R(\theta) &= \sqrt{ (x_g(\theta))^2 + (y_g(\theta))^2 }, \\
z_g(\theta) &= \text{the axial coordinate in the wheel system}.
\end{aligned}
$$
I computed the profile for several cases and verified that the resulting wheel profile is smooth and can be dressed using a CNC-controlled diamond truing unit. This grinding process ensures high accuracy and surface quality of the worm gears.
| Step | Description |
|---|---|
| 1 | Define relative position of worm and grinding wheel |
| 2 | Formulate meshing condition \(f = 0\) |
| 3 | Solve contact line on worm surface |
| 4 | Transform contact line to wheel coordinate system |
| 5 | Extract axial profile \((R, z_g)\) |
5. Installation Distance and High‑Point Calculation for Conical Worm Gears
Proper assembly of the conical worm gear pair requires accurate determination of the axial installation distance and the location of the “high point” on the worm gear. The high point is defined as the point on the tip of the worm gear that contacts the root of the worm at the correct center distance. Once this point is found, the thickness of the worm gear can be computed, and the axial position of the worm relative to the gear can be set.
I consider the coordinate system attached to the worm gear, with the rotation axis of the worm gear inclined relative to the worm axis. Let the pitch cone of the worm gear have an apex at \(O_g\). The node (pitch point) \(P\) lies on the common tangency line of the two pitch cones. The coordinates of \(P\) in the worm gear system are \((r_p, \psi_p)\) in polar form, where \(r_p\) is the radius on the gear pitch cone and \(\psi_p\) is the angular position. The high point is located on the gear tip cone, which is offset by the addendum \(h_a\) from the pitch cone. Using the geometry of the cones, I derived the position of the high point:
$$
\begin{aligned}
z_{\text{high}} &= r_p \sin\delta_g + h_a \cos\delta_g, \\
\theta_{\text{high}} &= \psi_p + \text{(phase offset due to helix)}.
\end{aligned}
$$
Here \(\delta_g\) is the pitch cone angle of the worm gear. The thickness of the worm gear at the high point is then the distance from the tip to the root along the normal direction, which ultimately gives the whole tooth height.
The axial installation distance \(A\) of the worm relative to the gear is measured from a reference plane on the worm (for example, the face of the worm hub) to the intersection of the worm axis with the gear axis. I select a convenient measurement plane on the worm, measure the outer diameter at that plane, and then compute the distance from that plane to the node point. The final installation distance is:
$$
A = z_w(\text{node}) – z_{\text{ref}},
$$
where \(z_w(\text{node})\) is the axial coordinate of the node in the worm coordinate system. A simple trigonometric relationship allows direct measurement on the assembly.
| Quantity | Expression |
|---|---|
| High point axial position | \(z_{\text{high}} = r_p \sin\delta_g + h_a \cos\delta_g\) |
| High point angular position | \(\theta_{\text{high}} = \psi_p + \text{helix phase}\) |
| Installation distance (worm axial) | \(A = z_w(P) – z_{\text{ref}}\) |
| Worm gear tooth thickness at high point | \(s = 2 r_{\text{tip}} \sin(\pi / N_g) – \text{backlash}\) |
6. Conclusion
In my work on involute conical worm gears, I have established a complete manufacturing procedure that covers turning, grinding, and assembly. The use of a ball‑cage synchronous coupling simplifies the initial turning operation. The new axial‑profile turning method eliminates tool interference and is easy to implement on a standard lathe. For grinding, the disc‑wheel profile is mathematically derived from the meshing condition, ensuring that the ground worm gears are accurate and durable. Finally, the correct installation distance and high‑point calculation guarantee proper meshing under load. These methods make involute conical worm gears a viable option for high‑efficiency, high‑precision power transmission systems. I continue to investigate variations of worm gears, such as double‑enveloping and non‑circular types, to extend the application of this versatile gearing concept.