
In the field of power transmission between non-parallel and non-intersecting axes, hyperboloidal gears represent a significant advancement over traditional crossed helical gears. As a researcher focused on gear design and analysis, I have extensively studied the meshing behavior of hyperboloidal gears, particularly through tooth surface modification. This article delves into the mathematical modeling, tooth contact analysis (TCA), and simulation results to elucidate how modification parameters and assembly errors influence the performance of hyperboloidal gears. The goal is to optimize their meshing characteristics, including contact patterns, transmission errors, and sensitivity to misalignments, thereby enhancing load capacity and operational smoothness. Throughout this discussion, the term “hyperboloidal gears” will be emphasized to underscore their unique geometry and advantages.
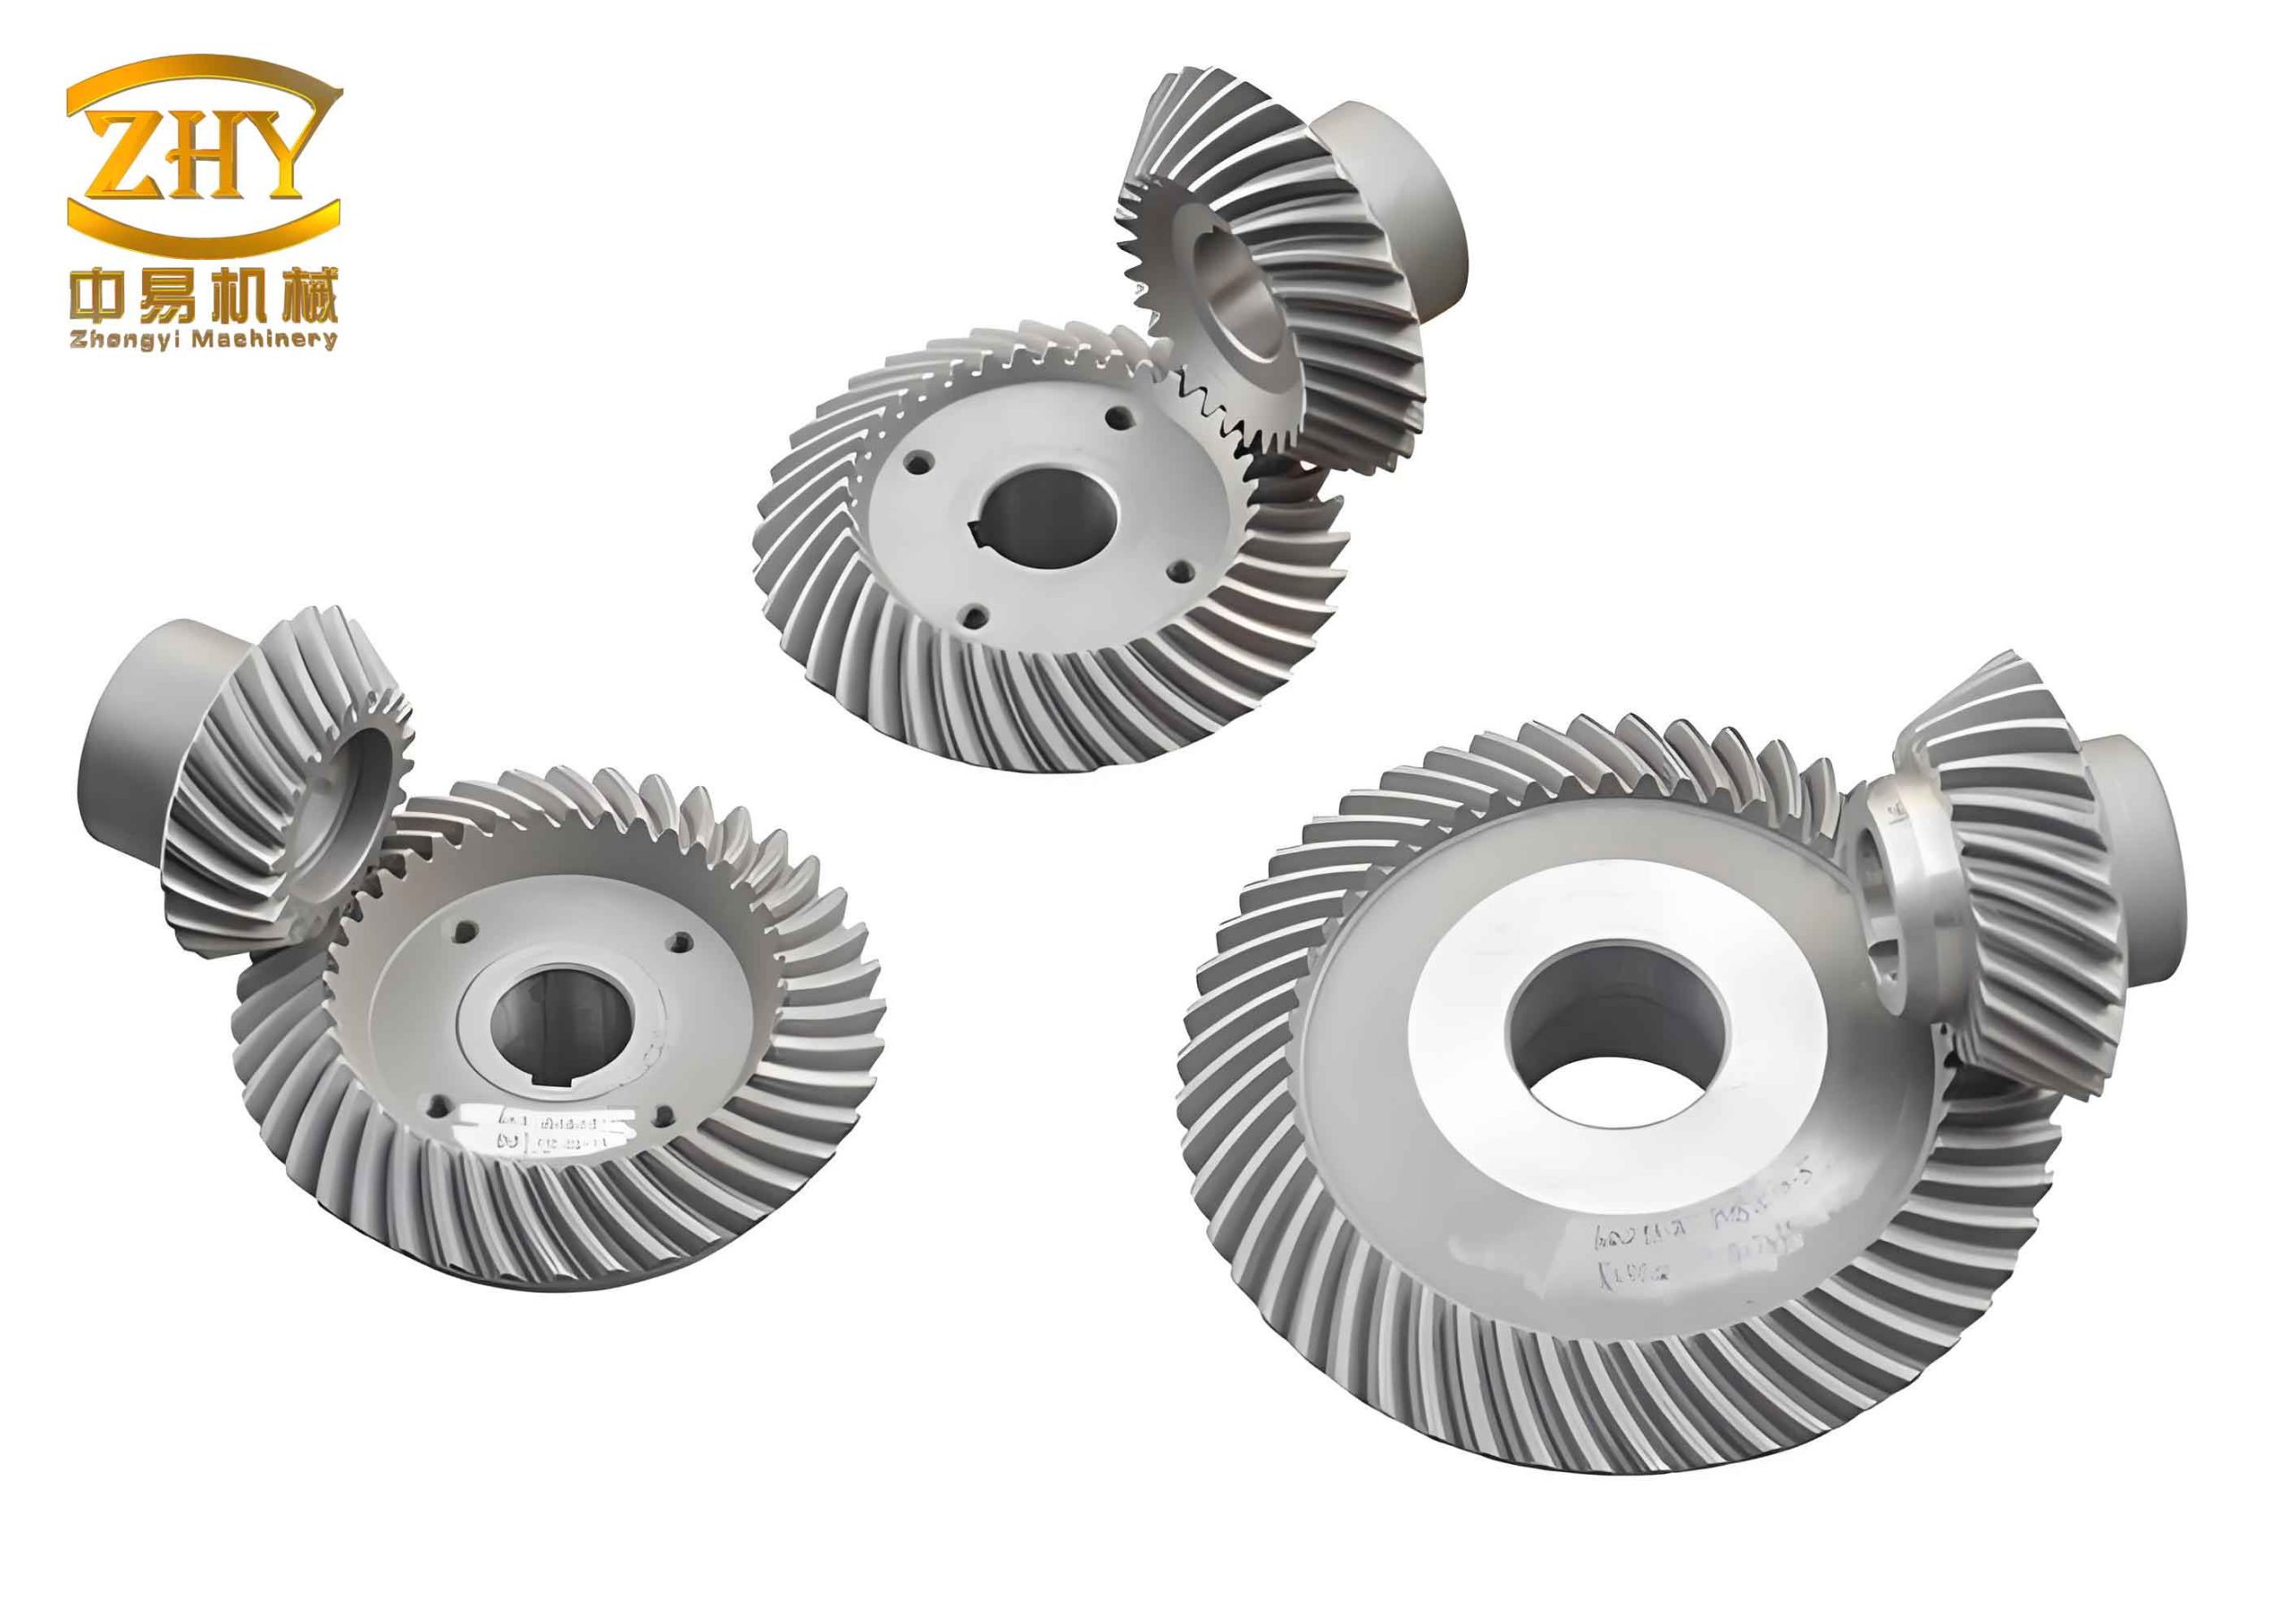
Hyperboloidal gears, often referred to as helipoid gears, feature a hyperboloidal pitch surface, which distinguishes them from conventional gears with cylindrical pitch surfaces. This geometry allows for improved contact conditions and higher torque transmission capabilities. However, the complexity of their tooth surfaces necessitates precise design and manufacturing. In my work, I apply surface modification to the pinion tooth surface to achieve desirable meshing properties, such as a parabolic transmission error that can absorb assembly errors and reduce noise and vibration. The modification is introduced via a rack cutter with a parabolic profile, which generates a modified shaper cutter, and subsequently, the hyperboloidal gear teeth. This approach enables control over the contact ellipse size, shape, and transmission error amplitude.
The mathematical foundation for hyperboloidal gears begins with the derivation of the modified shaper cutter tooth surface. An imaginary rack cutter with a parabolic profile is used to generate the shaper cutter. In the coordinate system \( S_a \) and \( S_t \), the rack cutter tooth surface is defined by parameters \( u_i \) (along the profile direction) and \( l_i \) (along the tooth length direction), where \( i = c, t \) for the pinion and gear shaper cutters, respectively. The normal pressure angle is \( \alpha_n \), the normal module is \( m_n \), \( a_m = \pi m_n / 4 \) is half of the tooth space width, \( a_i \) is the parabolic modification coefficient, and \( d_i \) is the parabolic pole position. The surface equation of the rack cutter in coordinate system \( S_c \) is given by:
$$r_c(u_i, l_i) = \begin{bmatrix} u_i \cos \alpha_n – a_i u_i^2 \sin \alpha_n – d_i \cos \alpha_n \\ -u_i \sin \alpha_n + a_i u_i^2 \cos \alpha_n + a_m + d_i \sin \alpha_n \\ l_i \\ 1 \end{bmatrix}$$
This equation represents a parabolic modification applied to the standard involute profile, where the quadratic term \( a_i u_i^2 \) introduces curvature changes for controlled meshing behavior. The shaper cutter tooth surface \( \Sigma_s \) is then generated by enveloping the rack cutter surface \( \Sigma_c \) through a simulated gear cutting process. The coordinate systems \( S_{ci} \), \( S_i \), and \( S_d \) describe this generation, with \( S_{ci} \) attached to the rack cutter, \( S_i \) to the shaper cutter, and \( S_d \) as a fixed reference. As the shaper cutter rotates by an angle \( \theta_i \), the rack cutter translates by \( r_{pi} \theta_i \), where \( r_{pi} = m_n z_i / 2 \) is the pitch radius and \( z_i \) is the number of teeth. The meshing condition requires that the normal vector at the contact point passes through the instantaneous axis of rotation I-I, leading to:
$$\frac{X_{ci} – x_{ci}}{n_{cxi}} = \frac{Y_{ci} – y_{ci}}{n_{cyi}} = \frac{Z_{ci} – z_{ci}}{n_{czi}}$$
Here, \( (X_{ci}, Y_{ci}, Z_{ci}) \) are coordinates of the instantaneous axis in \( S_{ci} \), \( (x_{ci}, y_{ci}, z_{ci}) \) are contact point coordinates, and \( (n_{cxi}, n_{cyi}, n_{czi}) \) are components of the normal vector. Solving this yields the shaper cutter rotation angle \( \theta_i = (n_{cxi} y_{ci} – n_{cyi} x_{ci}) / (n_{cxi} r_{pi}) \), with \( X_{ci} = 0 \) and \( Y_{ci} = r_{pi} \theta_i \). The shaper cutter tooth surface position vector \( r_s^{(i)} \) and normal vector \( n_s^{(i)} \) in coordinate system \( S_i \) are obtained through coordinate transformations:
$$r_s^{(i)}(u_i, l_i) = M_{ic}(\theta_i) r_c(u_i, l_i)$$
$$n_s^{(i)}(u_i, l_i) = \frac{\partial r_s^{(i)}}{\partial u_i} \times \frac{\partial r_s^{(i)}}{\partial l_i}$$
where \( M_{ic} \) is the homogeneous transformation matrix from \( S_c \) to \( S_i \). This formulation ensures that the shaper cutter incorporates the parabolic modification, which will be transferred to the hyperboloidal gears during the subsequent generation process.
The tooth surface of the hyperboloidal gear \( \Sigma_i \) is generated by simulating the meshing between the shaper cutter and the gear blank. For a left-handed hyperboloidal gear, the coordinate systems \( S_q \), \( S_f \), \( S_p \), \( S_s \), and \( S_i \) define the generation setup, where \( \beta_i \) is the helix angle, \( \phi_s^{(i)} \) is the shaper cutter rotation angle, and \( \phi_i \) is the gear rotation angle, related by the ratio \( \phi_s^{(i)} / \phi_i = N_i / N_s^{(i)} \), with \( N_s^{(i)} \) and \( N_i \) being the tooth numbers of the shaper cutter and gear, respectively. The gear tooth surface is derived using homogeneous transformations and the meshing equation:
$$r_i(u_i, l_i, \phi_s^{(i)}) = M_{is}(\phi_s^{(i)}) r_s^{(i)}(u_i, l_i)$$
$$n_i(u_i, l_i, \phi_s^{(i)}) = L_{is}(\phi_s^{(i)}) n_s^{(i)}(u_i, l_i)$$
$$f_i(u_i, l_i, \phi_s^{(i)}) = n_s^{(i)} \cdot v_s^{(si)} = 0$$
Here, \( M_{is} = M_{if} M_{fp} M_{qs} \) is the transformation matrix from \( S_s^{(i)} \) to \( S_i \), \( L_{is} \) is the linear part of \( M_{is} \), and \( v_s^{(si)} \) is the relative velocity vector between the shaper cutter and gear in \( S_s^{(i)} \). This mathematical model captures the complex geometry of hyperboloidal gears, enabling precise control over tooth surface topography through modification parameters \( a_i \) and \( d_i \).
To analyze the meshing characteristics of hyperboloidal gear pairs, I develop a tooth contact analysis (TCA) model that accounts for assembly errors. The TCA model ensures continuous tangency between the pinion and gear tooth surfaces \( \Sigma_1 \) and \( \Sigma_2 \) in a fixed coordinate system \( S_h \). The coordinate systems include \( S_1 \) and \( S_2 \) attached to the pinion and gear, \( S_g \), \( S_r \), \( S_k \), and \( S_v \) for incorporating axis crossing angle and assembly errors such as horizontal error angle \( \Delta \gamma_h \), vertical error angle \( \Delta \gamma_v \), and center distance error \( \Delta C \). The position and normal vectors of the tooth surfaces in \( S_h \) are expressed as:
$$r_h^{(1)}(u_1, l_1, \phi_s^{(1)}, \phi_1) = M_{h1}(\phi_1) r_1(u_1, l_1, \phi_s^{(1)})$$
$$n_h^{(1)}(u_1, l_1, \phi_s^{(1)}, \phi_1) = L_{h1}(\phi_1) n_1(u_1, l_1, \phi_s^{(1)})$$
$$r_h^{(2)}(u_2, l_2, \phi_s^{(2)}, \phi_2) = M_{h2}(\phi_2) r_2(u_2, l_2, \phi_s^{(2)})$$
$$n_h^{(2)}(u_2, l_2, \phi_s^{(2)}, \phi_2) = L_{h2}(\phi_2) n_2(u_2, l_2, \phi_s^{(2)})$$
where \( \phi_1 \) and \( \phi_2 \) are the rotation angles of the pinion and gear during meshing, \( M_{h1} = M_{hk} M_{kv} M_{v1} \), \( M_{h2} = M_{hg} M_{gr} M_{r2} \), and \( L_{h1} \), \( L_{h2} \) are their linear parts. The conditions for continuous contact are:
$$r_h^{(1)}(u_1, l_1, \phi_s^{(1)}, \phi_1) = r_h^{(2)}(u_2, l_2, \phi_s^{(2)}, \phi_2)$$
$$n_h^{(1)}(u_1, l_1, \phi_s^{(1)}, \phi_1) = n_h^{(2)}(u_2, l_2, \phi_s^{(2)}, \phi_2)$$
$$f_1(u_1, l_1, \phi_s^{(1)}) = 0, \quad f_2(u_2, l_2, \phi_s^{(2)}) = 0$$
These vector equations yield five independent scalar equations when considering the unit normal condition. By taking \( \phi_1 \) as the input and solving numerically, I obtain the contact path on the tooth surfaces. The transmission error is defined as:
$$\delta \phi_2 = (\phi_2 – \phi_{02}) – \frac{N_1}{N_2} (\phi_1 – \phi_{01})$$
where \( \phi_{01} \) and \( \phi_{02} \) are initial engagement angles. A parabolic transmission error curve, typically convex downward, is desirable for error absorption and noise reduction.
Contact ellipses are determined by searching points around the contact point where the surface separation is within a threshold, say 0.00635 mm. In coordinate system \( S_h \), given the contact point \( P \) and normal vector \( n_h \), a vector \( r \) perpendicular to \( n_h \) is rotated by angle \( \theta \) with step \( \delta \theta \), and its magnitude is increased by step \( \delta r \). The rotated vector \( r’ \) is computed as:
$$r’ = (n_h \cdot r) r + \sin \theta \, n_h \times r + \cos \theta \, (n_h \times r) \times n_h$$
Points along \( r’ \) are evaluated until the separation exceeds the threshold, defining the contact ellipse boundary. This method provides insight into the load distribution and contact stress of hyperboloidal gears.
To illustrate the effects of modification and geometric parameters, I present simulation results based on the developed models. The design parameters for two cases, Case 1 and Case 2, are summarized in the table below. These cases vary in axis crossing angle and modification coefficients to demonstrate key trends in hyperboloidal gears performance.
| Design Parameter | Case 1 | Case 2 |
|---|---|---|
| Pinion tooth number \( N_1 \) | 31 | 31 |
| Gear tooth number \( N_2 \) | 43 | 43 |
| Shaper cutter tooth number \( N_s \) | 20 | 20 |
| Normal module \( m_n \) (mm) | 3.0 | 3.0 |
| Normal pressure angle \( \alpha_n \) (degrees) | 20.0 | 20.0 |
| Axis crossing angle \( \gamma \) (degrees) | 50 | 90 |
| Pinion helix angle \( \beta_1 \) (degrees) | 25 | 45 |
| Gear helix angle \( \beta_2 \) (degrees) | 25 | 45 |
| Handedness (pinion, gear) | Left, Left | Left, Left |
| Face width \( B \) (mm) | 30 | 30 |
| Parabolic modification coefficient \( a_1 \) | 0.003 | 0.005 |
| Parabolic pole position \( d_i \) | -0.1 | 0.05 |
The TCA results for these cases reveal significant insights into hyperboloidal gears behavior. For Case 1 with an axis crossing angle of 50°, the contact ellipse is relatively larger, with a moderate aspect ratio. The transmission error curve exhibits a convex parabolic shape due to the parabolic modification. The amplitude of the transmission error is influenced by the modification coefficient \( a_1 \); a smaller \( a_1 \) reduces the amplitude, promoting smoother meshing and higher contact ratio. The symmetry of the transmission error curve is controlled by the parabolic pole position \( d_i \); adjusting \( d_i \) can avoid edge contact and ensure even load distribution. In hyperboloidal gears, the contact path tends to be diagonal across the tooth surface, enhancing overlap and load capacity.
For Case 2 with an axis crossing angle of 90°, the contact ellipse becomes smaller, and its aspect ratio (major to minor axis) increases. This indicates a more localized contact, which may affect stress concentrations. However, the larger axis crossing angle results in a more inclined contact path, increasing the contact ratio and reducing sensitivity to assembly errors. The transmission error remains parabolic, but with a higher amplitude due to the larger modification coefficient. The following table summarizes the impact of axis crossing angle on key meshing parameters for hyperboloidal gears.
| Meshing Parameter | Axis Crossing Angle 50° | Axis Crossing Angle 90° |
|---|---|---|
| Contact ellipse major axis length | Larger | Smaller |
| Contact ellipse aspect ratio | Moderate | Higher |
| Contact path inclination | Less inclined | More inclined |
| Contact ratio | Lower | Higher |
| Sensitivity to assembly errors | Higher | Lower |
| Transmission error amplitude | Controlled by \( a_i \) | Controlled by \( a_i \) |
Assembly errors, such as misalignments in axis position or orientation, can degrade the performance of hyperboloidal gears. My TCA model incorporates these errors to evaluate their effects. For instance, with a horizontal error angle \( \Delta \gamma_h = 0.1^\circ \) and a vertical error angle \( \Delta \gamma_v = 0.05^\circ \), the contact ellipse shifts and deforms. In Case 1, the ellipse shifts toward the tooth edge, potentially causing stress concentrations. In Case 2, due to the higher axis crossing angle, the shift is less pronounced, demonstrating lower sensitivity. This robustness is a key advantage of hyperboloidal gears in practical applications where perfect alignment is challenging.
The mathematical relationship between modification parameters and transmission error can be approximated by a quadratic function. For a parabolic modification, the transmission error \( \delta \phi_2 \) as a function of pinion rotation \( \phi_1 \) is:
$$\delta \phi_2 = k_2 (\phi_1 – \phi_{01})^2 + k_1 (\phi_1 – \phi_{01}) + k_0$$
where \( k_2 \) is proportional to the modification coefficient \( a_i \), and \( k_1 \) and \( k_0 \) are influenced by \( d_i \) and assembly errors. By optimizing \( a_i \) and \( d_i \), I can achieve a symmetric, low-amplitude transmission error that minimizes vibration. For example, setting \( d_i = 0 \) often yields symmetry, while \( a_i \) values in the range of 0.001 to 0.01 provide adequate error absorption without excessive contact stress.
Furthermore, the shaper cutter tooth number \( N_s \) has a minor effect on contact ellipse size. Increasing \( N_s \) slightly enlarges the ellipse but is less significant than axis crossing angle or modification parameters. In manufacturing, modern CNC gear cutting machines can implement these modifications precisely, enabling the production of high-performance hyperboloidal gears. The generation process involves simulating the meshing kinematics to derive tooth surfaces, which can be programmed into multi-axis CNC hobbers or grinders.
In terms of load capacity, hyperboloidal gears benefit from the hyperboloidal pitch surface, which provides more gradual contact entry and exit compared to cylindrical gears. The contact ellipse dimensions influence the Hertzian contact stress. The semi-major axis \( a_e \) and semi-minor axis \( b_e \) of the contact ellipse can be estimated from the surface curvatures at the contact point. For two elastic bodies in point contact, the maximum contact pressure \( p_{\text{max}} \) is given by:
$$p_{\text{max}} = \frac{3F}{2\pi a_e b_e}$$
where \( F \) is the normal load. By optimizing the modification to enlarge the contact ellipse within geometric constraints, I can reduce \( p_{\text{max}} \) and enhance durability. This is particularly important for hyperboloidal gears used in high-torque applications, such as automotive differentials or industrial machinery.
Another critical aspect is the lubrication condition. The elastohydrodynamic lubrication (EHL) film thickness in hyperboloidal gears depends on the contact ellipse size and surface velocities. A larger ellipse can promote better film formation, reducing wear. The parabolic modification helps maintain a consistent film by controlling the transmission error and minimizing sudden load changes. Future studies could integrate EHL analysis with the TCA model to fully optimize hyperboloidal gears for both meshing and lubrication performance.
To summarize, the meshing characteristics of hyperboloidal gears are profoundly influenced by tooth surface modification and geometric parameters. Through parabolic modification of the rack cutter profile, I can achieve a convex parabolic transmission error that absorbs assembly errors and reduces noise. The modification coefficients \( a_i \) and \( d_i \) allow control over the error amplitude and symmetry, respectively. The axis crossing angle plays a pivotal role: larger angles increase contact ratio and reduce sensitivity to misalignments but may result in smaller contact ellipses. The following equation encapsulates the relationship between transmission error and modification for hyperboloidal gears:
$$\delta \phi_2 \approx C_1 a_i \phi_1^2 + C_2 d_i \phi_1 + C_3 \Delta \gamma$$
where \( C_1, C_2, C_3 \) are constants derived from gear geometry, and \( \Delta \gamma \) represents assembly errors. This underscores the tunability of hyperboloidal gears through design parameters.
In conclusion, my research demonstrates that hyperboloidal gears, with proper surface modification, offer superior meshing properties compared to traditional crossed helical gears. The mathematical models and TCA simulations provide a robust framework for designing hyperboloidal gears with optimized contact patterns and transmission errors. Key recommendations include using parabolic modification with coefficients tailored to the axis crossing angle, and leveraging higher axis angles for applications where alignment variability is expected. The integration of these insights into CNC manufacturing processes will enable the widespread adoption of hyperboloidal gears in advanced power transmission systems. Future work could explore dynamic analysis and experimental validation to further refine the design of hyperboloidal gears for emerging technologies.
Throughout this article, the focus on hyperboloidal gears highlights their potential in improving gear performance. By repeatedly emphasizing “hyperboloidal gears,” I aim to reinforce their significance in modern mechanical engineering. The tables and equations presented serve as practical tools for engineers designing these gears, ensuring that the meshing characteristics are precisely controlled for reliable and efficient operation.