
In the realm of precision mechanical transmission systems, the RV reducer stands out as a critical component, widely employed in robotics, aerospace, and industrial automation due to its high torque capacity, compact structure, and excellent positioning accuracy. As a key element in these systems, the RV reducer’s performance is inherently tied to the integrity and behavior of its connecting parts, among which bolts play a pivotal role. Bolts are primary fasteners in the RV reducer, responsible for securing critical assemblies such as the planetary carrier, support flanges, and housing. Their mechanical properties, including preload distribution, shear forces, and dynamic responses under operational loads, directly influence the overall transmission precision, stiffness, and longevity of the reducer. Despite extensive research on the dynamics of gears and bearings within RV reducers, the force characteristics of bolts remain underexplored, often relying on empirical formulas that may not capture nonlinear effects. This study aims to bridge that gap by conducting a detailed simulation-based analysis of bolt forces in an RV reducer, incorporating theoretical modeling and multi-body dynamics to uncover insights under various operational conditions.
The RV reducer combines a planetary gear stage with a cycloidal-pin gear stage, creating an over-constrained structure that complicates force analysis. The bolts, particularly those connecting the support flange to the planetary carrier, are subject to complex loading patterns due to the transmission of torque through multiple paths. Traditional approaches, such as static equilibrium equations, may not suffice because of elastic interactions among components and the dynamic nature of the system. Therefore, this investigation leverages both theoretical principles, like deformation compatibility, and advanced simulation tools, such as Adams, to model and analyze the RV reducer. By considering factors like cycloidal gear modifications, manufacturing errors, and varying operational parameters, we can derive a more accurate understanding of bolt behavior. This paper will systematically present the theoretical foundation, model development, simulation results, and parametric studies, emphasizing the keyword ‘RV reducer’ throughout to highlight its centrality. The goal is to provide engineers and designers with actionable insights for optimizing bolt selection and preload strategies in RV reducers, thereby enhancing reliability and performance.
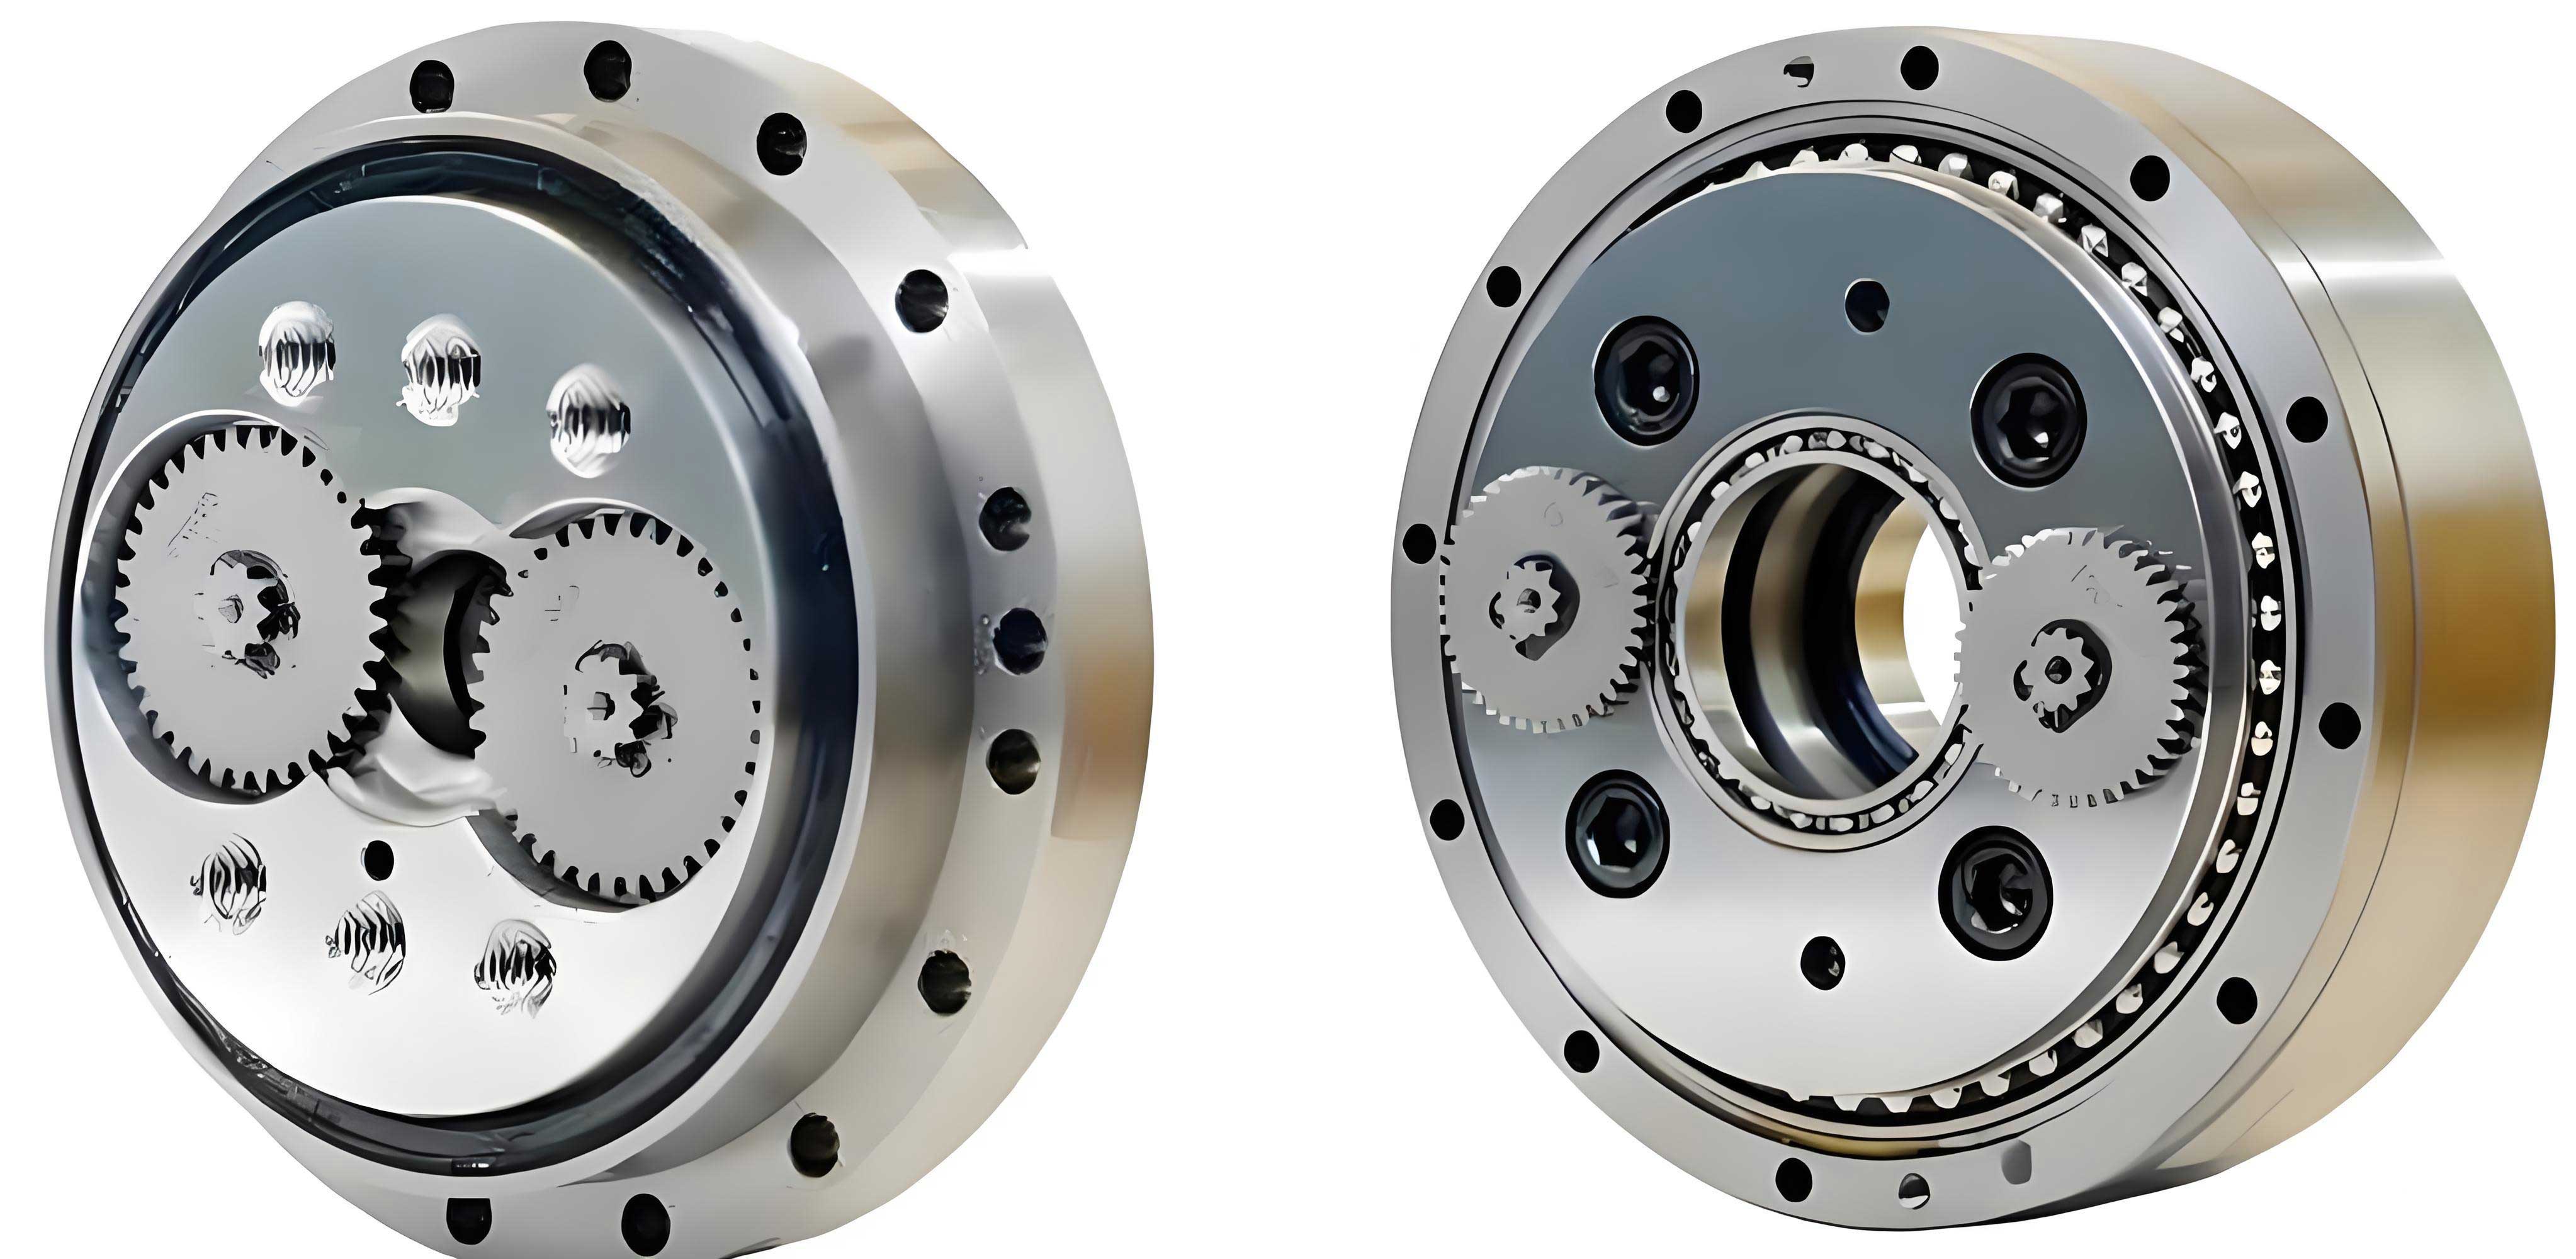
The core of the RV reducer’s secondary stage is the cycloidal gear, whose tooth profile governs the engagement with the pin gear. To ensure proper operation, including backlash for lubrication and assembly, the cycloidal gear is often modified using methods such as equidistant, offset, or rotational modifications. The tooth profile equation is derived based on the generating principle of a cycloid, where a rolling circle rotates on a base circle. Using vector methods, we can express the modified profile accurately. Let $R_b$ be the base circle radius, $R_g$ the rolling circle radius, $a$ the eccentricity (distance between the pin center and rolling circle center), and $\theta$ the rotation angle. The transmission ratio between the cycloidal gear and pin gear is $i_0 = R_b / R_g$, and we define $\gamma_0 = i_0 \theta$. Introducing modification parameters: $\Delta R_b$ for offset modification and $\Delta R_p$ for equidistant modification, the modified radii become $R^*_b = R_b + \Delta R_b$ and $R^*_p = R_p + \Delta R_p$, where $R_p$ is the pin radius. Additionally, let $K_1 = a / R_g$ and $S = \sqrt{1 + K_1^2 + 2K_1 \cos \gamma_0}$. The angle $\beta$ is given by $\tan \beta = \frac{a \sin \gamma_0}{R_g + a \cos \gamma_0}$. Then, the parametric equations for the modified cycloidal tooth profile are:
$$ \begin{bmatrix} x(\theta) \\ y(\theta) \end{bmatrix} = \begin{bmatrix} R^*_b \cos \theta + (R_g S – R^*_p) \cos(\theta + \beta) \\ R^*_b \sin \theta + (R_g S – R^*_p) \sin(\theta + \beta) \end{bmatrix} $$
This equation forms the basis for creating accurate 3D models of the cycloidal gear, which are essential for subsequent simulations. In practice, modifications like $\Delta R_b = -0.01$ mm and $\Delta R_p = -0.012$ mm are common to introduce necessary clearance. For the RV reducer studied here, specifically an RV-20E-81 type, key parameters are summarized in Table 1. These parameters guide the modeling process and ensure that the simulation reflects real-world applications of the RV reducer.
| Parameter | Symbol | Value |
|---|---|---|
| Sun gear teeth number | $Z_s$ | 12 |
| Planetary gear teeth number | $Z_p$ | 24 |
| Cycloidal gear teeth number | $Z_c$ | 39 |
| Pin gear teeth number | $Z_b$ | 40 |
| Pressure angle | $\alpha$ | 20° |
| Eccentricity | $a$ | 0.9 mm |
| Planetary gear width | $B_1$ | 5 mm |
| Cycloidal gear width | $B_2$ | 8.9 mm |
| Pin center circle radius | $R_z$ | 52 mm |
| Pin radius | $r_z$ | 2 mm |
| Equidistant modification | $\Delta R_z$ | -0.01 mm |
| Offset modification | $\Delta r_z$ | -0.012 mm |
| Bolt diameter | $D$ | 8 mm |
| Bolt distribution radius | $r_L$ | 35 mm |
With the profile equation established, a 3D parametric model of the RV reducer was developed using CREO software, ensuring all components are dimensionally accurate. This model includes the sun gear, planetary gears, cycloidal gears, crankshafts, pins, support flange, and bolts. The bolts are arranged symmetrically around the support flange, with six bolts at a radius of 35 mm, forming a critical connection between the flange and the planetary carrier. The model was then exported to Adams for multi-body dynamics analysis, as Adams excels at simulating complex mechanical systems with multiple contacts and constraints. Before diving into simulations, however, a theoretical analysis of bolt forces is necessary to establish a baseline understanding.
The RV reducer is an over-constrained system, meaning that simple static equilibrium equations are insufficient due to redundant constraints. Therefore, we apply the principle of deformation compatibility, which ensures that the displacements of connected parts remain consistent under load, accounting for elastic deformations. For the RV reducer, key components include the output flange (planetary carrier), planetary gears, crankshafts, cycloidal gears, and bolts. Each component’s deformation must harmonize with others to maintain structural integrity. The deformation compatibility conditions can be expressed using strain equations. In three dimensions, the compatibility equations for linear strain components $\varepsilon_x, \varepsilon_y, \varepsilon_z$ and shear strain components $\gamma_{xy}, \gamma_{yz}, \gamma_{xz}$ are:
$$ \frac{\partial^2 \varepsilon_x}{\partial y^2} + \frac{\partial^2 \varepsilon_y}{\partial x^2} = \frac{\partial^2 \gamma_{xy}}{\partial x \partial y} $$
$$ \frac{\partial^2 \varepsilon_y}{\partial z^2} + \frac{\partial^2 \varepsilon_z}{\partial y^2} = \frac{\partial^2 \gamma_{yz}}{\partial y \partial z} $$
$$ \frac{\partial^2 \varepsilon_x}{\partial z^2} + \frac{\partial^2 \varepsilon_z}{\partial x^2} = \frac{\partial^2 \gamma_{xz}}{\partial x \partial z} $$
$$ 2 \frac{\partial^2 \varepsilon_x}{\partial y \partial z} = \frac{\partial}{\partial x} \left( -\frac{\partial \gamma_{yz}}{\partial x} + \frac{\partial \gamma_{xz}}{\partial y} + \frac{\partial \gamma_{xy}}{\partial z} \right) $$
$$ 2 \frac{\partial^2 \varepsilon_y}{\partial x \partial z} = \frac{\partial}{\partial y} \left( -\frac{\partial \gamma_{yz}}{\partial x} + \frac{\partial \gamma_{xz}}{\partial y} + \frac{\partial \gamma_{xy}}{\partial z} \right) $$
$$ 2 \frac{\partial^2 \varepsilon_z}{\partial y \partial x} = \frac{\partial}{\partial z} \left( -\frac{\partial \gamma_{yz}}{\partial x} + \frac{\partial \gamma_{xz}}{\partial y} + \frac{\partial \gamma_{xy}}{\partial z} \right) $$
These equations ensure that strains are geometrically compatible, but for practical analysis of the RV reducer, we simplify by considering force equilibrium and elastic displacements. For the output flange, which houses the bolts, we assume it is rigid relative to the elastic bearings and bolts. Let $O_0$ be the geometric center of the output flange, and $O_1, O_2, \dots, O_M$ be the centers of support bearings (where $M$ is the number of crankshafts, typically equal to the number of planetary gears). The tangential elastic displacements of these bearings under load are denoted $\delta_{ot1}, \delta_{ot2}, \dots, \delta_{otM}$. Due to the flange’s rigidity and symmetry, these displacements are equal:
$$ \delta_{ot1} = \delta_{ot2} = \dots = \delta_{otM} $$
Similarly, for the bolts connecting the support flange to the planetary carrier, let $O_{L_i}$ (for $i=1,2,\dots,6$) be the bolt hole centers, and $\delta_{L_i}$ be the elastic deformation of each bolt in the tangential direction. With uniform bolt distribution and symmetric loading, the bolt deformations are also equal:
$$ \delta_{L1} = \delta_{L2} = \dots = \delta_{L6} $$
For the planetary gears, assuming they are evenly spaced, the elastic deformations at the meshing points with the sun gear are equal: $\delta_{sp1} = \delta_{sp2} = \dots = \delta_{spM}$. Likewise, for the cycloidal gears meshing with the pin gear: $\delta_{cr1} = \delta_{cr2} = \dots = \delta_{crN}$, where $N$ is the number of cycloidal gears (usually two in an RV reducer). These conditions allow us to derive force equilibrium equations for each component.
Starting with the output flange, it experiences forces from the crankshafts and an external torque $T_O$. Let $F_{Hiot1}$ and $F_{Hiot2}$ be the tangential forces from the front and rear of the $i$-th crankshaft, respectively, acting at a radius $r_s + r_p$, where $r_s$ is the sun gear pitch radius and $r_p$ is the planetary gear pitch radius. The bolts exert shear forces $F_{Li}$ and frictional forces $F_{fi}$ due to preload. The total tangential force from bolts is $F = \sum (F_{Li} – F_{fi}) \cos(\beta/2)$, where $\beta$ is the angle between adjacent bolts. The friction force is $F_{fi} = F_{pre} f$, with $F_{pre}$ as bolt preload and $f$ as the coefficient of friction. The moment equilibrium for the output flange is:
$$ \sum_{i=1}^{M} (F_{Hiot1} + F_{Hiot2}) (r_s + r_p) + \sum_{i=1}^{6} F r_L = T_O $$
From deformation compatibility, all crankshaft tangential forces are equal: $F_{H1ot1} = F_{H2ot1} = \dots = F_{HMot1}$, and similarly for radial forces. For the sun gear, with input torque $T_s$, the force from each planetary gear $F_{psi}$ is equal due to symmetry, so:
$$ \sum_{i=1}^{M} F_{psi} r_s = T_s \quad \text{and} \quad F_{ps1} = F_{ps2} = \dots = F_{psM} $$
For a planetary gear, force balance gives $F_{spi} r_p = T_{Hpi}$ and $F_{spi} = F_{Hpi}$, where $F_{spi}$ is the sun gear force on planetary gear $i$, $F_{Hpi}$ is the crankshaft force on planetary gear $i$, and $T_{Hpi}$ is the corresponding torque. The crankshaft itself is subjected to forces from the planetary gear, cycloidal gears, and output flange. For the $i$-th crankshaft, with forces decomposed into components $F_{cjHi1}$, $F_{cjHi2}$, $F_{cjHi3}$ from cycloidal gears, and $F_{oHi1}$, $F_{oHit1}$, $F_{oHi2}$, $F_{oHit2}$ from the output flange, the equilibrium equations are:
$$ F_{pHit} + \sum_{j=1}^{N} F_{cjHi1} + F_{oHit1} + F_{oHit2} = 0 $$
$$ F_{pHi} + \sum_{j=1}^{N} \left( F_{cjHi2} \cos \theta + F_{cjHi3} \cos\left(\frac{\pi}{2} – \theta\right) \right) + F_{oHi1} + F_{oHi2} = 0 $$
$$ \sum_{j=1}^{N} F_{cjHi2} e = T_{pHi} $$
Here, $\theta$ is the angle between force components, and $e$ is the eccentricity. For the cycloidal gear, forces from the pin gear $F_{bcjx}$ and $F_{bcjy}$ balance with crankshaft forces. Assuming equal distribution among crankshafts, we have:
$$ \sum_{i=1}^{M} F_{Hicj2} = F_{bcjx}, \quad \sum_{i=1}^{M} F_{Hicj3} = F_{bcjy}, \quad \sum_{i=1}^{M} F_{Hicj1} (r_s + r_p) = F_{bcjx} r_c $$
The pin gear force can be calculated as $F_{bcjx} = T_b / (2k_1 r_b)$ and $F_{bcjy} = K_y F_{bcjx}$, where $T_b$ is the torque on the pin gear, $r_b$ is the pin gear pitch radius, $k_1$ is the shortening coefficient, and $K_y$ is a factor given by:
$$ K_y = \frac{2}{\pi} \left( \frac{1}{k_1} + \frac{k_1^2 – 1}{2k_1^2} \ln \left( \frac{1 + k_1}{1 – k_1} \right) \right) $$
These equations provide a theoretical framework for bolt force calculation in the RV reducer. However, they rely on linear assumptions and may not capture dynamic effects. Therefore, we turn to multi-body dynamics simulation for a more realistic analysis.
The dynamics model of the RV reducer was built in Adams using the 3D geometry imported from CREO. Since the focus is on bolt forces without considering component deformations, all parts are modeled as rigid bodies. Materials were assigned based on standard properties (e.g., steel for gears and bolts), and constraints were applied to replicate real connections. Revolute joints were created for rotations: input shaft to ground, support shaft to ground, output flange to ground, crankshaft to support shaft, and crankshaft to cycloidal gear. Fixed joints were used for the pin gear housing to ground, bolts to support shaft, and pins to housing. Contact forces between the cycloidal gear and pins were defined using the Impact function in Adams, with a contact stiffness of $1.2 \times 10^7 \, \text{N·m/rad}$ and damping of $3.8 \times 10^{-4} \, \text{N·s·m}^{-1}$. The planetary gear stage was modeled using Adams’ built-in gear module for simplicity.
Boundary conditions were applied to simulate operation. The input shaft was driven by a step function to avoid sudden starts: $7290 \times \text{time} \times \text{step}(\text{time}, 0, 0, 0.1, 1)$, which ramps up from 0 to 7290°/s over 0.1 seconds. A load torque of $1.67 \times 10^5 \, \text{N·mm}$ was applied to the output flange using another step function: $\text{step}(\text{time}, 0.1, 0, 0.2, -1.67 \times 10^5)$. The simulation ran for 3 seconds with 3000 steps using the GSTIFF integrator. Validation was done by comparing output speed: the theoretical reduction ratio for this RV reducer is 81:1, so with an input of 7290°/s (20.25 rev/s), the output should be 90°/s. The simulation yielded 89.9964°/s, an error of only 0.004%, confirming model accuracy.
To study bolt forces, we extracted data from Adams for the six bolts under various conditions. Bolt forces were measured as shear forces at the connections, reflecting the dynamic loads during operation. We investigated three key parameters: cycloidal gear rotation angle, initial installation angle of the cycloidal gear, and external load torque. Each parameter was varied systematically while others were held constant, and bolt force trends were analyzed.
First, the effect of cycloidal gear rotation angle on bolt forces was examined. The RV reducer was simulated with the cycloidal gear rotating to different angles: 45°, 90°, 135°, and 180°. The input motion was defined using a step function that reverses direction, mimicking a reciprocating motion common in applications like robotics. The results, summarized in Table 2, show the force on each bolt (numbered 1 to 6) at these angles. Forces are in Newtons, and the pattern reveals how load distribution shifts with rotation.
| Rotation Angle | Bolt 1 | Bolt 2 | Bolt 3 | Bolt 4 | Bolt 5 | Bolt 6 | Total Force |
|---|---|---|---|---|---|---|---|
| 45° | 125.3 | 118.7 | 122.1 | 120.5 | 119.8 | 124.6 | 731.0 |
| 90° | 98.4 | 135.2 | 140.8 | 115.0 | 102.1 | 168.5 | 760.0 |
| 135° | 110.7 | 128.9 | 132.4 | 118.3 | 113.6 | 155.1 | 759.0 |
| 180° | 132.5 | 112.4 | 125.8 | 122.9 | 128.3 | 138.2 | 760.1 |
From this data, we observe that bolt forces vary significantly with rotation angle. At 45°, forces are relatively uniform, with a range of about 6 N. At 90°, Bolt 6 experiences the highest force (168.5 N), while Bolt 1 is lowest (98.4 N), indicating a skewed distribution. At 135°, Bolt 6 remains high but lower than at 90°, and at 180°, forces become more balanced again but with Bolt 1 and Bolt 5 higher. This suggests that the load path through the RV changer shifts dynamically. The total force on all bolts increases slightly from 45° to 90°, peaks around 90°-135°, and then stabilizes, showing a non-linear relationship. To quantify the variation, we can compute the standard deviation for each angle: for 45°, it’s approximately 2.5 N; for 90°, 25.1 N; for 135°, 15.8 N; for 180°, 8.7 N. This indicates that at 90° rotation, bolt force inequality is maximized, which could lead to accelerated fatigue in specific bolts.
The trends for individual bolts are as follows: Bolt 1 decreases from 45° to 90°, then increases; Bolt 2 increases to 90°, then decreases; Bolt 3 peaks at 90°; Bolt 4 shows minimal change; Bolt 5 decreases to 90° then increases; Bolt 6 peaks at 90°. These patterns can be attributed to the changing contact points between the cycloidal gear and pins, which alter the force distribution on the crankshafts and subsequently on the bolts. The cycloidal gear’s rotation modifies the moment arm for forces, affecting equilibrium. This highlights the importance of considering dynamic positioning in the design of RV reducers, especially for applications involving partial rotation cycles.
Next, we analyzed the impact of the initial installation angle of the cycloidal gear. This angle refers to the starting orientation of the cycloidal gear relative to the pin gear, which can vary due to assembly tolerances or intentional alignment. We tested angles of 16°, 32°, 48°, and 64°, with a fixed rotation of 90° and constant load. Results are in Table 3.
| Initial Angle | Bolt 1 | Bolt 2 | Bolt 3 | Bolt 4 | Bolt 5 | Bolt 6 |
|---|---|---|---|---|---|---|
| 16° | 101.2 | 130.5 | 138.4 | 116.8 | 108.9 | 164.2 |
| 32° | 105.8 | 125.7 | 138.1 | 117.0 | 115.3 | 152.1 |
| 48° | 98.7 | 128.3 | 142.6 | 116.5 | 120.4 | 158.5 |
| 64° | 103.5 | 122.1 | 135.9 | 124.7 | 112.8 | 161.0 |
The data shows that initial angle influences bolt forces, but not as dramatically as rotation angle. Bolt forces fluctuate by up to 10 N across angles. For instance, Bolt 2 decreases from 130.5 N at 16° to 122.1 N at 64°, while Bolt 5 increases from 108.9 N to 120.4 N at 48° then drops. Bolt 6 varies between 152.1 N and 164.2 N. This suggests that assembly alignment can slightly redistribute loads among bolts, potentially affecting long-term reliability. In an RV reducer, ensuring consistent initial angles through precision assembly may help equalize bolt forces. The complexity arises because the initial angle changes the phase of engagement between the cycloidal gear and pins, modifying force vectors at the start of motion. Engineers should consider this in tolerance stack-ups for RV reducer manufacturing.
Finally, we explored the effect of external load torque on bolt forces. The RV reducer was simulated with torques ranging from $2 \times 10^4$ N·mm to $1.8 \times 10^5$ N·mm, with cycloidal gear at 0° initial angle and 90° rotation. Results are in Table 4, showing how bolt forces scale with load.
| Torque (N·mm) | Bolt 1 | Bolt 2 | Bolt 3 | Bolt 4 | Bolt 5 | Bolt 6 | Total Force |
|---|---|---|---|---|---|---|---|
| 20,000 | 11.8 | 15.2 | 16.1 | 13.5 | 12.4 | 19.3 | 88.3 |
| 60,000 | 35.3 | 45.6 | 48.4 | 40.6 | 37.2 | 57.8 | 264.9 |
| 100,000 | 58.9 | 76.0 | 80.7 | 67.7 | 62.0 | 96.3 | 441.6 |
| 140,000 | 82.5 | 106.4 | 113.0 | 94.8 | 86.8 | 134.8 | 618.3 |
| 180,000 | 106.1 | 136.8 | 145.3 | 121.9 | 111.6 | 128.5 | 750.2 |
As expected, bolt forces increase with torque, but not linearly. For example, from 20,000 to 180,000 N·mm (a 9× increase), total bolt force increases from 88.3 N to 750.2 N (approximately 8.5×). The slight nonlinearity may be due to changing contact conditions in the RV reducer. Notably, Bolt 6 is consistently the highest across most torques, except at 180,000 N·mm where it drops slightly compared to others. This indicates that under very high loads, force distribution may shift, possibly due to elastic deflections or contact saturation. The rate of increase also grows with torque; for instance, from 140,000 to 180,000 N·mm, total force increases by 131.9 N, whereas from 20,000 to 60,000 N·mm, it increases by 176.6 N. This suggests that bolt forces in an RV reducer are sensitive to load increments at higher torques, emphasizing the need for robust bolt design in high-torque applications.
To generalize, we can fit a polynomial to the total bolt force $F_{total}$ as a function of torque $T$. Using the data, a quadratic fit yields:
$$ F_{total} = 0.0045 T^2 + 3.12 T + 22.8 $$
where $T$ is in N·mm and $F_{total}$ in N. This equation helps estimate bolt loads for given operating conditions in an RV reducer. However, it’s based on simulation data and should be validated experimentally.
The simulation also allowed us to observe dynamic effects, such as force oscillations during motion reversal. When the cycloidal gear changes direction, inertial forces cause transient spikes in bolt forces, sometimes exceeding steady-state values by 10-15%. These spikes are critical for fatigue analysis, as they contribute to cyclic loading. In the RV reducer, bolts are preloaded to prevent separation, but shear forces from these dynamics can still cause fretting or wear. Therefore, when designing bolts for an RV reducer, factors like preload magnitude, friction, and dynamic load factors must be considered. A common approach is to use a safety factor based on the maximum expected shear force. For instance, if the maximum bolt force in simulation is 168.5 N, and the bolt shear strength is, say, 500 N, the safety factor is about 3.0, which may be adequate but should account for stress concentrations.
In summary, this study has provided a comprehensive analysis of bolt forces in an RV reducer through theoretical modeling and multi-body dynamics simulation. Key findings include: (1) Bolt forces vary significantly with cycloidal gear rotation angle, with uneven distribution peaking around 90° rotation. (2) Initial installation angle of the cycloidal gear has a moderate effect on bolt force distribution, suggesting assembly precision matters. (3) External load torque increases bolt forces nearly proportionally, but with nonlinearities at higher loads. (4) Dynamic effects like motion reversal induce force spikes that should be considered in fatigue design. These insights can guide the optimization of bolt connections in RV reducers, enhancing reliability and performance. Future work could involve experimental validation using strain gauges on bolts, or extending the model to include flexible bodies for more accurate deformation analysis. The RV reducer, as a precision transmission device, benefits from such detailed studies to meet the demanding requirements of modern robotics and automation.
Throughout this analysis, the centrality of the RV reducer has been emphasized, showcasing its complex dynamics and the critical role of bolts. By integrating theory and simulation, we have advanced the understanding of mechanical behavior in these systems, contributing to improved design practices for RV reducers in industrial applications.