
Gear transmission is one of the most common mechanical transmission forms in modern machinery, characterized by high transmission efficiency, accurate transmission ratio, and long service life. Among various gear types, the straight bevel gear is widely used for transmitting motion and power between intersecting axes, typically at a shaft angle of 90 degrees. It possesses high load-carrying capacity, stable meshing, and relatively low noise, making it indispensable in applications such as aircraft, automobiles, tractors, machine tools, and heavy engineering equipment. However, the manufacturing of high-precision straight bevel gears remains a challenging task, especially when precise tooth surface geometry and high surface quality are required. Traditional methods often rely on approximate equivalences, such as the concept of imaginary cylindrical gears, which introduce inherent errors. To overcome these limitations, a novel generating line method has been proposed, allowing the production of theoretically exact spherical involute tooth surfaces. In this paper, I present a comprehensive study on the grinding of straight bevel gears based on the generating line method, including theoretical analysis, tool and fixture design, finite element verification, and process simulation using DEFORM-3D. The overall goal is to provide a reliable theoretical basis for practical gear grinding operations and to improve the competitiveness of domestic gear manufacturing technology.
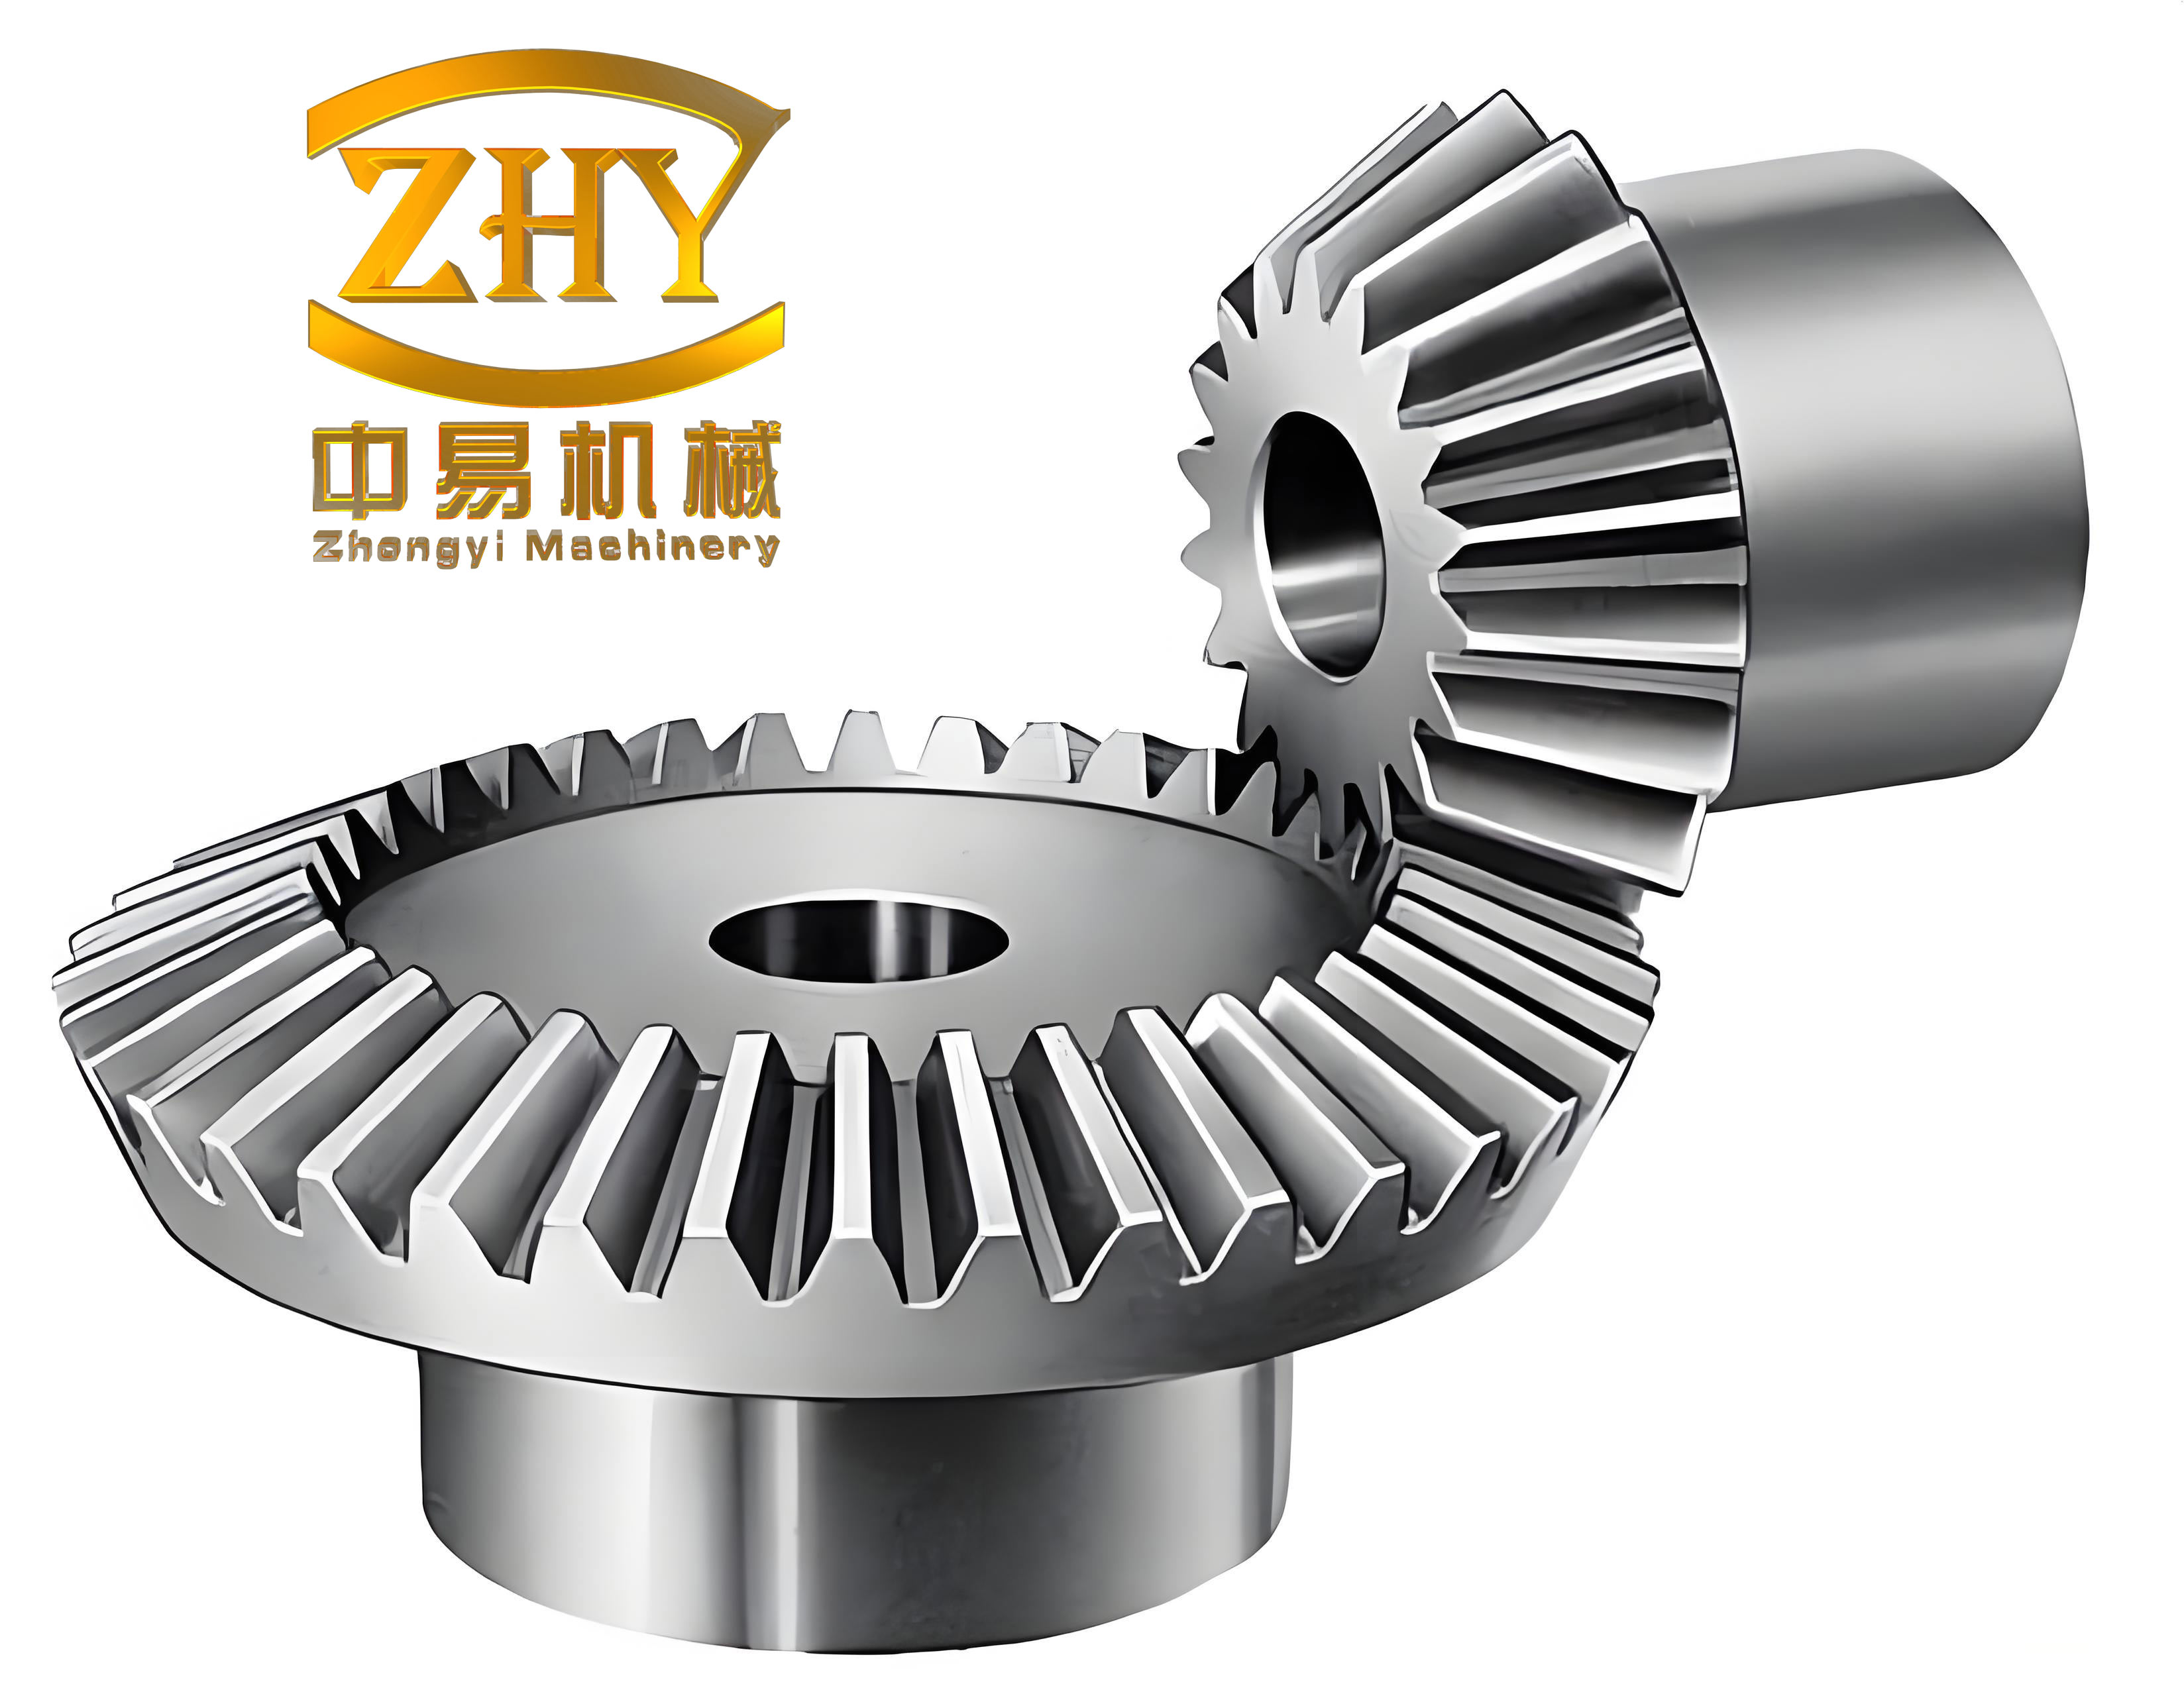
The current state of gear grinding technology both domestically and internationally reveals that many advanced gear production companies keep their grinding techniques highly confidential. Publicly available literature on grinding technology is scarce. To change the situation where China relies on foreign countries for precision gear manufacturing, continuous independent innovation in gear manufacturing theory and practice is essential. The research presented here focuses on the grinding of straight bevel gears based on the generating line method. This approach eliminates principle errors and offers simpler relative motions, simpler tools, and lower manufacturing costs compared to traditional methods. The main contributions of this study are: (1) detailed derivation of the tooth surface generation principle for spherical involute straight bevel gears; (2) design of a dedicated grinding wheel and fixture; (3) finite element analysis of the wheel and fixture to ensure structural safety; (4) numerical simulation of the grinding process using DEFORM-3D to investigate the influence of grinding parameters on grinding force and temperature; and (5) optimization of grinding parameters based on regression models. These contributions collectively validate the feasibility of the generating line method for grinding straight bevel gears and offer practical guidance for process planning.
Theoretical Fundamentals of the Generating Line Method
The generating line method, introduced by Professor Peng Fuhua, provides a novel approach to generating involute gear tooth surfaces. The fundamental idea is to use a straight line lying in a plane that rolls on a base cone as the generating line (cutting edge) to form the tooth surface of a straight bevel gear. Since the base cone cannot be developed into a plane without distortion, traditional methods approximate the spherical involute using “equivalent spur gears.” In contrast, the generating line method creates the tooth surface directly by rolling a plane (called the Q-plane) on the base cone. The intersection of the Q-plane with the base cone is a generating line that sweeps out the tooth flank. This principle ensures that every point on the generated surface lies on a true spherical involute, leading to theoretically correct meshing and constant angular velocity ratio.
For the left tooth surface of a straight bevel gear, the generation process can be described as follows. A base cone with a base cone angle δb rotates about its own axis with angular velocity ω1, while the Q-plane rotates about an axis perpendicular to its plane through its center O with angular velocity ω. The line A-A within the Q-plane, which is tangent to the base cone, acts as the generating line. The relation between the two angular velocities must satisfy:
$$ \omega_1 = \omega \sin \delta_b $$
where δb is the base cone angle. When the base cone and the Q-plane perform a pure rolling motion, the generating line sweeps from the base cone toward the face cone, forming the left flank ΣL. Similarly, the right tooth flank ΣR is generated using a different generating line A’-A’, with the opposite rolling direction. In practice, a disk-shaped grinding wheel with a straight cutting edge (the chord of its end face) can be used as the generating line. By properly controlling the relative motion between the workpiece and the wheel, the desired tooth flank can be ground.
The machining process for the left flank involves two stages. Initially, the tool and the gear blank are positioned so that the generating line lies on the extension of the root line. Then the workpiece feeds along the root line with a velocity v until the generating line completely engages the tooth root. In the second stage, the workpiece and the Q-plane perform a pure rolling motion. The workpiece rotates about its own axis with angular velocity ω1 and simultaneously rotates about the axis of the machine table (the Q-plane normal) with angular velocity ω, while the tool is held stationary. The direction of these rotations must be consistent with the pure rolling model. The right flank is generated in a similar manner but with opposite directions of rolling. This process is exactly what a grinding machine must realize when using the generating line method to grind straight bevel gears.
Gear Parameters and Solid Modeling
In this study, the selected straight bevel gear has the primary parameters listed in Table 1. The gear is an “non-equal clearance shrinking tooth” type, which is common in practice. The module is 8 mm, the number of teeth is 15, the pressure angle is 20 degrees, and the shaft angle is 90 degrees (transmission ratio i = 1). The addendum coefficient is 1.0, and the tip clearance coefficient is 0.2. These values serve as the basis for all subsequent calculations and simulations.
| Parameter | Symbol | Value |
|---|---|---|
| Module | m | 8 mm |
| Number of teeth | z | 15 |
| Pressure angle | α | 20° |
| Transmission ratio | i | 1 |
| Addendum coefficient | ha* | 1.0 |
| Tip clearance coefficient | c* | 0.2 |
| Profile shift coefficient | x | 0 |
Using standard formulas for straight bevel gears, the following geometric quantities are derived:
| Parameter | Formula | Result |
|---|---|---|
| Pitch cone angle δ | δ = arctan(i) | 45° |
| Reference diameter d | d = m·z | 120 mm |
| Addendum ha | ha = m(ha*+x) | 8 mm |
| Base circle diameter db | db = d·cos α | 112.763 mm |
| Base cone angle δb | δb = δ − arctan(hb/R) | 41.549° |
| Root cone angle δf | δf = δ − arctan(hf/R) | 38.545° |
| Face width b | b = R/3 | 28 mm |
| Cone distance R | R = d/(2·cos δ) | 84.853 mm |
| Addendum angle θa | θa = arctan(ha/R) | 5.386° |
| Root angle correction ψ | ψ = arccos(cos δf/cos δb) | 0° |
| Cutting zone angle μ | μ = arccos(cos δa/cos δb) − arccos(cos δf/cos δb) | 31.572° |
The root cone angle is initially calculated to be less than the base cone angle; however, for a shrinking-tooth bevel gear, the root cone angle must be greater than or equal to the base cone angle. Therefore, the root cone angle is set equal to the base cone angle, and the adjustment angle ψ becomes zero. The three-dimensional solid model of the straight bevel gear is created using CATIA, and a two-dimensional engineering drawing is generated in AutoCAD. The gear model is later used for both motion simulation and finite element analysis.
To verify the correctness of the tooth surface generation principle and the feasibility of the grinding process, a motion simulation is performed in CATIA using the DMU Kinematics workbench. The gear model and the grinding wheel model (designed later) are assembled according to the required relative positions. Then, rotational motions are applied to the gear and the wheel with the prescribed angular velocity ratio. The “collision stop” function is enabled to detect any possible interference. The simulation results show that the grinding wheel moves along the tooth flank without interference, generating the theoretical spherical involute surface correctly. This confirms that the generating line method can be effectively implemented for grinding straight bevel gears.
Design of the Grinding Wheel and Fixture
Since commercially available grinding wheels do not meet the specific requirements of the generating line method, a custom wheel must be designed. The grinding wheel is composed of abrasive grains, bond, and pores. The selection of the abrasive type, grain size, hardness, bond, and organization directly affects the grinding quality and efficiency. In this work, the workpiece material is aluminum alloy 2A12, which is a typical hard alloy with high strength, good thermal conductivity, and low density. Based on the material properties and the grinding process requirements, silicon carbide (SiC) abrasive is selected. SiC is suitable for grinding non-ferrous metals such as aluminum and brass.
The grain size is chosen according to the desired surface finish. For semi-finishing and finishing operations, a grit size of 60# to 80# is appropriate. In this study, 60# is used, corresponding to an average particle size of about 250–315 μm. The hardness grade of the wheel is selected as medium-hard to hard (e.g., P–R in the Chinese standard), because aluminum is relatively soft and the wheel wear is low; a harder wheel retains its cutting ability longer. The bond type is ceramic (vitrified) bond, which is widely used for non-ferrous metal grinding and offers good heat resistance and rigidity. The wheel organization is chosen as loose (number 13 or 14) to provide sufficient chip clearance and reduce grinding heat.
The shape of the grinding wheel must have a flat end face so that a chord of the circle can serve as the generating line. Disk-type wheels are suitable. The wheel is designed based on a commercial flat wheel of dimension 300 mm × 40 mm × 75 mm (outer diameter × thickness × bore). However, the outer edge thickness must be reduced to avoid interference when grinding the small-end tooth space. Let h be the outer edge thickness of the wheel; it must be smaller than the base circular tooth space width at the small end of the gear. For the designed gear, the small-end base circle tooth space width is calculated as approximately 7.60 mm. Hence, an outer edge thickness of 5 mm is chosen.
Another key dimension is the wheel diameter. From the geometric relation between the chord length (the generating line length) and the amount of protrusion (over-cut) t, the wheel diameter d is given by:
$$ d = t + \frac{c^2}{4t} $$
where c is the length of the generating line (must be greater than or equal to the tooth width b = 28 mm), and t is the over-cut amount, typically t ≤ 0.3m (2.4 mm for m = 8). Selecting t = 0.125m = 1.0 mm and c = 30 mm yields a diameter of 226 mm, which is less than the chosen 300 mm. Conversely, with d = 300 mm and t = 0.1m = 0.8 mm, the available chord length is about 30.94 mm, which satisfies the requirement. Therefore, the designed wheel has an outer diameter of 300 mm, an outer edge thickness of 5 mm, and an inner hole of 75 mm. The wheel is modeled in CATIA and a two-dimensional drawing is prepared.
The grinding wheel is intended to be mounted on a YK2250 machine tool spindle with a BT40 taper. A dedicated fixture is designed to clamp the wheel securely. The fixture consists of a flange on one side to fit the BT40 shank, and a shaft with a sleeve-type clamping plate on the other side, tightened by an M30 nut. The dimensions are determined according to the safety standard GB4674-2009. For example, the flange diameter is 130 mm (minimum 115 mm), the sleeve thickness is 13 mm, and the clamping plate diameter is 160 mm. The fixture is modeled in CATIA and a two-dimensional drawing is made.
Finite Element Analysis of the Grinding Wheel and Fixture
Finite element analysis (FEA) is a powerful numerical method for solving complex engineering problems. In this work, I use ANSYS Workbench to perform structural analyses of the grinding wheel and fixture. The material properties of SiC used in the analysis are listed in Table 3. Since the grinding wheel is porous, the effective density is reduced according to the abrasive percentage (approximately 36%). The wheel model is imported into ANSYS Workbench, and automatic mesh generation is employed. Modal analysis is performed to obtain the natural frequencies and mode shapes, which are essential to avoid resonance with the machine spindle.
| Property | Value |
|---|---|
| Density (kg/m³) | 3200 |
| Young’s modulus (GPa) | 450 |
| Poisson’s ratio | 0.14 |
| Thermal conductivity (W/m·°C) | 40 |
| Thermal expansion coefficient (10⁻⁶/°C) | 4.5 |
The first six natural frequencies are obtained as shown in Table 4. All of them lie in the range of 10,000–16,000 Hz. Since the maximum spindle frequency of the YK2250 machine is about 100 Hz, the wheel’s fundamental frequency is more than 100 times higher, so resonance will not occur during operation. The mode shapes indicate that the wheel deforms primarily in the radial plane (torsional modes) and axially for the sixth mode. The maximum deformation occurs at the outer edge, which is expected. These results confirm the structural integrity of the wheel design.
| Mode | 1 | 2 | 3 | 4 | 5 | 6 |
|---|---|---|---|---|---|---|
| Frequency (Hz) | 10390 | 10393 | 10815 | 11688 | 11690 | 15699 |
A harmonic response analysis is then performed to evaluate the steady-state response of the wheel under a periodic cutting force. A sinusoidal force of 300 N in the axial direction is applied to the wheel face, while the frequency is swept from 10,000 Hz to 22,000 Hz. The analysis uses the mode-superposition method. The frequency-amplitude plot shows a distinct peak at approximately 10,800 Hz, which is very close to the third natural frequency. This indicates that if the excitation frequency coincides with a natural frequency, large amplitudes can occur. Therefore, in practice the grinding wheel should not be operated at those critical speeds. The maximum displacement amplitude at resonance is about 1.55e-5 m, which is acceptable for the intended grinding conditions.
The fixture is also analyzed using static structural analysis. The fixture is assumed to be a cantilever beam clamped at the flange side, and the total weight (including wheel, sleeve, nut, and shaft) is estimated at 10 kg, producing a force of 98 N at the free end. The stress distribution is computed. The maximum equivalent stress is about 12.09 MPa, which is far below the yield strength of 45 steel (≥200 MPa). The maximum total deformation is 1.26e-2 mm, which is negligible. Thus, the fixture design satisfies strength and stiffness requirements.
Grinding Simulation Using DEFORM-3D
Because the grinding process is complex and difficult to observe experimentally, finite element simulation offers an effective way to study the effects of process parameters. DEFORM-3D is a specialized software for metal forming and machining simulation. In this section, I simulate the grinding of a straight bevel gear tooth surface using a single abrasive grain. The realistic cutting process involves many grains, but a single-grain model is a simplification that retains the essential physics and is computationally efficient. The grain is modeled as a four-sided pyramid (truncated quadrangular pyramid) with a base diameter of 300 μm (corresponding to 60# grit) and a height of 77 μm. The workpiece is modeled as an elastic–plastic block made of aluminum alloy 2A12 (matched to DEFORM-3D material library as AL_2024_COLD). The grain and the backing plate are assumed to be rigid.
The simulation is designed as a two-factor, three-level full factorial experiment. The factors are the wheel speed vc (15, 20, 25 m/s) and the grinding depth ap (0.01, 0.015, 0.02 mm), resulting in 9 runs (NOP11 to NOP33). The workpiece dimensions are 1 mm × 0.5 mm × 0.25 mm, and the back plate is 1 mm × 1 mm × 0.25 mm. The mesh is generated using absolute sizing with a minimum element size of 0.02 mm for the workpiece, and the grain is meshed with 5000 elements. The friction coefficient is set to 0.25 (Coulomb friction). The simulation employs Lagrangian incremental formulation with deformation and heat transfer coupling. The time step is chosen as 10⁻⁷ s, and the total steps are 745, 560, and 450 for speeds of 15, 20, and 25 m/s respectively, corresponding to the time needed for the grain to traverse the 1 mm workpiece length.
After the simulations, the surface morphology is examined. It is observed that during the initial cutting phase, the groove width and depth increase gradually until full engagement, then remain nearly constant. When the grinding depth increases, the groove becomes deeper and wider, and more chips are formed. When the speed increases while the depth is constant, the groove width and depth do not change significantly, indicating that the grinding depth has a more pronounced effect on the surface morphology. Some plastic side-flow and burr formation are visible at the exit side, which is typical for ductile aluminum.
The grinding forces are extracted from the post-processor. The radial (normal) force Fz and tangential force Fy are recorded as functions of time. A typical curve (from run NOP22) shows that the force increases from zero during initial penetration, reaches a quasi-steady state during full engagement, and eventually drops to zero at the exit. Due to mesh distortion, some abnormal spikes appear in the raw data. These outliers are removed using the 3-sigma rule in MATLAB. Then, wavelet denoising is applied to smooth the curve. The maximum value of the radial grinding force is extracted for each run. Table 5 lists the maximum radial force Fz for all nine runs.
| Run | NOP11 | NOP12 | NOP13 | NOP21 | NOP22 | NOP23 | NOP31 | NOP32 | NOP33 |
|---|---|---|---|---|---|---|---|---|---|
| Fz | 3.644 | 5.518 | 7.599 | 4.513 | 5.157 | 7.769 | 3.976 | 6.843 | 7.376 |
From the results, it is clear that increasing the grinding depth ap leads to a significant increase in the grinding force, whereas the influence of the wheel speed vc on the force is relatively small. Therefore, the grinding depth is the dominant factor affecting the grinding force. To establish a mathematical model, I average the forces for each depth level and fit a quadratic polynomial:
$$ F_z = k_1 a_p^2 + k_2 a_p + k_3 $$
Using the Matlab curve fitting toolbox, the coefficients are found as k1 = -1060, k2 = 385.5, and k3 = 0.2953. Thus,
$$ F_z = -1060 a_p^2 + 385.5 a_p + 0.2953 $$
This model is valid within the tested range of ap from 0.01 to 0.02 mm.
The grinding temperature is also monitored in the simulations. The temperature at the workpiece surface rises rapidly during the initial engagement and tends to stabilize during steady state, with a slight increase toward the exit because of heat accumulation. Abnormal values (above 1000°C) are discarded, and the remaining temperature–time data are denoised using the same wavelet approach. The maximum temperature Tm for each run is given in Table 6.
| Run | NOP11 | NOP12 | NOP13 | NOP21 | NOP22 | NOP23 | NOP31 | NOP32 | NOP33 |
|---|---|---|---|---|---|---|---|---|---|
| Tm | 361.9 | 365.6 | 380.4 | 384.2 | 385.4 | 396.5 | 471.2 | 476.5 | 490.9 |
Figure (not shown) indicates that the speed vc has a dominant effect on the grinding temperature, while the depth ap has a weaker effect. Averaging the temperatures for each speed level, the trend is fitted with a quadratic polynomial:
$$ T_m = k_4 v_c^2 + k_5 v_c + k_6 $$
The fitted coefficients are k4 = 1.428, k5 = -46.1, and k6 = 739.5, giving:
$$ T_m = 1.428 v_c^2 – 46.1 v_c + 739.5 $$
where vc is in m/s.
Parameter Optimization and Verification
For high-quality grinding, both the grinding force and the temperature should be minimized, because excessive force causes tool wear and deflection, while excessive temperature leads to surface burns, residual stresses, and microcracks. Using the derived models, I perform a simple optimization. For the grinding force, taking the derivative of Fz with respect to ap:
$$ \frac{dF_z}{da_p} = -2120 a_p + 385.5 $$
Setting this equal to zero gives ap = 0.18 mm, which is outside the feasible range (0–0.02 mm). Since the derivative is positive within the range, Fz increases monotonically with ap. Therefore, the minimum force occurs at the smallest practical depth, ap = 0.01 mm, yielding Fz,min = 4.044 N (using the model).
For the grinding temperature, the derivative with respect to vc is:
$$ \frac{dT_m}{dv_c} = 2.856 v_c – 46.1 $$
Setting this to zero gives vc = 16.14 m/s, which lies within the range. The second derivative is positive, so this is a minimum. The corresponding minimum temperature is Tm,min = 367.4°C. Since the grinding depth also slightly raises the temperature, the optimal combination is ap = 0.01 mm and vc = 16.14 m/s, where both force and temperature are minimized simultaneously.
To verify the optimization, an additional simulation is performed with vc = 16.14 m/s and ap = 0.01 mm. The mesh is refined to improve accuracy (26,770 elements). The simulated maximum radial force is 4.089 N and the maximum temperature is 364.8°C, which are very close to the predicted values. The small differences are attributed to numerical noise and the fact that the regression model is an average over different speeds/depths. Therefore, the optimized parameters are acceptable for practical grinding. It should be noted that these simulations are conducted under dry grinding conditions. In real manufacturing, the use of grinding fluid can further reduce the temperature and improve surface quality.
Conclusion
This paper presents a comprehensive study and simulation of the grinding process for straight bevel gears based on the generating line method. The key findings and contributions are summarized as follows.
- The generating line method is theoretically sound and practically feasible for grinding straight bevel gears. The motion simulation in CATIA confirmed that the generated tooth surface is a true spherical involute without interference.
- A custom grinding wheel using SiC abrasive with a disc shape and an outer edge thickness of 5 mm was designed. The wheel and its fixture were verified via finite element analysis to be structurally safe and free from resonance under operating conditions.
- DEFORM-3D simulations revealed that the grinding depth ap has a dominant effect on the grinding force, while the wheel speed vc has a dominant effect on the grinding temperature. Mathematical models were established for both relationships.
- Parameter optimization yielded the optimal grinding parameters as ap = 0.01 mm and vc = 16.14 m/s under dry conditions, achieving minimum force and temperature. The verification simulation matched the predictions well.
The research provides a useful theoretical basis for the actual grinding of straight bevel gears using the generating line method. Future work could extend the single-grain simulation to a multi-grain wheel model, incorporate the effect of grinding fluid, and conduct experimental validation on a real machine tool to further refine the process parameters.