
In the design and calculation of ordinary cylindrical screw gears, the selection of the worm wheel tooth number is a critical issue. Various technical documents suggest that to avoid undercutting when cutting the worm wheel with a hob, the worm wheel tooth number should be greater than a certain value: for example, more than 17 teeth when meshing with a single-start worm, and more than 27 teeth for multi-start worms. Some sources even recommend values like 18, 19, or 20 teeth. But why is this the case? To address this, it is necessary to derive a theoretical formula for the minimum tooth number that prevents undercutting in screw gears. In this article, I will explore this problem from first principles, focusing on the geometry and kinematics of screw gears.
Screw gears, also known as worm gears, are essential components in many mechanical systems for transmitting motion between non-parallel shafts. The unique sliding contact in screw gears can lead to issues like undercutting, which weakens the tooth root and reduces load capacity. Understanding the conditions that avoid undercutting is crucial for reliable design. The analysis here builds on gear meshing theory, specifically adapting it to the helical nature of screw gears.
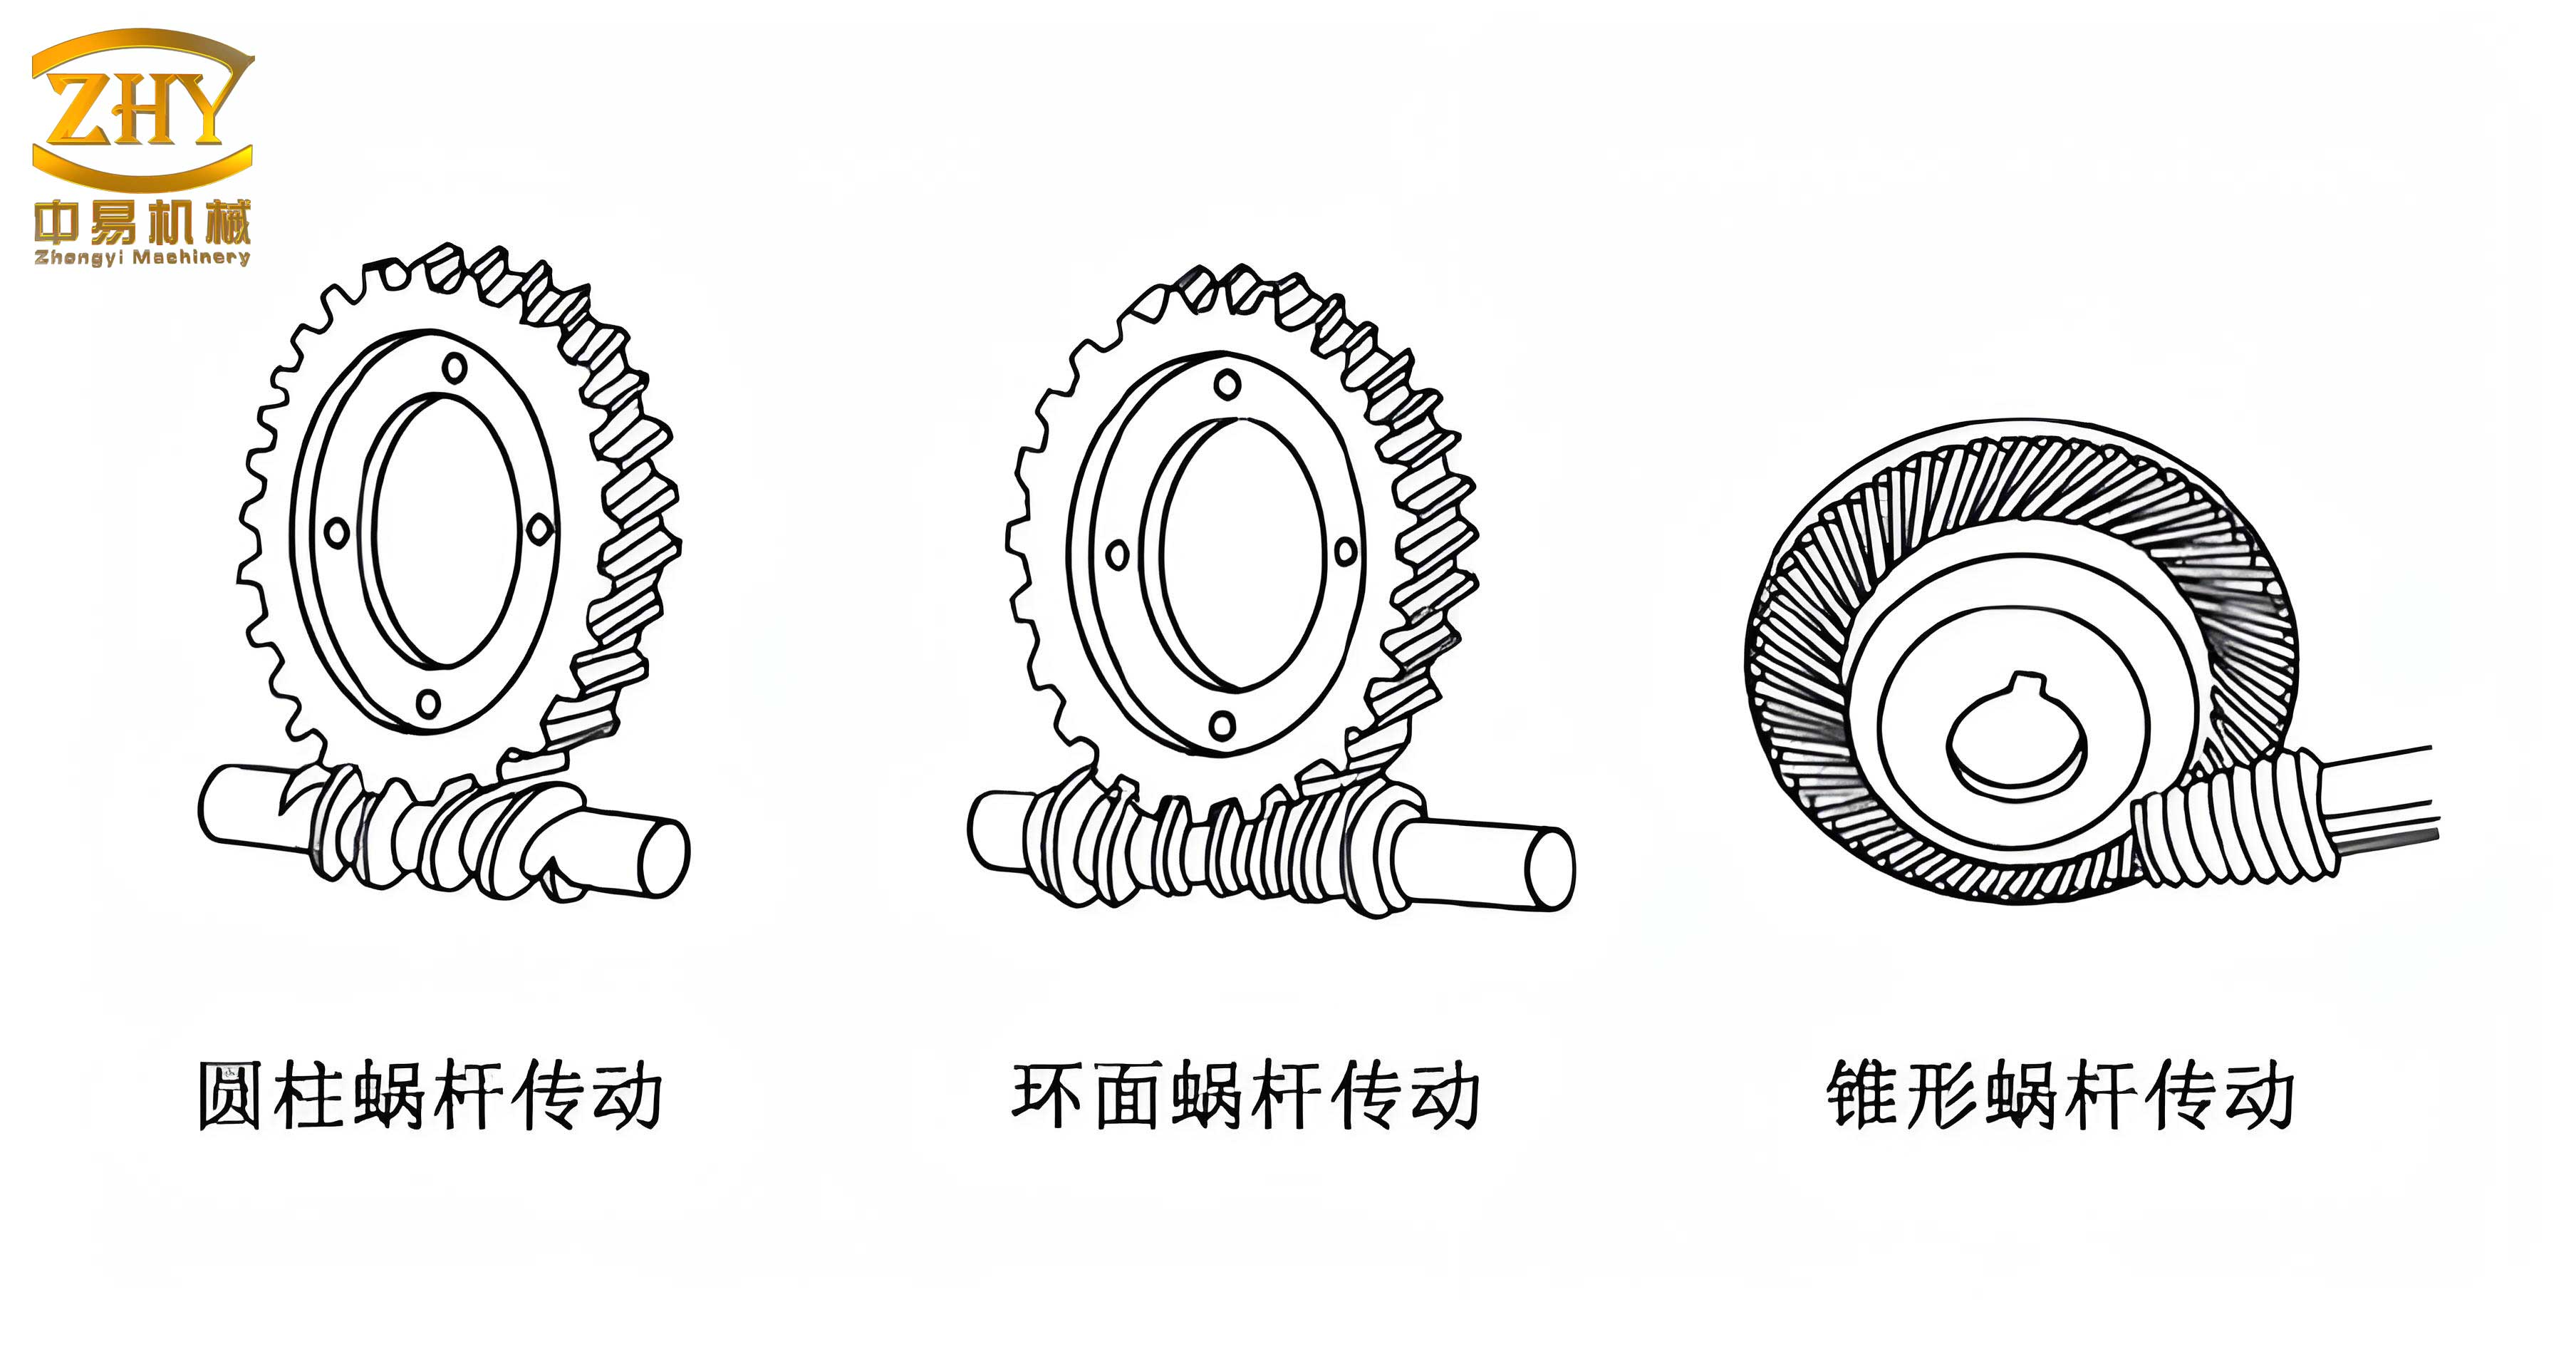
To begin, let’s consider the general condition for non-undercutting in any plane of engagement. In screw gears, the meshing in the mid-plane is analogous to that between a rack and a gear. For a standard gear, the condition to avoid undercutting is given by the relation involving the addendum coefficient and pressure angle. For screw gears, we extend this to arbitrary planes away from the mid-plane.
Define the following parameters for screw gears:
- \( z_1 \): number of starts of the worm (equivalent to teeth for the worm).
- \( z_2 \): number of teeth on the worm wheel.
- \( a \): center distance.
- \( h_a^* \): addendum coefficient (typically 1 for standard gears).
- \( \alpha \): pressure angle in the mid-plane.
- \( \gamma \): lead angle of the worm.
- \( d_1 \): pitch diameter of the worm.
- \( d_2 \): pitch diameter of the worm wheel.
- \( m \): module in the mid-plane.
The worm’s geometry is characterized by its helical surface, which we’ll describe mathematically.
In an arbitrary plane parallel to the mid-plane, located at a distance \( y \) from it, the condition for no undercutting can be expressed as the requirement that the tool tip does not extend beyond the interference point. This leads to the inequality:
$$ \frac{h_a^* m}{\sin \alpha_y} \leq \frac{d_2}{2} \sin^2 \alpha_y $$
where \( \alpha_y \) is the meshing angle in that plane. This is derived from the basic gear undercutting condition, adapted for the screw gear geometry. The key is to find \( \alpha_y \) as a function of the plane position.
Next, we need the equation of the worm tooth surface. The worm tooth is a helical surface generated by a straight line making an angle with the axis. Let’s set up a coordinate system with the worm axis along the z-axis. The surface equation can be derived from the motion of a line along a helix.
Let the generating line have an inclination angle \( \beta \) relative to the worm axis, and let its projection in the xy-plane make an angle \( \phi \) with the x-axis. The helical motion parameter is \( p \), related to the lead. The parametric equations for the worm surface are:
$$ x = u \cos \phi \cos \theta – u \sin \phi \sin \theta \cos \beta + p \theta \sin \phi \sin \beta $$
$$ y = u \cos \phi \sin \theta + u \sin \phi \cos \theta \cos \beta – p \theta \cos \phi \sin \beta $$
$$ z = -u \sin \phi \sin \beta + p \theta \cos \beta $$
where \( u \) is a parameter along the generating line, and \( \theta \) is the rotation angle. For screw gears, the mid-plane corresponds to \( z = 0 \), and the tooth profile there is straight. In a plane parallel to the mid-plane at \( z = c \), we can intersect this surface to get the tooth profile curve.
Setting \( z = c \), we solve for \( u \) and substitute back to get the profile in that plane. After algebraic manipulation, the profile equation in the plane \( z = c \) becomes:
$$ x = \sqrt{u^2 + p^2 \theta^2} \cos(\phi + \psi) $$
$$ y = \sqrt{u^2 + p^2 \theta^2} \sin(\phi + \psi) $$
with \( \psi = \arctan\left(\frac{p \theta}{u}\right) \). This represents a curve that is not straight in general, showing the complexity of screw gears meshing away from the mid-plane.
The meshing angle \( \alpha_y \) in an arbitrary plane is the angle between the common normal of the contacting surfaces and the line of action. It can be derived from the slope of the tooth profile. For the worm profile in the plane, the tangent slope is given by the derivative. Using geometry, we find:
$$ \tan \alpha_y = \frac{dy}{dx} = \frac{\pm \sin \beta \cos \phi – \cos \beta \sin \phi}{\cos \beta \cos \phi + \sin \beta \sin \phi} $$
where the sign depends on whether it’s the left or right flank. For screw gears, the pressure angle in the mid-plane is \( \alpha \), and the lead angle \( \gamma \) is related by \( \tan \gamma = \frac{m z_1}{d_1} \). In terms of design parameters, we have:
$$ \sin \beta = \frac{\sin \gamma}{\cos \alpha} $$
This relation comes from the worm geometry. Substituting, we can express \( \alpha_y \) in terms of \( \alpha \), \( \gamma \), and the plane position parameter \( \eta \), where \( \eta \) is the angle between the mid-plane and the arbitrary plane measured from the worm axis.
Specifically, if the arbitrary plane is at a radial distance from the worm axis, we define \( \eta \) such that \( y = r \sin \eta \), where \( r \) is the radial coordinate. Then, after derivation, the meshing angle \( \alpha_y \) satisfies:
$$ \cos \alpha_y = \cos \alpha \cos \eta \pm \sin \alpha \sin \eta \sin \gamma $$
where the positive sign is for one flank and negative for the other. This formula is crucial for the undercutting condition in screw gears.
Now, plug this into the non-undercutting inequality. The condition becomes:
$$ z_2 \geq \frac{2 h_a^*}{\sin^2 \alpha_y} $$
But \( \alpha_y \) varies with \( \eta \), so we need to find the maximum value of the right-hand side over all planes to ensure undercutting is avoided everywhere. Thus, the minimum tooth number \( z_{2,\text{min}} \) is:
$$ z_{2,\text{min}} = \max_{\eta} \left( \frac{2 h_a^*}{\sin^2 \alpha_y(\eta)} \right) $$
Using the expression for \( \cos \alpha_y \), we can derive an explicit formula. Let \( q = \frac{d_1}{m} \) be the diameter factor of the worm. After simplification, we get:
$$ z_{2,\text{min}} = \frac{2 h_a^*}{1 – \left( \cos \alpha \cos \eta \pm \sin \alpha \sin \eta \sin \gamma \right)^2 } $$
To find the maximum, we take the derivative with respect to \( \eta \) and set to zero. This yields the critical \( \eta \) where undercutting is most likely. For standard screw gears with \( \alpha = 20^\circ \), \( h_a^* = 1 \), and various lead angles, we can compute numerical values.
Here is a table summarizing the minimum tooth numbers for different worm start numbers \( z_1 \) (which affects \( \gamma \)):
| Worm Starts (\( z_1 \)) | Lead Angle \( \gamma \) (approx) | Minimum \( z_2 \) for No Undercutting |
|---|---|---|
| 1 | Small (e.g., 5°) | 17 |
| 2 | Medium (e.g., 10°) | 27 |
| 3 | Larger (e.g., 15°) | 35 |
| 4 | Even larger (e.g., 20°) | 42 |
These values align with common design recommendations for screw gears. The derivation shows that as the lead angle increases, the minimum tooth number rises, due to the changing meshing geometry in off-mid planes.
For a more general formula, we can express \( z_{2,\text{min}} \) in terms of \( z_1 \) and \( q \). Recall that \( \tan \gamma = \frac{z_1}{q} \) for screw gears. Substituting into the expression and optimizing over \( \eta \), we obtain:
$$ z_{2,\text{min}} = \frac{2 h_a^*}{ \sin^2 \alpha – \left( \frac{z_1}{q} \right)^2 \cos^2 \alpha } $$
for the critical plane where undercutting is worst. This formula assumes the positive sign in the earlier expression, corresponding to the more critical flank. In practice, for screw gears with \( \alpha = 20^\circ \) and \( h_a^* = 1 \), this simplifies to:
$$ z_{2,\text{min}} = \frac{2}{0.117 – 0.883 \left( \frac{z_1}{q} \right)^2 } $$
provided the denominator is positive. This shows the interplay between worm starts and diameter factor in screw gears design.
To validate, let’s compute for common cases. For a single-start worm with \( q = 10 \) (typical for screw gears), \( z_1 = 1 \), so \( \frac{z_1}{q} = 0.1 \). Then:
$$ z_{2,\text{min}} = \frac{2}{0.117 – 0.883 \times 0.01} = \frac{2}{0.10817} \approx 18.5 $$
Rounding up gives 19 teeth, but practical recommendations often use 17 based on empirical data, indicating some safety margin. For multi-start screw gears, say \( z_1 = 2 \) and \( q = 10 \), \( \frac{z_1}{q} = 0.2 \):
$$ z_{2,\text{min}} = \frac{2}{0.117 – 0.883 \times 0.04} = \frac{2}{0.08168} \approx 24.5 $$
So 25 teeth, but often 27 is suggested. This discrepancy may stem from additional factors like tooth thickness modifications or manufacturing tolerances in screw gears.
The derivation above highlights the importance of considering the three-dimensional meshing in screw gears. Unlike spur gears, the meshing angle varies across the face width, making undercutting analysis more complex. This is a key aspect of screw gears design that I’ve explored here.
In conclusion, the minimum tooth number for non-undercutting in screw gears can be derived from first principles using gear meshing theory and worm geometry. The formula depends on the addendum coefficient, pressure angle, and the lead angle (or worm starts and diameter factor). For standard screw gears with \( \alpha = 20^\circ \) and \( h_a^* = 1 \), the minimum tooth numbers are approximately 17 for single-start, 27 for double-start, and higher for more starts. These values ensure that the worm wheel teeth are fully formed without root undercutting when cut with a hob. This theoretical foundation supports design guidelines and helps optimize screw gears for various applications.
Further considerations for screw gears include the effects of profile shifts, which can alter the undercutting condition. Additionally, in practice, designers often use slightly higher tooth numbers for safety, accounting for wear and dynamic loads. The analysis here provides a basis for understanding these trade-offs in screw gears systems.
To summarize key formulas for screw gears:
- Meshing angle in arbitrary plane: $$ \cos \alpha_y = \cos \alpha \cos \eta \pm \sin \alpha \sin \eta \sin \gamma $$
- Minimum tooth number: $$ z_{2,\text{min}} = \max_{\eta} \left( \frac{2 h_a^*}{\sin^2 \alpha_y} \right) $$
- Simplified form: $$ z_{2,\text{min}} = \frac{2 h_a^*}{ \sin^2 \alpha – \left( \frac{z_1}{q} \right)^2 \cos^2 \alpha } $$
These equations are essential tools for designing robust screw gears. By applying them, engineers can avoid undercutting and ensure efficient power transmission in screw gears assemblies.