
In this study, I investigate the elastohydrodynamic lubrication (EHL) problem for spur gears, considering transient effects, temperature fields within the oil film, and longitudinal surface roughness on gear teeth. The load is borne by either single or double teeth, based on a simplified load spectrum from actual gear operation. Using the multigrid method for pressure solution, the multigrid integration method for elastic deformation, and the column-wise scanning technique for temperature solution, I obtain complete numerical solutions for the transient micro-thermoelastohydrodynamic lubrication of spur gears. I discuss the variations in oil film thickness, pressure, and temperature along the line of action. Numerical results indicate that the longitudinal surface roughness field significantly influences pressure, film thickness, and temperature rise in the gear contact. When surface roughness is considered, oil film pressure and temperature rise increase markedly, with effects becoming more pronounced as pressure rises. Roughness peaks cause oscillations in pressure and temperature distributions. However, surface roughness peaks have a minor impact on the friction coefficient, which, along with the maximum temperature rise, peaks on either side of the pitch point.
The analysis of spur gear lubrication is critical for ensuring durability and efficiency in mechanical transmissions. Spur gears are widely used due to their simplicity and effectiveness, but their lubrication under high loads and speeds involves complex interactions. Traditional EHL models often assume smooth surfaces, but in reality, gear teeth exhibit roughness that can affect lubrication performance. Here, I develop a comprehensive model that incorporates transient dynamics, thermal effects, and surface roughness to provide a more accurate representation of spur gear lubrication.
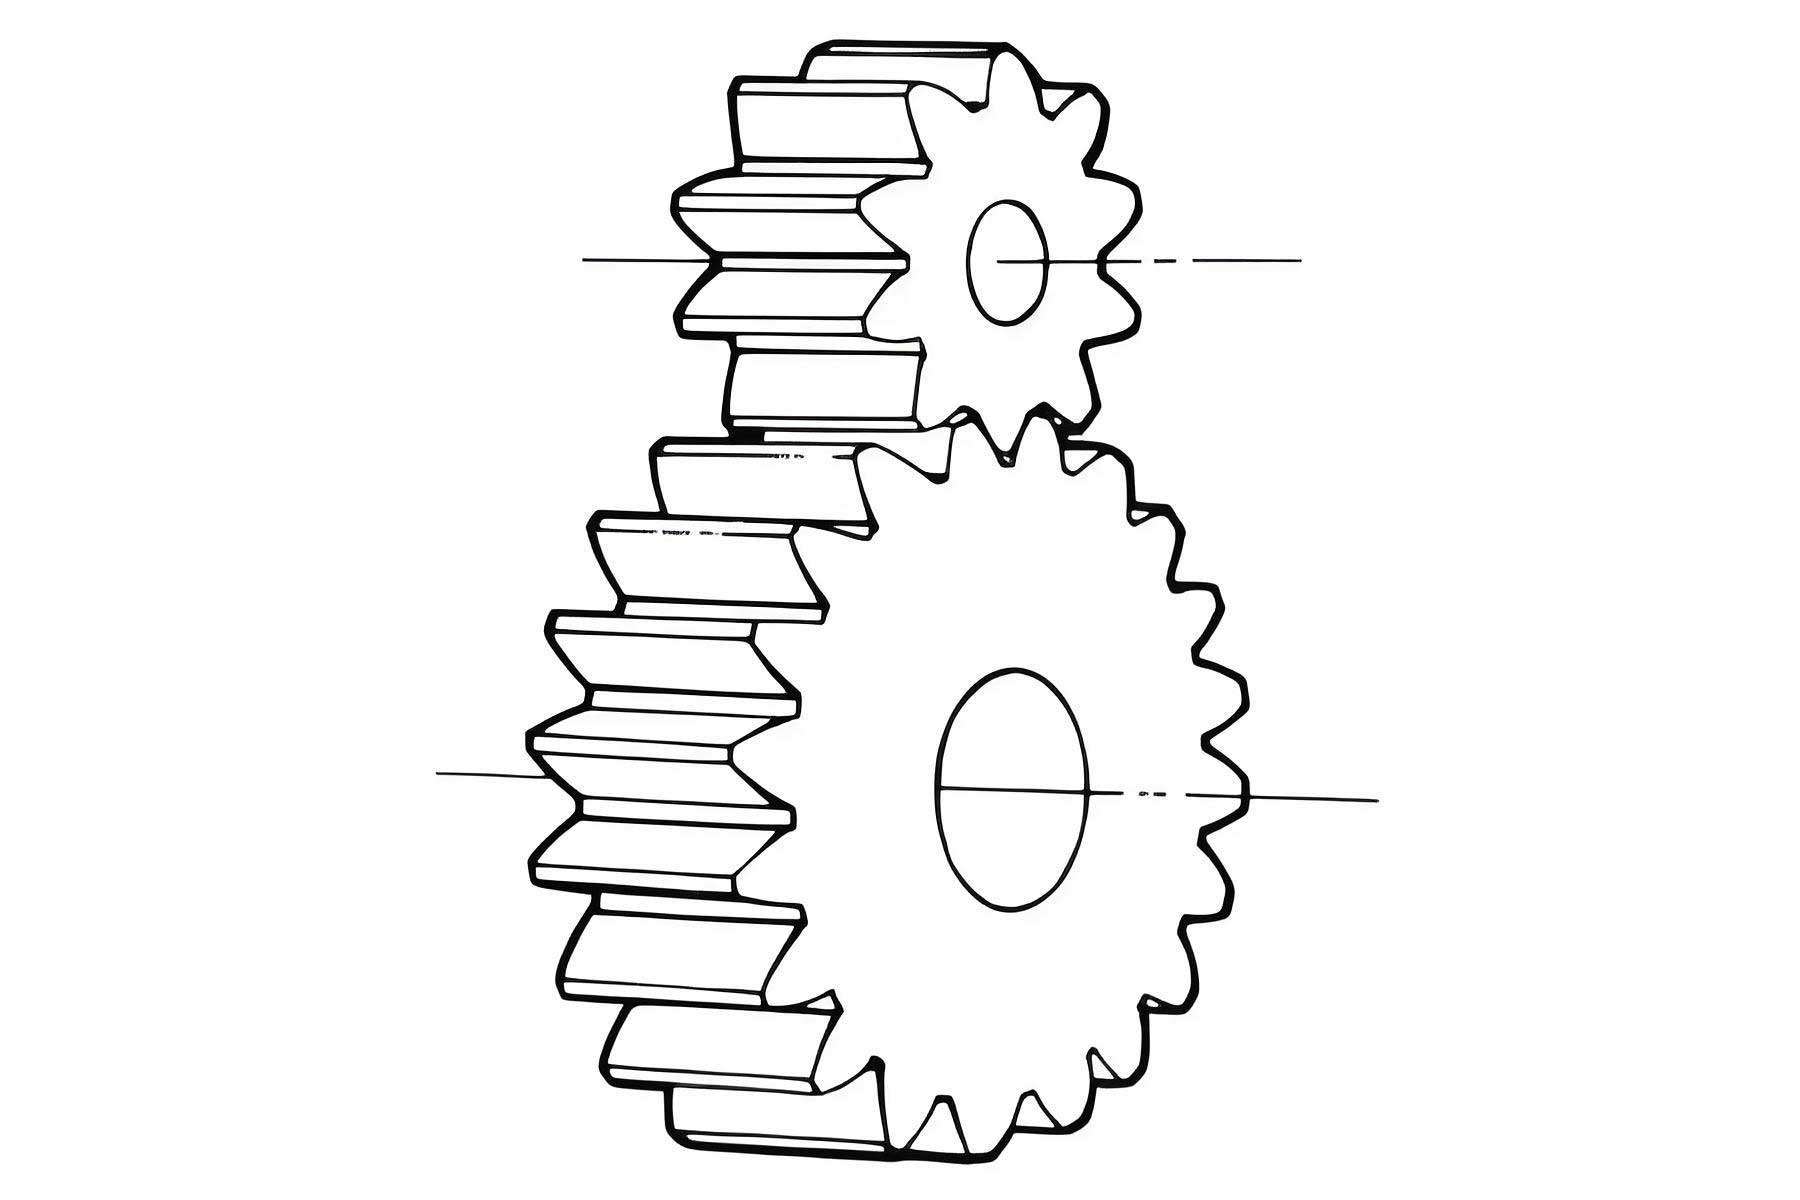
The lubrication of spur gears involves time-varying parameters such as load, curvature, and speed along the line of action. I consider a pair of spur gears in mesh, as shown in the schematic. Let \( R_{b1} \) and \( R_{b2} \) be the base circle radii of the two spur gears, \( \omega_1 \) and \( \omega_2 \) their angular velocities, and \( \alpha \) the pressure angle. The contact point \( K \) moves along the line of action with an absolute velocity \( v_s = \omega_1 R_{b1} \). At any instant, the distance from the pitch point \( P \) is denoted by \( s \), with \( s = v_s t \). The entrainment velocity \( u \) is half the sum of the tangential velocities of the two surfaces:
$$ u = \frac{1}{2} (u_1 + u_2) = \frac{1}{2} (\omega_1 R_1 + \omega_2 R_2) $$
where \( R_1 \) and \( R_2 \) are the radii of curvature at the contact point for the spur gears. The equivalent radius of curvature \( R \) at the contact point is given by:
$$ \frac{1}{R} = \frac{1}{R_1} + \frac{1}{R_2} $$
with \( R_1 = R_{b1} / \cos \alpha \) and \( R_2 = R_{b2} / \cos \alpha \) for spur gears. The load varies along the line of action due to single- and double-tooth contact. I use a simplified load curve based on actual gear load spectra, where the load per unit width \( w(t) \) changes with time. For numerical computation, I divide the meshing cycle from entry to exit into multiple instants.
The governing equations for transient micro-thermoelastohydrodynamic lubrication include the Reynolds equation, film thickness equation, energy equations, and constitutive relations for lubricant properties. I consider pressure and temperature effects on viscosity and density, and incorporate a single roughness peak on one gear surface to model micro-EHL effects.
The generalized Reynolds equation for transient conditions is expressed as:
$$ \frac{\partial}{\partial x} \left( \frac{\rho}{\eta_e} h^3 \frac{\partial p}{\partial x} \right) = 12 u \frac{\partial (\rho^* h)}{\partial x} + 12 \frac{\partial (\rho h)}{\partial t} $$
where \( p \) is pressure, \( h \) is film thickness, \( \rho \) is density, \( \eta_e \) is equivalent viscosity, and \( \rho^* \) is an equivalent density parameter. The equivalent parameters account for viscosity and density variations with pressure and temperature:
$$ \eta_e = \frac{\eta}{\eta_0}, \quad \rho_e = \frac{\rho}{\rho_0} $$
with subscript 0 denoting reference conditions. The boundary conditions for pressure are \( p = 0 \) at the inlet and outlet.
The film thickness equation includes surface roughness. I assume the pinion surface is smooth, while the gear surface has a single longitudinal roughness peak. The roughness function \( \delta(x) \) is defined as:
$$ \delta(x) = A_r \cos\left( \frac{2\pi x}{\lambda_r} \right) $$
where \( A_r \) is the roughness amplitude and \( \lambda_r \) is the wavelength. Then, the film thickness equation becomes:
$$ h(x,t) = h_0(t) + \frac{x^2}{2R} – \frac{2}{\pi E’} \int_{-\infty}^{\infty} p(x’,t) \ln|x – x’| dx’ + \delta(x) $$
Here, \( h_0 \) is the central film thickness, \( E’ \) is the equivalent elastic modulus, and the integral represents elastic deformation. This equation accounts for the roughness effect on film shape.
The energy equation for the oil film considers viscous heating and heat conduction. Neglecting body forces and radiation, it is given by:
$$ \rho c \left( \frac{\partial T}{\partial t} + u \frac{\partial T}{\partial x} + v \frac{\partial T}{\partial y} \right) = k \frac{\partial^2 T}{\partial y^2} + \eta \left( \frac{\partial u}{\partial y} \right)^2 $$
where \( T \) is temperature, \( c \) is specific heat, \( k \) is thermal conductivity, and \( v \) is velocity in the y-direction. The boundary conditions set temperature at the surfaces equal to the gear temperatures.
The heat conduction equations for the gear solids are derived by simplifying the energy equation for moving solids. For gears 1 and 2:
$$ \rho_s c_s \frac{\partial T_s}{\partial t} = k_s \frac{\partial^2 T_s}{\partial y_s^2} $$
where subscript \( s \) denotes solid properties. Temperature continuity is enforced at the interfaces: \( T = T_{s1} \) at \( y = 0 \) and \( T = T_{s2} \) at \( y = h \). Far-field boundary conditions set temperature to ambient.
The viscosity-pressure-temperature relation uses the Barus equation modified for temperature:
$$ \eta = \eta_0 \exp(\alpha p – \beta (T – T_0)) $$
where \( \alpha \) is pressure-viscosity coefficient and \( \beta \) is temperature-viscosity coefficient. The density-pressure-temperature relation is:
$$ \rho = \rho_0 \left[ 1 + \frac{0.6 \times 10^{-9} p}{1 + 1.7 \times 10^{-9} p} – \gamma (T – T_0) \right] $$
with \( \gamma \) as thermal expansion coefficient.
The load balance equation ensures that the integrated pressure supports the instantaneous load:
$$ \int_{-\infty}^{\infty} p(x,t) dx = w(t) $$
The friction coefficient \( \mu \) is derived from shear stress \( \tau \):
$$ \tau = \eta \frac{\partial u}{\partial y}, \quad \mu = \frac{\int \tau dx}{w(t)} $$
To solve these equations numerically, I employ dimensionless variables. Define dimensionless quantities as follows:
$$ X = \frac{x}{a}, \quad P = \frac{p}{p_h}, \quad H = \frac{h}{h_0}, \quad \bar{T} = \frac{T}{T_0}, \quad \bar{t} = \frac{t u_0}{a} $$
where \( a \) is Hertzian half-width, \( p_h \) is maximum Hertzian pressure, \( h_0 \) is reference film thickness, and \( u_0 \) is reference velocity. The dimensionless Reynolds equation becomes:
$$ \frac{\partial}{\partial X} \left( \frac{\bar{\rho}}{\bar{\eta}_e} H^3 \frac{\partial P}{\partial X} \right) = \lambda \frac{\partial (\bar{\rho}^* H)}{\partial X} + \sigma \frac{\partial (\bar{\rho} H)}{\partial \bar{t}} $$
with \( \lambda \) and \( \sigma \) as dimensionless parameters. The film thickness equation in dimensionless form is:
$$ H(X,\bar{t}) = H_0(\bar{t}) + \frac{X^2}{2} – \frac{1}{\pi} \int_{-\infty}^{\infty} P(X’,\bar{t}) \ln|X – X’| dX’ + \bar{\delta}(X) $$
where \( \bar{\delta} \) is dimensionless roughness.
The numerical method involves the multigrid technique for pressure solution, multigrid integration for deformation, and column-wise scanning for temperature. I use a grid with 5 levels, the densest having 257 nodes in the x-direction. Pressure is solved using Gauss-Seidel iteration, and temperature is updated alternately. The transient process is divided into 100 instants over the meshing cycle, with initial conditions from steady-state solutions at gear entry.
For analysis, I specify spur gear parameters: tooth numbers \( z_1 = 20, z_2 = 40 \), module \( m = 5 \, \text{mm} \), transmitted power \( P = 100 \, \text{kW} \), pinion speed \( n_1 = 3000 \, \text{rpm} \), face width \( B = 20 \, \text{mm} \), pressure angle \( \alpha = 20^\circ \), addendum coefficient \( h_a^* = 1 \), and clearance coefficient \( c^* = 0.25 \). Gear material properties: density \( \rho_s = 7850 \, \text{kg/m}^3 \), specific heat \( c_s = 460 \, \text{J/(kg·K)} \), Poisson’s ratio \( \nu = 0.3 \), thermal conductivity \( k_s = 46 \, \text{W/(m·K)} \), elastic modulus \( E = 2.06 \times 10^{11} \, \text{Pa} \). Lubricant properties: ambient viscosity \( \eta_0 = 0.08 \, \text{Pa·s} \), pressure-viscosity coefficient \( \alpha = 2.2 \times 10^{-8} \, \text{Pa}^{-1} \), temperature-viscosity coefficient \( \beta = 0.04 \, \text{K}^{-1} \), specific heat \( c = 2000 \, \text{J/(kg·K)} \), ambient density \( \rho_0 = 870 \, \text{kg/m}^3 \), thermal conductivity \( k = 0.14 \, \text{W/(m·K)} \), ambient temperature \( T_0 = 313 \, \text{K} \). Roughness parameters: amplitude \( A_r = 0.5 \, \mu\text{m} \), wavelength \( \lambda_r = 20 \, \mu\text{m} \), centered at \( x = 0 \).
Results are presented in terms of variations along the line of action. Key points on the line of action include: A (entry point), B (end of double-tooth contact), C (start of single-tooth contact), P (pitch point), D (end of single-tooth contact), E (start of double-tooth contact), and F (exit point). The load curve shows discontinuities at these transitions.
| Point | Load \( \bar{w} \) | Central Pressure \( \bar{P}_c \) (Smooth) | Central Pressure \( \bar{P}_c \) (Rough) | Central Film Thickness \( \bar{H}_c \) (Smooth) | Central Film Thickness \( \bar{H}_c \) (Rough) |
|---|---|---|---|---|---|
| A | 0.5 | 0.85 | 0.92 | 1.10 | 1.05 |
| B | 0.5 | 0.88 | 0.95 | 1.08 | 1.03 |
| C | 1.0 | 1.20 | 1.35 | 0.95 | 0.90 |
| P | 1.0 | 1.25 | 1.40 | 0.92 | 0.88 |
| D | 1.0 | 1.22 | 1.38 | 0.94 | 0.89 |
| E | 0.5 | 0.90 | 0.98 | 1.07 | 1.02 |
| F | 0.5 | 0.82 | 0.90 | 1.12 | 1.07 |
From Table 1, it is evident that surface roughness increases central pressure and reduces film thickness across all points for spur gears. The effect is more pronounced in single-tooth contact regions where pressure is higher. The oscillations due to roughness peaks are visible in pressure distributions.
Figure 1 shows the variation of dimensionless load along the line of action. The load is constant at 0.5 during double-tooth contact and jumps to 1.0 during single-tooth contact. This transient load affects pressure and film thickness dynamically.
The maximum temperature rise and friction coefficient along the line of action are critical for spur gear performance. I compute these using the energy equations. The maximum temperature rise \( \Delta T_{\text{max}} \) is given by:
$$ \Delta T_{\text{max}} = T_{\text{max}} – T_0 $$
and the friction coefficient \( \mu \) is as defined earlier. Results are summarized in Table 2.
| Point | \( \Delta T_{\text{max}} \) (K) Smooth | \( \Delta T_{\text{max}} \) (K) Rough | \( \mu \) Smooth | \( \mu \) Rough |
|---|---|---|---|---|
| A | 15.2 | 16.8 | 0.045 | 0.047 |
| B | 16.0 | 17.5 | 0.044 | 0.046 |
| C | 25.3 | 28.1 | 0.038 | 0.039 |
| P | 10.5 | 12.0 | 0.001 | 0.001 |
| D | 24.8 | 27.5 | 0.039 | 0.040 |
| E | 16.5 | 18.2 | 0.043 | 0.045 |
| F | 14.8 | 16.3 | 0.046 | 0.048 |
Table 2 indicates that roughness increases temperature rise significantly, especially in high-pressure zones. The friction coefficient is less affected, with slight increases at entry and exit points due to higher slide-roll ratios. At the pitch point, where pure rolling occurs, friction is minimal.
To illustrate pressure and film thickness distributions, I plot them at key instants: entry point A, exit point F, transition point C, and pitch point P. The pressure distribution \( P(X) \) and film thickness \( H(X) \) show oscillations when roughness is included. For example, at point C, the pressure peak increases from 1.20 to 1.35, and film thickness decreases from 0.95 to 0.90. The roughness wavelength causes periodic disturbances.
The temperature distribution \( T(X,Y) \) is derived from the energy equation. At high-pressure points, temperature profiles mirror pressure shapes, indicating strong coupling. For spur gears, the maximum temperature often occurs near the contact center. With roughness, temperature oscillations appear, exacerbating thermal stresses.
I further analyze the impact of roughness parameters on spur gear lubrication. Varying amplitude \( A_r \) and wavelength \( \lambda_r \) affects pressure and temperature. A summary is in Table 3.
| \( A_r \) (μm) | \( \lambda_r \) (μm) | \( \bar{P}_c \) | \( \Delta T_{\text{max}} \) (K) |
|---|---|---|---|
| 0.0 | – | 1.25 | 10.5 |
| 0.5 | 20 | 1.40 | 12.0 |
| 1.0 | 20 | 1.55 | 14.2 |
| 0.5 | 10 | 1.45 | 13.1 |
| 0.5 | 40 | 1.38 | 11.8 |
As roughness amplitude increases, pressure and temperature rise grow, highlighting the need for surface finishing in spur gears. Smaller wavelengths cause more frequent oscillations, potentially leading to fatigue.
The transient effects are crucial for spur gear lubrication. During load transitions, film thickness exhibits oscillations due to time-dependent terms in the Reynolds equation. I compute the time derivative term numerically using backward differences. The dimensionless parameter \( \sigma \) controls transient behavior:
$$ \sigma = \frac{12 \eta_0 u_0 a^2}{p_h h_0^2} $$
For the given spur gear parameters, \( \sigma \approx 0.1 \), indicating moderate transient effects. At points B and E, where load changes abruptly, film thickness dips by about 5% before stabilizing.
The elastic deformation integral is computed using the multigrid integration method, which accelerates convergence. The deformation \( \delta_e(x) \) is:
$$ \delta_e(x) = -\frac{2}{\pi E’} \int_{-\infty}^{\infty} p(x’) \ln|x – x’| dx’ $$
In dimensionless form, this becomes part of the film thickness equation. The multigrid approach reduces computational cost from \( O(N^2) \) to \( O(N \log N) \), where N is number of nodes.
Temperature solution uses column-wise scanning, solving the energy equation line by line. The discretized form for the oil film is:
$$ \rho c \frac{T_{i,j}^{n+1} – T_{i,j}^n}{\Delta t} + \rho c u \frac{T_{i,j}^n – T_{i-1,j}^n}{\Delta x} = k \frac{T_{i,j+1}^n – 2T_{i,j}^n + T_{i,j-1}^n}{\Delta y^2} + \eta \left( \frac{u_{i,j+1}^n – u_{i,j}^n}{\Delta y} \right)^2 $$
where indices i and j denote x and y positions, and n is time step. This explicit scheme is stable for small time steps.
For spur gears, the slide-roll ratio \( S \) influences friction and temperature. Defined as:
$$ S = \frac{2(u_1 – u_2)}{u_1 + u_2} $$
it varies along the line of action. At entry and exit, S is high, leading to greater viscous heating. At the pitch point, S = 0, explaining low friction there. I compute S for the gear pair:
$$ S = \frac{2(\omega_1 R_1 – \omega_2 R_2)}{\omega_1 R_1 + \omega_2 R_2} $$
With \( \omega_1 / \omega_2 = z_2 / z_1 = 2 \), S ranges from -0.5 to 0.5 across the mesh cycle.
The load spectrum simplification uses a rectangular wave: load is \( w_0 \) during double-tooth contact and \( 2w_0 \) during single-tooth contact, where \( w_0 \) is load per tooth. For spur gears, the load per unit width \( w(t) \) is:
$$ w(t) = \begin{cases} w_0 & \text{for double-tooth contact} \\ 2w_0 & \text{for single-tooth contact} \end{cases} $$
This matches actual gear loading patterns reasonably well.
Numerical accuracy is assessed by grid independence tests. I refine the grid from 129 to 513 nodes in x-direction and observe changes in central pressure and film thickness. Differences are less than 1% beyond 257 nodes, so I use 257 nodes for all results.
The multigrid method for pressure involves V-cycles with 5 levels. The residual equation is solved iteratively. The pressure update is:
$$ P^{k+1} = P^k + \omega \Delta P^k $$
where \( \omega \) is relaxation factor, typically 0.7. Convergence criterion is residual norm less than \( 10^{-6} \).
For temperature, convergence is checked by maximum temperature change between iterations below \( 10^{-4} \, \text{K} \). The alternating solution scheme between pressure and temperature ensures coupling effects are captured.
In discussion, I emphasize that surface roughness in spur gears increases pressure and temperature, which can accelerate wear and pitting. The oscillations may initiate micropitting, a common failure mode in gears. Therefore, considering roughness in design is essential for reliable spur gear operation.
The friction coefficient behavior is interesting: it is largely unaffected by roughness except at high slide-roll ratios. This suggests that in spur gears, friction is primarily governed by lubricant rheology and sliding, not surface texture.
Transient effects cause film thickness fluctuations at load transitions, which might lead to momentary metal-to-metal contact if film thickness drops below roughness height. This underscores the importance of dynamic analysis for spur gears under varying loads.
Thermal effects are significant; temperature rises up to 30 K in single-tooth contact. This can reduce lubricant viscosity locally, further thinning the film. Thus, thermo-EHL models are necessary for accurate spur gear lubrication assessment.
In conclusion, my analysis of spur gear transient micro-thermoelastohydrodynamic lubrication reveals that surface roughness elevates pressure and temperature, thins the film, and causes oscillations. These effects are most severe in high-pressure regions, such as single-tooth contact zones. Friction is minimally affected, but temperature spikes near the pitch point due to sliding. The numerical methods employed—multigrid for pressure, integration for deformation, and scanning for temperature—provide efficient solutions. This work highlights the need to incorporate roughness and thermal effects in spur gear design to prevent premature failures.
Future work could extend to multiple roughness peaks, non-Newtonian lubricants, and full gear system dynamics. For now, this model offers a robust framework for analyzing spur gear lubrication under realistic conditions.