
In the realm of precision gear manufacturing, gear honing stands as a critical finishing process, particularly for hardened gears where surface finish and dimensional accuracy are paramount. Traditional gear honing methods, while effective, often suffer from limitations such as low honing speeds and reduced efficiency, which hinder the broader adoption and development of gear honing technologies. As a researcher deeply immersed in advanced manufacturing techniques, I have explored the integration of ultrasonic vibrations into gear honing processes, leading to the innovative approach known as ultrasonic vibration gear honing. This method promises enhanced material removal rates, improved surface quality, and extended tool life, thereby addressing the shortcomings of conventional gear honing. In this comprehensive article, I will delve into the fundamental principles, material removal mechanisms, and practical implications of ultrasonic vibration gear honing, with a focus on quantitative analyses using formulas and tables to elucidate key concepts. Throughout this discussion, the term “gear honing” will be repeatedly emphasized to underscore its centrality in this technological advancement.
The core idea behind ultrasonic vibration gear honing is to superimpose high-frequency vibrations onto the relative motion between the honing tool and the gear workpiece. Typically, these vibrations are applied to the gear itself, inducing micro-impacts that facilitate material removal. From a microscopic perspective, the gear honing process involves the interaction of numerous abrasive grains on the honing wheel with the gear tooth surface. These grains, often made of cubic boron nitride (CBN) due to its superior hardness and thermal stability, act as tiny cutting edges that engage in negative-rake-angle切削, similar to grinding operations. The arrangement of these grains is irregular, as illustrated in the following figure, which depicts the distribution on the honing wheel齿廓 surface. This irregularity contributes to the complexity of the gear honing process, necessitating a detailed mechanistic analysis.
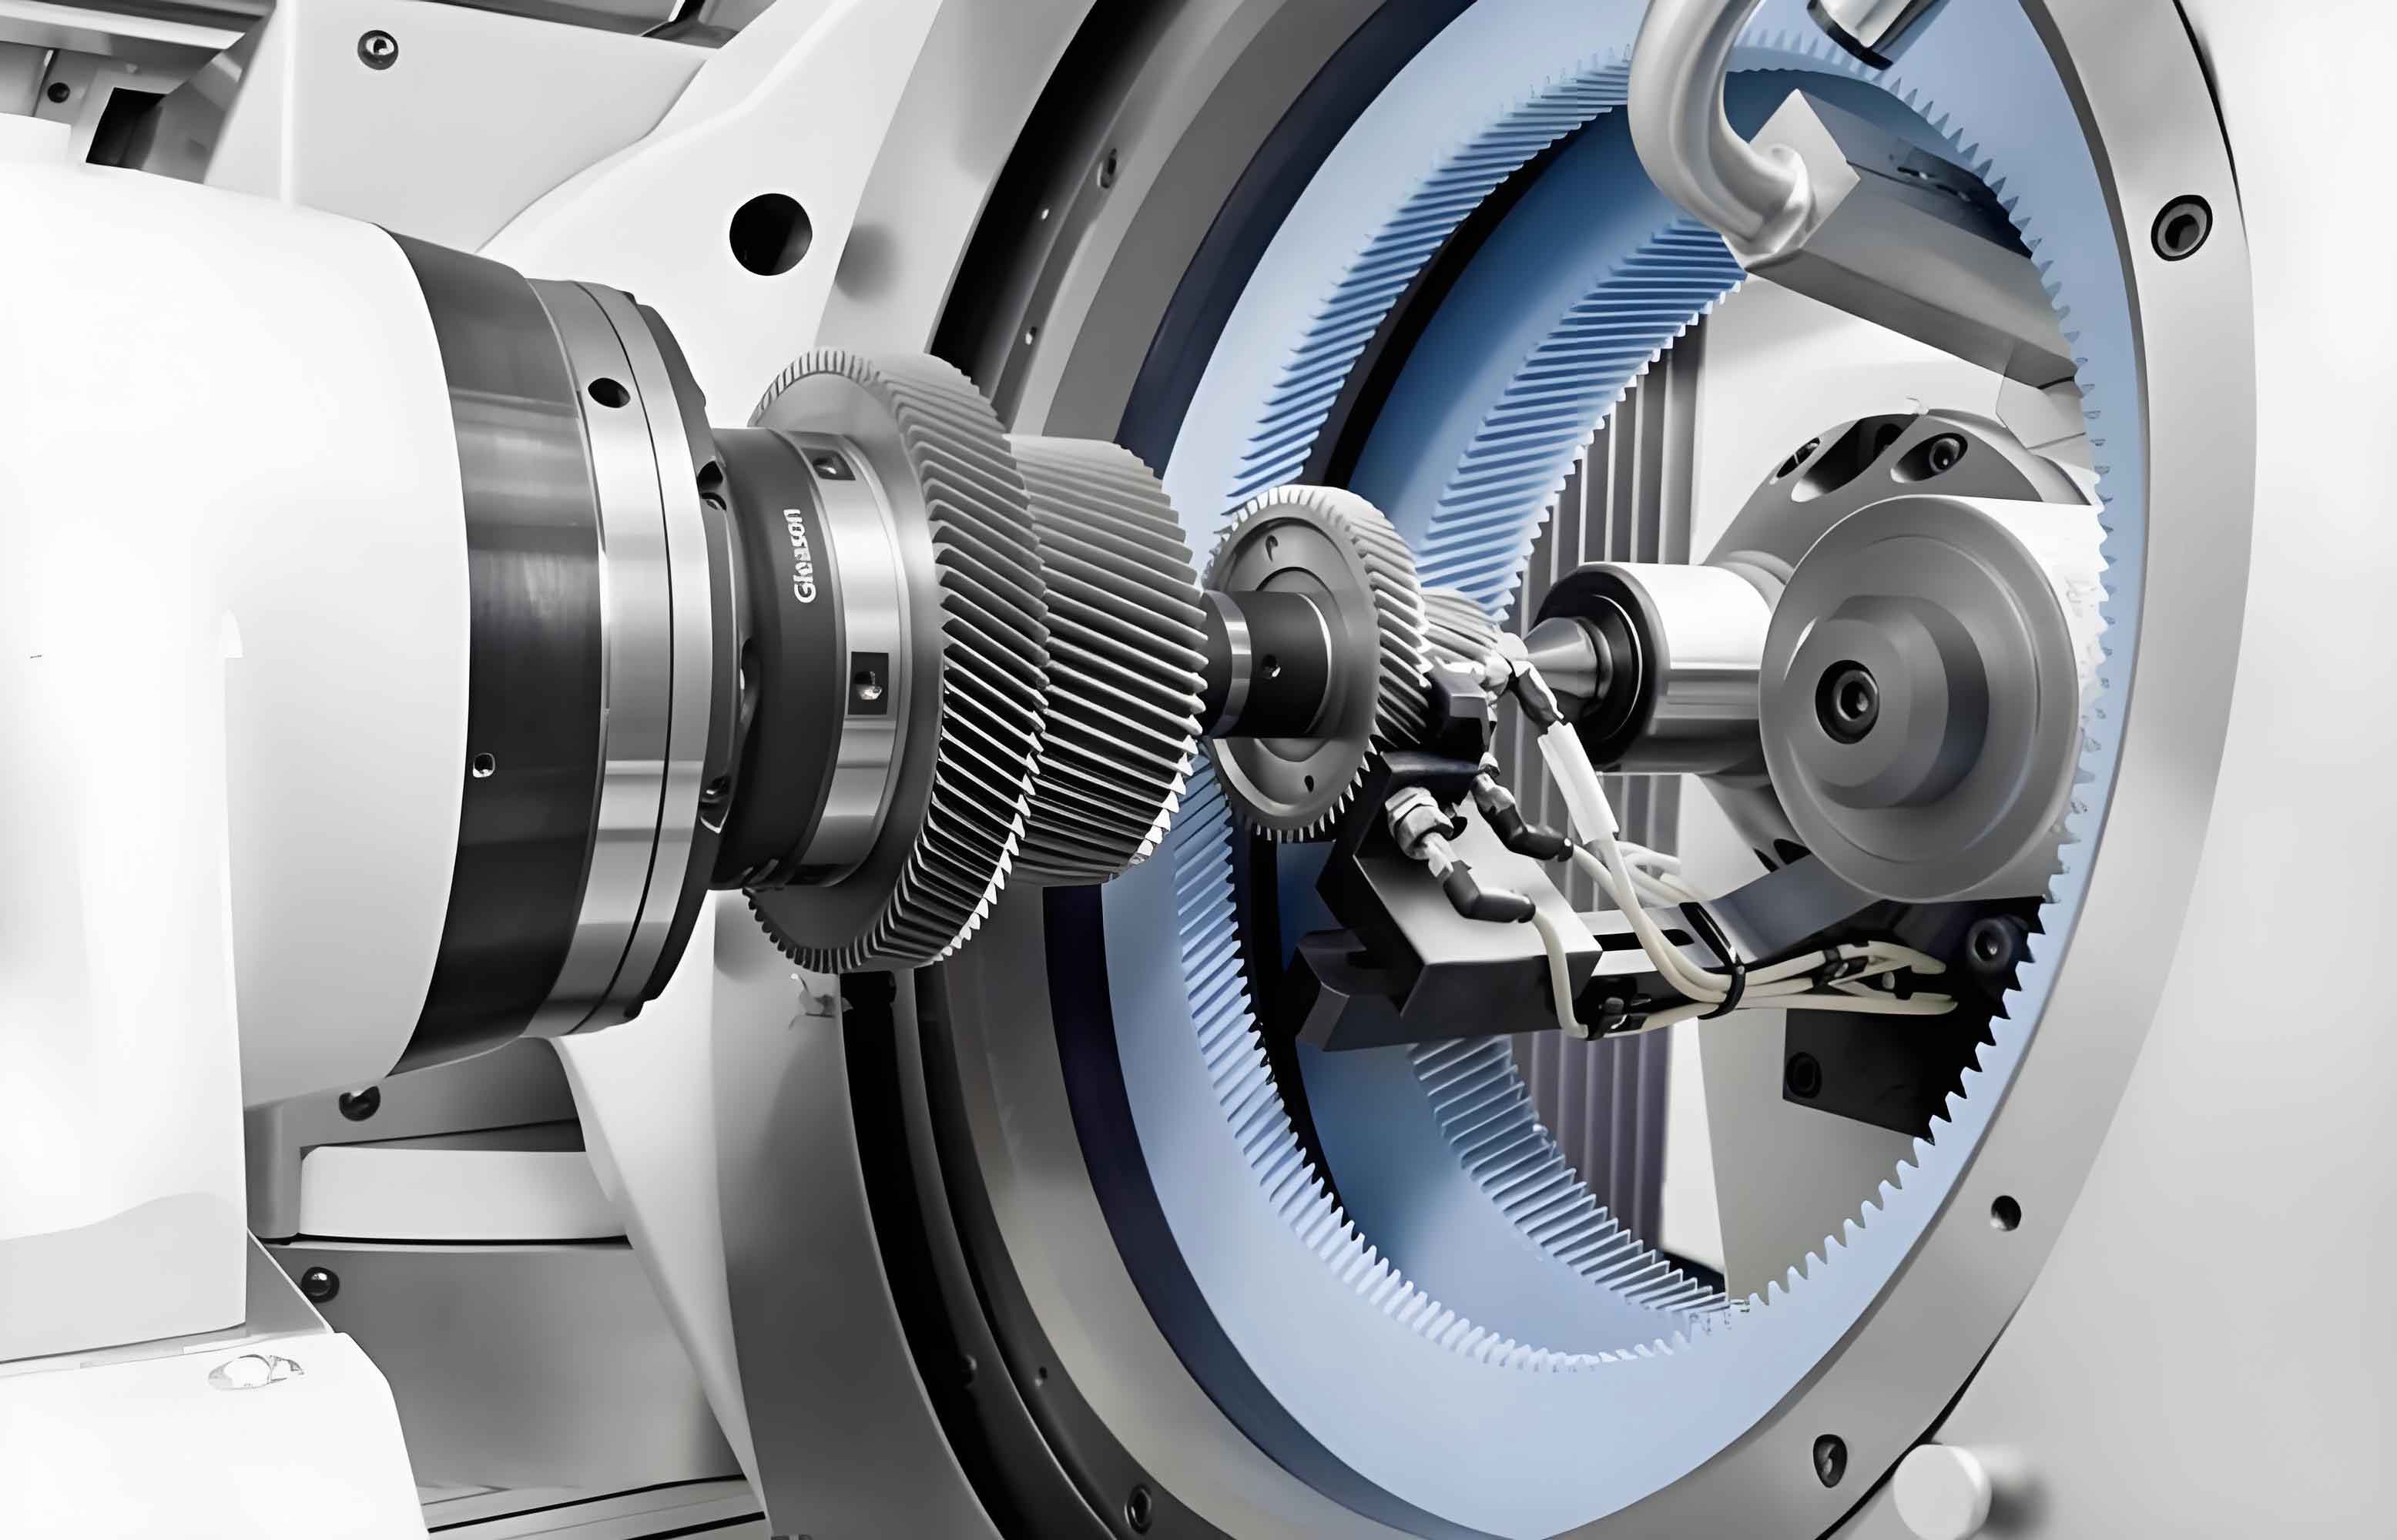
To understand the material removal in ultrasonic vibration gear honing, we must first examine the dynamics of a single abrasive grain. When ultrasonic vibrations are applied, the gear workpiece undergoes oscillatory motion, which can be described by a simple harmonic equation. Let the displacement of the gear be represented as:
$$x(t) = A \sin(\omega t)$$
where \(A\) is the amplitude in micrometers, and \(\omega = 2\pi f\) is the angular frequency with \(f\) being the vibration frequency in Hz. The velocity of the gear is then the time derivative:
$$v(t) = \frac{dx}{dt} = A\omega \cos(\omega t)$$
If the mass of the gear is \(M\), the impulsive force generated during vibration can be approximated as the rate of change of momentum over a small time interval \(\Delta t\):
$$F = M \frac{\Delta v}{\Delta t} = \frac{M A \omega \cos(\omega t)}{\Delta t}$$
This impulsive force is distributed among the active abrasive grains in contact. To quantify this, we need to determine the number of dynamic effective grains \(N_d\) per unit contact area. Based on established models from grinding and honing literature, \(N_d\) can be expressed as:
$$N_d = A_n (C_e)^\psi \left( \frac{v_w}{v_s} \right) \left( \frac{a_p}{d_{se}} \right)^{\frac{\alpha}{2}}$$
Here, \(A_n\) is a proportionality coefficient related to static grain density (typically around 1.2), \(C_e\) is a coefficient depending on the grain distribution density and shape on the honing wheel, \(v_w\) is the workpiece linear velocity, \(v_s\) is the honing wheel linear velocity, \(a_p\) is the honing depth, and \(d_{se}\) is the honing wheel diameter. The exponents \(\psi\) and \(\alpha\) depend on the grain geometry and distribution. For an arbitrary contact length \(l\) along the honing arc, the number of dynamic grains \(N_d(l)\) becomes:
$$N_d(l) = N_d \left( \frac{l}{l_s} \right)^\beta = A_n (C_e)^\psi \left( \frac{v_w}{v_s} \right) \left( \frac{a_p}{d_{se}} \right)^{\frac{\alpha}{2}} \left( \frac{l}{l_s} \right)^\beta$$
where \(l_s\) is the total contact arc length, and \(\beta\) is an index influenced by cutting edge shape and distribution. Consequently, the impulsive force per grain during ultrasonic vibration gear honing is:
$$F_{gd} = \frac{F}{N_d(l)} = \frac{M A \omega \cos(\omega t)}{\Delta t} \times \frac{1}{A_n (C_e)^\psi} \times \frac{v_s}{v_w} \times \left( \frac{d_{se}}{a_p} \right)^{\frac{\alpha}{2}} \times \left( \frac{l_s}{l} \right)^\beta$$
The maximum impulsive force per grain occurs when \(\cos(\omega t) = 1\):
$$F_{gdm} = \frac{M A \omega}{\Delta t} \times \frac{1}{A_n (C_e)^\psi} \times \frac{v_s}{v_w} \times \left( \frac{d_{se}}{a_p} \right)^{\frac{\alpha}{2}} \times \left( \frac{l_s}{l} \right)^\beta$$
In contrast, for conventional gear honing without ultrasonic vibration, the force on a single grain is derived from the overall honing load \(W\), which can be measured experimentally. Assuming the same honing parameters, the force per grain \(F_{gs}\) is:
$$F_{gs} = \frac{W}{N_d(l)} = \frac{W}{A_n (C_e)^\psi} \times \frac{v_s}{v_w} \times \left( \frac{d_{se}}{a_p} \right)^{\frac{\alpha}{2}} \times \left( \frac{l_s}{l} \right)^\beta$$
When ultrasonic vibrations are superimposed, the total force on a single grain \(F_{gdh}\) becomes the vector sum of the impulsive force and the conventional honing force:
$$\vec{F}_{gdh} = \vec{F}_{gd} + \vec{F}_{gs}$$
This combined force enhances the material removal mechanism by introducing cyclic loading and micro-fracture at the grain-workpiece interface. The negative rake angle of the grains (typically 90° to 120°) means that cutting occurs primarily through extrusion and shearing, with the normal force component dominating over the tangential component. This is illustrated in a grain切削 diagram where the force \(dF_x\) resolves into normal \(dF_{nx}\) and lateral \(dF_{tx}\) components; the lateral components cancel out, while the normal components accumulate, leading to high compressive stresses that facilitate material removal.
To further elucidate the differences between ultrasonic vibration gear honing and conventional gear honing, I have compiled a comparative table summarizing key parameters and their effects on material removal efficiency. This table highlights how ultrasonic vibrations alter the dynamics of the gear honing process.
| Parameter | Conventional Gear Honing | Ultrasonic Vibration Gear Honing |
|---|---|---|
| Honing Speed | Relatively low, limited by thermal and mechanical constraints | Enhanced due to reduced cutting forces and improved chip evacuation |
| Single Grain Force | Steady-state, derived from honing load \(W\) | Pulsating, with impulsive component \(F_{gd}\) superimposed |
| Material Removal Rate | Moderate, often limited by wheel wear | Higher, due to micro-impact and fatigue mechanisms |
| Surface Finish | Good, but may exhibit burnishing effects | Excellent, with reduced surface roughness and minimal subsurface damage |
| Tool Life | Lower, especially for resin-bonded wheels | Extended, as vibrations reduce adhesive wear and loading |
| Heat Generation | Significant if cooling is inadequate | Reduced due to intermittent cutting and better fluid penetration |
Another critical aspect of gear honing is the management of honing heat. Since honing involves relatively low cutting speeds and small切削 volumes, heat generation is less pronounced compared to grinding. However, it still warrants attention, especially when using CBN abrasives, which can react with water vapor and oxygen at elevated temperatures (around 1000°C), forming ammonia and boric acid. Therefore, water-based cutting fluids are generally avoided in CBN gear honing. Instead, kerosene is often employed as a cutting fluid due to its effective lubrication and cleaning properties. The fluid is injected under pressure into the honing zone to carry away chips, prevent wheel clogging, and dissipate heat. Filtration of the cutting fluid is essential to maintain its efficacy and protect the honing wheel and workpiece surfaces.
The material removal mechanism in ultrasonic vibration gear honing can be further analyzed through the concept of specific energy. The specific honing energy \(u\) is defined as the energy required to remove a unit volume of material. For conventional gear honing, it can be expressed as:
$$u_c = \frac{P_c}{Q_w}$$
where \(P_c\) is the honing power and \(Q_w\) is the volumetric material removal rate. In ultrasonic vibration gear honing, the total power \(P_u\) includes both the conventional honing power and the ultrasonic vibration power \(P_v\):
$$P_u = P_c + P_v = F_{gs} v_s + \frac{1}{2} \zeta A^2 \omega^3$$
Here, \(\zeta\) is a damping coefficient related to the vibration system. The volumetric removal rate \(Q_w\) may increase due to enhanced cutting efficiency, so the specific energy becomes:
$$u_u = \frac{P_u}{Q_w}$$
Typically, \(u_u < u_c\), indicating that ultrasonic vibration gear honing is more energy-efficient. This efficiency stems from the reduction in apparent shear strength of the workpiece material under high-frequency vibrations, a phenomenon known as “acoustic softening.”
To quantify the material removal rate in gear honing, we can use a model based on the number of active grains and the volume removed per grain per cycle. For ultrasonic vibration gear honing, each grain experiences a cyclic loading that promotes crack initiation and propagation in brittle materials like hardened steel. The volume removed per grain per vibration cycle \(V_g\) can be approximated by considering the indentation fracture mechanics:
$$V_g = k \left( \frac{F_{gdh}}{K_{IC}} \right)^3$$
where \(k\) is a material constant, and \(K_{IC}\) is the fracture toughness of the workpiece material. The total material removal rate \(Q_w\) is then:
$$Q_w = N_d(l) \cdot f \cdot V_g$$
Substituting the expressions for \(N_d(l)\) and \(F_{gdh}\), we obtain a comprehensive formula linking process parameters to removal rate. This model underscores the importance of ultrasonic frequency \(f\) and amplitude \(A\) in enhancing gear honing productivity.
In practice, the implementation of ultrasonic vibration gear honing requires careful design of the acoustic system, including transducers, boosters, and horns to deliver vibrations to the gear workpiece. The vibration frequency typically ranges from 20 kHz to 40 kHz, with amplitudes of a few micrometers. The honing wheel, often a CBN-plated斜齿外珩轮, must withstand the dynamic loads without premature grain dislodgement. Compared to resin-bonded wheels, electroplated CBN wheels offer higher grain protrusion and stronger bonding, making them ideal for ultrasonic vibration gear honing applications.
To illustrate the parameter dependencies, I present another table showing how variations in ultrasonic vibration parameters affect key outcomes in gear honing. This table can guide process optimization for specific gear honing tasks.
| Vibration Parameter | Effect on Honing Force | Effect on Removal Rate | Effect on Surface Integrity |
|---|---|---|---|
| Amplitude \(A\) | Increases impulsive force linearly | Increases due to larger indentation | May increase roughness if too high; optimal range improves finish |
| Frequency \(f\) | Increases impulsive force proportionally to \(\omega\) | Increases linearly with frequency | Higher frequency reduces chatter and improves uniformity |
| Phase \(\phi\) | Modulates force superposition | Can optimize chip formation | Affects residual stress distribution |
Moreover, the gear honing process involves complex kinematics due to the crossed-axis configuration between the honing wheel and the gear. The relative velocity \(v_r\) at the contact point has both sliding and rolling components, which influence the cutting action. With ultrasonic vibration, an additional oscillatory velocity \(v_v = A\omega \cos(\omega t)\) is added, altering the effective cutting direction and promoting self-sharpening of the abrasive grains. This can be modeled by modifying the velocity ratio in the \(N_d\) formula to account for the vibration component.
The benefits of ultrasonic vibration gear honing extend beyond material removal. For instance, the induced vibrations can help in deburring and edge radiusing of gear teeth, which are critical for reducing stress concentrations and improving fatigue life. Additionally, the process can be applied to a variety of gear types, including spur, helical, and bevel gears, making it versatile for industrial gear honing operations.
From a thermodynamic perspective, the honing heat generated during ultrasonic vibration gear honing is dissipated through conduction to the workpiece and honing wheel, convection via the cutting fluid, and radiation. The temperature rise \(\Delta T\) in the cutting zone can be estimated using a simplified energy balance:
$$\Delta T = \frac{u_u Q_w \tau}{m C_p}$$
where \(\tau\) is the honing time per tooth, \(m\) is the mass of the heated volume, and \(C_p\) is the specific heat capacity. Since \(u_u\) is lower and \(Q_w\) is higher, the temperature rise may be comparable to or lower than in conventional gear honing, reducing the risk of thermal damage such as rehardening or tempering of the gear surface.
To achieve optimal results in gear honing, it is essential to select appropriate honing parameters. Based on experimental studies, I recommend the following ranges for ultrasonic vibration gear honing of hardened steel gears:
- Honing wheel speed \(v_s\): 10-30 m/s
- Workpiece speed \(v_w\): 5-15 m/s
- Honing depth \(a_p\): 0.01-0.05 mm
- Ultrasonic frequency \(f\): 20-30 kHz
- Amplitude \(A\): 2-10 µm
- Cutting fluid: Kerosene with high-pressure injection (5-10 bar)
These parameters ensure efficient material removal while maintaining surface quality and tool life in gear honing applications.
In conclusion, ultrasonic vibration gear honing represents a significant advancement in gear finishing technology. By leveraging high-frequency vibrations, this method enhances material removal mechanisms through impulsive forces, reduces specific energy, and improves surface integrity. The material removal is governed by complex interactions between abrasive grains and the workpiece, describable through力学 models and formulas. As the demand for high-precision gears grows in industries such as automotive, aerospace, and robotics, ultrasonic vibration gear honing offers a viable solution to overcome the limitations of traditional gear honing. Future research should focus on optimizing vibration parameters, developing advanced honing wheel designs, and integrating real-time monitoring systems to further elevate the efficacy of gear honing processes. Through continued innovation, gear honing will remain a cornerstone of quality gear manufacturing.
Throughout this exploration, I have emphasized the term “gear honing” to reinforce its importance in the context of ultrasonic vibration applications. The integration of tables and formulas, as presented, provides a quantitative foundation for understanding and implementing this advanced gear honing technique. As I reflect on the potential of ultrasonic vibration gear honing, it is clear that this technology not only enhances productivity but also contributes to sustainable manufacturing by reducing energy consumption and extending tool life, thereby aligning with modern industrial goals.