
Miter gears have always attracted my attention because of their outstanding load-carrying capacity and their ability to eliminate the axial force that commonly appears in helical gear transmissions. In my research, I have focused on the vibration behavior of a miter gear system under variable operating conditions. A miter gear pair can be regarded as two helical gear pairs with opposite handings, which means that the axial forces generated on the two sides can cancel each other. This characteristic makes miter gears highly suitable for heavy-duty applications such as aero engines, vehicle drivetrains, and marine propulsion systems. However, the increasing demand for higher speed, larger torque, and lower noise in modern mechanical transmission systems requires a deeper understanding of the dynamic behavior of miter gears. Therefore, I have developed a systematic approach that combines finite element analysis, a twelve-degree-of-freedom dynamic model, gearbox modal analysis, and experimental verification. The central goal of my work is to predict the vibration characteristics of a miter gear transmission system at the design stage and to provide a reliable theoretical basis for reducing vibration and noise.
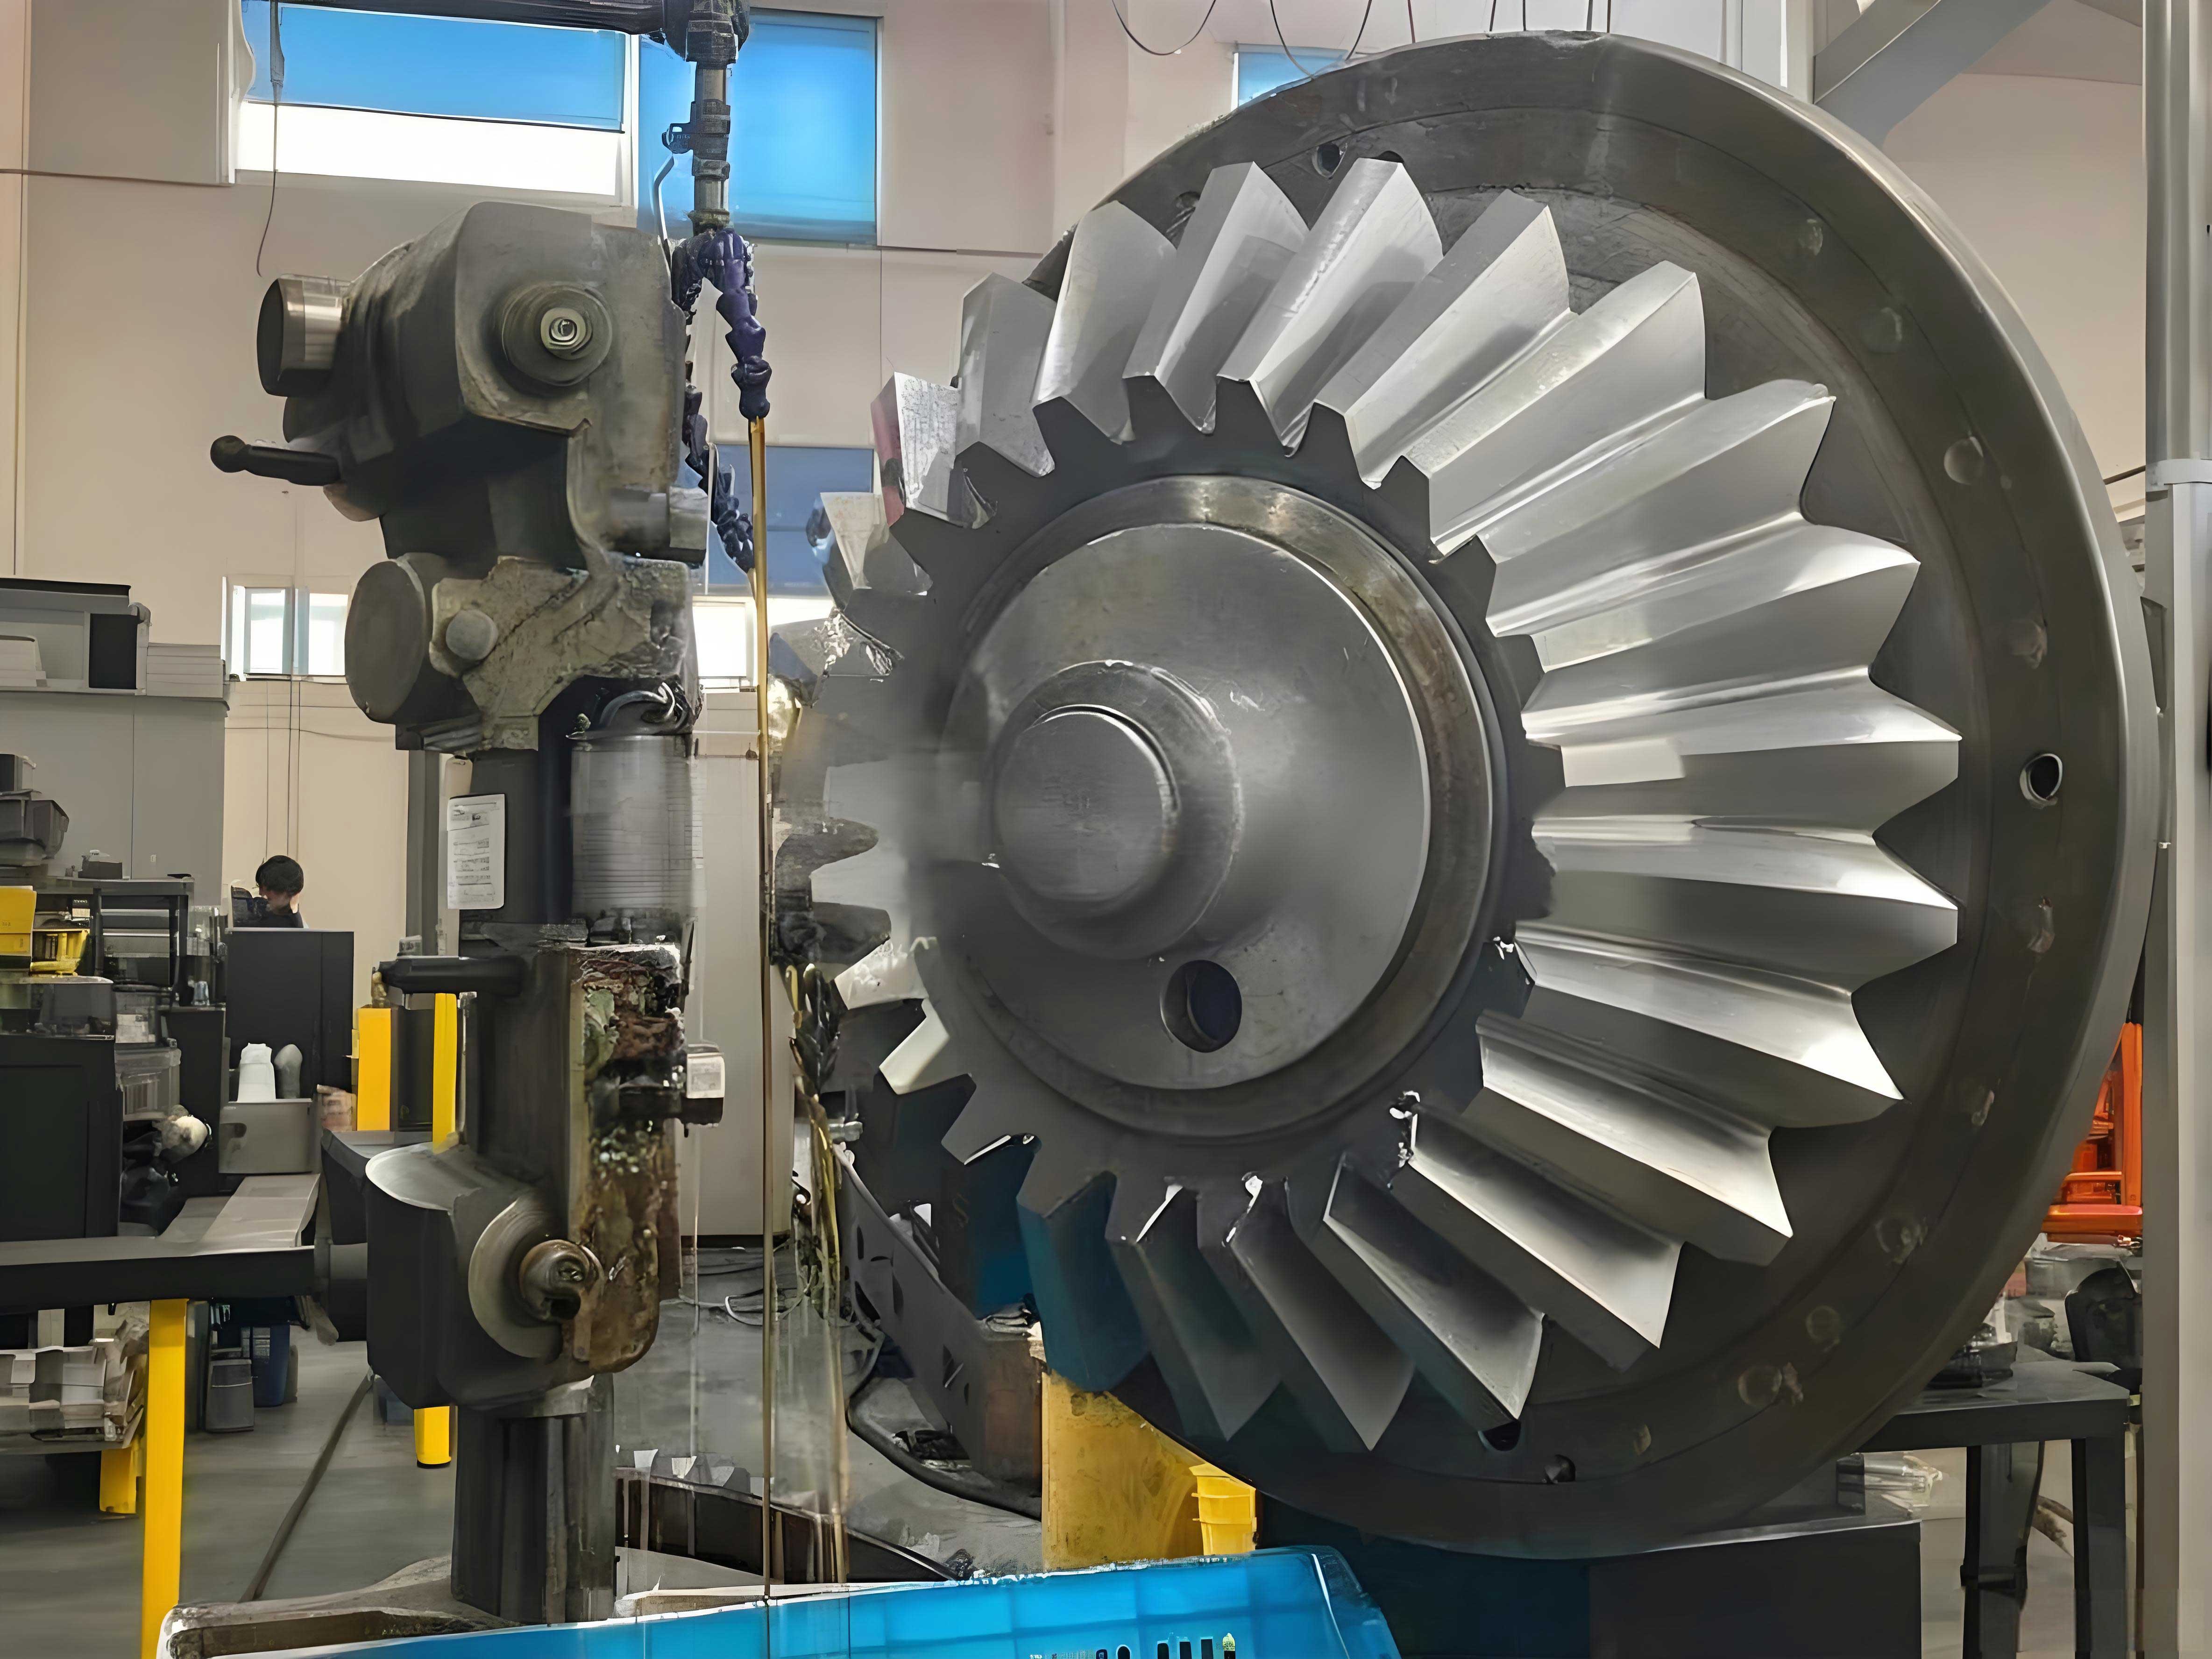
In my study, the meshing stiffness of a miter gear pair is the first key factor that I investigate. Meshing stiffness is defined as the ability of the gear teeth to resist elastic deformation under a normal load. Because the number of engaged tooth pairs changes periodically during rotation, the meshing stiffness of a miter gear pair is time-varying. For a miter gear, the total meshing stiffness can be considered as the sum of the meshing stiffness of the two opposite helical gear pairs. However, manufacturing errors and assembly errors often cause a symmetry deviation between the left and right tooth flanks, which leads to unbalanced loading and a reduction in the effective meshing stiffness. I have derived the fundamental equations for the comprehensive elastic deformation and the normal meshing stiffness as follows:
$$ \delta_n = \frac{\Delta \varphi \cdot m_n z_2 \cos \alpha_t}{2 \cos^2 \beta} $$
$$ \Delta \varphi = \varphi_2 – \frac{z_1}{z_2} \varphi_1 $$
$$ K_n = \frac{F_n}{\delta_n} $$
Here, \(\delta_n\) is the normal comprehensive elastic deformation, \(\Delta \varphi\) is the quasi-static transmission error, \(m_n\) is the normal module, \(z_1\) and \(z_2\) are the numbers of teeth of the pinion and the gear, \(\alpha_t\) is the transverse pressure angle, \(\beta\) is the helix angle, \(\varphi_1\) and \(\varphi_2\) are the rotation angles of the pinion and the gear, and \(F_n\) is the total normal load on the tooth surface. These equations form the basis for my finite element simulation of the miter gear meshing stiffness.
To perform the finite element analysis, I first established a three-dimensional model of a miter gear pair. The basic parameters of the miter gear pair used in my study are listed in Table 1. The pinion has 27 teeth, and the gear has 81 teeth. The normal module is 3.5 mm, the normal pressure angle is 20°, the center distance is 218.2 mm, and the helix angle is 30°. These parameters are consistent with the experimental setup that I later built.
| Parameter | Pinion | Gear |
|---|---|---|
| Number of teeth | 27 | 81 |
| Normal module (mm) | 3.5 | 3.5 |
| Normal pressure angle (°) | 20 | 20 |
| Center distance (mm) | 218.2 | |
| Helix angle (°) | 30 | 30 |
I used Pro/E to generate the involute profiles and the helical sweeps of the miter gear. The involute equation in polar coordinates can be written as:
$$ R = \frac{R_b}{\cos \alpha} $$
$$ \theta = \tan \alpha – \alpha $$
where \(R_b\) is the base radius, \(\alpha\) is the pressure angle at a point on the involute, and \(\theta\) is the involute angle. By converting these equations into Cartesian coordinates, I obtained the precise tooth profile. Then I imported the three-dimensional model into HyperMesh for mesh generation. Because the miter gear consists of two opposite helical sections, I first meshed one helical section and then mirrored it to obtain the full miter gear mesh. A fine mesh was applied near the tooth flanks to capture the contact deformation accurately. The resulting finite element mesh was then imported into Abaqus for contact analysis.
The meshing stiffness of the miter gear pair was computed under different symmetry deviations. I defined the symmetry deviation \(f_A\) as the distance between the actual intersection point of the two helical lines and the central plane of the miter gear. When \(f_A\) is zero, the left and right tooth flanks are perfectly symmetric. When \(f_A\) is nonzero, the load is no longer evenly distributed between the two sides. I considered \(f_A = 0\), \(10\,\mu\text{m}\), and \(20\,\mu\text{m}\). The results show that the meshing stiffness decreases as the symmetry deviation increases. Moreover, the difference between the left and right meshing stiffnesses becomes more pronounced. The contact stress distributions confirm that the side with a larger effective tooth thickness carries more load, while the other side carries less. This unbalanced loading is a major source of vibration in miter gear systems.
In addition to symmetry deviation, I also studied the effect of tooth profile modification on the meshing stiffness. Tooth profile modification is often used to reduce the transmission error and the dynamic load. I adopted a Walker curve for the modification, which is given by:
$$ \Delta = \Delta_{max} \left( \frac{x}{h} \right)^n $$
where \(\Delta_{max}\) is the maximum modification amount, \(x\) is the coordinate along the line of action measured from the starting point of modification, \(h\) is the modification height, and \(n\) is the modification exponent. In my analysis, I set \(n = 2\) to obtain a parabolic curve that smoothly connects with the original involute profile. I examined three cases: no modification, \(\Delta_{max} = 5\,\mu\text{m}\), and \(\Delta_{max} = 10\,\mu\text{m}\), with a modification height \(h = 3\,\text{mm}\). The results indicate that when \(\Delta_{max} = 5\,\mu\text{m}\), the comprehensive meshing stiffness slightly increases compared with the unmodified case. When \(\Delta_{max} = 10\,\mu\text{m}\), the maximum meshing stiffness decreases from \(2.011 \times 10^9\,\text{N/m}\) to \(1.992 \times 10^9\,\text{N/m}\), a reduction of about 0.95%. This shows that a moderate tooth profile modification can reduce the variation in meshing stiffness and lower the dynamic load, while excessive modification may reduce the load-carrying capacity. Table 2 summarizes the meshing stiffness under different modification amounts.
| Modification amount \(\Delta_{max}\) | Maximum meshing stiffness (\(\times 10^9\,\text{N/m}\)) | Relative change |
|---|---|---|
| 0 (unmodified) | 2.011 | — |
| 5 \(\mu\text{m}\) | 2.023 | +0.60% |
| 10 \(\mu\text{m}\) | 1.992 | -0.95% |
After obtaining the meshing stiffness, I proceeded to establish a dynamic model of the miter gear transmission system. I used the lumped parameter method and neglected the detailed connection between the gear hub and the shaft. The system was modeled as a twelve-degree-of-freedom bending-torsion-axial coupled system. The generalized displacement vector is:
$$ \{ \delta \} = \{ y_1, z_1, \theta_1, y_2, z_2, \theta_2, y_3, z_3, \theta_3, y_4, z_4, \theta_4 \} $$
where \(y_i\), \(z_i\), and \(\theta_i\) represent the translational displacements in the \(y\) and \(z\) directions and the rotational displacement of the four gear bodies. The subscripts 1 and 2 refer to the left pinion and left gear, while 3 and 4 refer to the right pinion and right gear. The equations of motion for the left pinion can be written as:
$$ m_1 \ddot{y}_1 + c_{y1} \dot{y}_1 + k_{y1} y_1 = -F_{y1} $$
$$ m_1 \ddot{z}_1 + c_{z13} (\dot{z}_1 – \dot{z}_3) + k_{z13} (z_1 – z_3) = -F_{z1} $$
$$ I_1 \ddot{\theta}_1 = -F_{y1} R_{b1} + T_1 – F_{s1} R_{b1} $$
Similar equations can be written for the left gear, the right pinion, and the right gear. The normal dynamic meshing force \(F_{n1}\) on the left side is given by:
$$ F_{n1} = c_{m1} \left[ \cos \beta_1 (\dot{y}_1 – \dot{y}_2 + R_{b1} \dot{\theta}_1 – R_{b2} \dot{\theta}_2) + \sin \beta_2 (\dot{z}_1 – \dot{z}_2) \right] + k_{m1} f \left[ \cos \beta_2 (y_1 – y_2 + R_{b1} \theta_1 – R_{b2} \theta_2) + \sin \beta_2 (z_1 – z_2 + \varepsilon_z) \right] $$
where \(\beta_1 = \beta\), \(\beta_2 = -\beta\), \(c_{m1}\) is the meshing damping, \(k_{m1}\) is the time-varying meshing stiffness, and \(f[\cdot]\) is the backlash function. The tangential and axial dynamic meshing forces are:
$$ F_{y1} = \cos \beta_2 F_{n1} $$
$$ F_{z1} = \sin \beta_2 F_{n1} $$
Similarly, for the right side, the normal dynamic meshing force \(F_{n2}\) and its components can be expressed in an analogous manner. The meshing damping is calculated as:
$$ C_m(t) = 2\zeta \sqrt{ \frac{k_m(t) I_p I_g}{r_{pb}^2 I_p + r_{gb}^2 I_g} } $$
where \(\zeta\) is the meshing damping coefficient, \(I_p\) and \(I_g\) are the moments of inertia of the pinion and the gear, and \(r_{pb}\) and \(r_{gb}\) are their base radii. The backlash function is defined as:
$$ f[x] = \begin{cases} X – \delta, & X > \delta \\ 0, & |X| \le \delta \\ X + \delta, & X < -\delta \end{cases} $$
where \(X\) is the dynamic transmission error and \(2\delta\) is the total backlash. In my model, the normal backlash is set to \(180\,\mu\text{m}\). The backlash function introduces a strong nonlinearity into the system, especially under light-load and high-speed conditions.
Another important excitation in my model is the meshing impact. When a pair of teeth enters mesh, the actual contact point may deviate from the theoretical point on the line of action because of elastic deformation and manufacturing errors. This phenomenon is called the meshing impact, and it can cause severe vibration and noise. I calculated the impact velocity \(v_s\) and the maximum impact force \(F_s\) using the following equations:
$$ v_s = \omega_1 r_{b1} \left( 1 + \frac{1}{i} \right) \left[ 1 – \frac{\cos(\lambda_1 + \gamma_1′)}{\cos \alpha} \right] $$
$$ F_s = v_s \sqrt{ \frac{J_1 J_2}{(J_1 r_{b2}’^2 + J_2 r_{b1}^2)(q_s + \cos^2 \theta \cdot q_p)} } $$
Here, \(\omega_1\) is the input angular velocity, \(r_{b1}\) is the base radius of the pinion, \(i\) is the transmission ratio, \(\lambda_1\) and \(\gamma_1’\) are geometric angles, \(\alpha\) is the pressure angle, \(J_1\) and \(J_2\) are the moments of inertia, \(q_s\) is the single-tooth compliance at the initial impact point, \(q_p\) is the comprehensive compliance of other tooth pairs, and \(\theta\) is the angle between the impact force and the normal direction. These equations allow me to predict the impact force as a function of rotational speed and load.
Using the dynamic model described above, I analyzed the vibration characteristics of the miter gear system under different operating conditions. The dynamic parameters of the system are listed in Table 3. The meshing damping coefficient is 0.1, the normal backlash is 180 \(\mu\text{m}\), the center distance installation error is 8 \(\mu\text{m}\), and the radial and axial support stiffnesses are given. I solved the equations of motion numerically and extracted the displacement and velocity responses of the pinion and the gear in both the axial and radial directions.
| Parameter | Pinion | Gear |
|---|---|---|
| Meshing damping coefficient \(\zeta\) | 0.1 | |
| Normal backlash \(2\delta\) (\(\mu\text{m}\)) | 180 | |
| Center distance installation error (\(\mu\text{m}\)) | 8 | |
| Radial support stiffness (\(\times 10^8\,\text{N/m}\)) | 6.34 | 6.34 |
| Axial support stiffness (\(\times 10^8\,\text{N/m}\)) | — | 2.03 |
The first condition I investigated was the effect of meshing stiffness on the system vibration. Because of the symmetry deviation, the left and right meshing stiffnesses are different. I considered three cases: \(f_A = 0\), \(10\,\mu\text{m}\), and \(20\,\mu\text{m}\). The axial vibration displacement and velocity of the pinion and the gear were computed. The results show that as the symmetry deviation increases, the amplitude of both the axial displacement and the axial velocity increases. This is because the unbalanced load causes a larger dynamic mesh force on one side, which in turn excites stronger axial vibration. The radial vibration follows a similar trend, but the amplitudes are generally smaller than those in the axial direction. In addition, the vibration amplitude of the pinion is larger than that of the gear, which is consistent with the fact that the pinion has a smaller moment of inertia and is closer to the input excitation.
Next, I examined the effect of meshing impact on the axial vibration. I calculated the impact force at three different load torques: \(200\,\text{N}\cdot\text{m}\), \(250\,\text{N}\cdot\text{m}\), and \(300\,\text{N}\cdot\text{m}\). The results indicate that the impact velocity and the maximum impact force increase with the load torque. This is because a higher load torque leads to a larger elastic deformation and a larger base pitch error, which in turn increases the impact velocity. The axial vibration velocity of the pinion also increases with the load torque. The impact force acts as a short-duration pulse, and its frequency content is rich in high harmonics, which can excite the natural frequencies of the gearbox. Therefore, the meshing impact is an important excitation that must be considered in the vibration analysis of miter gears.
I also studied the influence of load torque on the system vibration. Keeping the input speed constant, I varied the load torque from \(200\,\text{N}\cdot\text{m}\) to \(300\,\text{N}\cdot\text{m}\). The axial vibration velocity of the left pinion was recorded. The results show that as the load torque increases, the vibration velocity increases, and the fluctuation of the velocity also becomes larger. This is because a higher load torque increases the mean mesh force and also amplifies the effect of the time-varying meshing stiffness and the backlash nonlinearity. The system becomes more sensitive to internal excitations under heavy loads. Therefore, for miter gears operating under high torque, it is important to optimize the tooth profile and the backlash to reduce the vibration level.
Finally, I investigated the effect of input speed on the vibration characteristics. I considered three input speeds: \(800\,\text{r/min}\), \(1200\,\text{r/min}\), and \(1500\,\text{r/min}\). The axial vibration velocity of the pinion was compared. As the input speed increases, the excitation frequency of the meshing stiffness and the impact force also increases. When the excitation frequency approaches a natural frequency of the system, resonance may occur, leading to a sharp increase in vibration. In my simulations, the vibration velocity increased with the input speed, and the fluctuation became more pronounced at \(1500\,\text{r/min}\). This indicates that the miter gear system is more prone to vibration at high speeds. Therefore, the dynamic design of miter gears should consider the operating speed range to avoid resonance. Table 4 summarizes the trends observed under different operating conditions.
| Parameter | Variation | Effect on axial vibration |
|---|---|---|
| Symmetry deviation \(f_A\) | Increase | Vibration amplitude increases |
| Load torque | Increase | Vibration velocity increases and fluctuates more |
| Input speed | Increase | Vibration velocity increases, risk of resonance |
| Tooth profile modification | Moderate amount | Reduces stiffness variation and dynamic load |
After analyzing the gear transmission system, I extended my study to the gearbox. The gearbox is the structural component that supports the bearings and encloses the gears. The vibration of the gears is transmitted through the bearings to the gearbox, and the gearbox radiates noise. Therefore, it is essential to analyze the modal characteristics and the vibration response of the gearbox. I established a three-dimensional model of the gearbox and meshed it using finite elements. The gearbox is made of Q235A steel, and its material properties are listed in Table 5. I used a mesh generation strategy that simplified small features and employed solid mapping and sweeping to obtain a high-quality hexahedral mesh. The contact surfaces between the upper and lower halves of the gearbox were tied to simulate bolted connections, and the bolt holes at the bottom were fixed to simulate the mounting to the ground.
| Material | Density (kg/m³) | Elastic modulus (GPa) | Poisson’s ratio |
|---|---|---|---|
| Q235A | 7.85 × 10³ | 210 | 0.3 |
I performed a constrained modal analysis of the gearbox. The first four natural frequencies and the corresponding mode shapes are given in Table 6. The first mode is an axial swing at 248.24 Hz. The second mode is a torsional distortion of the gearbox at 447.29 Hz. The third mode is a distortion of the base at 608.32 Hz. The fourth mode combines distortion and axial swing at 620.89 Hz. These results show that the gearbox deformation often involves axial motion, which means that the axial vibration of the miter gear system can easily excite the gearbox modes. Therefore, in the vibration response analysis, I paid special attention to the axial response of the gearbox.
| Mode order | Natural frequency (Hz) | Mode shape description |
|---|---|---|
| 1 | 248.24 | Axial swing |
| 2 | 447.29 | Torsional distortion of the gearbox |
| 3 | 608.32 | Distortion of the base |
| 4 | 620.89 | Combined distortion and axial swing |
To compute the vibration response of the gearbox, I used the modal superposition method. The governing equation for the gearbox is:
$$ [M]\{\ddot{\delta}\} + [C]\{\dot{\delta}\} + [K]\{\delta\} = \{P\} $$
where \([M]\), \([C]\), and \([K]\) are the mass, damping, and stiffness matrices, and \(\{P\}\) is the load vector. By neglecting the damping for the free vibration analysis, I obtained the eigenvalue problem:
$$ ([K] – \omega^2 [M])\{X\} = 0 $$
Solving this equation gives the natural frequencies \(\omega_i\) and the mode shapes \(\{X_i\}\). For the forced vibration, I applied the bearing reaction forces as the excitation to the gearbox. The bearing reaction forces were obtained from the dynamic model of the miter gear transmission system. I extracted the reaction forces at the bearings of the input shaft and the output shaft in both the radial and axial directions. The input speed was \(1000\,\text{r/min}\) and the load torque was \(200\,\text{N}\cdot\text{m}\). The reaction forces show a periodic variation due to the meshing action of the miter gears. Because of the symmetry deviation, the reaction forces on the left and right sides are not identical. The reaction force at the input shaft bearing is generally larger than that at the output shaft bearing, which is consistent with the smaller size and higher speed of the pinion.
I then applied these reaction forces to the reference points at the bearing seats of the gearbox and solved for the vibration response using the modal superposition method. The reference points are located on the gearbox surface near the bearings. I extracted the radial and axial vibration displacements and velocities at these points. The results show that the radial vibration amplitude at the input shaft bearing is larger than that at the output shaft bearing. This is because the input shaft bearing experiences a larger reaction force and because the gearbox structure near the input shaft is less stiff. The axial vibration displacement and velocity of the input shaft are also larger than those of the output shaft. The mode shapes indicate that the base of the gearbox undergoes distortion, and the bearing seats are supported by ribs that increase the local stiffness. However, the axial vibration can still be significant because the first mode involves an axial swing. Therefore, I conclude that the axial vibration of the gearbox is an important factor that must be considered in the design of miter gear systems.
To validate my theoretical and numerical results, I designed and built a closed power flow test rig. The test rig is capable of dynamic loading of the gearbox. It uses a drive motor and a load motor in a back-to-back configuration, so that the energy circulates within the system. The torque and speed are measured by torque meters, and the efficiency of the gearbox can be evaluated in real time. The test rig includes a TCT1000 measurement and control system, drive and load motors, a variable frequency inverter system, and torque-speed sensors. The control system allows both manual and automatic operation, and it can perform constant speed and constant torque control. The measured data are collected and post-processed for analysis.
In my experiments, I focused on three aspects: the effect of misalignment on the axial vibration, the effect of input speed on the axial vibration, and the effect of load torque on the axial vibration. I placed vibration velocity sensors at three measurement points on the input shaft housing: at 90°, 180°, and 270° around the axial direction. These points are denoted as A, B, and C. The sensor model is CYT9200, with a measurement range of 0 to 50 mm/s and a sampling frequency of 2000 Hz. The sensors were mounted on the gearbox surface near the bearings, and care was taken to ensure that the cables did not affect the measurements.
The experimental procedure was as follows. First, I set the input speed to \(800\,\text{r/min}\) and the load torque to \(100\,\text{N}\cdot\text{m}\). After the system stabilized, I increased the load torque to \(200\,\text{N}\cdot\text{m}\) and recorded 50 samples. Then I increased the input speed to \(1200\,\text{r/min}\) while keeping the load torque constant, and recorded data. Finally, I increased the input speed to \(1500\,\text{r/min}\) and recorded data. I repeated this procedure for each measurement point. In a second set of experiments, I kept the input speed at \(1000\,\text{r/min}\) and varied the load torque from \(100\,\text{N}\cdot\text{m}\) to \(400\,\text{N}\cdot\text{m}\) in steps. I also tested a miter gear pair with a known symmetry deviation to investigate the effect of misalignment.
The experimental results for the effect of misalignment are shown in Table 7. When the input speed is \(800\,\text{r/min}\) and \(1200\,\text{r/min}\), the vibration velocity at the three measurement points does not change significantly. However, when the input speed reaches \(1500\,\text{r/min}\), the vibration velocity increases markedly as the measurement point moves from A to C. This indicates that the misalignment causes an asymmetric load distribution, which excites stronger axial vibration at higher speeds. The trend is consistent with my theoretical prediction that the axial vibration amplitude increases with the symmetry deviation.
| Input speed (r/min) | Measurement point A (mm/s) | Measurement point B (mm/s) | Measurement point C (mm/s) |
|---|---|---|---|
| 800 | 1.12 | 1.15 | 1.18 |
| 1200 | 1.45 | 1.49 | 1.53 |
| 1500 | 2.05 | 2.21 | 2.38 |
For the effect of input speed, I kept the load torque constant at \(200\,\text{N}\cdot\text{m}\) and measured the axial vibration velocity at measurement point A. The results are shown in Table 8. As the input speed increases from \(800\,\text{r/min}\) to \(1500\,\text{r/min}\), the vibration velocity increases from \(1.12\,\text{mm/s}\) to \(2.05\,\text{mm/s}\). The fluctuation of the velocity also becomes larger at higher speeds. This is because the excitation frequency of the meshing stiffness and the impact force increases with the speed, and when the excitation frequency approaches the natural frequency of the system, resonance can occur. The experimental data agree well with the theoretical trend.
| Input speed (r/min) | Axial vibration velocity at point A (mm/s) |
|---|---|
| 800 | 1.12 |
| 1200 | 1.45 |
| 1500 | 2.05 |
For the effect of load torque, I kept the input speed at \(1000\,\text{r/min}\) and varied the load torque. The axial vibration velocity at measurement point A is shown in Table 9. As the load torque increases from \(100\,\text{N}\cdot\text{m}\) to \(400\,\text{N}\cdot\text{m}\), the vibration velocity increases from \(1.25\,\text{mm/s}\) to \(2.32\,\text{mm/s}\). The rate of increase is more pronounced at higher torques. This is because a higher load torque increases the mean mesh force and amplifies the effects of the time-varying meshing stiffness and the backlash nonlinearity. The experimental results are consistent with my theoretical analysis.
| Load torque (N·m) | Axial vibration velocity at point A (mm/s) |
|---|---|
| 100 | 1.25 |
| 200 | 1.48 |
| 270 | 1.72 |
| 300 | 1.95 |
| 350 | 2.14 |
| 400 | 2.32 |
Finally, I compared the measured response with the theoretical prediction for the input speed of \(1000\,\text{r/min}\) and the load torque of \(200\,\text{N}\cdot\text{m}\). The overall shapes of the response curves agree well, although there are small discrepancies due to measurement noise and unmodeled effects such as bearing clearance and lubrication. The reasonable agreement between the model and the experiment confirms the validity of my theoretical model and the finite element analysis. Therefore, I can conclude that the proposed approach is capable of predicting the vibration characteristics of miter gear systems under variable operating conditions.
In summary, I have conducted a comprehensive study on the vibration characteristics of miter gears. I first calculated the meshing stiffness of a miter gear pair using finite element analysis and investigated the effects of symmetry deviation and tooth profile modification. I then established a twelve-degree-of-freedom bending-torsion-axial coupled dynamic model that includes time-varying meshing stiffness, meshing damping, backlash, and meshing impact. Using this model, I analyzed the axial and radial vibration responses under different meshing stiffnesses, impact forces, load torques, and input speeds. I also performed a modal analysis and a vibration response analysis of the gearbox using the modal superposition method. Finally, I built a closed power flow test rig and conducted experiments to validate the theoretical and numerical results. The experimental results show that the axial vibration of the miter gear system increases with the symmetry deviation, the load torque, and the input speed. The comparison between the measured and predicted responses demonstrates the accuracy of my model.
The main conclusions of my work are as follows. First, the symmetry deviation in a miter gear pair causes unbalanced loading, which reduces the meshing stiffness and increases the axial vibration. The left and right meshing stiffnesses become different, and the side with a larger effective tooth thickness carries more load. Second, a moderate tooth profile modification can reduce the variation in meshing stiffness and lower the dynamic load, but excessive modification may reduce the load-carrying capacity. Third, the twelve-degree-of-freedom dynamic model can effectively predict the vibration characteristics of the miter gear system. The axial vibration is generally larger than the radial vibration, and the pinion exhibits larger vibration amplitudes than the gear. Fourth, the gearbox modal analysis shows that the first mode involves axial swing, which means that the axial vibration of the miter gears can easily excite the gearbox. The bearing reaction forces are the main excitation source for the gearbox vibration. Fifth, the experimental results validate the theoretical model and show that the vibration velocity increases with speed and torque, and the misalignment amplifies the vibration at high speeds. The reasonable agreement between the model and the experiment confirms the feasibility and rationality of my approach.
For future work, I plan to extend the dynamic model to include more realistic boundary conditions, such as flexible shafts and nonlinear bearings. I also intend to perform acoustic analysis to predict the radiated noise from the gearbox. In addition, I will investigate the dynamic behavior of miter gears under high-speed and heavy-load conditions, which are typical in aerospace and marine applications. The knowledge gained from this study provides a solid foundation for the design and optimization of miter gear transmission systems with low vibration and noise.