
In the design of modern mechanical transmission systems, particularly within the demanding environment of offshore wind turbine gearboxes, the helical gear stands out due to its superior load-carrying capacity and smooth, quiet operation. The accurate prediction of contact pressure and contact pattern is paramount for ensuring the reliability and longevity of these critical components. While finite element analysis (FEM) offers a powerful tool for such detailed investigation, the inherent non-linearity of contact problems makes the results highly sensitive to mesh density in the contact zone. Traditional mesh independence studies, requiring multiple simulation runs with progressively finer meshes, are computationally expensive and time-consuming. This research, therefore, aims to establish an efficient mesh control strategy that can yield reliable contact results for helical gear pairs without the need for exhaustive mesh sensitivity analysis. The core idea is to derive a general mesh sizing rule from a fundamental Hertzian contact problem and validate its applicability to the more complex case of helical gear meshing.
1. Theoretical Foundation: Hertzian Contact Theory
The contact between two elastic bodies under load is classically described by Hertzian theory. For the contact simulation of a helical gear pair, where friction can initially be neglected for stress analysis, the problem can be approximated as the contact between two equivalent elastic cylinders. The foundational theory provides closed-form solutions for key parameters. For two parallel cylinders in line contact, the half-width \( b \) of the contact strip and the maximum contact pressure \( p_{max} \) are given by:
$$ b = \sqrt{\frac{4 F}{\pi l} \frac{\frac{1-\nu_1^2}{E_1} + \frac{1-\nu_2^2}{E_2}}{\frac{1}{R_1} + \frac{1}{R_2}}} $$
$$ p_{max} = \frac{2F}{\pi b l} $$
Where \( F \) is the normal load per unit length, \( l \) is the length of the cylinders (effective face width in gears), \( R_1 \) and \( R_2 \) are the radii of curvature, and \( E \) and \( \nu \) are the Young’s modulus and Poisson’s ratio of the respective materials. These formulas are the benchmark for validating finite element simulations of simple contact and form the basis for extrapolating mesh guidelines.
2. Mesh Independence Study on Cylindrical Contact
To develop a practical mesh strategy, we first investigate the canonical problem of two elastic cylinders in normal contact. Multiple finite element models with varying mesh densities in the potential contact region were created. The goal was to observe the convergence of \( p_{max} \) and \( b \) as the element size decreases and to identify the threshold mesh size at which results become stable (i.e., mesh-independent).
2.1 Finite Element Modeling Approach
A simplified 3D segment model was used to reduce computational cost while preserving the essence of the contact physics. The mesh was constructed by generating a mapped mesh on the end face of the cylinder segment, which was then swept along the axial direction. A critical region of dimensions \( w \) (tangential width) and \( h \) (radial height) was defined around the expected contact line to control local refinement. The key parameter is the uniform element size \( e \) within this contact control zone. SOLID186 elements were used for the bodies, and CONTA174/TARGE170 element pairs defined the frictionless contact interface, solved using the Augmented Lagrangian method.
2.2 Analysis of Cylindrical Contact Examples
Two distinct cases were analyzed with different geometries and loads. The parameters and theoretical Hertz solutions are summarized below:
| Parameter | Example 1 | Example 2 |
|---|---|---|
| Cylinder 1 Radius, \( R_1 \) (mm) | 8 | 5 |
| Cylinder 2 Radius, \( R_2 \) (mm) | 12 | 6 |
| Young’s Modulus, \( E \) (GPa) | 200 | 200 |
| Poisson’s Ratio, \( \nu \) | 0.3 | 0.3 |
| Length, \( l \) (mm) | 3 | 1 |
| Load, \( F \) (N) | 1300 | 200 |
| Theoretical \( b \) (mm) | 0.1552 | 0.0795 |
| Theoretical \( p_{max} \) (MPa) | 1777 | 1601 |
For each example, simulations were run with a progressively smaller element size \( e \). The calculated \( p_{max} \) and \( b \) were plotted against the ratio \( w/e \), which represents the number of elements across the contact control width. The convergence behavior was strikingly consistent across both examples:
- The calculated \( p_{max} \) increased and the calculated \( b \) decreased as the mesh was refined.
- Convergence began when the element size \( e \) became smaller than the theoretical contact half-width \( b \).
- Stable results, with errors less than 5% compared to the theoretical values, were consistently achieved once the element size \( e \) was reduced to approximately \( b/4 \) or smaller.
This leads to a fundamental and practical conclusion: for reliable simulation of Hertzian contact pressure and contact patch size, the element size in the contact region should be less than or equal to one-quarter of the estimated contact half-width (\( e \leq b/4 \)). Adhering to this rule effectively guarantees mesh-independent results for these key outputs.
3. Application to Helical Gear Contact Simulation
The logical step is to apply this mesh control principle to the simulation of a helical gear pair. The meshing of helical gears is a spatially varying process, but at any given instant, the contact between two teeth can be locally approximated as the contact of two cylinders with radii equal to the instantaneous radii of curvature at the contact point.
3.1 Analytical Solution for Helical Gears
The maximum contact stress for a helical gear pair is typically calculated using standards such as ISO 6336. The formula incorporates several factors to account for gear geometry and load sharing:
$$ \sigma_H = Z_H Z_E Z_{\epsilon} Z_{\beta} \sqrt{\frac{F_t}{d_1 b} \frac{u+1}{u}} $$
Where \( \sigma_H \) is the contact stress, \( Z_H \) is the zone factor, \( Z_E \) is the elasticity factor, \( Z_{\epsilon} \) is the contact ratio factor, \( Z_{\beta} \) is the helix angle factor, \( F_t \) is the tangential load, \( d_1 \) is the pinion reference diameter, \( b \) is the facewidth, and \( u \) is the gear ratio.
To estimate the contact half-width \( b_g \) for mesh sizing purposes, we can directly adapt the Hertz formula for cylinders, using the normal load \( F_n \), the total contact line length \( l_s \), and the equivalent radii of curvature at the pitch point \( \rho_1 \) and \( \rho_2 \):
$$ b_g = \sqrt{\frac{4 F_n}{\pi l_s} \frac{\frac{1-\nu_1^2}{E_1} + \frac{1-\nu_2^2}{E_2}}{\frac{1}{\rho_1} + \frac{1}{\rho_2}}} $$
This calculated \( b_g \) provides the target value for applying our mesh control rule.
3.2 Finite Element Modeling and Results of a Helical Gear Pair
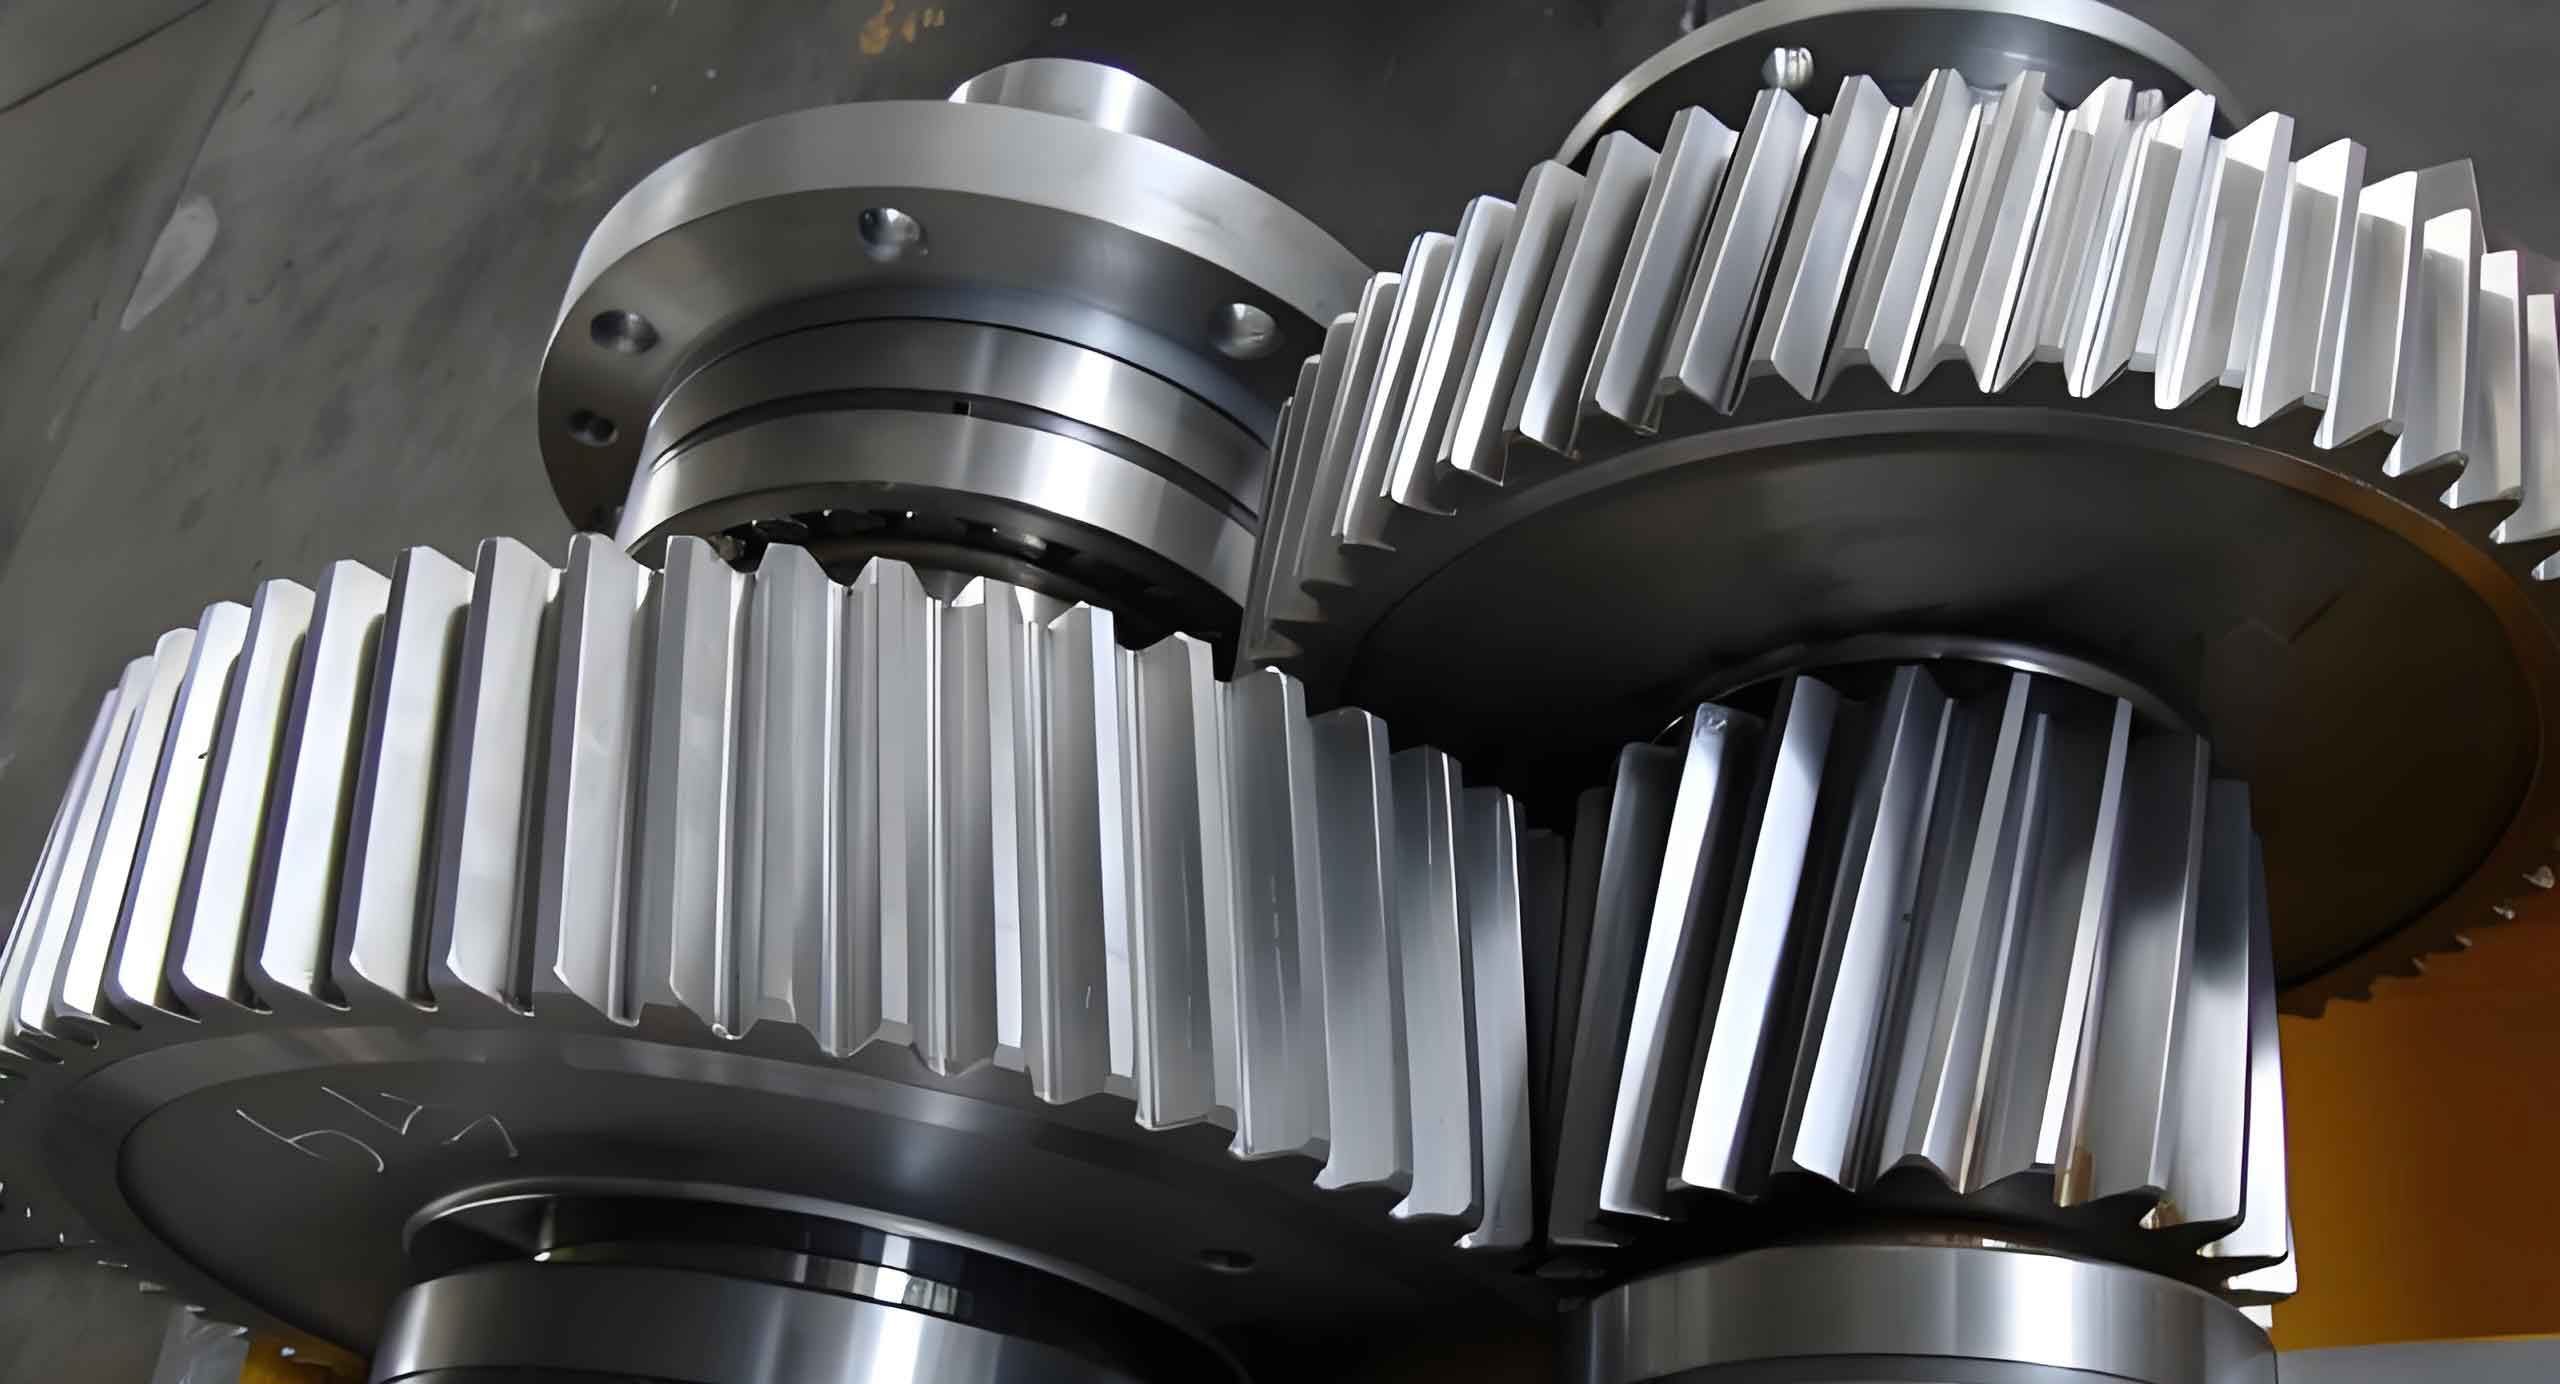
A three-dimensional model of a helical gear pair was created for a specific meshing position. The helical gear parameters are listed below:
| Parameter | Pinion | Gear |
|---|---|---|
| Normal Module, \( m_n \) (mm) | 6 | 6 |
| Number of Teeth, \( z \) | 35 | 85 |
| Helix Angle, \( \beta \) (°) | 18 (Left) | 18 (Right) |
| Face Width (mm) | 70 | 70 |
| Input Torque (N·m) | 8500 | – |
The gears were discretized using SOLID185 elements. The core of the strategy was applied during meshing: based on a preliminary calculation of the contact half-width \( b_g \) (approximately 0.694 mm for this gear set), the element size in the potential contact region on the tooth flanks was explicitly controlled to be less than \( b_g / 4 \approx 0.17 \) mm. This was achieved by partitioning the tooth surfaces and applying local size controls. A frictionless contact pair was defined between the gears, and appropriate boundary conditions and torque were applied.
The simulation was solved in a single run, without performing a traditional mesh convergence study. The results were highly satisfactory. The extracted maximum contact pressure from the FEA was 967 MPa, and the measured contact half-width was 0.685 mm. These values show excellent agreement with the theoretical calculations (998 MPa and 0.694 mm, respectively), with deviations well under 5%.
This successful validation demonstrates that the mesh control rule derived from simple cylindrical contact (\( e \leq b/4 \)) is directly applicable and effective for the complex contact simulation of a helical gear pair. By using the estimated Hertzian contact half-width to guide the initial mesh generation, engineers can obtain reliable contact pressure and contact patch size results in a single simulation, dramatically improving efficiency in the design analysis of helical gears.
4. Conclusion and Significance
This investigation establishes a robust and efficient methodology for the finite element analysis of contact in helical gear pairs. The key findings are:
- The mesh sensitivity study of the fundamental Hertzian contact problem reveals a clear threshold: for mesh-independent results in contact pressure and contact patch width, the element size in the contact region must be smaller than one-quarter of the theoretical contact half-width (\( e \leq b/4 \)).
- This rule is successfully extended to the simulation of helical gears. By calculating the approximate Hertzian contact half-width \( b_g \) for the gear pair and enforcing a local mesh size of \( e \leq b_g/4 \) on the tooth flanks, reliable results can be achieved without conducting iterative mesh refinement studies.
The significance of this strategy is substantial for the design process of critical components like offshore wind turbine gearboxes. It provides a practical, first-principles guideline for meshing, transforming a traditionally iterative and computationally costly step into a predictable and efficient one. This allows engineers to focus more on design exploration and optimization of the helical gear system, confident in the accuracy of their contact simulation results. The method is general and can be integrated into parameterized and automated simulation workflows, further accelerating the development of reliable and high-performance helical gear transmissions.