
In my analysis of precision reducers used in industrial robotics, the rotary vector reducer stands out due to its compact design, high rigidity, and excellent performance in applications such as robotic joints. This study delves into the kinematics of the rotary vector reducer, exploring its motion principles, transmission ratios under various configurations, and the kinematic relationships among its components. Understanding these aspects is crucial for optimizing the design and performance of the rotary vector reducer in real-world applications.
The rotary vector reducer is a type of closed differential gear system that combines a planetary gear mechanism with a cycloidal pinwheel transmission. It is widely adopted in industrial robots because of its high reduction ratio, compact size, and durability. In this article, I will break down the motion transfer process, derive key formulas, and summarize the kinematic behaviors using tables and equations. Throughout, I will emphasize the unique features of the rotary vector reducer to provide a comprehensive guide for engineers and researchers.
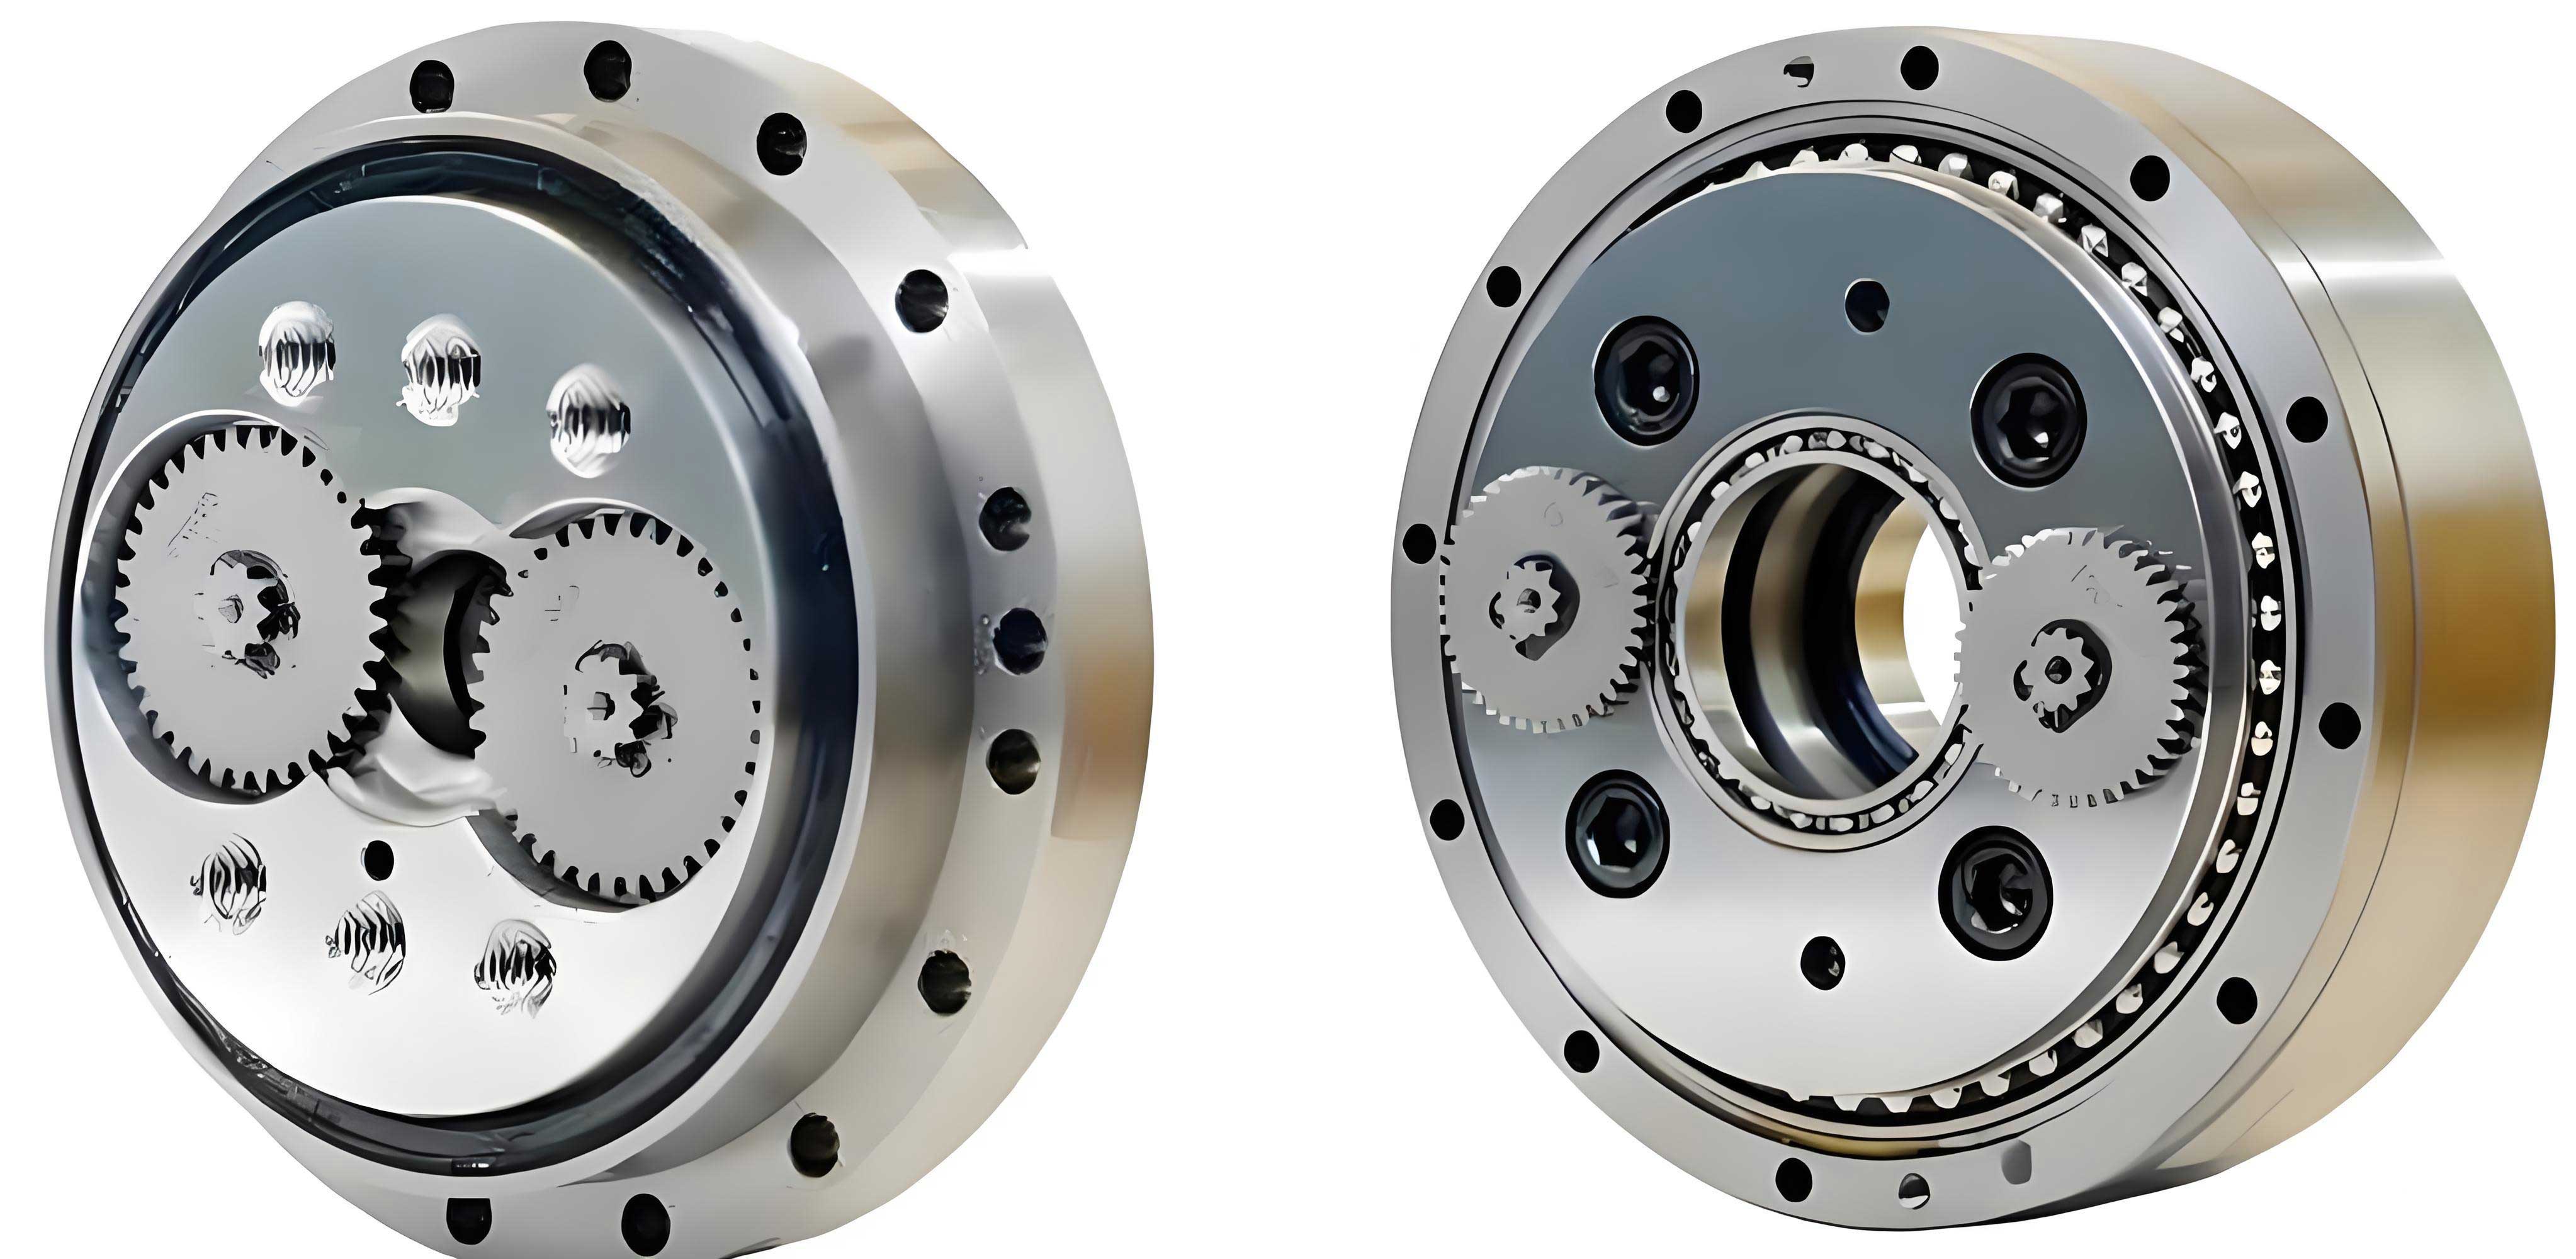
The rotary vector reducer consists of several key parts: an input gear, planetary gears, crankshafts, cycloidal gears, a pinwheel (or pin gear), and a carrier. The pinwheel is typically fixed as the frame, while the input gear serves as the input shaft, and the carrier acts as the output shaft. Motion is transferred through a series of engagements: the input gear drives the planetary gears, which are rigidly connected to the crankshafts. The crankshafts, in turn, cause the cycloidal gears to orbit, and their interaction with the fixed pinwheel results in rotation of the carrier. This complex arrangement forms a closed differential system with one degree of freedom, making the rotary vector reducer highly efficient and reliable.
To analyze the kinematics of the rotary vector reducer, I first consider its motion principles. The differential part includes the input gear, planetary gears, and the carrier, while the closed part comprises the crankshafts, cycloidal gears, and pinwheel. The connection between these parts—through rigid links and an equiangular speed transmission mechanism—imposes constraints that determine the overall motion. In the following sections, I will derive the transmission ratios for different installation methods and detail the kinematic relationships of all moving components.
Motion Principles of the Rotary Vector Reducer
In my examination, the rotary vector reducer operates as a closed differential gear train. The differential section has two degrees of freedom, but the closed cycloidal section reduces this to one by adding constraints. Let me explain the motion transfer step by step. When the input gear rotates, it meshes with the planetary gears, causing them to rotate on their own axes. However, the planetary gears are free to revolve around the central axis. This rotation is transmitted to the crankshafts, which are fixed to the planetary gears. As the crankshafts rotate, they drive the cycloidal gears in an orbital motion. The cycloidal gears then mesh with the fixed pinwheel, leading to their rotation. Finally, this rotation is transferred to the carrier via an equiangular speed mechanism, resulting in a controlled output motion.
The carrier serves as the connecting rod for the planetary gears, meaning its angular velocity is the same as the revolution speed of the planetary gears. Similarly, the crankshafts act as the connecting rods for the cycloidal gears, so their rotation speed equals the orbital speed of the cycloidal gears. This interplay is key to understanding the kinematics of the rotary vector reducer. The equiangular speed transmission ensures that the carrier and cycloidal gears rotate at the same speed, which simplifies the analysis.
To formalize this, I define the angular velocities: let $\omega_1$ be the angular velocity of the input gear, $\omega_2$ the angular velocity of the planetary gears (and crankshafts), $\omega_3$ the angular velocity of the cycloidal gears, $\omega_4$ the angular velocity of the pinwheel, $\omega_{H’}$ the angular velocity of the carrier, and $\omega_{H”}$ the angular velocity of the crankshafts as connecting rods. Based on the gear engagements, I can derive relationships using the formula for converted mechanisms in planetary gear systems.
Transmission Ratios of the Rotary Vector Reducer
The transmission ratio of the rotary vector reducer depends on how it is installed—specifically, which component is fixed, which is input, and which is output. In my analysis, I consider three common configurations and derive their transmission ratios using the principles of gear kinematics.
First, for the differential part, the conversion ratio is given by:
$$ i_{12}^{H’} = \frac{\omega_1 – \omega_{H’}}{\omega_2 – \omega_{H’}} = -\frac{z_2}{z_1} $$
where $z_1$ is the number of teeth on the input gear and $z_2$ is the number of teeth on the planetary gears. This equation arises from the external meshing between the input and planetary gears.
Second, for the closed cycloidal part, the conversion ratio is:
$$ i_{34}^{H”} = \frac{\omega_3 – \omega_{H”}}{\omega_4 – \omega_{H”}} = \frac{z_4}{z_3} $$
where $z_3$ is the number of teeth on the cycloidal gears, $z_4$ is the number of pins in the pinwheel, and typically $z_4 = z_3 + 1$ for the rotary vector reducer.
Third, the connections between parts yield: $\omega_2 = \omega_{H”}$ (since planetary gears and crankshafts are rigidly linked) and $\omega_{H’} = \omega_3$ (due to the equiangular speed transmission).
By combining these equations and setting the fixed component’s angular velocity to zero, I can solve for the transmission ratios in different installations. Below, I summarize the results in a table for clarity.
| Installation Method | Fixed Component | Input Component | Output Component | Transmission Ratio Formula | Direction Relationship |
|---|---|---|---|---|---|
| Case 1 | Pinwheel ($\omega_4 = 0$) | Input gear ($\omega_1$) | Carrier ($\omega_{H’}$) | $i_{1H’} = \frac{\omega_1}{\omega_{H’}} = 1 + \frac{z_2}{z_1} \cdot z_4$ | Same direction |
| Case 2 | Carrier ($\omega_{H’} = 0$) | Input gear ($\omega_1$) | Pinwheel ($\omega_4$) | $i_{14} = \frac{\omega_1}{\omega_4} = -\frac{z_2}{z_1} \cdot z_4$ | Opposite direction |
| Case 3 | Input gear ($\omega_1 = 0$) | Pinwheel ($\omega_4$) | Carrier ($\omega_{H’}$) | $i_{4H’} = \frac{\omega_4}{\omega_{H’}} = 1 + \frac{z_1}{z_2} \cdot \frac{1}{z_4}$ | Same direction |
These formulas highlight the versatility of the rotary vector reducer in achieving different reduction ratios. For example, in a typical rotary vector reducer like the RV-320E-201, with $z_1 = 14$, $z_2 = 70$, and $z_4 = 40$, the transmission ratios are $i_{1H’} = 201$, $i_{14} = -200$, and $i_{4H’} \approx 1.005$. This demonstrates the high reduction capability of the rotary vector reducer in robotic joints.
To further illustrate, I can express the angular velocities in terms of the input speed. For Case 1, where the pinwheel is fixed, the angular velocities are:
$$ \omega_{H’} = \frac{\omega_1}{1 + \frac{z_2}{z_1} \cdot z_4}, \quad \omega_2 = -\frac{z_3}{1 + \frac{z_2}{z_1} \cdot z_4} \omega_1, \quad \omega_3 = \frac{\omega_1}{1 + \frac{z_2}{z_1} \cdot z_4}, \quad \omega_{H”} = -\frac{z_3}{1 + \frac{z_2}{z_1} \cdot z_4} \omega_1 $$
where $z_3 = z_4 – 1$. This shows how the rotary vector reducer distributes motion among its components.
Kinematic Relationships in the Rotary Vector Reducer
In my study of the rotary vector reducer, I find it essential to summarize the kinematic relationships of all moving parts. These relationships are crucial for dynamic analysis and force calculations. Based on the derivations, I can tabulate the angular velocities and their directions for a standard installation with the pinwheel fixed, input gear driving, and carrier output.
| Component | Rotation Type | Angular Velocity Expression | Direction Relative to Input |
|---|---|---|---|
| Planetary gears and crankshafts | Rotation (spin) | $\omega_2 = -\left( \frac{\omega_1}{i_{1H’}} \right) \cdot z_3$ | Opposite |
| Planetary gears and crankshafts | Revolution (orbit) | $\omega_{H’} = \frac{\omega_1}{i_{1H’}}$ | Same |
| Cycloidal gears | Rotation (spin) | $\omega_3 = \frac{\omega_1}{i_{1H’}}$ | Same |
| Cycloidal gears | Revolution (orbit) | $\omega_{H”} = -\left( \frac{\omega_1}{i_{1H’}} \right) \cdot z_3$ | Opposite |
Here, $i_{1H’}$ is the transmission ratio from Case 1. Note that the spin of the cycloidal gears equals the revolution of the planetary gears, and vice versa, which is a distinctive feature of the rotary vector reducer. This interlocking motion ensures smooth operation and high torque transmission.
Additionally, the relative speeds between components are important for bearing selection and lubrication analysis. For instance, the relative speed between the crankshafts and the cycloidal gears (at the needle bearing) is $\omega_2 – \omega_3 = -\left( \frac{\omega_1}{i_{1H’}} \right) \cdot z_4$, and between the crankshafts and the carrier (at the tapered roller bearing) is $\omega_2 – \omega_{H’} = -\left( \frac{\omega_1}{i_{1H’}} \right) \cdot z_4$. In the RV-320E-201 example, with $\omega_1 = 201$ rpm (assuming input speed for illustration), $\omega_{H’} = 1$ rpm, so these relative speeds are $-40$ rpm, indicating significant internal motion that must be accounted for in design.
Another key aspect is the motion of the meshing point between the cycloidal gears and the pinwheel, denoted as point P. This point lies on the line connecting the center of the pinwheel O and the center of the cycloidal gears O_c, and it moves with the orbital speed of the cycloidal gears. Specifically, when point P rotates by an angle $\theta$ relative to the fixed frame, the rotations of other components can be derived as follows.
| Component | Rotation Angle (Spin) | Rotation Angle (Orbit) |
|---|---|---|
| Planetary gears and crankshafts | $\theta$ | $-\frac{\theta}{z_3}$ |
| Cycloidal gears | $-\frac{\theta}{z_3}$ | $\theta$ |
This implies that for every full orbit of point P (i.e., $\theta = 360^\circ$), the cycloidal gears spin by $-\frac{360^\circ}{z_3}$, and the crankshafts spin by $360^\circ$ relative to the frame. In the RV-320E-201 case, $z_3 = 39$, so the cycloidal gears spin approximately $-9.23^\circ$ per orbit. This detailed kinematic understanding helps in analyzing contact forces and wear in the rotary vector reducer.
To further elaborate, I can derive the position equations for point P. Let $O$ be the origin, and $O_c$ the center of the cycloidal gears. The distance $OP$ is related to $OO_c$ by $OP = OO_c \cdot \frac{z_4}{z_3}$. As point P moves, it traces a path that influences the meshing dynamics. The angular velocity of point P is $\omega_{H”}$, which equals the orbital speed of the cycloidal gears. Therefore, the kinematics of the rotary vector reducer are tightly coupled, with each component’s motion dictating the others.
Extended Analysis and Applications
In my exploration of the rotary vector reducer, I also consider factors like efficiency, backlash, and load distribution, which are influenced by kinematics. The high reduction ratio of the rotary vector reducer makes it ideal for robotic joints where precise motion control is required. By understanding the kinematic relationships, engineers can optimize tooth profiles, bearing arrangements, and lubrication systems to enhance performance.
For example, the relative motion between the crankshafts and the cycloidal gears leads to sliding friction at the needle bearings. Using the kinematic formulas, I can calculate the sliding speeds to estimate heat generation and wear rates. Similarly, the motion of point P affects the contact stress between the cycloidal gears and the pins, which is critical for durability. In the rotary vector reducer, the cycloidal gear teeth engage with multiple pins simultaneously, distributing loads evenly—a benefit derived from its kinematic design.
Moreover, the rotary vector reducer can be modeled using matrix methods for dynamic simulation. The kinematic constraints can be expressed as linear equations, allowing for numerical analysis in software like MATLAB. For instance, the angular velocities satisfy:
$$ \begin{bmatrix} 1 & 0 & -1 & 0 \\ 0 & 1 & 0 & -1 \\ -\frac{z_2}{z_1} & 1 & 0 & 0 \\ 0 & 0 & \frac{z_4}{z_3} & -1 \end{bmatrix} \begin{bmatrix} \omega_1 \\ \omega_2 \\ \omega_3 \\ \omega_4 \end{bmatrix} = \begin{bmatrix} 0 \\ 0 \\ 0 \\ 0 \end{bmatrix} $$
when appropriate boundary conditions are applied (e.g., $\omega_4 = 0$ for Case 1). Solving this system yields the same transmission ratios, demonstrating the consistency of the kinematic model for the rotary vector reducer.
In practical applications, the rotary vector reducer is often subjected to varying loads and speeds. The kinematic analysis provides a foundation for studying dynamic responses, such as vibration and resonance. By incorporating inertia terms, I can extend the equations to account for accelerations, but that goes beyond the scope of this kinematic study. Nonetheless, the relationships established here are essential first steps.
To summarize the advantages of the rotary vector reducer from a kinematic perspective, I compile the following points:
- The closed differential design ensures a single degree of freedom, leading to deterministic motion.
- High reduction ratios are achieved through the combination of planetary and cycloidal stages.
- The equiangular speed transmission simplifies the output mechanism, reducing complexity.
- Kinematic constraints minimize backlash, enhancing precision in robotic applications.
These features make the rotary vector reducer a preferred choice in industries requiring reliable and precise motion control.
Conclusion
In this comprehensive study, I have analyzed the kinematics of the rotary vector reducer, covering its motion principles, transmission ratios, and detailed kinematic relationships. Through derivations and tables, I have shown how the rotary vector reducer operates as a closed differential system, with distinct angular velocities for each component depending on the installation method. The formulas and data provided here serve as a valuable reference for designing and analyzing rotary vector reducers in robotic systems. Future work could integrate these kinematic insights with dynamic and force analyses to further optimize the performance of the rotary vector reducer in demanding applications.
Overall, the rotary vector reducer exemplifies sophisticated gear engineering, and its kinematic understanding is key to leveraging its full potential. As robotics continue to advance, the role of the rotary vector reducer will likely expand, driven by its proven capabilities in motion transmission.