
In the field of high-precision robotics, the RV reducer plays a critical role due to its compact design, high transmission ratio, and excellent load-bearing capacity. As an essential component in robotic joints, the torsional stiffness of the RV reducer directly impacts the system’s dynamic performance, including vibration suppression, positioning accuracy, and operational stability. Insufficient stiffness can lead to chatter during operation, reduced load capacity, and positional deviations at the end-effector, thereby affecting production efficiency. Therefore, analyzing the torsional stiffness characteristics of the RV reducer is of paramount importance. This study focuses on the finite element analysis of the overall torsional stiffness and hysteresis of an RV reducer, considering factors such as gear meshing stiffness, elastic components, and bearing compliance. The goal is to provide a reliable reference for the design and optimization of RV reducers in robotic applications.
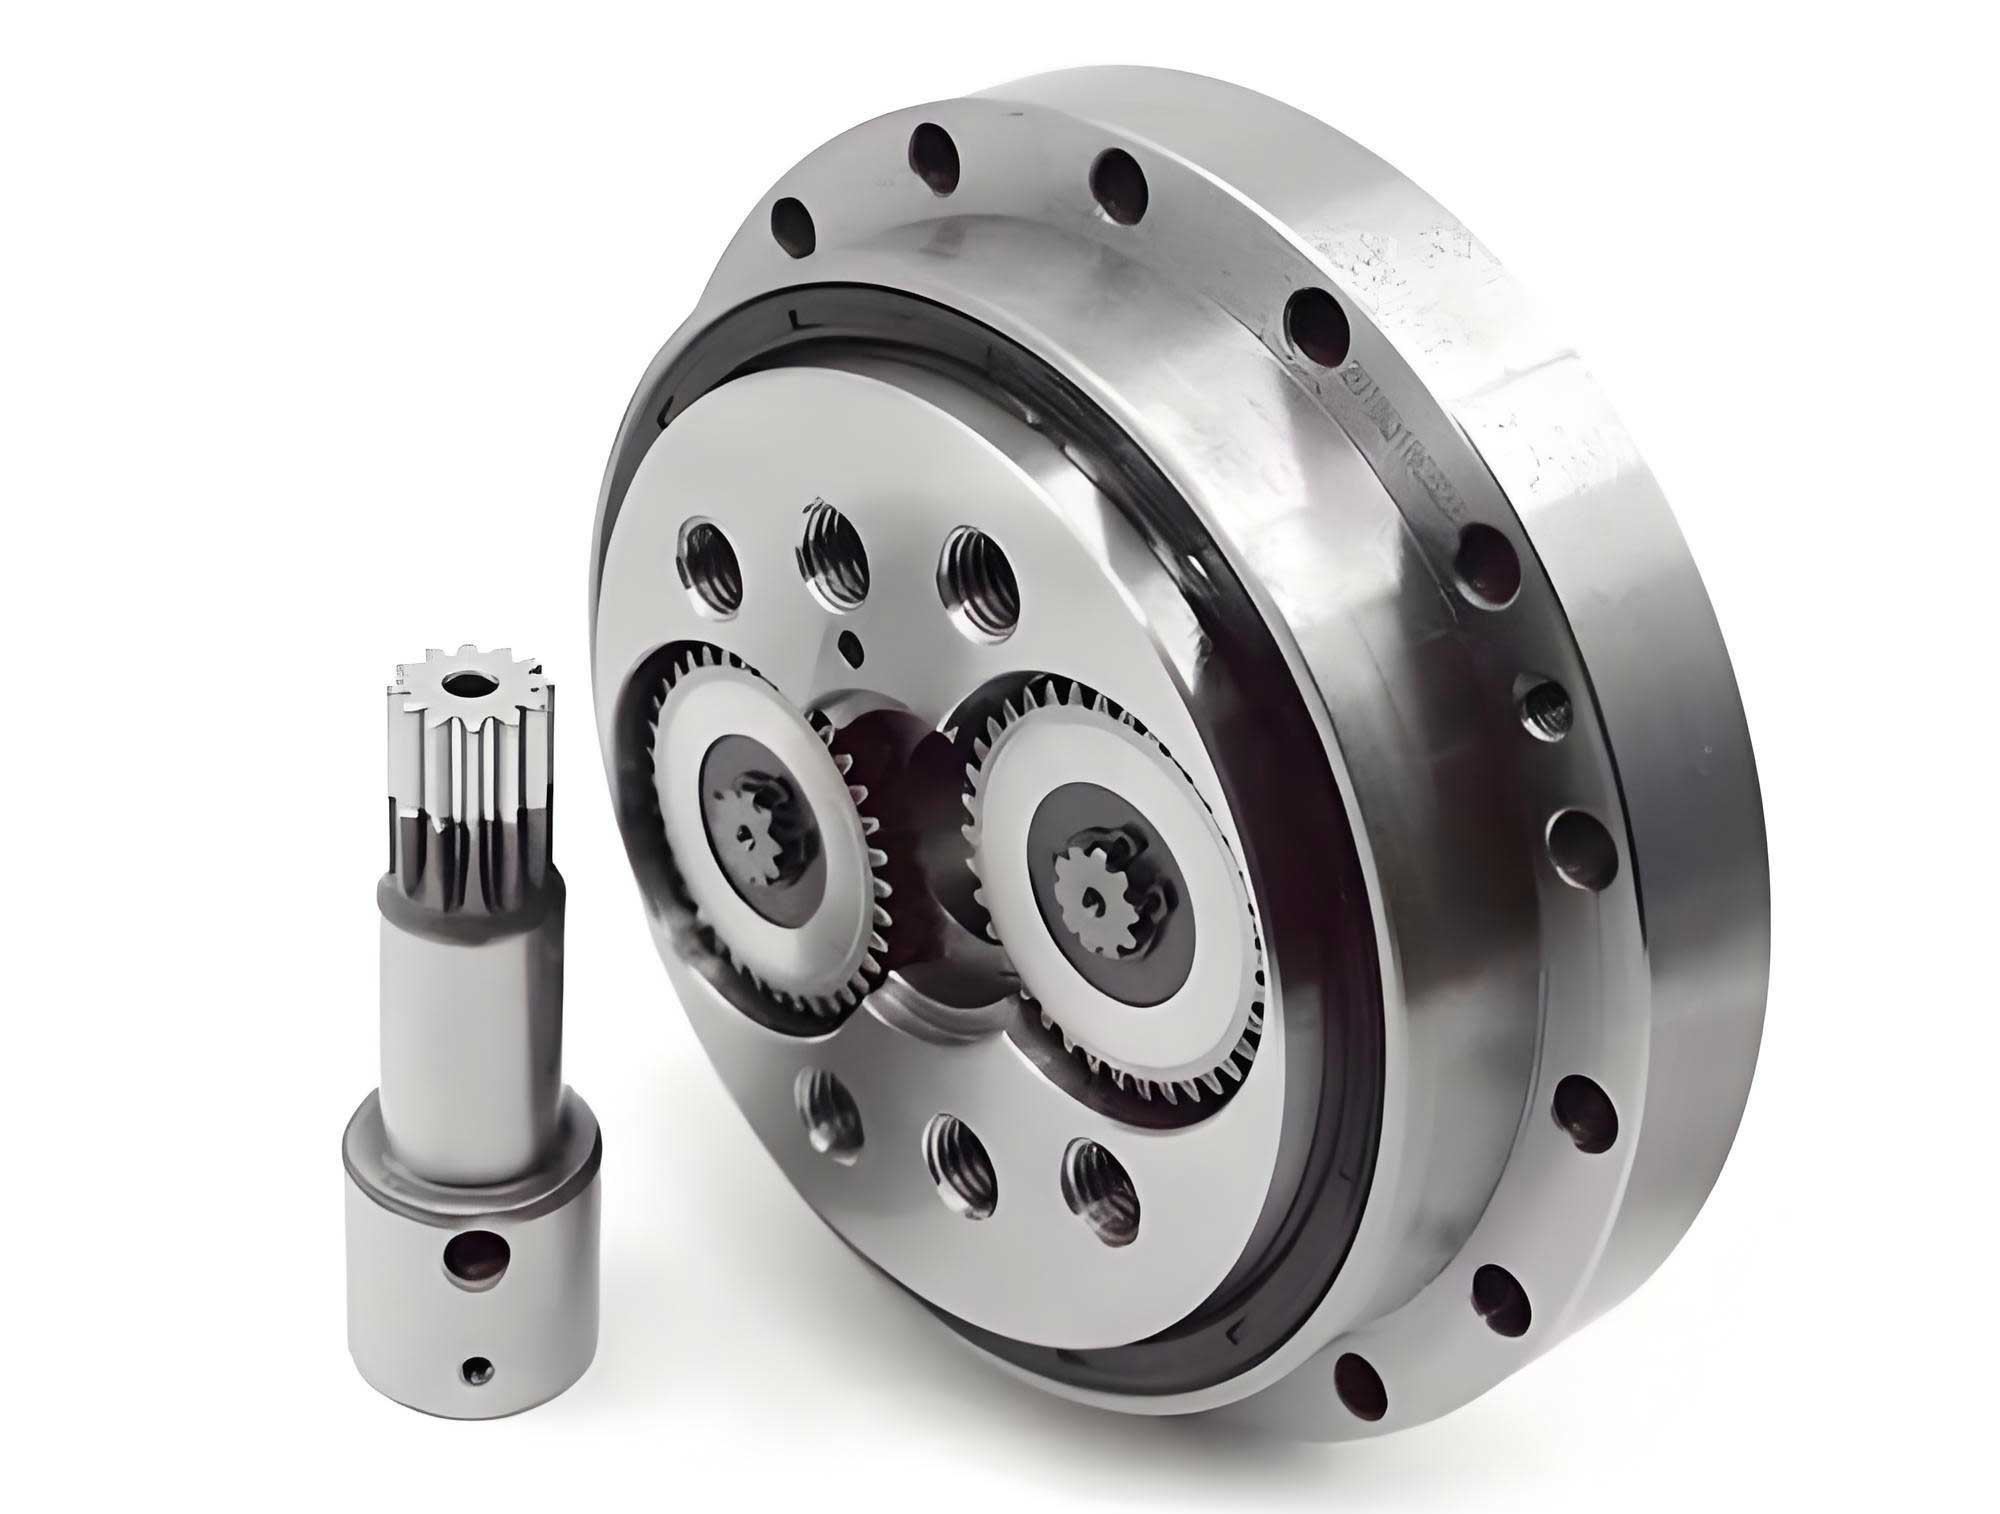
The RV reducer is a two-stage closed planetary transmission mechanism. The first stage consists of an involute planetary gear set, including a sun gear and planetary gears, which provides initial speed reduction. The second stage involves a cycloidal pin gear mechanism, comprising cycloid gears, pin gears, a pin housing, crankshafts, and an output planetary frame. The crankshafts connect the planetary gears to the cycloid gears, facilitating motion transmission. When the sun gear rotates, it drives the planetary gears, which in turn rotate the crankshafts. The cycloid gears, mounted eccentrically on the crankshafts, engage with the fixed pin gears, resulting in a reverse rotation that is output through the planetary frame. This unique configuration gives the RV reducer its advantages, such as high rigidity and low backlash.
To accurately analyze the torsional behavior of the RV reducer, a detailed finite element model was developed using APDL (ANSYS Parametric Design Language). The model incorporates all critical components, including the sun gear, planetary gears, cycloid gears, pin gears, crankshafts, bearings, and housing. The geometry was parameterized to allow for easy modification of design parameters. The mesh was generated by extruding pre-meshed surfaces into solids, ensuring high-quality hexahedral elements. The element types used were PLANE182 for 2D surfaces and SOLID185 for 3D solids, resulting in a model with 158 entities, 1,227,915 nodes, and 1,006,668 elements. This fine mesh captures the complex contact interactions and deformations within the RV reducer.
The material properties assigned to the components are based on standard engineering materials. The sun gear and planetary gears are made of 20CrMnTi, the pin housing uses QT450, and all other parts, including the cycloid gears and crankshafts, are constructed from GCr15. The material properties are summarized in Table 1.
| Material | Density (kg/m³) | Elastic Modulus (MPa) |
|---|---|---|
| GCr15 | 7,830 | 2.19 × 10⁵ |
| 20CrMnTi | 7,860 | 2.12 × 10⁵ |
| QT450 | 7,060 | 1.69 × 10⁵ |
The RV reducer model includes key design parameters, such as the number of cycloid gear teeth, pin gear diameter, eccentricity, and modification values for the cycloid gear profile. Isometric and shift modifications were applied to the cycloid gears to optimize meshing performance and reduce hysteresis. The modification values were determined based on design manuals and algorithms to ensure strength, precision, and hysteresis below 1 arcminute. The parameters of the RV reducer are listed in Table 2.
| Parameter | Value |
|---|---|
| Input Motor Power (kW) | 1.64 |
| Output Torque (N·m) | 784 |
| Output Speed (r/min) | 15 |
| Pin Gear Center Circle Diameter (mm) | 154 |
| Pin Gear Diameter (mm) | 7 |
| Pin Hole Diameter (mm) | 7.008 |
| Eccentricity (mm) | 1.5 |
| Number of Cycloid Gear Teeth | 39 |
| Isometric Modification Amount (mm) | -0.042 |
| Shift Modification Amount (mm) | -0.047 |
In the finite element analysis, loads and boundary conditions were applied to simulate real-world operating conditions. The RV reducer was subjected to a rated output torque of 784 N·m at an output speed of 15 r/min. The torque was converted into circumferential forces distributed evenly across the nodes of the pin housing. Boundary conditions were set to constrain the degrees of freedom appropriately: the sun gear was fixed at its cylindrical surface to simulate the input side; the planetary gears and crankshafts were axially constrained; the bearing rollers were circumferentially constrained using a local cylindrical coordinate system; the cycloid gears were axially constrained; the planetary frame was fixed using a MASS21 point element; and the pin housing was allowed only rotational motion about its axis. These constraints ensure that the model accurately represents the kinematic and dynamic behavior of the RV reducer.
Contact interactions between components were modeled using surface-to-surface contact pairs with “flexible-flexible” contact settings. The target surfaces were defined with TARGE170 elements, and the contact surfaces with CONTA174 elements. Seven contact pairs were established: two for the cycloid gear and pin gear meshing (with cycloid gear teeth as target and pin gear surfaces as contact), two for the cycloid gear bearing holes and crankshaft bearings, two for the crankshaft eccentric surfaces and bearings, and one for the sun gear and planetary gear meshing. The contact stiffness factor (FKN) was set to 2, and the maximum penetration (FTOLN) was 0.01 to ensure convergence and accuracy in the simulation. This comprehensive contact modeling captures the nonlinear stiffness effects in the RV reducer.
The torsional stiffness of the RV reducer is defined as the ratio of the applied torque to the resulting angular deformation. However, due to clearances such as gear backlash and bearing play, the effective stiffness must exclude these gaps. Therefore, the torsional stiffness \( K \) is calculated using the formula:
$$ K = \frac{T_{\text{rated}} – T_{\text{previous}}}{\theta_{\text{rated}} – \theta_{\text{previous}}} $$
where \( T_{\text{rated}} \) is the rated torque, \( \theta_{\text{rated}} \) is the angular displacement under rated torque, and the subscript “previous” refers to the values from the prior load step. This approach isolates the elastic deformation from the clearance effects. The torsional stiffness of the RV reducer is not constant but varies with the meshing position of the cycloid gears, due to changes in meshing stiffness and bearing compliance. To analyze this, the cycloid gear was divided into 13 meshing positions around its circumference, as illustrated in Figure 3 (refer to the conceptual diagram). The torsional stiffness was computed for each position, and the results are presented in Table 3.
| Meshing Position | Maximum Torsional Angle (arcmin) | Torsional Stiffness (N·m/arcmin) |
|---|---|---|
| 1 | 3.463 | 256.2 |
| 2 | 3.573 | 247.1 |
| 3 | 3.554 | 248.6 |
| 4 | 3.349 | 265.8 |
| 5 | 3.212 | 278.8 |
| 6 | 3.289 | 271.4 |
| 7 | 3.350 | 265.8 |
| 8 | 3.564 | 247.8 |
| 9 | 3.563 | 247.9 |
| 10 | 3.487 | 254.0 |
| 11 | 3.229 | 277.1 |
| 12 | 3.367 | 265.2 |
| 13 | 3.384 | 262.7 |
The variation in torsional stiffness across meshing positions follows a sinusoidal pattern, with the maximum stiffness of 278.8 N·m/arcmin occurring at position 5 and the minimum stiffness of 247.1 N·m/arcmin at position 2. The average torsional stiffness across all positions is calculated as 260.65 N·m/arcmin. This variability highlights the dynamic nature of the RV reducer’s stiffness, which must be considered in high-precision applications. The stiffness fluctuation is primarily attributed to the changing number of teeth in contact and the compliance of the crankshaft bearings as the cycloid gears rotate.
Hysteresis, or backlash, is another critical performance metric for the RV reducer. It refers to the angular lag between the input and output shafts when the direction of rotation is reversed. Hysteresis can be categorized into geometric, thermal, and elastic components. In this study, we focus on elastic hysteresis, which arises from deformations under load. According to Nabtesco Corporation, the hysteresis of an RV reducer is defined as the torsional deformation under ±0.03 times the rated torque. For symmetric meshing positions, the deformation under positive and negative loads is assumed equal. The hysteresis \( \phi_i \) for each meshing position \( i \) is given by:
$$ \phi_i = \frac{0.03T}{K_i} + \frac{0.03T}{K_{15-i}} $$
where \( T \) is the rated torque, \( K_i \) is the torsional stiffness at position \( i \), and \( K_{15-i} \) corresponds to the stiffness at the symmetric position. Using this formula, the hysteresis values for the RV reducer were computed, as shown in Table 4.
| Meshing Position | Hysteresis (arcmin) | Meshing Position | Hysteresis (arcmin) |
|---|---|---|---|
| 1 | 0.214 | 2, 13 | 0.215 |
| 3, 12 | 0.213 | 4, 11 | 0.213 |
| 5, 10 | 0.217 | 6, 9 | 0.211 |
| 7, 8 | 0.213 |
The hysteresis of the RV reducer ranges from 0.173 to 0.185 arcmin, with an average value of 0.214 arcmin. This low hysteresis is essential for precision robotics, as it minimizes positional errors during directional changes. The finite element analysis demonstrates that the RV reducer design meets the stringent requirements for high-accuracy applications.
To validate the finite element results, experimental tests were conducted on a physical RV reducer of the same model. A torsional stiffness test bench was constructed, consisting of a torque loading device, the RV reducer, and an optical encoder for angle measurement. The input shaft was fixed, and incremental loads were applied to the output side while measuring the angular displacement. The data collected during loading and unloading cycles were plotted as a hysteresis curve, as shown in Figure 6 (refer to the conceptual diagram). The experimental data, after excluding clearance effects, are summarized in Table 5.
| Load (kg) | Torque (N·m) | Angular Displacement (arcsec) | Load (kg) | Torque (N·m) | Angular Displacement (arcsec) |
|---|---|---|---|---|---|
| 0 | 0 | 0 | 3.6 | 24.7 | 14 |
| 5 | 34.3 | 30 | 15 | 102.9 | 68 |
| 35 | 240.1 | 120 | 55 | 377.3 | 167 |
| 75 | 514.5 | 210 | 95 | 651.7 | 250 |
| 115 | 788.9 | 291 | 95 | 651.7 | 261 |
| 75 | 514.5 | 228 | 55 | 377.3 | 187 |
| 35 | 240.1 | 144 | 15 | 102.9 | 95 |
| 5 | 34.3 | 63 | 3.5 | 24.7 | 46 |
| 0 | 0 | 37 | -3.6 | -24.7 | 27 |
| -5 | -34.3 | -4 | -15 | -102.9 | -47 |
| -35 | -240.1 | -92 | -55 | -377.3 | -132 |
| -75 | -514.5 | -164 | -95 | -651.7 | -200 |
| -115 | -788.9 | -242 | -95 | -651.7 | -211 |
| -75 | -514.5 | -180 | -55 | -377.3 | -146 |
| -35 | -240.1 | -110 | -15 | -102.9 | -67 |
| -5 | -34.3 | -42 | -3.5 | -24.7 | -26 |
| 0 | 0 | -18 |
From the experimental data, the torsional stiffness of the RV reducer was calculated, yielding a maximum stiffness of 274.4 N·m/arcmin and a minimum stiffness of 196 N·m/arcmin. The average experimental stiffness is 232.37 N·m/arcmin, and the hysteresis is 0.233 arcmin. A comparison between the finite element analysis and experimental results is presented in Table 6.
| Metric | Finite Element Method | Experimental Method | Deviation |
|---|---|---|---|
| Torsional Stiffness (N·m/arcmin) | 260.65 | 232.37 | 10.85% |
| Hysteresis (arcmin) | 0.214 | 0.233 | 8.9% |
The finite element analysis overestimates the torsional stiffness by 10.85% and underestimates the hysteresis by 8.9% compared to experimental values. This discrepancy can be attributed to simplifications in the model, such as the omission of the planetary frame and tapered roller bearings connecting the planetary frame to the crankshafts. These components contribute additional compliance that reduces the overall stiffness of the RV reducer. Additionally, manufacturing tolerances and assembly clearances in the physical RV reducer may introduce extra flexibility not captured in the ideal finite element model. Despite these differences, the finite element results exhibit similar trends and patterns as the experimental data, confirming the validity of the simulation approach for analyzing torsional stiffness and hysteresis in RV reducers.
In conclusion, this study provides a comprehensive finite element analysis of the torsional stiffness and hysteresis of an RV reducer. The model incorporates detailed geometry, material properties, contact interactions, and boundary conditions to simulate the behavior under operational loads. The results show that the torsional stiffness of the RV reducer varies sinusoidally with the meshing position, ranging from 247.1 to 278.8 N·m/arcmin, with an average of 260.65 N·m/arcmin. The hysteresis is low, averaging 0.214 arcmin, which meets precision requirements. Experimental validation indicates that the finite element method tends to overestimate stiffness and underestimate hysteresis, primarily due to model simplifications. However, the close agreement in trends demonstrates that finite element analysis is a valuable tool for the design and optimization of RV reducers. Future work could enhance the model by including additional components, such as the planetary frame and bearings, and incorporating nonlinear material behavior to improve accuracy. Overall, this research contributes to a deeper understanding of the mechanical performance of RV reducers, supporting their application in high-precision robotic systems.
The RV reducer remains a critical component in robotics, and ongoing analysis of its torsional properties will continue to drive advancements in design and performance. By leveraging finite element methods, engineers can efficiently evaluate and refine RV reducer designs to achieve higher stiffness, lower hysteresis, and improved reliability. This study underscores the importance of integrating simulation and experimental testing in the development of precision transmission systems.