
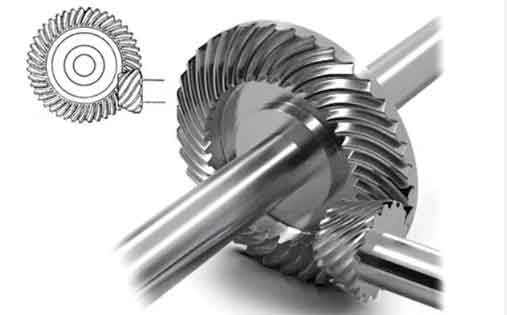
Spiral bevel gears are a critical type of gear mechanism characterized by intersecting, typically perpendicular, axes of rotation. Their design, featuring curved and oblique teeth, offers significant advantages such as compact structure, high load-bearing capacity, and smooth, quiet operation. These attributes make them indispensable in demanding applications like automotive differentials, aerospace transmissions, and heavy industrial machinery, where they frequently operate under high-speed and heavy-load conditions. The core of their performance lies in the complex, point-contact conjugate geometry of their tooth surfaces. The meshing process is inherently nonlinear, involving dynamic interactions that can induce meshing impacts, vibrations, and noise. Consequently, a profound understanding of the dynamic contact behavior of spiral bevel gears is essential for optimizing their design, improving reliability, and extending service life.
This article delves into the dynamic contact performance of spiral bevel gears using an explicit finite element analysis (FEA) approach. The primary objective is to systematically investigate the influence of key operational parameters on the meshing characteristics. These parameters include the input pinion speed, the acceleration time during startup, the inherent structural damping, and the inertial load resulting from the gear’s mass properties. The analysis focuses on dynamic responses such as the driven gear’s angular velocity, the instantaneous contact force between mating teeth, and the resulting vibration signatures. Furthermore, the phenomenon of meshing shock during the initial engagement period is explored through vibration displacement and acceleration analyses. The findings provide valuable insights into the dynamic behavior of spiral bevel gears and offer practical guidance for their design and installation support systems.
Fundamentals and Finite Element Modeling of Spiral Bevel Gears
The complex geometry of spiral bevel gear teeth makes precise modeling a foundational step for any accurate performance analysis. The tooth surface is a sophisticated spatial contour generated based on principles of local conjugate theory and machine-tool settings. Modern digital modeling techniques allow for the creation of highly accurate solid models from basic design parameters. For the purpose of this investigation, a standard gear pair was designed. The primary geometric parameters of the pinion (driving gear) and the gear (driven gear) are summarized in Table 1.
| Parameter | Gear (Driven) | Pinion (Driving) |
|---|---|---|
| Number of Teeth, \( z \) | 59 | 20 |
| Module, \( m_n \) (mm) | 4.1 | 4.1 |
| Outer Diameter (mm) | 243.23 | 91.28 |
| Pressure Angle, \( \alpha \) (°) | 20 | 20 |
| Spiral Angle, \( \beta \) (°) | 35 | 35 |
| Shaft Angle, \( \Sigma \) (°) | 90 | 90 |
| Hand of Spiral | Left | Right |
Following the generation of the precise solid model, a high-quality finite element mesh is crucial for obtaining reliable dynamic simulation results. Due to the highly twisted and complex tooth geometry, generating a structured hexahedral mesh directly within general-purpose FEA software is challenging. Therefore, specialized pre-processing tools are often employed. The model undergoes operations like volume decomposition and controlled 2D meshing to create a full-tooth, predominantly hexahedral mesh, ensuring accuracy and computational efficiency in the contact regions.
Setting up the boundary conditions and loads correctly is paramount for a dynamic analysis. The interaction between the mating tooth surfaces is defined as a surface-to-surface contact pair with finite sliding formulation. The contact property is defined as “hard” normal contact and a penalty-based friction formulation in the tangential direction. Since a concentrated rotational degree of freedom is needed to apply velocity and torque, a reference point is created at the center of mass on the axis of each gear. This reference point is then kinematically coupled to all nodes on the respective gear’s inner bore surface using a rigid body coupling constraint. This allows the application of a prescribed angular velocity to the pinion’s reference point and a resisting torque to the gear’s reference point, accurately simulating the power transmission scenario. The material is assumed to be linear elastic steel with properties: Young’s Modulus \( E = 210 \) GPa, Poisson’s ratio \( \nu = 0.3 \), and density \( \rho = 7850 \) kg/m³ unless specified otherwise for inertial studies.
Dynamic Contact Performance Under Varying Operational Parameters
The dynamic meshing process of spiral bevel gears is highly sensitive to operating conditions. This section presents a detailed parametric study, analyzing the system’s response through the driven gear’s angular velocity and the instantaneous contact force on a single tooth pair.
Influence of Pinion (Driving Gear) Speed
The input speed is a fundamental operational parameter. Three dynamic simulations were conducted with constant pinion speeds (\( \omega_p \)) of 50 rad/s, 100 rad/s, and 150 rad/s. Other parameters were held constant: acceleration time \( t_a = 0.001 \) s, damping (mass proportional coefficient \( \alpha = 500 \)), and a resisting torque on the gear of \( T_g = 500 \) N·m.
The results for the driven gear’s angular velocity (\( \omega_g \)) are shown conceptually in Figure 4. A clear trend is observed: the steady-state speed of the gear increases proportionally with the pinion speed, adhering to the basic kinematic ratio. However, the path to stability differs. The time taken for \( \omega_g \) to stabilize and the magnitude of initial oscillations are influenced by the input speed. Notably, at very high speeds, the system may overcome transient dynamics more quickly due to increased contact forces ensuring continuous engagement.
The contact force (\( F_c \)) response is even more revealing. As expected, the mean steady-state contact force increases significantly with speed due to higher dynamic loads. The amplitude of force fluctuations and their frequency also rise. This is summarized quantitatively in Table 2. Higher speeds lead to larger impact forces during initial engagement and more severe dynamic loading throughout operation, which can accelerate wear and fatigue.
| Pinion Speed, \( \omega_p \) (rad/s) | Gear Steady-State Speed, \( \omega_g \) (rad/s) | Contact Force Peak, \( F_{c,max} \) (kN) | Steady-State Contact Force, \( F_{c,ss} \) (kN) | Stabilization Time (s) |
|---|---|---|---|---|
| 50 | ~7.75 | 79.08 | ~7.56 | 0.0051 |
| 100 | ~20.35 | 144.83 | ~37.57 | 0.0082 |
| 150 | ~32.76 | 208.51 | ~82.77 | 0.0132 |
Influence of Acceleration Time
The startup transient is a critical phase where severe meshing shocks can occur. To mitigate this, the rate of acceleration can be controlled. Simulations were run with a constant pinion speed of 100 rad/s but with varying acceleration periods (\( t_a \)): 0.001 s, 0.002 s, and 0.005 s.
The results demonstrate a clear benefit of smoother acceleration. As shown in Table 3, increasing the acceleration time dramatically reduces the peak contact force during engagement. While the final steady-state speed and average contact force remain governed by the final speed and load, the path to that state becomes much gentler. The oscillations in both angular velocity and contact force are damped more quickly and have lower amplitudes. This directly translates to reduced stress peaks on the teeth and lower induced vibrations, enhancing the gear’s long-term durability.
| Acceleration Time, \( t_a \) (s) | Contact Force Peak, \( F_{c,max} \) (kN) | Stabilization Time for \( F_c \) (s) | Observation on Oscillations |
|---|---|---|---|
| 0.001 | 79.08 | ~0.0051 | High amplitude, high frequency |
| 0.002 | 42.57 | ~0.0081 | Moderate amplitude and frequency |
| 0.005 | 20.06 | ~0.0100 | Low amplitude, low frequency |
Influence of Structural Damping
Damping is an intrinsic property of any mechanical system that dissipates vibrational energy. In FEA, Rayleigh damping is commonly used, defined by the matrix equation:
$$ \mathbf{C} = \alpha \mathbf{M} + \beta \mathbf{K} $$
where \( \mathbf{C} \), \( \mathbf{M} \), and \( \mathbf{K} \) are the damping, mass, and stiffness matrices, respectively. The coefficient \( \alpha \) (mass proportional) primarily suppresses lower-frequency oscillations, which are dominant in gear meshing dynamics, while \( \beta \) (stiffness proportional) affects higher frequencies. For this study, \( \beta \) was set to zero, and the effect of \( \alpha \) was investigated with values of 100, 500, and 1000.
The impact of damping is significant on system stability. Higher damping (\( \alpha \)) effectively reduces the amplitude and persistence of oscillations in the driven gear’s speed, allowing it to reach a steady state more rapidly. The trade-off is a slight increase in the peak contact force, as the damping resists the initial separation and impact cycles. However, the primary benefit is the drastic reduction in the number of oscillatory cycles before stabilization, as quantified in Table 4. This highlights the importance of considering material damping and potential damping from lubricants or mounted components in the design of spiral bevel gear systems.
| Damping Coeff., \( \alpha \) | Contact Force Peak, \( F_{c,max} \) (kN) | Stabilization Time for \( \omega_g \) (s) | Steady-State \( F_c \) (kN) |
|---|---|---|---|
| 100 | 165.28 | 0.016 | 6.01 |
| 500 | 174.57 (+5.6%) | 0.007 (-56%) | 30.89 |
| 1000 | 191.32 (+9.6%) | 0.005 (-29%) | 55.03 |
Influence of Inertial Load
Inertial loads arise from the acceleration of the gear masses themselves. According to Newton’s second law for rotation, the inertial torque is related to the angular acceleration \( \dot{\omega} \) and the mass moment of inertia \( J \). For a given geometry, the inertia \( J \) is directly proportional to the material density \( \rho \). To isolate this effect, simulations were conducted where the density ratio between the gear and pinion was varied as 1:5, 1:1, and 5:1, effectively scaling the inertial loads.
The results, summarized in Table 5, show that increased inertia (higher density) has a pronounced effect. The system takes considerably longer to stabilize, with larger oscillations persisting in both speed and contact force. The peak contact force during the highly dynamic transient phase escalates dramatically. This demonstrates that while using dense, strong materials is often desirable for strength, it can adversely affect the dynamic response and shock characteristics of spiral bevel gears. Designers must balance static strength with dynamic performance.
| Density Ratio (Gear:Pinion) | Contact Force Peak, \( F_{c,max} \) (kN) | Stabilization Time for \( \omega_g \) (s) | Steady-State \( F_c \) (kN) |
|---|---|---|---|
| 1:5 (Low Inertia) | 12.41 | 0.007 | 6.42 |
| 1:1 (Baseline) | 53.04 | 0.012 | 25.27 |
| 5:1 (High Inertia) | 324.74 | 0.018 | 197.01 |
Vibration Analysis and Transmission Error
Vibration is a direct consequence of the dynamic contact forces and geometric imperfections in spiral bevel gears. Analyzing vibrations provides insights into noise generation, system health, and the severity of meshing impacts. Using the model with baseline parameters (ω_p=100 rad/s, t_a=0.001 s, α=500), the vibration response at a node on the meshing tooth in the axial (Z) and radial (X, Y) directions was extracted.
Vibration Displacement and Acceleration
The time-domain responses reveal distinct patterns for the pinion and the gear. The vibration displacement in the axial direction is significantly larger for the pinion compared to the gear. Conversely, in the radial directions, the gear exhibits larger vibration displacements. This asymmetry can be attributed to differences in the effective support stiffness and the direction of the dynamic meshing force components for each member of the spiral bevel gear pair.
A similar trend is observed for vibration acceleration, which is the second derivative of displacement. The pinion experiences higher axial accelerations, while the gear is subjected to higher radial accelerations. These observations are crucial for the design of bearing supports and housing structures. Supports for the pinion must be stiffer axially, whereas supports for the gear require higher radial stiffness to effectively control vibrations and maintain proper alignment.
Transmission Error Analysis
Transmission error (TE) is a primary excitation source for gear vibration and noise. It is defined as the deviation of the actual angular position of the driven gear from its theoretical position based on a perfect kinematic transfer ratio. It can be expressed as:
$$ TE(\theta_p) = \theta_g – \left( \frac{z_p}{z_g} \right) \theta_p $$
where \( \theta_g \) and \( \theta_p \) are the actual rotations of the gear and pinion, and \( z_g \), \( z_p \) are their tooth numbers. In dynamic analysis, it is often calculated from the difference between the expected and actual relative displacement along the line of action.
The dynamic transmission error for the analyzed spiral bevel gear pair exhibits a periodic pattern corresponding to the tooth meshing frequency. The amplitude and waveform of the TE are influenced by all the parameters studied above—load, speed, damping, and inertia. A key observation from the simulation is that the transmission error fluctuates more significantly during the startup transient, correlating with the high contact force peaks, and then settles into a steadier periodic pattern once stable operation is achieved. Minimizing transmission error through geometric modification (e.g., profile and lead crowning) is a central aspect of optimizing spiral bevel gears for quiet operation.
Conclusion
This comprehensive investigation into the dynamic contact performance of spiral bevel gears using explicit finite element analysis yields several critical conclusions for engineers and designers:
- Pinion Speed: Operating speed fundamentally dictates the dynamic load level. While necessary for power transmission, higher speeds generate larger contact force amplitudes and higher fluctuation frequencies, increasing the risk of fatigue and wear.
- Acceleration Time: The startup transient is a critical period for meshing shock. Increasing the acceleration time is a highly effective, control-based strategy to dramatically reduce peak contact forces and vibrational oscillations, thereby enhancing gear life.
- Structural Damping: Damping plays a vital role in stabilizing the system. Increased damping rapidly attenuates speed and force oscillations after an impact, leading to quicker stabilization, albeit with a minor increase in the initial force peak. The incorporation of damping effects in simulation models is essential for realistic dynamic prediction.
- Inertial Load: The mass properties of the spiral bevel gears have a profound dynamic effect. Higher inertia, often resulting from denser materials, leads to longer stabilization times and significantly higher transient contact force peaks. This necessitates a design trade-off between static strength (using dense materials) and favorable dynamic response.
- Vibration Characteristics: The pinion and gear exhibit distinct vibrational behavior. The pinion is more susceptible to axial vibrations, while the gear experiences larger radial vibrations. This asymmetric response must inform the design of bearing supports and housing structures to ensure system rigidity where it is most needed.
- Transmission Error: The dynamic transmission error, a key driver of vibration and noise, is directly modulated by the operational parameters studied. Optimizing gear geometry to minimize TE, combined with controlling operational dynamics, is the path to high-performance spiral bevel gear systems.
In summary, the performance of spiral bevel gears is a complex interplay of geometry, material, and operational dynamics. The finite element method, particularly explicit dynamic analysis, provides a powerful tool to simulate this interplay, allowing designers to proactively assess and improve gear designs for smoother operation, lower noise, and longer lifespan under realistic working conditions. Future work may integrate these dynamic models with thermo-elastohydrodynamic lubrication analysis and system-level models of the entire drivetrain for an even more holistic understanding.