
In the realm of mechanical engineering, gear transmission stands as a cornerstone technology for motion and power transfer, evolving over centuries to become ubiquitous in everything from industrial machinery to consumer devices. Among the diverse gear types, the bevel gear holds a pivotal role due to its ability to transmit power between intersecting shafts, typically at right angles, making it essential in applications like automotive differentials, aerospace systems, and heavy machinery. The design and manufacturing of bevel gears are complex, requiring precision and efficiency to meet modern engineering demands. As such, integrating computer-aided design (CAD) technology into bevel gear development has become a critical pursuit, aimed at streamlining processes and enhancing accuracy. In this paper, I explore a parametric modeling approach for bevel gear transmission systems, leveraging SolidWorks as the 3D modeling platform and Visual Basic 6.0 for secondary development. This methodology not only automates the design cycle but also fosters innovation by allowing rapid customization through parameter-driven models. The focus here is on creating a robust system that transforms input parameters into detailed three-dimensional representations, thereby reducing manual effort and minimizing errors in bevel gear production.
The concept of parametric modeling revolves around defining geometric features based on variables that can be easily modified to generate new designs. For bevel gear systems, this involves identifying key parameters such as pitch cone angle, number of teeth, module, tooth width, and central hole diameter. By adopting a modular design philosophy, I developed a template-based library where each bevel gear variant stems from a foundational model. This library serves as a repository of parameterized templates, enabling users to input specific values and instantly derive corresponding 3D models. The process begins with a clear flowchart that outlines the steps from parameter input to model generation: starting with user-defined inputs, progressing through geometric calculations, driving SolidWorks via API calls, and culminating in the automatic creation of the bevel gear assembly. This systematic approach ensures consistency and repeatability, which are vital for scaling designs across different bevel gear configurations. The parametric framework not only accelerates prototyping but also facilitates optimization, as designers can iteratively adjust parameters to meet performance criteria without rebuilding models from scratch.
To visualize the intricate geometry of a bevel gear, consider the following image, which illustrates the conical shape and tooth arrangement typical in transmission systems:
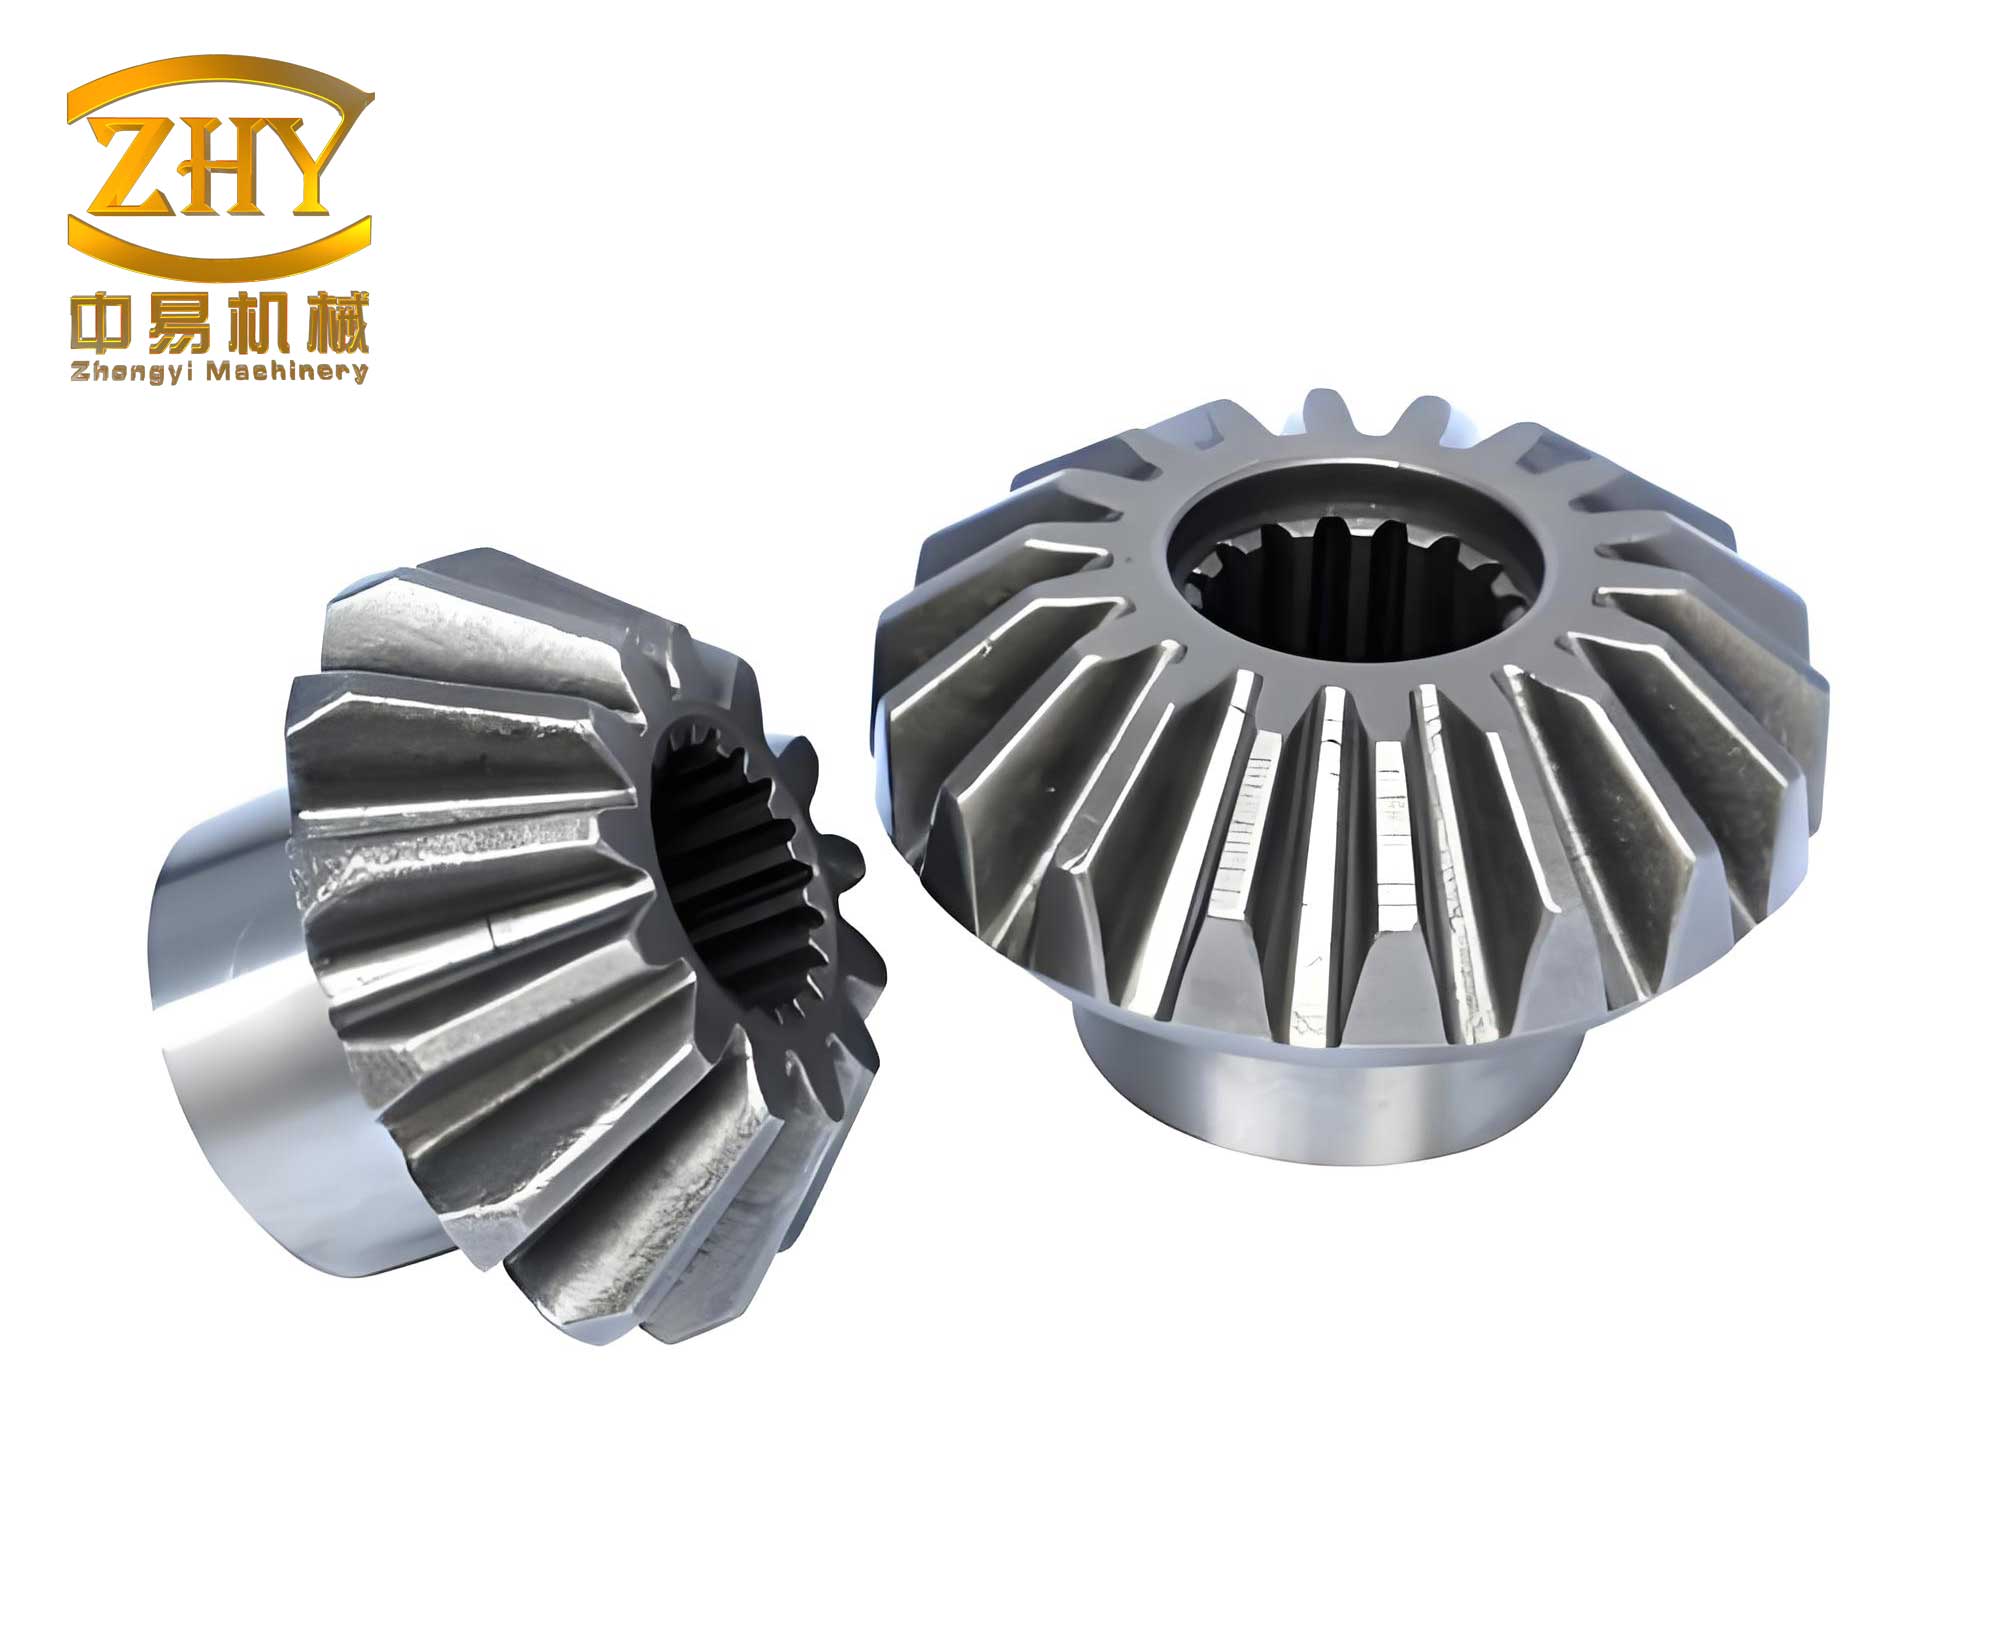
This depiction underscores the complexity involved in bevel gear design, highlighting the need for precise parametric control. The image serves as a reference for understanding how parameters like pitch cone angle and tooth profile influence the overall structure, reinforcing the importance of accurate modeling in achieving functional bevel gear systems.
The design of bevel gears hinges on a set of fundamental parameters and geometric relationships that dictate their form and function. These parameters are derived from standard engineering principles and are essential for ensuring proper meshing and power transmission. Below, I present a comprehensive table summarizing the key parameters and their mathematical formulas for a standard straight bevel gear transmission. This table encapsulates the core calculations needed to define the bevel gear geometry, serving as a foundation for the parametric modeling system.
| Name | Symbol | Formula |
|---|---|---|
| Pitch Cone Angle | $\delta$ | $\delta_1 = \arctan\left(\frac{1}{i_{12}}\right)$, $\delta_2 = \frac{\pi}{2} – \delta_1$ |
| Addendum | $h_a$ | $h_a = h_a^* m$ |
| Dedendum | $h_f$ | $h_f = (h_a^* + c^*) m$ |
| Whole Depth | $h$ | $h = h_a + h_f = (2h_a^* + c^*) m$ |
| Clearance | $c$ | $c = c^* m$ |
| Pitch Diameter | $d$ | $d_1 = m z_1$, $d_2 = m z_2$ |
| Addendum Diameter | $d_a$ | $d_{a1} = d_1 + 2h_a \cos \delta_1$, $d_{a2} = d_2 + 2h_a \cos \delta_2$ |
| Dedendum Diameter | $d_f$ | $d_{f1} = d_1 – 2h_f \cos \delta_1$, $d_{f2} = d_2 – 2h_f \cos \delta_2$ |
| Cone Distance | $R$ | $R = \frac{\sqrt{d_1^2 + d_2^2}}{2}$ |
| Addendum Angle | $\theta_a$ | For non-equal clearance contracting teeth: $\theta_{a1} = \theta_{a2} = \arctan\left(\frac{h_a}{R}\right)$; for equal clearance: $\theta_{a1} = \theta_{f2}$, $\theta_{a2} = \theta_{f1}$ |
| Dedendum Angle | $\theta_f$ | $\theta_{f1} = \theta_{f2} = \arctan\left(\frac{h_f}{R}\right)$ |
| Face Cone Angle | $\delta_a$ | $\delta_{a1} = \delta_1 + \theta_{a1}$, $\delta_{a2} = \delta_2 + \theta_{a2}$ |
| Root Cone Angle | $\delta_f$ | $\delta_{f1} = \delta_1 – \theta_{f1}$, $\delta_{f2} = \delta_2 – \theta_{f2}$ |
| Pitch Circle Tooth Thickness | $s$ | $s = \frac{\pi m}{2}$ |
| Virtual Number of Teeth | $z_v$ | $z_v = \frac{z}{\cos \delta}$ |
| Tooth Width | $b$ | $b \leq \frac{R}{3}$ |
In these formulas, $m$ represents the module, a scaling factor for tooth size; $z$ denotes the number of teeth; $h_a^*$ is the addendum coefficient (typically 1 for standard bevel gears); $c^*$ is the clearance coefficient (often 0.25); and $i_{12}$ is the transmission ratio between the two bevel gears. The pitch cone angle $\delta$ is particularly crucial, as it defines the conical orientation of the bevel gear teeth, influencing the gear’s ability to transmit torque smoothly. For instance, the addendum diameter $d_a$ ensures proper tooth engagement, calculated using $$d_a = d + 2h_a \cos \delta$$ where $d$ is the pitch diameter. Similarly, the cone distance $R$ determines the overall size of the bevel gear, derived from the Pythagorean relationship between pitch diameters: $$R = \frac{1}{2} \sqrt{(m z_1)^2 + (m z_2)^2}$$ These equations form the backbone of the parametric system, allowing for dynamic updates when input parameters change. The bevel gear’s performance metrics, such as load capacity and efficiency, rely heavily on these geometric dimensions, underscoring the need for accurate computation in the modeling process.
To implement the parametric modeling of bevel gears in SolidWorks, I followed a detailed, step-by-step procedure that integrates the calculated parameters into a 3D environment. The primary input parameters include pitch cone angle $\delta$, number of teeth $z$, tooth width $b$, central hole diameter $D_4$, and module $m$. These are designated as driving variables that control the entire model. The process initiates by creating a new SolidWorks file and defining a sketch on the front plane, labeled as “Parameter Driver.” In this sketch, I draw lines and annotate dimensions, renaming them to intuitive labels like $\delta$, $z$, $b$, $D_4$, and $m$ to enhance clarity. This sketch acts as a central hub for parameter management, where any modification propagates throughout the model.
Subsequently, I develop another sketch on the front plane to outline the bevel gear profile. This involves constructing lines and arcs based on the geometric formulas from the table. For example, the dedendum diameter $d_f$ is expressed as $$d_f = \frac{m z}{\cos \delta} – 2 h_f \cos \delta$$ with $h_f = 1.2 m$ for standard designs. To enforce these relationships, I use SolidWorks’ equation manager to link dimensions. A key relation is established for the addendum angle $\theta_a$: $$\theta_a = \arctan\left(\frac{h_a}{R}\right)$$ where $R$ is computed from the cone distance formula. Additionally, the tooth thickness $s$ is derived from the circular pitch: $$s = \frac{\pi m}{2}$$ which ensures proper meshing between bevel gear teeth. These equations are embedded as driving constraints, enabling automatic recalculation when parameters are adjusted.
Once the profile is defined, I employ SolidWorks features to generate the 3D geometry. The revolve feature creates the conical base of the bevel gear, while a sweep operation forms a single tooth based on the sketched profile. This tooth is then replicated around the axis using a circular pattern, producing the full set of teeth. The central hole and keyway are added via an extruded cut, with dimensions tied to the input parameter $D_4$. Throughout this process, I maintain parametric associations, such as linking the tooth width $b$ to the gear body’s extrusion depth. The final model is a fully associative bevel gear that updates dynamically with parameter changes. This parametric approach not only speeds up design iterations but also ensures dimensional accuracy, which is critical for manufacturing and assembly of bevel gear systems.
The automation of this modeling workflow is achieved through a custom software tool developed in Visual Basic 6.0. This tool comprises several modules: a user interface for parameter input, a data module for handling calculations, a parameter driving module for interfacing with SolidWorks, and a program calling module for executing commands. The interface is designed to be intuitive, featuring text boxes and dropdown menus for entering bevel gear parameters like $\delta$, $z$, $b$, $D_4$, and $m$. Upon input, the software performs real-time calculations using the formulas discussed earlier. For instance, the pitch diameter $d$ is computed as $$d = m z$$ and the cone distance $R$ as $$R = \frac{\sqrt{(m z_1)^2 + (m z_2)^2}}{2}$$ These values are then passed to SolidWorks via its API, triggering the modeling sequence.
The VB code integrates seamlessly with SolidWorks, utilizing methods like `OpenDoc`, `CreateSketch`, and `AddDimension` to manipulate the 3D model programmatically. A snippet for calculating and setting the addendum diameter might look like: `d_a = d + 2 * h_a * Math.Cos(delta)`, where `delta` is the pitch cone angle in radians. The software also includes error handling to validate inputs, ensuring that parameters like tooth width $b$ adhere to the constraint $b \leq R/3$. Users can set a save path for the generated bevel gear models, enhancing workflow organization. When the “Create” button is clicked, the software orchestrates the entire process—from parameter calculation to model generation—resulting in a fully defined bevel gear assembly in SolidWorks. This tool exemplifies how secondary development can bridge design intent with digital modeling, making bevel gear design more accessible and efficient.
In expanding on the geometric calculations, it is valuable to delve deeper into the derivations that underpin bevel gear design. The pitch cone angle $\delta$, for instance, is fundamental because it dictates the gear’s orientation relative to the shaft. For a pair of bevel gears with transmission ratio $i_{12} = z_2 / z_1$, the angles are computed using inverse trigonometric functions: $$\delta_1 = \arctan\left(\frac{1}{i_{12}}\right)$$ and $$\delta_2 = \frac{\pi}{2} – \delta_1$$ This ensures proper meshing at the intended shaft intersection. The module $m$, a standardized parameter, scales all tooth dimensions, with the addendum $h_a$ and dedendum $h_f$ following from it: $$h_a = h_a^* m$$ and $$h_f = (h_a^* + c^*) m$$ where $h_a^*$ and $c^*$ are coefficients typically set to 1 and 0.25, respectively, for standard bevel gears. The whole depth $h$, representing the total tooth height, is then $$h = h_a + h_f = (2h_a^* + c^*) m$$ These linear dimensions are crucial for stress analysis and durability assessments in bevel gear applications.
The cone distance $R$, a measure of the gear’s radial extent, is derived from the geometry of the pitch cones: $$R = \frac{d_1}{2 \sin \delta_1} = \frac{d_2}{2 \sin \delta_2}$$ which simplifies to $$R = \frac{\sqrt{d_1^2 + d_2^2}}{2}$$ as shown in the table. This distance influences other angles, such as the addendum angle $\theta_a$ and dedendum angle $\theta_f$, calculated via: $$\theta_a = \arctan\left(\frac{h_a}{R}\right)$$ and $$\theta_f = \arctan\left(\frac{h_f}{R}\right)$$ These angles define the taper of the tooth flanks, affecting the bevel gear’s contact pattern and load distribution. The face cone angle $\delta_a$ and root cone angle $\delta_f$ are then: $$\delta_a = \delta + \theta_a$$ and $$\delta_f = \delta – \theta_f$$ ensuring the teeth are properly oriented for manufacturing and assembly. The virtual number of teeth $z_v$, used in strength calculations, accounts for the conical shape: $$z_v = \frac{z}{\cos \delta}$$ which modifies the effective gear geometry for analysis purposes. These formulas collectively enable a comprehensive parametric description of the bevel gear, facilitating automated design updates.
Regarding the SolidWorks modeling steps, additional details can be provided on feature creation and parametric constraints. After establishing the parameter driver sketch, I create a reference sketch for the gear profile, incorporating dimensions like addendum diameter $d_a$ and dedendum diameter $d_f$. These are linked to the driver sketch through equations, such as: $$”d_a@Sketch2″ = “m@ParameterDriver” * “z@ParameterDriver” / \cos(“delta@ParameterDriver”) + 2 * “h_a@Sketch2” * \cos(“delta@ParameterDriver”)$$ where `@` denotes the sketch name in SolidWorks. The tooth profile is constructed using arcs and lines, with constraints to ensure tangency and symmetry. For the sweep feature, a path is defined along the pitch cone, and a tooth cross-section is sketched based on the calculated tooth thickness $s$. The circular pattern feature then replicates this tooth around the axis, with the instance count set to $z$. To add the central hole, I sketch a circle with diameter $D_4$ and a keyway slot, extruding it as a cut. All these features are fully parametric, meaning that altering $z$ or $m$ automatically adjusts the tooth count and size, while changing $\delta$ reorients the entire bevel gear structure. This dynamic behavior is key to efficient bevel gear design, allowing for rapid prototyping and customization.
The VB software development involves further intricacies in user interface design and API integration. The login interface, for instance, includes a timer to display the current system time via code like: `Label1.Caption = Now`. The main form features tabs for different gear types, with the bevel gear section containing input fields for all key parameters. Upon submission, the software validates the inputs—for example, checking that $b$ does not exceed $R/3$—and computes derived values using VB’s math functions. The communication with SolidWorks is handled through the `SolidWorks.Interop.sldworks` namespace, with methods like `ISldWorks.NewPart()` to create a new document and `IModelDoc2.Extension.SelectByID2()` to select sketches. The driving process involves updating dimension values in SolidWorks using statements like: `dimension.SetSystemValue3(newValue, False)`, where `newValue` is calculated from the input parameters. This seamless interaction enables the automatic generation of bevel gear models, reducing the need for manual modeling in SolidWorks. The software also logs errors and provides feedback, ensuring robustness in diverse design scenarios.
In conclusion, the parametric modeling system for bevel gear transmission systems presented here demonstrates a significant advancement in gear design methodology. By combining SolidWorks’ powerful 3D capabilities with VB-driven automation, I have created a tool that streamlines the entire design process—from parameter input to model generation. This system not only saves time and reduces errors but also enhances flexibility, allowing engineers to explore multiple bevel gear configurations quickly. The emphasis on parametric relationships ensures that designs are both accurate and adaptable, catering to various industrial applications. Future enhancements could include integration with finite element analysis for stress evaluation, expansion to other gear types like spiral bevel gears, or cloud-based collaboration features. Ultimately, this work underscores the transformative potential of CAD secondary development in advancing mechanical engineering, particularly in the domain of bevel gear technology, where precision and efficiency are paramount. The repeated focus on bevel gear parameters throughout this discussion highlights their centrality in achieving optimal transmission performance, reinforcing the value of parametric approaches in modern engineering practices.