
In modern mechanical engineering, the analysis and mitigation of vibration and noise are critical for enhancing the performance, durability, and operator comfort of industrial machinery. This research focuses specifically on the complex dynamics of bevel gear systems, which are integral components in various applications, including agricultural equipment like cotton harvesters. The primary objective of this study is to develop a robust numerical framework for analyzing the multi-field coupled vibration and noise generated by bevel gear transmissions. By integrating finite element analysis, multi-body dynamics, and acoustic boundary element methods, a comprehensive model is constructed to simulate the dynamic behavior and acoustic radiation of the entire gear system. The findings aim to provide foundational theories for vibration and noise reduction in traditional mechanical equipment, with particular emphasis on optimizing bevel gear designs.
The core of the investigation revolves around a detailed numerical model of a bevel gear system. Bevel gears, due to their conical shape, are used to transmit power between intersecting shafts, often at right angles. However, their operation is prone to dynamic excitations arising from factors such as varying mesh stiffness, manufacturing errors, and load fluctuations. These excitations induce vibrations that propagate through the gear shafts, bearings, and housing, ultimately radiating noise. To address this, a systematic approach is adopted, beginning with the creation of a high-fidelity digital twin of the bevel gear assembly. This model includes all critical components: the bevel gear pair, transmission shafts, gearbox housing, bearings, and ancillary parts like pulleys and flanges. The accuracy of this digital representation is paramount, as it directly influences the reliability of subsequent vibration and noise assessments.
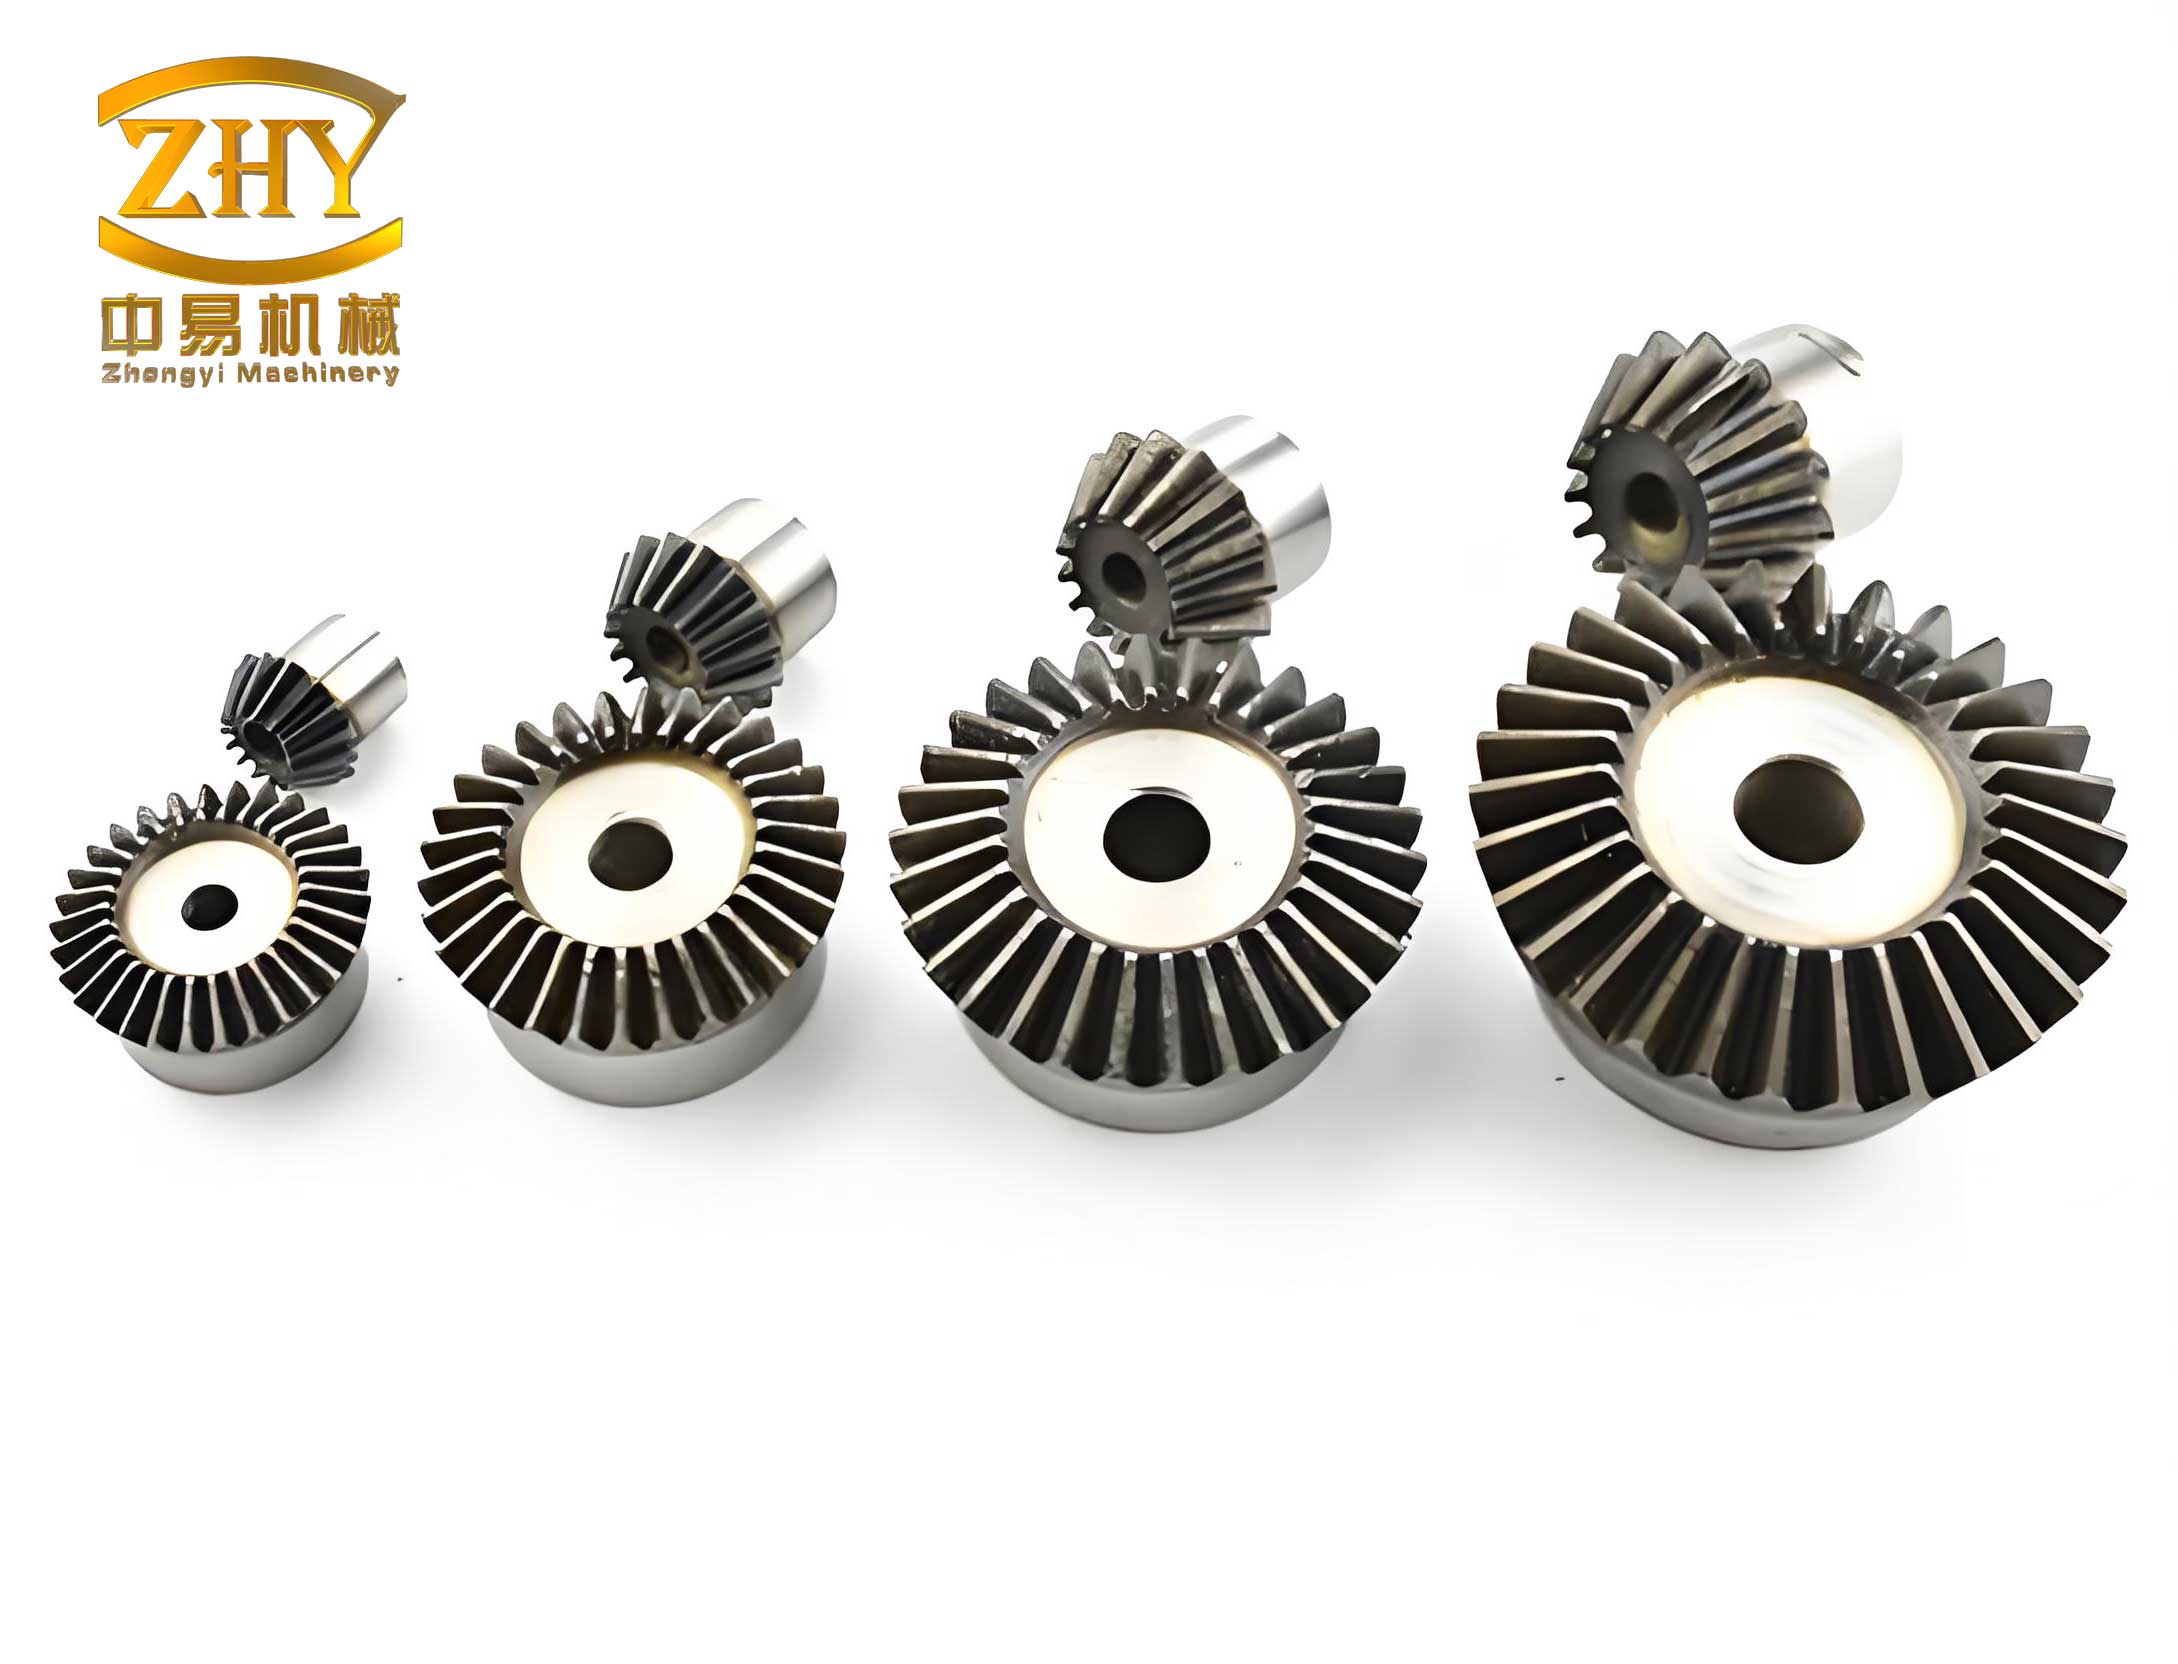
The geometric and operational parameters of the bevel gears are fundamental inputs for the analysis. The specific system studied involves a pair of bevel gears with defined characteristics. These parameters are summarized in the table below to establish a clear reference for the numerical simulations.
| Gear Designation | Number of Teeth | Module | Pitch Cone Angle | Root Cone Angle | Pressure Angle | Cone Distance | Pitch Diameter |
|---|---|---|---|---|---|---|---|
| Driven Bevel Gear | 29 | 3.75 | 54°5′ | 50°15′ | 20° | 64.134 mm | 64.134 mm |
| Driving Bevel Gear | 21 | 3.75 | 35°55′ | 32°05′ | 20° | 108.75 mm | 78.75 mm |
The first phase of the analysis involves determining the inherent dynamic characteristics, or modal properties, of the bevel gear system. This is achieved through finite element analysis (FEA) using the NASTRAN solver. The Lanczos method is employed to extract the natural frequencies and corresponding mode shapes. The modal analysis process follows a structured workflow: geometry preparation, mesh generation, application of material properties and constraints, and finally, the eigenvalue solution. Since low to medium-frequency modes often dominate the vibration response, the first 20 natural frequencies and their predominant vibration directions are calculated. The results are crucial as they reveal the system’s resonant frequencies, which must be avoided or controlled during operation to prevent excessive vibrations. The table below presents the extracted modal data for the bevel gear assembly.
| Mode Order | Natural Frequency (Hz) | Total Amplitude (mm) | Primary Vibration Direction |
|---|---|---|---|
| 1 | 352.9 | 0.618 | X-direction |
| 2 | 361.9 | 0.582 | Z-direction |
| 3 | 675.9 | 0.354 | Y-direction |
| 4 | 976.7 | 1.25 | Y-direction |
| 5 | 1253.0 | 1.60 | Y-direction |
| 6 | 1528.0 | 1.016 | Y-direction |
| 7 | 1539.0 | 1.016 | X-direction |
| 8 | 1811.0 | 1.111 | X-direction |
| 9 | 1995.0 | 1.251 | Z-direction |
| 10 | 2289.0 | 0.881 | Z-direction |
| 11 | 2458.0 | 0.849 | X-direction |
| 12 | 2769.0 | 0.951 | Y-direction |
| 13 | 2921.0 | 0.841 | X-direction |
| 14 | 3149.0 | 1.371 | X-direction |
| 15 | 3221.0 | 1.321 | Y-direction |
| 16 | 3561.0 | 0.681 | Y-direction |
| 17 | 3741.0 | 1.342 | X-direction |
| 18 | 3832.0 | 1.471 | X-direction |
| 19 | 3949.0 | 2.499 | Z-direction |
| 20 | 4137.0 | 1.431 | X-direction |
Understanding the dynamic excitation forces generated during the meshing of bevel gears is the next critical step. These forces are the primary source of vibration in the system. For this purpose, a multi-body dynamics (MBD) approach is utilized. The operational conditions for the bevel gears are defined: the driving gear inputs a power of 4.4 kW at a rotational speed of 2200 rpm. The load torque on the driven gear is calculated using the standard power-torque relationship:
$$ M_e = 9550 \times \frac{P_e}{N} $$
where \( P_e \) is the input power in kilowatts, \( N \) is the rotational speed in revolutions per minute, and \( M_e \) is the output torque in Newton-meters. Substituting the values yields \( M_e = 25.6 \, \text{N·m} \). In the MBD software RecurDyn, a contact model is established between the teeth of the driving and driven bevel gears. The driving gear is assigned a constant rotational velocity, and the calculated load torque is applied to the driven gear. The simulation solves the equations of motion using a recursive algorithm, accounting for the relative coordinate systems in the multi-body dynamics framework. The output is the time-domain history of the dynamic contact force at the gear mesh interface. This force fluctuates due to time-varying mesh stiffness and geometric imperfections inherent in bevel gears. The resulting contact force and contact moment curves serve as the essential dynamic loading conditions for the subsequent forced vibration response analysis of the entire bevel gear system structure.
With the modal properties and dynamic excitation forces known, the forced vibration response of the bevel gear system is computed. This involves applying the time-varying mesh force, obtained from the MBD analysis, as a boundary condition along the line of action of the gear teeth in the finite element model. The NASTRAN solver’s transient dynamic analysis capability, employing the full method (direct integration), is used to calculate the system’s response over time. The analysis outputs key vibration metrics at various nodes, particularly on the gearbox housing. These include displacement, velocity, and acceleration responses. Furthermore, the force transmissibility—how forces are transmitted from the excitation point to other locations—is evaluated. Frequency response functions (FRFs) are also derived, showing the system’s response to a unit force input across a frequency range. For instance, the acceleration frequency response at a specific observation point on the housing illustrates how sensitive that location is to dynamic forces at different frequencies. This step bridges the gap between the internal gear mesh excitations and the resultant structural vibrations of the bevel gear housing, which ultimately radiates noise.
The propagation of vibration into audible noise is governed by the principles of acoustics. To predict the radiated noise from the vibrating bevel gearbox, an acoustic analysis is performed. The fundamental equation for sound wave propagation in a fluid (like air) is the wave equation. Starting from the basic conservation laws—the equation of motion (Euler’s equation), the continuity equation, and the equation of state—the linear acoustic wave equation can be derived. For a homogeneous, inviscid, and adiabatic medium, the process is as follows. The continuity equation is:
$$ \frac{\partial (\rho_0 + \rho’)}{\partial t} = (\rho_0 + \rho’) q’ – (\rho_0 + \rho’) \nabla \cdot \mathbf{v} $$
The equation of motion (linearized momentum equation) is:
$$ (\rho_0 + \rho’) \left( \frac{\partial}{\partial t} + \mathbf{v} \cdot \nabla \right) \mathbf{v} = -\nabla (p_0 + p’) $$
The equation of state (linearized) is:
$$ p’ = \frac{\gamma p_0}{\rho_0} \rho’ + \frac{\gamma (\gamma – 1)}{2\rho_0^2} (\rho’)^2 + \ldots $$
By retaining only first-order terms (linear acoustics) and assuming no external mass source (\(q’ = 0\)) for the free radiation problem, the equations simplify. Combining them leads to the classical homogeneous wave equation for the acoustic pressure perturbation \( p’ \):
$$ \nabla^2 p’ – \frac{1}{c^2} \frac{\partial^2 p’}{\partial t^2} = 0 $$
where \( c = \sqrt{\gamma p_0 / \rho_0} \) is the speed of sound, \( \gamma \) is the specific heat ratio, \( p_0 \) and \( \rho_0 \) are the ambient pressure and density, respectively. For time-harmonic fields, which is a common assumption for steady-state vibration analysis, we assume \( p’ = p(x,y,z) e^{j\omega t} \), where \( \omega \) is the angular frequency. Substituting this into the wave equation yields the Helmholtz equation:
$$ \nabla^2 p + k^2 p = 0 $$
with the wavenumber \( k = \omega / c \). This equation forms the foundation for numerical acoustic methods. For exterior radiation problems, such as noise from a gearbox, the Boundary Element Method (BEM) is particularly advantageous as it only requires discretization of the radiating surface, reducing the dimensionality of the problem. The direct boundary element formulation is employed here. The vibration velocity field on the surface of the bevel gearbox, obtained from the forced response analysis, serves as the normal velocity boundary condition (\( v_n \)) for the acoustic BEM model.
The implementation involves several steps. The structural finite element mesh of the gearbox housing is used as the basis. However, BEM requires a surface mesh. Therefore, the outer surface mesh of the housing is extracted to create the acoustic boundary element mesh. Additionally, a field point mesh is defined in the surrounding air domain to calculate the sound pressure at specific locations of interest. The workflow integrates the NASTRAN structural results with the acoustic solver in LMS Virtual.Lab Acoustics. The time-domain vibration acceleration results from the structural analysis are transformed into the frequency domain and mapped onto the acoustic surface mesh as the boundary condition. The direct BEM solver then computes the complex acoustic pressure on the gearbox surface and at the defined field points by solving the Helmholtz integral equation. The primary output is the sound pressure level (SPL) distribution on the gearbox surface, which visually identifies “hot spots” of high noise radiation. The simulation for this bevel gear system revealed that the maximum surface SPL reached 83.6 dB, while the minimum was 2.18 dB. The highest radiation occurred near the corners and stiffening ribs of the gearbox housing, areas prone to high vibration amplitudes due to structural dynamics. This quantitative noise map is instrumental in guiding design modifications for noise reduction, such as adding damping materials or redesigning rib patterns to alter the vibration mode shapes of the bevel gear housing.
The interaction between the dynamic forces in the bevel gears and the structural-acoustic response is a coupled phenomenon. A deeper exploration into the mechanics of bevel gear meshing provides further insight. The dynamic transmission error, a key excitation mechanism in bevel gears, can be modeled. The static transmission error \( \epsilon(t) \) due to gear tooth profile deviations and assembly errors can be expressed as a Fourier series:
$$ \epsilon(t) = \sum_{m=1}^{M} A_m \cos(m\omega_m t + \phi_m) $$
where \( \omega_m \) is the mesh frequency (the gear rotational frequency multiplied by the number of teeth), \( A_m \) and \( \phi_m \) are the amplitude and phase of the m-th harmonic. The dynamic mesh force \( F_m(t) \) is then related to this error and the time-varying mesh stiffness \( k_m(t) \):
$$ F_m(t) = k_m(t) [x(t) – \epsilon(t)] $$
Here, \( x(t) \) is the relative dynamic displacement along the line of action. The mesh stiffness \( k_m(t) \) for bevel gears is periodic and can be approximated as:
$$ k_m(t) = k_0 + \sum_{n=1}^{N} \Delta k_n \cos(n\omega_m t + \psi_n) $$
where \( k_0 \) is the average mesh stiffness, and \( \Delta k_n \) are the stiffness variation amplitudes. Substituting into the equation of motion for the gear pair leads to a parametrically excited system. The governing equation for a simplified two-degree-of-freedom model (torsional vibration) can be written as:
$$ I_p \ddot{\theta}_p + c (\dot{\theta}_p – \dot{\theta}_g) + k_m(t) R_p (R_p \theta_p – R_g \theta_g – \epsilon(t)) = T_p $$
$$ I_g \ddot{\theta}_g – c (\dot{\theta}_p – \dot{\theta}_g) – k_m(t) R_g (R_p \theta_p – R_g \theta_g – \epsilon(t)) = -T_g $$
In these equations, \( I_p \) and \( I_g \) are the polar mass moments of inertia of the pinion (driving bevel gear) and gear (driven bevel gear), \( \theta_p \) and \( \theta_g \) are their torsional displacements, \( R_p \) and \( R_g \) are the base circle radii, \( c \) is a damping coefficient, and \( T_p \), \( T_g \) are the input and load torques. Solving this system numerically, in conjunction with the full finite element model, provides a more detailed understanding of the vibration sources within the bevel gear transmission. The spectral content of the dynamic mesh force typically shows dominant peaks at the mesh frequency and its harmonics, which correspond to the natural frequencies identified in the modal analysis. When these frequencies align, resonance occurs, leading to amplified vibrations and consequently higher noise radiation from the bevel gearbox.
To generalize the findings for design purposes, dimensionless parameters and scaling laws can be considered. For instance, the sound power radiated by a vibrating structure is proportional to the square of the vibration velocity, the radiation efficiency, and the surface area. For a baffled planar radiator, the radiated sound power \( W \) can be estimated by:
$$ W = \rho_0 c S \sigma \langle v_n^2 \rangle $$
where \( S \) is the surface area, \( \sigma \) is the radiation efficiency (a function of frequency and structural wavelength), and \( \langle v_n^2 \rangle \) is the mean-square normal surface velocity. The radiation efficiency for a finite plate below the critical frequency is often less than unity, but for complex structures like gearboxes with ribs and curvatures, it can vary significantly. The analysis performed provides a direct numerical evaluation of this relationship for the specific bevel gear housing. The results underscore that reducing the surface vibration velocity, particularly in areas of high radiation efficiency, is key to noise control. This can be achieved by shifting the natural frequencies of the bevel gear system away from excitation frequencies through stiffness redesign, or by increasing damping to attenuate the vibration response.
In conclusion, this research establishes an integrated numerical methodology for analyzing the coupled vibration and acoustic behavior of bevel gear systems. The process encompasses the development of a detailed digital model, modal analysis to identify resonant frequencies, multi-body dynamics simulation to capture time-varying mesh forces, transient structural analysis to compute forced vibration responses, and finally, acoustic boundary element analysis to predict radiated noise. The study successfully identifies the critical link between internal dynamic excitations in bevel gears and the external noise field. The maximum noise radiation was pinpointed to specific geometric features of the housing. These insights provide a theoretical and practical foundation for proactive noise and vibration reduction in the design phase of bevel gear transmissions. Future work could involve extending the analysis to include nonlinear effects such as backlash in bevel gears, investigating the influence of different lubrication conditions on damping, and performing experimental validation to refine the numerical models. Ultimately, optimizing the dynamic performance of bevel gears is essential for advancing quieter and more reliable mechanical systems across various industries.