
The pursuit of ultra-high precision in rotary indexing and servo-driven axes represents a fundamental challenge in advanced manufacturing and metrology. In applications ranging from multi-axis machining centers to precision inspection equipment, the ability to position a rotary table with micron-level accuracy and maintain this precision over an extended service life is paramount. A critical obstacle to achieving this longevity is the inherent wear in power transmission components, particularly in worm gear sets, which leads to increasing backlash and a consequent degradation of positional accuracy. Standard worm gears, while effective initially, succumb to this wear, necessitating frequent maintenance or complete replacement. This treatise explores in detail the application, design, and implementation of a specific type of worm gear pair—the variable-lead screw gear—as an elegant and robust solution to this persistent problem. The fundamental advantage of this system lies in its ability to actively and precisely compensate for wear-induced backlash without disassembly, thereby restoring and preserving its original kinematic accuracy indefinitely.
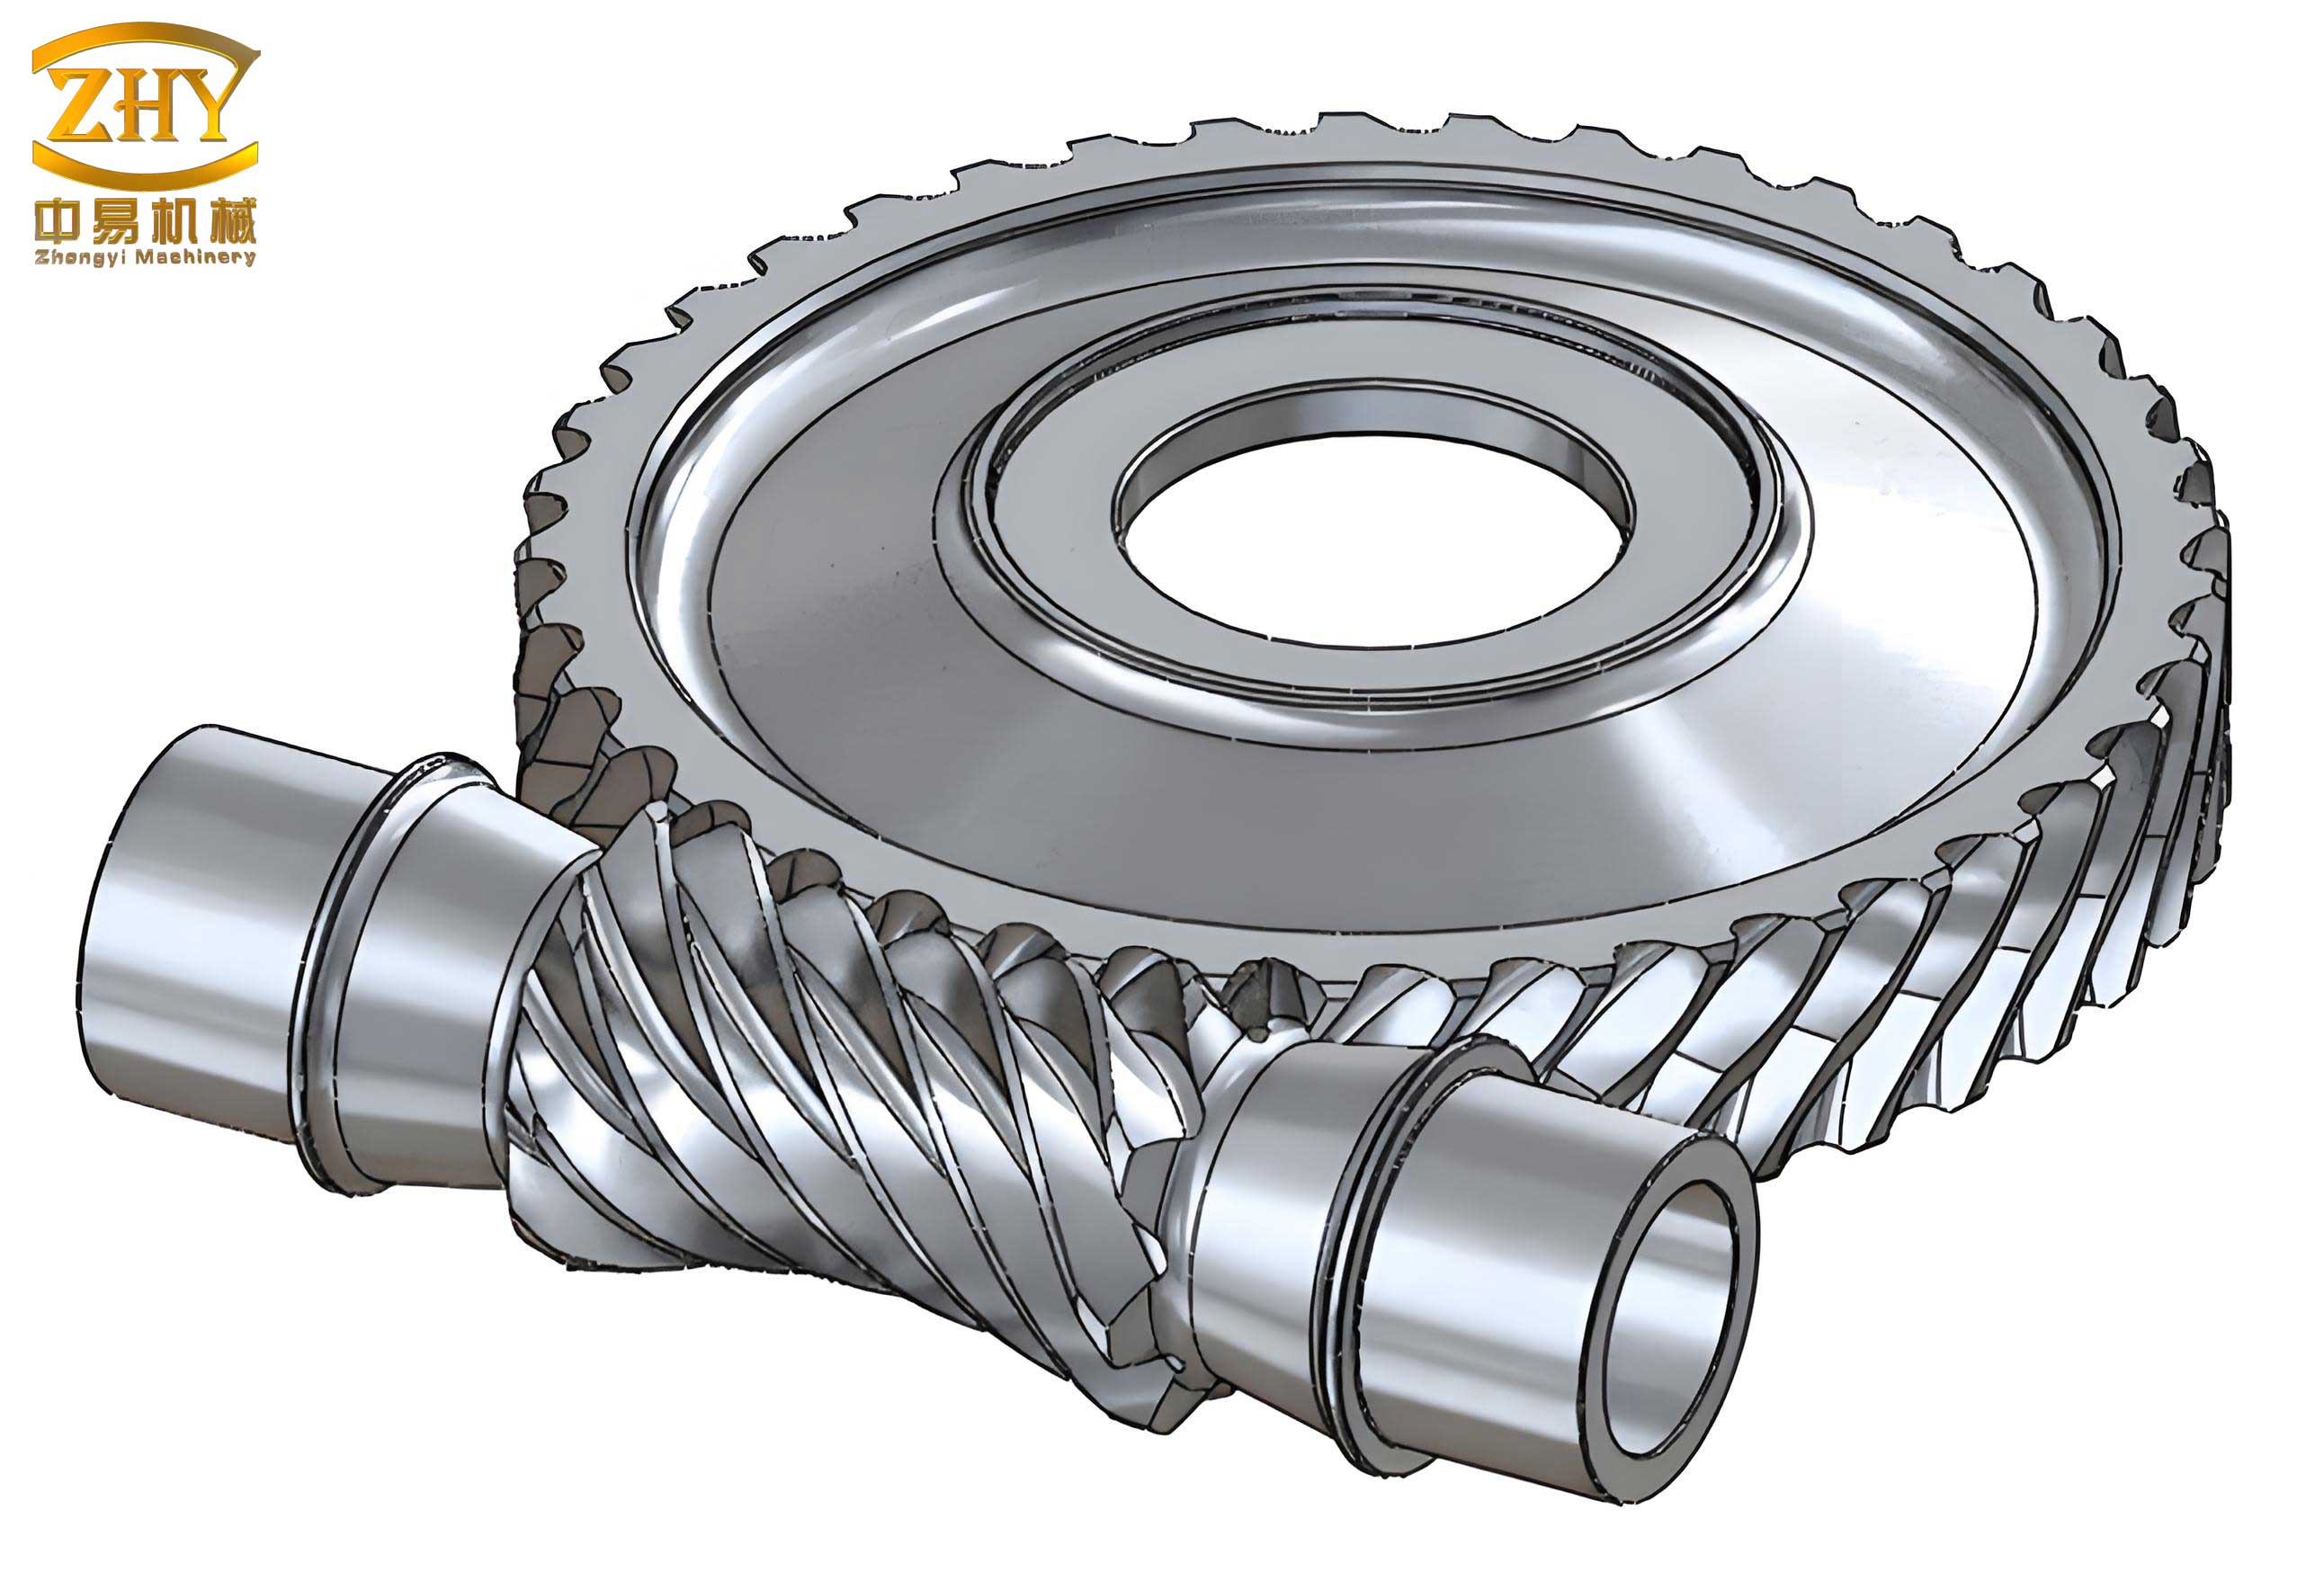
At the heart of this solution is the unique geometry of the variable-lead worm, which is the driving member of the screw gear pair. Unlike a standard single-start worm with a constant axial pitch \( p = \pi m \) (where \( m \) is the module), the variable-lead worm features a linearly progressing pitch along its axis. Consider a worm where the nominal axial pitch for a reference tooth is \( p_0 \). For subsequent teeth, the pitch is deliberately altered by a small, constant increment \( \Delta p \). Therefore, the axial pitch for the \( n \)-th tooth (relative to the reference) can be expressed as:
$$ p_n = p_0 + n \cdot \Delta p $$
This results in a corresponding change in the tooth thickness. If the tooth thickness at the reference is \( s_0 = p_0 / 2 \), then for the \( n \)-th tooth, the thickness \( s_n \) on one flank increases while the space width remains tied to the nominal pitch of the mating gear. Crucially, the mating worm wheel, or gear, is manufactured with a constant, symmetrical tooth profile. The kinematic principle is illustrated in the comparison below.
| Parameter | Standard Screw Gear | Variable-Lead Screw Gear |
|---|---|---|
| Worm Axial Pitch | Constant: \( p = \pi m \) | Variable: \( p_n = p_0 + n \cdot \Delta p \) |
| Worm Tooth Thickness | Constant: \( s = p/2 \) | Progressively changes along axis |
| Worm Wheel Tooth | Constant, symmetrical profile | Constant, symmetrical profile |
| Backlash Adjustment Mechanism | None (fixed center distance shims) | Axial displacement of the worm |
The functional magic of this screw gear pair becomes apparent when considering wear. As the contacting flanks of the worm and gear wear over time, the natural backlash in the system increases. In a standard screw gear, this is irreversible without part replacement. In the variable-lead system, the worm can be shifted axially by a precise amount \( \delta x \). This axial movement engages a slightly different, unworn portion of the worm thread with the gear teeth. Because the effective lead (and thus the tooth thickness) varies linearly with axial position, this shift effectively changes the meshing condition, reducing or entirely eliminating the accumulated backlash. The relationship between axial adjustment \( \delta x \) and the resulting change in effective meshing pitch can be derived from the lead gradient. If the lead changes by \( \Delta L \) over the worm’s active length \( L_{active} \), the gradient \( G \) is:
$$ G = \frac{\Delta L}{L_{active}} $$
An axial shift \( \delta x \) then provides a lead change of \( \delta L = G \cdot \delta x \), which directly correlates to a change in the effective tooth engagement and backlash.
Mathematical Modeling and Stiffness Considerations
The performance of any precision screw gear transmission is not solely defined by its lack of backlash but also by its torsional stiffness, which determines its resistance to deflection under load. The variable-lead design influences this characteristic. The primary source of angular deflection in a preloaded screw gear system is the contact compliance at the tooth interface. We can model the meshing stiffness \( k_m \) as a function of the contact geometry and material properties. The total torsional stiffness \( k_t \) referred to the output (gear) shaft is a combination of the mesh stiffness and the bearing stiffnesses, but is often dominated by \( k_m \).
For a worm with lead angle \( \gamma \) and pitch circle radius \( r_{worm} \), an axial preload force \( F_a \) (generated by the adjustment mechanism to eliminate backlash) creates a normal force at the tooth contact. The resulting tangential stiffness at the gear can be approximated. The transmission ratio \( i \) for a single-start worm gear is large, typically \( i = N_{gear} \), where \( N_{gear} \) is the number of teeth on the gear. The reflected inertia and stiffness are dramatically different from input to output. The key takeaway is that the adjustment mechanism for the variable-lead screw gear must not only provide precise axial positioning but also maintain a rigid lock to preserve this high stiffness. Any compliance in the adjustment lock-up directly reduces the system’s overall torsional rigidity.
$$ k_t \approx \frac{\Delta T_{gear}}{\Delta \theta_{gear}} $$
Where \( \Delta T_{gear} \) is the change in output torque and \( \Delta \theta_{gear} \) is the resulting angular deflection at the output. A well-designed variable-lead screw gear system, when properly preloaded, can exhibit stiffness comparable to a new, zero-backlash standard worm gear, but with the added benefit of maintainability.
Design and Implementation of the Backlash Adjustment System
The theoretical advantages of the variable-lead screw gear are wholly dependent on a practical and robust adjustment mechanism. The design must facilitate micron-level axial displacement of the worm shaft assembly and then lock it securely in the corrected position. A highly effective implementation integrates the worm, its support bearings, and the drive motor (often a high-resolution servo or stepper motor) into a single, monolithic cartridge or sleeve. This cartridge is mounted within the housing such that it can slide axially but is constrained in all other degrees of freedom.
Adjustment is achieved through a finely threaded mechanism. A common design employs two large-diameter, precision locknuts on a threaded portion of the housing or the cartridge itself. By carefully loosening one locknut and tightening the other, the entire worm-motor cartridge is translated axially. The use of large diameters provides a favorable leverage, allowing fine adjustments—where one full turn of the nut might correspond to a 1mm axial travel, enabling easy sub-micron control over the backlash setting. After adjustment, the two locknuts are tightened against each other, creating a rigid, zero-backlash lock that maintains the axial position against operational forces. This design philosophy ensures that the critical alignment between the worm and gear axes, established during initial assembly, remains undisturbed during the backlash compensation process. The adjustment procedure can be summarized as follows:
| Step | Action | Purpose |
|---|---|---|
| 1 | Loosen outer locknut. | Releases axial constraint on the worm cartridge. |
| 2 | Rotate inner adjustment nut. | Translates the worm cartridge axially (e.g., clockwise to reduce backlash). |
| 3 | Monitor backlash (via dial indicator or servo error). | To achieve the desired preload (slight negative backlash). |
| 4 | Tighten outer locknut against inner nut. | Creates a rigid, locked assembly with no axial play. |
| 5 | Verify stiffness and smoothness of rotation. | Ensures proper preload without excessive binding. |
Manufacturing and Run-In Processes for Variable-Lead Screw Gears
The manufacturing of a variable-lead worm is a specialized process, typically performed on CNC worm grinding machines capable of generating a precise linear lead progression. The greater challenge often lies in the manufacturing and run-in of the mating worm wheel to ensure optimal contact and load distribution across the unique worm profile. While theoretically, the wheel could be hobbled with a matching variable profile, a more pragmatic and common approach for moderate lead variations is to use a standard gear hob and then perform a controlled run-in or “lapping” process.
In this method, the variable-lead worm is coated with a fine abrasive compound. The gear is then meshed with the worm at a slightly larger than nominal center distance. The gear is slowly rotated while the center distance is gradually decreased to its final, nominal value. This process, often called “crowning in mesh,” allows the abrasive action to selectively remove material from the gear teeth, effectively generating a conjugate profile that matches the variable-lead worm’s actual flanks. The result is a near-perfect contact pattern that maximizes the contact area and minimizes stress concentrations. This run-in process is critical for achieving the high stiffness and smooth motion expected from a precision screw gear assembly. It compensates for minor manufacturing deviations and ensures that the benefits of the variable-lead geometry are fully realized in the physical components.
System Integration and Performance in High-Precision Applications
When integrated into a high-precision indexing table or a rotary servo axis, the variable-lead screw gear is typically driven by a closed-loop servo motor with a high-resolution encoder. The system’s final positioning resolution \( \Delta \theta_{res} \) is a product of the motor’s electronic subdivision resolution and the gear ratio. For a motor encoder with \( N_{enc} \) counts per revolution and a screw gear reduction ratio of \( i \), the theoretical resolution is:
$$ \Delta \theta_{res} = \frac{360^\circ}{N_{enc} \cdot i} $$
For example, a motor with a 5120-line encoder (yielding 20,480 counts/rev with 4x interpolation) driving a 72:1 ratio screw gear provides a theoretical resolution of \( 360^\circ / (20,480 \cdot 72) \approx 0.00024^\circ \). The variable-lead mechanism’s role is to ensure that this theoretical resolution is not compromised by mechanical backlash. The repeatability and long-term accuracy of the system are thus decoupled from wear, relying instead on the stability of the electronic feedback and the periodic, simple adjustment of the screw gear preload.
This capability is indispensable in applications like 5-axis contour milling of complex sculpted surfaces (e.g., aerospace blisks, molds, and prosthetics), where the rotary axes (A, B, or C) must move in perfect synchrony with the linear axes (X, Y, Z) without any lost motion. It is equally vital in precision inspection rotary stages, where angular positioning accuracy over millions of cycles is required. The following table contrasts the lifecycle performance of a traditional versus a variable-lead screw gear system.
| Performance Metric | Standard Screw Gear System | Variable-Lead Screw Gear System |
|---|---|---|
| Initial Backlash | Low (can be preloaded) | Very Low (preloaded) |
| Backlash after Wear | Increases irreversibly | Can be restored to zero via adjustment |
| Long-term Accuracy | Degrades over time | Maintainable at original specification |
| Maintenance Action for Wear | Complete disassembly, part replacement | Simple external adjustment (minutes) |
| Total Lifecycle Cost | Higher (parts, labor, downtime) | Lower (minimal downtime, no part replacement) |
Advanced Considerations and Future Directions
The principle of the variable-lead screw gear opens doors to further innovation. One area is the integration of the adjustment mechanism with automated feedback. Imagine a system where a micro-actuator, controlled by the machine’s CNC, automatically performs the axial adjustment based on real-time monitoring of servo following error or a dedicated backlash sensor. This would enable “active” or “self-healing” screw gear sets that maintain optimal preload without manual intervention.
Another frontier is the application of advanced materials and surface engineering. Coating the flanks of both the worm and gear with hard, low-friction coatings like diamond-like carbon (DLC) or molybdenum disulfide (MoS2) can drastically reduce the rate of initial wear and the coefficient of friction. When combined with the variable-lead design, the intervals between required adjustments become exceptionally long, potentially spanning the entire machine’s service life. Furthermore, research into optimized lead variation profiles—non-linear progressions tailored to specific load distributions—could yield even better performance characteristics, such as more constant mesh stiffness across the adjustment range or improved efficiency.
In conclusion, the variable-lead screw gear stands as a remarkably effective and elegant mechanical solution to the age-old problem of wear-induced backlash in precision rotary drives. By cleverly using a geometric gradient in the worm’s lead, it transforms a maintenance-intensive wear problem into a simple, periodic adjustment procedure. Its design, encompassing the specialized worm geometry, a rigid yet adjustable cartridge assembly, and a careful run-in process, results in a transmission system that offers and maintains exceptionally high positional accuracy, stiffness, and longevity. As demands for precision in manufacturing and measurement continue to escalate, the role of this sophisticated screw gear technology will only become more central to the success of high-performance rotary axis applications.