
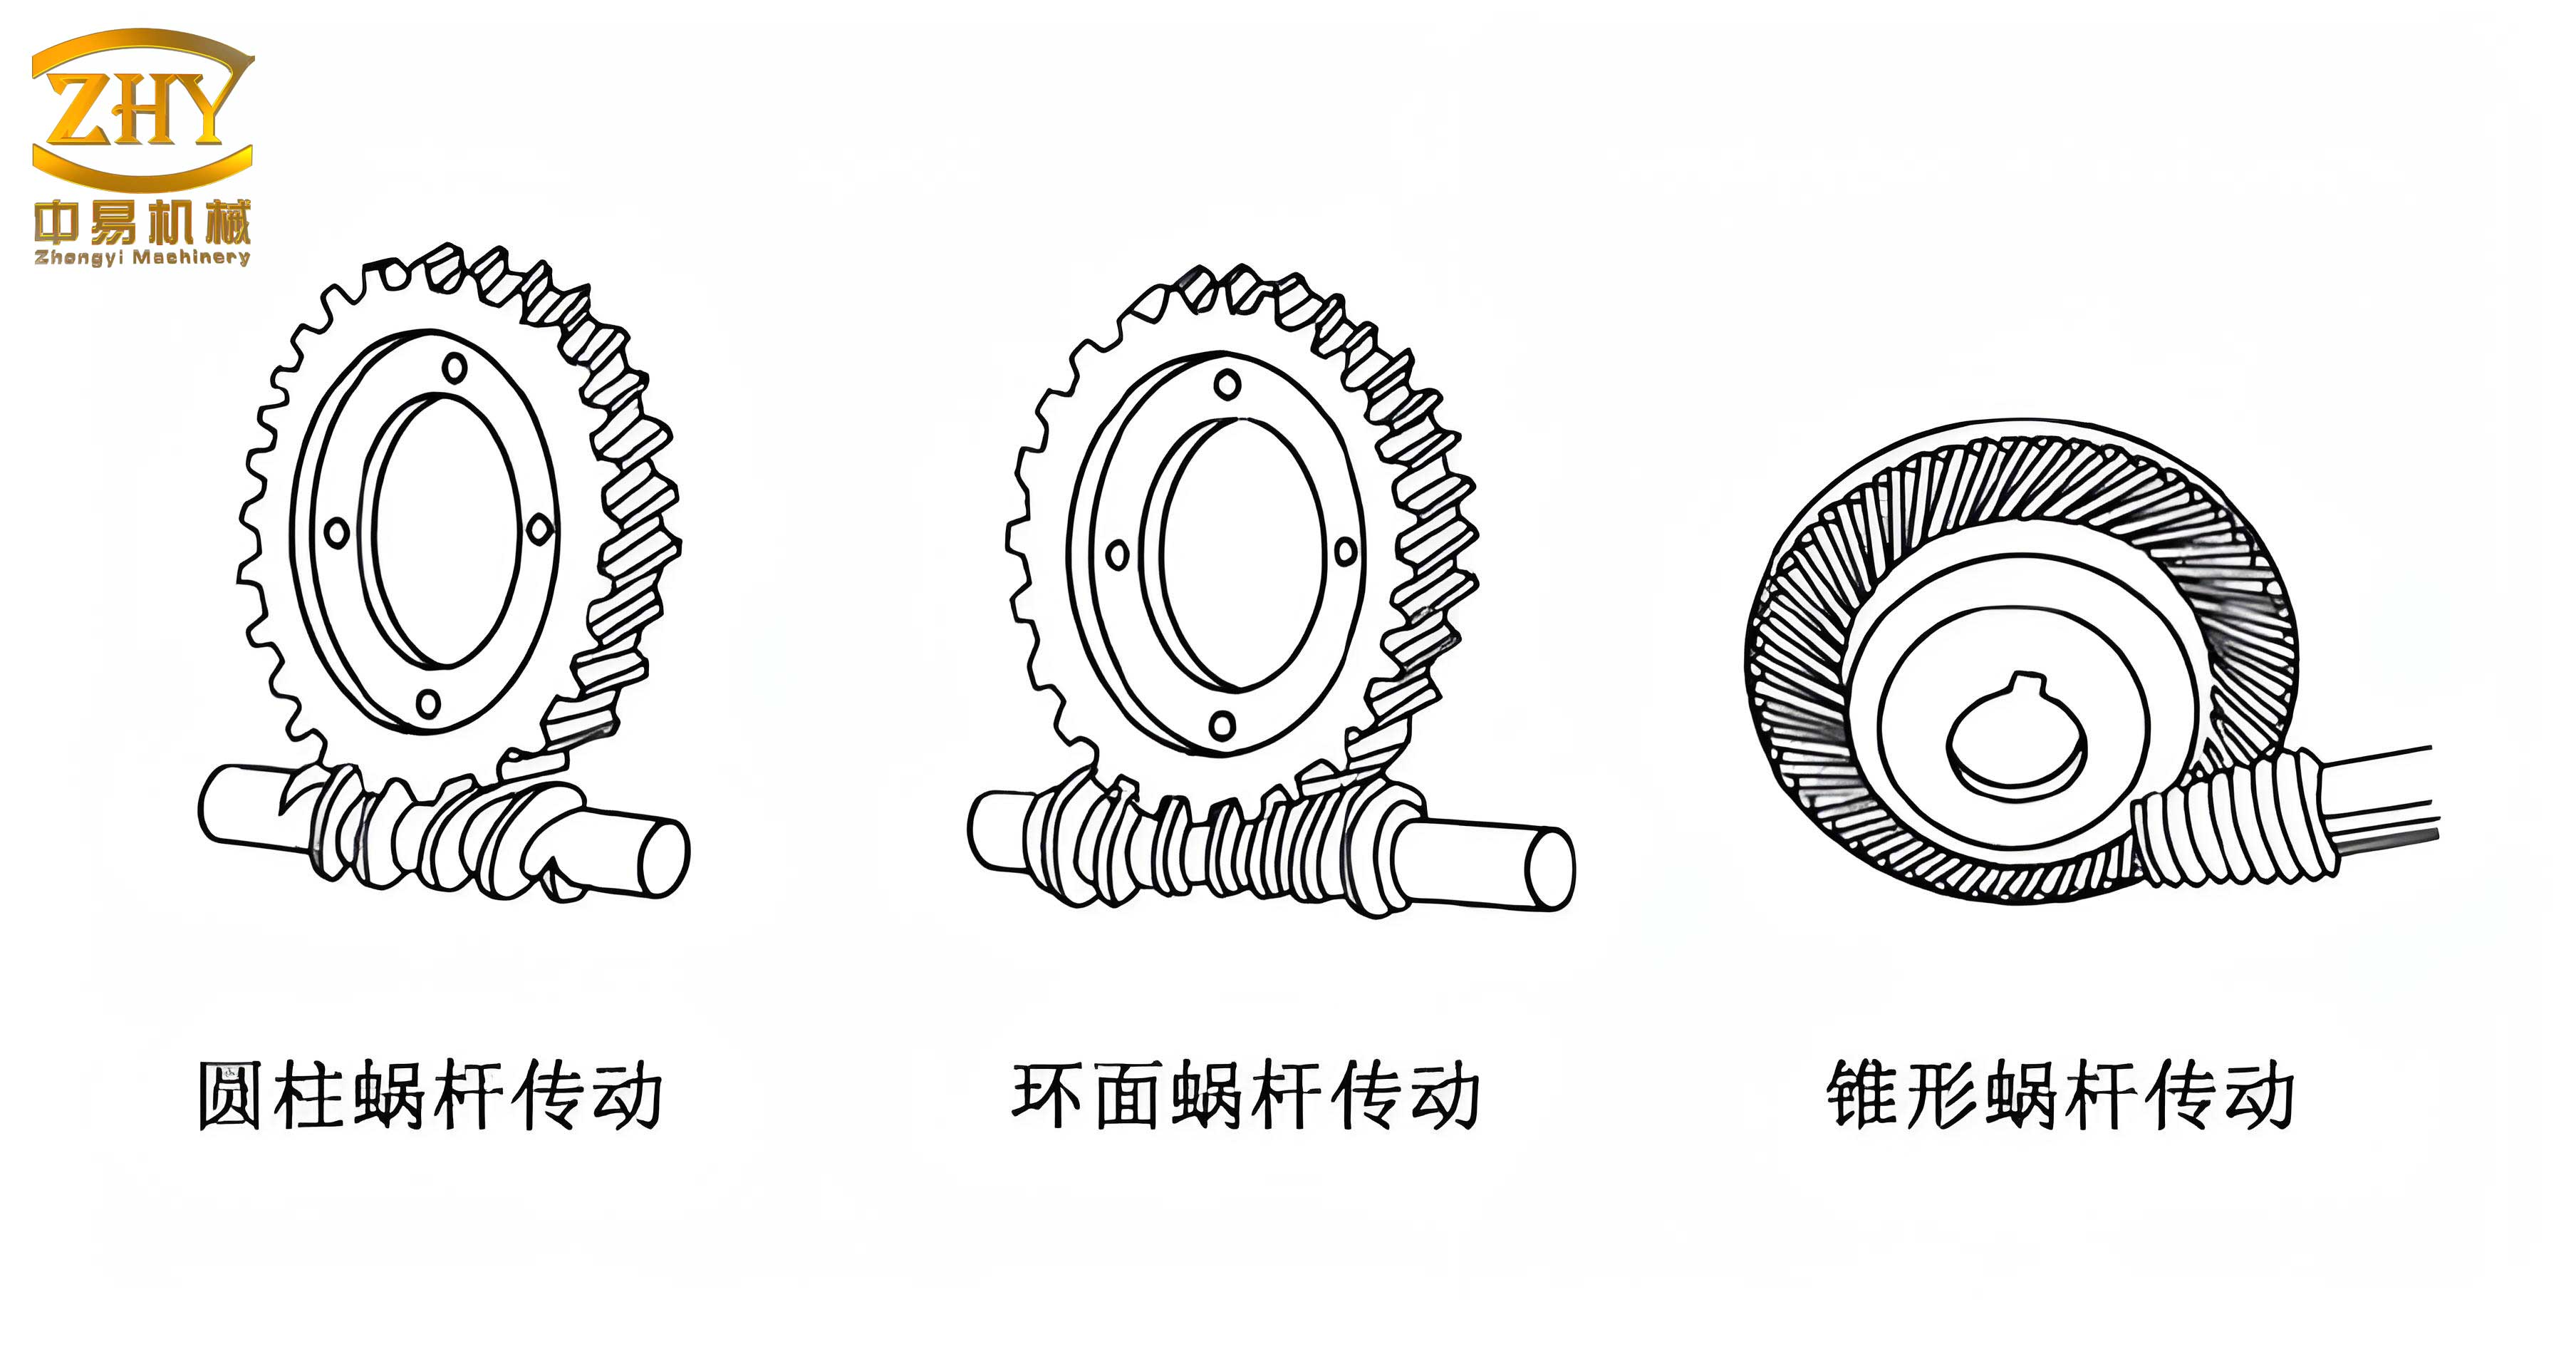
In the realm of mechanical power transmission, the screw gear drive, more commonly referred to as a worm drive, holds a unique and vital position. This mechanism, primarily composed of a worm (the screw) and a worm wheel (the gear), is designed to transmit motion and power between non-intersecting, perpendicular shafts, most often achieving significant speed reduction. As an engineer with extensive practical experience, I have found the screw gear to be an indispensable component in applications ranging from conveyor systems and lifting equipment to precision instruments and automotive steering mechanisms. Its distinctive operating principle and characteristics demand a thorough understanding for optimal selection, application, and maintenance. This article aims to provide a comprehensive exploration of screw gear drives, delving into their fundamental traits, various configurations, and critical operational aspects such as efficiency, lubrication, and thermal management.
Fundamental Characteristics and Operating Principles
The operation of a screw gear set is akin to a power screw engaging a helical gear. The worm, with its one or more helical threads, meshes with the teeth of the worm wheel, resulting in a sliding contact rather than the rolling contact predominant in parallel-shaft gear systems. This fundamental action bestows upon the screw gear a set of distinctive advantages and limitations.
Primary Advantages:
- High Reduction Ratio in a Single Stage: This is arguably the most celebrated feature of the screw gear. A significant speed reduction and corresponding torque multiplication can be achieved within a very compact envelope. Reduction ratios (i) typically range from 5:1 to 70:1 for power transmission, and can exceed 300:1 for primarily motion control applications.
- Quiet and Smooth Operation: Due to the continuous, multi-tooth engagement and the inherent sliding action, screw gear drives operate with remarkably low vibration and noise levels compared to some other gear types, making them ideal for environments where noise is a concern.
- Irreversibility and Self-Locking Potential: A crucial characteristic arises from the lead angle (λ) of the worm. When the worm’s lead angle is smaller than the equivalent friction angle (ρ) between the mating materials, the drive becomes irreversible or self-locking. This means the worm can drive the worm wheel, but the worm wheel cannot back-drive the worm. This property is essential for safety in applications like hoists and lifts, where it prevents the load from descending uncontrollably.
Inherent Limitations:
- Lower Mechanical Efficiency: The significant sliding contact generates considerable friction, leading to higher power losses in the form of heat. Efficiencies (η) for a single-stage screw gear reducer typically range from 40% to 90%, heavily influenced by the lead angle and lubrication. Notably, self-locking screw gears have efficiencies below 50%.
- Heat Generation and Thermal Management: Directly resulting from the lower efficiency, a substantial amount of input power is dissipated as heat. Effective cooling and lubrication are therefore not just beneficial but often mandatory for reliable operation.
- Material and Cost Considerations: To mitigate wear and the risk of seizure (scuffing or scoring), the worm wheel is frequently made from a softer, often bronze-based material, while the worm is made from hardened steel. The use of expensive bearing alloys for the wheel increases the overall cost of the screw gear assembly.
Types and Structural Configurations of Screw Gears
Screw gear drives are classified based on the geometry of the worm and the configuration of the meshing pair. The selection among these types involves trade-offs between load capacity, efficiency, manufacturability, and cost.
1. Cylindrical Worm Drives
This is the most prevalent category, where the worm has a cylindrical pitch surface. It is further subdivided.
| Type | Worm Profile Generation | Key Characteristics |
|---|---|---|
| ZA (Straight Side) | Cut by a straight-sided trapezoidal tool in the axial plane. | Simplest to manufacture and inspect. Common for general-purpose, non-critical applications. |
| ZN (Normal Straight Side) | Cut by a straight-sided tool in the normal plane. | Offers slightly better tooth contact than ZA. Used in applications with higher lead angles. |
| ZI (Involute Helical) | The worm thread flank is an involute helicoid. | Allows precise generation by gear hobbing machines. Facilitates high-precision gearing and regrinding of the worm. |
| ZK (Convolute) | Cut by a cone-shaped milling cutter or grinding wheel. | Good accuracy and surface finish. Commonly used in high-performance and mass-produced drives. |
| Hollow (ZC) Worm Drive | Worm thread has a circular arc profile in the normal section. | Superior load capacity and efficiency (can reach 90-95%). The concave worm profile envelops the convex wheel tooth, improving lubrication film formation. Requires precise alignment. |
2. Double-Enveloping Worm Drives
In this high-performance configuration, both the worm and the worm wheel are throated, meaning they envelop each other not just laterally but also radially. This dramatically increases the number of teeth in contact at any moment, distributing the load over a much larger area. Consequently, double-enveloping screw gears boast the highest torque density and load capacity (often 2-4 times that of cylindrical worms) and excellent shock load resistance, but they are the most sensitive to misalignment and are costly to manufacture.
3. Structural Design of Components
The Worm: Typically, the worm is integrated with its shaft, forming a single piece known as a worm shaft. It is manufactured from case-hardened or through-hardened alloy steels (e.g., AISI 4140, 8620) and is ground or polished after heat treatment to achieve a hard, wear-resistant, and smooth thread surface.
The Worm Wheel: The structure depends on size and material.
- Solid: Used for small-diameter wheels or wheels made entirely of cast iron.
- Composite: The standard for medium to large sizes. A durable bronze ring (centrifugally cast for quality) forms the toothed portion, which is then mounted onto a less expensive cast iron or steel center (hub). The assembly methods include:
- Interference Fit: The bronze rim is heated and shrunk onto the hub.
- Bolt Connection: The rim is fastened to the hub with bolts, allowing for replacement.
- Bonded/Bimetallic Casting: The bronze is cast directly onto the pre-machined hub, creating a metallurgical bond.
Efficiency Analysis of Screw Gear Drives
Understanding and predicting efficiency is paramount for screw gear application. The total efficiency (ηtotal) is the product of three components:
$$
\eta_{total} = \eta_{mesh} \times \eta_{bearing} \times \eta_{churn}
$$
Where:
ηmesh = Efficiency of the worm-worm wheel mesh (dominates)
ηbearing = Efficiency of the supporting bearings (~0.98-0.995 each pair)
ηchurn = Efficiency loss due to oil churning and seal drag (~0.96-0.98)
The meshing efficiency (ηmesh) for a worm-driven system can be accurately modeled using the power screw analogy:
$$
\eta_{mesh} = \frac{\tan \lambda}{\tan (\lambda + \rho’)}
$$
Where:
λ = Lead angle of the worm at the pitch cylinder.
ρ’ = Equivalent friction angle, where $\tan \rho’ = \mu’$. Here, μ’ is the equivalent coefficient of friction, which is not constant but depends heavily on the sliding velocity (Vs).
The sliding velocity is calculated as:
$$
V_s = \frac{\pi d_1 n_1}{60000 \cos \lambda} \quad \text{(m/s)}
$$
Where d1 is the worm pitch diameter (mm) and n1 is the worm speed (rpm). A higher Vs generally promotes the formation of a more effective elastohydrodynamic (EHL) lubricant film, reducing μ’ and thus increasing ηmesh. This relationship is often depicted in empirical charts.
The lead angle λ is the most influential design parameter. Efficiency increases with λ up to a point (typically 45°-55° maximum theoretical), but practical manufacturing constraints often limit λ to around 25°-35°. The condition for self-locking is λ ≤ ρ’. It is critical to note that a self-locking screw gear is inherently inefficient.
For preliminary design before dimensions are finalized, total efficiency can be estimated based on the number of worm threads (starts) and the enclosure type:
| Drive Condition | Worm Starts (z₁) | Estimated Total Efficiency (ηtotal) |
|---|---|---|
| Enclosed (Oil Bath) | 1 (Single-start) | 0.70 – 0.80 |
| 2 (Double-start) | 0.80 – 0.88 | |
| 4 (Quadruple-start) | 0.85 – 0.92 | |
| Open / Unenclosed | 1, 2 | 0.60 – 0.75 |
| 4 | 0.75 – 0.82 |
Lubrication: The Lifeline of a Screw Gear Drive
Proper lubrication is non-negotiable for the longevity and performance of a screw gear unit. It serves to reduce friction, minimize wear, dissipate heat, and protect against corrosion. The high sliding velocities and pressures necessitate lubricants with specific properties:
- High Viscosity: To maintain an adequate lubricant film under extreme pressure (EP) conditions.
- EP (Extreme Pressure) Additives: To prevent scoring and seizure under heavy loads.
- Anti-Wear and Friction Modifiers: To further protect surfaces and improve efficiency.
- Oxidation and Foam Resistance: For stable long-term performance.
Lubricant selection (ISO Viscosity Grade) and lubrication method are primarily functions of the sliding velocity (Vs) and the operating temperature.
| Sliding Velocity, Vs (m/s) | Lubrication Method | Recommended Oil Type |
|---|---|---|
| < 2 | Oil Bath (Splash Lubrication) | High-viscosity mineral oil with EP additives (e.g., ISO VG 460-680) |
| 2 – 10 | Oil Bath or Circulating Oil System | Medium-to-high viscosity EP oil (e.g., ISO VG 220-460) |
| > 10 | Forced Circulation / Jet Lubrication | Lower viscosity EP oil (e.g., ISO VG 100-220) to reduce churning losses. Often coupled with an external cooler. |
Oil Bath Lubrication: For worm-below-wheel configurations, the worm should dip into the oil to a depth of approximately one tooth height, but not so deep as to cause excessive churning. For worm-above-wheel configurations (used when Vs > ~5 m/s to avoid massive churning losses), the wheel dips to about 1/6 to 1/3 of its diameter.
Forced Circulation/Jet Lubrication: Oil is pumped from a reservoir, directed through a filter and cooler (if needed), and then sprayed directly into the mesh area. This method ensures positive lubrication and is essential for high-speed, high-power screw gear applications.
Thermal Balance and Power Rating
The usable power rating of an enclosed screw gear drive is often limited by its thermal capacity, not its mechanical strength. The heat generated by power losses must be dissipated to the environment at an equal rate to prevent overheating, which would degrade the lubricant and damage the gear surfaces.
Heat Generation (Qgen): The power loss in the gear mesh is converted to heat.
$$
Q_{gen} = P_{in} \times (1 – \eta_{total}) \quad \text{(W)}
$$
Where Pin is the input power in Watts.
Heat Dissipation (Qdiss): For a naturally cooled unit, heat is dissipated through the housing surface area (A) to the ambient air.
$$
Q_{diss} = k \times A \times (T_{oil} – T_{amb})
$$
Where:
k = Overall heat transfer coefficient [W/(m²·°C)]. Typically 12-18 for still air, up to 20-25 with good airflow.
A = Effective heat-dissipating surface area of the housing (m²), including fins (count ~50% of fin surface).
Toil = Operating oil temperature (°C).
Tamb = Ambient temperature (°C).
Thermal Equilibrium Condition: At steady state, Qgen = Qdiss. This allows us to calculate the expected equilibrium oil temperature or the maximum allowable input power for a given temperature rise.
Solving for Maximum Allowable Input Power (Pin, max):
$$
P_{in, max} = \frac{k \times A \times (T_{oil, max} – T_{amb})}{(1 – \eta_{total})}
$$
Where Toil, max is the maximum safe continuous oil temperature, often 85-95°C for mineral oils.
If the calculated equilibrium temperature is too high, supplemental cooling is required. Common solutions include:
- External Fan (on Worm Shaft): Increases the heat transfer coefficient (k) significantly.
- Cooling Fins: Increases the effective surface area (A).
- Water-Cooling Coil: A coil immersed in the oil sump or a cooling jacket around the housing.
- Forced Lubrication with External Cooler: The most effective method for high-power units. Oil is circulated through an air-blast or water-cooled heat exchanger.
Installation, Alignment, and Operational Maintenance
Precision in installation is critical for the performance and life of a screw gear drive. The single most important alignment criterion is that the central plane of the worm wheel must contain the axis of the worm. Misalignment drastically increases wear, noise, and the risk of failure.
Installation Procedure:
- Mount the unit on a rigid, level base.
- Connect input/output couplings, ensuring they are properly aligned (parallel and angular) to prevent imposing bending moments on the shafts.
- Adjust the worm wheel’s axial position using shims or an adjustable end cover until the specified center distance and proper tooth contact pattern are achieved. A light marking compound (prussian blue) on the wheel teeth can be used to verify contact.
Run-in (Break-in): New or rebuilt screw gears should undergo a controlled run-in period:
- Start at low load (≤25%) and low speed.
- Operate for short intervals (15-30 mins), checking for unusual noise or temperature rise.
- Gradually increase load and run time over a period of 8-24 hours.
- Inspect for proper contact pattern development. If bronze is smearing onto the worm threads, stop, clean with fine abrasive cloth, and continue run-in.
- After run-in, drain the initial oil (which will contain wear debris), flush if necessary, and refill with fresh lubricant.
Ongoing Maintenance:
- Regular Oil Checks: Monitor oil level and condition. Look for discoloration, viscosity change, or metal particles.
- Scheduled Oil Changes: Follow manufacturer recommendations, typically every 2,500 to 5,000 operating hours for industrial units. Harsh environments require more frequent changes.
- Temperature Monitoring: Regularly check housing temperature as an indicator of internal condition.
- Vibration and Noise Monitoring: Changes can indicate wear, misalignment, or bearing issues.
Conclusion
The screw gear drive is a remarkably versatile and powerful mechanical component whose unique kinematics offer solutions unavailable with other transmission types. Its ability to provide high reduction ratios in a compact space, operate with smoothness and quietness, and offer inherent braking through self-locking makes it invaluable across countless industries. However, these benefits come with the responsibility of understanding its quirks: its propensity for generating heat, its sensitivity to lubrication quality and alignment, and its relatively lower efficiency. Successfully applying a screw gear drive requires a holistic approach that balances mechanical design (type, ratio, materials), thermal management (lubricant selection, cooling method), and meticulous installation and maintenance practices. When these factors are correctly addressed, the screw gear proves to be a robust, reliable, and long-lasting workhorse of mechanical engineering. The ongoing development of advanced materials, surface treatments, and synthetic lubricants continues to push the boundaries of what these fascinating drives can achieve.