
Throughout my career as an automotive design and maintenance engineer, I have been deeply involved with the application, troubleshooting, and optimization of gear systems. Among these, the hyperboloid gear holds a particular fascination due to its unique geometry and performance characteristics. Its widespread use in automotive differentials for transmitting power at angles, especially in rear axles, is a testament to its engineering merits. However, this very complexity also makes it susceptible to specific failure modes, particularly when operational protocols or lubrication practices are not meticulously followed. In this comprehensive discussion, I will delve into the principles, common pitfalls, and essential maintenance strategies for hyperboloid gear systems, drawing from firsthand field observations and technical analyses.
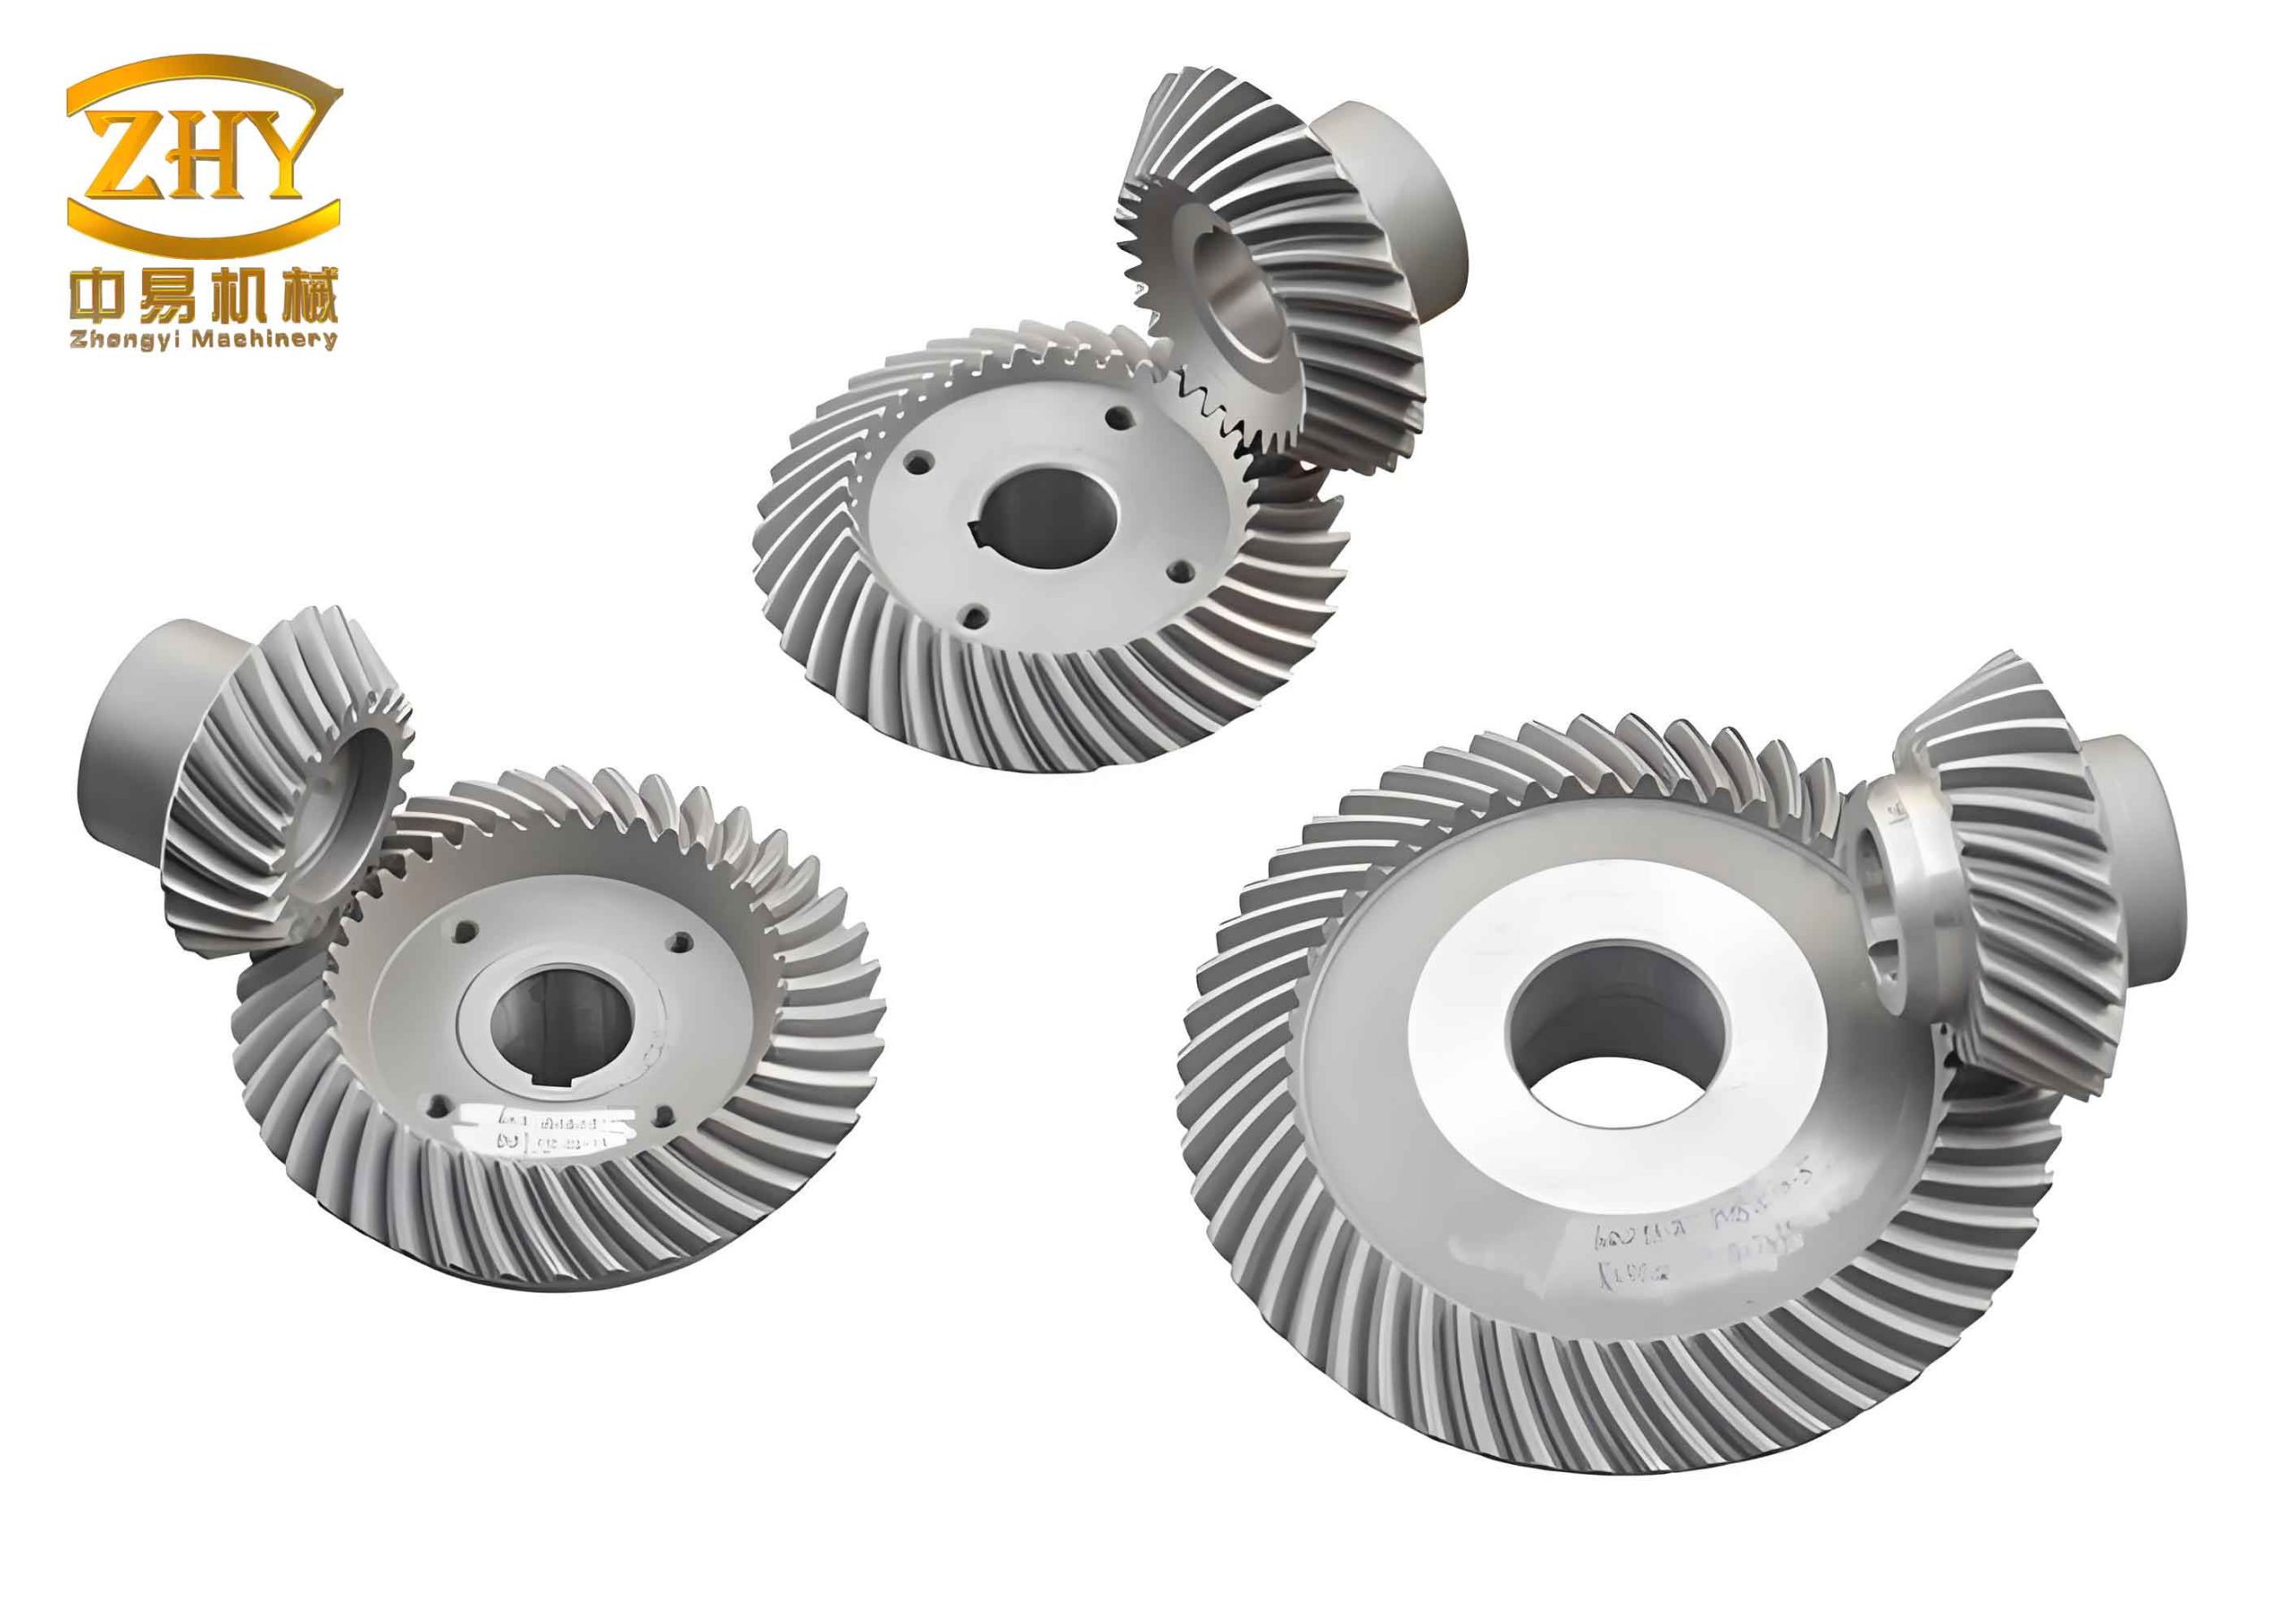
The fundamental advantage of a hyperboloid gear lies in its tooth geometry. Unlike conventional involute spur or helical gears, the teeth of a hyperboloid gear are generated from a hyperboloid of revolution. This design allows for a larger contact area and a more gradual engagement between meshing teeth. The primary kinematic relationship for a hyperboloid gear pair can be described by its gear ratio and the geometry of the hyperboloid surfaces. For a pair with axes that are non-parallel and non-intersecting (crossed axes), the velocity ratio is constant, and the contact is typically line contact, which under load becomes an elliptical contact patch. The relative curvature at the contact point is critical for stress analysis. The effective radius of curvature, $\rho_e$, for a hyperboloid gear contact can be approximated by:
$$
\frac{1}{\rho_e} = \frac{1}{\rho_1} + \frac{1}{\rho_2}
$$
where $\rho_1$ and $\rho_2$ are the principal radii of curvature of the two gear tooth surfaces at the point of contact. This geometry enables the hyperboloid gear to transmit higher torques with less noise and vibration compared to conventional designs, a key reason for its adoption in high-stress applications like vehicle drivetrains.
However, the high-performance nature of the hyperboloid gear comes with stringent requirements. One prevalent issue I’ve frequently encountered involves starter mechanisms in heavy-duty vehicles, where a small pinion gear (often part of a starter motor’s overrunning clutch) must engage with a large ring gear on the engine’s flywheel. While not always a classic hyperboloid gear pair, the principles of misaligned engagement and high contact stress are analogous and often involve gears designed with hyperbolic profiles for robustness. Failures in these systems are multifaceted. A common root cause is timing misalignment between the pinion’s outreach and the closure of the main electrical contacts. If the pinion is driven into rotation before it fully meshes with the stationary flywheel ring gear, severe impact and grinding occur. This is exacerbated by wear in the starter’s bushings, which allows excessive radial play of the armature shaft. The resulting misalignment destroys the tooth profiles. The contact stress during such an abusive engagement can be modeled using a simplified Hertzian contact stress formula for cylindrical surfaces:
$$
\sigma_H = \sqrt{ \frac{F}{\pi L} \cdot \frac{1}{\rho_e} \cdot \frac{E^*}{2} }
$$
Where $F$ is the normal load, $L$ is the effective tooth width, $\rho_e$ is the effective radius of curvature as defined earlier, and $E^*$ is the combined modulus of elasticity of the two materials $\left( \frac{1}{E^*} = \frac{1-\nu_1^2}{E_1} + \frac{1-\nu_2^2}{E_2} \right)$. When the engagement is mistimed, $F$ becomes an impact load, dramatically increasing $\sigma_H$ beyond the material’s endurance limit.
To systematically analyze the failure modes of such starter ring and pinion systems, which share design philosophy with hyperboloid gear sets in terms of handling misalignment, the following table categorizes observed problems, their primary causes, and immediate corrective actions.
| Observed Failure Symptom | Primary Technical Cause | Root Origin | Recommended Corrective Action |
|---|---|---|---|
| Starter motor spins (audible whirring) but engine does not crank | Pinion gear fails to engage with flywheel ring gear; teeth grind without meshing. | Faulty solenoid or plunger mechanism; excessive wear in engagement lever linkage; misadjusted control circuit timing. | Disassemble starter, inspect and replace solenoid/plunger assembly; adjust or replace engagement lever; check ignition switch circuit for voltage drop. |
| Loud grinding noise during engine start attempt | Partial engagement leading to shear and spalling of tooth flanks. | Worn starter motor bushings causing armature shaft misalignment; incorrect pinion travel stop adjustment. | Replace worn bushings with new ones, ensuring precise alignment; adjust pinion stop to specification. |
| Chipped or broken teeth on ring gear or pinion | High-impact loading due to late engagement or excessive cranking torque. | Weak battery causing slow pinion ejection; engine seizure or excessive friction; use of incorrect lubrication increasing resistance. | Replace damaged gear set; perform engine compression/leak-down test; ensure battery is at full charge; verify correct lubricant is used in engine. |
| Slow or labored cranking even with a healthy battery | Increased frictional drag in starter motor or engine, overloading the gear teeth. | Dry or corroded armature shaft bushings; thickened engine oil in cold conditions; internal starter motor faults (shorted windings). | Service starter motor with proper lubrication of bushings; use engine oil of appropriate viscosity; bench-test starter for current draw. |
Another critical, yet often misunderstood, aspect is lubrication. The hyperboloid gear, especially in its common automotive form known as the hypoid gear, operates under extreme pressure (EP) conditions. The sliding velocity component along the tooth face is significantly higher than in parallel-axis gears. This combination of high normal force and high sliding velocity generates immense localized heat, often reaching temperatures between 200°C and 300°C. Standard lubricating oils with simple anti-wear additives cannot maintain a protective film under these conditions. Therefore, specialized hypoid gear oils, often called Extreme Pressure (EP) oils, are formulated. These oils contain sulfur, phosphorus, and chlorine-based compounds that react chemically with the metal surface under high heat to form a sacrificial, low-shear-strength boundary layer (e.g., iron sulfide, iron chloride). This process is effectively a controlled corrosion that prevents adhesive wear (seizure). The chemical reaction kinetics can be loosely related to temperature by an Arrhenius-type equation:
$$
k = A e^{-E_a / (R T)}
$$
where $k$ is the reaction rate of the EP additive with the metal surface, $A$ is a pre-exponential factor, $E_a$ is the activation energy for the surface reaction, $R$ is the universal gas constant, and $T$ is the absolute temperature at the contact interface.
A serious and costly error I have witnessed is the misuse of this specialized hyperboloid gear oil in standard manual transmissions. Manual transmissions primarily use involute spur or helical gears, which operate under much lower unit pressures (typically below 1.5 GPa) and lower temperatures. These gears rely on a hydrodynamic or elastohydrodynamic (EHL) lubrication film. The EP additives in hyperboloid gear oil are chemically aggressive and are not needed in this milder environment. When used in a transmission, these additives can actively corrode the synchronizer rings (often made of brass or bronze) and other non-ferrous components, leading to premature wear and shifting issues. The corrosion wear rate, $W_c$, might be crudely modeled as proportional to the additive activity and the sliding distance:
$$
W_c \propto C_{add} \cdot k \cdot S
$$
where $C_{add}$ is the concentration of active EP additives, $k$ is the reaction rate constant from the previous equation, and $S$ is the total sliding distance. The following table contrasts the lubrication requirements and consequences of misuse for different gear types, emphasizing the unique needs of the hyperboloid gear.
| Gear Type / Application | Typical Operating Pressure | Primary Lubrication Regime | Required Oil Type | Consequence of Using Hyperboloid (EP) Gear Oil |
|---|---|---|---|---|
| Hyperboloid/Hypoid Gear (Vehicle Differential) | 2.5 – 4.0 GPa | Extreme Pressure Boundary Lubrication | EP Gear Oil (e.g., API GL-5) | Ideal. Provides necessary sacrificial film to prevent scuffing and pitting. |
| Helical/Spur Gear (Manual Transmission) | 0.5 – 1.5 GPa | Elastohydrodynamic (EHL) Lubrication | Non-EP Gear Oil (e.g., API GL-4) | Potentially corrosive wear on yellow metals (synchronizers), increased friction in synchronizers, wasted cost. |
| Worm Gear | Varies, high sliding | Mixed/Boundary Lubrication | Specific Worm Gear Oil (often high-viscosity with friction modifiers) | Possible incompatibility; EP additives may not be effective or could be detrimental to efficiency. |
Material science plays a pivotal role in the durability of a hyperboloid gear. The ring gear on a flywheel, which mates with the starter pinion, must have a carefully balanced hardness. If too soft, it wears rapidly; if too hard and brittle, it is prone to tooth fracture under impact. Through failure analysis, I’ve often concluded that a case-hardening process, such as carburizing or nitriding, provides an optimal combination of a tough core and a hard, wear-resistant surface. The surface hardness, often measured on the Vickers or Rockwell C scale, should be sufficiently high to resist the abrasive wear during the high-speed sliding phase of engagement. The core toughness is necessary to absorb the shock loads. The relationship between wear volume $V$, load $F$, sliding distance $S$, and material hardness $H$ is often described by the Archard wear equation:
$$
V = K \frac{F S}{H}
$$
where $K$ is a dimensionless wear coefficient specific to the material pair and lubrication condition. For a hyperboloid gear or similar engaging pair, reducing $K$ through proper lubrication and increasing $H$ through material selection and treatment are key strategies.
Preventive maintenance is non-negotiable for systems involving hyperboloid gears or similarly stressed components. For starter systems, a regimented inspection schedule should include checking the battery’s state of charge and terminal integrity, as low voltage leads to sluggish solenoid action and mistimed engagement. The starter motor itself should be periodically removed for bench testing. During such servicing, one must measure the pinion gear travel and engagement clearance meticulously. Any axial or radial play in the armature shaft exceeding manufacturer specifications—often a mere few hundredths of a millimeter—mandates the replacement of bushings. Furthermore, the engagement lever mechanism and the solenoid contacts should be inspected for wear or burning. Applying a specific high-temperature grease to the pinion shaft splines is crucial to ensure smooth axial movement, a step often overlooked.
From a design improvement perspective, several innovations can mitigate these issues. For the starter engagement problem, modern systems often employ planetary gear reduction within the starter motor itself. This allows the use of a smaller, higher-speed motor while increasing the output torque at the pinion. This design reduces the inertia of the rotating assembly, allowing for quicker pinion extension and potentially softer engagement. Another advancement is the use of pre-engaged starters with assistance from the engine control unit (ECU). The ECU can slightly adjust the fuel injection or ignition timing during the cranking phase to reduce the peak compression pressure the starter must overcome, thereby lowering the stress on the hyperboloid-influenced gear teeth at the moment of initial mesh.
The thermal management of the hyperboloid gear in its primary differential application is another area of constant development. The frictional heat generated must be effectively dissipated to prevent the lubricant from thermally degrading. The heat generation rate, $\dot{Q}$, can be estimated from the power loss due to friction:
$$
\dot{Q} \approx \mu \cdot F \cdot v_s
$$
where $\mu$ is the coefficient of friction under boundary lubrication conditions, $F$ is the normal tooth load, and $v_s$ is the sliding velocity. Efficient housing design with cooling fins and, in high-performance applications, even integrated cooling loops, are necessary to maintain oil sump temperature within a safe operating window, typically below 120°C for mineral-based oils.
In conclusion, the reliable operation of mechanical systems employing hyperboloid gear principles, whether in a starter mechanism or a final drive axle, hinges on a holistic understanding of their unique demands. This encompasses precise mechanical timing, appropriate material selection with controlled hardness, and—most critically—the use of lubrication tailored specifically to the extreme pressure environment. The misapplication of a hyperboloid gear oil, formulated with chemically active EP additives, into a system not designed for it, such as a standard transmission, is a recipe for accelerated corrosive wear. As engineers and technicians, our goal must be to respect the specific physics governing each component. By adhering to rigorous maintenance schedules, employing correct materials and lubricants, and leveraging modern design enhancements, we can ensure the longevity and reliability of these sophisticated gear systems. The hyperboloid gear, with its elegant geometry and formidable load capacity, will continue to be a cornerstone of power transmission, provided we match its engineering sophistication with equally sophisticated care and understanding.