
In the automotive industry, hyperboloid gears play a critical role in rear-drive vehicle transmission systems, directly impacting noise, vibration, and harshness (NVH) performance. The quality of the meshing contact zone is a key factor influencing driving safety and comfort. However, during heat treatment processes, hyperboloid gears undergo significant distortion due to non-uniform thermal and organizational stresses, leading to undesirable shifts in the contact zone and degraded performance. This article, from a first-person research perspective, delves into the mechanisms behind contact zone偏移 after heat treatment and proposes a practical method for quality control through cutting compensation.
Heat treatment distortion in hyperboloid gears is a complex phenomenon, but under consistent processing conditions, the changes in tooth surface errors before and after heat treatment follow predictable patterns. Through analysis of multiple gear sets, it was observed that pressure angle errors tend to stabilize post-heat treatment, while spiral angle errors exhibit more variability. Specifically, for the driving gear convex side, the spiral angle error typically decreases by approximately 3 arcminutes, and for the driven gear concave side, it decreases by about 7 arcminutes. The table below summarizes the changes in spiral angle errors after heat treatment for a batch of hyperboloid gears.
| Category | Range of Change (arcmin) | Mean Change (arcmin) | Variance (arcmin²) |
|---|---|---|---|
| Driving Gear Convex Side | -1.96 to 2.47 | -2.14 | 0.14 |
| Driven Gear Concave Side | -8.01 to -6.03 | -7.25 | 0.55 |
This distortion规律 indicates that spiral angle errors are the primary contributor to contact zone shifts, making them the focus of this study. To analytically describe the偏移, we employ the concept of first-order relative tooth surface errors. The relative pressure angle error \(\alpha\) and relative spiral angle error \(\beta\) are defined as:
$$
\alpha = \Delta \alpha_z – \Delta \alpha_b
$$
$$
\beta = \Delta \beta_z – \Delta \beta_b
$$
where \(\Delta \alpha_z\) and \(\Delta \alpha_b\) are the pressure angle errors of the driving and driven hyperboloid gears, respectively, and \(\Delta \beta_z\) and \(\Delta \beta_b\) are their spiral angle errors. These relative errors vectorially influence the meshing间隙 between tooth surfaces. For instance, consider the meshing of the driving gear convex side and the driven gear concave side. The relative间隙 at the major end \(L_H\) and minor end \(L_T\) are affected by \(\beta\). An increase in \(\beta\) (e.g., a smaller \(\Delta \beta_z\) or larger \(\Delta \beta_b\)) leads to an increased \(L_H\) and a decreased \(L_T\), causing the actual contact zone to shift toward the minor end. Similarly, \(\alpha\) influences the shift along the tooth height direction. The governing relationships can be expressed as:
$$
L_H = \frac{\sum L_H(i,j)}{5}, \quad (i=1,…,5; j=9)
$$
$$
L_T = \frac{\sum L_T(i,j)}{5}, \quad (i=1,…,5; j=1)
$$
where \(i\) and \(j\) represent grid points along the tooth height and length, respectively. The general偏移 rules derived from this analysis are: a larger \(\beta_a\) (relative spiral angle error for the coast side) shifts the driven gear concave contact zone toward the minor end; a larger \(\beta_t\) (relative spiral angle error for the drive side) shifts the driven gear convex contact zone toward the major end; a larger \(\alpha_a\) shifts the coast side contact zone toward the tooth root; and a larger \(\alpha_t\) shifts the drive side contact zone toward the tooth top.
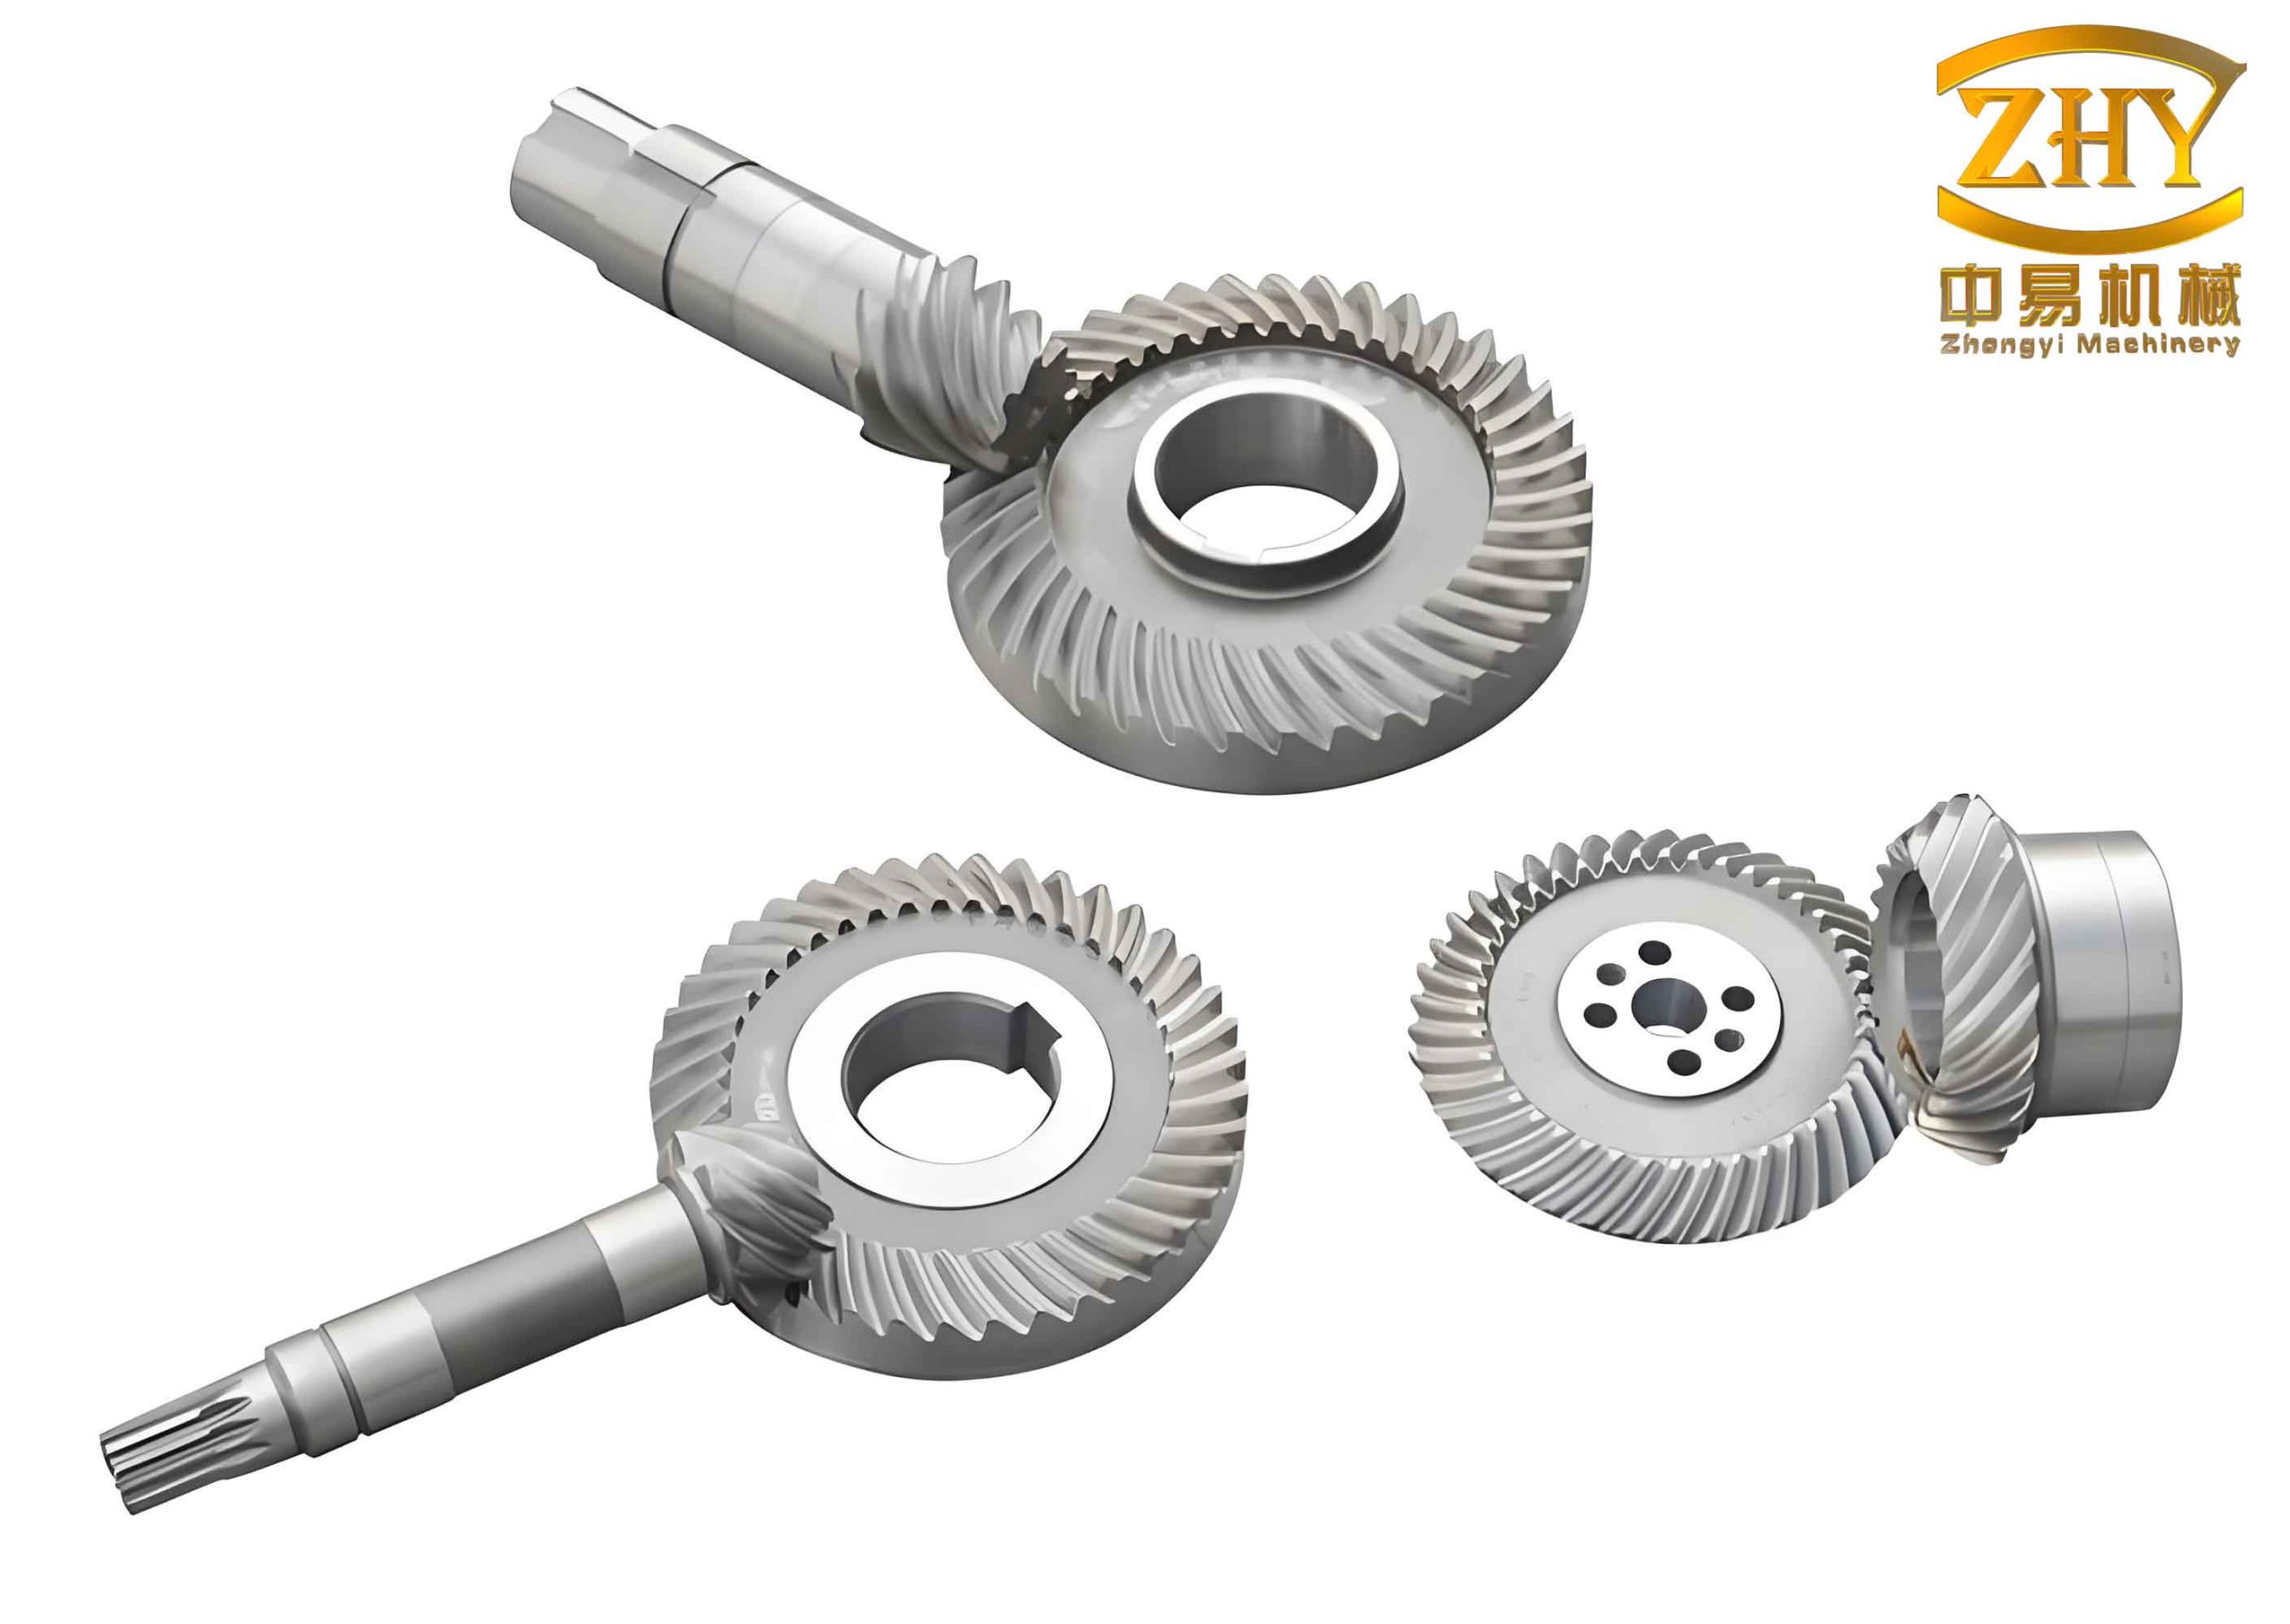
To validate this principle and quantify the impact of relative spiral angle error on contact zone position, experimental studies were conducted using a computerized numerical control rolling tester and a gear measuring machine. The objective was to observe contact zone locations under different relative spiral angle errors and verify the偏移原理. A driving hyperboloid gear with a convex side spiral angle error of approximately -2 arcminutes was paired with driven hyperboloid gears having concave side spiral angle errors around -6, -7, and -8 arcminutes. The rolling tests were performed under preset conditions: a load torque of 5 N·m, a lateral clearance of 0.1 mm, and a speed of 200 rpm for 8 seconds. The contact zones on the driven gear concave side were recorded and analyzed.
The results clearly demonstrated the influence of relative spiral angle error. As \(\beta\) increased from approximately 4 arcminutes (driving gear -2′ and driven gear -6′) to 6 arcminutes (driving gear -2′ and driven gear -8′), the contact zone progressively shifted toward the minor end. This trend confirmed the correctness of the first-order relative error analysis for hyperboloid gears. The table below details the experimental outcomes for the driven hyperboloid gears.
| Test Group | Sample | Concave Spiral Angle Error (arcmin) | Contact Zone Position |
|---|---|---|---|
| 1 | 1 | -5.93 | Near minor end |
| 2 | -5.96 | ||
| 3 | -6.03 | ||
| 2 | 4 | -6.94 | Minor end |
| 5 | -7.03 | ||
| 6 | -7.12 | ||
| 3 | 7 | -9.75 | Extreme minor end |
| 8 | -8.07 | ||
| 9 | -8.16 |
The experiment indicated that to achieve a standard contact zone located at the mid-to-minor end, the post-heat treatment concave spiral angle error of driven hyperboloid gears should be controlled within -6 arcminutes. This insight forms the basis for implementing a cutting compensation strategy. Given the challenges in post-heat treatment grinding of hyperboloid gears, pre-compensation during the cutting stage is a viable approach. By反向调整 the cutting parameters based on the heat treatment distortion规律, a new cutting model was developed to intentionally introduce an opposite error that cancels out the expected distortion. Specifically, for the driven hyperboloid gear concave side, the spiral angle was adjusted during cutting so that after heat treatment, it falls within the desired range of -6 to -4 arcminutes.
To verify the effectiveness of this compensation method for hyperboloid gears, a trial production was conducted using the new cutting model. A batch of 360 gears was manufactured, and a sampling inspection was performed. Samples were taken at intervals: the first five, last five, and every twentieth gear in between. After heat treatment, the tooth surface errors of these samples were measured. The results for spiral angle errors are summarized below, showing that the post-heat treatment errors met the target range.
| First-Order Tooth Surface Error | Mean (arcmin) | Variance (arcmin²) |
|---|---|---|
| Driving Gear Concave Spiral Angle Error | -2.12 | 0.12 |
| Driving Gear Convex Spiral Angle Error | -2.14 | 0.09 |
| Driven Gear Concave Spiral Angle Error | -5.33 | 0.53 |
| Driven Gear Convex Spiral Angle Error | -1.12 | 0.22 |
Furthermore, rolling tests were conducted on hyperboloid gears from the compensated batch to inspect the contact zone quality. Driving gears were paired with driven gears having post-heat treatment concave spiral angle errors of approximately -6, -5, and -4 arcminutes. The resulting contact zones were all located at the mid-to-minor end, aligning with the standard requirements. The table below presents the contact zone trends for these验证 tests.
| Test Group | Sample | Concave Spiral Angle Error (arcmin) | Contact Zone Position |
|---|---|---|---|
| 1 | 1 | -6.03 | Mid-to-minor end |
| 2 | -5.79 | ||
| 3 | -6.16 | ||
| 2 | 4 | -5.01 | Mid-to-minor end |
| 5 | -5.14 | ||
| 6 | -5.06 | ||
| 3 | 7 | -4.18 | Mid-to-minor end |
| 8 | -4.04 | ||
| 9 | -4.06 |
The application of cutting compensation for heat treatment distortion in hyperboloid gears proves to be a effective methodology. The mathematical framework using relative tooth surface errors provides a clear understanding of contact zone偏移 mechanisms. The experimental validation confirms that controlling relative spiral angle error is crucial for maintaining contact zone quality in hyperboloid gears after heat treatment. By integrating distortion规律 into the cutting process, manufacturers can achieve consistent post-heat treatment tooth surface errors and optimal contact zone positioning, ultimately enhancing the performance and reliability of hyperboloid gear transmissions in automotive applications.
In summary, this research on hyperboloid gears highlights the importance of proactive quality control. The distortion during heat treatment, particularly in spiral angle errors, significantly affects the contact zone. Through systematic analysis and compensation, it is possible to mitigate these effects. The first-order relative error model offers a practical tool for predicting and correcting shifts. Future work could explore advanced optimization algorithms for cutting parameters or investigate the effects of different heat treatment protocols on hyperboloid gears. Nonetheless, the presented method provides a robust solution for ensuring high-quality hyperboloid gears in mass production, contributing to better NVH performance and overall vehicle dynamics.