
We present a comprehensive theoretical analysis of a novel worm gears configuration termed the parallel inclined double roller enveloping hourglass worm gear drive. This design is derived from the single roller enveloping hourglass worm gear by introducing two parallel rollers per tooth on the worm gear, each inclined relative to the radial direction. Our work establishes a complete mathematical model based on spatial gear meshing theory. We derive the meshing equations, tooth surface equations, and evaluate key performance parameters including induced normal curvature, lubrication angle, self-rotation angle, and relative entrainment velocity. The results demonstrate excellent meshing performance, making this worm gears variant suitable for high-precision applications where backlash needs to be minimized or eliminated.
1. Introduction
Traditional worm gears suffer from inherent limitations including high sliding friction, significant backlash, and poor lubrication conditions. The sliding friction leads to severe wear, heat generation, and low efficiency, while backlash causes positioning errors in precision machinery. Researchers have proposed various solutions, such as substituting sliding friction with rolling friction using roller-based worm gears. Among these, the double roller enveloping hourglass worm gear drive has shown promise by replacing the worm gear teeth with cylindrical rollers that can rotate, thereby converting sliding motion into rolling motion. However, further improvements are needed to enhance the meshing performance, particularly the self-rotation capability and lubrication conditions of the rollers.
In this work, we introduce a novel configuration where each worm gear tooth consists of two parallel cylindrical rollers, both inclined by an angle γ with respect to the radial direction. This design reduces the roller radius while maintaining strength, increases the lubrication angle and self-rotation angle, and allows for adjustable backlash. We develop a rigorous theoretical framework based on spatial gear meshing theory and differential geometry. We then analyze the meshing characteristics and performance parameters numerically.
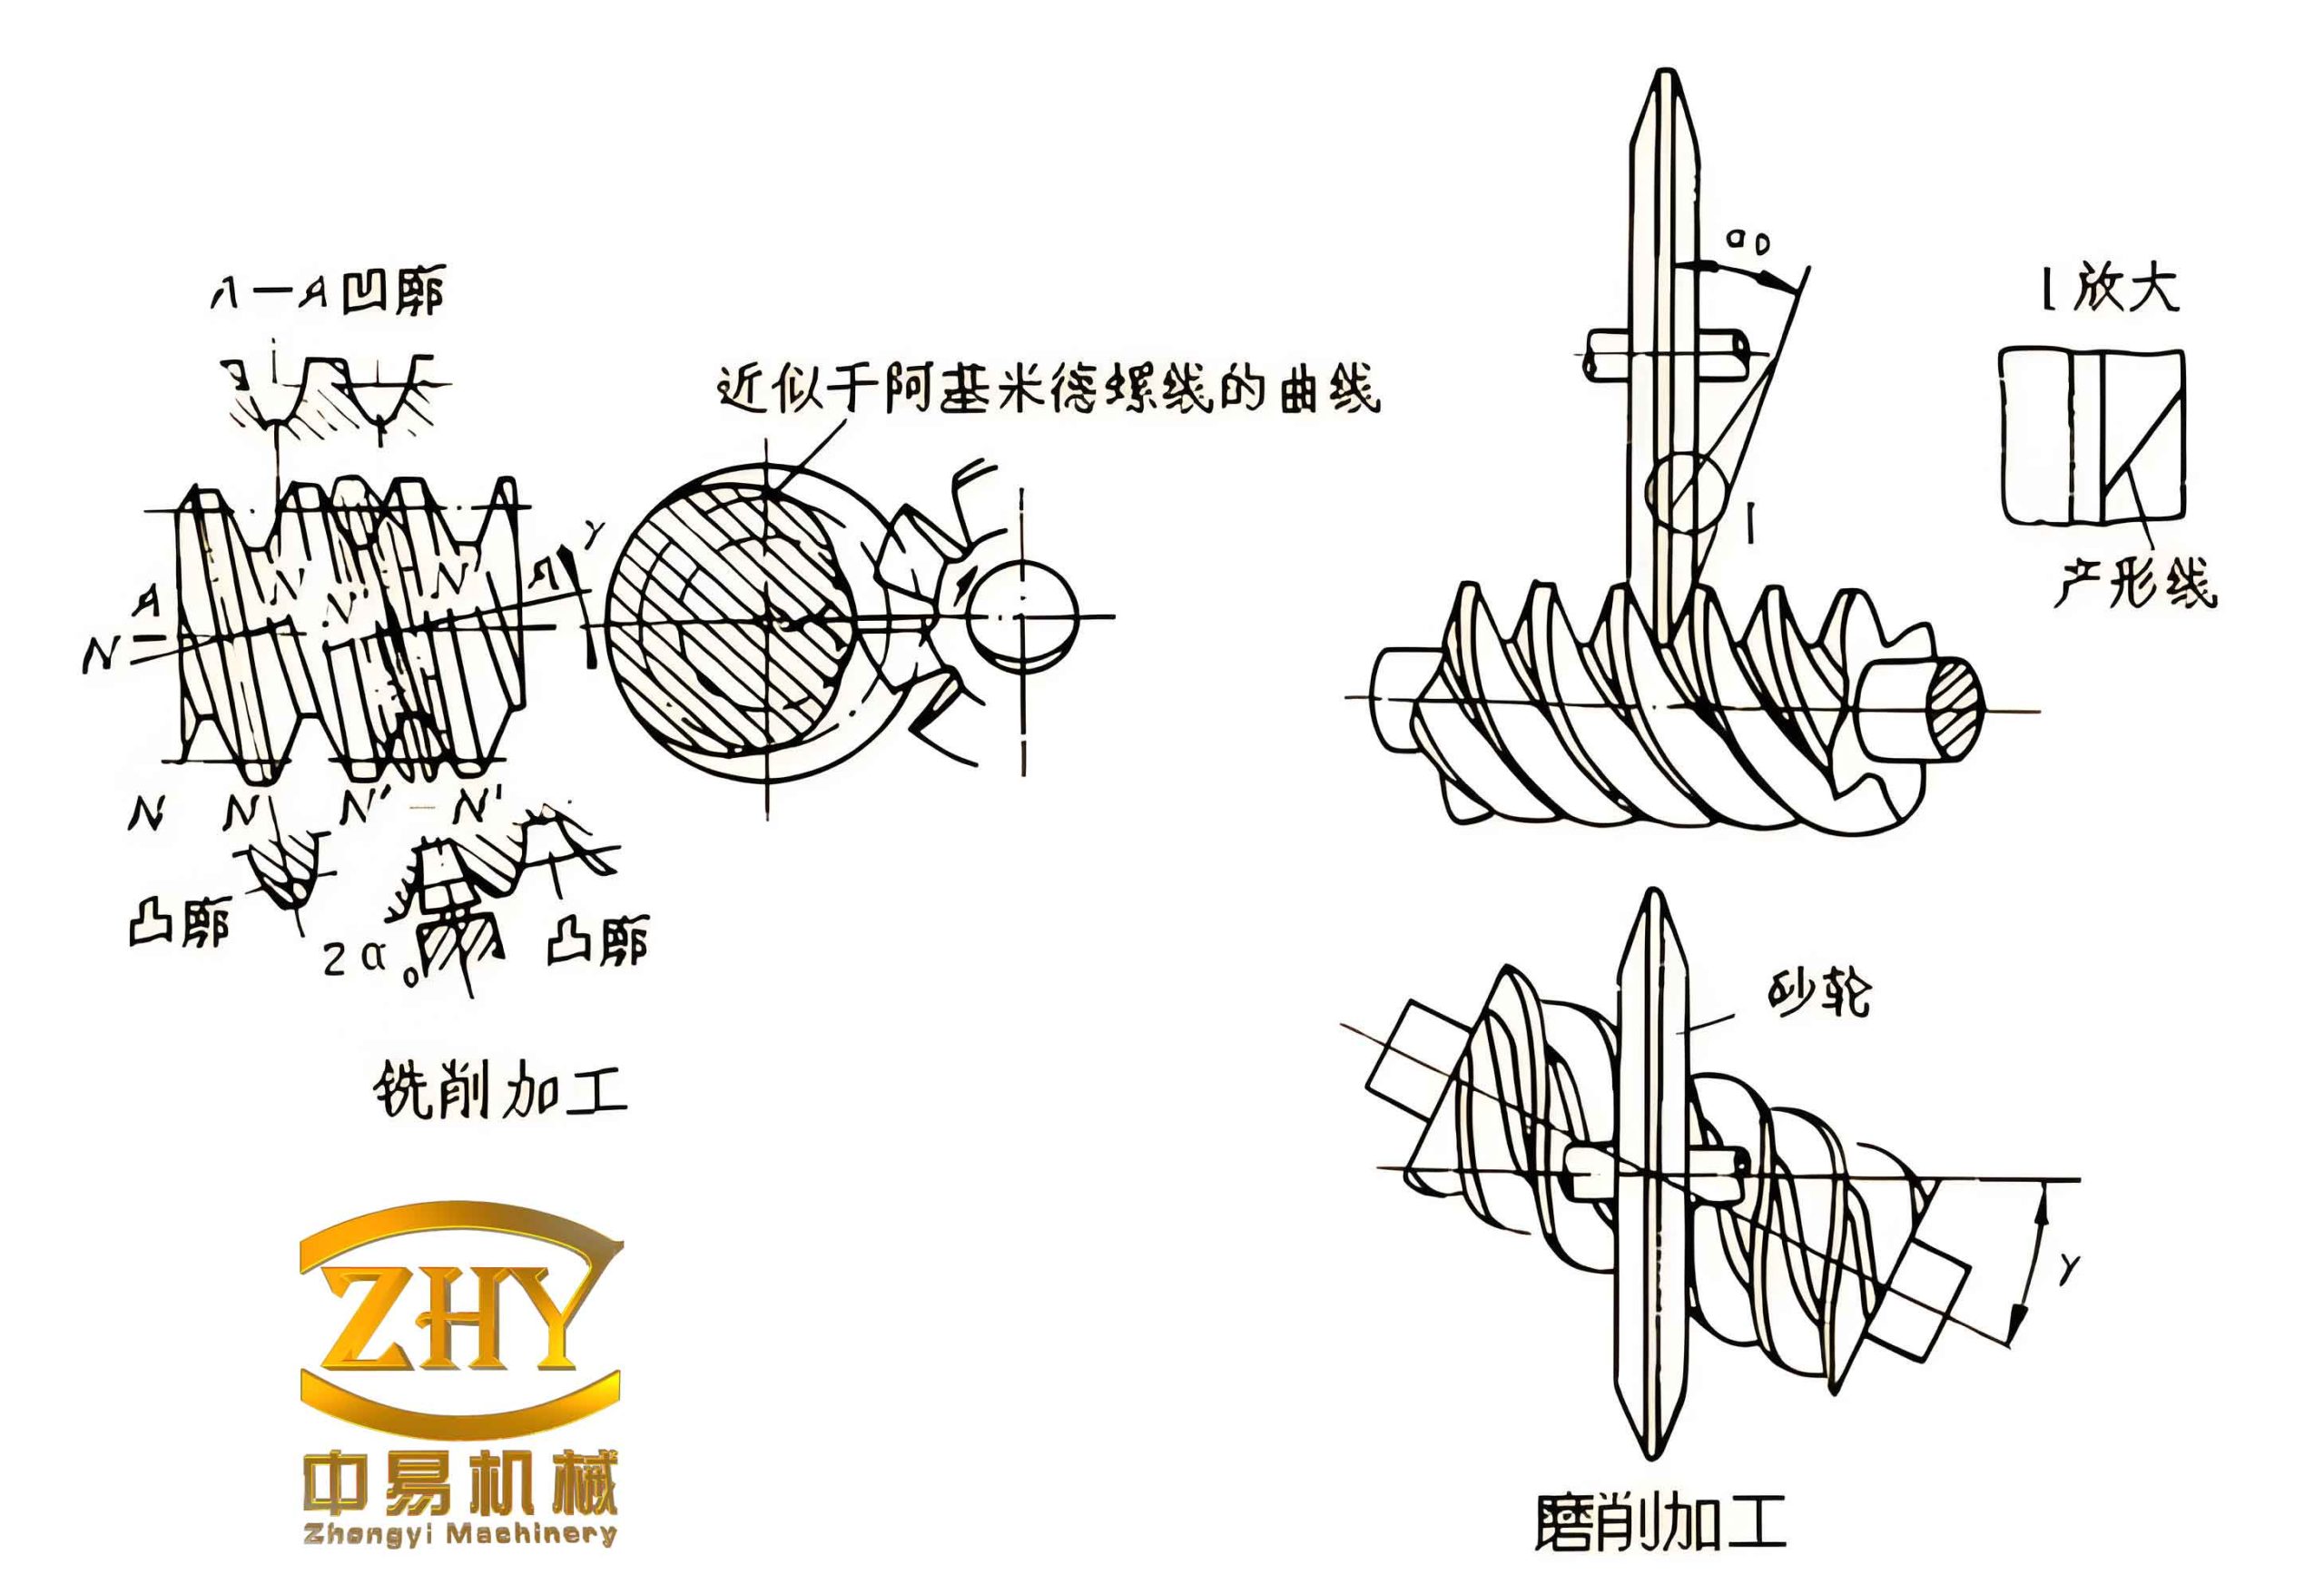
2. Basic Principle of the Novel Worm Gears
The parallel inclined double roller enveloping hourglass worm gear drive consists of an integral hourglass worm and a worm gear whose teeth are formed by two parallel rollers. Each roller is mounted such that its axis makes an angle γ with the radial line of the worm gear. The rollers are free to rotate about their own axes, replacing the sliding contact between worm and worm gear teeth with rolling contact. This significantly reduces friction and wear. The worm gear is split into two symmetric halves (left and right) corresponding to the two rollers of each tooth. During operation, the left roller meshes with the left flank of the worm thread, and the right roller meshes with the right flank, achieving simultaneous double-side contact that eliminates backlash. The inclination γ provides additional degrees of freedom that improve self-rotation and lubrication.
3. Mathematical Model
3.1 Coordinate Systems
We establish a set of coordinate systems as shown schematically (without figure reference). The fixed coordinate systems are S1′ (O1′; i1′, j1′, k1′) attached to the worm, and S2′ (O2′; i2′, j2′, k2′) attached to the worm gear. The moving coordinate systems S1 (O1; i1, j1, k1) and S2 (O2; i2, j2, k2) are rigidly connected to the worm and worm gear respectively. Additionally, we define moving frames S0r and S0l attached to the centers of the right and left rollers, with coordinates (a2r, b2r, c2r) and (a2l, b2l, c2l) in S2, where c2r = c2l = 0. The center distance between worm and worm gear is A. The rotational angles of worm and worm gear are φ1 and φ2 respectively, with transmission ratio i12 = ω1/ω2 = z2/z1. The inclination angle γ is defined as the angle between the roller axis and the radial line. Positive γ indicates leftward inclination.
On each roller surface, we set up an orthogonal moving frame (Frenet frame) at the contact point. For the right roller, the frame Spr (Opr; e1r, e2r, nr) is defined, and similarly Spl for the left roller. The position vectors of a point on the roller surface in the roller-attached coordinate systems are:
$$
\mathbf{r}_{0r} = x_{0r}\mathbf{i}_{0r} + y_{0r}\mathbf{j}_{0r} + z_{0r}\mathbf{k}_{0r}
$$
$$
x_{0r} = R \cos\theta_r,\quad y_{0r} = R \sin\theta_r,\quad z_{0r} = u_r
$$
$$
\mathbf{r}_{0l} = x_{0l}\mathbf{i}_{0l} + y_{0l}\mathbf{j}_{0l} + z_{0l}\mathbf{k}_{0l}
$$
$$
x_{0l} = R \cos\theta_l,\quad y_{0l} = R \sin\theta_l,\quad z_{0l} = u_l
$$
where R is the roller radius, and (ur, θr), (ul, θl) are surface parameters for the right and left rollers.
3.2 Transformation Matrices
The transformation from the worm moving coordinate system S1 to the fixed system S1′ is given by rotation about the z-axis by angle φ1:
$$
\mathbf{B}_{1′} = \mathbf{M}_{1’1}\mathbf{B}_{1},\quad
\mathbf{M}_{1’1} = \begin{bmatrix}
\cos\varphi_1 & -\sin\varphi_1 & 0 & 0\\
\sin\varphi_1 & \cos\varphi_1 & 0 & 0\\
0 & 0 & 1 & 0\\
0 & 0 & 0 & 1
\end{bmatrix}
$$
Similarly, for the worm gear:
$$
\mathbf{B}_{2′} = \mathbf{M}_{2’2}\mathbf{B}_{2},\quad
\mathbf{M}_{2’2} = \begin{bmatrix}
\cos\varphi_2 & -\sin\varphi_2 & 0 & 0\\
\sin\varphi_2 & \cos\varphi_2 & 0 & 0\\
0 & 0 & 1 & 0\\
0 & 0 & 0 & 1
\end{bmatrix}
$$
The transformation from S1 to S2 is obtained through the fixed systems:
$$
\mathbf{B}_2 = \mathbf{M}_{21}\mathbf{B}_1,\quad
\mathbf{M}_{21} = \begin{bmatrix}
a_{11} & a_{12} & a_{13} & a_{14}\\
a_{21} & a_{22} & a_{23} & a_{24}\\
a_{31} & a_{32} & 0 & 0\\
0 & 0 & 0 & 1
\end{bmatrix}
$$
where:
- a11 = -cos φ1 cos φ2, a21 = cos φ1 sin φ2, a31 = -sin φ1
- a12 = sin φ1 cos φ2, a22 = -sin φ1 sin φ2, a32 = -cos φ1
- a13 = -sin φ2, a23 = -cos φ2
- a14 = A cos φ2, a24 = -A sin φ2
The moving frames on the rollers are related to S2 via orientation matrices. For the left roller:
$$
\mathbf{S}_{pl} = \mathbf{A}_{pl2}\mathbf{S}_2,\quad
\mathbf{A}_{pl2} = \begin{bmatrix}
-\sin\gamma\cos\theta_l & \cos\gamma\cos\theta_l & -\sin\theta_l\\
-\sin\gamma & -\sin\gamma & 0\\
-\sin\gamma\sin\theta_l & \cos\gamma\sin\theta_l & \cos\theta_l
\end{bmatrix}
$$
For the right roller:
$$
\mathbf{S}_{pr} = \mathbf{A}_{pr2}\mathbf{S}_2,\quad
\mathbf{A}_{pr2} = \begin{bmatrix}
-\sin\gamma\cos\theta_r & \cos\gamma\cos\theta_r & -\sin\theta_r\\
-\sin\gamma & -\sin\gamma & 0\\
-\sin\gamma\sin\theta_r & \cos\gamma\sin\theta_r & \cos\theta_r
\end{bmatrix}
$$
3.3 Position Vectors and Velocity
The position vectors of the contact points in S2 are:
$$
\mathbf{r}_{2r} = x_{2r}\mathbf{i}_2 + y_{2r}\mathbf{j}_2 + z_{2r}\mathbf{k}_2
$$
$$
x_{2r} = a_{2r} – y_{0r}\sin\gamma – z_{0r}\cos\gamma
$$
$$
y_{2r} = b_{2r} + y_{0r}\cos\gamma – z_{0r}\sin\gamma
$$
$$
z_{2r} = x_{0r}
$$
and similarly for the left side with subscript l. The center distance vector in S2 is ξ = A cos φ2 i2 – A sin φ2 j2.
Setting ω1 = 1, the angular velocities are:
$$
\boldsymbol{\omega}_1 = -\sin\varphi_2\,\mathbf{i}_2 – \cos\varphi_2\,\mathbf{j}_2
$$
$$
\boldsymbol{\omega}_2 = i_{21}\,\mathbf{k}_2,\quad \text{where } i_{21} = \frac{\omega_2}{\omega_1}
$$
The relative angular velocity is:
$$
\boldsymbol{\omega}_{12} = -\sin\varphi_2\,\mathbf{i}_2 – \cos\varphi_2\,\mathbf{j}_2 – i_{21}\,\mathbf{k}_2
$$
The relative sliding velocities at the contact points are obtained from:
$$
\mathbf{v}_{12r} = \boldsymbol{\omega}_{12} \times \mathbf{r}_{1r} – \boldsymbol{\omega}_2 \times \boldsymbol{\xi}
$$
$$
\mathbf{v}_{12l} = \boldsymbol{\omega}_{12} \times \mathbf{r}_{1l} – \boldsymbol{\omega}_2 \times \boldsymbol{\xi}
$$
where r1r = r2r – ξ and r1l = r2l – ξ (in S2). After algebraic manipulation, the components in S2 become:
$$
\mathbf{v}_{12r} = B_{1r}\mathbf{i}_2 + B_{2r}\mathbf{j}_2 + B_{3r}\mathbf{k}_2
$$
$$
B_{1r} = y_{2r} i_{21} – z_{2r}\cos\varphi_2
$$
$$
B_{2r} = -x_{2r} i_{21} + z_{2r}\sin\varphi_2
$$
$$
B_{3r} = x_{2r}\cos\varphi_2 – y_{2r}\sin\varphi_2 – A
$$
and analogous expressions for the left side with subscript l. Transforming these velocities into the moving frames on the rollers yields the components:
$$
v_{12r1} = -B_{3r}\sin\theta_r + B_{2r}\cos\gamma\cos\theta_r – B_{1r}\sin\gamma\cos\theta_r
$$
$$
v_{12r2} = -B_{1r}\cos\gamma – B_{2r}\sin\gamma
$$
$$
v_{12r n} = B_{2r}\cos\gamma\sin\theta_r + B_{3r}\cos\theta_r – B_{1r}\sin\gamma\sin\theta_r
$$
Similarly for the left side with corresponding parameters.
4. Meshing Equations and Tooth Surfaces
4.1 Meshing Function
The condition for continuous meshing is that the relative velocity is orthogonal to the common normal, i.e., v12·n = 0. For the right roller, this gives:
$$
\Phi_r = v_{12rn} = M_{1r}\cos\varphi_2 + M_{2r}\sin\varphi_2 + M_{3r} = 0
$$
$$
M_{1r} = a_{2r}\cos\theta_r – u_r\cos\gamma\cos\theta_r
$$
$$
M_{2r} = u_r\sin\gamma\cos\theta_r – b_{2r}\cos\theta_r
$$
$$
M_{3r} = i_{21}u_r\sin\theta_r – A\cos\theta_r – b_{2r}i_{21}\sin\gamma\sin\theta_r – a_{2r}i_{21}\cos\gamma\sin\theta_r
$$
For the left roller, the meshing function Φl is obtained by replacing subscript r with l.
4.2 Contact Lines
For a fixed worm gear rotation angle φ2, the contact lines on the roller surfaces are given by the simultaneous solution of the roller surface equations and the meshing equation. Solving for ur yields:
$$
u_r = \frac{P_{3r}}{P_{4r}}
$$
$$
P_{3r} = b_{2r}\sin\varphi_2\cos\theta_r + b_{2r}i_{21}\sin\gamma\sin\theta_r + a_{2r}i_{21}\cos\gamma\sin\theta_r + A\cos\theta_r – a_{2r}\cos\varphi_2\cos\theta_r
$$
$$
P_{4r} = \sin\gamma\sin\varphi_2\cos\theta_r + i_{21}\sin\theta_r – \cos\gamma\cos\varphi_2\cos\theta_r
$$
Analogous expressions hold for the left roller with subscript l. The angular parameter θr ranges from -π to 0 for the right flank engagement, and θl ranges from 0 to π for the left flank engagement.
4.3 Tooth Surface of the Worm
The worm tooth surface is the envelope of the family of roller surfaces as the worm gear rotates. The coordinates in the worm moving system S1 are obtained via the transformation M21. The worm surface equations for the right flank are:
$$
\mathbf{r}_{1r} = x_{1r}\mathbf{i}_1 + y_{1r}\mathbf{j}_1 + z_{1r}\mathbf{k}_1
$$
$$
x_{1r} = y_{2r}\cos\varphi_1\sin\varphi_2 – x_{2r}\cos\varphi_1\cos\varphi_2 – z_{2r}\sin\varphi_1 + A\cos\varphi_1
$$
$$
y_{1r} = x_{2r}\sin\varphi_1\cos\varphi_2 – y_{2r}\sin\varphi_1\sin\varphi_2 – z_{2r}\cos\varphi_1 – A\sin\varphi_1
$$
$$
z_{1r} = -x_{2r}\sin\varphi_2 – y_{2r}\cos\varphi_2
$$
with ur determined by the meshing condition, and φ2 varying over the meshing cycle (e.g., φ2 ∈ [-π/5, π/5]). Similar equations define the left flank.
5. Meshing Performance Parameters
5.1 Induced Normal Curvature
The induced normal curvature along the contact line normal direction is a key indicator of conformity between the mating surfaces. Using the moving frame method, we derive:
$$
k_{12\sigma r} = -\frac{(v_{12r1}/R – \omega_{122r})^2 + (\omega_{121r})^2}{\Psi_r}
$$
$$
k_{12\sigma l} = -\frac{(v_{12l1}/R – \omega_{122l})^2 + (\omega_{121l})^2}{\Psi_l}
$$
where Ψr and Ψl are the first-order limit functions of the meshing equation, and ω121, ω122 are components of the relative angular velocity in the moving frame. The components ω121r and ω122r are given by:
$$
\omega_{121r} = i_{21}\sin\theta_r – \cos\gamma\cos\varphi_2\cos\theta_r + \sin\gamma\cos\theta_r\sin\varphi_2
$$
$$
\omega_{122r} = \sin\gamma\cos\varphi_2 + \cos\gamma\sin\varphi_2
$$
with similar expressions for the left side. Numerical evaluation shows that the induced normal curvature remains small and varies smoothly across the meshing cycle, indicating excellent surface conformity.
5.2 Lubrication Angle
The lubrication angle μ is defined as the angle between the instantaneous contact line and the relative velocity vector. It directly quantifies the lubricant entrapment capability. For the right roller:
$$
\mu_r = \arcsin\left(\frac{|v_{12r1}(v_{12r1}/R – \omega_{122r}) + v_{12r2}\omega_{121r}|}{\sqrt{(v_{12r1}/R – \omega_{122r})^2 + \omega_{121r}^2}\sqrt{v_{12r1}^2 + v_{12r2}^2}}\right)
$$
and similarly for the left roller with subscript l. The computed lubrication angles for both flanks are listed in Table 1.
| Flank | Min μ (°) | Max μ (°) |
|---|---|---|
| Left | 88.4 | 89.6 |
| Right | 87.6 | 89.0 |
The lubrication angle remains above 87.6° for both flanks, indicating excellent lubricating conditions. The left flank exhibits slightly higher values than the right flank.
5.3 Self-Rotation Angle
The self-rotation angle μz measures the inclination of the relative velocity vector with respect to the roller axis. A value close to 90° ensures that the roller rotates freely. It is computed as:
$$
\mu_{z0r} = \arccos\left(\frac{|\mathbf{k}_{0r} \cdot \mathbf{v}_{12r}|}{|\mathbf{v}_{12r}|}\right)
$$
where k0r is the unit vector along the roller axis. Table 2 summarizes the results.
| Flank | Min μz (°) | Max μz (°) |
|---|---|---|
| Left | 89.1 | 90.0 |
| Right | 88.5 | 89.45 |
Both flanks exhibit self-rotation angles above 88.5°, confirming excellent rotational capability of the rollers. The minimum occurs near the worm throat.
5.4 Relative Entrainment Velocity
The relative entrainment velocity vjx is half the sum of the surface velocities projected along the contact line normal direction. It influences the formation of a hydrodynamic oil film. The expressions are:
$$
v_{jxr} = \frac{v_{1\sigma r} + v_{2\sigma r}}{2}
$$
$$
v_{1\sigma r} = \frac{v_{1r1}(v_{12r1}/R – \omega_{122r}) + v_{1r2}\omega_{121r}}{T_r}
$$
$$
v_{2\sigma r} = \frac{v_{2r1}(v_{12r1}/R – \omega_{122r}) + v_{2r2}\omega_{121r}}{T_r}
$$
$$
T_r = \sqrt{(v_{12r1}/R – \omega_{122r})^2 + (\omega_{121r})^2}
$$
where v1r1, v1r2 are the velocity components of the worm surface, and v2r1, v2r2 are those of the roller surface in the moving frame. The variation of relative entrainment velocity with φ2 follows a concave-upward trend, with minimum values occurring near the throat. The left flank yields slightly higher minima than the right flank.
6. Summary of Performance
We consolidate the key performance parameters in Table 3 for comparison.
| Parameter | Left Flank | Right Flank |
|---|---|---|
| Induced normal curvature k12σ | Small (varies smoothly) | Even smaller than left |
| Lubrication angle μ (°) | 88.4 – 89.6 | 87.6 – 89.0 |
| Self-rotation angle μz (°) | 89.1 – 90.0 | 88.5 – 89.45 |
| Relative entrainment velocity vjx | Higher minimum | Lower minimum |
The analysis demonstrates that the proposed worm gears design achieves superior lubrication and self-rotation performance, with induced normal curvatures indicating good surface conformity. The left and right flanks exhibit slightly different characteristics, but both remain within excellent ranges. This new configuration thus offers a promising solution for high-precision worm gears applications requiring low friction, minimal backlash, and good load capacity.
7. Conclusion
We have presented a comprehensive theoretical analysis of a novel worm gears type: the parallel inclined double roller enveloping hourglass worm gear drive. The main contributions of this work are summarized as follows:
- We developed a complete mathematical model including coordinate systems, transformation matrices, and kinematic relations for the dual-roller configuration.
- We derived the meshing equations, contact line equations, and tooth surface equations for both flanks of the worm.
- We formulated and numerically evaluated the key performance parameters: induced normal curvature, lubrication angle, self-rotation angle, and relative entrainment velocity.
- The results confirm that the novel worm gears exhibit excellent meshing performance, with lubrication angles exceeding 87.6° and self-rotation angles above 88.5°, along with favorable conformity and oil film formation conditions.
This theoretical foundation provides a basis for further design optimization, manufacturing, and experimental validation of the parallel inclined double roller enveloping hourglass worm gear drive. The proposed architecture represents a significant step forward in the development of high-efficiency, backlash-free worm gears for precision machinery.