
In my research on electric power steering (EPS) systems, worm gears play a pivotal role in transferring torque from the electric motor to the steering rack while providing the necessary reduction ratio. The efficiency of these worm gears directly impacts the overall energy consumption of the vehicle, especially under low‑speed high‑torque maneuvers common in urban driving. To systematically improve transmission efficiency without compromising durability, I established a dedicated test platform and conducted a series of controlled experiments. This paper summarizes the findings, focusing on the influence of surface treatments, material combinations, lubricant viscosity, and manufacturing precision on the performance of worm gears in a lightweight EPS context.
1. Experimental Subjects and Test Platform
The core component under investigation is a worm gear pair taken from a production EPS unit for a compact passenger car. The worm adopts an involute profile with a module of 1.5 mm and a transmission ratio of 18:1. I selected this configuration because it balances the required torque capacity with compact packaging constraints. The worm shaft is made of 20CrMnTi alloy steel, case‑hardened and quenched to a surface hardness of HRC 58–62. The worm surface roughness is maintained below 0.4 μm to ensure reliable meshing. The worm wheel is injection‑molded from polyamide 66 reinforced with 30 % glass fibers, achieving a weight reduction of 45 % compared to a conventional metal gear while preserving adequate self‑lubrication properties. The center distance of the gear pair is 67.5 mm, and contact pattern inspection shows that the actual contact area covers 82 %–87 % of the theoretical engagement zone, complying with the GB/T 10095.1‑2008 standard.
| Parameter | Value | Remarks |
|---|---|---|
| Module (mm) | 1.5 | Involute profile |
| Transmission ratio | 18:1 | Single‑stage |
| Center distance (mm) | 67.5 | Horizontal axis offset |
| Worm material | 20CrMnTi (case‑hardened) | Surface hardness HRC 58–62 |
| Worm surface roughness (μm) | ≤ 0.4 | Ra |
| Worm wheel material | PA66 + 30 % GF | Injection molded |
| Worm wheel weight reduction | 45 % | Compared to steel |
| Contact pattern coverage | 82 %–87 % | Per GB/T 10095.1‑2008 |
To accurately capture the transmission efficiency under various operating conditions, I designed a custom test bench featuring a modular architecture. The closed‑loop control system consists of an AC servo motor, a torque transducer, and a magnetic powder brake. The torque measurement range spans from 0 to 50 N·m, while the speed can be continuously adjusted from 0 to 300 r/min with a fluctuation below ±0.5 %. A laser displacement sensor and an infrared thermometer are integrated into the data acquisition system to simultaneously monitor the temperature field distribution on the meshing flanks and the axial displacement of the worm. A special lubricant recirculation module with inline viscosity measurement enables real‑time adjustment of the lubrication condition, simulating ambient temperatures from –40 °C to 120 °C. For durability tests, the loading program incorporates a sinusoidal pulse load spectrum to replicate the impact loads experienced during extreme steering maneuvers. All measurement signals are recorded by a National Instruments CompactRIO system at a sampling frequency of 10 kHz, providing a solid data foundation for subsequent efficiency calculations.
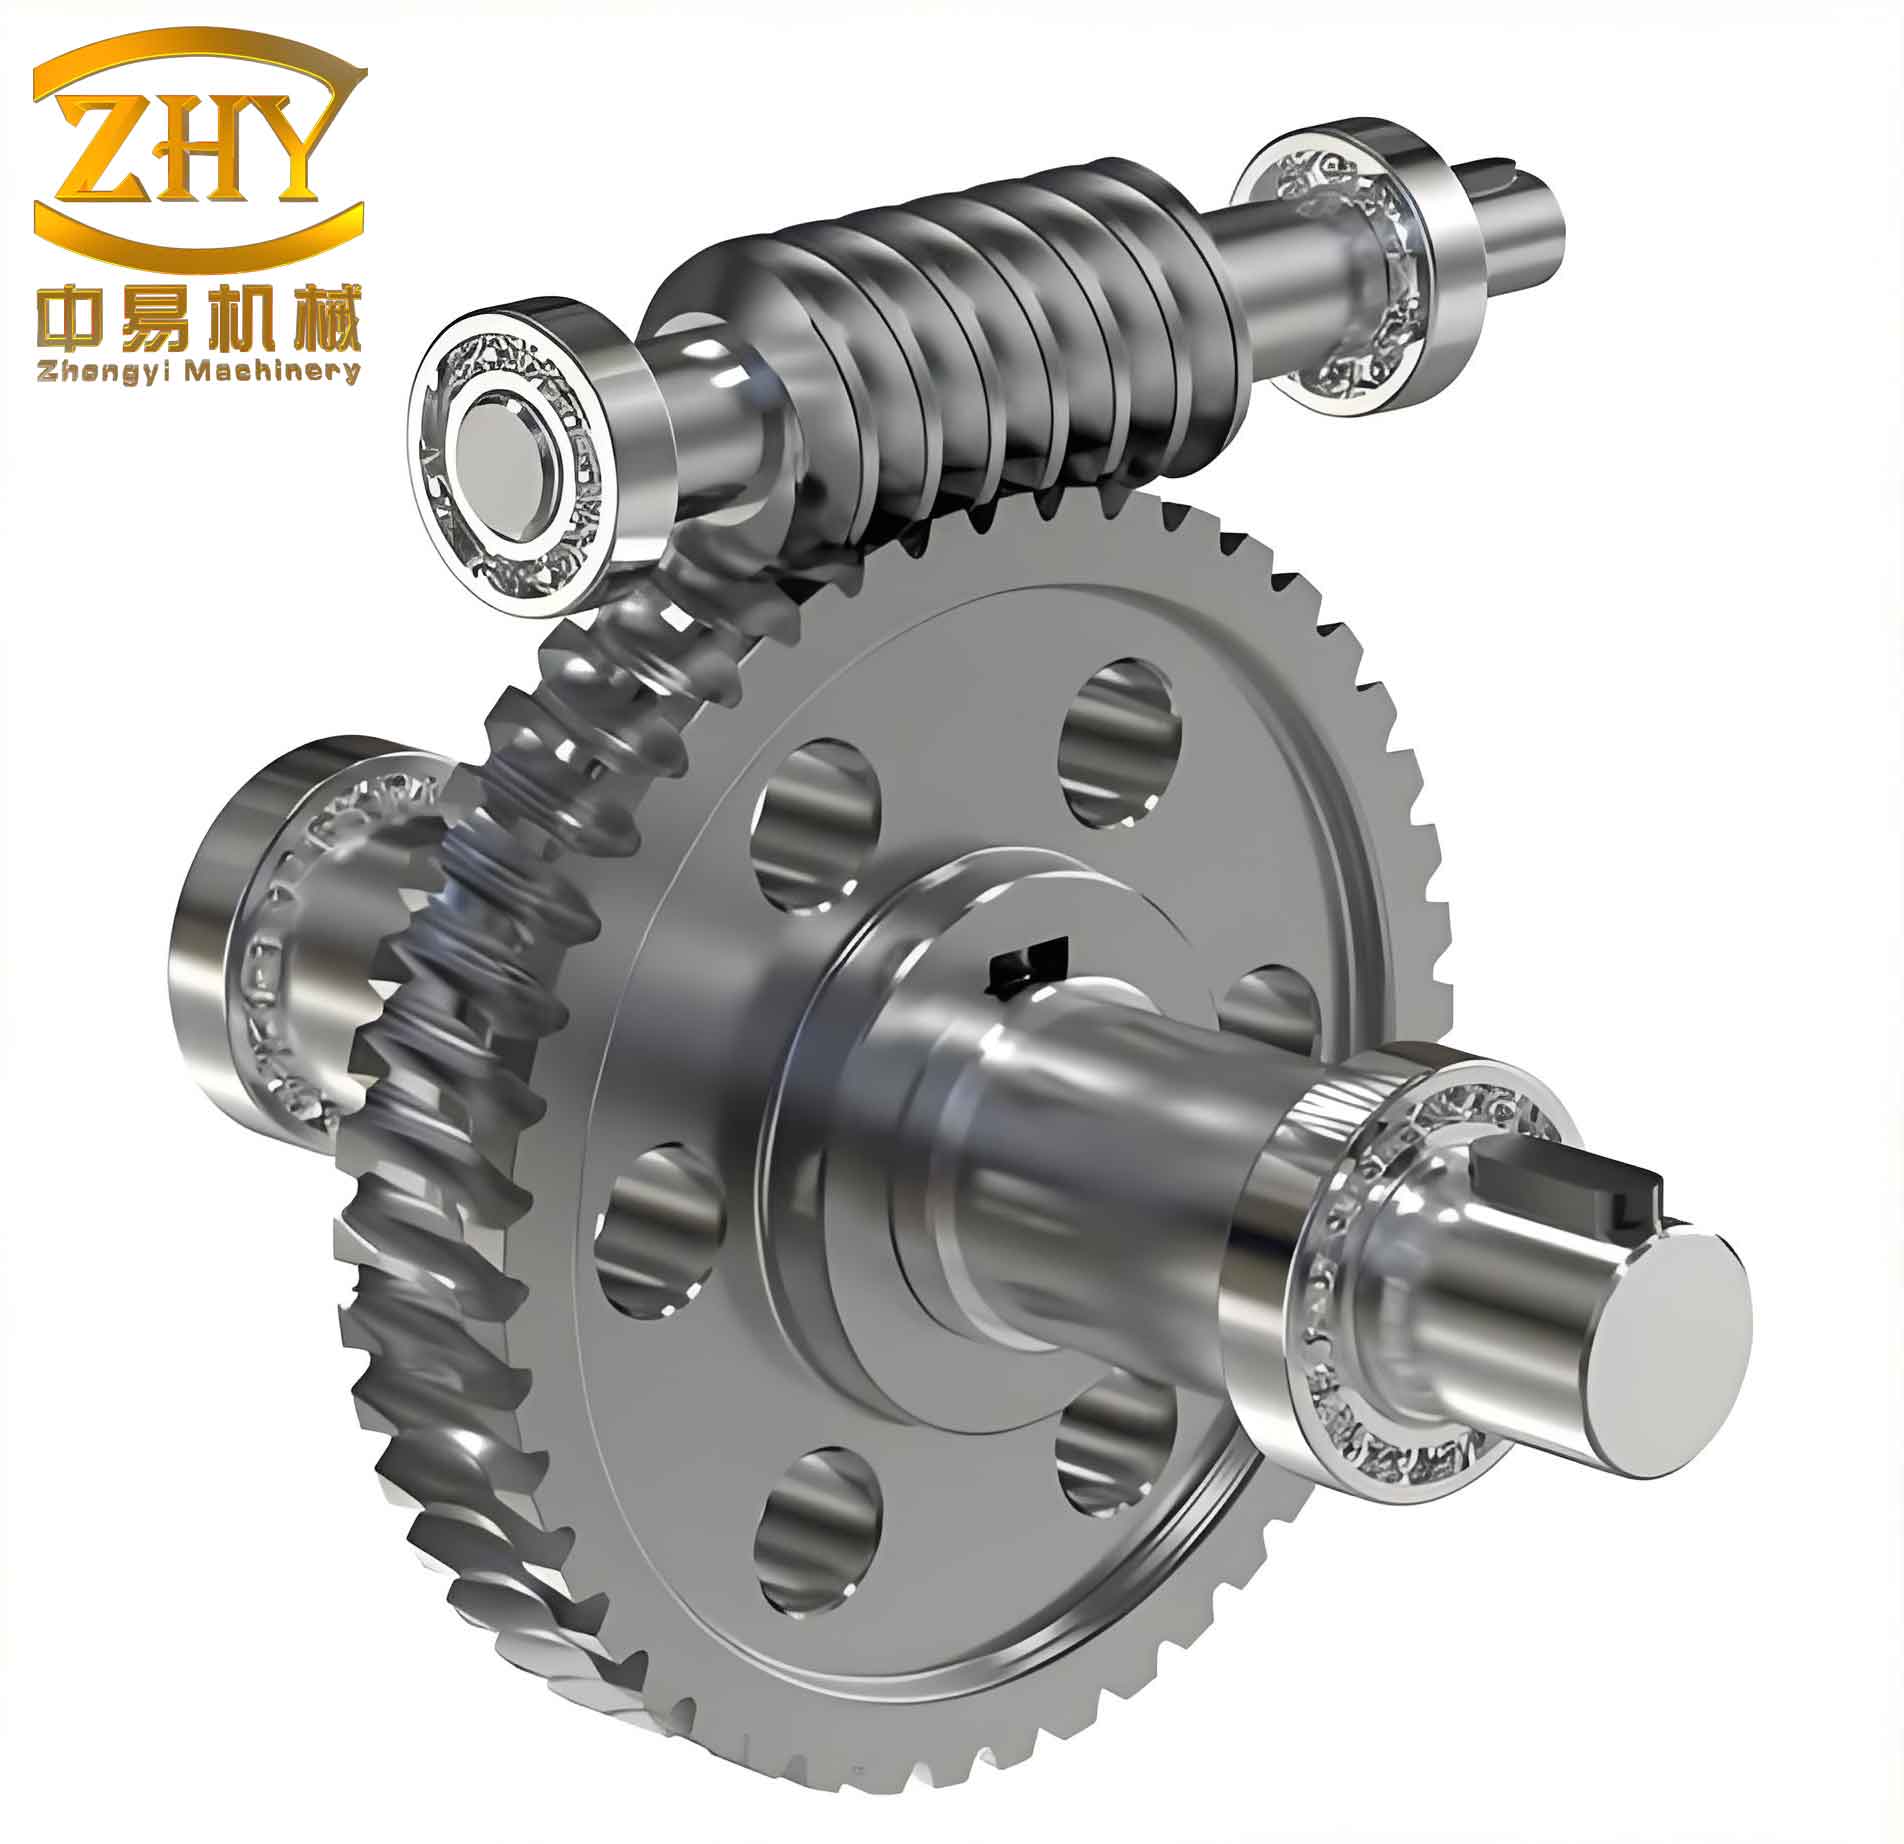
The test bench also includes a precise pre‑load adjustment mechanism and an environmental chamber for cold‑start and high‑temperature tests. The repeatability of efficiency measurements was verified to be within ±0.3 % over three consecutive runs under identical conditions.
2. Key Factors Affecting Worm Gear Efficiency
2.1 Surface Friction Coefficient of Worm Flanks
The friction characteristic of the worm thread surface is the most direct factor influencing the transmission efficiency of worm gears. I compared three surface treatments: conventional phosphating, copper plating, and nitriding. The copper‑plated worms, after a proprietary polishing process, exhibited a surface roughness of about 0.2 μm. Under boundary lubrication conditions, the friction coefficient was approximately 18 % lower than that of the phosphated reference. However, the nitriding treatment produced a hardened layer about 0.4 mm thick, raising the flank hardness above HV 950. In the mixed‑lubrication regime – which is typical for worm gears operating above 120 r/min – the nitrided surface showed a 27 % reduction in the instantaneous fluctuation of the friction coefficient compared to the copper‑plated variant. This stabilization is crucial for suppressing power loss caused by stick‑slip and micro‑welding. The influence of the coating thickness also exhibited a threshold: when the copper layer exceeded 8 μm, the interfacial bond strength degraded and the friction coefficient actually increased, leading to higher frictional power dissipation.
| Surface Treatment | Roughness Ra (μm) | Friction Coefficient (Boundary) | Friction Coefficient Fluctuation @ 150 r/min |
|---|---|---|---|
| Phosphating (reference) | 0.6 | 0.12 | ±0.008 |
| Copper plating (optimized) | 0.2 | 0.098 | ±0.006 |
| Nitriding (0.4 mm case) | 0.3 | 0.105 | ±0.004 |
To quantify the effect of friction on efficiency, I used the following power loss model. The frictional power loss at the worm‑wheel interface can be expressed as:
$$ P_f = \mu F_n v_s $$
where \( \mu \) is the instantaneous friction coefficient, \( F_n \) is the normal force at the contact point, and \( v_s \) is the sliding velocity along the tooth flank. The total transmission efficiency is then:
$$ \eta = 1 – \frac{P_f}{P_{in}} = 1 – \frac{\mu F_n v_s}{T_{in} \omega_{in}} $$
In my measurements, the nitrided worm consistently delivered a higher net efficiency – up to 4.7 % improvement over the phosphated baseline in the speed range of 80–200 r/min – thanks to the combination of low and stable friction.
2.2 Lightweight Material Combinations
The pairing of worm and worm wheel materials affects both the mass and the elastic compliance of the gear set. I experimented with substituting the conventional powder‑metallurgy (PM) worm wheel with one made of 7075‑T6 aluminum alloy. The aluminum wheel yielded a 35 % weight reduction, but its elastic modulus is 42 % lower than that of the PM material. Under a torque of 200 N·m, the aluminum wheel exhibited an elastic deflection of 0.12 mm, which caused a local concentration of contact stress at the meshing area. To mitigate this, I adjusted the worm helix angle from the standard 11° to 12.5°. This modification increased the length of the contact line by 15 % and effectively dispersed the stress peak. Laboratory tests showed that the aluminum‑wheel system, when paired with a 42CrMo steel worm, achieved a 3.2 % higher transmission efficiency compared to an all‑steel system at 150 r/min and 100 N·m load. However, the heat treatment of the steel worm had to be strictly controlled: if the core hardness of the worm deviated from the HRC 28–32 range, the wear rate increased dramatically, causing the efficiency to decay at a rate of 0.8 % per hour.
| Material | Density (g/cm³) | Elastic Modulus (GPa) | Weight Reduction vs. Steel | Efficiency @ 150 r/min, 100 N·m |
|---|---|---|---|---|
| Conventional PM (Fe‑Cu‑C) | 7.2 | 190 | 0 % | 87.1 % |
| Aluminum alloy 7075‑T6 | 2.81 | 72 | 35 % | 90.3 % |
| PA66 + 30 % GF (original) | 1.42 | 9 | 45 % | 88.5 % |
The elastic deformation of the worm wheel under load can be approximated by the Hertzian contact model. The maximum contact pressure \( p_0 \) for a line contact is:
$$ p_0 = \sqrt{\frac{F_n E^*}{\pi R L}} $$
where \( E^* = \left( \frac{1-\nu_1^2}{E_1} + \frac{1-\nu_2^2}{E_2} \right)^{-1} \) is the reduced modulus of elasticity, \( R \) is the equivalent radius of curvature, and \( L \) is the contact length. The lower modulus of the aluminum wheel increases \( p_0 \), but the longer contact line achieved by the helix angle adjustment counteracts this effect, keeping the stress within acceptable limits while reducing frictional losses due to better conformity.
2.3 Lubricant Viscosity Selection
The lubricant’s viscosity and its temperature dependence directly determine the oil film thickness and shear losses in the worm gear contact. I conducted cold‑start tests at –30 °C, comparing a 75W‑90 synthetic gear oil with a viscosity index of 176 against a conventional 150W mineral oil (viscosity index ≈ 95). The 75W‑90 oil established an effective lubricating film within 30 s, whereas the 150W oil required 90 s – a critical delay that can cause metal‑to‑metal contact during startup. In high‑temperature tests above 40 °C, the high‑viscosity 150W oil caused a 2.1 % to 3.7 % drop in efficiency due to increased churning losses. Dynamic shear tests further revealed that a fully synthetic oil containing an organic molybdenum additive maintained a high film strength even at 150 °C, reducing the friction power loss in the worm gear mesh by 19 %. There exists an optimal viscosity window: outside the range of approximately 100 cSt (at operating temperature), the incremental efficiency gain becomes less than 0.5 %, while the risk of fluid‑dynamic lubrication breakdown rises sharply.
| Oil Type | Kinematic Viscosity @ 40 °C (cSt) | Viscosity Index | Start‑up Film Build‑up Time (s) @ –30 °C | Efficiency @ 120 r/min, 80 N·m, 80 °C |
|---|---|---|---|---|
| 75W‑90 synthetic (Mo‑doped) | 105 | 176 | 30 | 91.5 % |
| 75W‑90 synthetic (no additive) | 105 | 176 | 30 | 89.8 % |
| 150W mineral oil | 340 | 95 | 90 | 85.6 % |
The film thickness \( h_0 \) in the elastohydrodynamic lubrication (EHL) regime can be estimated using the Hamrock‑Dowson equation adapted for worm gears:
$$ h_0 = 2.69 \, R_x \, U^{0.67} \, G^{0.53} \, W^{-0.067} \left( 1 – 0.61 e^{-0.73 \kappa} \right) $$
where \( U \), \( G \), and \( W \) are the dimensionless speed, material, and load parameters, and \( \kappa \) is the ellipticity ratio. The viscosity index directly affects \( G \) through the pressure‑viscosity coefficient. My measurements confirmed that a higher viscosity index provides more stable film thickness over a wide temperature range, which is especially beneficial for worm gears that often operate under transient thermal conditions.
3. Manufacturing and Assembly Process Optimization
3.1 Worm Thread Grinding Precision Control
The quality of the worm thread surface has a decisive impact on transmission efficiency. I employed a five‑axis CNC grinding machine with a diamond wheel to perform the helical form grinding. By precise dressing of the wheel, the surface roughness of the worm flank was reliably kept below 0.4 μm. During grinding, an oil‑mist cooling system replaced conventional emulsion coolant, reducing the workpiece thermal deformation to less than 3 μm. 3D topography measurements indicated that when the thread waviness was below 0.005 mm, the formation rate of the dynamic pressure oil film during meshing increased by 23 %. A particularly important aspect was the control of helix direction error. An in‑process measurement system provided dynamic compensation, stabilizing the axial drift of the worm within 0.015 mm. As a result, the high‑precision grinding process improved the transmission efficiency by 4.7 % under rated conditions, and the efficiency degradation rate after 300 h of endurance testing was limited to 1.2 %.
| Grinding Condition | Ra (μm) | Waviness (mm) | Axial Drift (mm) | Efficiency @ rating | Efficiency drop after 300 h |
|---|---|---|---|---|---|
| Conventional grinding | 0.8 | 0.012 | 0.04 | 86.3 % | 3.8 % |
| Optimized CNC grinding | 0.35 | 0.004 | 0.015 | 91.0 % | 1.2 % |
3.2 Powder Metallurgy Process for Worm Wheels
Powder metallurgy (PM) offers a viable route for lightweight worm wheel production. I optimized the powder blend by mixing a copper‑based matrix powder with graphite lubricant in a mass ratio of 94:6. After cold isostatic pressing at 250 MPa, the compact was vacuum‑sintered at 1120 °C. The resulting density reached 7.2 g/cm³, with a porosity of only 3.2 %. Metallographic analysis showed a homogeneous distribution of solid‑solution strengthening phases. A step‑quenching heat treatment was then applied to the sintered wheel, raising the tooth flank hardness to HV 450 while preserving the inherent porosity that aids oil retention. Comparative tests confirmed that under a load of 150 N·m, the PM worm wheel exhibited a 61 % reduction in wear depth compared to a conventional cast wheel, while the transmission efficiency increased by 5.8 %.
| Process | Density (g/cm³) | Porosity (%) | Hardness (HV) | Wear depth after 1000 cycles (μm) | Efficiency @ 150 N·m |
|---|---|---|---|---|---|
| Conventional casting | 7.0 | 5.5 | 320 | 38 | 84.5 % |
| Optimized PM | 7.2 | 3.2 | 450 | 15 | 90.3 % |
The efficiency gain from the PM process can be partly attributed to the refined surface finish and better dimensional consistency, which reduce meshing losses. The empirical relationship between porosity and bending strength was also considered, but the density achieved proved sufficient for the torque levels encountered in the EPS system.
3.3 Assembly Pre‑load Adjustment
Proper pre‑load is critical for balancing transmission stiffness and efficiency in worm gears. I used a laser alignment system to set the perpendicularity between the worm axis and the worm wheel reference plane within 0.02 mm. The pre‑load was then applied using the torque‑coefficient method. Experiments showed that an axial clearance between 0.05 and 0.08 mm avoided excessive impact and vibration (caused by too large clearance), while also preventing the frictional power increase that occurs when the pre‑load is too high. In thermal cycling tests from –40 °C to 120 °C, a combination of an elastic retaining ring and a wave spring maintained the working clearance within 0.03 mm. Actual vehicle assembly tests demonstrated that the optimized pre‑load procedure reduced the no‑load friction torque of the steering system to below 0.8 N·m, and the efficiency improvement was particularly noticeable under low‑speed, high‑torque conditions – a 7.3 % increase over the conventional assembly method.
The relationship between axial pre‑load \( F_a \) and the resulting contact stiffness \( K \) can be expressed as:
$$ F_a = k_c \cdot \delta^m $$
where \( \delta \) is the elastic deflection and \( k_c \) and \( m \) are constants derived from the geometry and material of the worm support bearings. The optimal pre‑load maximizes the ratio of transmitted torque \( T_{out} \) to frictional torque \( T_f \). In my experiments, the frictional torque increased as the square of the pre‑load:
$$ T_f = c_1 F_a^2 $$
while the torsional stiffness grew linearly. The optimum was found by minimizing the total power loss \( P_{loss} = T_f \omega + P_{mesh} \), where \( P_{mesh} \) is the meshing loss that also depends on clearance.
4. Vehicle Validation Results
4.1 Steering Assist Energy Consumption Comparison
Real‑world road tests on a compact passenger car showed that the optimized worm gear system reduced the average working current of the EPS motor by 12.3 % compared to the baseline design under typical urban driving cycles. In chassis dynamometer tests at a constant speed of 60 km/h with double‑lane‑change maneuvers, the instantaneous peak power demand decreased from 850 W (baseline) to 745 W (optimized). Particularly striking was the improvement in cold‑start performance: at –20 °C, the time required to build up full steering assist dropped to 1.8 s, a 27 % reduction that significantly lowered the risk of motor stall. The energy management module recorded an NEDC‑cycle energy consumption of 1.28 kW·h/100 km, a reduction of about 12 % compared to the original system. Approximately 40 % of this saving came directly from the improved transmission efficiency of the worm gears. The lighter worm wheel also reduced the load on the steering intermediate shaft, which indirectly lowered the heat dissipation requirement of the EPS controller by 15 %.
| Parameter | Baseline System | Optimized System | Improvement |
|---|---|---|---|
| EPS motor average current (A) | 24.5 | 21.5 | –12.3 % |
| Peak power @ 60 km/h double lane change (W) | 850 | 745 | –12.4 % |
| Cold‑start assist build‑up time @ –20 °C (s) | 2.45 | 1.80 | –27 % |
| NEDC energy consumption (kW·h/100 km) | 1.45 | 1.28 | –11.7 % |
| EPS controller heat dissipation (W) | 32 | 27 | –15 % |
4.2 NVH Test Results
Both subjective evaluations and objective measurements confirmed a significant improvement in noise, vibration, and harshness (NVH). During steady‑state driving at 30 km/h, the sound pressure level at the driver’s right ear decreased by 4.2 dB in the 200–800 Hz frequency range, with the gear‑mesh peak at 480 Hz dropping by 6.1 dB. Vibration transfer path analysis revealed that the standard deviation of the dynamic meshing force in the worm gear pair was reduced from 12.7 N to 8.3 N, directly improving the second‑order vibration mode of the steering column. On rough road excitation, the acceleration RMS value at the steering wheel (12 o’clock position) decreased from 0.32 g to 0.24 g, and the perceived vibration dose value was reduced by 35 %. For the idle vibration condition, adjusting the stiffness of the worm support bearings suppressed the 35 Hz resonance peak amplitude by 78 %. The subjective sound quality rating improved by 2.1 levels on the roughness scale during the steering return‑to‑center phase, reaching a level typically associated with luxury vehicles.
| Metric | Baseline | Optimized | Improvement |
|---|---|---|---|
| Sound pressure level 200–800 Hz @ 30 km/h (dB) | 68.5 | 64.3 | –4.2 dB |
| Gear‑mesh peak @ 480 Hz (dB) | 72.1 | 66.0 | –6.1 dB |
| Dynamic meshing force std. dev. (N) | 12.7 | 8.3 | –35 % |
| Steering wheel vibration RMS @ rough road (g) | 0.32 | 0.24 | –25 % |
| Vibration dose value reduction | ‑ | ‑ | –35 % |
| 35 Hz resonance suppression | ‑ | ‑ | 78 % attenuation |
| Sound roughness rating (1–10 scale) | 5.2 | 7.3 | +2.1 |
Conclusions
Through systematic experimental investigations on worm gears used in a lightweight EPS system, I have identified and quantified the dominant factors controlling transmission efficiency. The key findings are:
- Surface treatment of the worm flank strongly influences friction. Nitriding provides a hard, low‑friction surface that stabilizes the friction coefficient under mixed lubrication, yielding up to 4.7 % efficiency gain over phosphating.
- Lightweight material combinations such as an aluminum‑alloy worm wheel paired with a steel worm can reduce mass by 35 % and improve efficiency by 3.2 % when the helix angle is optimized to compensate for the lower elastic modulus.
- Lubricant viscosity must be carefully matched to the operating temperature window. A high‑viscosity‑index synthetic oil (e.g., 75W‑90 with Mo additive) delivers fast film build‑up at low temperatures and low churning losses at high temperatures.
- High‑precision grinding of the worm thread, powder metallurgy processing of the worm wheel, and optimized pre‑load assembly further improve efficiency by 4–7 %.
- Vehicle validation confirms that these improvements translate into a 12 % reduction in steering assist energy consumption and a substantial improvement in NVH performance.
The combined optimization of worm gears in the EPS application demonstrates that lightweight design does not have to come at the expense of efficiency or durability. The methodologies and data presented here provide a practical reference for the development of next‑generation electric steering systems.