
In my research on involute conical worm gear drives, I have thoroughly investigated the manufacturing process, geometric derivation, and installation parameters. This paper summarizes my findings on the generating principle, cutting method using a ball-cage synchronous coupling, the derivation of the involute helicoidal surface, a novel turning approach, the grinding wheel profile correction, and the precise calculation of the mounting distance and high-point of the conical worm gear. Throughout this work, the term worm gear refers to the conical worm and its mating wheel, and I emphasize the advantages of this transmission: it is a developable surface, can be ground with a disk-shaped wheel, the wheel dressing is simple, and the transmission accuracy and efficiency are high.
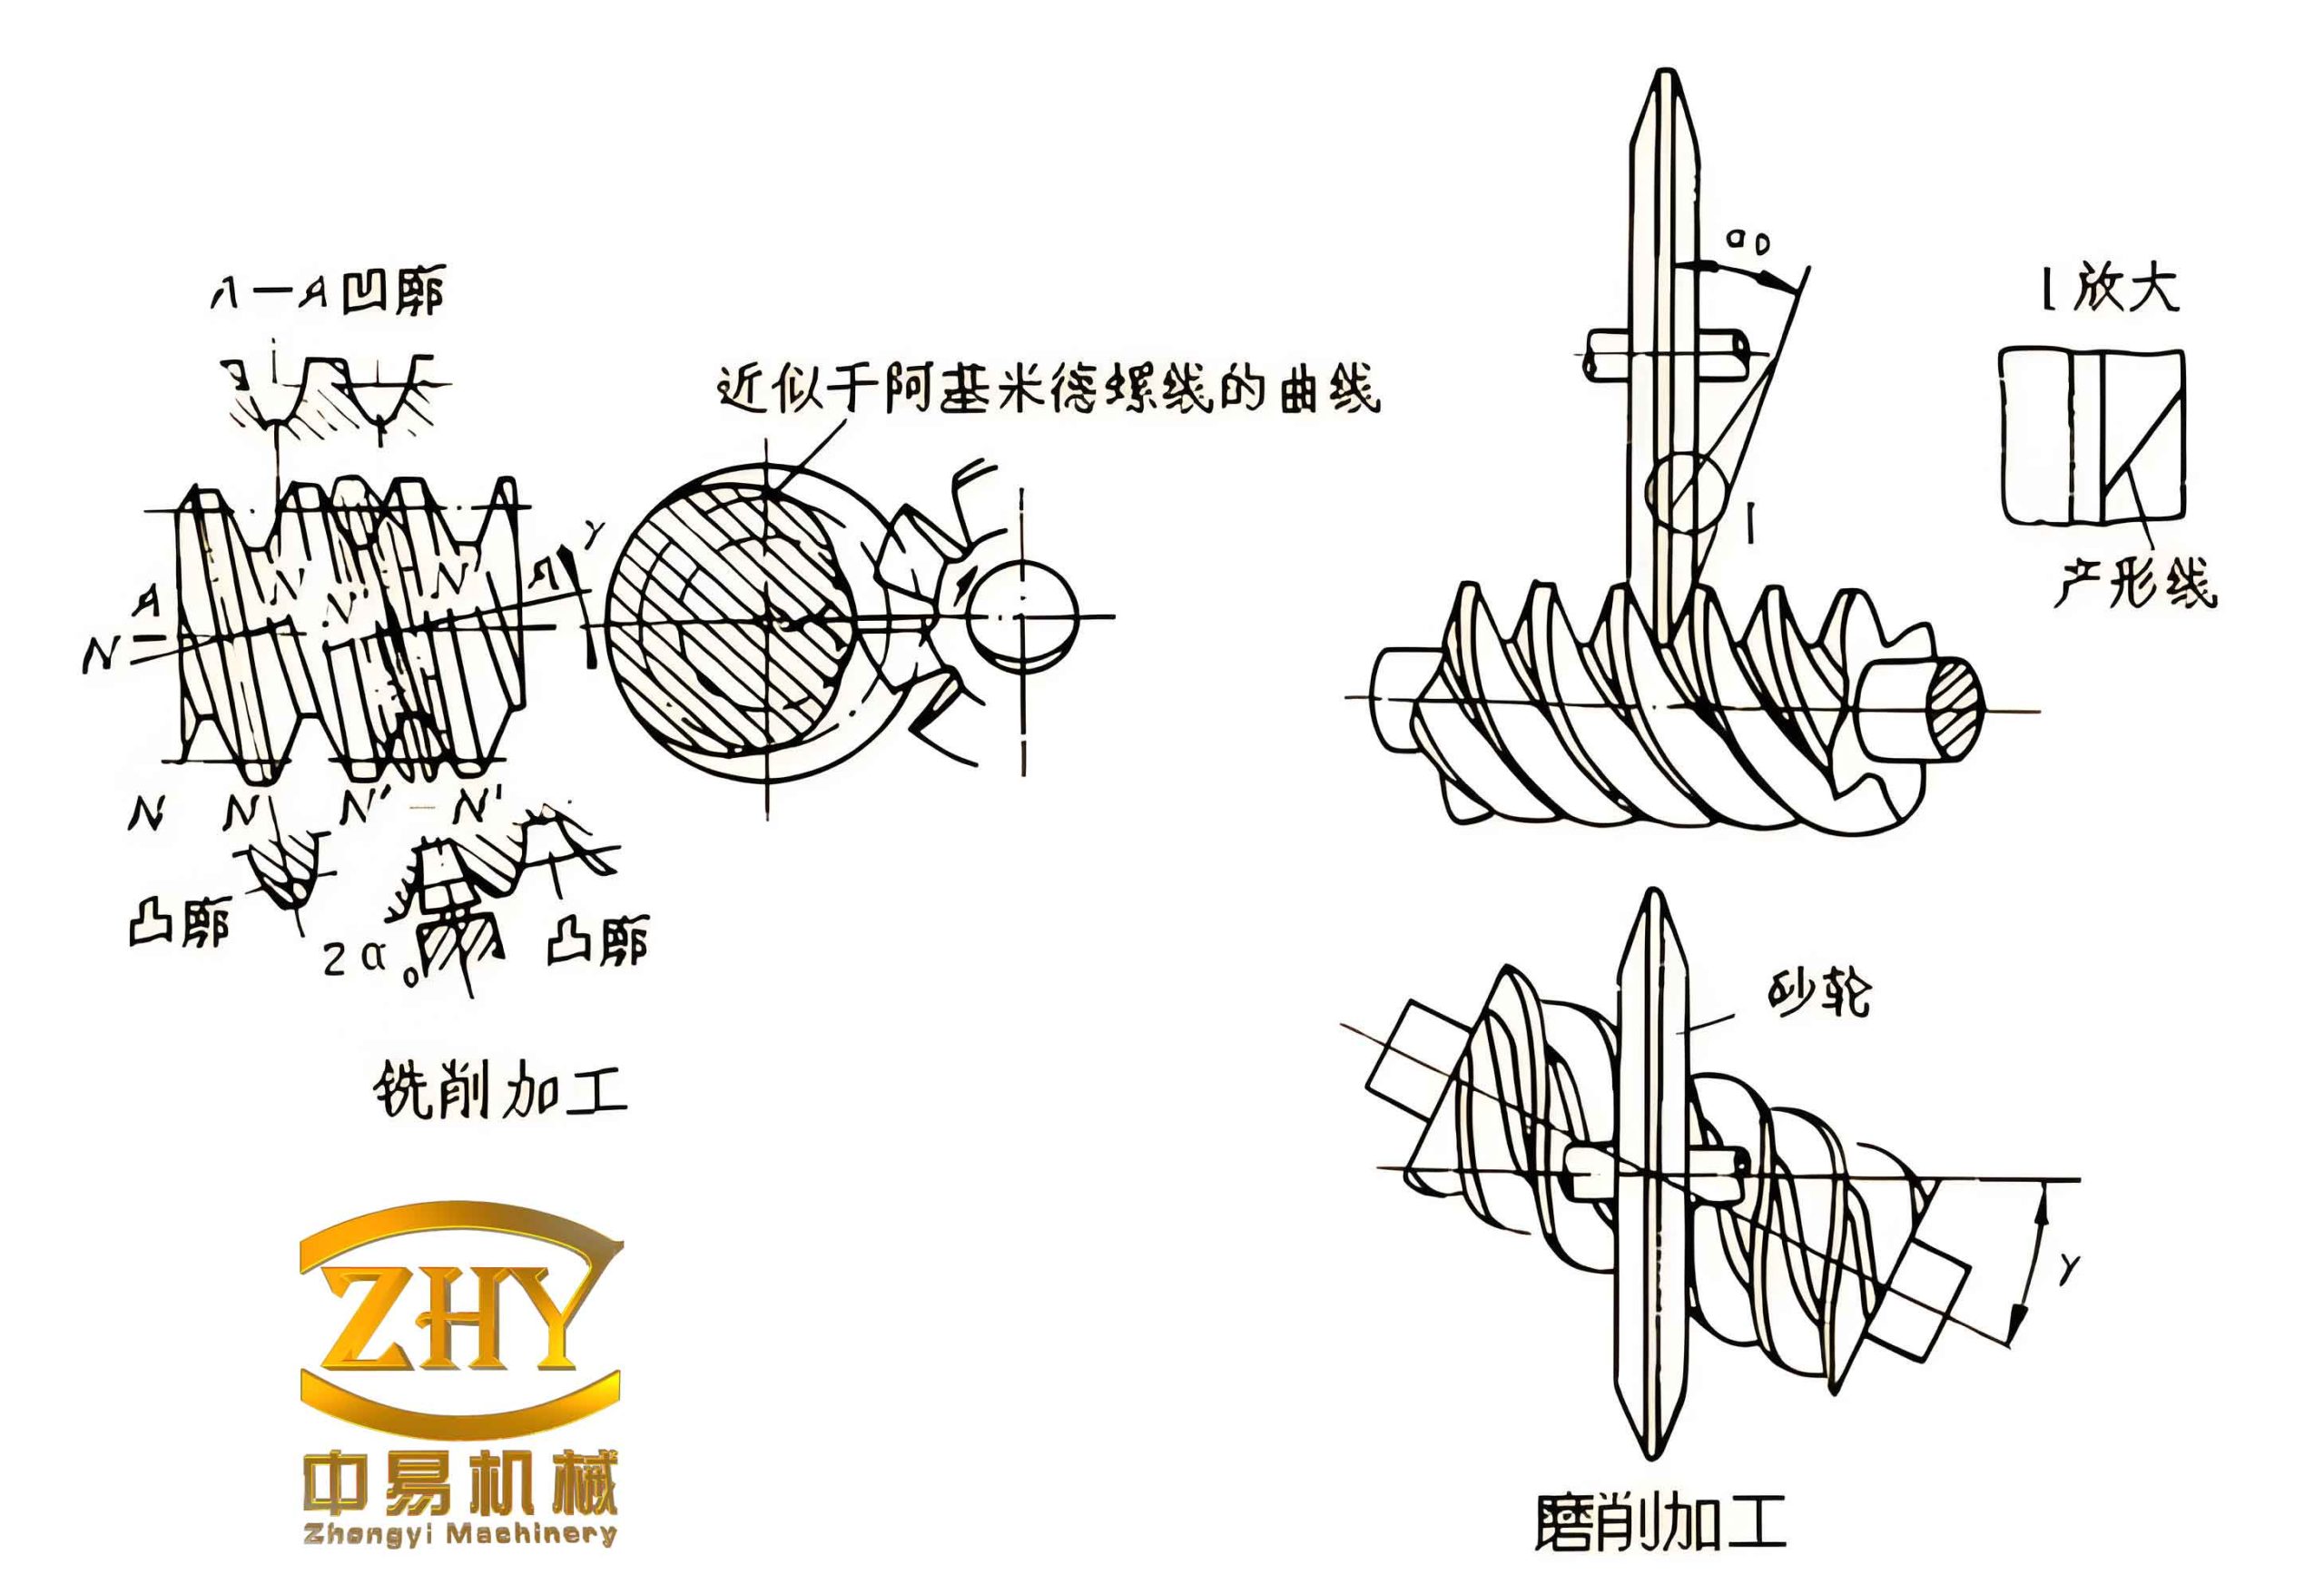
1. Manufacturing Process
To produce an involute conical worm, I used an ordinary lathe equipped with a ball-cage synchronous coupling. This coupling ensures that the driving spindle and the driven workpiece rotate synchronously. Such couplings are commercially available and require only minor modifications. The tailstock of the lathe was fitted with an intermediate shim to allow transverse movement and rotation by a certain angle. The cutting tool was a straight-edged tool whose cutting edge was set at a specific angle relative to the cone generator. The distance from the tool edge to the worm axis corresponds to the base cone radius. This setup allows the generation of the involute helicoidal surface as the tool rotates around the workpiece while the workpiece itself rotates.
2. Equation of the Involute Helical Surface
For the mathematical description, I introduced three coordinate systems:
- System \(S_1(O_1; x_1, y_1, z_1)\) fixed to the conical worm.
- System \(S_0(O_0; x_0, y_0, z_0)\) fixed to the cutting tool.
- Auxiliary fixed system \(S_a(O_a; x_a, y_a, z_a)\).
During cutting, the tool rotates around the worm axis, which is equivalent to the worm rotating while the tool remains stationary. The cutting edge is a straight line inclined at an angle \(\alpha\) to the vertical plane containing the cone generator. The resulting involute helicoidal surface equation in parametric form, derived via coordinate transformations, is:
$$
\begin{aligned}
x_1 &= R_b \cos\theta + u \sin\delta \cos\theta – p\theta \sin\theta \\
y_1 &= R_b \sin\theta + u \sin\delta \sin\theta + p\theta \cos\theta \\
z_1 &= u \cos\delta + p\theta
\end{aligned}
$$
where:
- \(R_b\) is the base cone radius (distance from the worm axis to the tool edge at the reference point),
- \(\delta\) is the half cone angle of the pitch cone,
- \(u\) is the parameter along the cutting edge (distance from a reference point),
- \(\theta\) is the rotation angle of the tool relative to the worm,
- \(p\) is the helix parameter: \(p = \frac{R_b}{\tan\gamma}\) with \(\gamma\) being the helix lead angle at the pitch circle.
From these equations, I obtained the transverse (end) section by setting \(z_1 = 0\) and solving for \(u\) and \(\theta\). Similarly, the axial section (in the plane containing the worm axis) was derived. The axial profile is particularly important for the turning method described later.
3. New Turning Method for the Conical Worm
During conventional turning, the straight cutting edge must be tangential to the base cone to generate the involute surface. However, this often leads to tool interference („cutter interference“) making the process impractical. My solution was to pre-calculate the exact axial profile of the worm and then use a tool whose cutting edge matches that profile. Placing this tool in the axial plane of the worm allows cutting without interference, similar to turning an Archimedean worm. This method is simple and robust.
The axial profile curve was obtained by substituting the condition of the axial plane into the general helicoidal surface equation. After coordinate transformation, the profile in the axial plane is given by:
$$
\begin{aligned}
x_a &= R_b \cos\theta_a + u \sin\delta \cos\theta_a – p\theta_a \sin\theta_a \\
z_a &= u \cos\delta + p\theta_a
\end{aligned}
$$
with the condition that the y-coordinate is zero. The parameter \(\theta_a\) is the specific value satisfying the axial plane condition. The resulting curve defines the shape of the turning tool.
4. Grinding of the Conical Worm
For worms with a small number of starts and a small helix angle, grinding with a disk-shaped wheel is feasible. However, the grinding wheel must be dressed to a specific profile to maintain the correct tooth flank. The contact line between the wheel and the worm helicoidal surface is not the same as the generating line from turning; therefore, the wheel profile must be computed based on the meshing theory.
I used a coordinate system fixed to the wheel and applied the condition of meshing: the relative velocity vector must be perpendicular to the common normal at the contact point. The meshing equation for the conical worm and the wheel is:
$$
n \cdot v_{12} = 0
$$
where \(n\) is the unit normal to the worm surface and \(v_{12}\) is the relative velocity. After algebraic manipulation, I obtained an expression relating the parameters \(u\), \(\theta\), and the wheel rotation angle \(\phi\). The contact line on the worm surface is then a curve in the \((\theta, u)\) domain. Transforming this contact line into the wheel coordinate system yields the wheel’s axial profile.
The wheel’s axial cross-section (the profile in the plane containing the wheel axis) is given by:
$$
\begin{aligned}
R_w &= \sqrt{x_w^2 + y_w^2} \\
z_w &= z_w
\end{aligned}
$$
where \(x_w, y_w, z_w\) are coordinates of points on the wheel’s surface. The function \(R_w(z_w)\) defines the dressing profile of the grinding wheel.
5. Installation Parameters and High-Point Calculation
Proper installation of the conical worm gear requires accurate determination of the mounting distance and the high-point on the worm wheel. The high-point is defined as the point on the tip of the worm wheel that contacts the root of the worm during correct meshing. From this high-point, the thickness of the worm wheel can be derived.
As shown in my analysis, the height coordinate of the high-point is:
$$
h = \frac{r_{p2}}{\cos\delta_2}
$$
where \(r_{p2}\) is the pitch radius of the worm wheel at the high-point and \(\delta_2\) is the face cone angle of the worm wheel. The thickness of the worm wheel is then:
$$
S_2 = h \cdot \tan\psi
$$
with \(\psi\) being the tooth thickness half-angle at the high-point.
For the worm, I defined a reference plane (a flat surface) as the measurement base. A measurement point on the worm’s outer diameter at a known axial distance from this base gives the required mounting distance of the worm. The axial mounting distance \(A\) is calculated as:
$$
A = L + \frac{d_{m}}{2 \tan\gamma}
$$
where \(L\) is the distance from the measurement point to the base plane, \(d_m\) is the measured outer diameter, and \(\gamma\) is the lead angle at the pitch cylinder.
6. Summary of Key Parameters
To facilitate the design and manufacturing, I have compiled the important formulas in the following tables.
| Parameter | Symbol | Formula / Value |
|---|---|---|
| Base cone radius | \(R_b\) | Given from design |
| Pitch cone half-angle | \(\delta\) | Given |
| Helix lead angle | \(\gamma\) | \(\arctan\left(\frac{p}{R_b}\right)\) |
| Helix parameter | \(p\) | \(R_b / \tan\gamma\) |
| Tooth profile angle (on normal) | \(\alpha_n\) | Standard value (e.g., 20°) |
| Quantity | Expression |
|---|---|
| Worm surface coordinates | \(x_1 = R_b\cos\theta + u\sin\delta\cos\theta – p\theta\sin\theta\) \(y_1 = R_b\sin\theta + u\sin\delta\sin\theta + p\theta\cos\theta\) \(z_1 = u\cos\delta + p\theta\) |
| Unit normal to worm surface | \(\mathbf{n} = \frac{\partial \mathbf{r}_1}{\partial u} \times \frac{\partial \mathbf{r}_1}{\partial \theta} / \left| \cdots \right|\) |
| Meshing condition | \(\mathbf{n} \cdot \mathbf{v}_{12} = 0\) |
| Contact line on worm (param.) | \(u = f(\theta)\) from solving meshing equation |
| Wheel axial profile | \(R_w = \sqrt{x_w^2 + y_w^2}\), \(z_w = g(\theta)\) |
| Parameter | Formula |
|---|---|
| High-point height \(h\) | \(h = r_{p2} / \cos\delta_2\) |
| Worm wheel thickness \(S_2\) | \(S_2 = h \cdot \tan\psi\) |
| Worm axial mounting distance \(A\) | \(A = L + \frac{d_m}{2\tan\gamma}\) |
7. Conclusion
In this work, I have systematically studied the manufacturing and geometry of involute conical worm gear drives. The use of a ball-cage synchronous coupling on a lathe provides a practical method for rough cutting, while the new turning method based on the axial profile avoids interference. For grinding, I derived the necessary wheel dressing profile from meshing theory, ensuring accurate tooth flanks. The installation parameters, especially the high-point calculation, were precisely determined, enabling correct mounting of the worm gear pair. These results contribute to the efficient production of high-precision conical worm gears.