
In this study, I present a comprehensive investigation into the transmission efficiency of a single-roller enveloping end face worm gear drive. Based on meshing theory, I establish a mathematical model to calculate both instantaneous and average transmission efficiencies. The influence of key parameters—such as friction coefficient, throat neck coefficient, roller radius, worm gear tooth number, and center distance—on the average efficiency is systematically analyzed. Using MATLAB optimization, I identify parameter combinations that yield higher transmission efficiency. The results show that the average efficiency is negatively correlated with friction coefficient, throat neck coefficient, roller radius, and worm gear tooth number, but positively correlated with center distance. Among these, the friction coefficient has the most pronounced effect, followed by worm gear tooth number, while center distance has the least impact.
1. Introduction
Worm gear drives are widely used in machinery for their high reduction ratio, compact structure, and smooth operation. However, compared to gear drives, worm gear systems typically suffer from lower efficiency due to significant sliding friction. To address this, researchers have developed movable-tooth enveloping worm gear drives, where the worm gear teeth (rollers) can rotate about their own axes, converting sliding friction into rolling friction and thereby improving efficiency. The single-roller enveloping end face worm gear drive is one such configuration. In this design, the worm gear tooth surface is generated by enveloping a series of cylindrical rollers mounted on the face of the worm gear disk. This paper focuses on the modeling and analysis of the transmission efficiency of this worm gear drive, aiming to identify key influencing factors and optimize performance.
2. Geometric and Kinematic Modeling
The three-dimensional model of the single-roller enveloping end face worm gear drive is shown in the figure below. The worm gear consists of a disk with rollers uniformly distributed on its end face. Each roller can rotate about its own axis, which reduces sliding friction at the contact points.
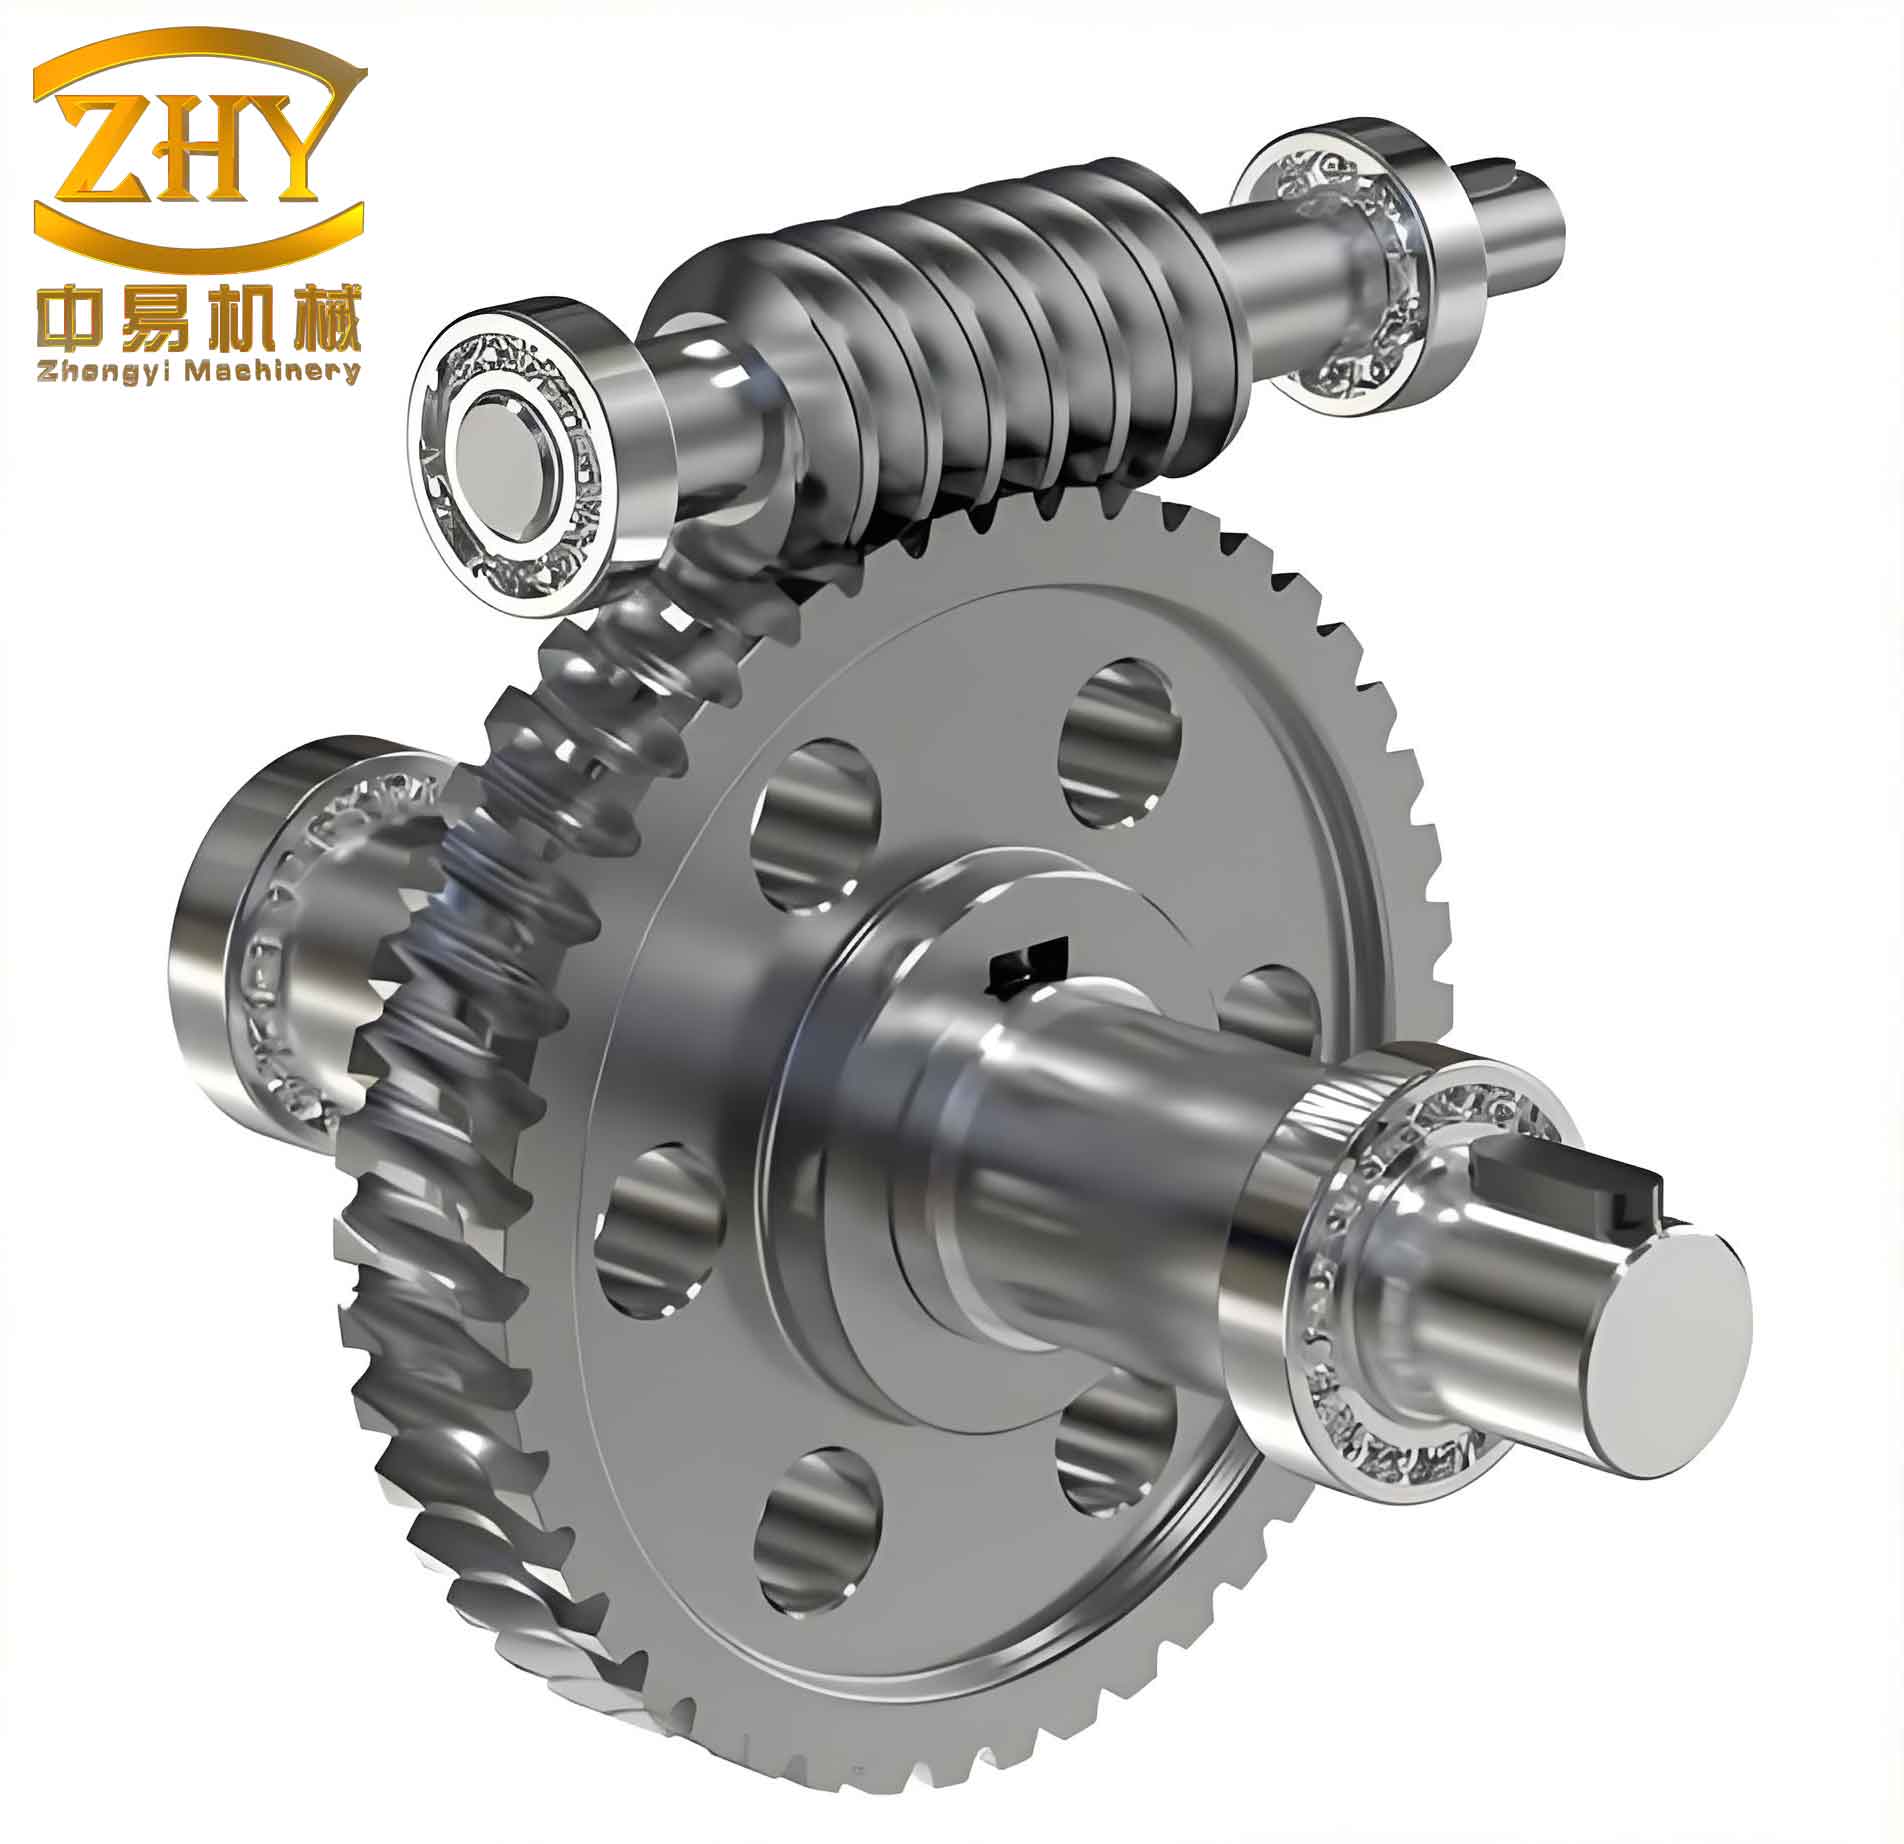
The worm gear structure is illustrated schematically. The rollers are evenly spaced around the worm gear disk. This design increases the contact area and ensures stable meshing with the worm.
2.1 Force Analysis at the Meshing Point
Consider an arbitrary meshing point p on the common contact surface. Let Fn1 and Fn2 be the normal forces on the worm and worm gear, respectively. Tangential forces are denoted as Ft1 and Ft2, and axial forces as Fa1 and Fa2. According to the meshing theory, the relative velocity vector v12 at point p has zero normal component. Consequently, friction forces act only in the common tangent plane. The worm gear tooth (roller) rotates under the action of tangential force, converting sliding into rolling. Let fg be the ratio of rolling friction coefficient to sliding friction coefficient. The effective forces influencing efficiency on the worm gear tooth side are:
$$ \mathbf{F}_2 = \mathbf{F}_{n2} + \mathbf{F}_{a2} + f_g \mathbf{F}_{t2} $$
Similarly, for the worm side:
$$ \mathbf{F}_1 = \mathbf{F}_{n1} + \mathbf{F}_{a1} + f_g \mathbf{F}_{t1} $$
By equilibrium, F1 = −F2. The sliding friction forces are given by Ff1 = Fn1 f and Ff2 = Fn2 f, where f is the sliding friction coefficient. The angles between tangential and friction components are α1 = α2 = arctan(V2/V1), with:
$$
\begin{aligned}
V_1 &= A\sin\theta + R\sin\phi_2 + (u-a_2)(i_{21}\cos\theta + \cos\phi_2\sin\theta) \\
V_2 &= R\cos\theta\cos\phi_2 – i_{21}R\sin\theta
\end{aligned}
$$
where A is center distance, R is roller radius, θ and u are tooth parameters, i21 is transmission ratio, φ2 is worm gear rotation angle, k is throat neck coefficient, z2 is worm gear tooth number, and intermediate variable a2 = A(2−k)(8−5z2)/(10z2).
2.2 Efficiency Calculation Model
Let v1 and v2 be the velocity vectors of worm and worm gear at meshing point p in the moving coordinate system. The instantaneous power of worm (Pw) and worm gear (Pg) are:
$$ P_w = \mathbf{F}_1 \cdot \mathbf{v}_1, \quad P_g = \mathbf{F}_2 \cdot \mathbf{v}_2 $$
The instantaneous transmission efficiency η is:
$$ \eta = \frac{P_g}{P_w} = \frac{(\mathbf{e}_n \mp f\sin\alpha_2\mathbf{e}_2 \pm f_g f\cos\alpha_2\mathbf{e}_1) \cdot \mathbf{v}_2}{(\mathbf{e}_n \mp f\sin\alpha_1\mathbf{e}_2 \mp f_g f\cos\alpha_1\mathbf{e}_1) \cdot \mathbf{v}_1} $$
where e1, e2, en are basis vectors of the movable coordinate system attached to the worm gear tooth.
The single-tooth instantaneous efficiency ηu is the integral of η along the instantaneous contact line:
$$ \eta_u = \frac{1}{h} \int_0^h \eta \, du $$
Here, h = ha + hf, with hf = hfc (typically 1 or 0.8). The single-tooth average efficiency ηp is obtained by integrating over the worm gear rotation angle:
$$ \eta_p = \frac{1}{\phi_{2e} – \phi_{20}} \int_{\phi_{20}}^{\phi_{2e}} \eta_u \, d\phi_2 $$
For multi-tooth simultaneous meshing with n teeth in contact, the instantaneous efficiency ηun and average efficiency ηpn are:
$$ \eta_{un} = \frac{\sum_{i=1}^n \int_0^h \eta_i \, du}{n h} $$
$$ \eta_{pn} = \frac{1}{n} \sum_{i=1}^n \frac{\int_{\phi_{20i}}^{\phi_{2ei}} \eta_{ui} \, d\phi_2}{\phi_{2ei} – \phi_{20i}} $$
where φ20i = φ201 + (i−1)γ, φ2ei = φ201 + iγ, γ = 360°/z2 is the angular pitch, and φ201 = −90° − nγ/2.
3. Parametric Analysis of Transmission Efficiency
In the following analysis, the worm gear drive has a single-start worm. The baseline parameters are listed in Table 1. I adopt a single-variable approach to examine the influence of each parameter on the average efficiency, while keeping other parameters at their baseline values.
| Parameter | Symbol | Value |
|---|---|---|
| Center distance | A | 160 mm |
| Number of worm starts | z1 | 1 |
| Number of worm gear teeth | z2 | 24 |
| Simultaneously meshing teeth | n | 4 |
| Throat neck coefficient | k | 0.4 |
| Roller radius | R | 10 mm |
| Worm angular velocity | ω1 | 1 rad/s |
| Sliding friction coefficient | f | 0.15 |
| Rolling-to-sliding friction ratio | fg | 0.2 |
3.1 Effect of Worm Gear Rotation Angle
Figure 6 (not shown here) shows the instantaneous multi-tooth average efficiency ηun versus worm gear rotation angle φ2. The efficiency increases almost linearly from meshing-in to meshing-out. For different sliding friction coefficients f = 0.05, 0.10, 0.15, 0.20, the efficiency at the exit is higher than at the entry by 4.65%, 7.63%, 9.72%, and 11.27%, respectively. This indicates that a larger f amplifies the sensitivity to φ2. At a fixed φ2, a larger f reduces efficiency.
3.2 Effect of Sliding Friction Coefficient
Figure 7 presents the average efficiency ηpn as a function of sliding friction coefficient f. The efficiency decreases significantly with increasing f. For f = 0.05, 0.10, 0.15, 0.20, the average efficiencies are 75.29%, 60.53%, 50.67%, and 43.59%, respectively. A change from 0.05 to 0.20 reduces efficiency by about 31.7%. This demonstrates that the friction coefficient is the most dominant factor affecting the worm gear drive efficiency.
3.3 Effect of Throat Neck Coefficient
Figure 8 shows the influence of throat neck coefficient k. As k increases from 0.30 to 0.50, the average efficiency decreases. For f = 0.05, 0.10, 0.15, 0.20, the reductions are 3.09%, 4.93%, 6.18%, and 7.07%, respectively. A larger f amplifies the sensitivity to k.
3.4 Effect of Roller Radius
Figure 9 depicts the effect of roller radius R. Efficiency decreases slightly as R increases from 5 mm to 10 mm. For f = 0.05, 0.10, 0.15, 0.20, the reductions are 0.71%, 1.14%, 1.44%, and 1.66%, respectively. The impact is modest but more noticeable at higher friction.
3.5 Effect of Worm Gear Tooth Number
Figure 10 shows the effect of worm gear tooth number z2. Efficiency decreases as z2 increases. For each increment of one tooth, the efficiency drops by approximately 1.00%, 1.61%, 2.02%, and 2.33% for f = 0.05, 0.10, 0.15, 0.20, respectively. Thus, z2 has a considerable influence, second only to friction.
3.6 Effect of Center Distance
Figure 11 shows the influence of center distance A. As A increases from 160 mm to 200 mm, efficiency increases slightly. For f = 0.05, 0.10, 0.15, 0.20, the gains are 0.28%, 0.46%, 0.58%, and 0.67%, respectively. Center distance has the smallest effect among all parameters considered.
4. Optimization of Transmission Efficiency
I formulate an optimization problem to maximize the average transmission efficiency ηpn of the worm gear drive. The design variables include throat neck coefficient k, roller radius R, worm gear tooth number z2, center distance A, addendum coefficient hfa, dedendum coefficient hfc, and number of simultaneously meshing teeth n.
To avoid geometric distortions such as tooth tip thinning and to satisfy installation space and smoothness, the following constraints are imposed:
$$
\begin{aligned}
s_2 &> R \\
s_1 &= (2-k)A/2 – (h_{fc} + c_c)m \\
s_2 &= s_1 \tan\beta, \quad \beta = \gamma/2 \\
f &\in [0.05, 0.2] \\
k &\in [0.3, 0.5] \\
R &\in [5, 10] \; \text{mm} \\
z_2 &\in [20, 30] \\
A &\in [160, 200] \; \text{mm} \\
h_{fa} &\in [0.8, 1.0] \\
h_{fc} &\in [0.8, 1.0] \\
n &\in [3, 5]
\end{aligned}
$$
where cc = 0.2 is the tip clearance coefficient. The objective is to minimize the reciprocal of efficiency:
$$ \min f(\mathbf{X}) = 1/\eta_{pn}(\mathbf{X}), \quad \mathbf{X} = [k, R, z_2, A, h_{fa}, h_{fc}, n] $$
I solve this optimization using MATLAB. Two methods are employed: the built-in fmincon function and a genetic algorithm. The results for different n values are summarized in Table 2.
| Parameter | fmincon |
Genetic Algorithm | ||||
|---|---|---|---|---|---|---|
| n=3 | n=4 | n=5 | n=3 | n=4 | n=5 | |
| k | 0.3635 | 0.3615 | 0.3623 | 0.3613 | 0.3618 | 0.36044 |
| R (mm) | 8.1917 | 8.1919 | 8.1922 | 8.1914 | 8.1921 | 8.1919 |
| z2 | 23.361 | 23.534 | 23.602 | 23.354 | 23.421 | 23.524 |
| A (mm) | 179.63 | 179.70 | 179.75 | 179.61 | 179.68 | 179.72 |
| hfa | 0.9180 | 0.9184 | 0.9190 | 0.9178 | 0.9187 | 0.9184 |
| hfc | 0.9068 | 0.9073 | 0.9067 | 0.9065 | 0.9068 | 0.9073 |
| ηpn (%) | 84.81 | 86.44 | 85.45 | 84.78 | 86.42 | 85.26 |
The highest efficiency is achieved when n=4, with both optimization methods yielding similar results. The optimal parameters are approximately k ≈ 0.36, R ≈ 8.19 mm, z2 ≈ 23.5, A ≈ 179.7 mm, hfa ≈ 0.918, hfc ≈ 0.907, yielding an average efficiency of about 86.4%. This represents a 3.2% improvement over the baseline efficiency calculated with the initial parameters (83.2%).
5. Discussion and Conclusions
From the parametric analysis, I draw the following conclusions regarding the single-roller enveloping end face worm gear drive:
- The average transmission efficiency is negatively correlated with the sliding friction coefficient, throat neck coefficient, roller radius, and worm gear tooth number. It is positively correlated with center distance.
- Among all factors, the friction coefficient has the most significant impact. A reduction from 0.20 to 0.05 can improve efficiency by over 30%. The worm gear tooth number is the second most influential geometric parameter, and center distance has the least effect.
- Both the
fminconand genetic algorithm optimizations yield similar results. For a drive with simultaneously meshing teeth n=4, the optimal configuration achieves an average efficiency of about 86.4%, which is 3.2% higher than the baseline. - To achieve high transmission efficiency in practice, it is essential to minimize friction through precise manufacturing and appropriate lubrication. Additionally, when the center distance is fixed, the throat neck coefficient, roller radius, and worm gear tooth number should not be excessively large.
This study provides a solid theoretical foundation for the design and optimization of single-roller enveloping end face worm gear drives. Future work may include experimental validation and investigation of dynamic effects under varying loads and speeds.