
This thesis presents a systematic investigation of the machining deformation mechanism of an oversize split straight bevel gear. The deformation of the split wheel blank during tooth cutting is dominated by the redistribution of initial residual stress and the continuous decrease of structural stiffness. I first established an equivalent bending stiffness model based on bending strain energy conservation, which allows the stiffness of the variable cross-section split wheel blank to be evaluated at any material removal stage. Then I built a finite element model in ABAQUS with an initial stress field generated by a user subroutine and simulated the cutting process using the element birth/death technique. On the basis of the simulated stress evolution, I derived a mapping model relating stiffness variation, residual stress evolution and deformation. The predicted deformation values were compared with finite element results and cutting experiments, and good agreement was obtained. The influences of wheel blank thickness, gear diameter, module and split ratio were also studied. The results show that the deformation of the split straight bevel gear can be effectively controlled by selecting a proper wheel blank thickness and a reasonable number of teeth in one split body.
Keywords: straight bevel gear; split structure; stiffness variation; residual stress; deformation mapping model; finite element simulation; cutting experiment.
1. Introduction
Straight bevel gears with extremely large diameters are key components in heavy industrial equipment, such as mining machinery, power generation systems and large rotating tables. Their manufacturing accuracy determines the stability and service life of the whole machine. With the increasing demand for heavy-duty equipment, the required size of straight bevel gears has reached more than three meters in diameter. For such a large straight bevel gear, a one-piece structure is difficult to manufacture, transport and assemble. Therefore, an oversize straight bevel gear is usually designed as a split structure, in which the whole gear ring is divided into several identical split bodies. Each split body is cut separately on a CNC machine and then assembled on a base to form the complete gear. The precision of the assembled gear strongly depends on the tooth cutting accuracy of each split body.
In engineering practice, the split body of an oversize straight bevel gear often undergoes significant structural deformation after tooth cutting. The deformation can be as large as several millimeters, which is unacceptable for tooth flank accuracy and gear assembly. It is therefore essential to understand the deformation mechanism of the split wheel blank during the cutting process. Previous studies on large split gears mainly focused on process optimization and empirical anti-deformation measures, while systematic theoretical research on the deformation mechanism is rarely reported. In contrast, the machining deformation of monolithic aerospace structural parts has been extensively studied, and it is widely accepted that the deformation caused by material removal is mainly due to the change of stiffness and the redistribution of initial residual stress. For a split straight bevel gear, the same mechanism applies. The tooth spaces are generated by removing material from a pre-stressed wheel blank. The removed material originally contains a certain amount of residual stress. When the material is cut away, the stress originally carried by that material disappears, so the remaining material must adjust its stress state to maintain equilibrium. Meanwhile, the cross-section of the wheel blank becomes discontinuous, leading to a reduction of bending stiffness. Both factors contribute to the final deformation of the split body.
In this thesis, I investigate the deformation mechanism of a representative oversize split straight bevel gear. The main research contents are as follows:
(1) A theoretical model for the equivalent bending stiffness of the split wheel blank is established using the bending strain energy conservation method. The stiffness evolution during different cutting sequences is analysed.
(2) A finite element model of the split wheel blank with initial residual stresses is constructed in ABAQUS. The tooth cutting process is simulated by the element birth/death technique. The stress evolution in three orthogonal directions is examined.
(3) A mapping model that connects stiffness variation, residual stress evolution and deformation is derived. The model is validated by comparing its predictions with finite element simulation results.
(4) The effects of wheel blank thickness, gear diameter, module and split ratio on the deformation are systematically studied. A rational range of design parameters is proposed.
(5) Cutting experiments are carried out on a split straight bevel gear blank. The measured deformation is compared with the predicted values, confirming the correctness of the analytical and numerical models.
Throughout this thesis, the term “straight bevel gear” is used to emphasize the specific gear type under investigation. The methods developed here are expected to provide a theoretical basis for deformation prediction and control of oversize split straight bevel gears.
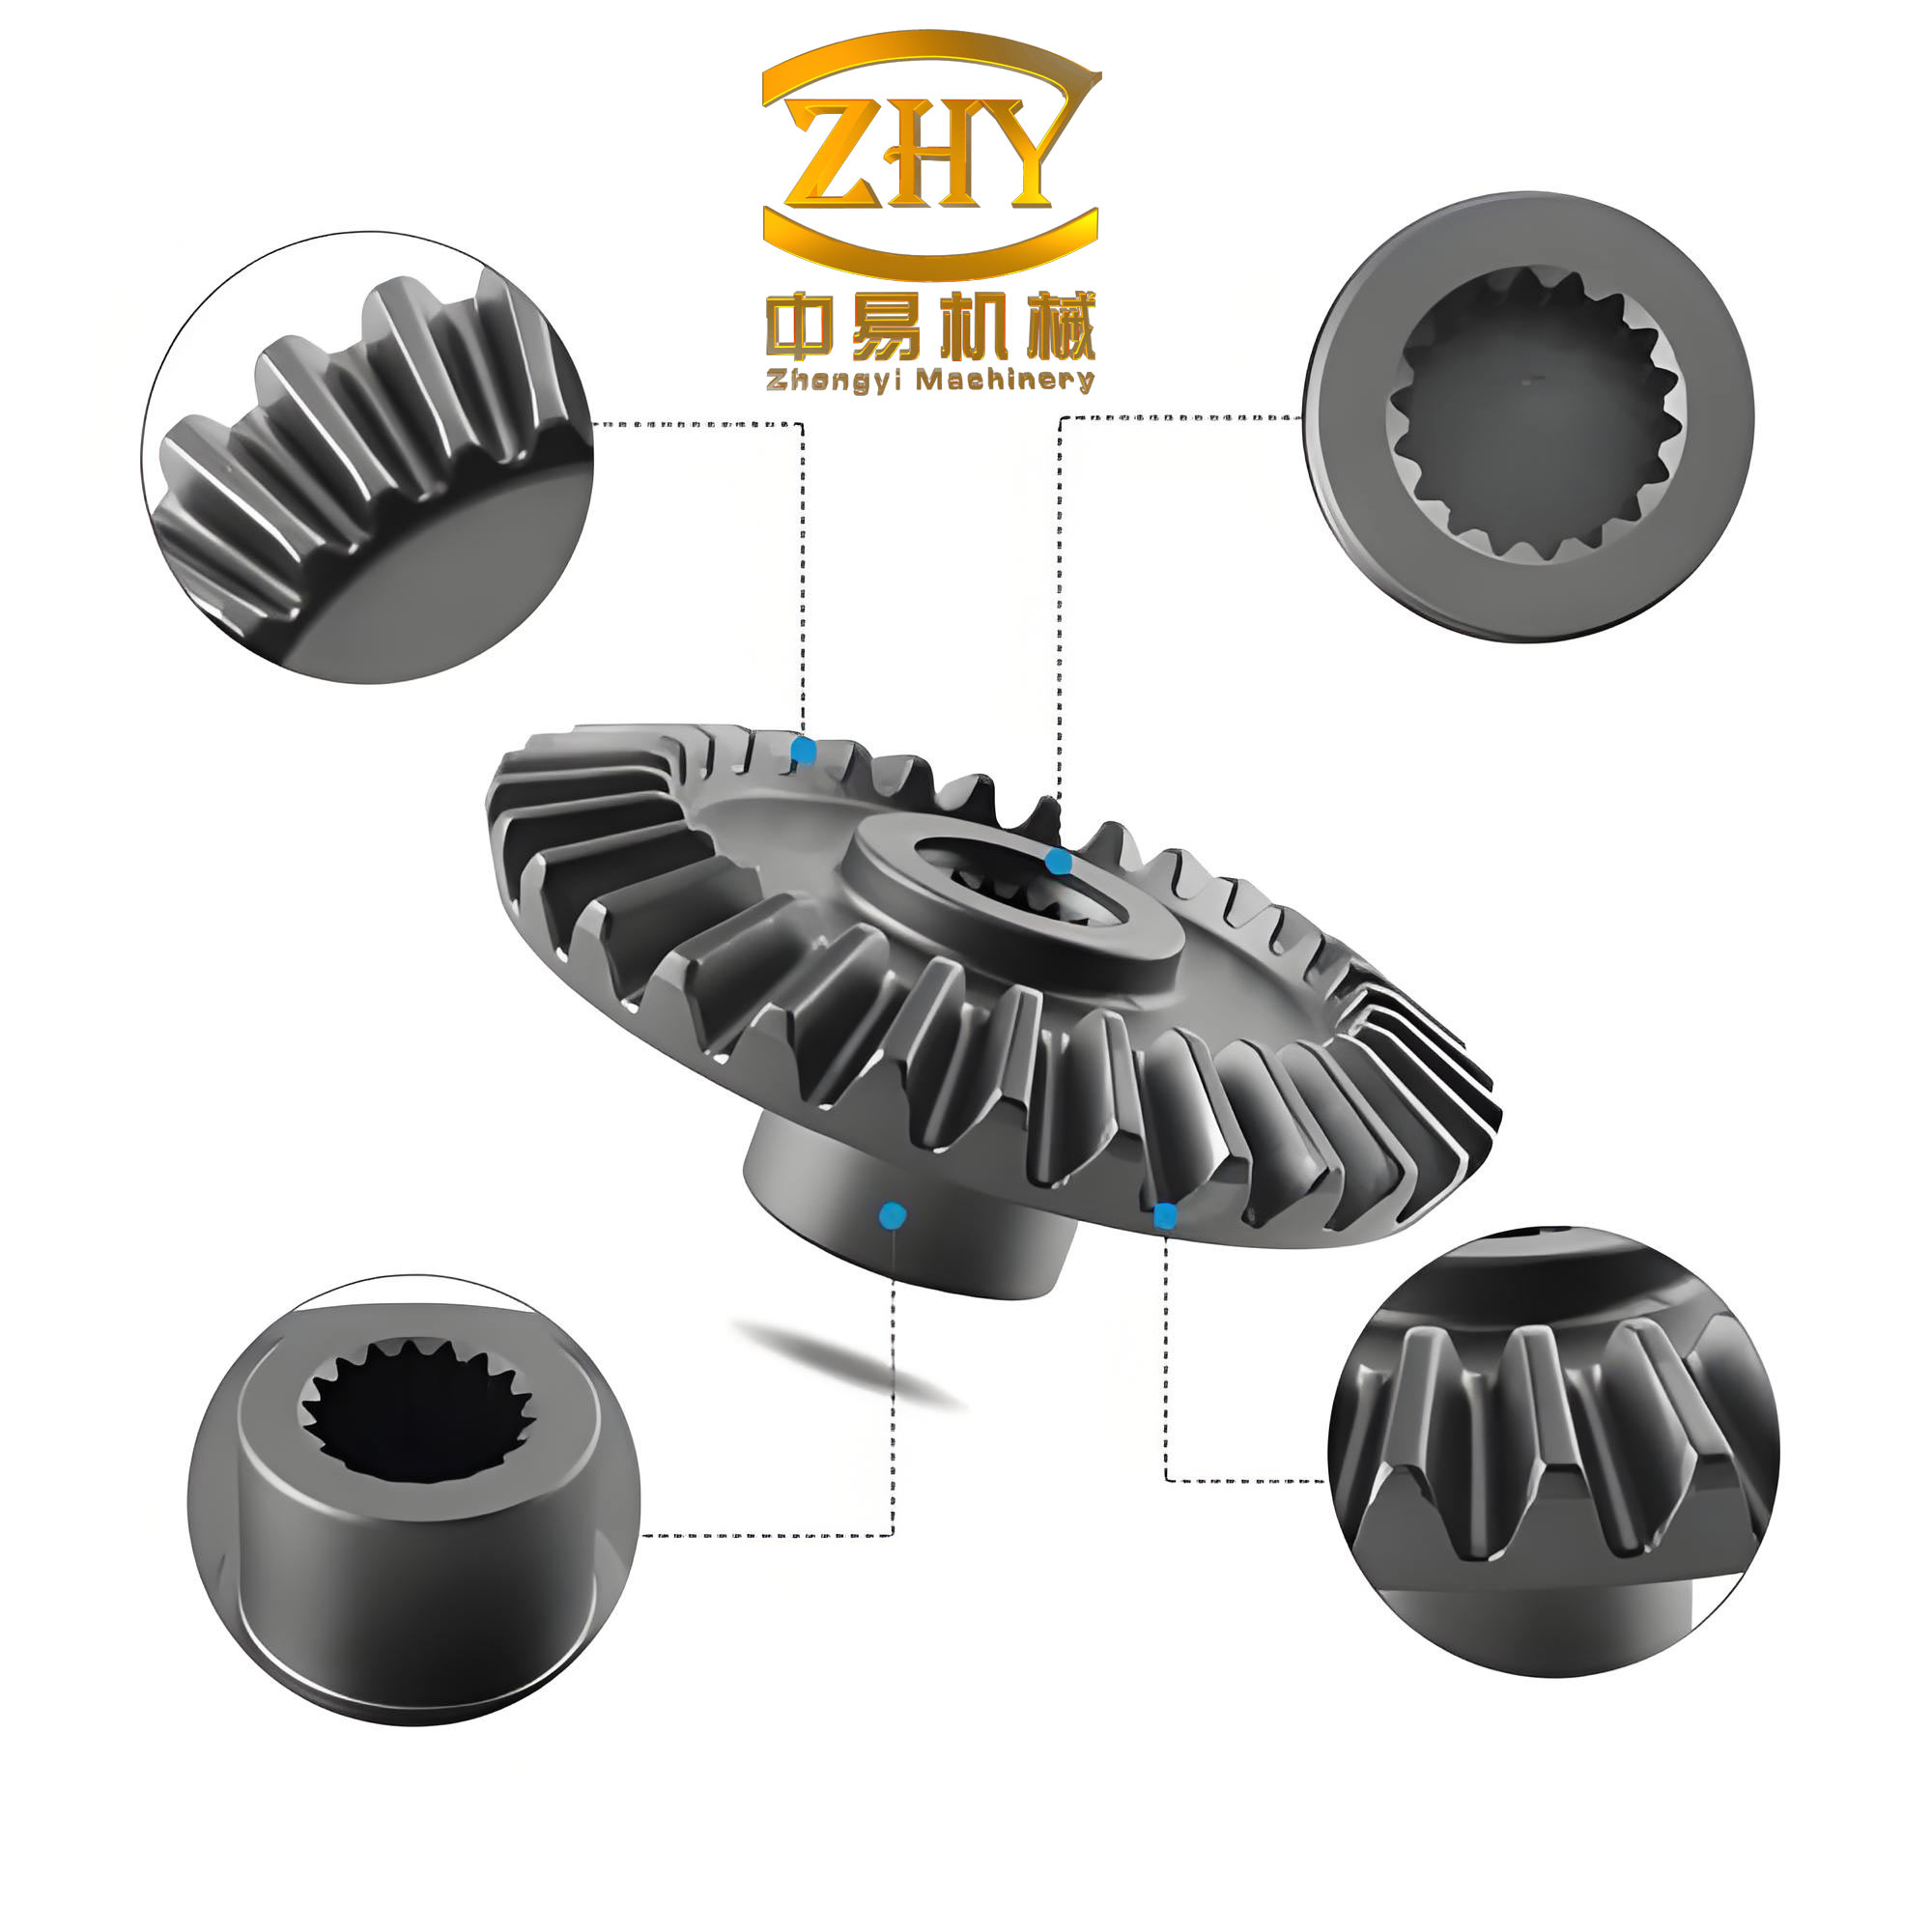
A typical split straight bevel gear body is shown above. The split body can be regarded as a curved beam with a relatively small curvature, so it is reasonable to simplify it as a straight beam of the same length for preliminary deformation analysis. In the following sections, the length direction of the split body is denoted as the \(x\)-axis, the width direction as the \(y\)-axis, and the thickness direction as the \(z\)-axis.
2. Stiffness Variation of the Split Wheel Blank during Cutting
2.1 Equivalent bending stiffness principle
The split wheel blank of a straight bevel gear has a variable cross-section during machining. The stiffness is not constant along the length direction, and therefore the traditional stiffness formula \(K=EI/L\) cannot be directly used. To solve this problem, I adopted the bending strain energy equivalence method. The deformed split wheel blank is replaced by an equivalent prismatic beam with the same length. The equivalent cross-section moment of inertia is determined by equating the bending strain energies of the two systems.
For a beam subjected to pure bending, the strain energy stored in an infinitesimal element is
$$dU = \frac{M^2 dx}{2EI}$$
or equivalently,
$$U = \frac{1}{2}\int_0^L EI \left[ y”(x) \right]^2 dx$$
For the actual split wheel blank with variable \(I_1(x)\), the strain energy is
$$U_1 = \frac{1}{2}\int_0^L E I_1(x) \left[ y_1”(x) \right]^2 dx$$
For the equivalent prismatic beam with constant \(I_2\),
$$U_2 = \frac{1}{2} E I_2 \int_0^L \left[ y_2”(x) \right]^2 dx$$
Letting \(U_1 = U_2\) and taking the deflection curve of the equivalent beam as the first approximation of the actual beam, the equivalent moment of inertia can be obtained:
$$I_2 = \frac{\int_0^L I_1(x) \left[ y_1”(x) \right]^2 dx}{\int_0^L \left[ y_2”(x) \right]^2 dx}$$
The equivalent bending stiffness is then
$$K = \frac{E I_2}{L}$$
2.2 Analysis model of the split wheel blank
In my study, the straight bevel gear has a module of \(m=20\), a tooth number of \(z=60\), a pitch angle of \(89^\circ\), a face width of \(100\ \text{mm}\), and an addendum-to-dedendum height of \(2.25m = 45\ \text{mm}\). The whole annular gear is divided into ten equal split bodies. One split body has dimensions of \(340\ \text{mm} \times 100\ \text{mm} \times 80\ \text{mm}\). The material is aluminium alloy 7075-T7451, with an elastic modulus of \(71.7\ \text{GPa}\). The initial moment of inertia of the untransformed blank is
$$I_0 = \frac{bh^3}{12} = \frac{100 \times 80^3}{12} = 4.267\times 10^6 \ \text{mm}^4$$
The initial stiffness is
$$K_0 = \frac{E I_0}{L} = \frac{71.7\times 10^3 \times 4.267\times 10^6}{340} \approx 8.998\times 10^5 \ \text{N/m}$$
The split body contains seven tooth spaces in total: five complete spaces and two half spaces at the two ends. The central tooth space is the fourth one. In the cutting simulation, removing the material of one complete tooth space is defined as one working step. Two typical cutting sequences are considered:
Method 1: cut the tooth spaces from left to right, i.e. 1, 2, 3, 4, 5, 6, 7.
Method 2: cut the middle tooth space first, then the right half, and finally the left half, i.e. 4, 5, 6, 7, 3, 2, 1.
During the cutting process, the material removal state changes gradually. A summary of the material removal states is listed in Table 1.
| State | Removed tooth spaces |
|---|---|
| 1 | None |
| 2 | 1 |
| 3 | 4 |
| 4 | 1,2 |
| 5 | 4,5 |
| 6 | 1,2,3 |
| 7 | 4,5,6 |
| 8 | 1,2,3,4 |
| 9 | 4,5,6,7 |
| 10 | 1,2,3,4,5 |
| 11 | 3,4,5,6,7 |
| 12 | 1,2,3,4,5,6 |
| 13 | 2,3,4,5,6,7 |
| 14 | 1,2,3,4,5,6,7 |
2.3 Calculation results of equivalent stiffness
Using the bending strain energy equivalence method, I calculated the equivalent stiffness of the split wheel blank under different material removal states and different load positions. The external force \(P=5000\ \text{N}\) was applied at four positions along the length of the blank. The averaged stiffness values are summarised in Table 2.
| Material removal state | Equivalent stiffness \(K\) (\(10^5\ \text{N/m}\)) |
|---|---|
| None | 8.998 |
| Tooth space 1 | 8.973 |
| Tooth space 4 | 7.808 |
| Tooth spaces 1,2 | 8.665 |
| Tooth spaces 4,5 | 6.699 |
| Tooth spaces 1,2,3 | 7.358 |
| Tooth spaces 4,5,6 | 6.124 |
| Tooth spaces 1,2,3,4 | 6.126 |
| Tooth spaces 4,5,6,7 | 6.117 |
| Tooth spaces 1,2,3,4,5 | 5.061 |
| Tooth spaces 3,4,5,6,7 | 5.062 |
| Tooth spaces 1,2,3,4,5,6 | 4.495 |
| Tooth spaces 2,3,4,5,6,7 | 4.521 |
| All tooth spaces | 4.487 |
It can be seen from Table 2 that the stiffness of the split wheel blank decreases continuously as material is removed. The stiffness reduction is not proportional to the material removal ratio. For example, after removing tooth space 1 and tooth space 2, the material removal ratio is relatively small, and the stiffness reduction is also small. However, after removing the middle tooth spaces, the stiffness drops much faster. This indicates that the stiffness variation depends not only on the amount of removed material but also on the position of the removed material. When the cut is closer to the middle of the split body, the influence on the bending stiffness is stronger.
In the final state, the stiffness is about 4.487 × 10^5 N/m, which is only about 49.9% of the initial value. This large stiffness reduction is one of the main reasons why the split body becomes more sensitive to deformation during the later cutting stages.
3. Residual Stress Evolution during Tooth Cutting
3.1 Initial residual stress distribution
The material 7075-T7451 is an aluminium alloy plate subjected to rolling, solution heat treatment, quenching, pre-stretching and ageing. The initial residual stress in such a plate is nearly uniform along the length and width directions but varies significantly through the thickness. For a plate with a thickness of 80 mm, the measured residual stress distribution in the rolling direction (\(x\)) and in the transverse direction (\(y\)) is shown by a dashed line in the original data. The stress profile resembles the letter “M” and is approximately symmetric about the mid-plane. The top and bottom surfaces are under compressive stresses of about \(-17.21\ \text{MPa}\) in the \(x\)-direction and \(-13.27\ \text{MPa}\) in the \(y\)-direction. The maximum tensile stresses occur at about 20 mm from the mid-plane, with values of \(16.21\ \text{MPa}\) in the \(x\)-direction and \(13.84\ \text{MPa}\) in the \(y\)-direction. The mid-plane stress is almost zero.
To apply this initial stress field to the finite element model, I performed a Fourier curve fitting in MATLAB. The fitted equations are:
$$
\sigma_x(z) = \sum_{i=1}^{5} a_i \cos\left[i \omega (z-2)\right] + \sum_{i=1}^{5} b_i \cos\left[i \lambda (z-2)\right]
$$
$$
\sigma_y(z) = \sum_{i=1}^{4} c_i \cos\left[i \mu (z-2)\right] + \sum_{i=1}^{4} d_i \cos\left[i \nu (z-2)\right]
$$
The fitted coefficients are listed in Table 3. The initial stress in the \(z\)-direction is considered to be zero.
| Coefficient | Value | Coefficient | Value |
|---|---|---|---|
| \(a_1\) | -8.89 | \(b_1\) | -2.70 |
| \(a_2\) | -8.40 | \(b_2\) | -5.62 |
| \(a_3\) | -0.97 | \(b_3\) | -1.19 |
| \(a_4\) | 1.63 | \(b_4\) | 3.95 |
| \(a_5\) | 0.19 | \(b_5\) | 1.94 |
| \(c_1\) | 0.35 | \(d_1\) | -0.15 |
| \(c_2\) | 2.30 | \(d_2\) | -2.33 |
| \(c_3\) | 4.01 | \(d_3\) | -9.95 |
| \(c_4\) | -0.09 | \(d_4\) | -7.22 |
3.2 Finite element modelling with initial stress
I created the three-dimensional model of the split wheel blank in UG and exported it in STEP format. The model was then imported into ABAQUS. The element type was C3D20R, a 20-node quadratic hexahedral element. The blank was meshed with a structured technique, and local seeds were placed along the thickness direction so that the thickness was divided into layers of 2 mm each. This fine mesh allowed a smooth stress gradient to be represented.
The initial stress field was implemented by a user subroutine named SIGINI, written in Fortran. The subroutine assigns the fitted stress values to every integration point as a function of the \(z\)-coordinate. In ABAQUS, the initial condition was defined by adding the keyword *initial condition, type=stress to the input file. After submitting the job, the model contained a self-equilibrated residual stress field.
To simulate material removal, I used the element birth/death technique. The elements belonging to a particular tooth space were grouped together. At each analysis step, the elements of the corresponding tooth space were removed by setting their stiffness and stress contribution to nearly zero. This process mimics the actual cutting process with sufficient accuracy for deformation prediction.
3.3 Stress evolution results
After the simulation, I extracted the stress distributions on the top surface, bottom surface and several internal sections. The main observations are summarised as follows.
In the \(x\)-direction, the compressive stress on the top surface gradually decreases as machining proceeds. The bottom surface also loses part of its compressive stress. Inside the remaining material, the stresses around the cut tooth spaces are significantly reduced. The tooth space bottom, which was initially under a small tensile stress, becomes compressive with a value of about \(-15\ \text{MPa}\). The internal tensile stresses near the bottom surface remain almost unchanged. The stress redistribution is stronger near the cut areas.
In the \(y\)-direction, the stress changes mainly occur on the surfaces. The top surface changes from compressive to tensile at the edges of the cut spaces, with the maximum tensile value reaching about \(13.6\ \text{MPa}\). The bottom surface also experiences a transition from compression to tension. Inside the blank, the \(y\)-direction stresses change only slightly during cutting.
In the \(z\)-direction, the initial stress is zero. During cutting, small tensile stresses appear both on the surfaces and inside the material, with values of about \(2\ \text{MPa}\). After machining, the surface stresses nearly vanish, while small tensile stresses remain in the core of the teeth. Overall, the \(z\)-direction stresses are much smaller than those in the \(x\)- and \(y\)-directions.
The finite element analysis shows that the \(x\)-direction stress change is the most significant. Since the split body mainly bends in the \(x\)-\(z\) plane, the release of \(x\)-direction residual stress is the primary driving force for the machining deformation. This conclusion is used in the theoretical mapping model in the next section.
4. Deformation Analysis and Mapping Model
4.1 Finite element deformation simulation
I simulated the cutting process for five different wheel blank thicknesses: 90, 85, 80, 75 and 70 mm. The other dimensions remained unchanged. The deformation in the \(z\)-direction (thickness direction) was the largest, indicating that the dominant deformation mode is bending. The maximum \(z\)-direction displacements after full machining are listed in Table 4.
| Blank thickness (mm) | Max. \(z\)-direction displacement (mm) |
|---|---|
| 90 | 0.098 |
| 85 | 0.117 |
| 80 | 0.142 |
| 75 | 0.173 |
| 70 | 0.227 |
The finite element results show that the deformation increases as the thickness decreases. The relationship is not linear. When the thickness is reduced below 80 mm, the deformation grows at an increasing rate. This implies that a sufficiently large thickness is necessary to keep the deformation within a small range.
In the \(x\)-direction, the deformation is symmetric about the middle of the blank. The upper surface moves towards the two ends, while the lower surface moves towards the centre. The absolute values of the maximum \(x\)-direction displacement increase when the thickness is reduced. In the \(y\)-direction, the entire blank moves towards the large end, and the maximum displacement is smaller than in the other two directions. Therefore, subsequent theoretical analysis focuses on the \(z\)-direction bending deformation.
4.2 Additional bending moment caused by material removal
When a tooth space is cut, the material together with its original residual stress is removed. The effect of removing the material can be represented by applying an opposite stress on the newly created surfaces. This equivalent stress produces an additional bending moment about the neutral axis of the remaining cross-section.
During cutting, the position of the neutral axis changes continuously. For a single tooth space, if the slot width at depth \(z\) is denoted by \(b(z)\), the cross-sectional area of the remaining material is
$$A = L h – \int_0^{z_1} b(z) dz$$
where \(L\) is the length of the split body, \(h\) its original thickness, and \(z_1\) the tooth depth. The neutral axis position with respect to the bottom surface is
$$z_c = \frac{\int_0^h z L dz – \int_0^{z_1} z b(z) dz}{L h – \int_0^{z_1} b(z) dz}$$
For the analysed straight bevel gear, \(L=340\ \text{mm}\), \(h=80\ \text{mm}\), \(z_1=45\ \text{mm}\). The slot width varies linearly from \(41.15\ \text{mm}\) at the top to \(14.52\ \text{mm}\) at the bottom. Substituting these values into the formula, the neutral axis position decreases from 40 mm to about 37.35 mm after the complete removal of one tooth space.
For multi-layer material removal, I derived the curvature change formula:
$$\frac{1}{\rho_{m+1}} – \frac{1}{\rho_m} = \frac{6 \sigma_{j}}{E \delta_m \delta_{m+1}}$$
Here, \(m\) is the layer number, \(\delta_m\) and \(\delta_{m+1}\) are the remaining tooth thicknesses before and after removing layer \(m\), and \(\sigma_j\) is the initial stress in the removed layer. The additional bending moment \(M\) acting on the remaining cross-section is
$$M = \int_0^{z_1} \sigma_i(z) (z – z_c) w(z) dz$$
where \(w(z)\) is the width of the removed material at depth \(z\). The calculation was implemented in MATLAB. The results show that the additional moment first increases almost linearly with the removed depth, and then the growth rate becomes slower because the newly removed layers are closer to the neutral axis.
4.3 Mapping model between stiffness, stress and deformation
To calculate the deformation from the additional moment, I used the moment-area method. The split wheel blank is treated as a simply supported beam. The bending moment diagram is integrated twice to obtain the deflection curve.
If a single tooth space is cut near the middle of the blank, the maximum local deformation can be expressed as:
$$\Delta = \int_{x_1}^{x_1+x_3} \frac{M(x)}{EI(x)} x_1 dx$$
In the above equation, \(x_1\) is the distance from the left end to the left side of the tooth space, \(x_3\) is the tooth space width at the top surface, \(M(x)\) is the bending moment, and \(I(x)\) is the equivalent moment of inertia. I used the time-varying equivalent stiffness calculated in Section 2 instead of a constant \(EI\).
For a single tooth space in the middle position, the calculated deformation after complete machining is about 0.0583 mm. The finite element simulation gives 0.0608 mm. The relative error is only about 4.1%, which confirms that the analytical model is reliable.
When multiple tooth spaces are cut, the deformation process is cumulative. I used a superposition method based on the local deformation caused by each individual tooth space. The method starts from the middle tooth space. The deformation of the blank after cutting the middle tooth space is first calculated. Then the deformation caused by cutting the adjacent tooth space is combined with the previous deformation by rotating the coordinate system according to the slope of the deformed blank. Repeating this procedure gives the final deformation of the entire split body.
Let \(S_i\) be the local deformation caused by cutting tooth space \(i\) alone, and let \(\theta_{i1}\) and \(\theta_{i2}\) be the angles of the right and left end faces with respect to the horizontal line caused by that tooth space. The final deformation after superimposing \(n\) tooth spaces is
$$S’_n = S’_{n-1} + \frac{S_n}{\cos \theta_{n}}$$
where \(\theta_n\) is an accumulated rotation angle. The calculated values are summarised in Table 5.
| Tooth space number | Single deformation \(S_i\) (mm) | Right end angle (deg) | Left end angle (deg) |
|---|---|---|---|
| 4 (middle) | 0.0583 | 0.020 | 0.020 |
| 5 | 0.0249 | 0.013 | 0.006 |
| 6 | 0.0104 | 0.011 | 0.002 |
| 7 | 0.0251 | 0.006 | 0.013 |
| 3 | 0.0103 | 0.002 | 0.011 |
After the superposition of all the tooth spaces, the final deformation of the full split blank is predicted to be 0.1301 mm. The finite element simulation result is 0.1304 mm. The difference is only 0.0003 mm, which is negligible. This close agreement validates the mapping model.
4.4 Influence of design parameters
In order to control the deformation of a straight bevel gear during machining, it is useful to investigate how the design parameters affect the final deformation. I carried out a series of finite element simulations by changing the thickness, module, diameter and split ratio.
First, I fixed the module at 20, 25, 30, 36 and 40, and changed the wheel blank thickness from 1.2 to 3.0 times the tooth height. The maximum \(z\)-direction deformation is listed in Table 6.
| Thickness / tooth height | \(m=20\) | \(m=25\) | \(m=30\) | \(m=36\) | \(m=40\) |
|---|---|---|---|---|---|
| 1.2 | 0.265 | 0.323 | 0.387 | 0.425 | 0.448 |
| 1.3 | 0.348 | 0.432 | 0.519 | 0.625 | 0.668 |
| 1.325 | 0.351 | 0.436 | 0.523 | 0.628 | 0.671 |
| 1.4 | 0.322 | 0.398 | 0.479 | 0.574 | 0.631 |
| 1.5 | 0.257 | 0.319 | 0.383 | 0.459 | 0.505 |
| 1.6 | 0.199 | 0.269 | 0.297 | 0.357 | 0.397 |
| 1.8 | 0.136 | 0.167 | 0.200 | 0.241 | 0.267 |
| 2.0 | 0.107 | 0.124 | 0.148 | 0.177 | 0.194 |
| 2.4 | 0.066 | 0.081 | 0.097 | 0.116 | 0.127 |
| 3.0 | 0.045 | 0.056 | 0.068 | 0.081 | 0.090 |
The results show that the deformation first increases with the thickness, reaches a maximum at about 1.325 times the tooth height, and then decreases rapidly. After the thickness ratio exceeds 1.8, the rate of decrease becomes small. Therefore, from both economic and deformation-control points of view, a wheel blank thickness of about 1.8 times the tooth height is recommended.
Next, I studied the effect of the split ratio. The split ratio is defined as the number of teeth on one split body divided by the total number of teeth of the straight bevel gear. For a gear with a fixed diameter, different total tooth numbers and different split ratios were considered. Some representative results are listed in Table 7.
| Total teeth | Module | Split ratio (teeth on split body) | Deformation (mm) |
|---|---|---|---|
| 70 | 40 | 1/7(10), 1/10(7), 3/35(6), 1/14(5), 2/35(4) | 0.777, 0.363, 0.267, 0.183, 0.119 |
| 80 | 40 | 3/20(12), 1/10(8), 3/40(6), 1/16(5), 1/20(4) | 1.130, 0.477, 0.266, 0.183, 0.119 |
| 90 | 40 | 1/6(15), 1/10(9), 1/15(6), 1/18(5), 2/45(4) | 1.812, 0.604, 0.267, 0.183, 0.119 |
| 100 | 36 | 3/20(15), 1/10(10), 1/15(6), 1/20(4) | 1.598, 0.647, 0.239, 0.108 |
It is found that the deformation strongly depends on the number of teeth contained in one split body. When the number of teeth is smaller than eight, the deformation is relatively small and increases slowly with the tooth number. When the number exceeds eight, the deformation grows dramatically. Therefore, it is recommended that a split body of an oversize straight bevel gear should contain five to eight teeth. This range provides a good compromise between small deformation and acceptable assembly complexity.
5. Experimental Verification
5.1 Generation of NC machining code
To verify the analytical and numerical models, I carried out an actual cutting experiment on a split wheel blank made of the same aluminium alloy. The process plan included rough milling and finish milling. A three-axis vertical CNC machine tool was used. The gear tooth space was machined with a cylindrical end mill of diameter 10 mm in the rough stage and a ball-end mill of diameter 8 mm in the finish stage. The spindle speed was 1200 rev/min. The depth of cut was 0.2 mm for roughing and 0.1 mm for finishing.
I prepared the machining programme in the UG CAM module. The three-dimensional model of the split straight bevel gear was imported into UG. In the machining environment, I defined the machining coordinate system, blank geometry, part geometry, cutting tools, and cutting parameters. Tool paths were generated for both roughing and finishing. After verifying the tool path simulation, I used the post-processor to produce the NC code. A short excerpt of the generated code is:
N0010 G40 G17 G90 G71
N0020 G91 G28 Z0.0
N0030 T01 M06
N0040 G00 G90 X-128.6662 Y-591.4247 S0 M03
N0050 G43 Z10.
N0060 Z2.8
N0070 G01 Z-.2 F250. M08
...
Before running the actual machining, I verified the NC program in VERICUT. The machine model and the cutting tools were created in the software environment. The simulation showed that neither tool collision nor over-cut occurred during the machining process. The simulated final shape was consistent with the CAD model.
5.2 Machining experiment and CMM measurement
Prior to cutting, the split wheel blank was measured with a coordinate measuring machine (CMM). The measurement was performed four times: before cutting, after cutting the middle tooth space, after cutting the right half, and after the whole gear was finished. The CMM measured the coordinates of points on the upper surface, the two end faces, and the inner and outer cylindrical surfaces. From these coordinates, the profile tolerances and the diameter changes were calculated automatically.
The measured values are summarised in Table 8. The initial outer and inner diameters of the split blank were designed as 1200 mm and 1000 mm. The nominal angle between the two end faces was 36°.
| Measurement stage | Upper surface parallelism (mm) | Left end verticality (mm) | Right end verticality (mm) | Outer diameter (mm) | Inner diameter (mm) | End face angle (deg) |
|---|---|---|---|---|---|---|
| Before cutting | 0.038 | 0.016 | 0.016 | 1200.001 | 1000.001 | 36.009 |
| After middle tooth space | 0.077 | 0.019 | 0.017 | 1200.028 | 1000.002 | 36.005 |
| After right half | 0.121 | 0.026 | 0.025 | 1200.049 | 1000.049 | 35.996 |
| After full machining | 0.161 | 0.031 | 0.028 | 1200.072 | 1000.071 | 35.989 |
From Table 8, it can be seen that the outer and inner diameters gradually increase during machining. The increase is about 0.070 mm after full machining, which means that the split body moves about 0.035 mm in the \(y\)-direction. This is consistent with the finite element prediction. The angle between the two end faces decreases by about 0.02 degrees, indicating a slight twist or opening deformation. The verticality tolerances also increase, but the upper surface parallelism shows the largest change. This is because the bending deformation in the \(z\)-direction is dominant.
5.3 Comparison between experiment and simulation
The CMM measurement showed that the maximum \(z\)-direction deformation of the split wheel blank after full machining was 0.137 mm. In my finite element simulation, the maximum \(z\)-direction deformation was 0.142 mm. The difference between the two values is about 0.005 mm, corresponding to a relative error of approximately 3.6%. The theoretical superposition model predicted 0.130 mm, which is lower than the experiment by about 5.1%. The small difference can be attributed to the simplification of the beam model and to the neglected deformation in the \(y\)-direction.
The comparison between the simulated and measured deformation distributions along the length is shown by the following data. At the left end, the deformation is nearly zero. The deformation increases towards the middle of the blank, reaches its maximum at the centre, and then decreases towards the right end. The experimental curve has the same tendency as the simulation curve. Therefore, both the finite element model and the analytical mapping model are reliable for predicting the machining deformation of an oversize split straight bevel gear.
6. Conclusion
In this thesis, I have systematically investigated the machining deformation mechanism of an oversize split straight bevel gear. The main conclusions are as follows.
(1) The equivalent bending stiffness of the split wheel blank during tooth cutting can be accurately calculated using the bending strain energy equivalence method. The stiffness decreases continuously with material removal. The position of the cut tooth space has a significant influence on the stiffness reduction. Cutting near the middle of the blank causes a faster stiffness drop.
(2) The finite element simulation with an initial residual stress field and element death technology can effectively reproduce the machining process of a split straight bevel gear. The stress evolution shows that the release of the \(x\)-direction residual stress is the main cause of the bending deformation.
(3) The proposed stiffness-stress-deformation mapping model is capable of predicting the deformation of the split wheel blank. The predicted final deformation of 0.1301 mm agrees well with the finite element result of 0.1304 mm. This model provides a theoretical basis for deformation control.
(4) The design parameters have clear influences on the deformation. The wheel blank thickness should be avoided at around 1.325 times the tooth height because the deformation is maximum there. A thickness of 1.8 times the tooth height is recommended. A split body containing five to eight teeth is suggested for a reasonable balance between deformation and assembly accuracy.
(5) The cutting experiment verified the correctness of the finite element model and the analytical model. The measured maximum deformation was 0.137 mm, which is close to the simulated value of 0.142 mm. The small error confirms that the proposed models are suitable for engineering applications.
Future work will focus on the influence of assembly errors and base machining errors on the meshing performance of the complete split straight bevel gear. The coupling of cutting deformation and assembly deformation should also be considered for more accurate precision control.