
Straight bevel gears represent fundamental components in modern mechanical transmission systems, serving critical roles in force and motion transfer between intersecting axes. The manufacturing and installation errors of straight bevel gears directly influence the precision and dynamic performance of mechanical systems, making the measurement, analysis, and evaluation of these errors a significant research focus in metrology. This dissertation presents a comprehensive investigation into the measurement and error evaluation technology of straight bevel gears, conducted on a CNC gear measuring center platform. The research encompasses the establishment of mathematical models for the tooth surface of straight bevel gears, design of measurement strategies, development of error evaluation software modules, and experimental validation of the proposed methodologies.
1. Introduction
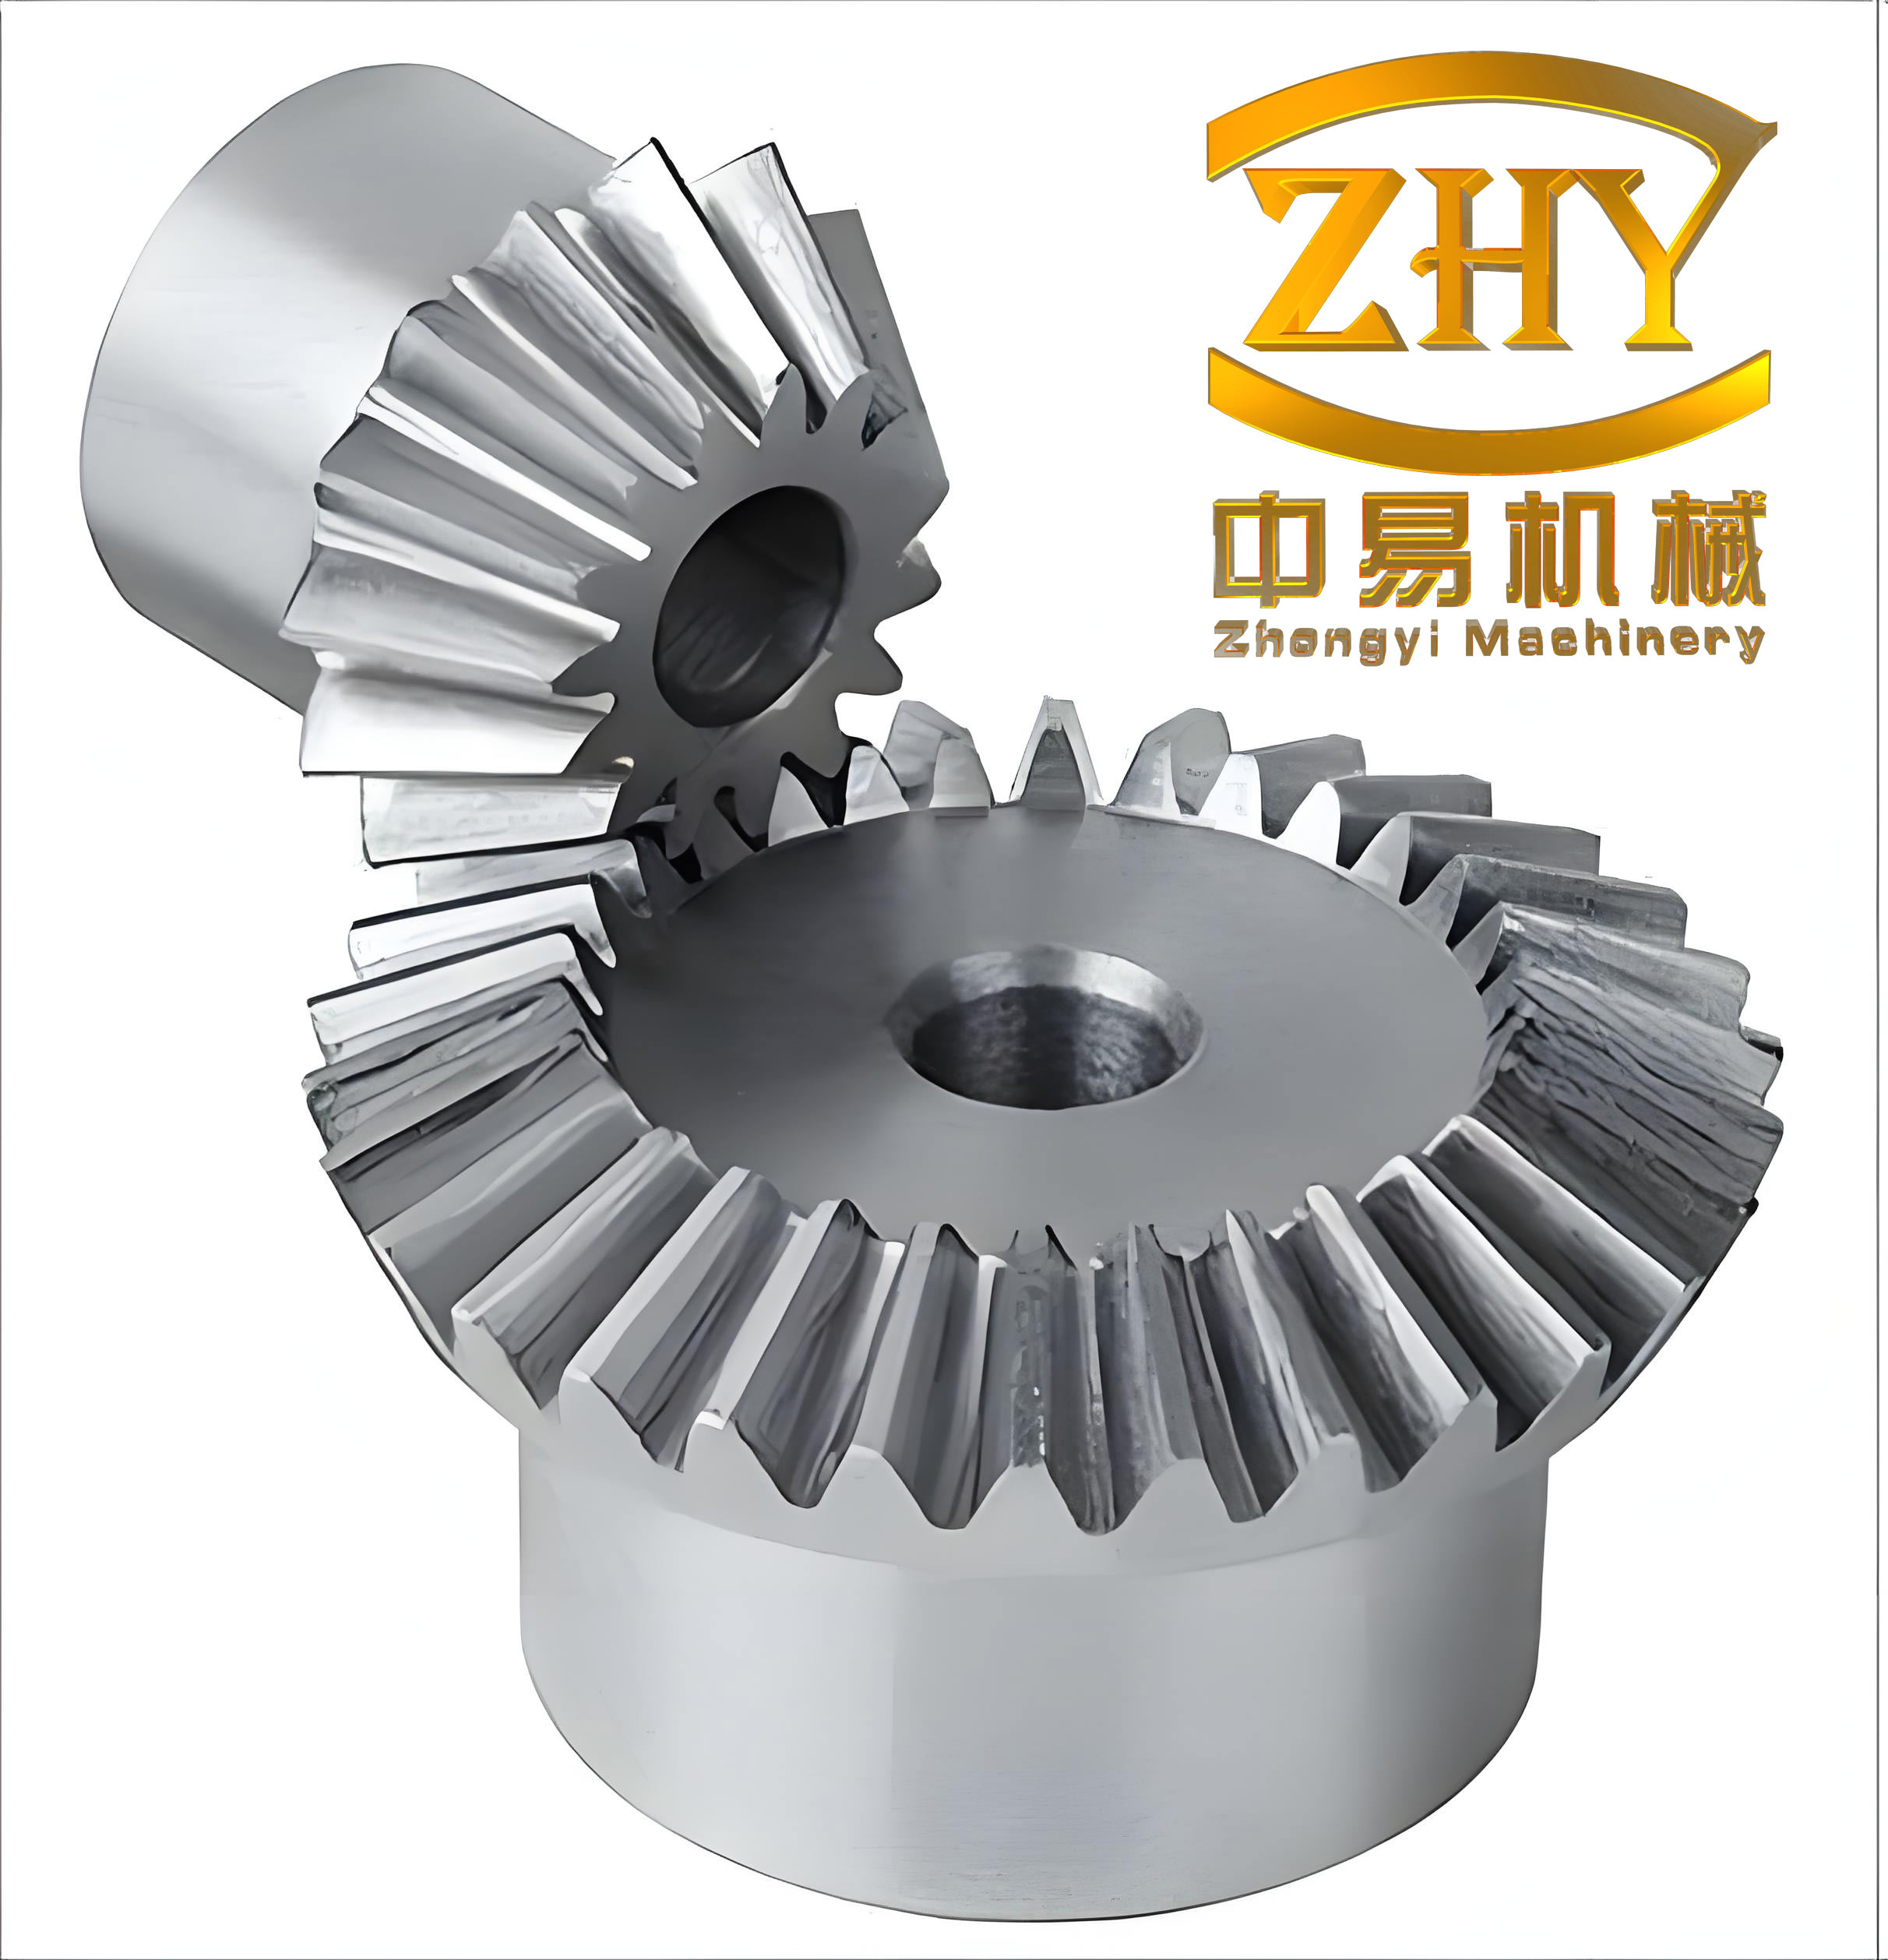
Gear transmission constitutes one of the most fundamental forms of mechanical power transmission, occupying a vital position in both mechanical manufacturing and instrumentation industries. With the rise of China’s equipment manufacturing sector, gear production has experienced unprecedented growth. Among various gear types, the straight bevel gear finds extensive application in intersecting axis transmission systems due to its relatively simple manufacturing process compared to spiral bevel gears and its favorable characteristic of not generating axial forces during operation. However, the measurement and quality control of straight bevel gears present considerable challenges due to their complex tooth surface geometry.
The historical development of gear measurement technology spans nearly a century. Traditional gear measurement instruments relied on mechanical generating mechanisms to create reference trajectories, where the precision of the measurement motion directly limited the achievable measurement accuracy. The emergence of CNC (Computer Numerical Control) gear measuring centers represents a paradigm shift in this field, enabling rapid acquisition of comprehensive gear error information on a single instrument platform. These modern systems employ coordinate measurement principles, essentially transforming the measurement process into a “model-based measurement” approach where actual part coordinates are compared against ideal mathematical models.
The measurement of straight bevel gears has traditionally lagged behind cylindrical gear measurement due to the inherent geometric complexity of conical tooth surfaces. The ideal tooth profile of a straight bevel gear follows a spherical involute curve, which cannot be developed onto a plane surface. This fundamental geometric property complicates both the manufacturing and measurement processes. Current international advanced gear measuring centers, such as those produced by Klingelnberg, M&M Precision Systems, and Mahr, offer capabilities for measuring straight bevel gears with measurement uncertainty reaching 2 micrometers. However, these systems are prohibitively expensive, and stringent technology export controls are applied to ultra-precision models destined for the Chinese market.
In China, several manufacturers including Harbin Measuring & Cutting Tool Group and Harbin Jingda Company have developed domestic CNC gear measuring centers. The 3903A model developed by Harbin Measuring & Cutting Tool Group has achieved measurement accuracy and speed approaching international standards, receiving industry recognition at major exhibitions. Despite these advances, gaps remain in Software functionality, measurement repeatability, and long-term stability compared to leading international products. This situation underscores the importance of developing indigenous measurement technology and error evaluation methodologies for straight bevel gears.
The primary objectives of this research are as follows:
- Establish the mathematical model of straight bevel gear tooth surfaces, including surface equations and normal line equations.
- Develop measurement strategies for straight bevel gears on CNC gear measuring centers, including probe path planning and zero position setting.
- Investigate error evaluation methods for various individual errors including tooth profile deviation, helix deviation, pitch deviation, and radial run-out error.
- Develop error evaluation software modules capable of computing these errors from raw measurement data.
- Validate the proposed methodologies through actual measurement experiments on a CNC gear measuring center.
2. Mathematical Model of Straight Bevel Gear Tooth Surface
2.1 Fundamentals of Straight Bevel Gear Geometry
Straight bevel gears transmit motion and power between intersecting shafts, with the shaft angle typically being 90 degrees in standard configurations. The tooth profile of a straight bevel gear theoretically conforms to a spherical involute curve. To understand the formation of the tooth surface, we must consider the kinematic generation process. As illustrated in the fundamental theory of gear geometry, when a circular plane S rolls purely over the base cone surface, any straight line OB passing through the center O of the plane generates an involute conical surface in space. This involute conical surface constitutes the tooth flank of the straight bevel gear. The intersection of this surface with the sphere centered at O with radius equal to the cone distance yields the spherical involute curve, which represents the theoretical large-end tooth profile.
Due to the mathematical complexity associated with spherical involutes and the impossibility of developing spherical surfaces onto planes, engineering practice employs an approximation method using the concept of the back cone and equivalent gear. The back cone is tangent to the pitch cone at the large-end pitch circle, and the tooth profile projected onto the back cone closely approximates the spherical involute. When this back cone is developed onto a plane, it yields a sector gear whose tooth profile can be analyzed using cylindrical gear theory. This equivalent cylindrical gear, with radius equal to the back cone distance, serves as the basis for the measurement and evaluation of straight bevel gear tooth profiles.
In this research, measurement of the tooth profile deviation of straight bevel gears is conducted on this equivalent gear’s involute profile. The various dimensional parameters of a straight bevel gear, such as pitch cone angle, root cone angle, face cone angle, cone distance, and tooth width, are interrelated. As shown in the important parameters table below:
| Parameter | Symbol | Relationship |
|---|---|---|
| Pitch cone angle | δ₀ | For 90° shaft angle: tan δ₀ = z₁/z₂ |
| Root cone angle | δf | δf = δ₀ − θf |
| Root angle | θf | tan θf = hf/R |
| Pitch cone distance | R | R = mz/(2 sin δ₀) |
| Back cone distance | Rv | Rv = R tan δ₀ (for large end) |
2.2 Tooth Surface Equation Derivation
For the mathematical modeling of straight bevel gear tooth surfaces, this research establishes a spatial rectangular coordinate system with the origin at the center of the large-end root circle, the XOY plane coinciding with the root circle plane, and the Z-axis directed from the large end toward the small end along the gear axis. The derivation considers both the left and right tooth flanks separately.
Left tooth flank equation: The involute curve formed by unwrapping a line from the base circle can be expressed through the involute function. For a point K on the involute with polar radius rk and polar angle θk, the involute equation is given by:
$$ r_k = \frac{r_b}{\cos \alpha_k} $$
$$ \theta_k = \tan \alpha_k – \alpha_k $$
where rb is the base circle radius and αk is the pressure angle at point K. In the straight bevel gear context, the base circle radius at any point along the tooth is related to the cone geometry. Using the geometric relationships within the axial section of the straight bevel gear, the Z-coordinate of any point on the tooth surface can be expressed as:
$$ z = \frac{R \cos \theta_f}{\cos \delta_f} \cos \delta_f – r \cos \delta = R \cos \theta_f – r \cos \delta $$
where r is the cone distance from the apex to the point, δ is the cone angle at that point, θf is the root angle, δf is the root cone angle, and R is the pitch cone distance. The relationship between the base circle radius at any point and the cone geometry is:
$$ r_{k} = r \sin \delta $$
The pressure angle αk at any point on the involute conical surface can be determined from the geometric relationship:
$$ \cos \alpha_k = \frac{r_b}{r_k} = \frac{r \sin \delta_f \cos \delta_f / \cos \delta_f}{r \sin \delta} = \frac{\sin \delta_f}{\sin \delta} $$
Consequently,
$$ \alpha_k = \arccos \left( \frac{\sin \delta_f}{\sin \delta} \right) = \arccos(\cot \delta_f \cdot \tan \delta) $$
Utilizing trigonometric identities, the polar angle θk can be expressed as a function of the cone angles:
$$ \theta_k = \tan \alpha_k – \alpha_k = \frac{\tan \delta_f}{\sqrt{1 – (\tan \delta_f / \tan \delta)^2}} – \arccos\left(\frac{\tan \delta_f}{\tan \delta}\right) $$
Combining these equations yields the left tooth flank equation in cylindrical coordinates:
$$ \begin{cases} r_k = r \sin \delta \\ \theta_k = \frac{\tan \delta_f}{\sqrt{1 – \tan^2\delta_f/\tan^2\delta}} – \arccos(\tan\delta_f/\tan\delta) \\ z = R \cos\theta_f – r\cos\delta \end{cases} $$
Transforming to rectangular coordinates with the x-axis aligned with the starting point of the involute:
$$ \begin{cases} x = r \sin\delta \cos\theta_k \\ y = r \sin\delta \sin\theta_k \\ z = R \cos\theta_f – r\cos\delta \end{cases} $$
Right tooth flank equation: The right flank equation can be derived through coordinate rotation transformation from the left flank. By establishing a coordinate system with the z-axis in the opposite direction (toward the apex), the right flank equation in cylindrical coordinates takes a similar form:
$$ \begin{cases} r_k = r \sin \delta \\ \theta_k = \frac{\tan \delta_f}{\sqrt{1 – \tan^2\delta_f/\tan^2\delta}} – \arccos(\tan\delta_f/\tan\delta) \\ z = -R \cos\theta_f + r\cos\delta \end{cases} $$
Applying the coordinate transformation to a common reference frame yields the right tooth flank rectangular coordinate equation:
$$ \begin{cases} x = r \sin\delta \cos(\phi + \theta_k) \\ y = r \sin\delta \sin(\phi + \theta_k) \\ z = R \cos\theta_f – r\cos\delta \end{cases} $$
where φ represents the angular offset between the coordinate systems for left and right flanks.
2.3 Normal Line Equation
The unit normal vector at any point on the tooth surface is essential for probe radius compensation during measurement. For a parametric surface defined by position vector H(r,δ), the unit normal is computed from the cross product of the partial derivatives:
$$ \mathbf{n} = \frac{H_r \times H_\delta}{|H_r \times H_\delta|} $$
For the left tooth flank, the partial derivatives with respect to r and δ are:
$$ H_r = \begin{bmatrix} \sin\delta\cos\theta_k \\ \sin\delta\sin\theta_k \\ -\cos\delta \end{bmatrix} $$
$$ H_\delta = \begin{bmatrix} r\cos\delta\cos\theta_k – r\sin\delta\sin\theta_k\frac{\partial\theta_k}{\partial\delta} \\ r\cos\delta\sin\theta_k + r\sin\delta\cos\theta_k\frac{\partial\theta_k}{\partial\delta} \\ r\sin\delta \end{bmatrix} $$
The derivative of θk with respect to δ can be determined from the polar angle expression. Following the complete derivation process, the unit normal vector for the left flank is obtained. Similarly, for the right tooth flank, the corresponding partial derivatives and unit normal vector are derived. These normal vectors play a critical role in converting measured probe center coordinates to actual contact point coordinates on the tooth surface.
2.4 Visualization Simulation
To validate the mathematical model, a MATLAB-based visualization simulation was performed. Using the following gear parameters as an example:
| Parameter | Value | Unit |
|---|---|---|
| Module | 9.222 | mm |
| Number of teeth | 10 | – |
| Face width | 24 | mm |
| Pitch cone angle | 32° | deg |
| Root cone angle | 27°23′ | deg |
| Face cone angle | 39°20′ | deg |
| Pressure angle | 20°30′ | deg |
| Pitch cone distance | 87 | mm |
The three-dimensional rendering of the tooth surfaces confirmed the correctness of the mathematical model through visual inspection across multiple viewpoints, validating the tooth surface equations for both left and right flanks of the straight bevel gear.
3. Measurement Technology of Straight Bevel Gears
3.1 Measurement Principles and CNC Gear Measuring Center
The measurement approach employed in this research is based on the principle of electronic generating. In contrast to traditional mechanical generating instruments where the measurement motion is produced by high-precision mechanical mechanisms, the CNC gear measuring center utilizes computer-controlled servo drives to generate the required relative motion between the probe and the workpiece. The fundamental advantage of this approach lies in the error separation principle: the measurement accuracy is not directly dependent on the precision of the motion trajectory itself. Instead, the actual trajectory is continuously measured using precision transducers (linear and rotary encoders), and the collected coordinate data are processed mathematically to obtain the actual tooth surface coordinates.
The CNC gear measuring center structure comprises three mutually perpendicular linear axes (X, Y, Z) and a rotary axis (W). Each axis is equipped with precision encoders: linear gratings for the linear axes and a circular grating coaxially mounted with the spindle for angular measurement. The workpiece is mounted on the spindle, and a micro-displacement sensor (probe) is mounted on the Y-axis slide. The CNC system coordinates multi-axis motion to achieve the desired measurement trajectory while the data acquisition system simultaneously records probe deflections and axis positions.
The hardware platform used in this research is the 3906 model CNC gear measuring center manufactured by Harbin Measuring & Cutting Tool Group. This system supports four-axis linkage control and provides the precision required for straight bevel gear measurement.
3.2 Measurement Path Planning
The measurement strategy for straight bevel gears in this research covers four key error items: tooth profile deviation, helix deviation, pitch deviation, and radial run-out error. Each measurement item requires a distinct measurement path:
- Tooth profile deviation: Measured on the equivalent cylindrical gear. The probe trajectory lies in a plane perpendicular to the pitch cone generatrix. Different Z coordinates correspond to different equivalent radii on the involute profile.
- Helix deviation: Measured on the pitch circle. The probe moves along the pitch cone generatrix from the large end to the small end of the tooth.
- Pitch deviation: Measured at the midpoint of the face width. For each tooth flank, one measurement point is acquired. To ensure computational accuracy, the final tooth measured is the first tooth (i.e., the first tooth is measured twice).
- Radial run-out: Can be measured simultaneously with pitch deviation. A small-diameter probe moves within the tooth space, contacting both flanks at the pitch circle, and the ball center position is calculated.
The critical aspect in measurement initialization is determining the coordinates (x, y, z) of the first measurement point at the pitch circle on the midpoint of the face width, which is derived from the gear parameters and the established instrument coordinate system.
3.3 Zero Position Setting
Before measurements can proceed, the instrument coordinate system must be established. In the traditional approach used with the 3906 gear measuring center, two procedures are required: cone apex positioning and zero setting. The cone apex positioning involves first calibrating the Z-coordinate using a standard sphere, then measuring the mounting reference surface to determine the apex position based on the gear’s mounting distance parameter. Following apex positioning, the probe is rotated to have its measuring force in the horizontal direction, and calibration against the standard sphere provides the X and Y coordinates of the spindle axis.
In the improved scheme developed in this research, only a single zero setting procedure is required. The probe is installed with its measuring force in the horizontal direction. During zero setting, the probe is positioned in front of the standard sphere and automatically measures a series of points on the sphere surface. Data fitting yields the sphere center coordinates in X and Y, enabling determination of the spindle axis coordinates. The Z-coordinate of the sphere center serves as the Z-axis zero reference. This simplified procedure establishes the instrument coordinate system entirely, after which all individual error measurements can proceed.
3.4 Probe Radius Compensation
During tooth profile measurement, the probe center moves within a measurement plane. However, due to the spiral nature of the tooth surface, the contact point trajectory does not remain within this plane. To determine the actual tooth profile errors, probe radius compensation must be applied. This research employs the contact point trajectory method, based on the principle that the actual contact point lies along the direction of the surface normal from the probe center. The compensation relationship is:
$$ \begin{cases} x_i = x_i’ + \Delta\rho_{xi} \\ y_i = y_i’ + \Delta\rho_{yi} \\ z_i = z_i’ + \Delta\rho_{zi} \end{cases} $$
where the compensation components are computed as:
$$ \Delta\rho_{xi} = R \cdot n_{xi}, \quad \Delta\rho_{yi} = R \cdot n_{yi}, \quad \Delta\rho_{zi} = R \cdot n_{zi} $$
In these equations, (x′i, y′i, z′i) represents the measured probe center coordinates, (xi, yi, zi) represents the actual contact point coordinates on the tooth surface, R is the probe ball radius, and (nxi, nyi, nzi) are the components of the unit normal vector at the contact point, as derived in the mathematical model of the tooth surface.
4. Error Evaluation Technology for Straight Bevel Gears
4.1 Tooth Profile Deviation Evaluation
Tooth profile deviation is evaluated on the equivalent cylindrical gear of the straight bevel gear. According to the GB/T10095.1-2001 standard, profile deviations are classified into three categories:
- Total profile deviation (Fα): The distance between two design profile lines that enclose the actual profile trace within the evaluation range.
- Profile form deviation (ffα): The distance between two curves, identical to the mean profile trace, enclosing the actual profile trace within the evaluation range, where both curves are at constant distance from the mean profile trace.
- Profile slope deviation (fHα): The distance between two design profile lines intersecting the mean profile trace at the ends of the evaluation range.
The evaluation process begins with computing the deviation values at each measurement point. The profile total deviation equals the difference between the maximum and minimum deviation values within the evaluation range. For the form and slope deviations, linear regression (least squares method) is applied to determine the mean profile trace. The mean profile trace is obtained by subtracting a straight line from the design profile trace ordinates, where this straight line minimizes the sum of squares of the actual profile trace deviations from the mean profile trace. The mathematical representation of this least squares problem is:
$$ \min_{a,b} \sum_{i=1}^{n} [y_i – (a + b \cdot x_i)]^2 $$
where yi are the individual deviation values, xi are the corresponding positions along the evaluation range, and the fitted line y = a + bx defines the mean profile trace orientation and position.
4.2 Helix Deviation Evaluation
For the straight bevel gear, helix deviation is evaluated on the pitch circle. During measurement, the probe traverses along the pitch cone generatrix from the large end to the small end of the gear tooth, acquiring a series of coordinate values along the helix line. The evaluation follows the same general framework as profile deviation, with three categories: total helix deviation (Fβ), helix form deviation (ffβ), and helix slope deviation (fHβ).
The normal deviation at each measurement point is calculated, and the deviations are plotted against the corresponding face width positions. The total helix deviation is determined as the difference between maximum and minimum deviation values. The helix form and slope deviations require computing the mean helix trace through least squares regression, analogous to the profile deviation evaluation procedure. The table below summarizes the definitions for both tooth profile and helix deviations:
| Deviation Type | Symbol | Definition |
|---|---|---|
| Total profile deviation | Fα | Distance between two design profile lines enclosing the actual profile trace |
| Profile form deviation | ffα | Distance between two curves identical to mean profile trace enclosing the actual trace |
| Profile slope deviation | fHα | Distance between two design profile lines at evaluation range ends |
| Total helix deviation | Fβ | Distance between two design helix lines enclosing the actual helix trace |
| Helix form deviation | ffβ | Distance between two curves identical to mean helix trace enclosing the actual trace |
| Helix slope deviation | fHβ | Distance between two design helix lines at evaluation range ends |
4.3 Pitch Deviation Evaluation
Pitch deviation is one of the most critical parameters for evaluating the quality of straight bevel gears, reflecting the uniformity of tooth distribution on the pitch circle. Pitch measurements are taken at the midpoint of the face width, providing data for computing several related errors: single pitch deviation (fpt), k-pitch cumulative deviation (Fpk), and total cumulative pitch deviation (Fp).
The evaluation process begins by determining the measurement circle radius rm based on the first measurement point. The theoretical pitch arc length on this measurement circle is:
$$ P_s = \frac{2\pi r_m}{z} $$
where z is the number of teeth of the straight bevel gear. The actual angular increment between successive tooth flanks is computed from the measured angular positions:
$$ \Delta\theta_i = \theta_i – \theta_{i-1}, \quad i = 2, 3, \ldots, n $$
The single pitch deviation for each tooth space is then:
$$ f_{pti} = r_m \cdot \Delta\theta_i – P_s, \quad i = 2, 3, \ldots, n $$
The first tooth is measured twice (as the last tooth) to verify measurement consistency. The k-pitch cumulative deviation is computed as:
$$ F_{pki} = \sum_{j=i}^{i+k-1} f_{ptj} = \sum_{j=i}^{i+k-1} (r_m \cdot \Delta\theta_j – P_s) $$
And the total cumulative pitch deviation is:
$$ F_p = \sum_{i=1}^{n} f_{pti} $$
Since the measurement is over a full revolution, the total cumulative pitch deviation will sum to approximately zero; the actual maximum cumulative deviation is found by the maximum excursion of the cumulative deviation curve. The table below shows structure of pitch deviation data for n teeth:
| Tooth No. | Angular Position θi | Δθi (rad) | fpt (μm) | Fp (μm) |
|---|---|---|---|---|
| 1 | 0 | – | – | 0 |
| 2 | θ2 | Δθ2 | fpt2 | Fp2 |
| … | … | … | … | … |
| n | θn | Δθn | fptn | Fpn |
| n+1 (=1) | θ1+2π | Δθn+1 | fpt(n+1) | Fp(n+1) |
4.4 Radial Run-out Error Evaluation
Radial run-out error (Fr) of the straight bevel gear is defined as the maximum variation in the position of a measuring probe relative to the gear axis when the probe contacts both flanks of the tooth space at the pitch circle, measured in the direction perpendicular to the pitch cone generatrix. This error primarily reflects eccentricity in the gear blank mounting or cutter spindle during manufacturing.
On the CNC gear measuring center, the radial run-out of straight bevel gear can be measured simultaneously with pitch deviation. A relatively small diameter probe is positioned within the tooth space, and both left and right flanks are measured at the pitch circle. The ball center position at each tooth space is recorded, and the radial run-out error is calculated as the difference between the maximum and minimum radial positions of these ball centers across one complete revolution of the gear. Mathematically:
$$ F_r = R_{max} – R_{min} $$
where Rmax and Rmin are the maximum and minimum distances from the gear rotation axis to the ball center positions. The first tooth space radial reading serves as the reference, and subsequent readings are expressed as deviations from this reference value.
5. System Software Design and Measurement Experiments
5.1 Software Architecture
The error evaluation software for straight bevel gears was developed in the Visual Basic 2005 programming environment. This development platform offers the advantages of rapid application development, comprehensive user interface design tools, and robust runtime performance through the .NET framework. The software architecture follows a modular design philosophy, enhancing maintainability and extensibility. The system includes the following functional modules:
- Geometric parameter input module: Receives the basic parameters of the straight bevel gear, including module, number of teeth, face width, pressure angle, cone angles, cone distance, and mounting distance.
- Measurement control module: Coordinates the motion of the CNC gear measuring center axes to execute the planned measurement paths for each error item.
- Data acquisition module: Collects and synchronizes probe readings with axis position feedback from the linear and rotary encoders.
- Data processing module: Performs coordinate transformations, probe radius compensation, and computation of deviation values at each measurement point.
- Error evaluation module: Implements the least squares based algorithms for computing tooth profile deviation, helix deviation, pitch deviation, and radial run-out according to the national standards.
- Graphical display module: Generates deviation curve plots for visual analysis of measurement results.
The system software flow proceeds as follows: the operator enters the straight bevel gear parameters, the system verifies the zero position and establishes the instrument coordinate system, the operator selects the measurement items, and the CNC systems execute the corresponding measurement paths. Following data acquisition, the error evaluation module processes the measurement data and displays the deviation curves and computed error values.
5.2 Measurement Experiments and Results
To validate the feasibility of the developed error evaluation software and the overall measurement methodology, experiments were conducted on the CNC gear measuring center using the straight bevel gear specimen with the following parameters:
| Parameter | Value | Unit |
|---|---|---|
| Module | 9.222 | mm |
| Number of teeth | 10 | – |
| Face width | 24 | mm |
| Pitch cone angle | 32° | deg |
| Root cone angle | 27°23′ | deg |
| Face cone angle | 39°20′ | deg |
| Pressure angle | 20°30′ | deg |
| Pitch cone distance | 87 | mm |
| Mounting distance | 80.04 | mm |
| Outside diameter | 100 | mm |
Tooth profile deviation measurement: The probe was positioned at the mid-face width position and driven along the direction perpendicular to the pitch cone generatrix. Measurement data were collected and processed by the error evaluation software. The profile deviation curve was generated, showing the variation of deviation values along the roll length of the involute profile. The computed profile error results are presented in the table below:
| Error Item | Symbol | Value (μm) |
|---|---|---|
| Total profile deviation | Fα | 77.6 |
| Profile form deviation | ffα | 37.0 |
| Profile slope deviation | fHα | 61.4 |
Helix deviation measurement: The probe was positioned on the pitch circle and traversed along the pitch cone generatrix from the large end toward the small end of the straight bevel gear tooth. The helix deviation curve showed the variation of normal deviations along the face width. The computed helix error results are:
| Error Item | Symbol | Value (μm) |
|---|---|---|
| Total helix deviation | Fβ | 26.2 |
| Helix form deviation | ffβ | 19.1 |
| Helix slope deviation | fHβ | 11.6 |
Pitch deviation measurement: The measurements were conducted at the midpoint of the face width on both left and right tooth flanks. The first tooth was measured at both the beginning and end of the measurement cycle to verify consistency. The single pitch deviation curves and cumulative pitch deviation curves were generated for both flanks. The computed pitch deviation results are:
| Error Item | Left Flank (μm) | Right Flank (μm) |
|---|---|---|
| Total cumulative pitch deviation Fp | 70.0 | 45.6 |
| 3-tooth cumulative deviation Fpk | 70.2 | 52.0 |
| Single pitch deviation fpt | 30.4 | 32.5 |
| Tooth position of max fpt | 0 | 7 |
| Tooth position of max Fpk | 1–3 | 4–6 |
Radial run-out error measurement: The radial run-out error of the straight bevel gear was evaluated from the pitch measurement data. The probe contacted both flanks of each tooth space at the pitch circle, and the ball center positions were recorded for all tooth spaces. The radial run-out deviation curve showed the variation of radial deviations across all tooth spaces. The computed radial run-out error for the straight bevel gear is:
| Error Item | Symbol | Value (μm) |
|---|---|---|
| Radial run-out error | Fr | 3.5 |
The measurement results obtained with the developed error evaluation software were compared to the results obtained from the measurement validation system of the instrument manufacturer. The comparison showed that the measurement results from the error evaluation software module developed in this research fell within the permissible tolerance range compared to the standard results, validating the correctness and feasibility of the proposed mathematical model, error evaluation methods, and measurement strategies for the straight bevel gear.
Conclusion
This dissertation presented a comprehensive investigation into the measurement and error evaluation technology of straight bevel gears on a CNC gear measuring center platform. The main contributions and conclusions of this research are summarized as follows:
- Mathematical modeling of straight bevel gear tooth surfaces: Based on the analysis of the formation principle of straight bevel gear tooth profiles, the tooth surface equations and normal line equations for both left and right flanks were established. The mathematical model was visualized using MATLAB simulation software, and the correctness of the model was validated through three-dimensional rendering of the tooth surfaces.
- Measurement scheme design: The measurement theory for straight bevel gears on CNC gear measuring centers was studied. Measurement path planning for each error item was accomplished, the zero position setting procedure was optimized, and the probe radius compensation method was investigated to convert measurement point coordinates to actual contact point coordinates.
- Error evaluation technology: The physical significance and national standards of various errors in straight bevel gears were studied, including tooth profile deviation, helix deviation, pitch deviation, and radial run-out error. An error evaluation model based on the least squares method was established, and corresponding error evaluation software modules were developed in the Visual Basic 2005 development environment.
- Experimental validation: Actual measurement experiments were conducted on a CNC gear measuring center, and the measurement data were processed using the developed software. The experimental results demonstrated that the tooth profile deviation, helix deviation, pitch deviation, and radial run-out error of the straight bevel gear could be evaluated accurately. The values obtained were within acceptable precision ranges when compared with the measurement results from an industry-standard measurement system, verifying the feasibility of the proposed methodologies.
The research presented in this dissertation contributes significantly to the development of gear measuring centers with independent intellectual property rights in China. The established mathematical model for straight bevel gear tooth surfaces and the error evaluation software provide a solid foundation for further advances in gear metrology. Future research directions may include extension of the measurement capabilities to spiral bevel gears and hypoid gears, implementation of three-dimensional tooth surface deviation analysis, and integration of process error diagnosis functionality into the measurement software suite.