
This paper presents a comprehensive study on the design, mathematical modeling, and machining technology of straight bevel gears manufactured with an inner concave cutter. The research aims to establish a complete technical solution for machining high-precision straight bevel gears on domestic CNC spiral bevel gear milling machines, breaking the technical monopoly of foreign companies. The work covers geometric parameter calculation, cutter parameter design, machine tool adjustment parameter computation, tooth surface mathematical modeling, tooth contact analysis (TCA), software development, and experimental verification.
1. Introduction
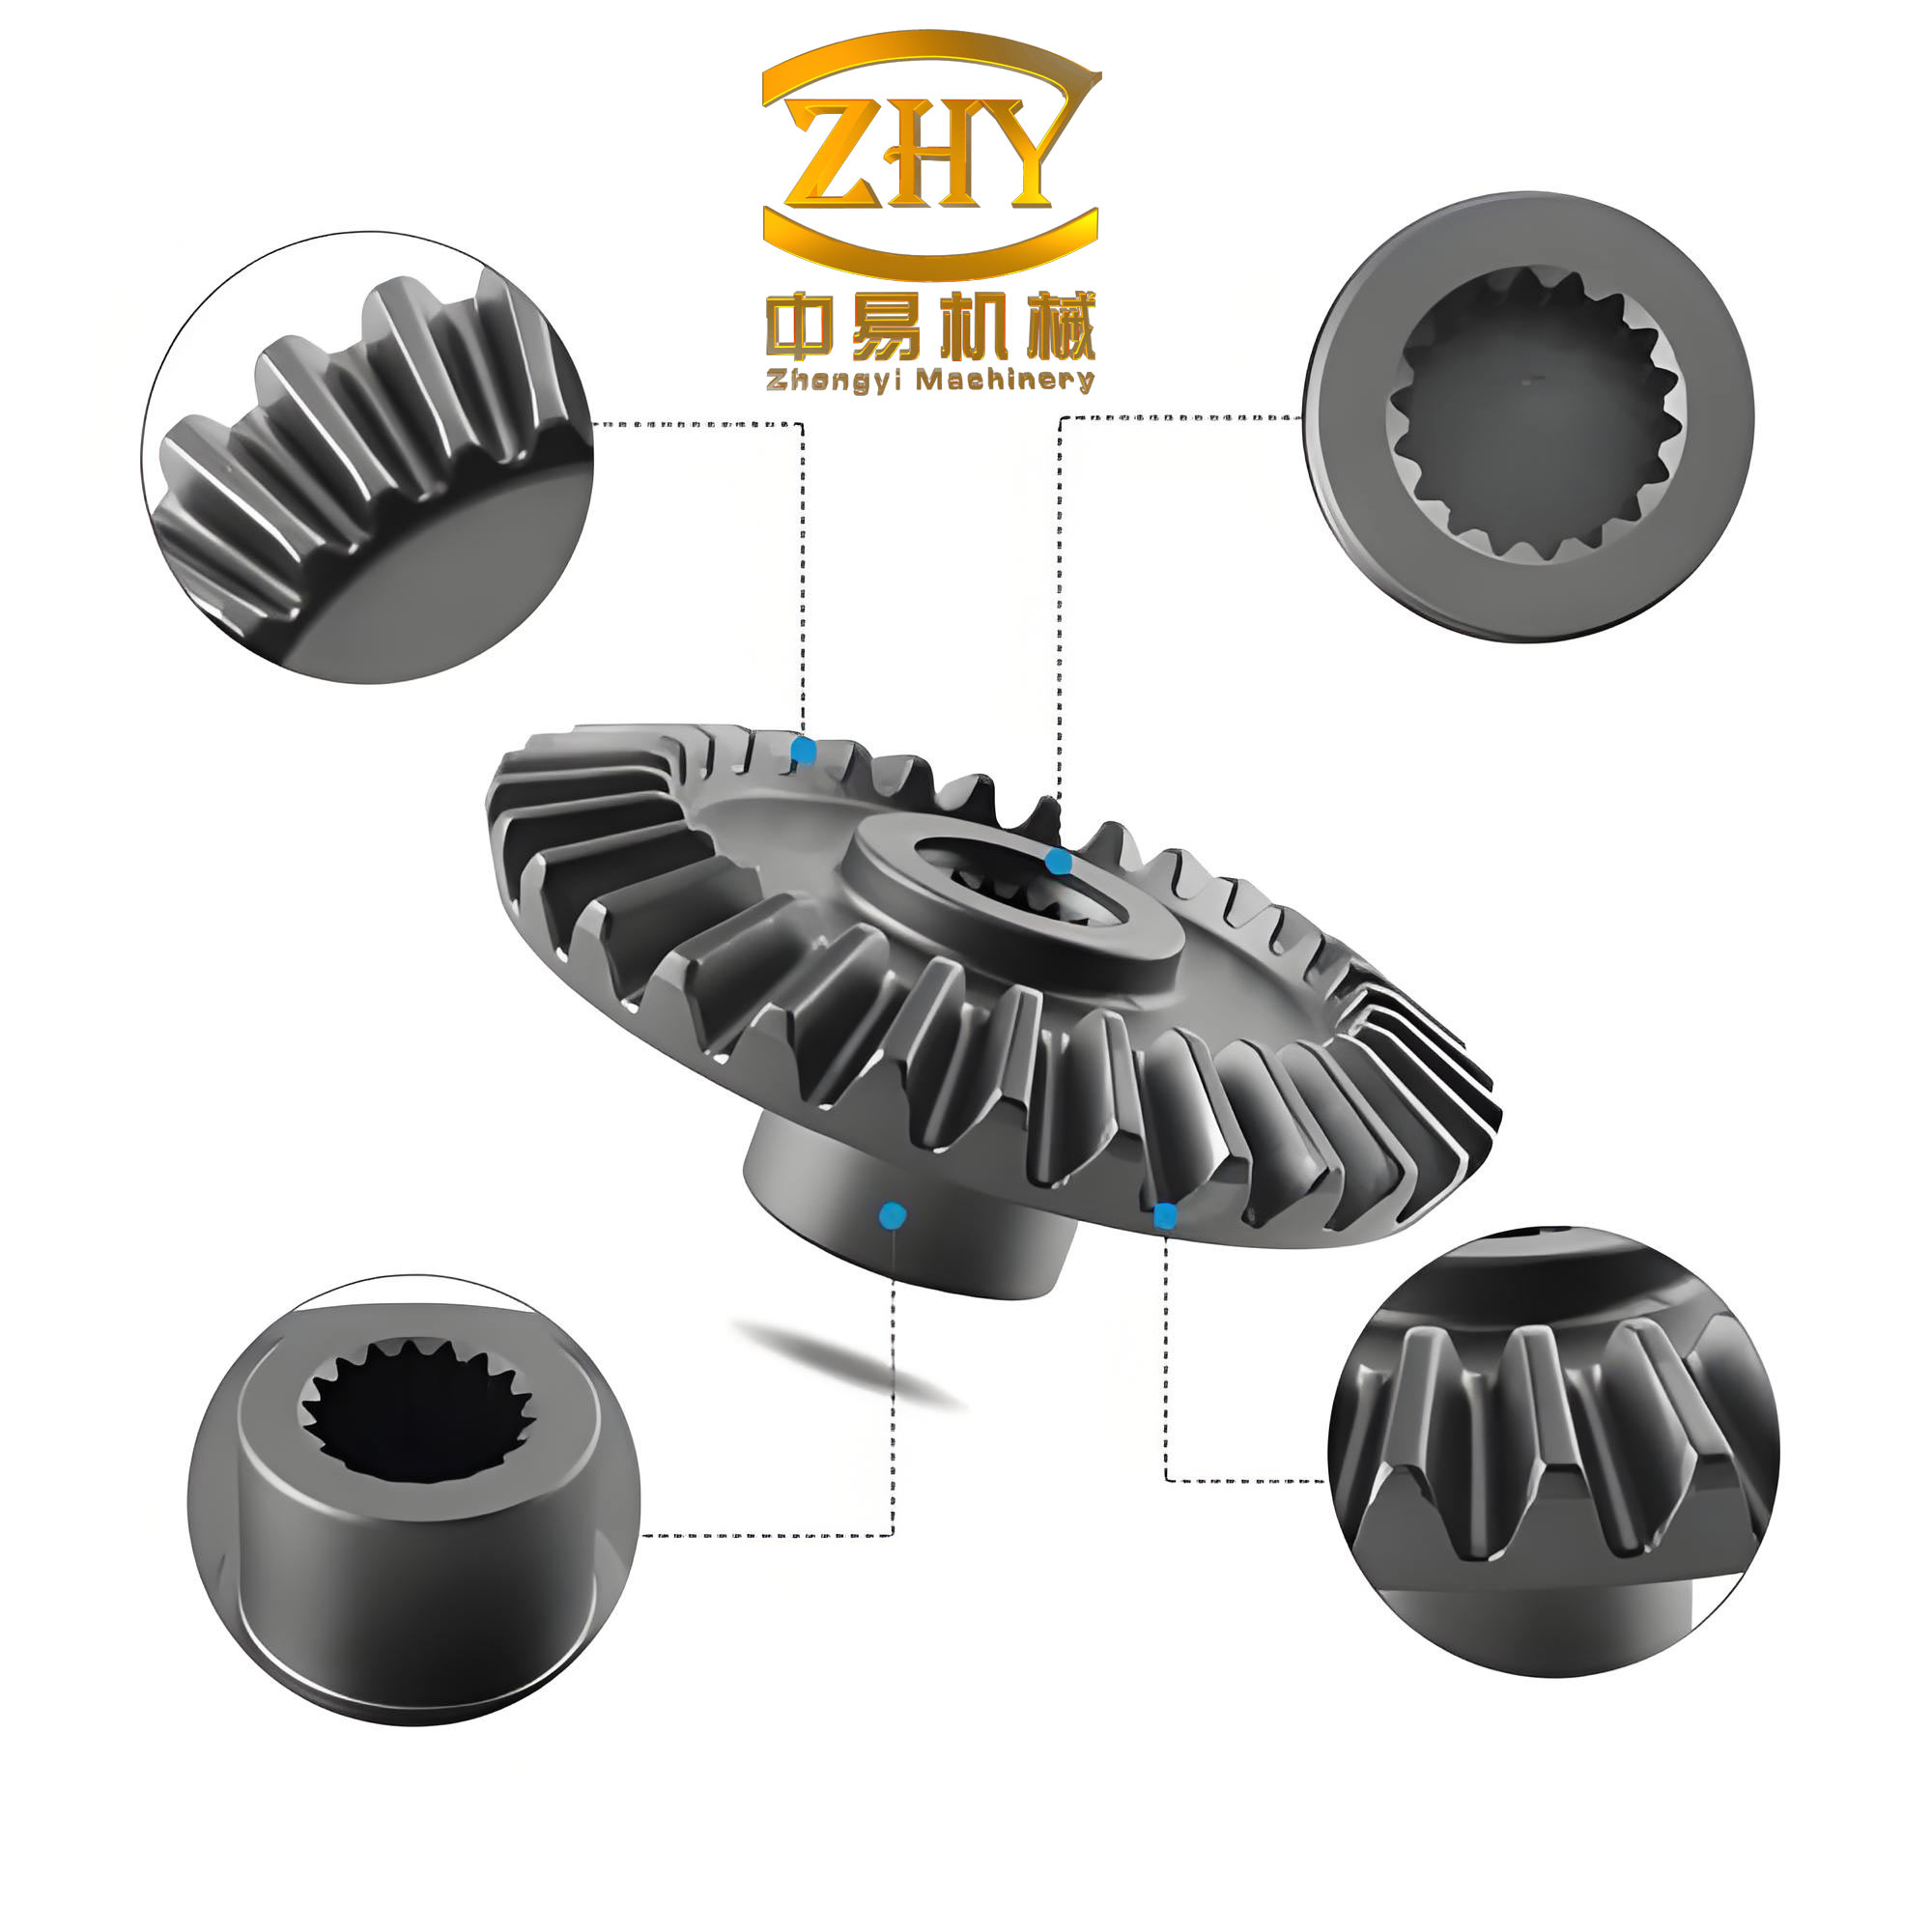
Gear transmission is one of the most important forms of mechanical transmission, and gears are core components in many mechanical products. Gears possess a series of advantages including compact structure, high transmission efficiency, accurate transmission ratio, and long service life. Among various gear types, straight bevel gears are widely used for power transmission between intersecting shafts, especially when the shaft angle is 90 degrees. Although spiral bevel gears and hypoid gears have developed rapidly, straight bevel gears still hold an irreplaceable position in aerospace, military defense, automotive, and engineering machinery fields due to their simpler design, easier manufacturing, and lower production cost.
Compared with the advanced machining technology of spiral bevel gears, the manufacturing of straight bevel gears remains relatively traditional. The commonly used methods include gear planing, gear milling, and gear pulling, which are performed on dedicated mechanical machines such as Y236 gear planing machines and Y2726 double-cutter straight bevel gear milling machines. These old machines rely on complex mechanical transmission chains, resulting in low precision, low efficiency, and difficult adjustment. In contrast, Gleason Company has successfully implemented the machining of straight bevel gears using an inner concave cutter on CNC spiral bevel gear machines, but the core technology is strictly confidential. To overcome this limitation, this research focuses on the principles and processing methods of machining straight bevel gears with an inner concave cutter on domestic CNC machines.
2. Geometric Parameter Design of Straight Bevel Gears
The design of straight bevel gears typically follows the standard at the large end. The primary geometric parameters include the large-end module \(m\), pressure angle \(\alpha\), face width \(b\), tip clearance \(c\), number of teeth \(z\), shaft angle \(\Sigma\), large-end pitch circle diameter \(d\), whole tooth height \(h\), addendum \(h_a\), dedendum \(h_f\), pitch angle \(\delta\), face angle \(\delta_a\), root angle \(\delta_f\), pitch cone distance \(R_e\), and crown-to-apex distance \(A_k\). These parameters directly affect the machining process and operating performance of straight bevel gears.
The geometric calculation is based on standard tooth proportions. For a pair of straight bevel gears with a shaft angle of 90°, the pitch angles are computed as:
$$ \tan \delta_1 = \frac{z_1}{z_2}, \qquad \delta_2 = 90^\circ – \delta_1 $$
The pitch cone distance is:
$$ R_e = \frac{d_1}{2\sin\delta_1} = \frac{d_2}{2\sin\delta_2} $$
The addendum and dedendum are functions of the module and the profile shift coefficients:
$$ h_{a1} = m(h_a^* + x_1), \qquad h_{a2} = m(h_a^* – x_1) $$
$$ h_{f1} = m(h_a^* + c^* – x_1), \qquad h_{f2} = m(h_a^* + c^* + x_1) $$
where \(h_a^*\) is the addendum coefficient, \(c^*\) is the tip clearance coefficient, and \(x_1\) is the profile shift coefficient for the pinion.
The root angle and face angle for equal-height teeth (or non-equal-height teeth) are calculated as shown in the following table:
| Parameter | Pinion | Gear |
|---|---|---|
| Large-end pitch diameter | \(d_1 = m z_1\) | \(d_2 = m z_2\) |
| Pitch angle | \(\delta_1 = \arctan(z_1/z_2)\) | \(\delta_2 = 90^\circ – \delta_1\) |
| Pitch cone distance | \(R_e = d_1/(2\sin\delta_1) = d_2/(2\sin\delta_2)\) | |
| Addendum | \(h_{a1} = m(h_a^* + x_1)\) | \(h_{a2} = m(h_a^* – x_1)\) |
| Dedendum | \(h_{f1} = m(h_a^* + c^* – x_1)\) | \(h_{f2} = m(h_a^* + c^* + x_1)\) |
| Whole tooth height | \(h = h_a + h_f\) | |
| Large-end tip diameter | \(d_{a1} = d_1 + 2h_{a1}\cos\delta_1\) | \(d_{a2} = d_2 + 2h_{a2}\cos\delta_2\) |
| Root angle | \(\delta_{f1} = \delta_1 – \arctan(h_{f1}/R_e)\) | \(\delta_{f2} = \delta_2 – \arctan(h_{f2}/R_e)\) |
| Face angle | \(\delta_{a1} = \delta_1 + \arctan(h_{a1}/R_e)\) | \(\delta_{a2} = \delta_2 + \arctan(h_{a2}/R_e)\) |
| Large-end circular tooth thickness | \(s_1 = m(\pi/2 + 2x_1\tan\alpha)\) | \(s_2 = m(\pi/2 – 2x_1\tan\alpha)\) |
| Large-end tooth space width | \(e_{d1} = \pi m – s_1 – 2h_{f1}\tan\alpha\) | \(e_{d2} = \pi m – s_2 – 2h_{f2}\tan\alpha\) |
The above formulas form the foundation for designing straight bevel gears. The tooth space width at the mid-point and small end are scaled by the corresponding cone distances. These values are crucial for determining the cutter blade width of the inner concave cutter.
3. Inner Concave Cutter Parameters and Machine Tool Adjustment
3.1 Machining Principle of Inner Concave Cutter
The inner concave cutter used for machining straight bevel gears features a main cutting edge that is inclined inward by a specific angle \(\delta\) (known as the concavity angle). When the cutter rotates, the cutting edges generate a conical surface with an internal concave shape. This concave surface is used to replace one tooth side of an imaginary generating gear. The generating gear, in turn, meshes with the workpiece straight bevel gear under a constant transmission ratio, producing the desired tooth profile by the generating (hobbing) process.
The most important characteristic of this method is that it produces a crowned tooth along the face width direction. The crowning amount \(\Delta S\) can be expressed as:
$$ \Delta S = \frac{B}{2}\left[\frac{1}{\cos\alpha_0}\left(\tan(\alpha_0 – \delta)\right) – \tan\alpha_0\right] $$
For small angles, an alternative formulation is:
$$ \Delta S \approx \frac{B^2 \cos\alpha_0}{4 r_c} \tan\delta $$
where \(B\) is the face width, \(\alpha_0\) is the pressure angle, \(r_c\) is the cutter radius, and \(\delta\) is the concavity angle. The crowning effectively reduces sensitivity to assembly errors and prevents edge contact, which is highly beneficial for straight bevel gears.
3.2 Cutter Diameter and Blade Width
The inner concave cutter diameter \(D_c\) (or radius \(r_c\)) is related to the desired concave depth at the tooth root \(\Delta h\) and the face width \(B\). The root line of the gear becomes a circular arc because the cutter does not feed along the tooth length direction. The required cutter radius is:
$$ r_c = \frac{B^2 \cos\alpha_0}{4 \Delta h} $$
The blade top width must be simultaneously larger than half of the large-end space width and smaller than the small-end space width. In practice, the cutter is selected from standard available sizes close to the theoretical values, and then the actual concavity depth is recalculated.
3.3 Machine Tool Adjustment Parameters
For machining straight bevel gears with an inner concave cutter on a CNC spiral bevel gear machine, the following adjustment parameters are essential: radial setting \(S\), angular setting \(q\), work offset \(E_m\), axial setting \(X_p\), machine root angle \(\delta_m\), sliding base \(X_B\), cutter tilt \(I\), cutter swivel \(J\), and roll ratio \(i_{12}\). The conversion from the cutter to the workpiece is established through a series of coordinate transformations that define the relative motion between the cutter, the generating gear, and the workpiece.
The angular spacing (tooth interval angle) \(\lambda\) is given by:
$$ \lambda = \arctan\left(\frac{e_m}{R_m}\right) $$
where \(e_m\) is the mid-point space width and \(R_m\) is the mid-point cone distance.
The cutter tilt angle \(I\) is computed from the pressure angle and the machine root angle:
$$ I = 90^\circ – \alpha_0 – \delta_f $$
The radial setting \(S_r\) is determined by:
$$ S_r = \sqrt{\left(\frac{R_m}{\cos\delta_f \cos\lambda}\right)^2 + \left(\frac{r_c}{\cos I}\right)^2 – 2 \cdot \frac{R_m}{\cos\delta_f \cos\lambda} \cdot \frac{r_c}{\cos I} \cdot \cos(\alpha_0 – \lambda)} $$
The angular setting \(q\) is:
$$ q = \arccos\left(\frac{R_m^2 + S_r^2 – r_c^2}{2 R_m S_r}\right) $$
The sliding base \(X_B\) is:
$$ X_B = r_c – \sin I – \Delta h $$
The cutter swivel angle \(J\) is simply:
$$ J = q – \lambda $$
The roll ratio between the generating gear and the workpiece is given by:
$$ i_{12} = \frac{\cos\lambda}{\sin\delta_f} $$
For the case study presented in this work, the following table lists the calculated parameters for a pair of straight bevel gears with \(z_1 = 25\), \(z_2 = 51\), \(m = 2.6737\) mm, \(B = 4.5\) mm, and \(\Sigma = 90^\circ\).
| Parameter | Pinion (small) | Gear (large) |
|---|---|---|
| Number of teeth | 25 | 51 |
| Large-end pitch diameter (mm) | 66.84 | 136.36 |
| Pitch angle (°) | 26.11 | 63.88 |
| Cone distance (mm) | 75.93 | 75.93 |
| Whole tooth height (mm) | 5.88 | 5.88 |
| Root angle (°) | 29.24 | 65.60 |
| Face angle (°) | 24.46 | 60.76 |
| Roll ratio | 2.270896 | 1.112031 |
| Cutter tilt angle (°) | 60 | 60 |
| Cutter swivel angle (°) | 20.61 | 19.92 |
| Radial setting (mm) | 79.24 | 79.16 |
| Angular setting (°) | 21.60 | 21.45 |
| Sliding base (mm) | 49.45 | 49.45 |
| Machine root angle (°) | 24.44 | 60.76 |
4. Tooth Surface Mathematical Model of Straight Bevel Gears
4.1 Coordinate Systems
To accurately describe the tooth surface of straight bevel gears machined by an inner concave cutter, several coordinate systems are defined. The cutter coordinate system \(S_t\) has its origin at the intersection of the cutter axis and the tip plane. The cutter surface is a cone with a concavity angle \(\delta\), and its position vector can be written as:
$$ \mathbf{r}_t(s,\theta) = \begin{bmatrix} s \sin\delta \sin\theta \\ s \sin\delta \cos\theta \\ s \cos\delta \\ 1 \end{bmatrix} + \begin{bmatrix} r_c \sin\theta \\ r_c \cos\theta \\ 0 \\ 0 \end{bmatrix} $$
where \(s\) is the distance along the cutting edge from the tip, \(\theta\) is the rotation angle around the cutter axis, and \(r_c\) is the cutter radius.
The unit normal vector to the cutter surface is:
$$ \mathbf{n}_t = \begin{bmatrix} -\sin\delta \sin\theta \\ -\sin\delta \cos\theta \\ \cos\delta \\ 0 \end{bmatrix} $$
The cutting edge tangent vector is:
$$ \mathbf{t}_t = \begin{bmatrix} \sin\delta \sin\theta \\ \sin\delta \cos\theta \\ \cos\delta \\ 0 \end{bmatrix} $$
The coordinate transformation from the cutter to the machine frame involves a series of rotations and translations that account for the machine settings. The transformation matrices are defined as follows:
From \(S_t\) to \(S_a\) (rotation about \(x\)-axis by cutter tilt \(I\)):
$$ \mathbf{M}_{at} = \begin{bmatrix} 1 & 0 & 0 & 0 \\ 0 & \cos I & \sin I & 0 \\ 0 & -\sin I & \cos I & 0 \\ 0 & 0 & 0 & 1 \end{bmatrix} $$
From \(S_a\) to \(S_b\) (rotation about \(z\)-axis by cutter swivel \(J\)):
$$ \mathbf{M}_{ba} = \begin{bmatrix} \cos J & \sin J & 0 & 0 \\ -\sin J & \cos J & 0 & 0 \\ 0 & 0 & 1 & 0 \\ 0 & 0 & 0 & 1 \end{bmatrix} $$
From \(S_b\) to \(S_c\) (translation by the cutter center coordinates \(L, A, D\)):
$$ \mathbf{M}_{cb} = \begin{bmatrix} 1 & 0 & 0 & L \\ 0 & 1 & 0 & A \\ 0 & 0 & 1 & D \\ 0 & 0 & 0 & 1 \end{bmatrix} $$
From \(S_c\) to \(S_m\) (rotation by the generating gear angle \(\phi\)):
$$ \mathbf{M}_{mc} = \begin{bmatrix} \cos\phi & -\sin\phi & 0 & 0 \\ \sin\phi & \cos\phi & 0 & 0 \\ 0 & 0 & 1 & 0 \\ 0 & 0 & 0 & 1 \end{bmatrix} $$
From \(S_m\) to \(S_g\) (rotation about \(x\)-axis to align with the workpiece axis):
$$ \mathbf{M}_{gm} = \begin{bmatrix} 1 & 0 & 0 & 0 \\ 0 & \sin\delta_f & \cos\delta_f & 0 \\ 0 & -\cos\delta_f & \sin\delta_f & 0 \\ 0 & 0 & 0 & 1 \end{bmatrix} $$
Finally, from \(S_g\) to the workpiece coordinate \(S_w\) (rotation by workpiece angle \(\phi_2\)):
$$ \mathbf{M}_{wg} = \begin{bmatrix} \cos\phi_2 & \sin\phi_2 & 0 & 0 \\ -\sin\phi_2 & \cos\phi_2 & 0 & 0 \\ 0 & 0 & 1 & 0 \\ 0 & 0 & 0 & 1 \end{bmatrix} $$
4.2 Meshing Equation
The tooth surface of the workpiece is the envelope of the cutter surface family during the generating motion. The meshing condition requires that the relative velocity \(\mathbf{v}_{12}\) between the cutter (generating gear) and the workpiece be perpendicular to the common normal:
$$ \mathbf{v}_{12} \cdot \mathbf{n}_m = 0 $$
In the machine coordinate system, the relative velocity is derived from the angular velocities of the generating gear \(\boldsymbol{\omega}_1\) and the workpiece \(\boldsymbol{\omega}_2\). The angular velocities are:
$$ \boldsymbol{\omega}_1 = [0, 0, 1]^T, \qquad \boldsymbol{\omega}_2 = i_{12} [0, -\sin\delta_f, \cos\delta_f]^T $$
The relative velocity at a point \(\mathbf{r}_m\) on the cutter surface (expressed in machine coordinates) is:
$$ \mathbf{v}_{12} = (\boldsymbol{\omega}_1 – \boldsymbol{\omega}_2) \times \mathbf{r}_m $$
Substituting \(\mathbf{r}_m\) and \(\mathbf{n}_m\) into the meshing equation yields a relation between the surface parameters \(s\) and \(\theta\). Eliminating \(s\) gives the contact line on the cutter surface, and sweeping \(\phi_1\) (or equivalently the workpiece rotation \(\phi_2 = \phi_1 / i_{12}\)) generates the entire tooth surface of the straight bevel gear.
4.3 Tooth Surface Discretization
For the purpose of gear measurement and contact analysis, the tooth surface is discretized into a grid. A common practice is to use 9 points along the face width and 5 points along the tooth height, with shrinkage of 10% of the face width at both ends and 5% of the tooth height at the top and bottom. The discrete points are then represented by their spatial coordinates and unit normal vectors.
The coordinates are calculated in the axial plane of the straight bevel gear. For each point \(P_{ij}\) (with \(i = 1,\ldots,9\) and \(j = 1,\ldots,5\)), its radial distance \(R_{ij}\) and axial position \(L_{ij}\) relative to the apex are determined. The following relations are used:
$$ R_{ij} = \sqrt{x_{ij}^2 + y_{ij}^2}, \qquad L_{ij} = z_{ij} $$
Full discretized lists are generated by the developed MATLAB program. An example output for the right tooth surface of a gear with 35 teeth and module 2.5 mm is shown in the table below (partial data).
| Point | Row/Col | X (mm) | Y (mm) | Z (mm) | n_x | n_y | n_z |
|---|---|---|---|---|---|---|---|
| 1 | 1,1 | 41.6266 | 0.6791 | -45.7265 | 0.0990 | 0.9897 | 0.1036 |
| 2 | 1,2 | 42.5654 | 0.4036 | -44.7913 | 0.1805 | 0.9672 | 0.1789 |
| 3 | 1,3 | 43.5025 | -0.0046 | -43.8561 | 0.2360 | 0.9435 | 0.2326 |
| 4 | 1,4 | 44.4347 | -0.5197 | -42.9209 | 0.2794 | 0.9194 | 0.2767 |
| 5 | 1,5 | 45.3589 | -1.1285 | -41.9857 | 0.3152 | 0.8952 | 0.3149 |
The complete grid is used to construct a precise three-dimensional model of the straight bevel gear in SolidWorks. The generated model matches the theoretical tooth surface within the prescribed tolerances.
5. Tooth Contact Analysis of Straight Bevel Gear Pairs
5.1 Meshing Coordinate System
Tooth contact analysis (TCA) is performed to simulate the meshing process of a pair of straight bevel gears under light load. The pinion and gear tooth surfaces are expressed in a common fixed coordinate system \(S_f\). The coordinate transformations are:
$$ \mathbf{r}_{fp} = \mathbf{M}_{f1}\mathbf{r}_1, \qquad \mathbf{r}_{fg} = \mathbf{M}_{f2}\mathbf{r}_2 $$
where \(\mathbf{M}_{f1}\) and \(\mathbf{M}_{f2}\) include the rotation angles of the pinion \(\phi_1\) and the gear \(\phi_2\), respectively, as well as the shaft angle \(\Sigma\). For a standard 90° shaft angle, the transformation matrix is:
$$ \mathbf{M}_{f2} = \begin{bmatrix} \cos\phi_2 & 0 & \sin\phi_2 & 0 \\ 0 & 1 & 0 & 0 \\ -\sin\phi_2 & 0 & \cos\phi_2 & 0 \\ 0 & 0 & 0 & 1 \end{bmatrix} $$
The basic contact condition is that the position vectors and unit normals of the two surfaces are equal at the contact point:
$$ \mathbf{r}_{fp} = \mathbf{r}_{fg}, \qquad \mathbf{n}_{fp} = \mathbf{n}_{fg} $$
Since the normal vectors are unit vectors, this gives 5 independent scalar equations. The unknowns are the two surface parameters of the pinion \((u_1,v_1)\), the two surface parameters of the gear \((u_2,v_2)\), and the two rotation angles \(\phi_1\) and \(\phi_2\). By fixing one angle (e.g., \(\phi_1\)), the remaining five unknowns can be solved using Newton-Raphson iteration.
5.2 Initial Point Selection and V/H Adjustment
The initial contact point is usually selected at the middle of the gear tooth surface, with the distance from the large end equal to 0.5 times the face width. The corresponding pinion point is found by requiring the theoretical transmission ratio. Then the gear is adjusted in the axial and radial directions by the calculated offsets \(V\) and \(H\) to ensure correct meshing at the reference point.
For different installation positions (large end, middle, small end), the V/H values are varied to study the sensitivity of the contact to mounting errors. In this analysis, three positions are typically considered: the large end, the midpoint, and the small end of the tooth. The V/H values are given by the differences in position vectors along the coordinate axes.
5.3 Contact Ellipse and Transmission Error
Once the contact point is found, the principal curvatures of the pinion and gear surfaces are calculated. The relative normal curvature in a tangent direction making an angle \(\theta\) with the gear tooth length direction is:
$$ \Delta K = \frac{\Delta A + \Delta B}{2} + \frac{\Delta A – \Delta B}{2}\cos 2\theta + \Delta C \sin 2\theta $$
where \(\Delta A\), \(\Delta B\), and \(\Delta C\) are the differences in the normal curvatures and geodesic torsion between the two surfaces along the tooth height and tooth width directions. The principal directions of the relative curvature determine the orientation of the contact ellipse. The semi-major axis \(a\) and semi-minor axis \(b\) are:
$$ a = \sqrt{\frac{2\delta}{\Delta K_{\min}}}, \qquad b = \sqrt{\frac{2\delta}{\Delta K_{\max}}} $$
where \(\delta\) is the elastic deformation, typically set to 0.00635 mm (the thickness of red lead powder). The contact pattern is obtained by plotting the contact ellipses at every contact point along the meshing path.
The transmission error is defined as the deviation of the actual gear rotation angle from the theoretical one:
$$ \Delta \phi_2 = (\phi_2 – \phi_{20}) – \frac{z_1}{z_2}(\phi_1 – \phi_{10}) $$
The graph of \(\Delta \phi_2\) versus \(\phi_1\) is the transmission error curve. For a correct design, the curve should be continuous and smooth, usually shaped like a parabola opening downward, indicating a smooth transition of load.
5.4 TCA Results for the Studied Gears
Using the developed MATLAB TCA program, the contact patterns and transmission error curves for the straight bevel gear pair (with \(z_1 = 35, z_2 = 35, m = 2.5\)) are obtained. The contact areas at three different V/H positions are summarized in the following table:
| Position | V (mm) | H (mm) | Contact length (% of face width) | Transmission error range (rad) |
|---|---|---|---|---|
| Large end | -0.0357 | 0.2141 | ~50% | -0.004 to 0 |
| Midpoint | -0.0367 | 0.0074 | ~50% | -0.003 to 0 |
| Small end | -0.0378 | -0.2161 | ~50% | -0.005 to 0 |
From the results, the contact area length is about half of the face width, matching the pre-set contact ratio. The transmission error curves are parabolic with a maximum absolute value less than 0.005 rad, which verifies the proper crowning effect introduced by the inner concave cutter.
6. Software Development
Based on the established mathematical models and computational methods, a complete software package was developed using MATLAB. The software includes the following modules:
- Geometric parameter calculation for straight bevel gears.
- Inner concave cutter parameter calculation.
- Machine tool adjustment parameter calculation.
- Tooth surface discrete point coordinate and unit normal vector calculation.
- Tooth contact analysis (TCA) module.
The main interface allows the user to input basic parameters such as number of teeth, module, face width, pressure angle, shaft angle, profile shift coefficients, and backlash. After clicking the calculation buttons, the software outputs all required parameters, including the complete list of tooth surface points. The software interface is designed to be user-friendly and provides both graphical and textual output.
7. Machining Experiments and Verification
7.1 Experimental Setup
To validate the theoretical research, a pair of straight bevel gears was machined on a domestic H350C CNC spiral bevel gear milling machine. The workpiece parameters are summarized below:
| Parameter | Value |
|---|---|
| Number of teeth (pinion/gear) | 35 / 35 |
| Module (mm) | 2.5 |
| Face width (mm) | 15 |
| Pressure angle (°) | 20 |
| Pitch angle (°) | 45 / 45 |
| Root angle (°) | 42.22 |
| Face angle (°) | 47.78 |
| Cutter radius (mm) | 72.78 |
| Concavity angle (°) | 2 |
The machine adjustment parameters are listed in the following table:
| Parameter | Value |
|---|---|
| Roll ratio | 1.412554 |
| Machine root angle (°) | 42.22 |
| Radial setting (mm) | 61.12 |
| Angular setting (°) | 27.18 |
| Cutter tilt (°) | 68 |
| Cutter swivel (°) | 26.37 |
| Work offset (mm) | 0 |
| Axial setting (mm) | 0 |
| Sliding base (mm) | 67.12 |
7.2 Machining Process
An inner concave cutter with the specified parameters was manufactured, and the gear blanks were prepared. The NC program was generated and loaded into the H350C machine. The cutting process was carried out successfully, and the machined straight bevel gear pair is shown in the figure. The machining parameters were optimized to ensure good surface quality and dimensional accuracy.
7.3 Tooth Profile Error Measurement
The machined straight bevel gears were measured on a gear measuring center. The tooth profile error was calculated by comparing the measured discrete points with the theoretical points generated from the mathematical model. The maximum profile error was found to be 11.9 μm, which satisfies the practical engineering requirement of less than 0.02 mm. The tooth pitch error was also measured, and the gear was graded to class 6 according to the Chinese national standard GB 11365.
The sources of the tooth profile error include the positioning errors of the CNC axes, cutter manufacturing errors, fixture errors, and blank errors. The small deviation confirms the correctness of the tooth surface model and the software calculations.
7.4 Contact Pattern Inspection
The machined straight bevel gear pair was mounted on a rolling inspection machine. Red lead powder was applied to the tooth surfaces, and the contact patterns were observed at three different positions: large end, midpoint, and small end. The actual contact patterns closely matched the theoretical TCA results. The photographs of the contact patterns confirmed that the contact area was located in the central region of the tooth surface, with a length of about half the face width, and no edge contact occurred. This excellent agreement validates the machining principle and the entire design methodology.
8. Conclusion
This paper presents a systematic study on the design and machining technology of straight bevel gears using an inner concave cutter. The following conclusions can be drawn:
- The geometric parameters of straight bevel gears were calculated using standard formulas, forming the basis for cutter and machine settings.
- The inner concave cutter parameters, including the concavity angle, cutter radius, and blade width, were derived from the desired crowning and root concave depth. The milling principle with a generating gear was successfully applied.
- A complete tooth surface mathematical model was established using coordinate transformations and the meshing equation. The tooth surface was discretized into a 9×5 grid of points with unit normals, enabling precise measurement and 3D modeling.
- Tooth contact analysis was implemented to predict the contact pattern and transmission error of straight bevel gear pairs. The TCA results confirmed the crowning effect and proper contact ratio.
- A MATLAB-based software suite was developed, integrating all calculation modules. The software is practical and efficient for industrial use.
- Machining experiments were conducted on a domestic H350C CNC machine. The measured tooth profile error was within 11.9 μm, and the contact pattern matched the theoretical prediction. These results validate the correctness and feasibility of the proposed method for producing high-quality straight bevel gears.
9. Future Work
Future research directions include the development of grinding technology with CBN wheels for straight bevel gears, error correction algorithms to compensate for machine and tool errors, and finite element analysis of contact strength and bending strength for straight bevel gears machined with inner concave cutters. Additionally, the influence of different concavity angles on the dynamic behavior of straight bevel gear transmissions can be further investigated.
In summary, this work provides a complete theoretical and experimental foundation for the efficient and high-precision manufacturing of straight bevel gears on domestic CNC machines, contributing to the advancement of gear manufacturing technology in China.