
In the production of straight bevel gears, one of the most difficult quality requirements is the coaxiality between the finished axial bore and the pitch cone axes. When I grind the axial hole of straight bevel gears, I prefer to mount the blank on its own tooth flanks rather than on an outside diameter or on a previously ground back face. The tooth working surface of straight bevel gears is an involute surface, and that surface is the functional datum that matters most. By using the tooth face as the locating datum, I can achieve a very consistent relationship between the bore and the tooth system of straight bevel gears.
The principle is simple. A special fixture carries a spherical support on which the conical back of the blank rests. I place hardened steel balls into selected tooth spaces of the straight bevel gears. The balls are forced against the involute flanks. Because the tooth flanks of straight bevel gears converge toward the common cone apex, the balls define the gear axis accurately. A clamping ring is then applied on the hub end face of the blank. This clamps the work without obstructing the bore. The bore-grinding wheel can then pass through the hole while the tooth flanks remain the only locating elements for the straight bevel gears.
This method is especially attractive for straight bevel gears because ordinary cylindrical locating methods are not able to relate the bore to the pitch cone. A chuck that grips the outside diameter of a bevel gear blank can leave large errors. The outside diameter of straight bevel gears is not necessarily the functional datum, and it is often machined with generous tolerances. If I locate on the outside diameter, errors in centering, ovality, and concentricity are transferred directly to the bore. If I locate on the back face only, the blank can wobble because straight bevel gears have a conical tooth system. Therefore, the tooth flanks themselves are the best datum.
Why Tooth Faces Are the Natural Datum for Straight Bevel Gears
For straight bevel gears, the active flanks are generated by a straight-sided crown gear. In a transverse section perpendicular to the axis, the profile is not a simple spur-gear involute, but on the back cone it can be treated as an involute tooth of an equivalent spur gear. The involute flank has a base circle, a pressure angle, and a well-defined line of action. A spherical or cylindrical ball placed in the tooth space of straight bevel gears will touch both flanks simultaneously if the ball size is correctly chosen. That double contact is kinematically stable.
I have used this method in batch grinding of straight bevel gears. The fixture does not depend on the abrasive wheel or on the grinding spindle alignment alone. The alignment of the wheel with the tooth-flank-defined axis is established by the fixture itself. Once the fixture is set, every blank of the batch is placed in the same relationship between the tooth flanks and the bore. This gives excellent repeatability.
Another advantage is that the tooth flanks of straight bevel gears have already been cut in the majority of cases. The blank has teeth, and those teeth are the surfaces that will eventually transmit load. If the bore is ground using those same flanks, any indexing error or tooth-thickness variation will have a controlled effect on the final runout. The bore is therefore ground to the actual tooth system of the straight bevel gears, not to an imaginary axis obtained from rough external surfaces.
Description of the Locating Fixture
The fixture for locating straight bevel gears consists of a body, a spherical rest, a set of steel balls, a ball cage, and a clamping element. The spherical rest is machined to match the back-cone surface of the particular size of straight bevel gears. The blank is placed onto the rest with its back face in contact with the spherical surface. The steel balls are then inserted into the tooth spaces. In most cases I use three balls for a kinematic location. The balls are supported radially by the two flanks of the tooth space and axially by the spherical rest.
In my fixture, the steel balls are held in a simple cage so that they remain at the correct spacing while the next blank of straight bevel gears is loaded. The cage prevents the balls from falling into the fixture or becoming mixed with swarf. The blank is then pressed gently backward against the spherical rest. After that, the clamping ring is placed on the hub face. The clamp is applied along the hub end face, so it never covers the bore and never touches the tooth flanks. This is very important for straight bevel gears because the clamping force should be taken by the stiff hub, not by the thin rim or the teeth.
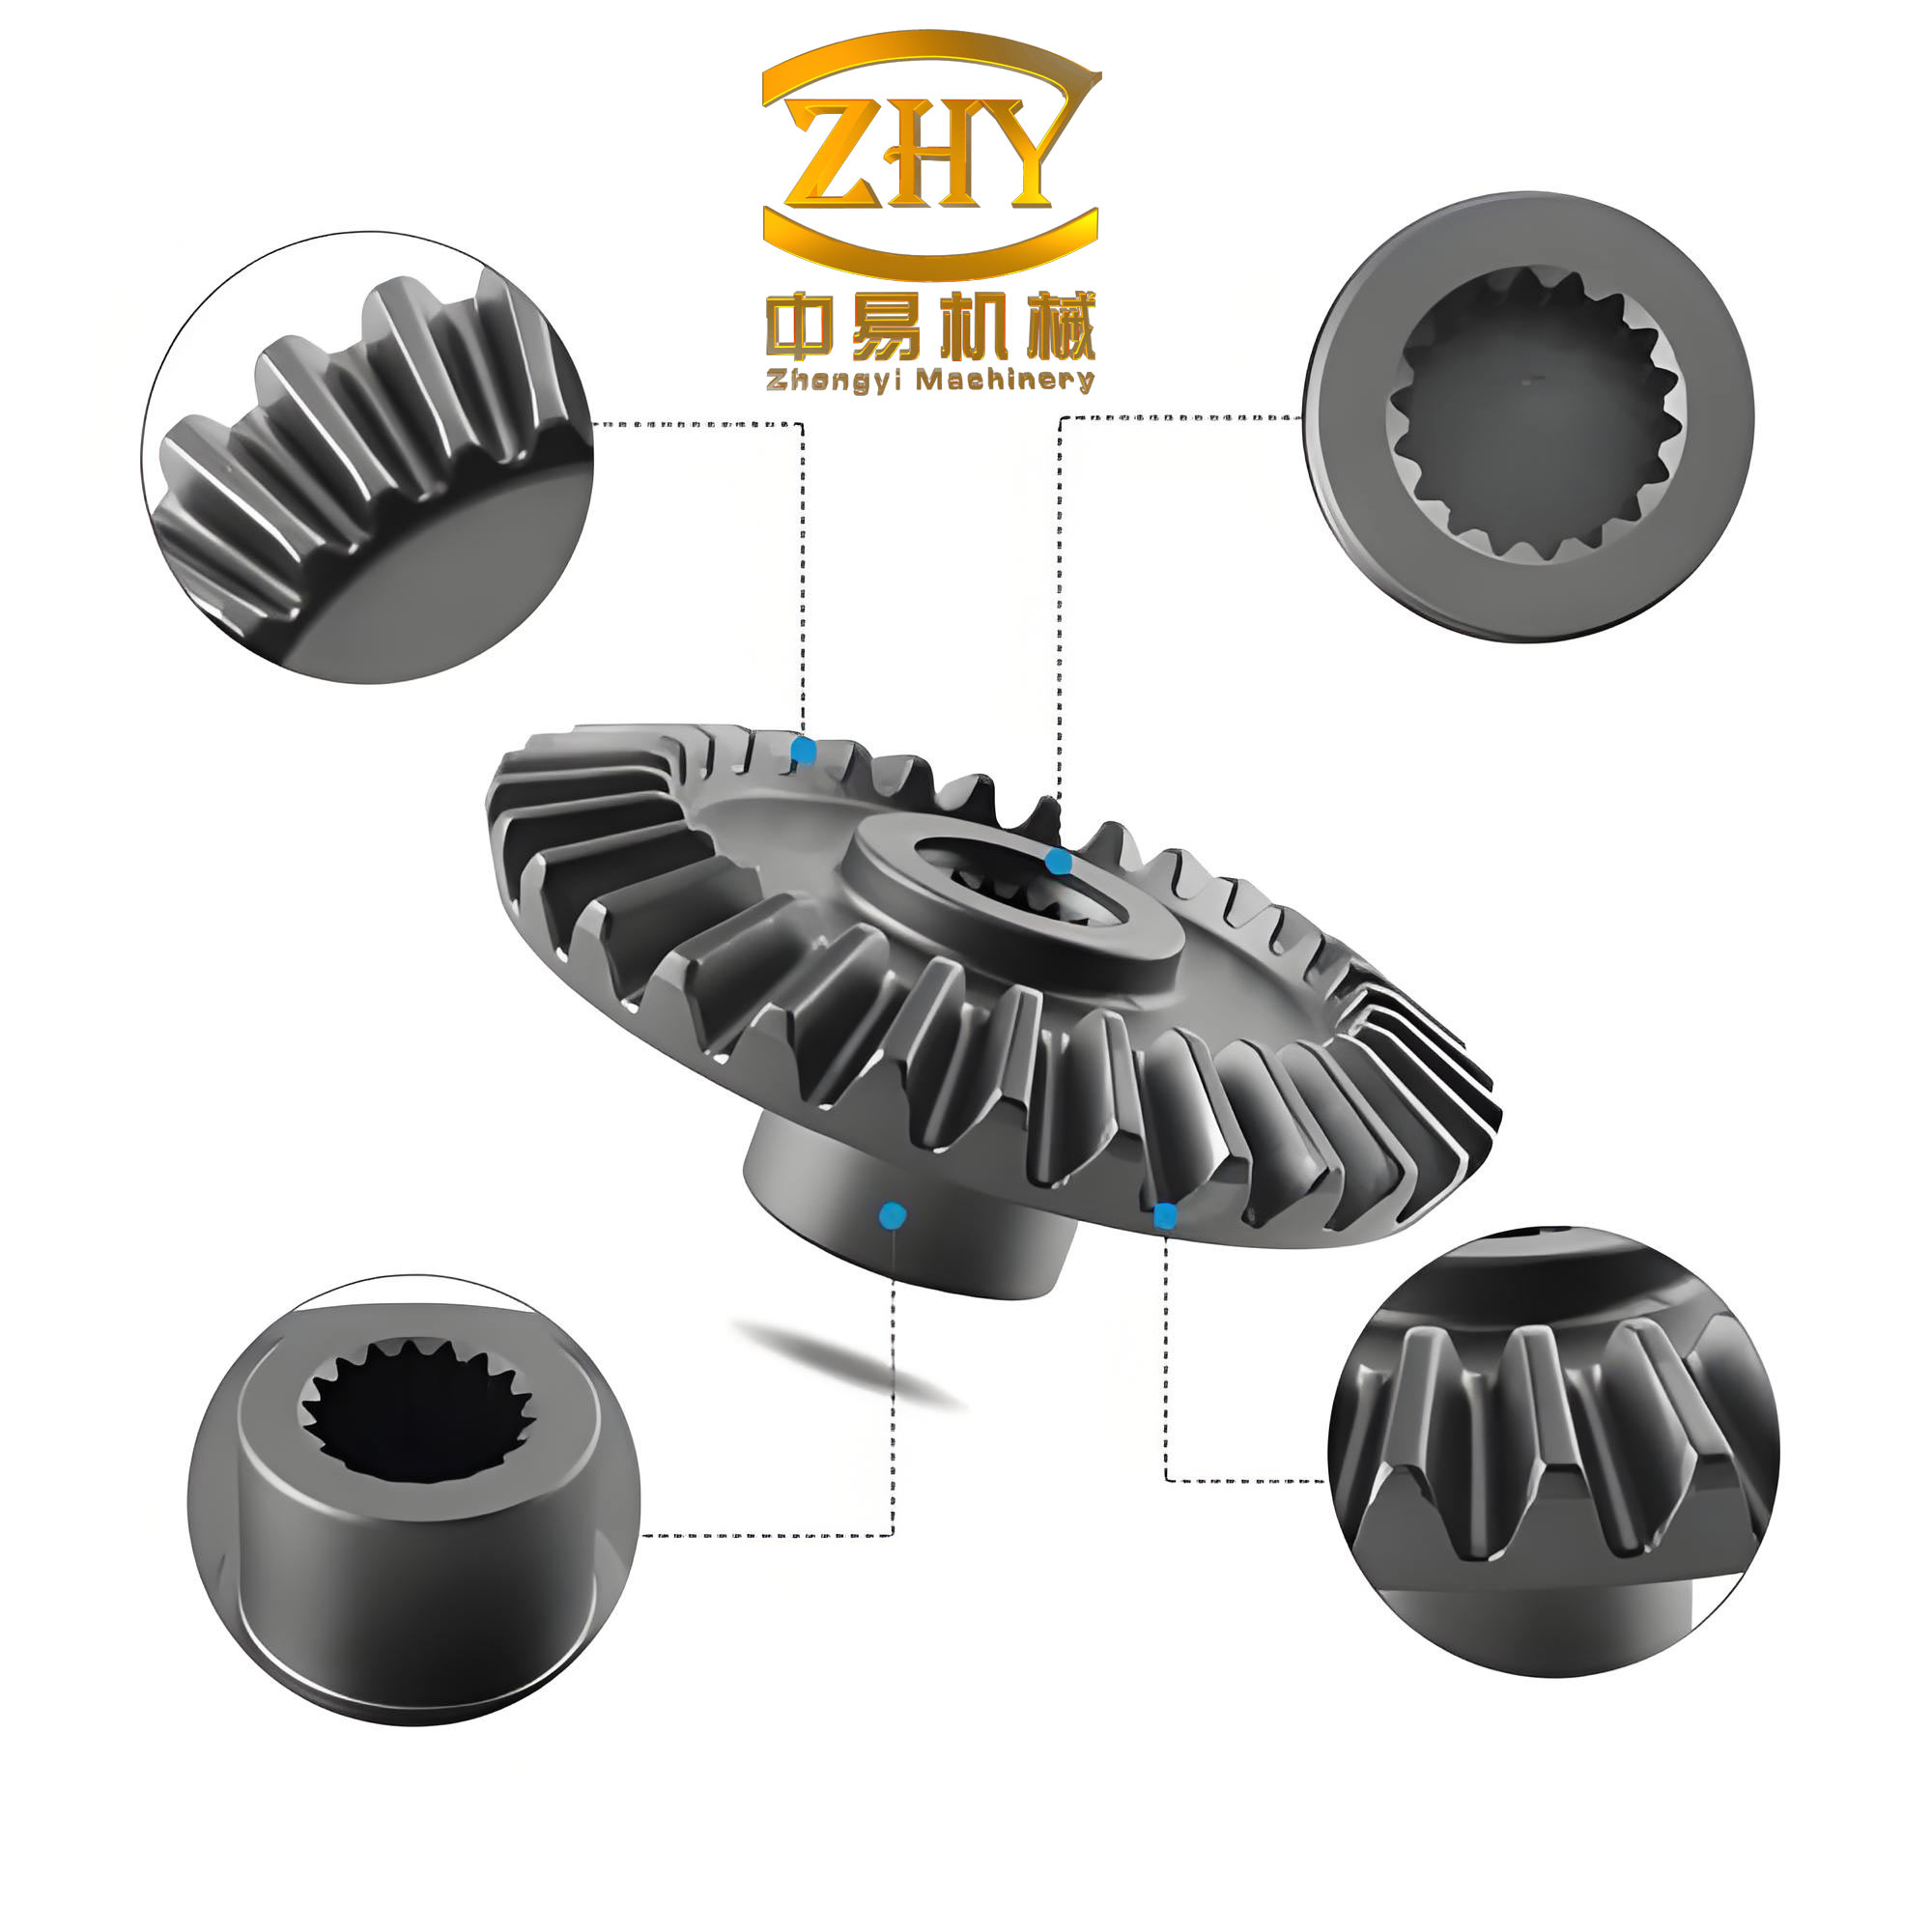
I have found that the spherical support must be carefully guarded against dirt. For straight bevel gears, even a small particle between the back face and the spherical support can tilt the blank. The steel balls, likewise, must be clean and free from burrs. The balls should be made of hardened bearing steel and ground to a very small tolerance on diameter. If the diameters of the balls differ, the centers of the balls will not lie on a common circle, and the axis of the straight bevel gears will be slightly displaced relative to the fixture spindle.
Geometry of the Steel Ball in the Tooth Space of Straight Bevel Gears
In order to calculate the correct ball size for straight bevel gears, I consider one transverse section of the gear at the location where the balls make contact. For straight bevel gears, the pitch radius changes along the face width. I therefore define a selected locating section along the pitch cone element. The ball should touch the flanks in that section, and its center should lie on a radial plane that bisects the tooth space.
The input data for the calculation of the ball diameter \(d\) and the locating distance \(M\) for straight bevel gears are:
| \(z\) | number of teeth |
| \(\varphi\) | pitch cone half angle |
| \(r_x\) | pitch radius in the selected locating section |
| \(\alpha\) | pressure angle of the tooth profile |
| \(s_x\) | circular tooth thickness in the same selected section |
| \(m\) | module in the same section |
| \(R_e\) | pitch cone generator length, often called the cone distance |
| \(\eta\) | half angular width of the tooth space at the pitch circle |
For external straight bevel gears, the local pitch radius can be written in terms of the cone distance from the apex to the selected section. If \(R_x\) is the cone distance at the selected section, then
\[
r_x = R_x \sin\varphi .
\]
At the outer end of the straight bevel gears, the cone distance is \(R_e\). If I choose a locating section at a distance \(l\) from the large end, measured along the pitch cone element toward the apex, then
\[
R_x = R_e – l .
\]
Thus
\[
r_x = (R_e – l) \sin\varphi .
\]
For a standard gear at the outer end, the pitch radius is
\[
r_e = \frac{m z}{2} .
\]
The pitch cone generator length is therefore
\[
R_e = \frac{r_e}{\sin\varphi} = \frac{m z}{2 \sin\varphi} .
\]
Along the face width of straight bevel gears, the tooth thickness changes if the tooth is cut with uniform angular thickness. In that case,
\[
s_x = s_e \frac{r_x}{r_e} .
\]
If the tooth thickness is not proportional to the pitch radius, I use the actual measured circular tooth thickness at the selected section. The calculation of the steel ball depends on the actual tooth space of the straight bevel gears, so the tooth thickness must be known accurately.
Half Angular Width of the Tooth Space
The angular pitch of straight bevel gears is \(2\pi / z\). Around the pitch circle, each tooth occupies an angular width \(s_x / r_x\). The remaining angular width is the tooth space. For one tooth space, the full angular width is
\[
\frac{2\pi}{z} – \frac{s_x}{r_x} .
\]
The half angular width \(\eta\) is therefore
\[
\eta = \frac{\pi}{z} – \frac{s_x}{2 r_x} .
\]
If the tooth thickness has the common proportion \(s_x = \pi m_x / 2\), then \(s_x / r_x = \pi / z\), and the half angular width becomes
\[
\eta = \frac{\pi}{2 z} .
\]
This is a convenient first estimate for many straight bevel gears with zero backlash. If backlash has been introduced by reducing the tooth thickness, the actual value of \(s_x\) must be used. The same applies when the teeth of straight bevel gears are left with grinding stock. The ball seats against the tooth faces as they exist on the blank, not against the final theoretical profile. For best results, I measure the tooth thickness before calculating the ball diameter.
Derivation of the Ball Diameter and the Locating Distance
When a steel ball is placed in the tooth space of straight bevel gears, its center lies on the bisector of the tooth space. I define the following points:
\(O\) is the gear axis point in the selected transverse section, \(P\) is the point where the ball touches the flank, and \(C\) is the center of the steel ball. The radius \(OP\) is the local pitch radius \(r_x\). The angle between the bisector \(OC\) and the radius \(OP\) is the half angular tooth-space width \(\eta\).
For involute straight bevel gears, the normal to the flank at the pitch point makes an angle \(90^\circ – \alpha\) with the radius \(OP\). Therefore triangle \(OPC\) has the following angles:
\[
\angle POC = \eta,
\]
\[
\angle OPC = 90^\circ – \alpha .
\]
The third angle is
\[
\angle OCP = 180^\circ – \eta – (90^\circ – \alpha)
= 90^\circ + \alpha – \eta .
\]
By the sine rule,
\[
\frac{PC}{\sin \eta} = \frac{OP}{\sin(90^\circ + \alpha – \eta)} .
\]
Since \(OP = r_x\) and \(\sin(90^\circ + \alpha – \eta) = \cos(\alpha – \eta)\), the ball radius is
\[
\rho = PC = \frac{r_x \sin \eta}{\cos(\alpha – \eta)} .
\]
The steel ball diameter \(d\) is therefore
\[
d = 2\rho
= \frac{2 r_x \sin \eta}{\cos(\alpha – \eta)} .
\]
This is the formula that I use for straight bevel gears. The ball touches the flanks at the pitch circle of the selected section. If the ball is smaller, it sinks too deeply into the tooth space; if it is larger, it rides too high. The above expression gives the ball that exactly contacts the flanks at the pitch line.
The distance from the gear axis to the ball center is
\[
M = OC .
\]
Using the sine rule in the same triangle,
\[
\frac{OC}{\sin(90^\circ – \alpha)} = \frac{r_x}{\cos(\alpha – \eta)} .
\]
Because \(\sin(90^\circ – \alpha) = \cos \alpha\),
\[
M = \frac{r_x \cos \alpha}{\cos(\alpha – \eta)} .
\]
This distance \(M\) is the radius of the circle on which the centers of the steel balls lie. In the fixture for straight bevel gears, \(M\) must be the same for every ball. If the fixture has a bore gauge or a setting ring, the balls are set to this radius before the blank is clamped.
Practical Calculation Example for Straight Bevel Gears
I will give a complete numerical example for a typical set of straight bevel gears. The input data are:
| Number of teeth | \(z = 20\) |
| Pitch cone half angle | \(\varphi = 45^\circ\) |
| Module at the outer end | \(m = 4\) mm |
| Pressure angle | \(\alpha = 20^\circ\) |
| Circular tooth thickness at the outer end | \(s_e = \pi m / 2 = 6.283\) mm |
| Face width | \(b = 16\) mm |
The pitch radius at the outer end is
\[
r_e = \frac{m z}{2}
= \frac{4 \times 20}{2}
= 40.000 \text{ mm}.
\]
The pitch cone generator length is
\[
R_e = \frac{r_e}{\sin\varphi}
= \frac{40.000}{\sin 45^\circ}
= 56.569 \text{ mm}.
\]
I choose the locating section at \(l = 10\) mm from the large end. The local cone distance is
\[
R_x = R_e – l
= 56.569 – 10
= 46.569 \text{ mm}.
\]
The local pitch radius is
\[
r_x = R_x \sin\varphi
= 46.569 \times 0.7071
= 32.929 \text{ mm}.
\]
The local circular tooth thickness is
\[
s_x = s_e \frac{r_x}{r_e}
= 6.283 \times \frac{32.929}{40.000}
= 5.172 \text{ mm}.
\]
The half angular width of the tooth space is
\[
\eta
= \frac{\pi}{z} – \frac{s_x}{2 r_x}
= 0.15708 – \frac{5.172}{65.858}
= 0.15708 – 0.07854
= 0.07854 \text{ rad}.
\]
This is equal to \(\pi / (2z)\), as expected for standard straight bevel gears with uniform tooth thickness proportion.
The steel ball diameter is now found:
\[
d
= \frac{2 r_x \sin\eta}{\cos(\alpha – \eta)}
= \frac{2 \times 32.929 \times \sin 0.07854}
{\cos(0.34907 – 0.07854)}
\]
\[
d
= \frac{65.858 \times 0.07846}{0.96367}
= 5.362 \text{ mm}.
\]
The locating distance is
\[
M
= \frac{r_x \cos\alpha}{\cos(\alpha – \eta)}
= \frac{32.929 \times \cos 20^\circ}{0.96367}
\]
\[
M
= \frac{32.929 \times 0.93969}{0.96367}
= 32.109 \text{ mm}.
\]
Thus the correct steel ball has a diameter of about 5.36 mm, and the centers of the balls must lie on a circle of radius 32.11 mm measured from the axis of the straight bevel gears.
Effect of the Locating Section Position
For straight bevel gears, the same calculation can be repeated for different positions along the cone element. The table below summarizes the results for the same gear when the locating section is moved from the large end toward the small end.
| \(l\) mm | \(R_x\) mm | \(r_x\) mm | \(d\) mm | \(M\) mm |
| 0 | 56.569 | 40.000 | 6.513 | 39.004 |
| 5 | 51.569 | 36.464 | 5.938 | 35.556 |
| 10 | 46.569 | 32.929 | 5.362 | 32.109 |
| 15 | 41.569 | 27.394 | 4.461 | 26.710 |
The position of the locating section should be chosen so that the balls contact the flanks in a region that has already been accurately machined on the straight bevel gears. I prefer to choose a section near the middle of the face width. The middle region of straight bevel gears is usually the best compromise between tooth deflection, surface finish, and manufacturing stability.
Dimensionless Coefficients for Straight Bevel Gears
It is often useful to express the ball diameter as a coefficient times the local module. For straight bevel gears, the local module is
\[
m_x = \frac{2 r_x}{z} .
\]
The dimensionless diameter coefficient is
\[
k_d = \frac{d}{m_x}
= \frac{z \sin\eta}{\cos(\alpha – \eta)} .
\]
For zero backlash, \(\eta = \pi / (2z)\), so
\[
k_d
= \frac{z \sin\left(\frac{\pi}{2z}\right)}
{\cos\left(\alpha – \frac{\pi}{2z}\right)} .
\]
This coefficient changes only a little with the number of teeth. The following table gives values for \(\alpha = 20^\circ\).
| Number of teeth \(z\) | \(\eta\) degrees | \(k_d = d / m_x\) |
| 10 | 9.000 | 1.602 |
| 12 | 7.500 | 1.604 |
| 16 | 5.625 | 1.616 |
| 20 | 4.500 | 1.628 |
| 30 | 3.000 | 1.642 |
| 50 | 1.800 | 1.653 |
The locating distance coefficient for the same straight bevel gears is
\[
k_M = \frac{M}{r_x}
= \frac{\cos\alpha}{\cos(\alpha – \eta)} .
\]
For \(\alpha = 20^\circ\), this coefficient is always close to 0.97. The table below shows the effect of pressure angle for \(z = 20\).
| Pressure angle \(\alpha\) | \(d / m_x\) | \(M / r_x\) |
| 14.5° | 1.610 | 0.983 |
| 20° | 1.628 | 0.975 |
| 25° | 1.676 | 0.967 |
Effect of Tooth Thickness Variation
The tooth thickness of straight bevel gears may differ from the theoretical value because of backlash allowance, grinding stock, or tool setting errors. The half angular tooth-space width \(\eta\) is changed by the actual tooth thickness. If the actual tooth thickness is \(s_x’\), then
\[
\eta’ = \frac{\pi}{z} – \frac{s_x’}{2 r_x} .
\]
The ball diameter becomes
\[
d’ = \frac{2 r_x \sin\eta’}{\cos(\alpha – \eta’)} .
\]
The locating distance becomes
\[
M’ = \frac{r_x \cos\alpha}{\cos(\alpha – \eta’)} .
\]
For example, if the tooth thickness of the straight bevel gears is reduced by 0.1 mm to provide backlash, the ball diameter decreases slightly, and the ball center moves closer to the gear axis. I must take this into account for each batch of straight bevel gears. If the tooth thickness varies from part to part within the same batch, the fixture will introduce a corresponding variation in the bore location. Therefore, the tooth thickness tolerance of straight bevel gears should be controlled when this locating method is used.
Choice of the Number and Arrangement of Steel Balls
The ball formula gives the size of one ball. For the complete mounting of straight bevel gears, at least three balls are needed. Two balls or one ball cannot define the gear axis uniquely. Three balls placed in three tooth spaces create a three-point location. The centers of the three balls lie on a circle of radius \(M\) from the gear axis. The plane of that circle is perpendicular to the axis of the straight bevel gears.
Ideally, the three tooth spaces should be spaced 120° apart. If the number of teeth of the straight bevel gears is divisible by three, this is easy. For other tooth numbers, I select three tooth spaces as close to 120° apart as possible. The small angular deviation is acceptable for many straight bevel gears because the tooth spaces are all on the same pitch circle and the balls are gaged by the same radius \(M\).
For very large straight bevel gears, I sometimes use more than three balls. The additional balls do not usually carry load; they help to stabilize the blank against its own weight. However, too many balls can overconstrain the system if the tooth spacing error of the straight bevel gears is large. A kinematic three-ball mount is generally safer.
Clamping Forces and Deformation of Straight Bevel Gears
When I clamp straight bevel gears by the tooth flanks, I have to be careful about elastic deformation. The contact stresses between the hardened steel ball and the soft tooth flank can be high. For straight bevel gears that are not yet hardened, the balls may leave small indentations. To avoid this, I limit the clamping force and distribute it over the hub end face. The tooth-flank locating elements need only position the blank, not resist the entire grinding force alone.
In the fixture, the clamp acts on the hub face. The clamping force is transmitted through the hub and the back face to the spherical support. The balls locate the gear in the radial direction. The tooth flanks of straight bevel gears are therefore not used as abutments for the clamping force. This reduces the risk of bending the rim of the straight bevel gears.
The diameter of the steel balls should be selected so that the balls seat in the tooth space without rising above the tips of the teeth. If the balls are too large, they may contact the edges of the tooth tips instead of the involute flanks. If the balls are too small, they may sink too deeply and the locating section may fall outside the useful face width. The calculated diameter is therefore not only a mathematical value; it is also checked visually and by a trial mounting of the straight bevel gears.
Spherical Support for Straight Bevel Gears
The back face of straight bevel gears is usually conical. The fixture has a spherical support that is manufactured to fit this back surface. When the blank is placed on the spherical support, the gear is stable in the axial direction. The balls in the tooth spaces cannot move independently because the back face is held against the spherical support. This gives a well-defined axial location for every batch of straight bevel gears.
The contact area between the spherical support and the back face of the straight bevel gears should be large enough to avoid crushing the work. I machine the support to the same nominal back-cone angle as the gear. A small mismatch can cause rocking. The back face of straight bevel gears should therefore be machined to a controlled runout relative to the pitch cone before the bore is ground.
In some cases, the back face of straight bevel gears is not well enough finished to be used as a spherical seat. I then use a small pilot ring or a centering cone on the hub to align the blank axially before the balls are inserted. However, this auxiliary element is removed after the balls are in place. The final locating datum for the bore is always the tooth face of the straight bevel gears.
Grinding the Axial Bore of Straight Bevel Gears
Once the blank is mounted on the fixture, the axial bore can be ground. The grinding spindle is aligned with the fixture spindle. The bore of the straight bevel gears is ground to size with a conventional internal grinding wheel. Because the tooth flanks have already defined the axis, the finished bore is coaxial with the pitch cone of the straight bevel gears.
During grinding, I use coolant carefully so that it does not wash away the balls or change their seating. The fixture should be equipped with seals or shields to keep abrasive grit away from the balls and the spherical support. After grinding, I remove the blank, clean the fixture, and inspect the runout of the bore relative to the tooth flanks. A quick method is to mount the ground straight bevel gears on a precision mandrel and check the runout of the tooth flanks with a dial indicator. The result obtained with tooth-face mounting is usually much better than the result obtained with conventional outside-diameter chucking of straight bevel gears.
Effects of Indexing Errors in Straight Bevel Gears
No gear is perfect. The tooth spaces of straight bevel gears may have small indexing errors. A ball placed in a tooth space will follow the actual position of that space. If I use only three balls, the axis of the straight bevel gears will be a best-fit axis through the three ball centers. This is usually acceptable for straight bevel gears produced on a good gear cutting machine.
If indexing errors are large, the bore may be ground eccentric to the average tooth system of the straight bevel gears. One way to reduce this effect is to use a hydraulic or spring-loaded ball cage that presses all balls equally against their tooth spaces. Another way is to measure the positions of all tooth spaces and select three spaces whose total spacing error is minimal. For high-precision straight bevel gears, I prefer to locate on three balls that are nominally 120° apart and then check the finished runout statistically.
Recommended Tolerances for the Locating Elements
For straight bevel gears, the accuracy of the steel ball diameter and the accuracy of the fixture radius \(M\) are directly related to the final bore runout. I recommend the following practical values:
| Element | Recommended tolerance |
| Steel ball diameter | \(\pm 0.5\) \(\mu\)m |
| Spherical support radius | \(\pm 5\) \(\mu\)m |
| Ball cage radial position \(M\) | \(\pm 10\) \(\mu\)m |
| Clamp face perpendicularity | \(\pm 5\) \(\mu\)m over the hub diameter |
These values are only starting points. The required tolerance depends on the size and quality class of the straight bevel gears. For small instrument straight bevel gears, the fixture must be made to tighter limits. For large heavy-duty straight bevel gears, thermal effects and workpiece deformation are often larger than the fixture tolerances.
Calibration of the Fixture for Straight Bevel Gears
Before using a new fixture for straight bevel gears, I make a master part that has a bore and tooth spaces that are known to be accurately concentric. I mount the master part in the fixture and grind or gage the bore. The fixture axis is adjusted until the bore runout is within the desired tolerance. I then use a dial indicator on a reference plug placed through the fixture spindle. The indicator value at the ball center radius \(M\) is recorded as the fixture setting.
During batch production, I recheck the setting several times per shift. The spherical support and the balls of straight bevel gears are subject to wear, especially when the tooth flanks are not hardened. If the runout begins to increase, I inspect the balls, the spherical seat, and the tooth flanks of the straight bevel gears. Worn balls should be replaced as a set, never singly.
Use of the Involute Flank as a Datum
The tooth working surface of straight bevel gears is the involute flank. In the equivalent spur gear, the involute has a base circle at radius
\[
r_b = r_x \cos\alpha .
\]
The normal to the involute flank is tangent to the base circle. This is the reason why the ball formula depends on the pressure angle \(\alpha\). A sphere placed in the tooth space of straight bevel gears touches the flanks at points where the radii are normal to the involute profiles. By calculating the ball diameter from the involute geometry, the contact points are controlled and the fixture center is known.
When the tooth flank of straight bevel gears has a protective chamfer or a blunt tip, the ball may contact the chamfer instead of the involute. I therefore specify that the tooth flanks used for locating straight bevel gears must be free of burrs and must have a clean involute zone in the selected section. The ball should never touch the root fillet or the tip edge.
Thermal Effects and Measurement of Straight Bevel Gears
Grinding generates heat. If the fixture and the straight bevel gears become hot, the dimensions of both the balls and the blank change. The formula for \(d\) and \(M\) is based on the temperature at which the gear is intended to operate. I prefer to grind the bore at a controlled shop temperature. For high-volume production of straight bevel gears, the coolant temperature should be stabilized before the final bore pass.
When I measure \(M\) on an actual fixture, I use the same steel-ball diameter as that used in the calculation. The measurement should be taken after the blank has reached thermal equilibrium. A change of only a few degrees can make a measurable difference in the locating distance of straight bevel gears. This is especially important for large straight bevel gears, where the radius \(r_x\) is large and the thermal expansion is proportional to the radius.
Comparison with Other Locating Methods
There are several ways to mount straight bevel gears before grinding the axial bore. The most common methods are:
| Method | Datum | Typical runout | Remarks |
| Outside diameter chucking | OD surface | Moderate | OD is not a functional surface of the finished straight bevel gears |
| Back-face chucking | Back cone | Moderate | Good axial location, poor radial relationship to teeth |
| Pitch cone locating | Pitch cone | Good | Requires accurate pitch cone surface |
| Tooth-face locating with balls | Involute flanks | Excellent | Directly matches the functional datum of straight bevel gears |
Tooth-face mounting is the only method that uses the same surface as the final operating datum of straight bevel gears. It is therefore the most logical method for precision grinding. I have used it with straight bevel gears for differentials, pumps, and industrial gearboxes.
Advantages and Limitations
The main advantage of this method is improved coaxiality between the bore and the tooth system of straight bevel gears. A second advantage is that the axis is defined by the actual flanks, so any eccentricity of the outside diameter has no influence. A third advantage is that the fixture is relatively simple. The balls are inexpensive, easy to replace, and can be hard-chromed or ceramic-coated for long life.
There are also limitations. The method cannot be used on straight bevel gears whose teeth have not yet been cut. If the teeth are cut with excessive runout or irregular spacing, the balls will not repeat well. The method is also sensitive to tooth-thickness variation. For very soft blanks, localized indentation of the flanks can occur under high clamping forces. Finally, the fixture is unique to a particular size and geometry of straight bevel gears, so a family of fixtures is needed for a range of sizes.
Conclusion
For straight bevel gears, the involute tooth face is the most meaningful datum for machining the axial hole. I have described a fixture principle that uses hardened steel balls in the tooth spaces of straight bevel gears, together with a spherical support on the back face and clamping on the hub end face. The steel ball diameter \(d\) can be calculated from the local pitch radius \(r_x\), the pressure angle \(\alpha\), and the half angular tooth-space width \(\eta\). The locating distance \(M\) is also calculated from the same triangle formed by the gear axis, the contact point, and the ball center.
The formulas I use for straight bevel gears are:
\[
d = \frac{2 r_x \sin\eta}{\cos(\alpha – \eta)},
\]
\[
M = \frac{r_x \cos\alpha}{\cos(\alpha – \eta)}.
\]
These formulas are suitable both for initial fixture design and for process control on the shop floor. They give a direct physical interpretation of the ball location and are accurate enough for the bore-grinding operation of straight bevel gears when the tooth thickness and pressure angle are known.
I have found that the best results are obtained when the fixture is kept rigid, the balls are ground to a high class, and the tooth flanks are clean and accurately cut. Under these conditions, the bore of straight bevel gears can be ground with excellent coaxiality to the tooth system. The tooth-face mounting method is therefore an important technique for anyone who produces precision straight bevel gears.