
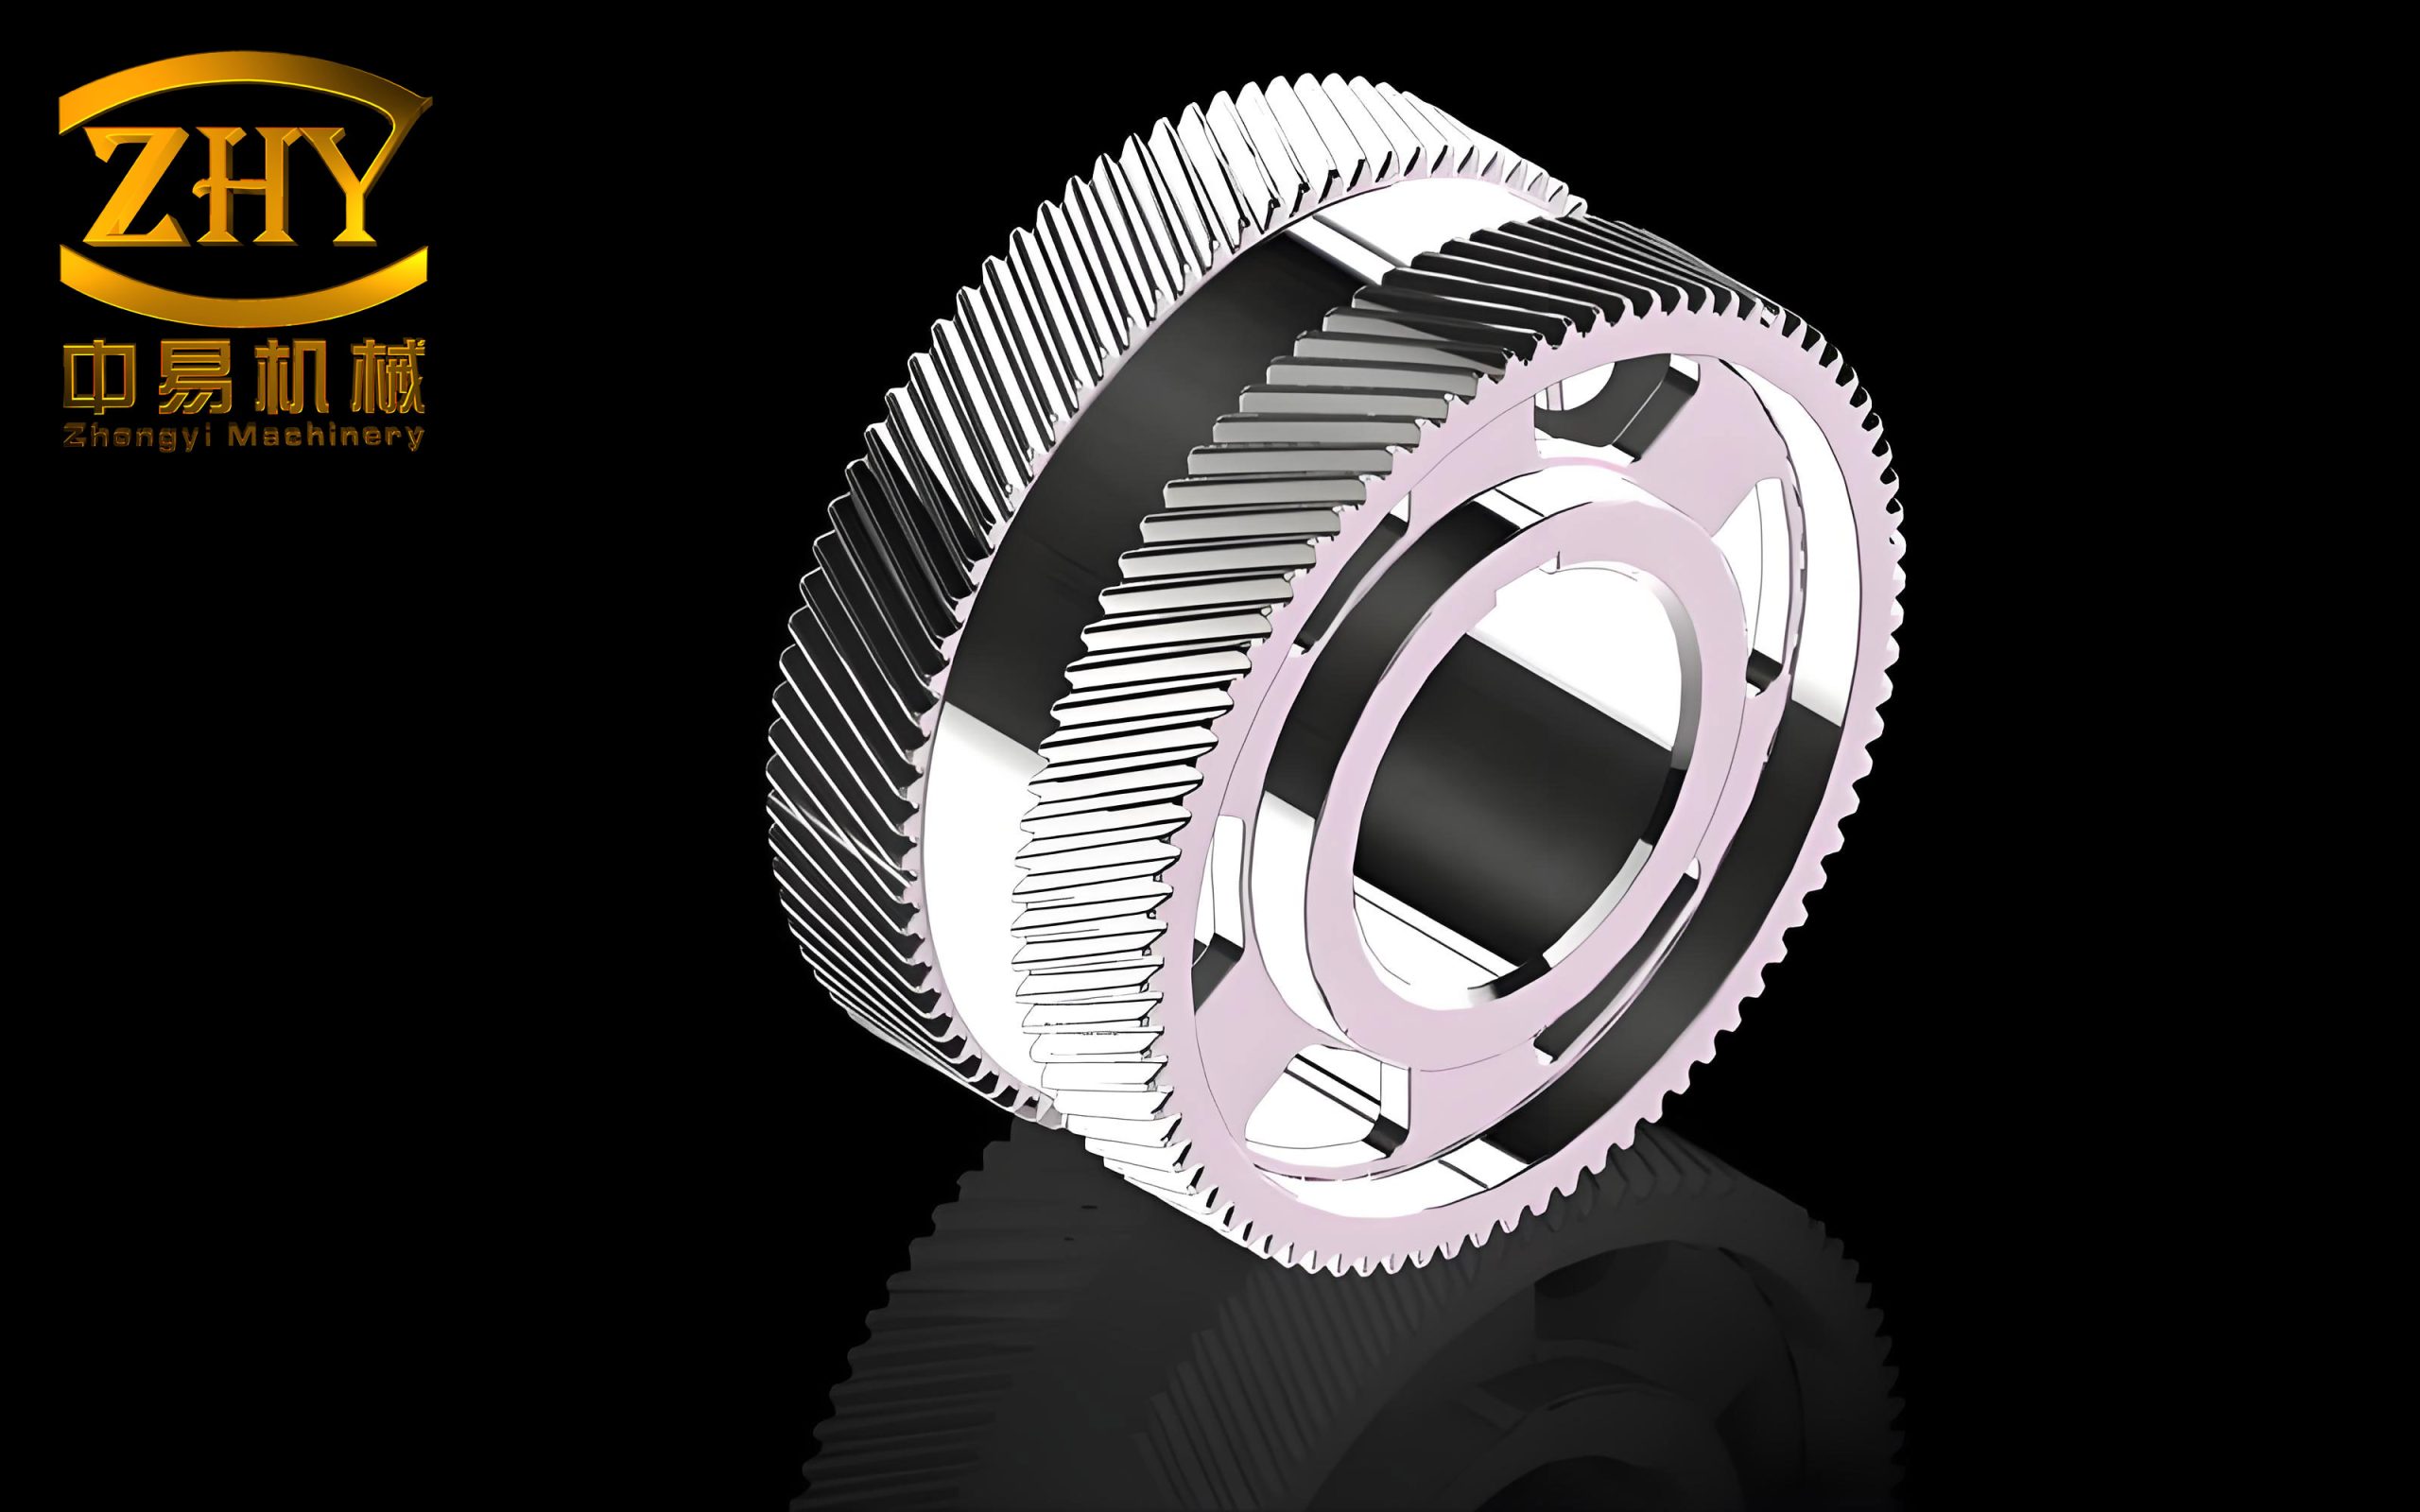
Herringbone gears, also referred to as double-helical gears, combine the high load-carrying capacity of helical gears with the inherent axial force cancellation achieved by opposing helix angles on two halves of the same gear. This unique configuration makes herringbone gears particularly suitable for high-power-density transmissions used in marine propulsion, aerospace actuation systems, heavy industrial machinery, and wind turbine drivetrains. Understanding the dynamic behavior of herringbone gear transmissions is essential for predictive maintenance, noise reduction, and reliability enhancement. Among the various excitation sources that affect gear dynamics, friction plays a particularly insidious role—it is ubiquitous, load-dependent, and its direction reverses across the pitch line, introducing additional parametric excitation into the system. This thesis presents a comprehensive investigation of the dynamic characteristics of herringbone gear transmissions under the influence of friction, including the effects of centering error and tooth tip modification.
My research begins with the development of a frictionless dynamic model to establish a baseline for comparison, then progressively adds complexity by introducing friction excitation, centering error, and tooth profile modification. The governing equations are derived using a lumped-parameter approach with spatial coordinate transformations that facilitate the separation of friction-induced responses from meshing force responses. The time-varying contact line length is computed analytically for different contact ratio conditions, and the time-varying meshing force is calculated via integration along the contact lines. Numerical integration using the Runge-Kutta method provides the dynamic responses under various operating conditions. The results reveal that friction significantly affects the out-of-plane vibration of herringbone gears, while centering error primarily introduces phase differences between the left and right helical halves, and tooth tip modification effectively smooths the meshing force fluctuations.
1. Dynamics of Herringbone Gear Transmission Without Friction
To establish a reference baseline for subsequent friction analysis, I first developed a 12-degree-of-freedom (DOF) lumped-parameter dynamic model of a single-stage herringbone gear pair. The herringbone gear is modeled as two coupled helical gear pairs sharing a common shaft. The governing differential equations incorporate time-varying meshing stiffness, damping, static transmission error, and bearing support stiffness. A special coordinate system was established such that the line of action is oriented parallel to the YOZ plane, allowing the meshing force to contribute only to the Y and Z directional responses. This eliminates unnecessary force decomposition and simplifies the mathematical formulation without loss of physical fidelity.
The key geometric parameters of the gear pair under investigation are summarized in Table 1. These parameters correspond to a laboratory-scale herringbone gear pair with a moderate helix angle, typical of industrial applications involving moderate to high speeds.
| Parameter | Symbol | Pinion (Gear 1) | Gear (Gear 2) |
|---|---|---|---|
| Number of teeth | Z | 37 | 79 |
| Module (mm) | m | 2.5 | |
| Normal pressure angle (°) | α | 20 | |
| Helix angle (°) | β | 15 | |
| Face width (mm) | B | 25 | |
1.1 Time-Varying Contact Line Length
The time-varying contact line length is the most fundamental parameter affecting both the meshing stiffness and the friction excitation. I derived analytical expressions for the single-tooth contact line length under two distinct contact ratio conditions.
For the case where the transverse contact ratio exceeds the face contact ratio (εα > εβ), the single-tooth contact line length as a function of the tooth position along the line of action is:
$$l(s_i) = \begin{cases} \dfrac{s_i}{\tan\beta_b}, & 0 \le s_i \le B\tan\beta_b \\[6pt] \dfrac{B}{\cos\beta_b}, & B\tan\beta_b \le s_i \le \varepsilon_\beta P_{bt} \\[6pt] \dfrac{\varepsilon_\beta P_{bt} – s_i}{\tan\beta_b} + \dfrac{B}{\cos\beta_b}, & \varepsilon_\beta P_{bt} \le s_i \le \varepsilon_\alpha P_{bt} \end{cases}$$
For the case where the face contact ratio dominates (εα < εβ), the contact line reaches its maximum value only when the tooth is fully engaged in the contact zone:
$$l(s_i) = \begin{cases} \dfrac{s_i}{\tan\beta_b}, & 0 \le s_i \le \varepsilon_\alpha P_{bt}\tan\beta_b \\[6pt] \dfrac{\varepsilon_\alpha P_{bt}}{\tan\beta_b}, & \varepsilon_\alpha P_{bt}\tan\beta_b \le s_i \le B\tan\beta_b \\[6pt] \dfrac{\varepsilon_\alpha P_{bt} + B\tan\beta_b – s_i}{\tan\beta_b}, & B\tan\beta_b \le s_i \le B\tan\beta_b + \varepsilon_\alpha P_{bt} \end{cases}$$
A critical methodological contribution of my work is the computation of the total time-varying contact line length. Rather than manually repeating the single-tooth function over consecutive meshing cycles—which can introduce artificial periodicity into the results—I considered a finite time window spanning from the moment a reference tooth (tooth ③) enters the contact zone until it completely exits. Within this window, five successive teeth contribute to the total contact line. The total contact line length is:
$$L(t) = \sum_{i=1}^{5} l_i(t)$$
where each li(t) is shifted in time by an integer multiple of the base pitch meshing period. Table 2 lists the piecewise intervals and the contributing teeth for each segment.
| Interval | Contributing teeth | Physical event |
|---|---|---|
| [t₀, t₁] | ③, ④, ⑤ | ⑤ fully exits, ③ still entering |
| [t₁, t₂] | ②, ③, ④ | ② enters, ④ begins exiting |
| [t₂, t₃] | ②, ③ | ④ fully exits, ② fully engaged |
| [t₃, t₄] | ①, ②, ③ | ① enters, ③ begins exiting |
| [t₄, t₅] | ①, ② | ③ fully exits, ② still engaged |
1.2 Time-Varying Meshing Force
The time-varying meshing force of the herringbone gear pair is calculated by integrating the elastic and damping forces along the instantaneous contact lines. Since the contact lines are continuous, the integration can be performed analytically. The meshing force is expressed as:
$$F_m(t) = k_t(t) \cdot f(\delta) + c_t(t) \cdot \dot{\delta}$$
where kt(t) is the time-varying meshing stiffness computed on the basis of the total contact line length:
$$k_t(t) = k_0 \cdot L(t)$$
and ct(t) is the time-varying meshing damping obtained from:
$$c_t(t) = 2\zeta_v \sqrt{k_t(t) \cdot m_{\text{eq}}}$$
Here, ζv is the damping ratio, and meq is the equivalent mass of the gear pair. The backlash function f(δ) is defined as:
$$f(\delta) = \begin{cases} \delta – b, & \delta > b \\ 0, & -b \le \delta \le b \\ \delta + b, & \delta < -b \end{cases}$$
where b is the half-backlash and δ is the relative displacement along the line of action, expressed as:
$$\delta = (x_p – x_g)\cos\alpha_t + (y_p – y_g)\sin\alpha_t + e_t(t)$$
Table 3 summarizes the dynamic responses of the frictionless herringbone gear transmission at three representative speeds.
| Speed (rpm) | Max meshing force (N) | Max transmission error (μm) | Max Y-direction displacement (μm) | Max Z-direction displacement (μm) |
|---|---|---|---|---|
| 600 | 2461.4 | 20.83 | 20.72 | 2.31 |
| 2000 | 2291.0 | 24.18 | 24.09 | 2.36 |
| 5000 | 2100.3 | 37.62 | 37.55 | 2.43 |
The results indicate that the herringbone gear transmission exhibits a predominantly linear behavior at low speed, with the meshing force following the contact line length pattern. At higher speeds, the inertia effects introduce curvature in the response, and the transmission error amplitude increases noticeably. The frequency spectra of all responses show a single dominant component corresponding to the tooth meshing frequency, confirming the periodic nature of the excitation.
2. Dynamic Characteristics of Herringbone Gear Transmission with Friction
Building on the frictionless model, I extended the formulation to include friction excitation. A 16-DOF model was developed to accommodate the additional friction-induced forces and moments. The key enhancement is the computation of the time-varying contact line lengths on each side of the pitch line—a critical quantity because the friction force direction reverses at the pitch line.
2.1 Contact Line Lengths on Each Side of the Pitch Line
For the herringbone gear parameters given in Table 1, the condition εα < εβ and lp < εβPbt < lg holds. The contact line length on the pinion side (left of the pitch line) for a single tooth is:
$$a_1(s_i) = \begin{cases} \dfrac{s_i – l_p}{\tan\beta_b}, & l_p \le s_i \le \varepsilon_\alpha P_{bt} \\[6pt] \dfrac{\varepsilon_\alpha P_{bt} – l_p}{\tan\beta_b}, & \varepsilon_\alpha P_{bt} \le s_i \le \varepsilon_\beta P_{bt} \\[6pt] \dfrac{\varepsilon_\beta P_{bt} + \varepsilon_\alpha P_{bt} – s_i – l_p}{\tan\beta_b}, & \varepsilon_\beta P_{bt} \le s_i \le \varepsilon_\beta P_{bt} + \varepsilon_\alpha P_{bt} – l_p \\[6pt] 0, & \text{otherwise} \end{cases}$$
The corresponding contact line length on the gear side (right of the pitch line) is:
$$a_2(s_i) = \begin{cases} \dfrac{s_i}{\tan\beta_b}, & 0 \le s_i \le \varepsilon_\alpha P_{bt} \\[6pt] \dfrac{\varepsilon_\alpha P_{bt}}{\tan\beta_b}, & \varepsilon_\alpha P_{bt} \le s_i \le l_p \\[6pt] \dfrac{\varepsilon_\beta P_{bt} + l_p – s_i}{\tan\beta_b}, & l_p \le s_i \le l_p + \varepsilon_\alpha P_{bt} – \varepsilon_\beta P_{bt} \\[6pt] \dfrac{\varepsilon_\alpha P_{bt} + \varepsilon_\beta P_{bt} – s_i}{\tan\beta_b}, & l_p + \varepsilon_\alpha P_{bt} – \varepsilon_\beta P_{bt} \le s_i \le \varepsilon_\beta P_{bt} + \varepsilon_\alpha P_{bt} – l_p \\[6pt] 0, & \text{otherwise} \end{cases}$$
The total time-varying contact line lengths on each side of the pitch line are then obtained by summing over all teeth simultaneously in contact:
$$L_{\text{pinion}}(t) = \sum_{i=1}^{5} a_{1i}(t), \qquad L_{\text{gear}}(t) = \sum_{i=1}^{5} a_{2i}(t)$$
Table 4 illustrates the piecewise segmentation of the total friction-driving contact line lengths over one meshing cycle.
| Segment | Time interval | L_pinion(t) (mm) | L_gear(t) (mm) | Active teeth |
|---|---|---|---|---|
| 1 | [0, t₁] | 5.27–7.63 | 3.78–5.12 | ③, ④, ⑤ |
| 2 | [t₁, t₂] | 7.63–8.26 | 5.12–4.95 | ②, ③, ④ |
| 3 | [t₂, t₃] | 8.26–7.98 | 4.95–4.63 | ②, ③ |
| 4 | [t₃, t₄] | 7.98–7.12 | 4.63–4.07 | ①, ②, ③ |
| 5 | [t₄, t₅] | 7.12–5.84 | 4.07–3.31 | ①, ② |
2.2 Friction Force Computation
The friction force on the tooth surface is calculated by integrating the instantaneous friction contribution along the contact lines, with the direction depending on the side of the pitch line:
$$F_f(t) = \mu \left[ \int_{L_{\text{pinion}}} p(s)\,ds – \int_{L_{\text{gear}}} p(s)\,ds \right]$$
where μ is the friction coefficient, and p(s) is the local contact pressure distribution. Using a lumped equivalent approach, the total friction force simplifies to:
$$F_f(t) = \mu F_m(t) \left( L_{\text{pinion}}(t) – L_{\text{gear}}(t) \right) / L(t)$$
The friction-induced moments on the pinion and gear are computed by considering the moment arm of each contact line segment about the gear center:
$$T_{fq} = \mu F_m(t) \cdot \frac{\sum_i a_{1i}(t) R_{c1i} – \sum_i a_{2i}(t) R_{c2i}}{L(t)}$$
$$T_{fp} = \mu F_m(t) \cdot \frac{\sum_i a_{2i}(t) R_{c2i} – \sum_i a_{1i}(t) R_{c1i}}{L(t)}$$
where Rc1i and Rc2i are the moment arms for the i-th contact segment on the pinion and gear sides, respectively.
2.3 Sixteen-DOF Dynamic Model and Governing Equations
The 16-DOF model treats the pinion and gear as rigid bodies connected by a pair of helical gear meshes. Each body has four DOFs: two translational displacements (Y and Z), one axial displacement (X), and one torsional rotation (θ). The support stiffness and damping at both ends of each shaft are modeled as linear springs and dampers. The dynamic equilibrium equations for the pinion are:
$$m_q \ddot{x}_q + c_{q1x}\dot{x}_q + c_{q2x}\dot{x}_q + k_{q1x}x_q + k_{q2x}x_q = -F_f(t)$$
$$m_q \ddot{y}_q + c_{q1y}\dot{y}_q + c_{q2y}\dot{y}_q + k_{q1y}y_q + k_{q2y}y_q = F_m(t)\sin\alpha_t + F_f(t)\cos\alpha_t$$
$$m_q \ddot{z}_q + c_{q1z}\dot{z}_q + c_{q2z}\dot{z}_q + k_{q1z}z_q + k_{q2z}z_q = F_m(t)\cos\alpha_t$$
$$I_q \ddot{\theta}_q = T_{q1} – F_m(t) r_{bq} – T_{fq}$$
with analogous equations for the gear. The meshing force F_m(t) couples the translational DOFs through the relative displacement:
$$\delta(t) = (y_q – y_p)\sin\alpha_t + (z_q – z_p)\cos\alpha_t + r_{bq}\theta_q – r_{bp}\theta_p + e_t(t)$$
To improve numerical conditioning and computational efficiency, I normalized the equations by introducing a displacement scale bc and a characteristic time τ. The nondimensional equations were then reduced to first-order form and solved using the built-in MATLAB solver ode45, which implements an explicit Runge-Kutta (4,5) formula with adaptive step size control.
2.4 Dynamic Responses with Friction
Table 5 compares the dynamic responses of the herringbone gear transmission with and without friction at the three operating speeds.
| Speed (rpm) | Condition | F_m max (N) | X-displacement (μm) | Y-displacement (μm) | Z-displacement (μm) |
|---|---|---|---|---|---|
| 600 | Without friction | 2461.4 | 0 | 20.72 | 2.31 |
| 600 | With friction | 2461.9 | 0.29 | 20.83 | 2.31 |
| 2000 | Without friction | 2291.0 | 0 | 24.09 | 2.36 |
| 2000 | With friction | 2292.3 | 0.17 | 24.17 | 2.37 |
| 5000 | Without friction | 2100.3 | 0 | 37.55 | 2.43 |
| 5000 | With friction | 2101.8 | 0.11 | 37.51 | 2.44 |
The most significant observation is that friction has a negligible effect on the meshing force magnitude, altering it by less than 0.1% in all cases. However, friction is the sole source of the X-direction displacement, which would be identically zero without friction. The X-direction response amplitude decreases with increasing speed, from 0.29 μm at 600 rpm to 0.11 μm at 5000 rpm. This is because the friction force direction alternates at the pitch line, and the alternation frequency increases with speed, making the excitation less effective at exciting the lightly damped axial mode at higher frequencies.
Table 6 presents the effects of damping on the dynamic response of herringbone gears with friction. The results reveal that damping prominently influences the Y and Z direction responses, which are dominated by the meshing stiffness at lower frequencies. Without damping, the response amplitudes oscillate wildly and lose the clear relationship with speed that was observed in the damped case.
| Quantity | With damping | Without damping |
|---|---|---|
| Max meshing force (N) | 2292.3 | 3123.4 |
| Max transmission error (μm) | 24.17 | 38.67 |
| X-displacement RMS (μm) | 0.17 | 0.31 |
| Y-displacement RMS (μm) | 24.17 | 38.66 |
| Z-displacement RMS (μm) | 2.37 | 4.31 |
3. Influence of Centering Error on Herringbone Gear Dynamics
Centering error is a specific manufacturing and assembly error unique to herringbone gears. It represents the circumferential misalignment between the opposing helical halves, measured as the axial deviation of the prolongation intersection points of the tooth flank helices across the central reference plane. This error introduces a phase lag between the two helical gear meshes, effectively destroying the perfect symmetry that gives herringbone gears their characteristic axial-force cancellation.
3.1 Formulation of Centering Error
The centering error ΔT is related to the helix angle and the geometric offsets shown in the schematic representation of a herringbone gear pair with centering error. The relationship is:
$$\Delta T = (l_1 – l_2) \cdot \tan\beta$$
where l₁ and l₂ are the distances from the intersection points C and D to a reference plane. In my analysis, I considered errors ranging from 25 μm to 500 μm. A positive error implies that the right-hand helical half leads the left-hand half.
3.2 Modified Time-Varying Contact Line Length
With centering error, the contact line length of the right half is shifted relative to the left half. For the case εα < εβ with lp < εβPbt < lg, the pinion-side contact line length of the left and right halves are:
$$a_{L1}(s_i) = a_1(s_i), \qquad a_{R1}(s_i) = a_1\left(s_i – \frac{\Delta T}{\tan\beta}\right)$$
Similarly, the gear-side contact line lengths are:
$$a_{L2}(s_i) = a_2(s_i), \qquad a_{R2}(s_i) = a_2\left(s_i – \frac{\Delta T}{\tan\beta}\right)$$
The total time-varying contact line length for the left and right halves must be computed by summing over all five teeth separately for each half. A 19-node piecewise segmentation is required to accurately capture the response when the right-half teeth lead the left-half teeth by the centering-error-induced phase.
3.3 Dynamic Response with Centering Error
Table 7 compares the dynamic responses of the herringbone gear transmission with and without a centering error of 50 μm, at 2000 rpm.
| Quantity | Without centering error | With 50 μm error | Percent change |
|---|---|---|---|
| Left-half meshing force max (N) | 2292.3 | 2341.2 | +2.13% |
| Right-half meshing force max (N) | 2292.3 | 2419.6 | +5.56% |
| Total meshing force max (N) | 4584.6 | 4631.5 | +1.02% |
| Transmission error (μm) | 24.17 | 24.42 | +1.03% |
The presence of a 50 μm centering error causes the right-half meshing force to increase more noticeably than the left-half. This imbalance is attributed to the phase shift of the contact line length pattern, which momentarily allows the right half to carry a greater proportion of the load during certain portions of the meshing cycle.
Figure 1 shows the variation of the total meshing force maximum with increasing centering error. The total maximum force increases only slightly—approximately 1.0% for a 50 μm error, 1.6% for 150 μm, and 2.1% for 500 μm. However, the stability of the total meshing force near its peak is more significantly affected. The minimum value within the peak region decreases more substantially with increasing error, indicating that the peak flattens and distorts as the error grows.
| Error (μm) | Normalized peak max (-) | Normalized peak min (-) | Peak fluctuation (%) |
|---|---|---|---|
| 0 | 1.0000 | 0.9992 | 0.08 |
| 25 | 1.0028 | 0.9971 | 0.57 |
| 50 | 1.0102 | 0.9912 | 1.90 |
| 100 | 1.0147 | 0.9811 | 3.36 |
| 250 | 1.0189 | 0.9654 | 5.35 |
| 500 | 1.0213 | 0.9477 | 7.36 |
The frequency spectra of the total meshing force under different centering errors show that the main meshing frequency component remains unchanged, but higher harmonic components gradually emerge as the error increases. This suggests that centering error primarily introduces additional excitation harmonics into the herringbone gear transmission, which may contribute to noise and vibration at frequencies not present in the perfectly symmetric case.
4. Influence of Tooth Tip Modification on Herringbone Gear Dynamics
Tooth tip modification is one of the most practically important profile modifications for improving gear performance. By deliberately removing material from the tooth tip region, engineers can reduce the sudden engagement impact when a tooth enters mesh, thereby reducing noise and vibration. In my study, I considered the effect of linear tooth tip modification on the dynamic characteristics of herringbone gear transmissions with friction.
4.1 Time-Varying Mesh Stiffness with Modification
The time-varying mesh stiffness with tooth tip modification was calculated using a slicing method. The gear tooth is discretized into a large number of thin slices, and the stiffness of each slice is computed using the potential energy method, which accounts for the Hertzian contact stiffness, bending stiffness, shear stiffness, axial compressive stiffness, and gear body stiffness:
$$\frac{1}{k_i} = \frac{1}{k_{h,i}} + \frac{1}{k_{b,i}} + \frac{1}{k_{s,i}} + \frac{1}{k_{a,i}} + \frac{1}{k_{f,i}}$$
For the modified profile, the slice stiffness is adjusted based on the local profile error Ei:
$$k_i^{\text{mod}} = \begin{cases} k_i, & E_i \le E_{\min} + \delta_{\text{def}} \\ 0, & E_i > E_{\min} + \delta_{\text{def}} \end{cases}$$
where δdef is the local deformation under load, and Emin is the minimum profile error among the engaging slices. This approach effectively removes the slices whose modification amount exceeds the local elastic deformation, simulating the delayed engagement caused by tip relief.
Table 9 summarizes the influence of modification height on the mean mesh stiffness and its fluctuation for the herringbone gear pair.
| Modification height (mm) | Mean mesh stiffness (N/m/μm) | Stiffness fluctuation amplitude (N/m/μm) | Reduction in fluctuation (%) |
|---|---|---|---|
| 0 (no modification) | 14.89 | 1.87 | — |
| 0.9 | 14.76 | 1.71 | 8.56% |
| 1.2 | 14.68 | 1.62 | 13.37% |
| 1.5 | 14.59 | 1.58 | 15.51% |
4.2 Dynamic Response with Modification
Table 10 compares the dynamic responses of the herringbone gear transmission at 2000 rpm under different modification heights and maximum modification amounts.
| h (mm) | Δmax (μm) | Max meshing force (N) | Transmission error (μm) | X-displacement (μm) | Y-displacement (μm) |
|---|---|---|---|---|---|
| 0 | 0 | 2292.3 | 24.17 | 0.17 | 24.17 |
| 0.9 | 25 | 2201.5 | 23.88 | 0.16 | 23.88 |
| 1.2 | 25 | 2162.4 | 23.69 | 0.16 | 23.69 |
| 1.2 | 15 | 2227.8 | 23.95 | 0.16 | 23.95 |
| 1.2 | 15 | 2208.3 | 23.87 | 0.16 | 23.87 |
The results demonstrate that tooth tip modification with appropriate parameters can reduce the maximum meshing force by approximately 5% while modestly decreasing the transmission error. The X-direction displacement, which is directly proportional to the friction force, also decreases slightly because the friction force is proportional to the meshing force. This indicates that tooth tip modification indirectly reduces friction excitation by lowering the dynamic meshing force.
Figure 2 shows the time-domain meshing force waveforms before and after modification. The modified case exhibits a smoother curve with less abrupt transitions, confirming the beneficial effect of tip relief on reducing mesh impact. The corresponding frequency spectra show that the modification suppresses the higher-order harmonics of the meshing frequency, concentrating the response energy at the fundamental meshing frequency. This spectral simplification is a clear indicator of improved dynamic behavior.
5. Discussion and Key Findings
The cumulative results of this research provide several important insights into the dynamic behavior of herringbone gears:
First, friction excitation, while traditionally overlooked in many herringbone gear dynamic models, has a measurable influence on the axial (X-direction) response. The X-direction displacement is identically zero in frictionless models, but reaches a maximum of 0.29 μm at 600 rpm and decays to 0.11 μm at 5000 rpm in the friction-inclusive model. This frequency-dependent behavior arises from the alternating direction of friction at the pitch line, which makes the axial excitation less effective at higher speeds due to the inherent low-pass filtering characteristic of the gear-support system. The influence of friction on the Y and Z direction responses is relatively small (less than 0.5%), indicating that the primary meshing plane dynamics are dominated by the meshing stiffness and damping, rather than friction.
Second, damping plays a crucial role in moderating the influence of friction on herringbone gear dynamics. In the absence of damping, friction-induced responses become unstable, and the displacement amplitudes no longer follow a clear trend with respect to speed. From a design perspective, adequate damping—whether from bearing lubrication, structural damping, or added damping treatments—can effectively suppress friction-induced vibration in herringbone gears.
Third, centering error has a nuanced but practically relevant effect on the dynamics of herringbone gears with friction. The error primarily introduces a time-varying phase lag between the two helical halves, which breaks the symmetry of load sharing between the left and right halves. The right half (which leads the phase) carries a greater proportion of the load, contributing to a slightly increased total meshing force. While the peak value of the total meshing force changes only minimally (2.1% for a 500 μm error), the fluctuation amplitude within the peak region increases substantially—up to 7.4% for the 500 μm error. This increased fluctuation can lead to higher vibration levels and reduced fatigue life. The practical implication is that even small centering errors should be carefully controlled in high-precision herringbone gear applications.
Fourth, tooth tip modification offers a straightforward and effective means of improving the dynamic performance of herringbone gears under friction excitation. By reducing the mesh stiffness fluctuation and smoothing the load transitions at tooth engagement and disengagement, modification reduces the maximum dynamic meshing force by approximately 5% with a modest reduction in transmission error. This reduction in dynamic force also implies a proportionate reduction in friction force, further enhancing the stability of the herringbone gear transmission. The results suggest that a modification height around 1.2 mm with a maximum modification amount of 25 μm provides a good balance between load reduction and contact ratio preservation for the gear pair studied.
Table 11 provides a consolidated comparison of the parametric effects studied in this work.
| Parameter | Effect on meshing force | Effect on axial response | Effect on transmission error | Overall stability impact |
|---|---|---|---|---|
| Friction | Negligible (<0.1%) | Significant (sole source) | Negligible | Moderate |
| Centering error (50 μm) | +1.0% | Phase shift ± | +1.0% | Moderate |
| Damping removal | +36% | +82% | +60% | Critical |
| Tip modification | −5% | −6% | −2% | Beneficial |
6. Conclusions
This thesis systematically investigated the dynamic characteristics of herringbone gear transmissions with friction excitation, including the effects of centering error and tooth tip modification. Through the development of multi-DOF lumped-parameter dynamic models, detailed time-varying contact line length formulations, and extensive numerical simulations, the following key conclusions can be drawn:
(1) The frictionless dynamic model of herringbone gears established a reliable baseline for comparison. The time-varying contact line length computation method, which avoids artificial periodicity by considering a full engagement cycle of a reference tooth, proved essential for accurately capturing the dynamic meshing force pattern.
(2) The 16-DOF friction-inclusive model revealed that friction excitation primarily manifests in the axial direction of herringbone gears. The X-direction displacement amplitude, which would be identically zero in a frictionless model, reaches meaningful values at low speeds and decreases with increasing speed. Friction does not meaningfully alter the meshing force magnitude but does influence the overall vibration level.
(3) Damping is critical for mitigating friction-induced vibration in herringbone gears. Complete removal of damping leads to unstable responses and significantly larger amplitudes, demonstrating the necessity of adequate damping in practical designs.
(4) Centering error introduces a phase mismatch between the helical halves, leading to asymmetric load sharing. While the peak meshing force changes only slightly, the fluctuation within the peak region increases appreciably with increasing error. For high-precision applications, the centering error should be controlled within a tight tolerance to minimize dynamic excitation.
(5) Tooth tip modification with appropriately selected parameters reduces both the mean mesh stiffness and its fluctuation, resulting in smoother meshing force waveforms and reduced vibration levels. The study confirmed that modification also indirectly reduces friction excitation by lowering the dynamic meshing force, making it a valuable tool for improving the stability of herringbone gear transmissions.
The findings of this research contribute to a deeper understanding of friction-related dynamics in herringbone gears and provide practical guidance for the design and optimization of herringbone gear transmission systems subjected to realistic operating conditions. The modeling framework and analysis methods presented can be extended to more complex herringbone gear systems, including planetary arrangements and multi-stage transmissions, where the interplay of friction, assembly errors, and profile modifications may have even more pronounced effects.