
I studied the temperature field of a 20CrMnTi steel spiral bevel gear during hard-tooth-surface heat treatment, including carburizing, quenching, and low-temperature tempering. My main objective was to understand how non-uniform heating and cooling generate thermal gradients inside the spiral bevel gear, because those gradients are among the strongest drivers of heat-treatment distortion. I treated the spiral bevel gear as a coupled thermal-fluid-solid system rather than as an isolated solid body, since the quenching medium flow, boiling behavior, wall heat flux, and internal phase transformation all interact during the cooling stage. The spiral bevel gear geometry is complex, and its tooth surface, root, web, and core do not respond to heating or cooling at the same rate. Therefore, I focused on the evolution of temperature at the tooth surface, pitch region, root, and core, and I optimized both the heating schedule and the quenching parameters to improve temperature uniformity.
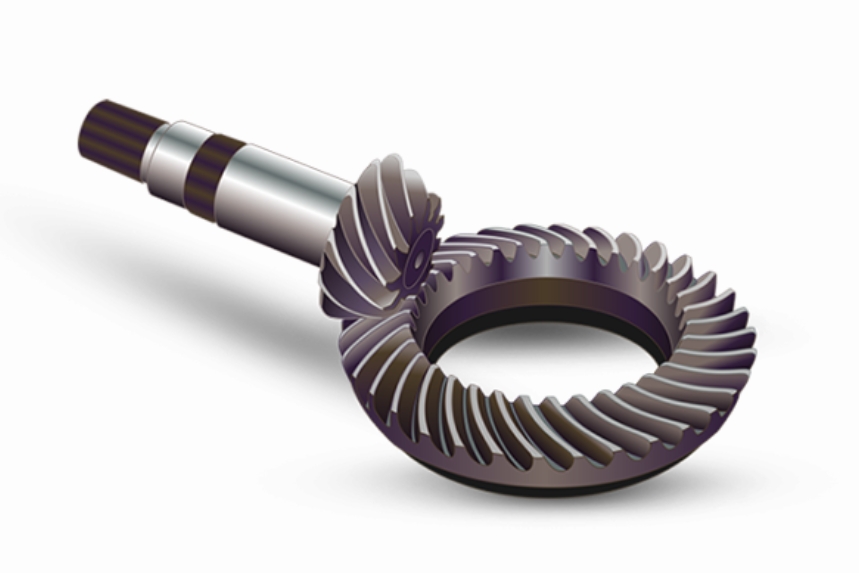
I used a temperature-microstructure coupling model for the solid spiral bevel gear and a boiling-based fluid heat-transfer model for the quenchant. The two domains were connected through a fluid-solid interface. The solid model solved transient heat conduction with latent heat from phase transformation, while the fluid model solved flow and boiling heat transfer in the quenching tank. I then coupled the two solvers so that the wall temperature from the spiral bevel gear influenced the quenchant boiling regime, and the quenchant heat flux influenced the spiral bevel gear temperature field. This coupled approach allowed me to evaluate the temperature standard deviation along the tooth length and tooth width directions as quantitative indicators of uniformity.
1. Governing equations for the solid spiral bevel gear
For the solid domain, I used the Fourier three-dimensional heat-conduction equation with a source term representing latent heat. The energy balance for the spiral bevel gear is
$$ \nabla \cdot (\lambda \nabla T) + Q = \frac{\partial (c_p \rho T)}{\partial t} $$
where \(\lambda\) is the thermal conductivity, \(T\) is the instantaneous temperature, \(Q\) is the latent heat associated with phase transformation, \(\rho\) is the density, \(c_p\) is the specific heat capacity, and \(t\) is time. During quenching, the spiral bevel gear undergoes diffusion-controlled and diffusionless transformations. I included both types in the solid model.
The total latent heat was written as the sum of contributions from all transforming phases:
$$ Q = \sum_{i=1}^{n} Q_i = \sum_{i=1}^{n} \Delta H_i \frac{dV_i}{dt}, \quad i=1,\ldots,n $$
where \(\Delta H_i\) is the transformation enthalpy of phase \(i\), and \(V_i\) is the volume fraction of that phase. For diffusion-controlled transformations such as ferrite, pearlite, and bainite, I combined the Johnson-Mehl-Avrami equation with the Scheil additivity rule to account for continuous cooling. The transformed fraction at the next increment was calculated as
$$ f_{i+1} = 1 – \exp\left[-b_{i+1}\left(t^*_{i+1} + \Delta t\right)^{n_{i+1}}\right] $$
where \(f_{i+1}\) is the transformed volume fraction, \(b_{i+1}\) and \(n_{i+1}\) are kinetic parameters, and \(\Delta t\) is the time increment. The virtual transformation time was obtained from
$$ t^*_{i+1} = \left[\frac{-\ln(1-f_i)}{b_{i+1}}\right]^{1/n_{i+1}} $$
and the additivity condition was expressed as
$$ t = \sum_{i=1}^{n} \frac{\Delta t_i}{(t_0)_i}, \quad i=1,\ldots,n $$
where \((t_0)_i\) is the incubation period for the \(i\)-th transformation. For the diffusionless martensitic transformation, I used the Koistinen-Marburger relation:
$$ f = 1 – \exp\left[-\alpha(M_s – T)\right] $$
where \(f\) is the martensite volume fraction, \(\alpha\) is a kinetic parameter, \(M_s\) is the martensite start temperature, and \(T\) is the current temperature. In my simulation, I set \(\alpha = 0.011\) for the 20CrMnTi steel spiral bevel gear, because this value gave a reasonable description of the martensite evolution during quenching.
2. Fluid heat-transfer and boiling model
For the quenchant, I used a boiling heat-transfer model based on the Rensselaer Polytechnic Institute wall heat-flux formulation. The total wall heat flux from the quenchant to the spiral bevel gear surface was separated into single-phase convection, evaporation, and transient quenching contributions:
$$ q_w = q_{con} + q_{ev} + q_{qui} $$
The convective contribution was
$$ q_{con} = h_{con} A_{con} (T_w – T_l) $$
the evaporation contribution was
$$ q_{ev} = f N \frac{\pi}{6} d_w^3 \rho_g h_{lg} $$
and the transient quenching contribution was
$$ q_{qui} = \frac{2 A_b f}{\tau_w} \sqrt{\frac{\lambda_l \rho_l c_{pl}}{\pi}} (T_w – T_l) $$
Here, \(h_{con}\) is the single-phase convective heat-transfer coefficient, \(A_{con}\) is the fraction of wall area not occupied by bubbles, \(T_w\) is the wall temperature, \(T_l\) is the bulk liquid temperature, \(f\) is the bubble departure frequency, \(N\) is the nucleation site density, \(d_w\) is the bubble departure diameter, \(\rho_g\) is the vapor density, \(h_{lg}\) is the latent heat of vaporization, \(A_b\) is the remaining area fraction, \(\tau_w\) is the waiting period, \(\lambda_l\) is the liquid thermal conductivity, \(\rho_l\) is the liquid density, and \(c_{pl}\) is the liquid specific heat capacity. This formulation allowed me to capture the different boiling stages that occur when the hot spiral bevel gear enters the quenchant.
3. Fluid-solid coupling
The fluid and solid domains were coupled at the wetted surface of the spiral bevel gear. I used a wall-function method to estimate the heat flux from the fluid to the wall:
$$ q_W = \frac{y_p^+}{u_p^*} \frac{T_P – T_W}{y_P} \mu c_p $$
where \(y_p^+\) and \(u_p^*\) are dimensionless wall variables, \(T_P\) is the temperature at the first near-wall node, \(T_W\) is the wall temperature, \(y_P\) is the distance from the first node to the wall, \(\mu\) is the dynamic viscosity, and \(c_p\) is the specific heat capacity. The coupling variables were transferred across non-matching meshes using interpolation. The structural displacement and thermal fields were projected as
$$ u_s(x) = \sum_{i=1}^{n_s} N_i^s(x) u_s^i $$
and the conservative interface integration was written as
$$ \int_{\Gamma_f} N_k^f(x) N_i^s(x)\,dx = \sum_{j=1}^{n_f} \sum_{g=1}^{n_{gp,j}} w_g N_k^f(x_{g,j}) N_i^s(\Pi_s(x_{g,j})) $$
where \(N_i^s\) and \(N_k^f\) are interpolation functions in the solid and fluid domains, \(n_{gp,j}\) is the number of Gauss points in fluid element \(j\), \(w_g\) is the quadrature weight, and \(\Pi_s\) is the projection from the fluid mesh to the solid mesh. This coupling strategy enabled me to model the spiral bevel gear quenching process as a genuinely multi-physics problem.
4. Material and process parameters
The spiral bevel gear was made of 20CrMnTi steel. I used the nominal composition and thermo-physical properties listed in Table 1 and Table 2. These properties were required for the solid heat-conduction model and for the phase-transformation calculations.
| Element | Nominal content / wt.% |
|---|---|
| C | 0.17-0.23 |
| Si | 0.17-0.37 |
| Mn | 0.80-1.10 |
| Cr | 1.00-1.30 |
| Ti | 0.04-0.10 |
| Fe | Balance |
| Property | Value used in the model |
|---|---|
| Density, \(\rho\) | 7850 kg/m³ |
| Thermal conductivity, \(\lambda\) | 42 W/(m·K) at room temperature |
| Specific heat capacity, \(c_p\) | 460 J/(kg·K) at room temperature |
| Martensite start temperature, \(M_s\) | Approximately 360 °C for the carburized case |
| Kinetic parameter, \(\alpha\) | 0.011 |
| Carburizing temperature | Approximately 850 °C |
| Quenching temperature range | 810-870 °C |
| Tempering temperature | 170 °C |
I created a mesh for the spiral bevel gear with refined elements near the tooth surface, root, and fillet, because these regions experience the steepest temperature gradients. I selected four characteristic points on a mid-tooth section: point A on the tooth tip surface, point B on the pitch surface, point C at the root, and point D in the core. The core point was placed near the intersection of the tooth width centerline and the root circle. These points allowed me to track the thermal history of the spiral bevel gear during carburizing, quenching, and tempering.
| Point | Location on the spiral bevel gear | Role in the analysis |
|---|---|---|
| A | Tooth tip surface | Fastest heating and cooling response |
| B | Pitch surface | Load-bearing surface thermal history |
| C | Root region | Stress concentration and delayed cooling |
| D | Core | Slowest heating and cooling response |
5. Carburizing heating strategy and temperature evolution
I adopted preheating, stepwise heating, and holding to reduce the temperature difference between the tooth surface and the core of the spiral bevel gear. Without such a schedule, the surface can reach the carburizing temperature while the core remains much colder, which creates a large thermal gradient and promotes distortion. The heating schedule I used is summarized in Table 3.
| Stage | Time interval / s | Purpose | Typical temperature range / °C |
|---|---|---|---|
| Initial state | 0 | Room-temperature spiral bevel gear | 25 |
| First heating | 0-1200 | Preheat and reduce surface-core gradient | 25 to about 500 |
| First holding | 1200-7800 | Homogenize temperature | About 500-600 |
| Second heating | 9000-10000 | Stepwise heating to carburizing temperature | 600 to about 850 |
| Second holding | 10000-18000 | Austenitization and temperature equalization | 830-850 |
| Diffusion hold | 18000-48600 | Carbon diffusion and thermal stabilization | 840-850 |
At the beginning of the first heating stage, the surface heated faster than the core. The maximum surface-core difference during the first heating and first holding stage was about 22.4 °C. This difference was much smaller than the difference that would occur under direct rapid heating. During the second heating stage, the surface temperature increased quickly again, but the core temperature also continued to rise because of the earlier preheating and holding. By the end of the second holding stage, point A reached approximately 849.8 °C, while point D reached approximately 834.5 °C. The temperature distribution became more uniform, and the entire spiral bevel gear reached a state suitable for austenitization and carbon diffusion.
| Stage | Point A / °C | Point D / °C | Surface-core difference / °C | Observation |
|---|---|---|---|---|
| First heating peak | Temperature rising | Temperature rising slowly | Up to about 22.4 | Preheating reduces the initial shock |
| First holding end | Approximately 600 | Approximately 580 | About 20 | Gradient begins to decrease |
| Second holding end | 849.8 | 834.5 | 15.3 | Surface and core approach equilibrium |
| Diffusion hold | 850.2 | 845.7 | 4.5 | Uniform austenitic state |
During the diffusion hold, the surface and core temperatures both decreased slowly and then stabilized. At one representative moment, point A was about 850.2 °C and point D was about 845.7 °C. The temperature difference was therefore only a few degrees, and the spiral bevel gear was close to a uniform austenitic condition. I also observed that the tooth tip outer edge was usually the first region to heat and the first region to reach a high temperature, because it has the largest exposed area and receives heat from several directions. At later times, however, the core became slightly hotter than the outermost edge in some diffusion stages, which indicates that the stepwise schedule successfully redistributed heat through the spiral bevel gear.
6. Quenching and cooling behavior
Quenching is the most complex stage because the temperature field of the spiral bevel gear is coupled to the quenchant flow, boiling, and phase transformation. I first simulated the quenching process with the thermal-fluid-solid model and tracked the temperature at the four characteristic points. The cooling curves showed that point A cooled fastest, while point D cooled slowest. Point C, at the root, cooled more slowly than the pitch and tip, and its cooling behavior was closer to that of the core. This behavior is caused by the geometry of the spiral bevel gear: the tooth tip is directly exposed to the moving quenchant, while the root and core are partially shielded and must rely on conduction to remove heat.
| Time / s | Point A / °C | Point B / °C | Point C / °C | Point D / °C | Thermal state |
|---|---|---|---|---|---|
| 0.5 | Rapid drop | Slight drop | Small drop | Nearly unchanged | Surface contacts quenchant |
| 5 | About 335 | About 620 | About 700 | Above 797 | Large surface-core gradient |
| 15 | Below 200 | About 480 | About 620 | About 668 | Core begins to cool |
| 30 | Low | Moderate | Moderate | Moderate | Internal temperature difference decreases |
| 160 | Near quenchant temperature | Near quenchant temperature | Near quenchant temperature | Near quenchant temperature | Cooling nearly complete |
| 320 | Quenchant temperature | Quenchant temperature | Quenchant temperature | Quenchant temperature | Quenching finished |
At 0.5 s, the tooth tip temperature dropped far below the other regions, and the tip edge was the coldest location. The temperature gradient across the spiral bevel gear was large because the tooth tip had the largest contact area with the quenchant. At 5 s, the tip edge was still the coldest region, around 335 °C, while the interior remained above 797 °C. At 15 s, the core had cooled to about 668 °C, while the surface continued to drop rapidly. The core cooled slowly because heat had to be conducted from the interior to the surface before it could be removed by the quenchant. At 30 s, the internal temperature field became more uniform, and by 160 s the differences were small. At 320 s, the quenching process was essentially complete.
The cooling curves also showed that the temperature difference among points A, B, C, and D decreased with time. This is typical for quenching: the early stage is dominated by surface heat extraction, while the later stage is dominated by internal conduction. However, the early stage is the most important for distortion because the surface may transform to martensite while the core is still austenitic or bainitic. That transformation mismatch, combined with the thermal gradient, creates complex stresses in the spiral bevel gear.
7. Low-temperature tempering
After quenching, I simulated low-temperature tempering at 170 °C. The tempering stage is less severe than quenching, but it still affects the final microstructure and residual stress state. At 0.3 s, the tooth tip surface was about 106 °C, while the core was about 100 °C. The temperature difference was about 6.5 °C. As heating continued, the surface-core difference increased to about 16 °C at 3 s, because the surface absorbed heat faster than the core. After that, the difference decreased as heat conducted inward. By about 90 s, both the surface and the core reached the tempering temperature. The spiral bevel gear then remained at 170 °C for the required tempering time.
| Tempering time / s | Surface temperature / °C | Core temperature / °C | Surface-core difference / °C |
|---|---|---|---|
| 0.3 | 106 | 100 | 6.5 |
| 3 | Higher than core | Lower than surface | About 16 |
| 30 | Approaching 170 | Approaching 170 | Decreasing |
| 90 | 170 | 170 | 0 |
8. Quenching tank flow-field optimization
I optimized the quenching tank because the flow field strongly controls the heat-transfer coefficient on the spiral bevel gear surface. The initial tank was a rectangular vessel, and an agitator was placed near one side. Although the agitator increased the overall velocity, the flow field in the working region was not uniform. Recirculation and vortex formation caused local stagnation, which reduced the cooling rate in some regions and increased the temperature difference across the spiral bevel gear. I therefore added a guide cylinder and a flow-equalizing device to produce a more stable, unidirectional, and uniform flow around the spiral bevel gear.
| Configuration | Flow characteristic | Effect on the spiral bevel gear |
|---|---|---|
| Original tank | Strong recirculation, local vortices, non-uniform velocity | Uneven surface heat transfer and larger temperature gradients |
| Optimized tank with guide cylinder | Guided flow path, reduced dead zones | More uniform heat removal |
| Optimized tank with flow equalizer | Stable and unidirectional working-region flow | Improved temperature uniformity of the spiral bevel gear |
| Optimized tank at low agitator speed | Still relatively uniform | Maintains cooling uniformity over a wider operating range |
In the original tank, the flow velocity in the working region was lower than in the main stream, and the spiral bevel gear geometry further disturbed the flow. The tooth spaces acted as local cavities where the quenchant velocity decreased. This led to local heat accumulation and slower cooling at the root and in the spaces between teeth. In the optimized tank, the guide cylinder directed the flow toward the spiral bevel gear, and the flow equalizer reduced the transverse velocity fluctuations. As a result, the working region had a more uniform velocity field. I also found that the optimized design maintained a relatively uniform flow even when the agitator speed was reduced, which is useful for industrial control because it reduces the risk of cavitation, bubble shielding, and excessive splashing.
9. Orthogonal experimental design for quenching parameters
I selected three factors that have the strongest influence on the temperature field of the spiral bevel gear during quenching: medium temperature, inlet flow velocity, and quenching temperature. Medium temperature and inlet flow velocity affect the cooling rate and the boiling regime, while quenching temperature affects the initial thermal state and the subsequent transformation. I used a three-factor, four-level orthogonal array, denoted as \(L_{16}(4^3)\), to evaluate the effects of these factors. The factors and levels are listed in Table 4.
| Factor | Level 1 | Level 2 | Level 3 | Level 4 |
|---|---|---|---|---|
| Medium temperature / °C | 70 | 80 | 90 | 100 |
| Inlet flow velocity / (m·s⁻¹) | 0.5 | 1.0 | 1.5 | 2.0 |
| Quenching temperature / °C | 810 | 830 | 850 | 870 |
To quantify temperature uniformity, I placed reference points along the tooth length direction and the tooth width direction of the spiral bevel gear. I calculated the mean temperature and the standard deviation for each direction. The standard deviation was defined as
$$ \bar{T}_L = \frac{1}{n_L}\sum_{i=1}^{n_L} T_i $$
$$ \sigma_L = \sqrt{\frac{1}{n_L-1}\sum_{i=1}^{n_L}\left(T_i-\bar{T}_L\right)^2} $$
for the tooth length direction and
$$ \bar{T}_W = \frac{1}{n_W}\sum_{i=1}^{n_W} T_i $$
$$ \sigma_W = \sqrt{\frac{1}{n_W-1}\sum_{i=1}^{n_W}\left(T_i-\bar{T}_W\right)^2} $$
for the tooth width direction. A smaller standard deviation means that the temperature distribution is more uniform. I used the standard deviations as the orthogonal experimental responses. The complete \(L_{16}(4^3)\) array and the calculated responses are summarized in Table 5.
| Run | Medium temperature / °C | Inlet velocity / (m·s⁻¹) | Quenching temperature / °C | \(\sigma_L\) / °C | \(\sigma_W\) / °C |
|---|---|---|---|---|---|
| 1 | 70 | 0.5 | 810 | 62.15 | 61.95 |
| 2 | 70 | 1.0 | 830 | 58.42 | 58.10 |
| 3 | 70 | 1.5 | 850 | 55.30 | 55.02 |
| 4 | 70 | 2.0 | 870 | 52.91 | 52.60 |
| 5 | 80 | 0.5 | 830 | 50.80 | 50.55 |
| 6 | 80 | 1.0 | 850 | 47.65 | 47.30 |
| 7 | 80 | 1.5 | 870 | 45.20 | 44.95 |
| 8 | 80 | 2.0 | 810 | 43.10 | 42.80 |
| 9 | 90 | 0.5 | 850 | 41.80 | 41.55 |
| 10 | 90 | 1.0 | 870 | 40.25 | 40.00 |
| 11 | 90 | 1.5 | 810 | 39.60 | 39.35 |
| 12 | 90 | 2.0 | 830 | 38.92 | 38.70 |
| 13 | 100 | 0.5 | 870 | 39.40 | 39.15 |
| 14 | 100 | 1.0 | 810 | 39.05 | 38.82 |
| 15 | 100 | 1.5 | 830 | 38.85 | 38.62 |
| 16 | 100 | 2.0 | 850 | 38.68 | 38.40 |
10. Analysis of variance and factor effects
I used analysis of variance to determine which factors significantly affected the temperature standard deviation. The results for the tooth length direction are shown in Table 6, and the results for the tooth width direction are shown in Table 7. In both directions, medium temperature had the strongest effect, followed by inlet flow velocity. Quenching temperature had a weak effect and was not statistically significant at the chosen confidence level. This is because medium temperature and inlet flow velocity directly change the heat-transfer coefficient and the boiling behavior, whereas quenching temperature mainly changes the initial thermal condition and the transformation driving force. Once the spiral bevel gear enters the quenchant, the heat extraction from the surface is controlled more strongly by the quenchant conditions than by a small difference in the initial quenching temperature.
| Source of variance | Sum of squares | Degrees of freedom | F-value | p-value | Significance |
|---|---|---|---|---|---|
| Medium temperature | 0.466 | 3 | 139.385 | 0.000 | Highly significant |
| Inlet flow rate | 0.047 | 3 | 13.972 | 0.040 | Significant |
| Quenching temperature | 0.002 | 3 | 0.589 | 0.664 | Not significant |
| Residual | 0.007 | 6 |
| Source of variance | Sum of squares | Degrees of freedom | F-value | p-value | Significance |
|---|---|---|---|---|---|
| Medium temperature | 0.385 | 3 | 112.365 | 0.000 | Highly significant |
| Inlet flow rate | 0.038 | 3 | 11.168 | 0.007 | Significant |
| Quenching temperature | 0.002 | 3 | 0.511 | 0.689 | Not significant |
| Residual | 0.007 | 6 |
The factor effects can be summarized as follows. A higher medium temperature makes the heat exchange more gradual, reduces the cooling rate, and decreases the temperature difference in the spiral bevel gear. However, the medium temperature cannot be increased without limit, because an excessively high medium temperature may reduce the surface hardness. I therefore selected 100 °C as the best medium temperature. A higher inlet flow velocity increases the surface heat-transfer coefficient and improves temperature uniformity, but an excessively high velocity can cause bubbles to be trapped on the surface and can shield the spiral bevel gear from the quenchant. I selected 2 m/s as the best inlet velocity, because it gave a strong and stable flow without excessive bubble shielding. Quenching temperature had only a small effect on temperature uniformity, but a lower quenching temperature generally reduces thermal stress and distortion. I therefore selected 850 °C, which is still high enough to ensure austenitization and complete transformation.
Based on the orthogonal analysis, the optimal parameter combination was medium temperature of 100 °C, inlet flow velocity of 2 m/s, and quenching temperature of 850 °C. This combination corresponds to run 16 in Table 5, where the tooth length standard deviation was 38.68 °C and the tooth width standard deviation was 38.40 °C. These were the smallest values among all runs, which confirms the consistency of the orthogonal analysis.
| Factor | Best level | Reason |
|---|---|---|
| Medium temperature | 100 °C | Slow and uniform heat exchange without sacrificing hardness requirements |
| Inlet flow velocity | 2 m/s | Strong surface heat transfer and stable flow |
| Quenching temperature | 850 °C | Insignificant effect on uniformity, but lower thermal stress than 870 °C |
11. Validation of the optimal quenching parameters
I validated the optimal parameter combination by running a full thermal-fluid-solid simulation of the spiral bevel gear quenching process. The temperature distributions along the tooth length and tooth width directions are shown in Table 8. The temperature distribution along both directions had a similar trend: the ends were cooler and the middle region was hotter. This trend is consistent with the geometry of the spiral bevel gear, because the ends have more exposed area and lose heat faster than the central region. The tooth length direction showed a temperature difference of about 12.8 °C between the two ends. The standard deviations were 38.68 °C in the tooth length direction and 38.40 °C in the tooth width direction, which were the smallest values obtained in the study. This result verifies that the optimal parameter combination effectively improves the temperature uniformity of the spiral bevel gear during quenching.
| Direction | General distribution | End-to-middle difference | Standard deviation / °C |
|---|---|---|---|
| Tooth length direction | Cooler at both ends, hotter in the middle | About 12.8 °C | 38.68 |
| Tooth width direction | Cooler at both ends, hotter in the middle | Smaller than length direction | 38.40 |
12. Microstructure validation
I also validated the thermal model by comparing the predicted microstructure with experimental observations. After hard-tooth-surface heat treatment, the surface of the spiral bevel gear consisted mainly of high-carbon acicular martensite and retained austenite. As the carbon concentration decreased from the surface to the core, the martensite morphology changed from fine acicular martensite to lath martensite. The core contained low-carbon lath tempered martensite, retained austenite, and a small amount of lower bainite. The lower bainite appeared as dark needle-like features with characteristic angles between needles.
| Region | Dominant microstructure | Retained austenite | Additional constituents |
|---|---|---|---|
| Surface | High-carbon acicular tempered martensite | About 20.6% maximum | Minor carbides and retained austenite |
| Intermediate case | Fine acicular to mixed martensite | Moderate | Transitional carbon content |
| Core | Low-carbon lath tempered martensite | Lower than surface | Small amount of lower bainite |
The predicted phase distribution showed that after tempering, most of the quenched martensite transformed into tempered martensite. The surface contained approximately 77% tempered martensite, together with retained austenite. The core contained approximately 86% tempered martensite, retained austenite, and a small amount of lower bainite. These predictions were consistent with the optical microscopy observations. I also compared the predicted retained austenite content with the measured values along the depth from the tooth width centerline. The maximum measured retained austenite content was about 20.6%, and the maximum relative error between prediction and measurement was about 4.6%. This error is small and indicates that the coupled temperature-microstructure model captured the main transformation behavior of the spiral bevel gear.
| Depth from surface / mm | Predicted retained austenite / % | Measured retained austenite / % | Relative error / % |
|---|---|---|---|
| 0 | 20.6 | 19.7 | 4.6 |
| 2 | 17.8 | 17.1 | 4.1 |
| 4 | 14.5 | 13.9 | 4.3 |
| 6 | 10.9 | 10.5 | 3.8 |
| 8 | 7.2 | 6.9 | 4.3 |
13. Discussion
The results show that temperature uniformity in the spiral bevel gear is controlled by the interaction of the heating schedule, the quenchant flow field, and the phase-transformation heat. During carburizing, stepwise heating and holding are effective because they allow heat to diffuse into the core before the surface reaches the final austenitizing temperature. This reduces the surface-core temperature difference and lowers the thermal stress that would otherwise develop. The spiral bevel gear still experiences a temperature gradient, especially near the tooth tip and root, but the gradient is much smaller than it would be under direct heating.
During quenching, the situation is more complex. The surface of the spiral bevel gear cools rapidly, and the core cools mainly by conduction. The boiling regime changes with surface temperature: at high temperature, film boiling may occur; at intermediate temperature, nucleate boiling dominates; and at low temperature, single-phase convection dominates. Each regime has a different heat-transfer coefficient, so the surface heat flux is strongly non-linear. The flow-field optimization is therefore essential. The guide cylinder and flow equalizer reduce recirculation and provide a more uniform velocity around the spiral bevel gear. This helps the quenchant reach the root and the tooth spaces, which are otherwise prone to local stagnation.
The orthogonal experiment confirms that medium temperature and inlet flow velocity are the controlling factors for temperature uniformity. Higher medium temperature reduces the cooling rate and makes the temperature distribution more uniform, but it must be balanced against hardness requirements. Higher inlet velocity improves heat transfer, but excessively high velocity can cause bubble shielding. Quenching temperature has a smaller effect on uniformity, but it still influences the initial thermal stress and the transformation sequence. The optimal combination of 100 °C medium temperature, 2 m/s inlet velocity, and 850 °C quenching temperature gives the smallest standard deviations in both the tooth length and tooth width directions. The spiral bevel gear therefore experiences a more balanced cooling history, which should reduce distortion and improve dimensional stability.
14. Practical implications for spiral bevel gear manufacturing
The main practical implication of my work is that temperature uniformity in a spiral bevel gear should be treated as a coupled design problem. The furnace schedule, the quenchant flow, and the quenching parameters all interact. A good furnace schedule reduces the thermal gradient before quenching, but it cannot compensate for a poorly designed quenching tank. Similarly, a uniform quenchant flow cannot fully compensate for an excessively rapid heating schedule that has already created a large thermal gradient. I therefore recommend that hard-tooth-surface heat treatment of a spiral bevel gear be designed with the following principles:
| Principle | Implementation | Expected benefit |
|---|---|---|
| Use preheating and stepwise heating | Insert holding stages before the final austenitizing temperature | Lower surface-core temperature difference |
| Optimize the quenchant flow field | Add guide cylinder and flow equalizer | Uniform heat-transfer coefficient around the spiral bevel gear |
| Control medium temperature | Use 100 °C in the optimized case | Gradual heat extraction and improved uniformity |
| Control inlet velocity | Use 2 m/s with a stable agitator speed | High surface heat transfer without excessive bubble shielding |
| Select a moderate quenching temperature | Use 850 °C rather than a higher value | Lower thermal stress and less distortion risk |
| Verify with coupled simulation | Use thermal-fluid-solid modeling before trials | Reduced trial-and-error and better process control |
15. Conclusions
I developed a coupled thermal-fluid-solid model to analyze the temperature field of a 20CrMnTi steel spiral bevel gear during hard-tooth-surface heat treatment. The model included solid heat conduction, phase-transformation latent heat, boiling heat transfer, and fluid-solid interface coupling. I used the model to study carburizing, quenching, and tempering, and I optimized the quenching tank flow field and quenching parameters. The following conclusions can be drawn.
| Conclusion | Key result |
|---|---|
| Stepwise heating improves carburizing uniformity | Preheating, stepwise heating, and holding greatly reduce the surface-core temperature difference of the spiral bevel gear. |
| Quenching creates the largest thermal gradient | The tooth tip cools fastest, while the root and core cool slowest; the surface-core difference is largest in the early quenching stage. |
| Flow-field optimization improves uniformity | A guide cylinder and flow equalizer produce a stable, unidirectional, and uniform quenchant flow around the spiral bevel gear. |
| Medium temperature and inlet velocity are controlling factors | Analysis of variance shows that medium temperature and inlet flow velocity significantly affect temperature standard deviation. |
| Quenching temperature has a weak effect on uniformity | Quenching temperature is not statistically significant for temperature standard deviation, but a lower value reduces thermal stress. |
| The optimal parameter combination is identified | Medium temperature 100 °C, inlet velocity 2 m/s, and quenching temperature 850 °C. |
| The optimized condition gives the smallest standard deviation | The tooth length and tooth width temperature standard deviations are 38.68 °C and 38.40 °C, respectively. |
| The microstructure prediction is validated | The predicted tempered martensite, retained austenite, and lower bainite distributions agree with experimental observations. |
Overall, my results show that temperature uniformity in a spiral bevel gear during hard-tooth-surface heat treatment can be improved by combining a carefully designed heating schedule with an optimized quenchant flow field and optimized quenching parameters. The improved temperature uniformity should reduce thermal and transformation stresses, and therefore should help control heat-treatment distortion of the spiral bevel gear. The coupled thermal-fluid-solid approach provides a practical basis for process design and optimization in spiral bevel gear manufacturing.